Week-4 Challenge WOT Condition Part-2
1.What is the difference between mapped and dynamic model of engine, motor and generator? How can you change model type?
ANS: The Mapped Motor block implements a mapped motor and drive electronics operating in torque-control mode.
The output torque tracks the torque reference demand and includes a motor-response and drive-response time constant.
Use the block for fast system-level simulations when you do not know detailed motor parameters, for example, for motor power and torque tradeoff studies.
The block assumes that the speed fluctuations due to mechanical load do not affect the motor torque tracking.
The dynamic model is used to express and model the behaviour of the system over time. It includes support for activity diagrams, state diagrams, sequence diagrams and extensions including
it means that this type of model is used when time dependent simulations are performed and results are required.
for clearly given below
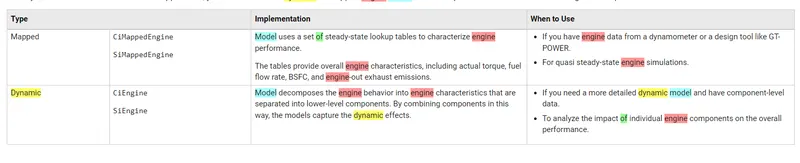
motor:
it convert elctrical energy into machanical energy
motor conssume Elctrical Energy
genarator:
it converts mechanical energy into Electrical Energy
it consumes kinatic Energy or rotational force
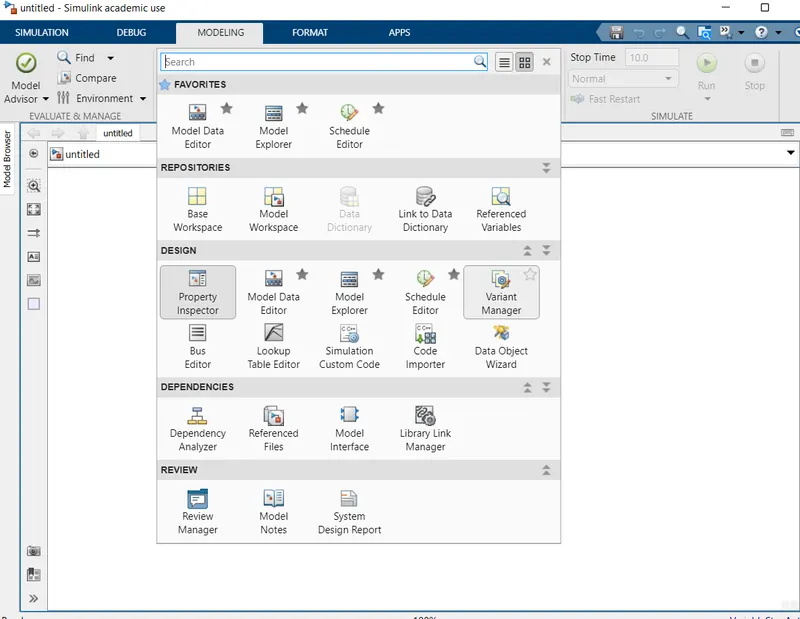
Changing model type: Go modeling and click the variant manager
choose, Variant --> Label mode active choice --> GenDynamic / GenMapped
2.How does the model calculate miles per gallon? Which factors are considered to model fuel flow?
Ans:
for this problem we need to get odometer data, battary power and fuel flow
Get the miles traveled from the trip odometer, Divide the miles traveled by the amount of gallons it took to refill the tank. The result will be your car's average miles per gallon yield for that driving period.
Then it's is converted into US gallon equivalent energy by dividing it by the standard value 33.7. Then converted into US gallons per second
3.Run the HEV ReferenceApplication with WOT drive cycle. Change the grade and wind velocity in the environment block. Comment on the results.
Ans:The simulink window of the HEV reference application and the modified drive cycle source window is show below.
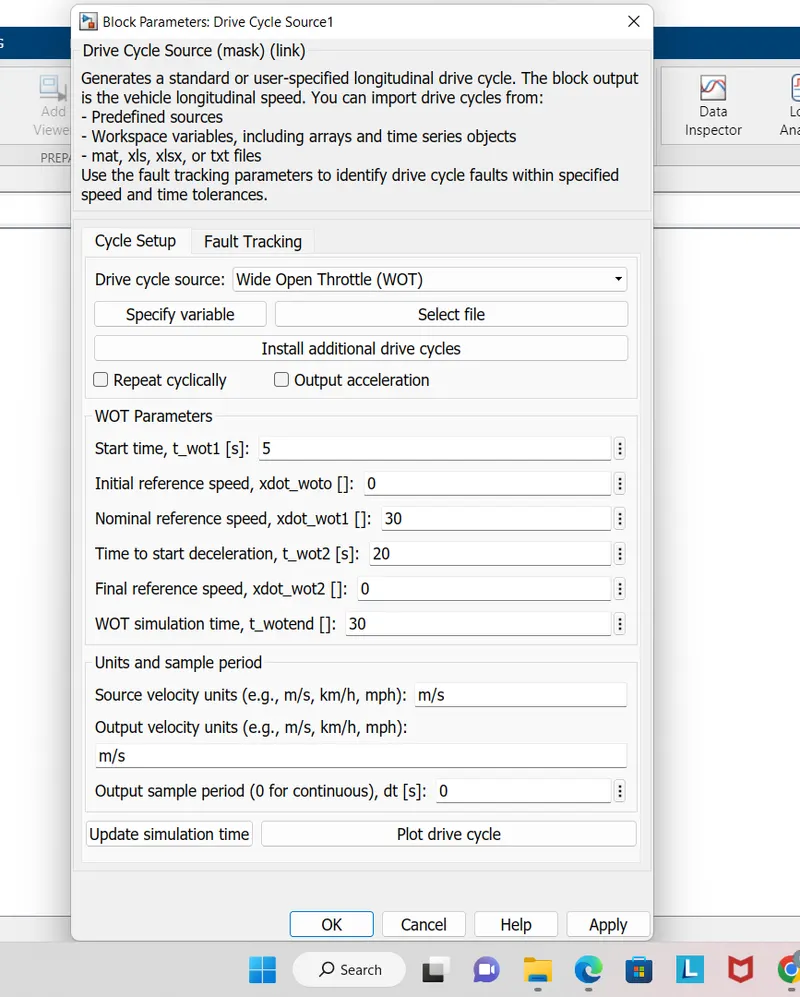
The drive cycle source is modified in such a manner to simulate the vehicle in wide open throttle condition.
Target speed vs Actual speed in mph
The top speed of 112 mph was achieved in 42.3 seconds
The deceleration from 112 mph - 0 mph was achieved in 7.5 seconds
Initially current required to start the motor is high and afetr that it reduces to normal
when the speed of the vehicle increases. The motor is used mainly for the starting torque of the vehicle since, the current requirement of the motor is also high.