Week-4 Challenge WOT Condition Part-2
ANSWER 1: MAPPED models : mapped model are used when the behavior of a particular model is not of our interest and can be modeled with predefined value in the form of lookup tables.
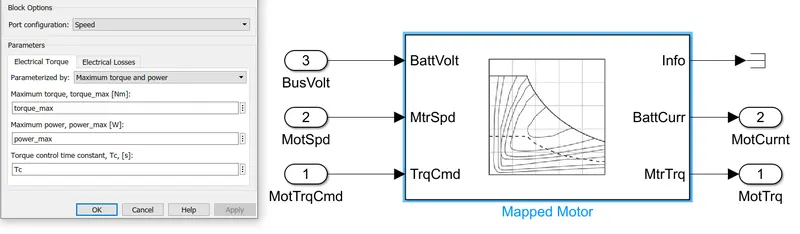
above model values are taken from experiment .
implements a mapped motor and drive eletronics operating in torque control mode . we have to specify electrical torque range with a torque speed envelope or maximum motor
power and torque reference demand and include a motor and drive responce time const. also have to specify electrical losses as a single operation point that estimates loss across the operating range , measured loss or measured efficency.
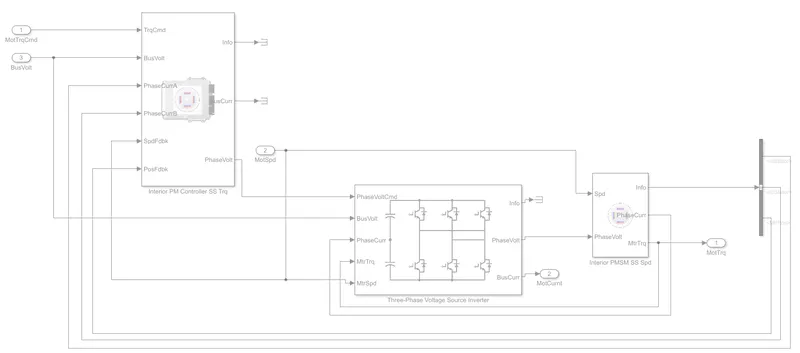
DYNAMIC MODEL: dynamic model are used when the internal resopnse toa model with respect to its components is needed .
eg. motor model:
components such as inverter , phase controller,feedback circuits are also modeled.
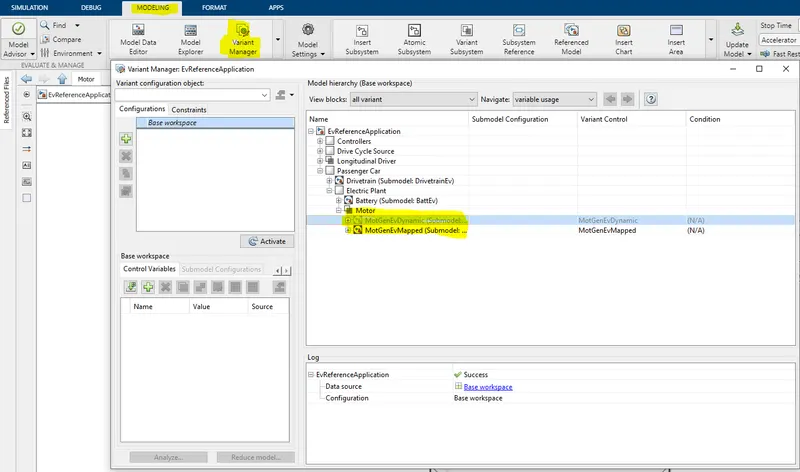
CHANGING the model type in EV powertrain blocks :
we can use the variant manager in the modeling tab to find the variant systems we have.
right-click on the model you want and use set as Label mode active choice.
ANSWER :2 Simulink block to calculate miles per gallon.
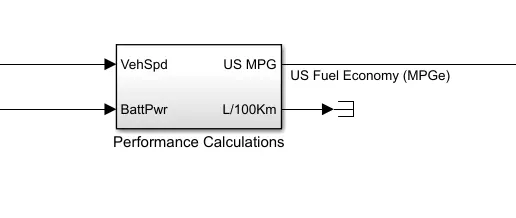
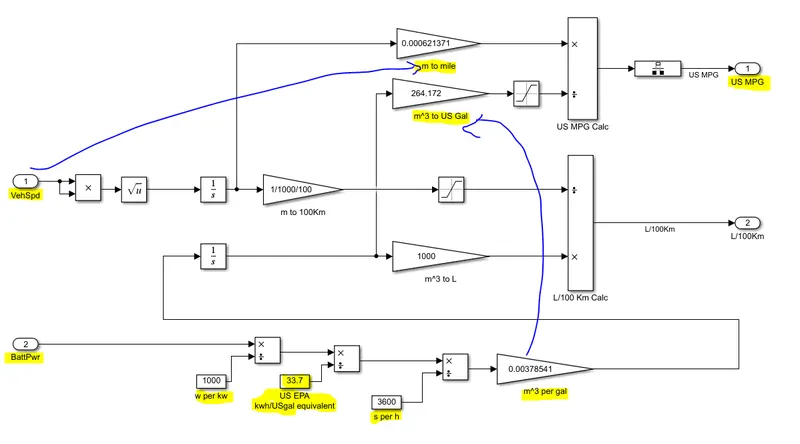
- vehicle speed data is used to calculate the distance traveled in meters which is then converted to miles
- Battery power data is used to find power used in kWh which is then converted to gasoline-equivalent using US EPA value by dividing with 33.7
- note: As per the US environmental protection agency(EPA) 1 gallon of gasoline is equal to 33.7 kWh
- Dividing distance traveled in miles by the number of gallons, we can get miles per gallon
- For HEV this gallon(gasoline-equivalent of battery power) is added with gallon used by IC engine then miles per gallon is calculated.
ANSWER 3:Open the HEV reference application
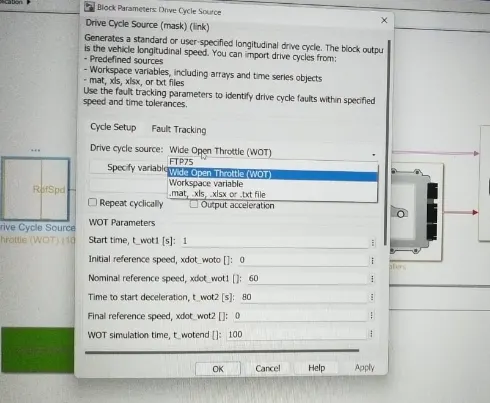
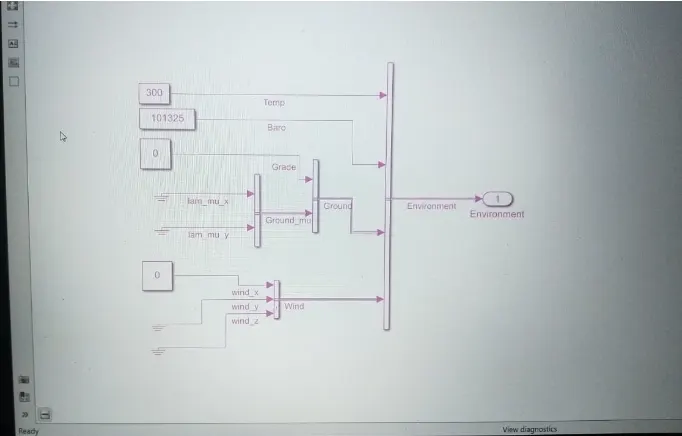
Grade - 0, wind velocity 0m/s
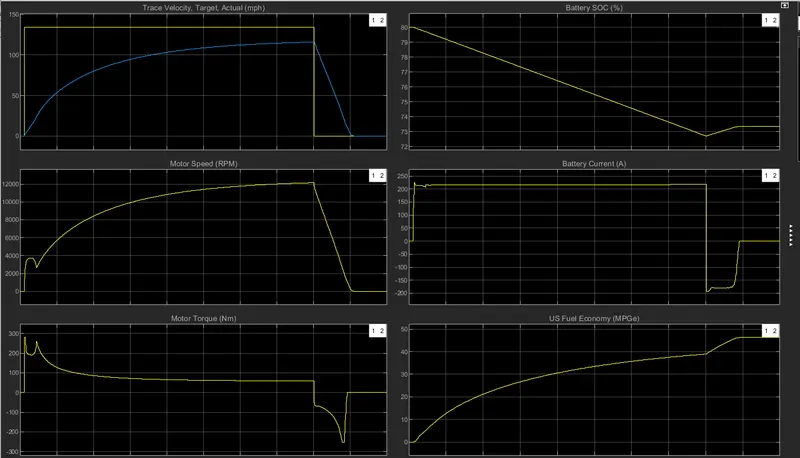
Grade - 15, wind velocity 30m/s
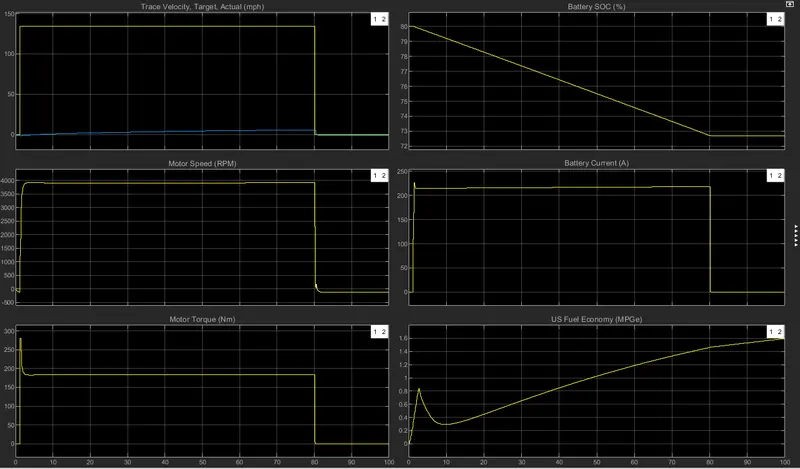
RESULTS: with the increase in grade and wind velocity,
- peak velocity achieved is reduced as gradient force and aerodynamic force becomes dominant.
- fuel economy is also reduced because the distance traveled is reduced due to external forces.
- deceleration time is reduced so batter recharging capacity is also reduced.
ANSWER4:
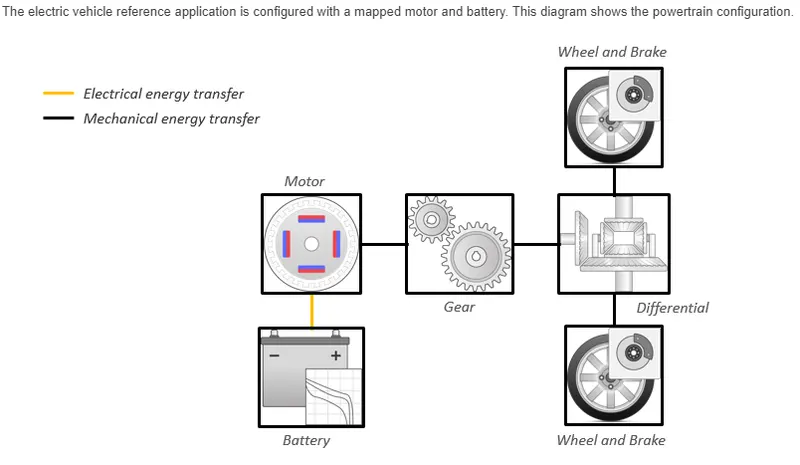
EV model powertrain configuration:
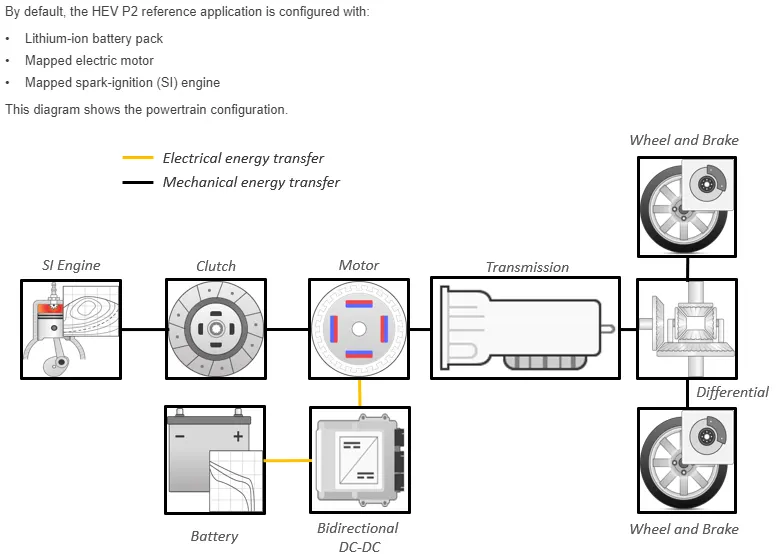
HEV p2 model:
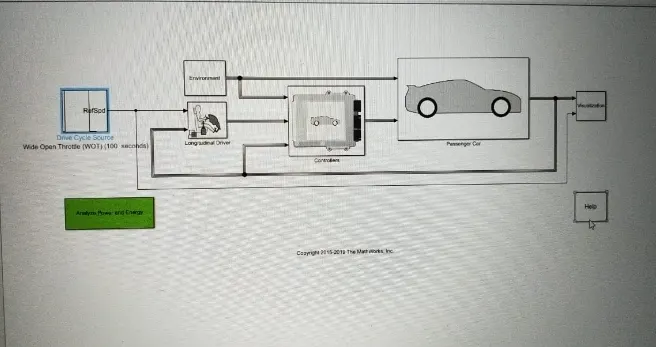
simulink model :
Results:
1.EV model :
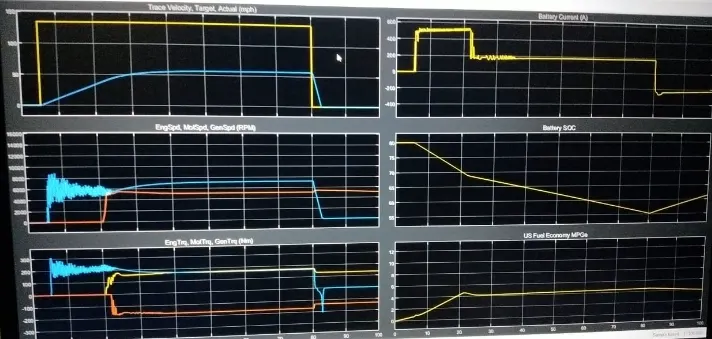
2.HEV P2 Model :
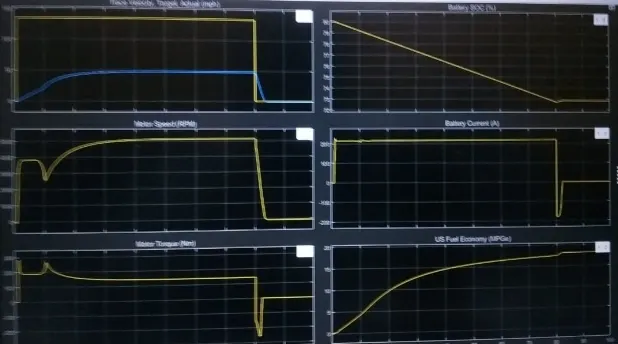
SUMMARY:
- Time taken to achieve the required peak velocity is less for HEV as compared to EV
- Deceleration time is also low for HEV as it has many moving frictional parts
- fuel economy is more for an EV compared to HEV due to less no of moving parts and thus low frictional losses.