Week-4 Challenge WOT Condition Part-2
Que-1):
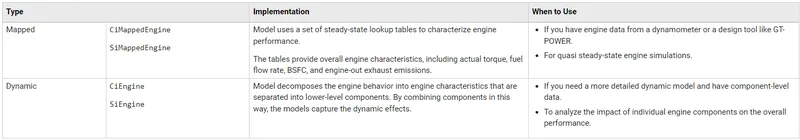
Difference between Mapped and Dynamic model
Maped model:
It is designed by using lookup table. The data of the machine is given to lookup table so that it create the replica of the machine operation.
By using it we can analyse the behaviour of the machine
It is faster in operation
Dynamic model:
It is designed by using the related blocks so that we can careate the replica of the machine operation.By using it we can analyse the behaviour of the machine
It represents the Actual model of the machine
Here are the example of IC engine
How can you change model type?
To change the model type follow the stes given below
Let's change the Generator Mapped model to Dynamic model. Open the HEV simulation file. Find the Motor model.
Step-1: Open the model where Dynamic and Mapped models are present (means subsystem)
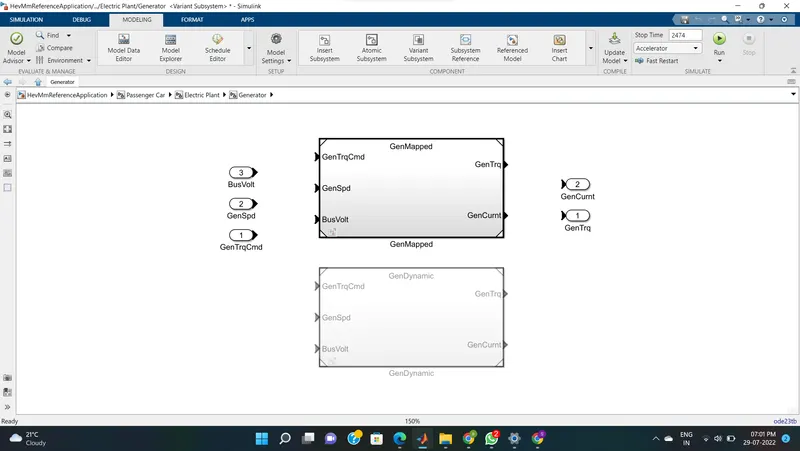
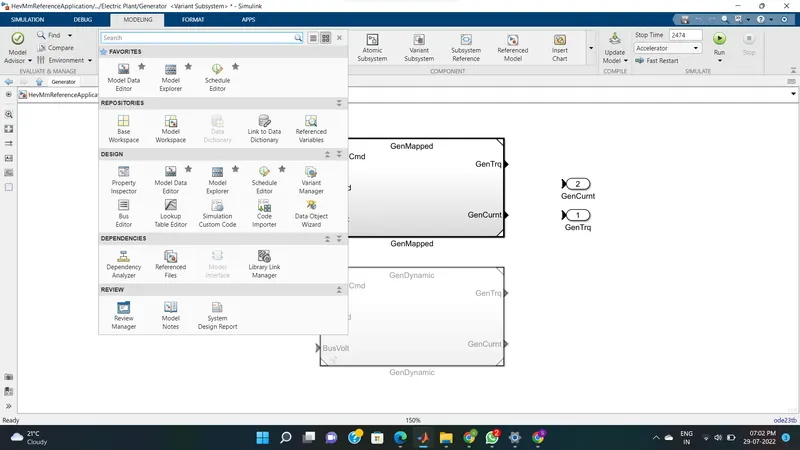
Step-2:Go to Modeling on top left,open it and find the "Varient manager" and open it.
Step-3: The varient manager popup window opens. You can fing the generator in it, under it you can fing the both the Maped and Dynamic models are present.
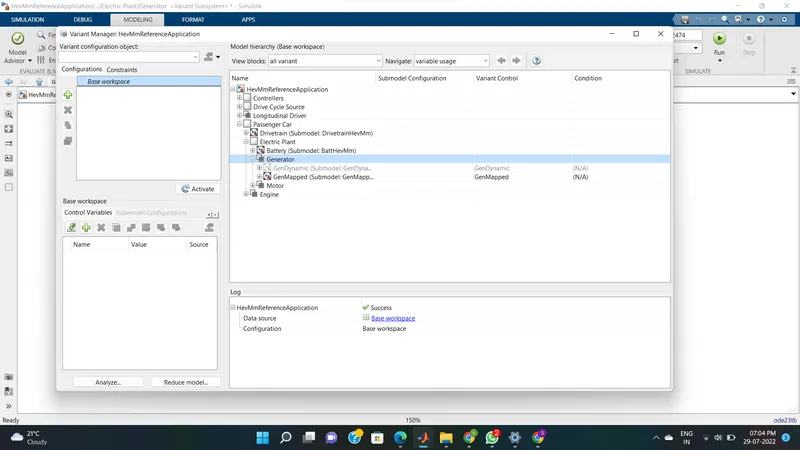
Step-4: Right click on the Gendynamic and select the "Set as Lable Model Active Choice"
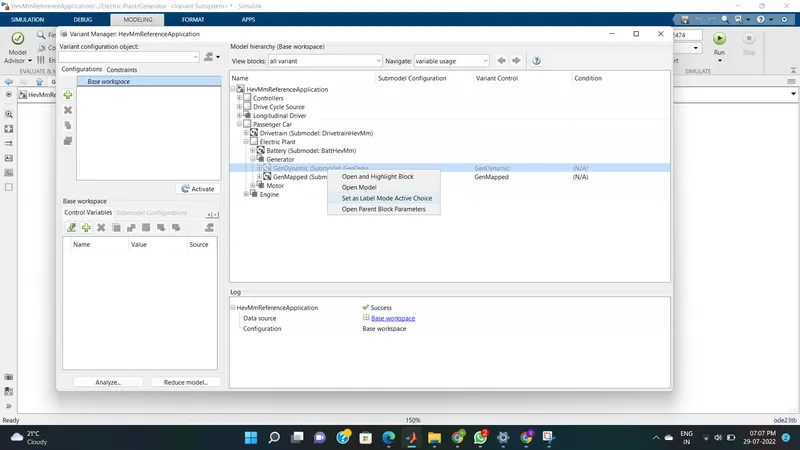
Step-5: You can observe that the maped model is cnaged to dynamic model in simulation
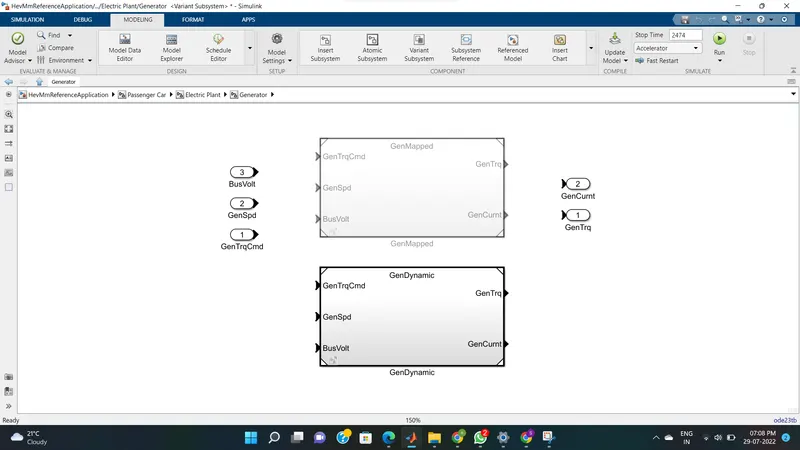
Like this we can shift from one model to another model,the basic steps are same for any system.
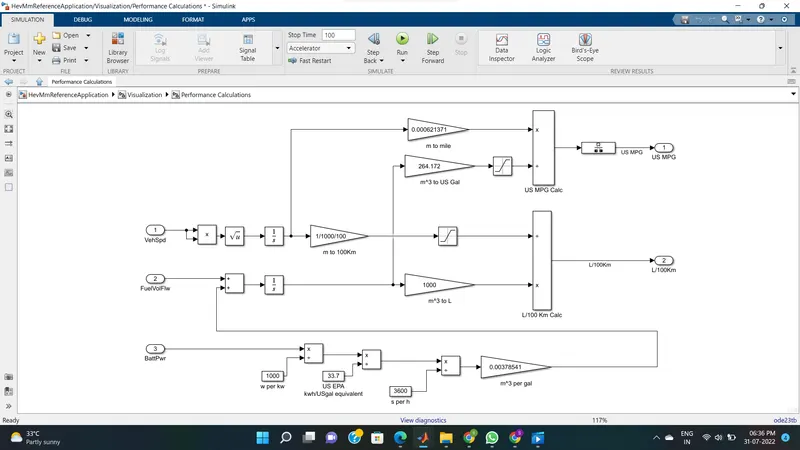
Que-2) How does the model calculate miles per gallon? Which factors are considered to model fuel flow?
The model calulate the miles per gallon by taking the inputs as vehicle speed,Fuel volume flow and Battery power and by doing some mathametical work realted to miles per gallon the miles per gallon(MPG) was calculated.
The factors efficting the fuel flow are
- vehicle speed
- Battery power
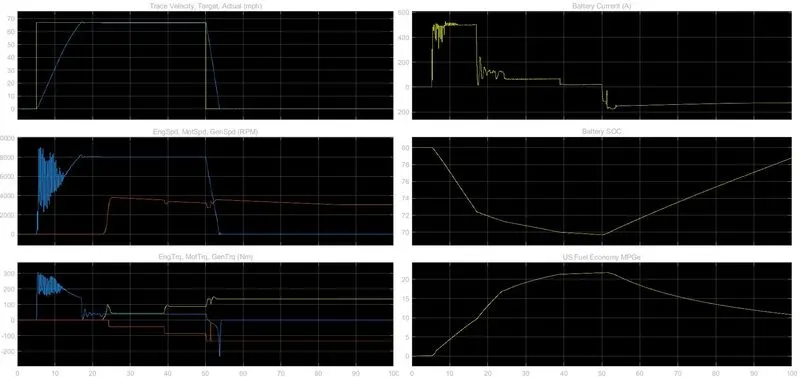
Output graph:
Que-3)
To get the simulation file open the link given below and copy the command past it in the MATLAB command window.It will open simulation file.
https://in.mathworks.com/help/autoblks/ug/hev-multimode-reference-application.html
HEV ReferenceApplication with WOT drive cycle:
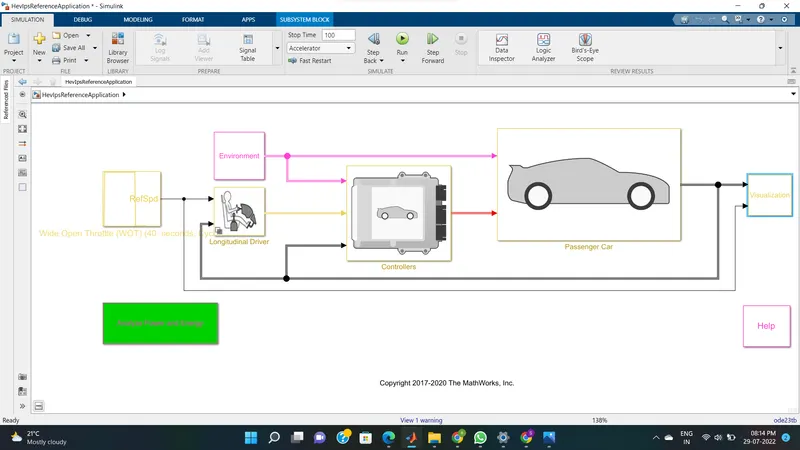
*The results of HEV ReferenceApplication with WOT drive cycle, grade and wind velocity are 0 are shown below
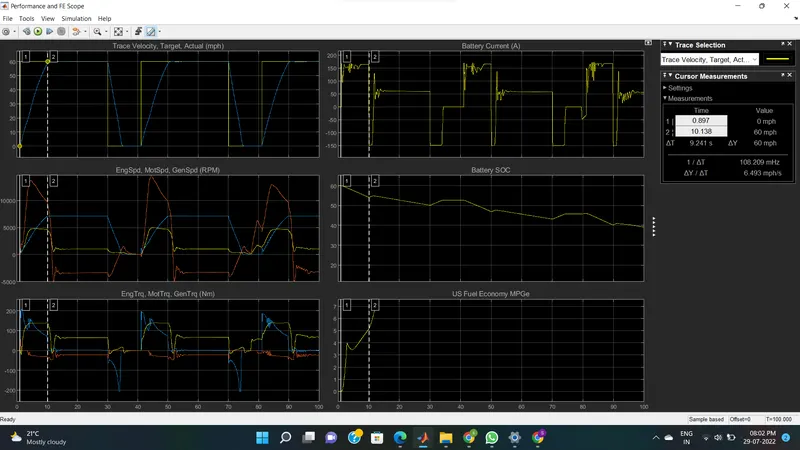
As the Grade and wind velocity are 0, the Hill climbing force is zero and Aeridinamic forces are minimum. So the vehicle reach to max speed in less time i.e., from 0 to 60 mph in 10 sec and staied in constant speed.
*The results of HEV ReferenceApplication with WOT drive cycle, grade and wind velocity are changed are shown below
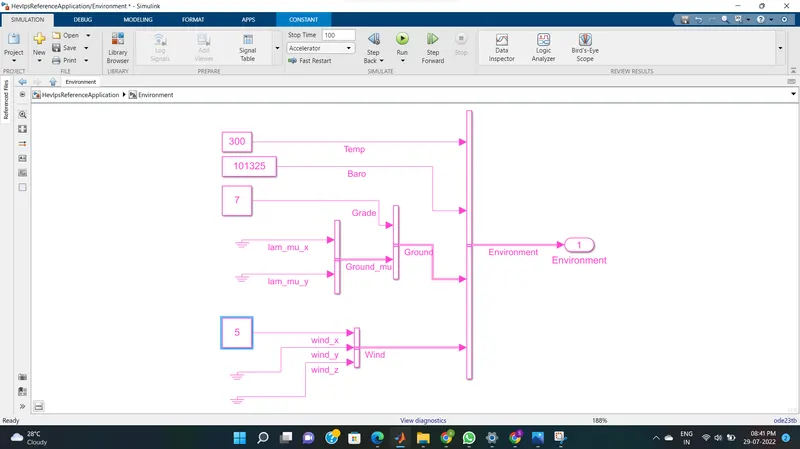
Grade = 7 and Vind velocity = 5
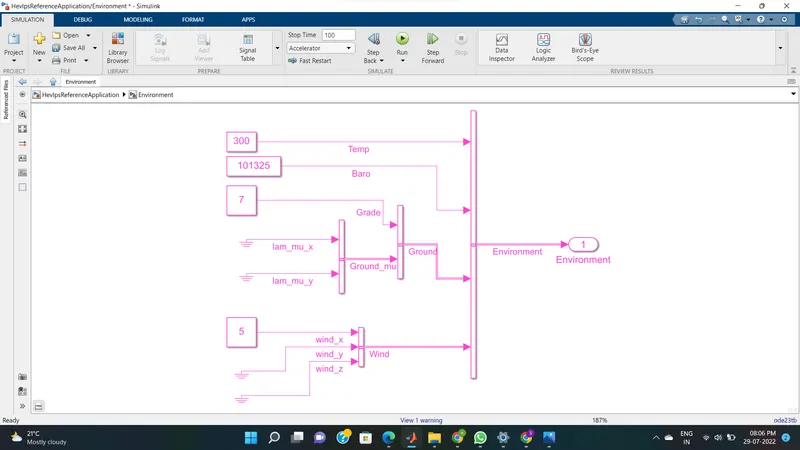
The results are
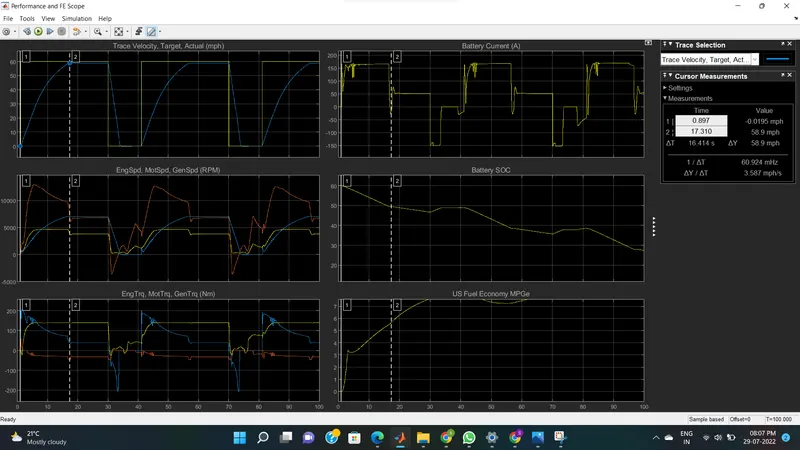
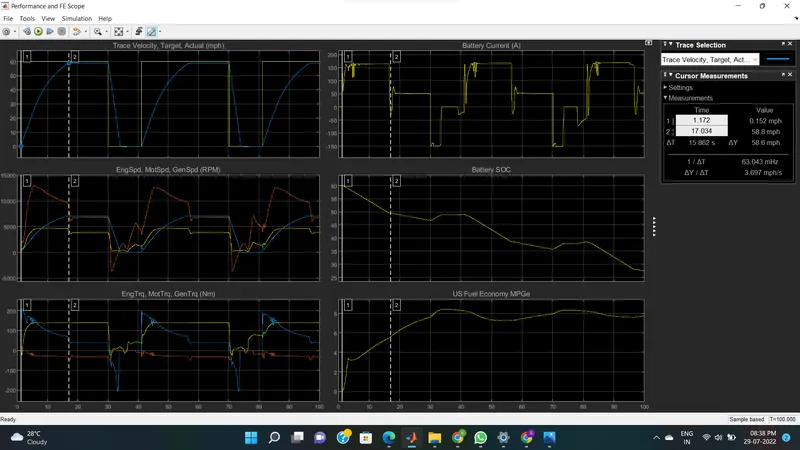
As the Grade and wind velocity are chaged, the Hill climbing force and Aeridinamic forces are increased and the Total tractive force is increased . So the vehicle need more time to reach its max speed as Hill climbing force and Aeridinamic forces are increased. To reach max speed i.e., from 0 to 58.9 mph it takes 16 sec and staied in constant speed.
Conclusion:
As the Grade and wind velocity increases the vehicle takes more time to reach max speed because to over come the Hill climbing force and Aeridinamic forces.
Que-4):
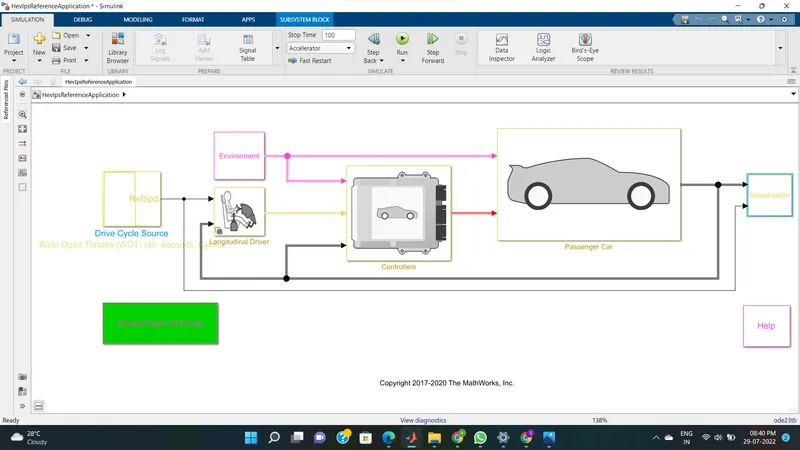
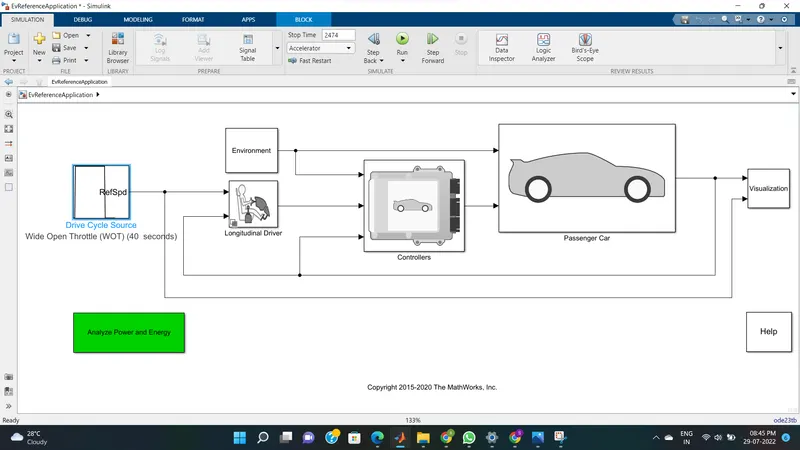
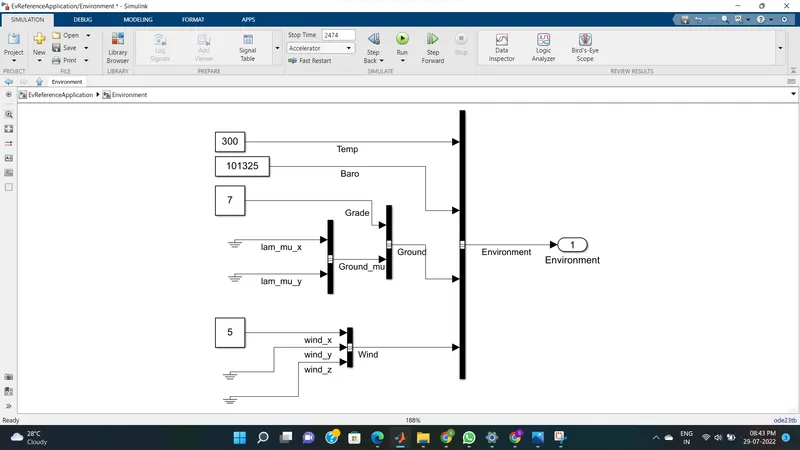
Both the EHV and EV models are simulated with Grade and Wind wind velocity are changed to grade = 7 and velocity = 5
HEV:
To get the simulation file open the link given below and copy the command past it in the MATLAB command window.It will open simulation file.
https://in.mathworks.com/help/autoblks/ug/hev-multimode-reference-application.html
Simulation
Output results:
EV:
To get the simulation file open the link given below and copy the command past it in the MATLAB command window.It will open simulation file.
https://in.mathworks.com/help/autoblks/ug/electric-vehicle-reference-application.html
Output results:
Observation:
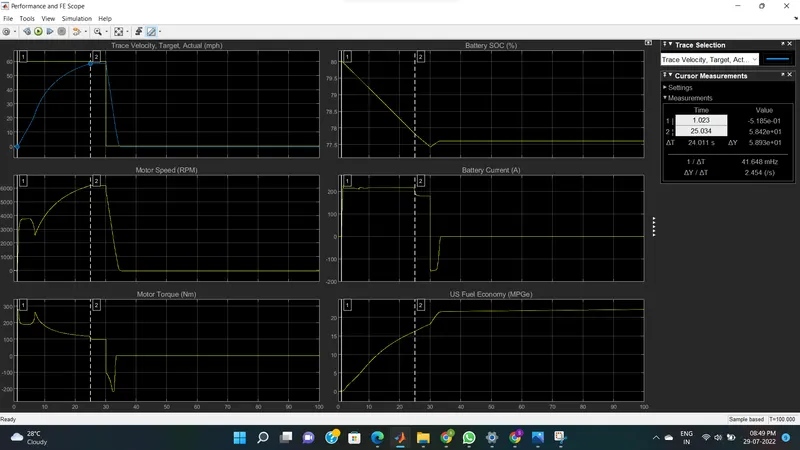
Both the results are shown above.
In HEV to reach the max speed 0 to 58.6 mph it takes 15.8 sec
In EV to reach the max speed 0 to 58.6 mph it takes 24 sec
Results:
Compared to EV, HEV takes less time to reach max speed. This is because in HEV both IC and Motor will share the power to run, so max power is used to reach the max speed. Hence it takes less time to reach max speed. Where as in EV only Motor is used, so the power transfer takes more time. Hence it takes moretime to reach max speed