Week-4 Challenge WOT Condition Part-2
AIM:
- What is the difference between mapped and dynamic model of engine, motor and generator? How can you change model type?
- How does the model calculate miles per gallon? Which factors are considered to model fuel flow?
- Run the HEV ReferenceApplication with WOT drive cycle. Change the grade and wind velocity in the environment block. Comment on the results.
- Keeping all other parameters same, compare the simulated results of hybrid and pure electric powertrains.
- What is the difference between mapped and dynamic model of engine, motor and generator? How can you change model type?
|
Difference between mapped and dynamic models |
|
|
MAPPED |
DYNAMIC |
|
In mapped models, the data used for the operation and simulation are to be entered in a form of lookup table which would be then configured with the operational parts and the analysis would be formed. |
In dynamic models, it understands the behaviour of the element and behaves accordingly. It gives detailed analysis for the variations entered in the specifications whereas it simulates according to real and dynamic operations |
|
If the detailed lookup table data is available with us the simulation becomes easier and it gives the result on the basis of data interpreted. It is also known as Global based model. |
It operates dynamically depending on the situation of operation. Detailed data and specifications are not required and the simulation gives the detailed analysis of the components simulated. |
|
More data has to be inserted and assumptions need to be implemented. |
Could not simulate as per our customised specifications. |
|
ENGINE |
Engine performance could be simulated with the array of data interpreted in the system. Whereas all the other conditions such as Engine Operations, Power, efficiency could be measured accordingly. |
Engine performance could be simulated as per the real engine specifications of the specified vehicle. All results would be obtained with real time details. |
|
MOTOR |
Motor specifications such as rpm, maximum efficiency, heat and such specifications are to be entered for simulating the results. |
The actual details of the same would be considered and the result is obtained. |
|
GENERATOR |
Specifications for Battery torque, Battery current, Motor torque and other parameters are to be entered for simulation. |
All the details and specifications would be considered as per the actual and dynamic state. The result of the same would be obtained same. |
To change the model from mapped to dynamic:
Go to modelling and then click Variant Manager.
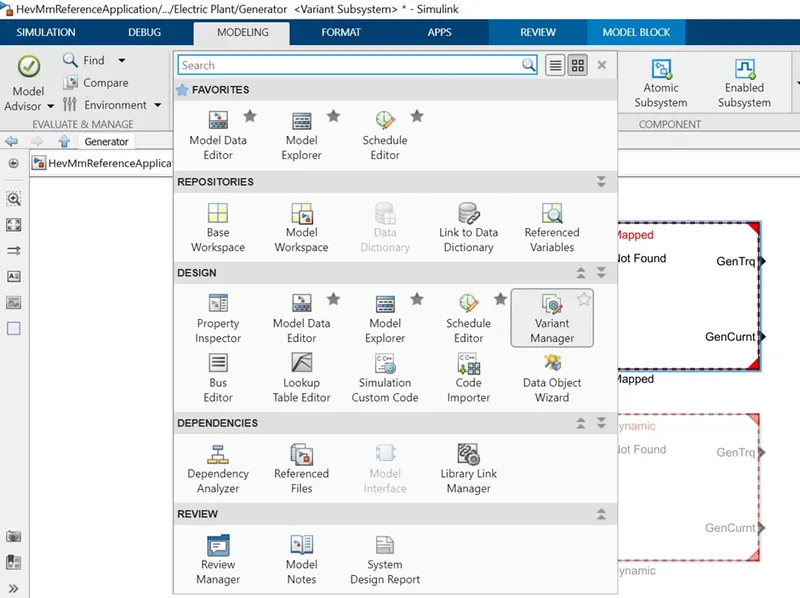
Suppose we plan to change the generator block from Mapped to Dynamic. Select GenDynamic and then right click. Select ‘Set as label Mode Active Choice’. The selected model gets activated. The same process can be repeated for motor and generator.
2) How does the model calculate miles per gallon? Which factors are considered to model fuel flow?
Miles per gallon (MPG) is a fuel economy rating determined by how far a vehicle can travel on a gallon of gasoline or diesel for a conventional IC engine vehicle. In the case of an electric vehicle, this is a measure how much electrical energy is consumed by the battery pack travel a particular distance.
It has found that 1 gallon of gas has the same amount of energy as 33.7kwh of electricity.
For example: A battery propels the vehicle for 3.125 miles per kwh capacity of battery. So,
3.125 miles/kwh * 33.7kwh/gallon = 105MPGe
In this model it is calculated by this block.
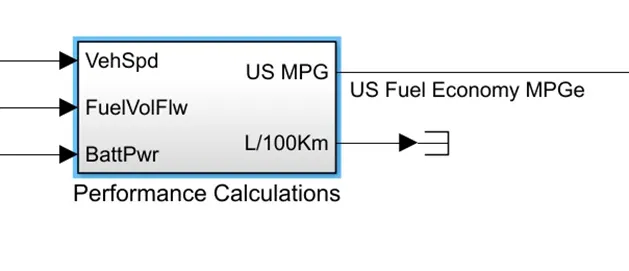
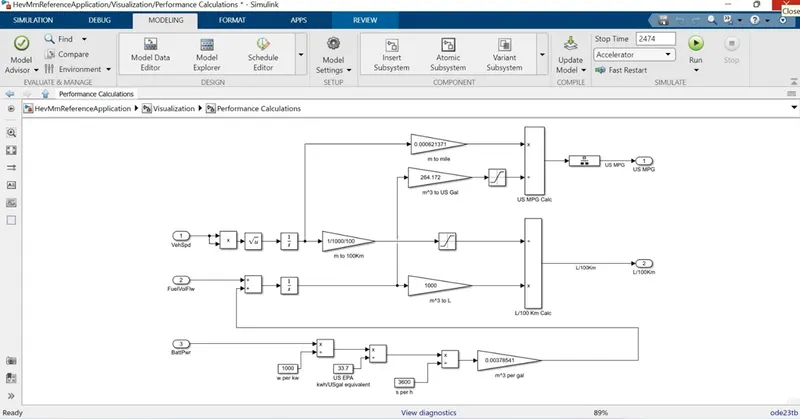
The inputs are VEHICLE SPEED, FUEL VOLUME FLOW AND BATTERY POWER.
3) Run the HEV Reference Application with WOT drive cycle. Change the grade and wind velocity in the environment block. Comment on the results.
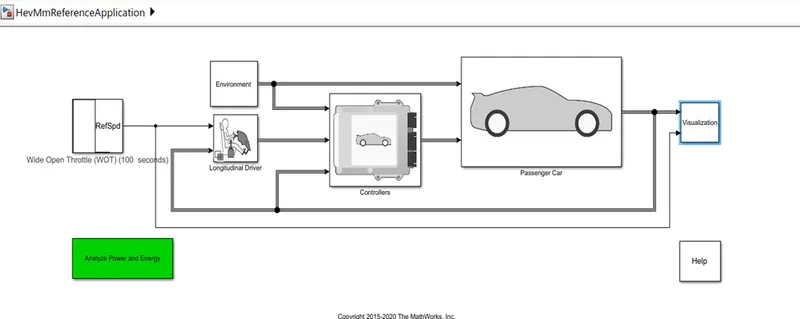
HEV ReferenceApplication with WOT drive cycle:
Use the command ‘autoblkEvStart’ int the command window to open the Simulink model.
Click on the drive cycle and change it to WOT as shown in the below image. Configure the parameters like time duration, WOT start time, initial speed, final speed, maximum speed and time to start deceleration.
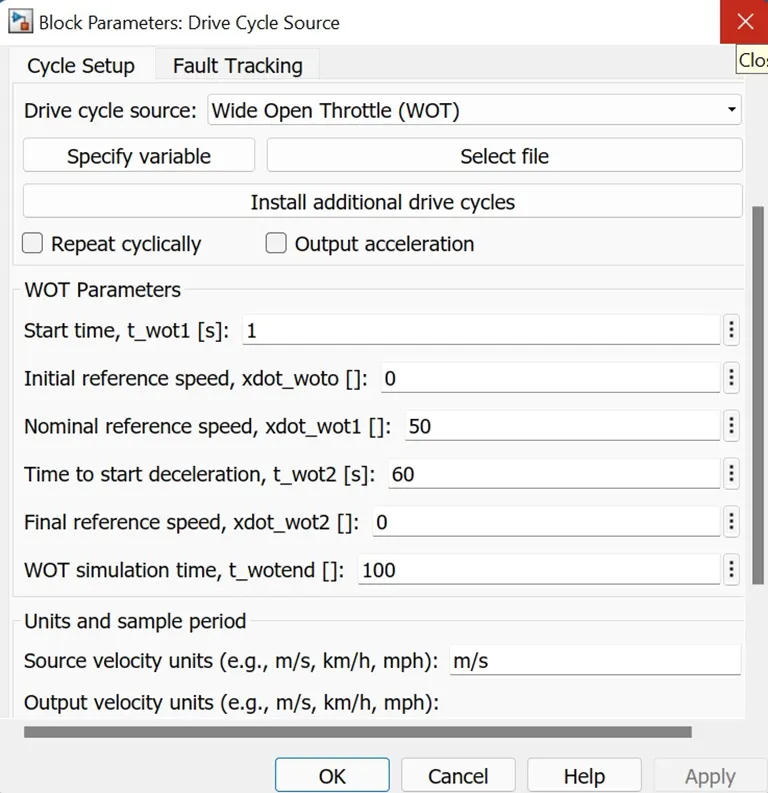
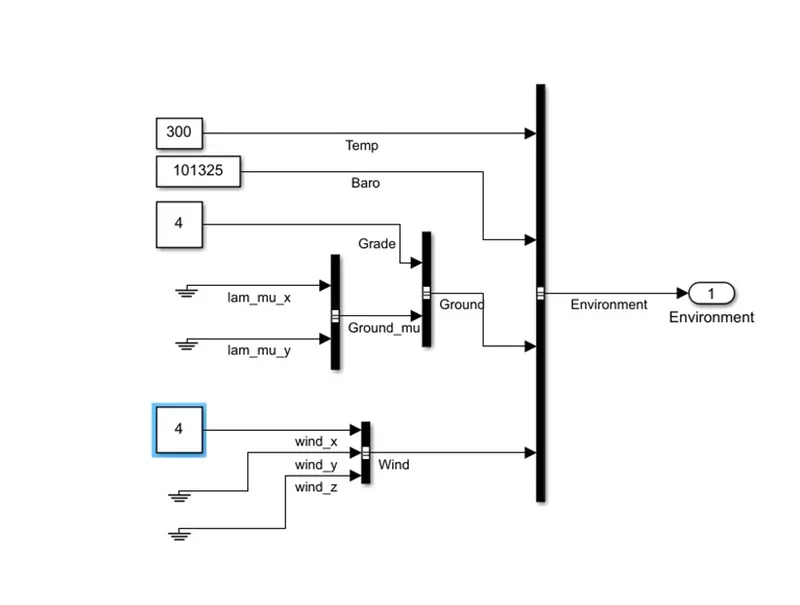
Change the Wind speed and grade from the environment block.
COMPLETE BLOCK DIAGRAM OF HEV REFERENCE APPLICATION
The following graphs are obtained for WOT model analysis.
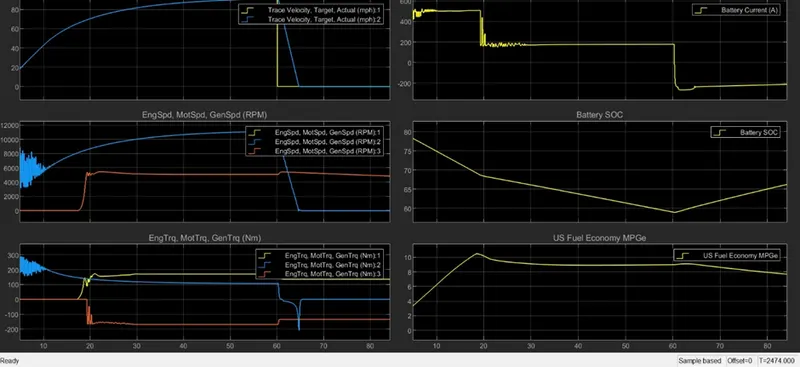
We can see that,Trace velocity target and actual graph: The yellow line indicates the desired path and blue line in the actual path, So, it can be seen that battery power is not enough to meet the requirements of grade and wind velocity.Battery current graph: When the vehicle is accelerating the battery current is also increasing. When the velocity is constant, the current requirement also becomes constant. When the deceleration starts, the battery current becomes negative indicating regenerative breaking.Battery SOC: The battery SOC keeps on depleting until regenerative breaking starts.Engine, Motor and Generator speed: Initially only motor is used to start the vehicle as motor has high initial torque. Later generator kicks in (red graph) charging the battery when SOC drops below 70%. Engine, Motor and Generator torque:Motor torque is high initially (blue line) and then engine kicks in at a later stage (yellow line). Generator torque (red line) is negative as it is charging the battery.
4) Keeping all other parameters same, compare the simulated results of hybrid and pure electric powertrains.
Now simulating the EV with WOT drive cycle with wind velocity equals 4m/s, grade 5 degree.Keeping all the parameters same as that of HEV case, we get the following performance graphs.
ENVIRONMENT BLOCK:
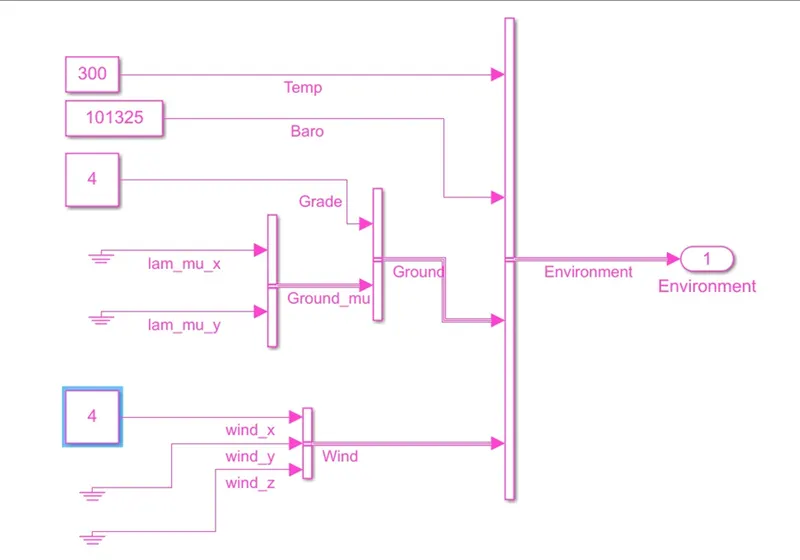
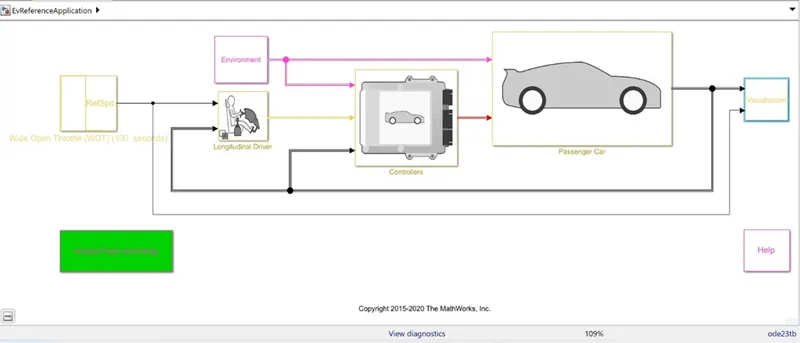
COMPLETE BLOCK DIAGRAM OF EV REFERENCE APPLICATION
OUTPUT PLOT:
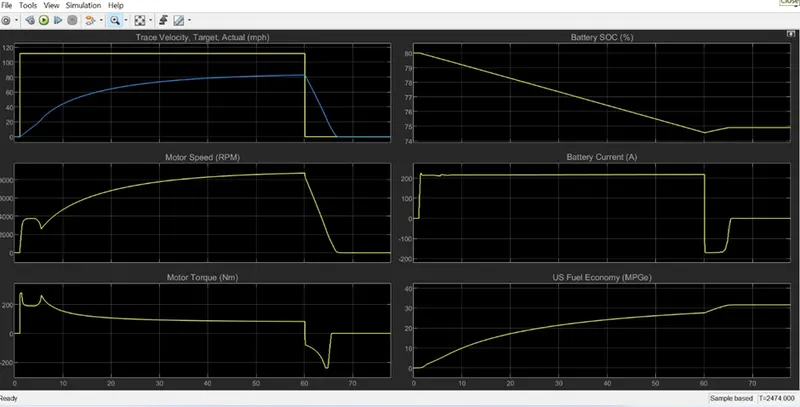
After comparing the graphs of both EV and HEV following conclusions can be drawn:
· The first graph (target and actual velocity graph) performance is almost same because of only motor was operating in that region in both EV and HEV case.
· The battery current draws by HEV initially is upto 500A and later decreases to 200A. This can be attributed to the fact that initially motor takes all the load and then later engine kicks in so motor load drops, thus current drawn by motor reduces. And during deceleration, it can be seen that negative current flows for a longer period of time in HEV case as compared to EV. Hence we can say that regenerative breaking is aggressive in HEV case.
· SOC improvement of almost 15% is seen in HEV during deceleration and only 2% improvement can be seen in EV during deceleration. This can be understood by the same reason in point2.
· Motor torque and motor speed are stable in EV and they keep fluctuating a lot in HEV case during starting. Also the peak RPM of the motor inEV is less than HEV. These differences can be said that battery power of EV is more than HEV.
· Fuel economy of EV is significantly greater than HEV. This is because electric motor is more efficient than engine.
RESULT AND CONCLUSIONS:
All the problems have been solved and the corresponding results are satisfactory.