Week-4 Challenge WOT Condition Part-2
1. Objective
What is the difference between mapped and dynamic model of engine, motor and generator? How can you change model type?
Introduction
Power train blockset consist of library of aotomtive component and pre assembled engine dynamometer . It is used to design the complete vehicle model which is used for simulation and real time testing. Powertrain blockset provide a standard model architecture which can be reused throughtout the process. It can be used for design tradeoff analysis, component sizing, control parameter optimization and harware in loop testing.
Mapped Model- Mapped model is a model where data are pre assigned in form of lookup tables. the output values are stored for the correspong input values of motor and generator. the accuracy of this type of model is not good but the simulation time is less as it does not deal with real time parameter. Mapped engine model are suitable for design analysis that do not require engine subsystem dynamic characteristics.
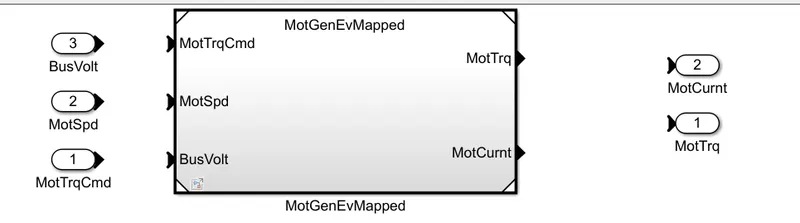
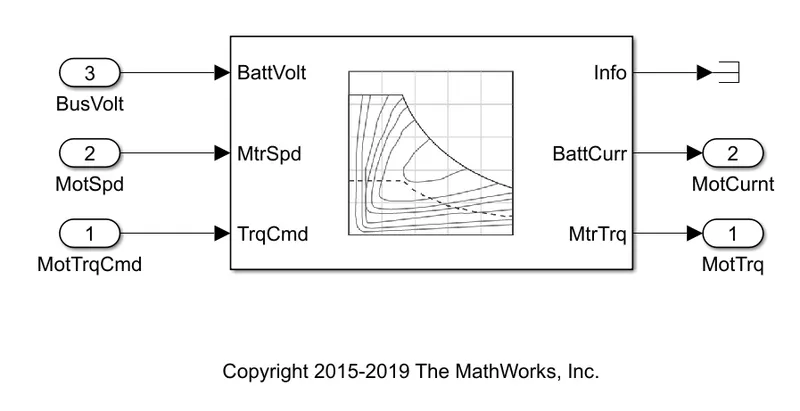
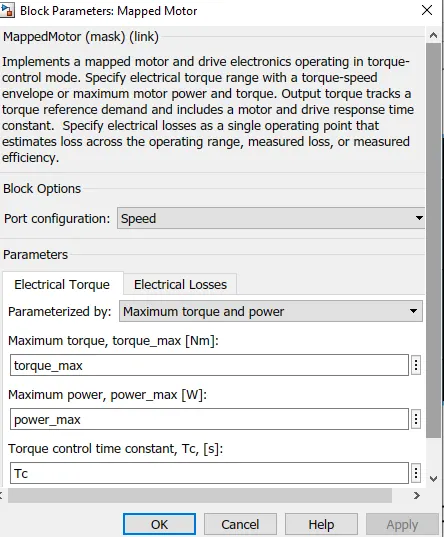
Dynamic Model
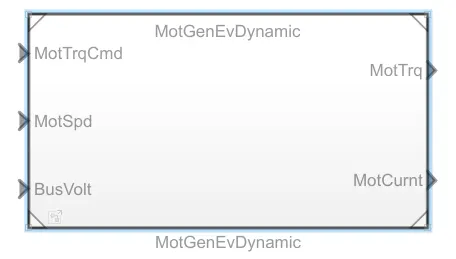
In the dynamic model , it understand the behaviour of the block and results accordingly. it gives the detailed analysis of the variation entered by the user in the specification block. it simulates according to the real dynamic opeartions. It is also called real time based model. In the below we have dynamic motor system which uses permanent magnet controller and inverter for regenerative braking.
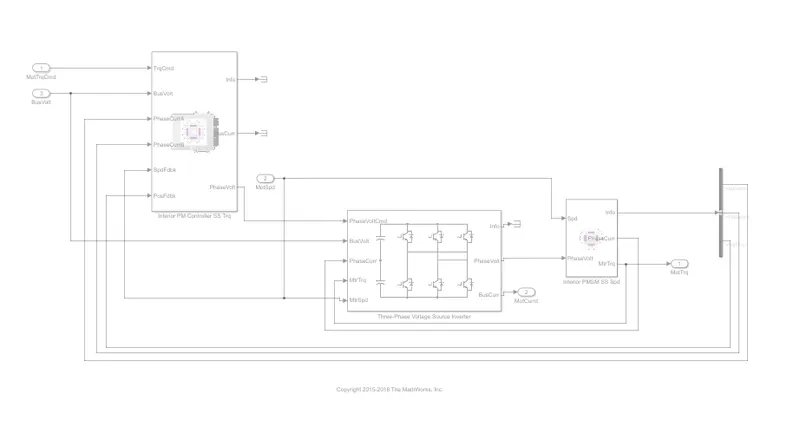
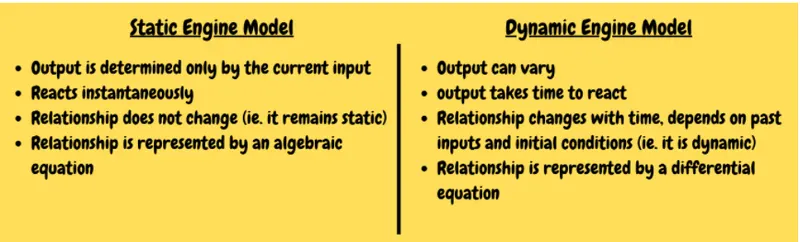
How to change model type?
select powertrain blockset.
select pure ev type,passenger block, electric plant, then EV Plant/ Generator.
right click simulink,variant, label mode active type, motor generator EV type.
2. How does the model calculate miles per gallon? Which factors are considered to model fuel flow?
-different factors effectingthe drive train of hybrid electric vehicle are
vehicle speed
fuel flow
battery power
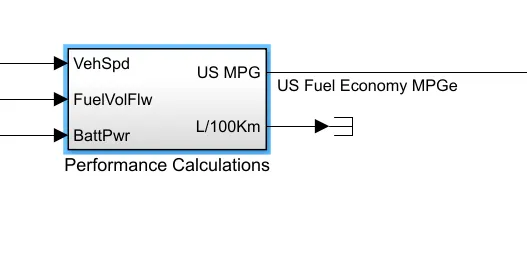
Here we have taken an example of hybrid Electric Vehicle foe conversion of miles per gallon
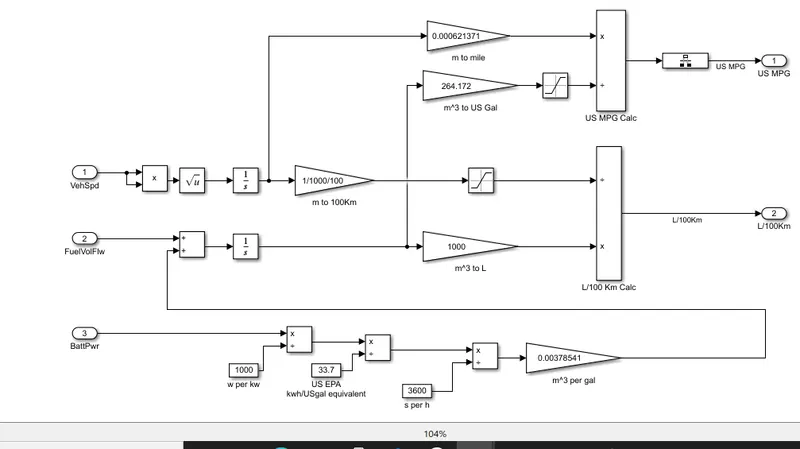
Convert cubic meter to gallon
as 1000L = 264.172 US GALLON
Factors to be considered in model fuel flow are-
Fuel Economy - Its a relationship between distance travelled by the vehicle and amount of fuel consumed. Since fuel consumption is significant factor in air pollution and importation of motor fuel can be large part of nation forgein trade. Many contries have impose requirements of fuel economy, Differnt methods are used to evaluate the actual performance of vehicle.
Fuel Consumption - Its vary for different type of reference model vehicle. For example the conventional and hybrid electric vehicle we need to considered a fuel as physical quantity, and calculate its volume from mass flow rate by integrating withthe time interval. Foe electric vehicle we need to consider battery electrical energy as te source of fuel. The battery power is converted into energy per gallon of gasoline fuel equivalent , then to volumetric form.
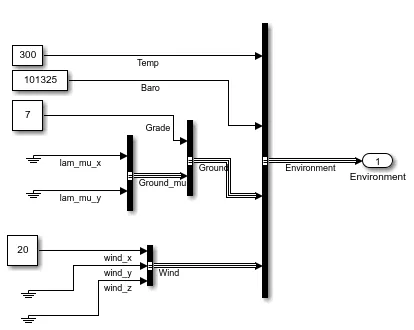
3. Run the HEV ReferenceApplication with WOT drive cycle. Change the grade and wind velocity in the environment block. Comment on the results
In the power train blockset , we have two types of hybrid electric vehicle. HEV using multimode reference application and HEV using power split reference application.
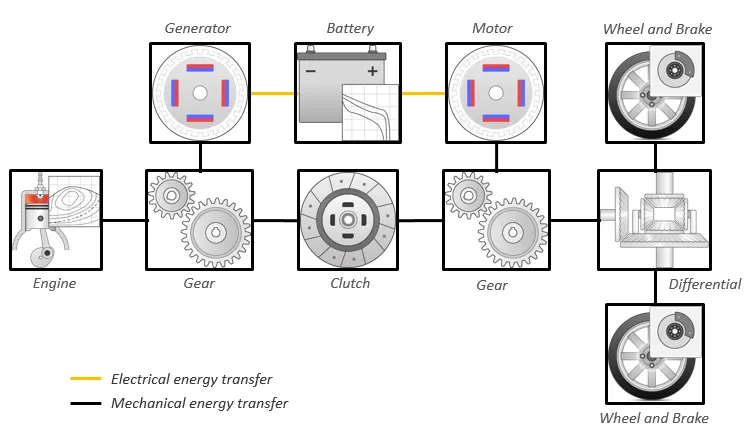
Multimode or dedicated hybrid transmission is where the electric motor is added to conventional automatic transmission . Here the electric motor is indespensible for the operation of overall powertrain. Some vehicle manufacturers offer DHT ( toyota prius 4th generation, GM with Voltech System, Mistubishi with multimode transmission).
Common power train Configuration are Series, parallel , powertrain Configuration.
special transmission concept have been developed which enables switching of operation mode of powertrain.Each operation mode confirms one of the common mode powertrain and capability of switching them in one of the vehicle operation will combine the advantage of the available power train configuration.
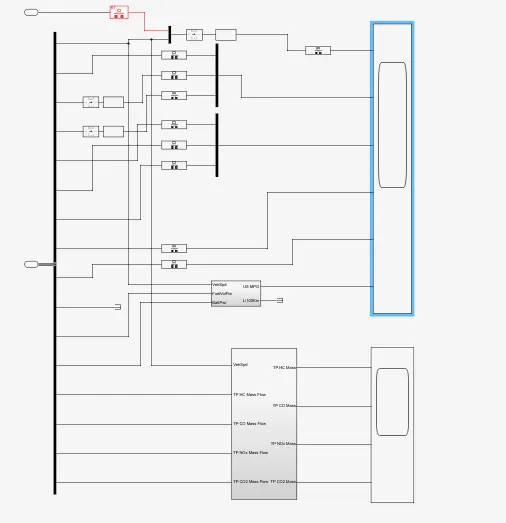
HEV Reference Application wuth WOT Drive Cycle
Performance in FE Scope
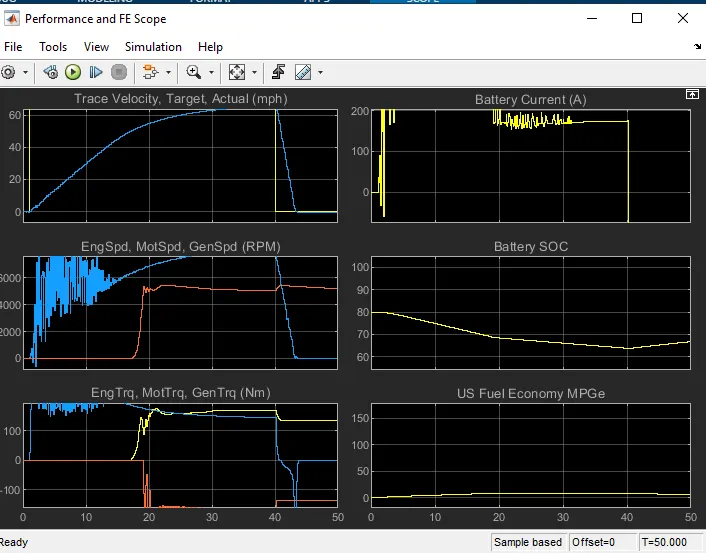
In the plot 1 the trace velocity is 60m/h till the deacceleration but as actual velocity doesnot reach the trace velocity because of gradeability and wind velocity is increased , the current and power is limited.
In second plot current going in negative direction as deacceleration started.The negative current means that battery is charging and in regenerative braking mode.
In third plot speed of motor and generator is same and it overlaps.
4. Keeping all other parameters same, compare the simulated results of hybrid and pure electric powertrains.
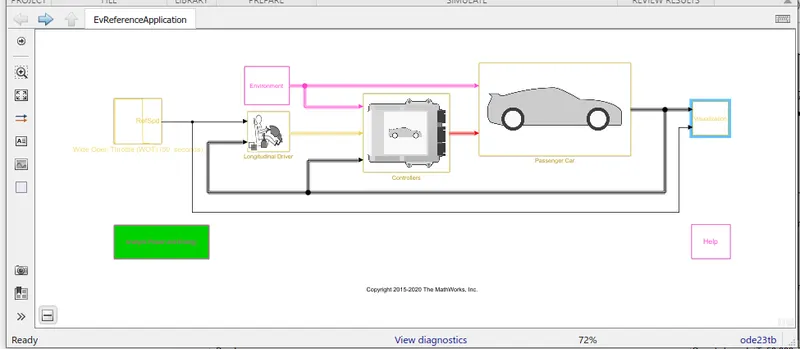
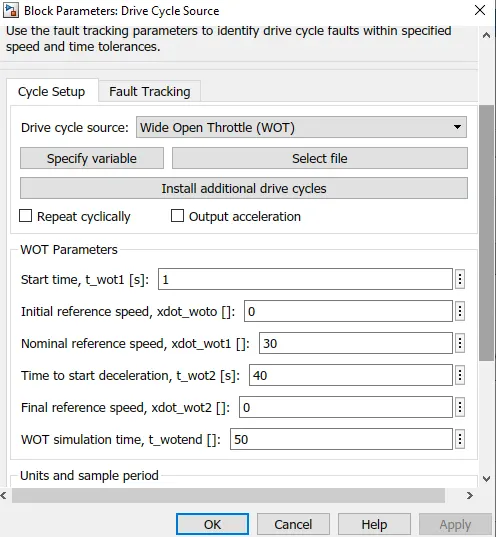
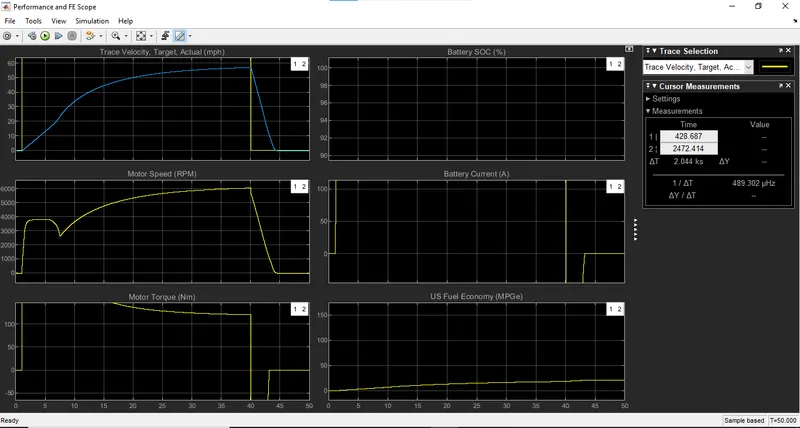
we can see that actual speed of vehicle is 58kmph for pure EV and hybrid is 60kmph.