Week-4 Challenge WOT Condition Part-2
1) What is the difference between mapped and dynamic model of engine, motor and generator? How can you change model type?
Mapped model:
This type of model uses a set of steady state lookup tabel to detemine engine performnce. This model is used for analysis and desiging purpose which does not required engine dynamic characteristics. The look up table consistes of all engine characteristics such as fuel flow, air flow, torque, efficiency, exhaust temperature etc.
Dynamic model:
Dynamic model decomposes the engine behavior into individual components model by combining components in this way, the models capture the dynamic effects. We can use this model to analyze the impact of individual engine component on overall performance.
Steps to change the model type:
1) open the simulink model of powertrain blockset which is available in matlab website.
2) Double click on the passenger block and enter into the block
3) There you will find the engine plant
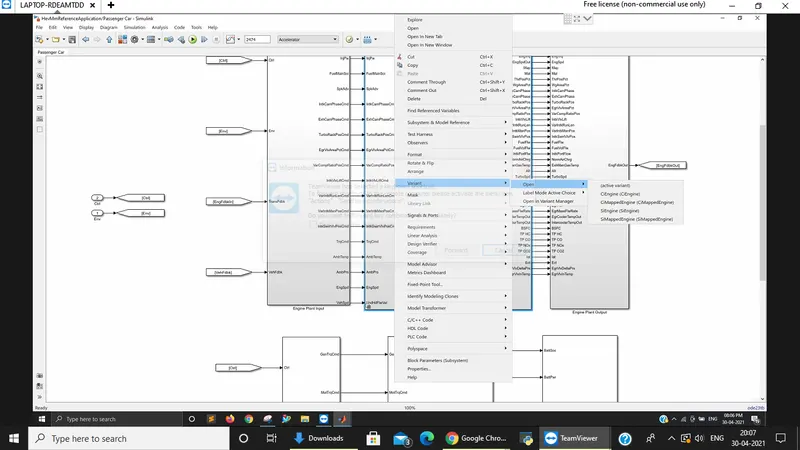
4) Right click on the engine plant and select variant
5) In variant click on lable model active choice and there you can choose mapped or dynamic model in this way you can change model type.
2) How does the model calculate miles per gallon? Which factors are considered to model fuel flow
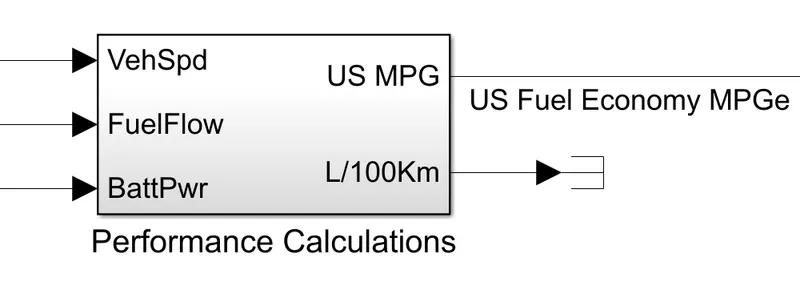
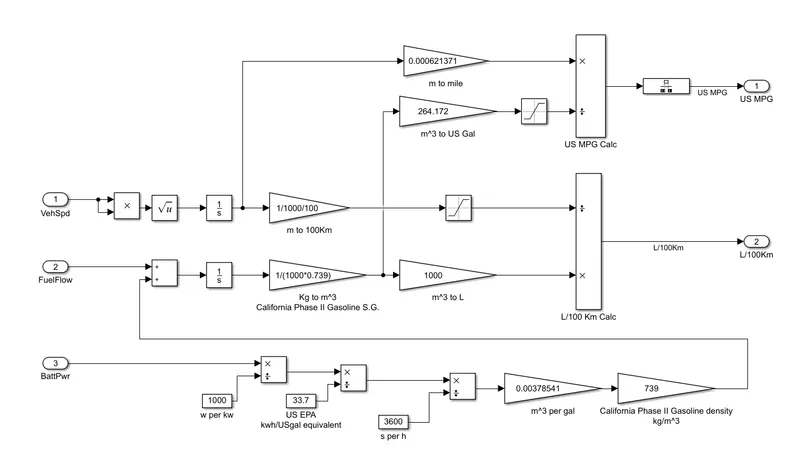
To know how the model calculate the miles per gallon open performance calculation block. miles per gallon is fuel economy rating which can be determined by how much miles the vehicle is travelled for per gallon of fuel. In this case of ev vehicle this is measured by how much electrical energy is consumed by battery while travelling cetrain distance. Factors are considered to model fuel flow are battery power, vehicle speed, fuel flow.
This is the simulink model to calculate MPG of vehicle.
3) Run the HEV ReferenceApplication with WOT drive cycle. Change the grade and wind velocity in the environment block. Comment on the results.
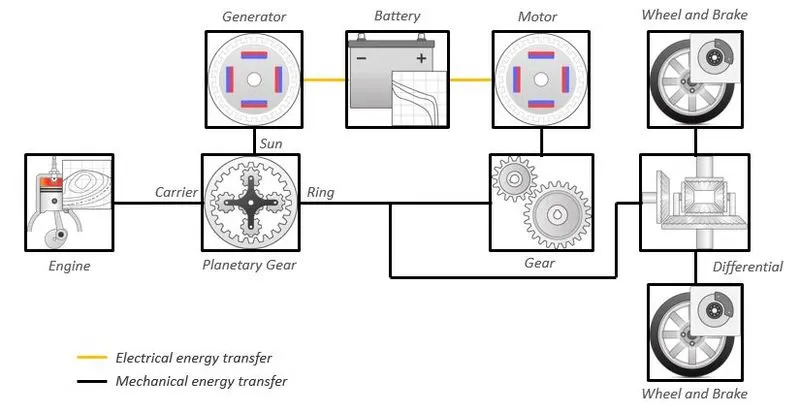
The above flow chart is the working flow of hybrid electrical vehicle
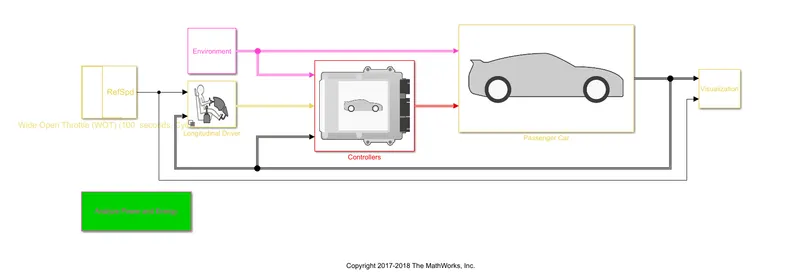
The above model is the simulink model of hybrid elecrical vehicle referance application
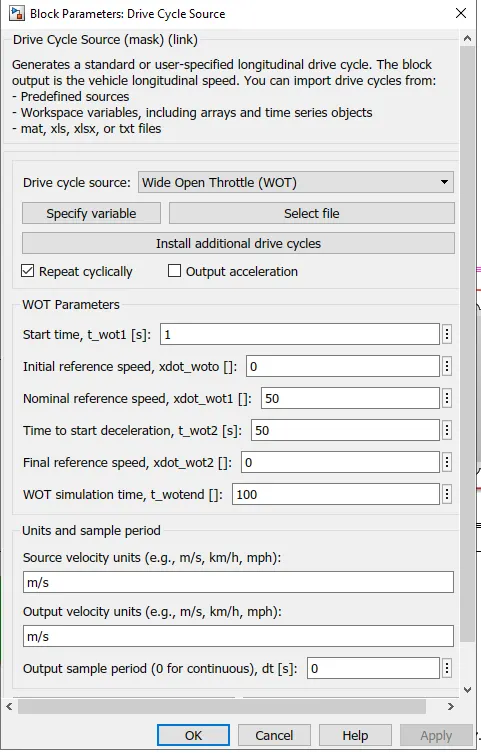
WOT condition drive cycle is choosen in drive cycle source block. The nominl reference speed is set to 50, time to start deceleration is 50 sec and the stimulation time of drive cycle is 100 sec
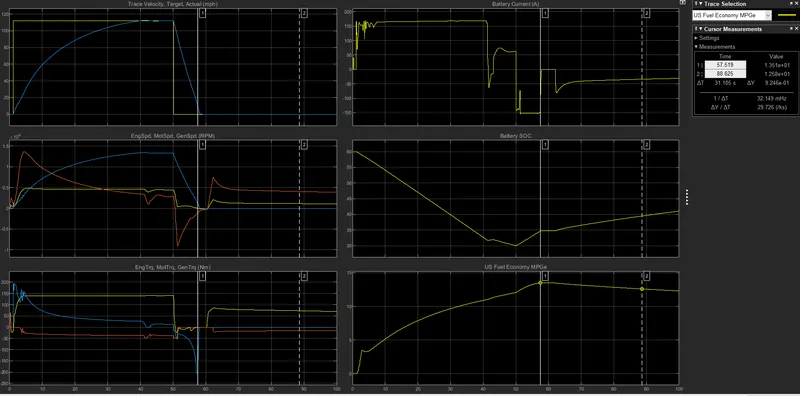
The above picture is the output graph of model 1 and the results from graph are noted in table
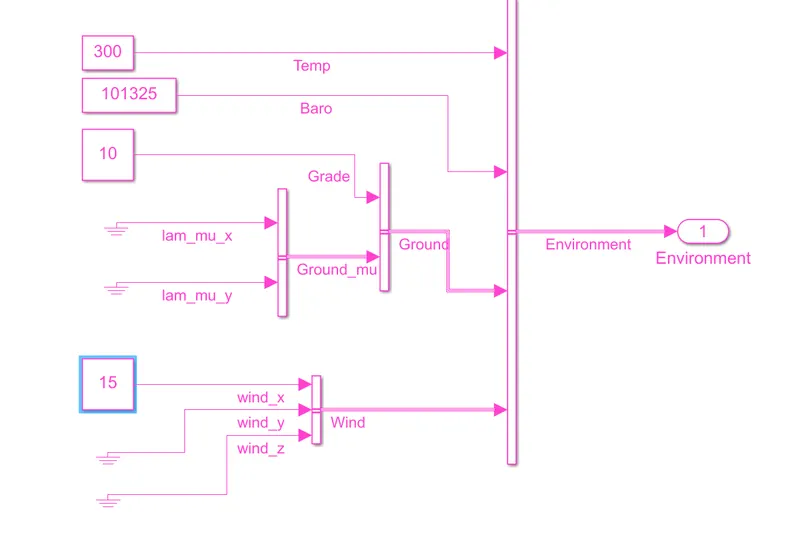
By opening environment block we cn see this model, here the initially the grade and wind velocity is set as 0 for model 1 and for model 2 they are changed to 10 and 15 respectively.
|
Parameters |
Model 1 |
Model 2 |
|
Grade |
0 |
5 |
|
Wind velocity |
0 |
10 |
|
Max speed(mph) |
112 |
82 |
|
Time of deceleration(sec) |
8 |
5.5 |
|
Engine Torque (Nm) |
140 |
140 |
|
Battery current(A) |
168 |
168 |
|
SOC (%) |
60-40 |
60-37 |
|
Fuel economy(MPG) |
13 |
9 |
|
Motor torque (Nm) |
200 |
200 |
From the above results it is observed as model 1 has maximum speed than model 2 because in model 2 grade and wind velocity act as resitance for vehicle. Due ro this resistance fuel economy of model 2 is also low when compared to model 1. There is only little devition is SOC. Time of deceleration of model 1 is more than model 2 because in model 1 there is no any resistance acting on vehicle. Engine Torque, Battery current, Motor torque these are the parameter which are same for both model.
4) Keeping all other parameters same, compare the simulated results of hybrid and pure electric powertrains.
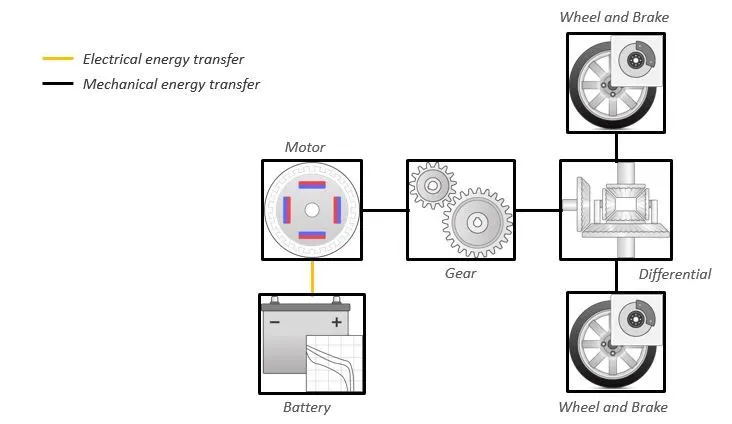
The above model is the simulink model of elecrical vehicle referance application
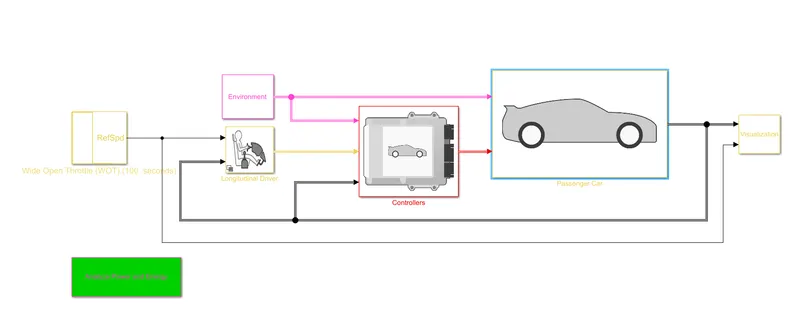
The above model is the simulink model of elecrical vehicle referance application. Stimulation is done in same way as the model 2 of hybrid elecrical vehicle is done with same grade and wind velocity.
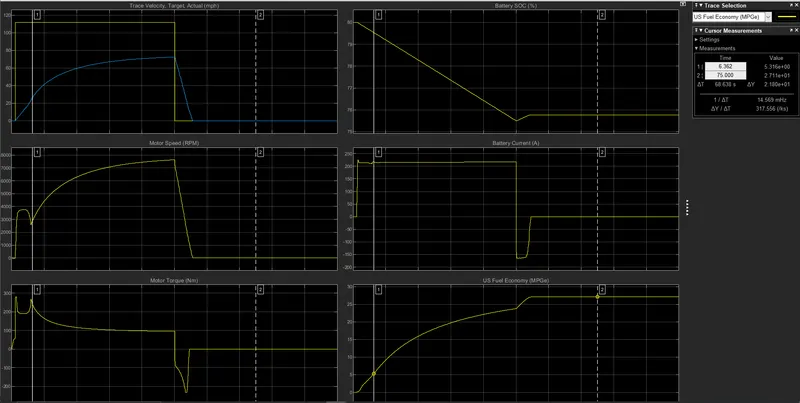
The above picture is the output graph of electrical vehicle referance application and the results from graph are noted in table
|
Parameters |
EV |
HEV |
|
Grade |
5 |
5 |
|
Wind velocity |
10 |
10 |
|
Max speed(mph) |
70 |
82 |
|
Battery current(A) |
215 |
168 |
|
SOC (%) |
80-76 |
60-37 |
|
Fuel economy(MPG) |
25 |
9 |
|
Motor torque (Nm) |
280 |
200 |
From the above result we can conclude that hybrid elecrical vehicle has maximum speed than electrical vehicle, Soc for electrical vehicle is higher than hybrid elecrical vehicle, and the fuel economy of electrical vehicle is 2.5 times more than hybrid elecrical vehicle. Since electrical vehicle is the purely based on electrical it has more battery current and motor torque compared to hybrid elecrical vehicle.