Week-4 Challenge WOT Condition Part-2
ANS 1:
Mapped Model:
- Model uses a set of steady-state lookup tables to characterize engine performance.
- The mapped model is one type where the data is defined in lookup tables by default and are provided to the model beforehand.
- This type of model requires data to be given to all systems previously by the user and cannot be changed later or during the simulation
- The motor or engine or generator block output depends simply without considering the real time motor or engine or generator, without change in in the parameters.
- The output values are stored for the corresponding given input values of the engine motor and generator
- The accuracy of this type is not that high but the time for simulation will be done in much less comparatively as it does not run by real time parameters.
Dynamic Model:
- Model decomposes the engine motor/generator behavior into engine motor/generator characteristics that are separated into lower-level components. By combining components in this way, the models capture the dynamic effects.
- The dynamic model in other hand uses the combination of the outputs as feedbacks from various subsystems to generate the total output.
- Every component parameter can be varied in real time simulation based on the user input.
- It runs by real time simulation where the required input from the drive cycle is taken and for that individual real time simulation occurs and summing of all the results of the subsystem gives the output for the simulation.
- As per the drive cycle requirements the initial Bus voltage, current is given along with the vehicle feedback so that it runs the actual simulation at that particular moment throughout the drive cycle.
- The accuracy of this model is very high as it considers the real outputs from all the subsystem to generate the output.
- The simulation will take very long time to complete as it has many individual simulations running by all the subsystem of the engine, motor/generator.
Steps to change the model type –
- First, select the type of vehicle config in the powertrain blockset module
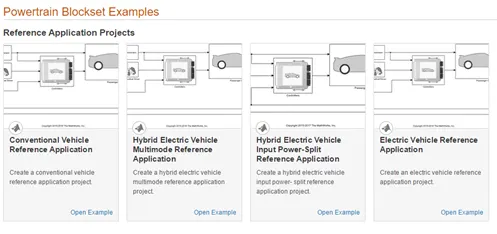
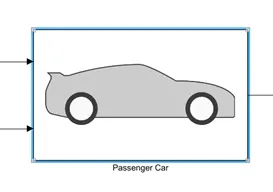
2. Select and open the passenger car block
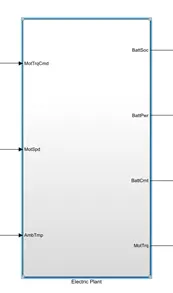
3. Open the electric plant block
4. Right click on the motor block an a dialog box will appear
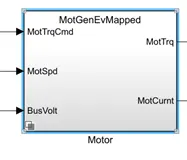
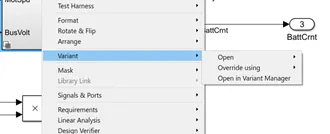
5. Select variant > open variant manager
6. In the variant manager right click on the motor select open and highlight block
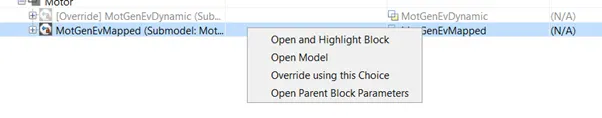
7. The dynamic model will be selected
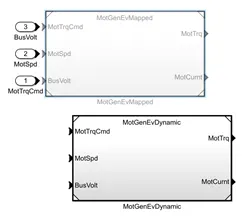
.
.
.
ANS 2:
Miles per gallon
Miles per Gallon is a fuel economy rating determined by how far a car can travel on a gallon of petrol or Diesel for An Engine powered vehicle. In case of an electric vehicle it tells us the battery energy consumed equivalent to that of an engine fuel consumption.
- The amount of Fuel Energy required to move an engine powered car through a distance is determined and then it is compared to the equivalent amount of electric energy required to move the car through the same distance and is expressed as the miles per gallon.
- The powertrain blockset has a model that calculates the miles per gallon for all kinds of vehicle
FOLLOWING STEPS SHOW HOW THE VEHICLE FUEL EFFICIENCY IN MILES PER GALLON(MPG) IS CALCULATED
- UNDER THE VISUALISATION THE VEHICLE PERFORMANCE CALCULAATION BLOCK CAN BE SEEN
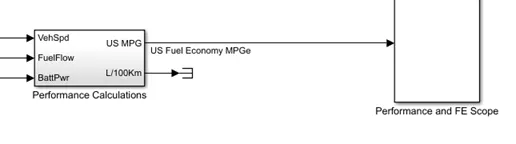
- THE PERFORMANCE CALCULATION REQUIRES THREE INPUT PARAMETERS FOR THE HEV
- Vehicle speed
- Fuel flow
- Battery power
- ON OPENING THE PERFORMANCE BLOCK WE CAN SE THE FOLLOWING BLOCK DIAGRAM
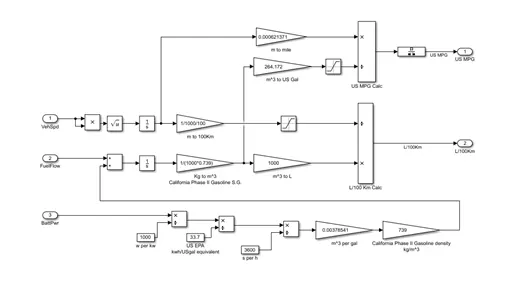
- FROM THE ABOVE FIGURE WE EVALUATE HOW THE EFFICIENCY CAN BE OBTAINED:
- The vehicle speed is first integrated to convert it into distance in kilo meter
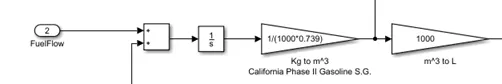
- The fuel flow is expressed in mass flow rate i.e Kg/sec, this is converted into mass in Kg using the integrator and the converted to volume using the gain after which it is converted in litres
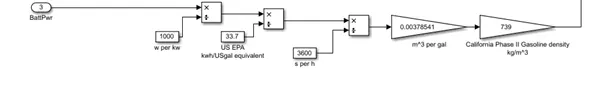
- The battery power is converted to energy using the gain and then calculate to US gallon equivalent, which is further expressed as energy in terms of LIS gallons per second
- At last the gallons per second is converted to volume of fuel flow using the gain expressed in Kg/m^3.
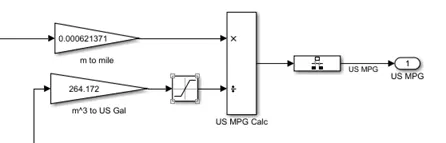
- The vehicle speed and distance is calculated in terms of miles and miles per hour.
- The total enegyr combined (battery and fuel ) is converted to gallons
- Both these inputs are divided at the end to obtain miles per gallon (MPG).
.
.
.
ANS 3 –
HEV ReferenceApplication with WOT drive cycle
The simulation is carried out for 100 seconds
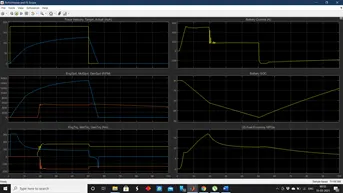
DEFAULT OUTPUT
OBSERVATIONS:
- Plot 1 (Trace Velocity Target vs Actual) - Through this plot it is denoted that the desired Velocity has not been met by the actual vehicle velocity. The desired velocity was ranging at near about 140 mph but he actual velocity achieved was near to 110 mph.
- Plot 2 (Engine Speed, Motor Speed) rpm - This plot gives the detailed analysis for the achieved Engine and Motor speed in rpm. The contribution of both the Power Generating sources for meeting the required Velocity.
- Plot 3 (Engine Torque, Motor Torque and Generator Torque) Nm - This plot gives the detailed analysis of the Engine, Motor Torque and generator Torque.
- Plot 4 (Battery Current) A - This plot denotes the power produced by the Battery and the readings are in Ampere.
- Plot 5 (Battery SOC) - This plot denotes the State Of Charge of the battery, this denotes the range of charge used for the achievement of velocity.
- Plot 6 (US Fuel Economy) MPG - This is the Fuel Efficiency or the Range of the drive and the same is denoted in Miles Per Gallon equivalent.
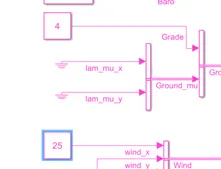
- NOW WE CHANGE THE GRADE AND WIND VELOCITY IN THE ENVIRONMENT BLOCK
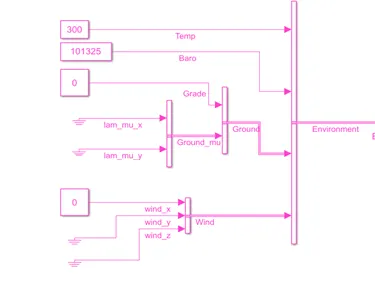
- WE CHANGE GRADE VALUE TO 4 AND WIND SPEED TO 25 MPH
- THE OUTPUT IS AS FOLLOWS
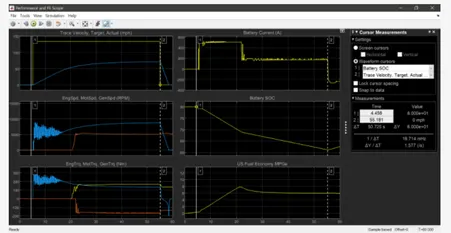
- Plot 1 (Trace Velocity Target vs Actual) - This is clearly visible that as the grade and the wind velocity is increased compared to the normal state the vehicle is not able to reach the target velocity
- Plot 2 (Engine Speed Motor Speed) rpm - In this plot comparing with the normal plot the Engine Speed has reduced to a steep slope on the negative side as compared to the normal situation the grade is increasing the load on the engine and thus the targeted Engine Speed is not met
- Plot 3 (Engine Torque, Motor Torque, Generator Torque) Nm - There are multiple variations in all these aspects and the same is visible in both the results of Normal and with the Grade and Wind Velocity
- Plot 4 (Battery Current) A - Battery current has been fluctuating at a higher range as compared to the normal after the vehicle is reaching near to the steady/stable pace the fluctuation starts and is simulated
- Plot 5 (Battery SOC) - The Battery State of Charge remains more or less similar in both the cases and are resulted at 65% after the end of the WOT Cycle
- Plot 6 (US Fuel Economy) MPGE- The average fuel economy differ in both the scenarios. .
.
.
.
ANS-4
Keeping all other parameters same, compare the simulated results of hybrid and pure electric powertrains
The simulation is done for pure electric & Hybrid electric vehicle with Wide open Throttle (WOT) Drive cycle. The
Total cycle time = 100 seconds
The Top speed of this cycle 80 mph
Time to start deceleration = 20 seconds
The Grade angle = 8 Degrees
The wind velocity = 10 m/s.
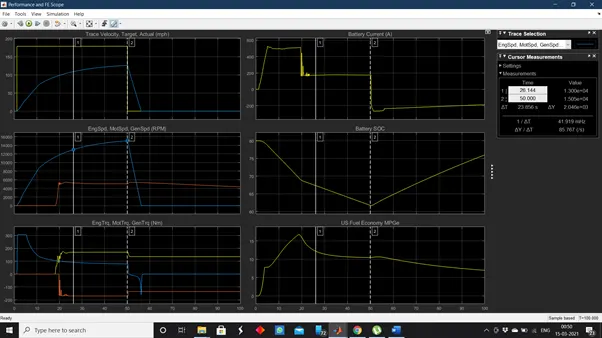
HYBRID ELECTRIC POWERTRAIN RESULTS
ELECTRIC POWERTRAIN RESULTS
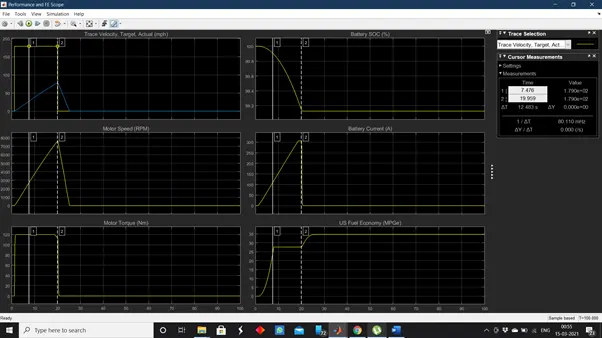
REMARKS:
- The overall difference in both these simulations are their vehicle operations where the EV is completely operated on Battery as the Power Sorte and on the other hand the HEV has two power soures SI/CI Engine and Battery. The results obtained are varied and the parameters are also differenciated accordingly.
- The electric vehicle when compared with hybrid electric vehicle with the same environmental and Drive cycle conditions results in less top speed achievement. The electric vehicle produces more values of Motor speed and motor torque compared to the hybrid vehicle's motor alone, but hybrid vehicle when it combines the torque of both motor and its engine it is higher than the electric vehicle's torque. This is responsible to pull the Hybrid car at higher top speed compared to the pure electric.
- As the pure electric car here uses Lithium-ion battery compared to the Nickel metal hydride battery the discharging capacity and the rate of charging is higher in the pure electric car. it is able to discharge in a fast rate the motor can produce high amount of torque instantly compared to the hybrid vehicle.
- Also the state of charge shows the battery efficiency of the pure electric to be higher than the hybrid vehicle and this is also due to the battery type used in these cars.
- The efficiency of the Electric car is higher than the hybrid car which is evident from the miles per gallon numbers of both of these cars.
- Electric vehicle produces zero emissions whereas the hybrid one's produce waste gas emission. These are some of the observations from the comparison of the above simulations.