Week 3 - Solving second order ODEs
clear all
close all
clc


b=0.05;
m=1;
l=1;
g=9.81;


%initial condition

theta_0=[0;3];

%time points

t_span=linspace(0,20,200);

%solve ode

[t,results]= ode45(@(t,theta) ode_func(t,theta,b,g,m,l),t_span,theta_0);

plot(t,results(:,1));
hold on

plot(t,results(:,2));

ylabel('plot');
xlabel('time');

%pendulum
figure(2)
for i = 1:length(t_span);

x0=0;
y0=0;

x1= 1*sin(results(i,1));
y1=-1*cos(results(i,1));
plot ([x0 x1],[y0 y1],'linewidth',3);
hold on
plot ([-0.5 0.5], [0 0],'linewidth',3);

%plotting pendulum bob;
plot (x0,y0,'o','markersize',10,'markerfacecolor','b');

%joining end points of line and fixed end
plot (x1,y1,'o','markersize',6,'markerfacecolor','k');

%connecting bob and fixed end
plot([x0 x1],[y0 y1],'linewidth',2);
axis ([-1.5 1.5 -1.5 1.5]);

M(i)=getframe(gcf);
% ct=ct+1;
hold off

end

movie(M)
videofile=videoWriter('ODE.AVI','uncompressed AVI');
open(videofile)
writeVideo(videofile,M)
close(videofile);
HERE THE EXPLANATON OF CODE;
THE GIVEN EQUATION IS
d^2/dt^2+b/m dtheta/dt+g/LSINTHETA=0
the given values are:
b=0.05(damping coefficent);
m=1(mass);
g=9.82ms/s^2 (damping coefficent)
there are two order odes
velocity and dispalcement
velocity=3
dispalacement=0
initial condition for displacement
theta_o=0.5
initial pendulum=0
initial velocity=5m/sec
there the time points
t_span
the span is for calculating the time points
in the time span we using the linespace command for calculting the pendulum counting here we use the 0 to 20 for 200 times
we have to solve the function
ode 45 its the referens take by the refernce rk theory partial differntial equation using a numerical method..
function of [d theta_dt]=ode func(t,theta,b,g,l,m);
explanation this function
dtheta1_dt = dtheta a2
dtheta2dt=-b/m*theta 2 -g/lsin theta
plot will be using the make a graph
t_results _:1
plot results (t,theta:2)
x label is use for plot and y label for time
for pendulum
for using the for loop to make a pendulum of degress sin and cos degress
plot for the pendulum bob and joining end for line and fixed end points
for frame function get frame will be used gcf
movie m file reader to make a pendulum movie an video writer
close window for finish the video file
ERROR FACING:
1
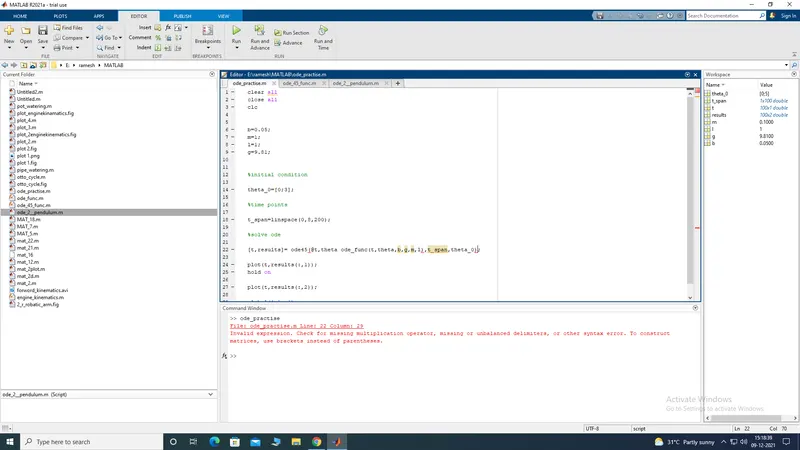
ERROR 1 WHILE I FACED:
line 22 i missed the brackets by multiplication for construct the matrix using the brackets
to rectify the error
and am put the brackets and mention the brackets for theta and its should be solved
error 2
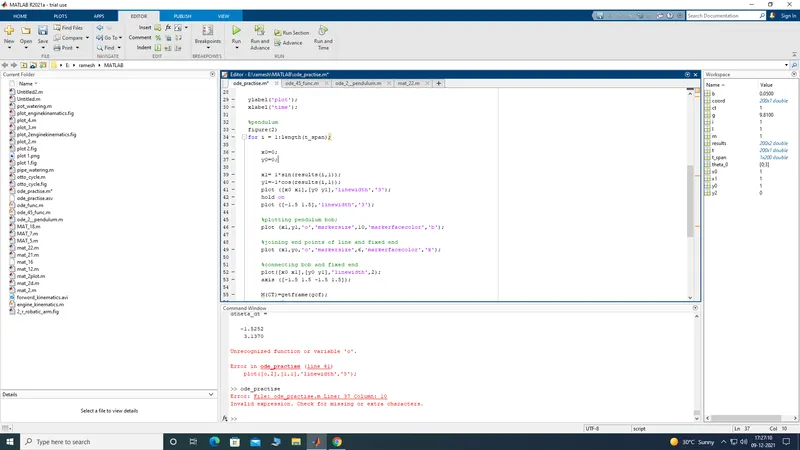
error i faced
inavlid expression missing the extra character y=o
error to be rectified
put the y o for putting y zero and its be solved;
ERROR 3
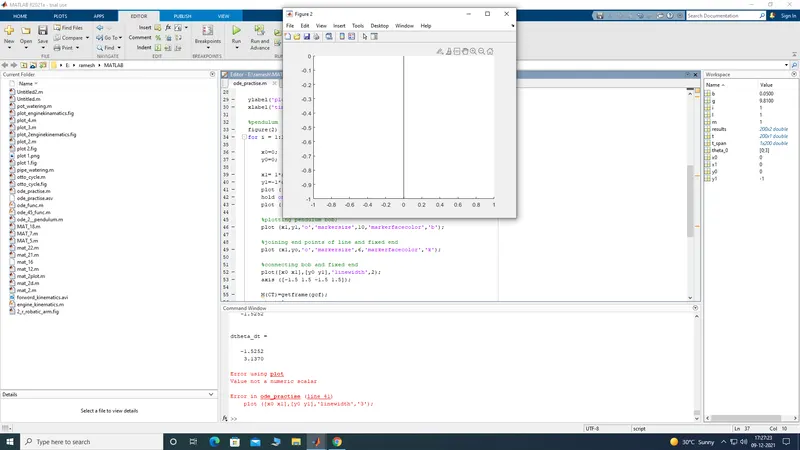
ERROR I FACED
FOR PLOTING am not putting brackets to xo x1 yo y1
error i rectified
am putting the individual square brackets for [xo x1[ yo y1] for this...
ERROR 4
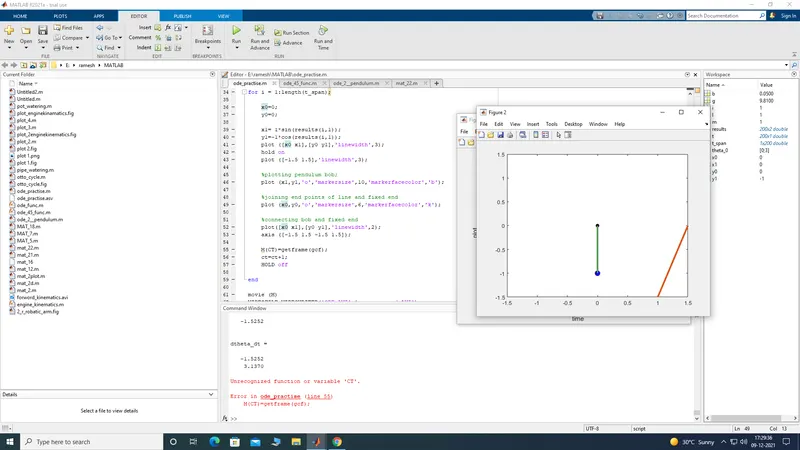
error i faced in line 55 am putting m(mct)=getframe ct will be mention on this one
error am rectified
i mention the ct =%comments for invalid the function of (ct) and its should be cleared:
output;
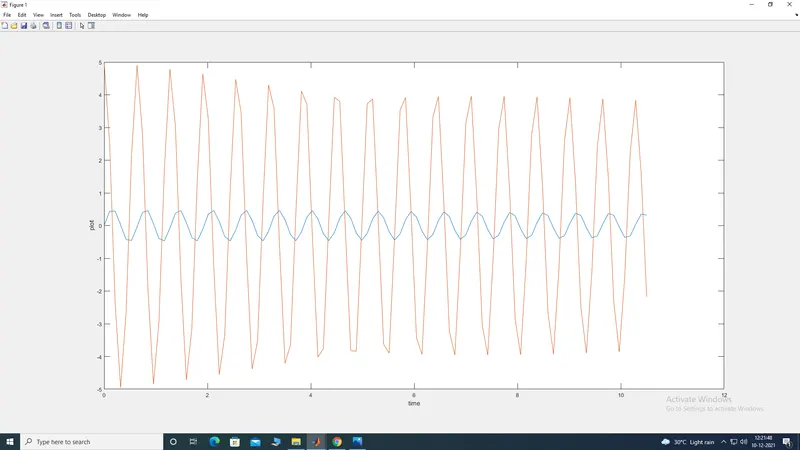
ANIMATION OF PENDULUM
YOUTUBE LINK