Week-11 Challenge: Braking
Answer 1.
Braking- The only function of braking system is to decelerates the vehicle accroding to the requirement. brakes may slow down the vehicle on speed breakers, turning points and also stops the vehicles at the same ponits during emergency conditions. brakes are two type in EV and HEV, first is regenerative braking and second is the mechanical braking. as we all know during motion vehicle have some kinetic energy and so when we applies the brakes on the vehicle with such kinetic energy, some ammount of the energy is wasted in the form of heat. This energy is called Braking Energy and is much essential for the calculations purpose.
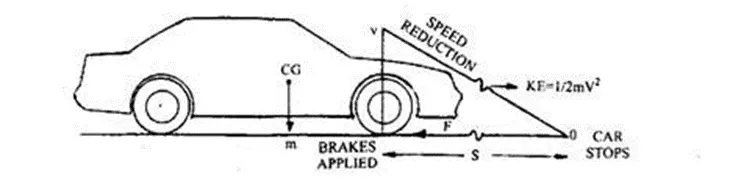
if the mass of the vehicle is M Kg, moving speed is V m/s, and the speed after brakes is U m/s then
kinetic energy of the Vehicle is
K= 1/2 * M * (V^2 - U^2) joules
if vehicle stops due to brakes then U=0 m/s
so K= 1/2 * M * V^2 Joules
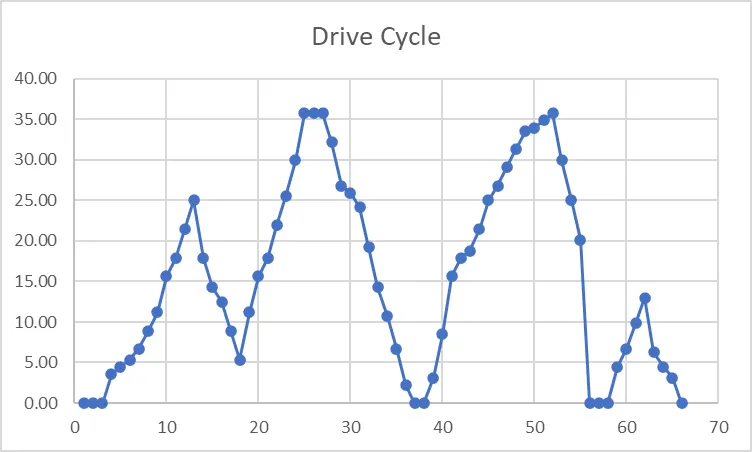
The drive clycle is given below-
| Time | Speed In mph | Speed in m/s |
| 1 | 0 | 0.00 |
| 2 | 0 | 0.00 |
| 3 | 0 | 0.00 |
| 4 | 8 | 3.58 |
| 5 | 10 | 4.47 |
| 6 | 12 | 5.36 |
| 7 | 15 | 6.71 |
| 8 | 20 | 8.94 |
| 9 | 25 | 11.18 |
| 10 | 35 | 15.65 |
| 11 | 40 | 17.88 |
| 12 | 48 | 21.46 |
| 13 | 56 | 25.03 |
| 14 | 40 | 17.88 |
| 15 | 32 | 14.31 |
| 16 | 28 | 12.52 |
| 17 | 20 | 8.94 |
| 18 | 12 | 5.36 |
| 19 | 25 | 11.18 |
| 20 | 35 | 15.65 |
| 21 | 40 | 17.88 |
| 22 | 49 | 21.90 |
| 23 | 57 | 25.48 |
| 24 | 67 | 29.95 |
| 25 | 80 | 35.76 |
| 26 | 80 | 35.76 |
| 27 | 80 | 35.76 |
| 28 | 72 | 32.19 |
| 29 | 60 | 26.82 |
| 30 | 58 | 25.93 |
| 31 | 54 | 24.14 |
| 32 | 43 | 19.22 |
| 33 | 32 | 14.31 |
| 34 | 24 | 10.73 |
| 35 | 15 | 6.71 |
| 36 | 5 | 2.24 |
| 37 | 0 | 0.00 |
| 38 | 0 | 0.00 |
| 39 | 7 | 3.13 |
| 40 | 19 | 8.49 |
| 41 | 35 | 15.65 |
| 42 | 40 | 17.88 |
| 43 | 42 | 18.78 |
| 44 | 48 | 21.46 |
| 45 | 56 | 25.03 |
| 46 | 60 | 26.82 |
| 47 | 65 | 29.06 |
| 48 | 70 | 31.29 |
| 49 | 75 | 33.53 |
| 50 | 76 | 33.98 |
| 51 | 78 | 34.87 |
| 52 | 80 | 35.76 |
| 53 | 67 | 29.95 |
| 54 | 56 | 25.03 |
| 55 | 45 | 20.12 |
| 56 | 0 | 0.00 |
| 57 | 0 | 0.00 |
| 58 | 0 | 0.00 |
| 59 | 10 | 4.47 |
| 60 | 15 | 6.71 |
| 61 | 22 | 9.83 |
| 62 | 29 | 12.96 |
| 63 | 14 | 6.26 |
| 64 | 10 | 4.47 |
| 65 | 7 | 3.13 |
| 66 | 0 | 0.00 |
Plot of the drive cycle
Matlab Code for Power Calculations are-
and the plot of drive cycle vs braking energy is given below
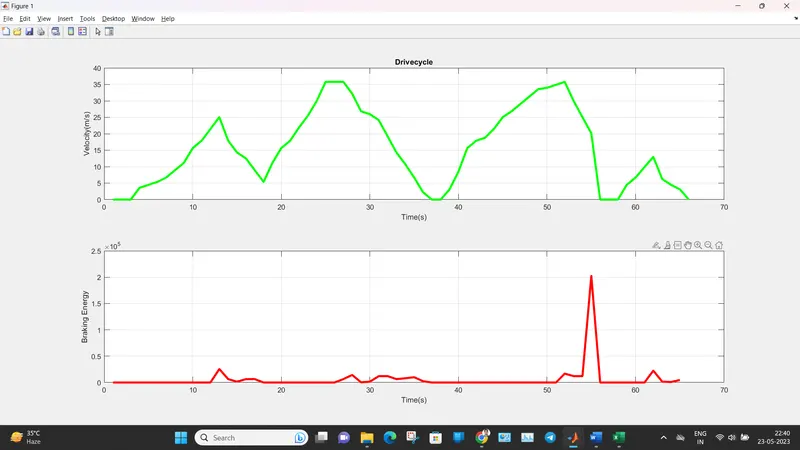
after calculations
Total Brake Energy in is 3.935943e+05 = 393.59 KJ
Average Brake Energy is 6.055296e+03 = 6.055 KJ
Answer 2.
The electric motor can't develop braking torque at high speed because once the electric supply is pulled off from the motor,it acts as a generator and due to the flux weakening effect of the electric generator,the generator produces low torque as expected and also during that period motor is working in constant power mode which in regenerative braking, which does not have sufficient torque during regenerative braking.
Regerative Braking: In this type of braking, the electric traction motor uses the vehicle's Kinetic energy to convert it into electrical energy by running motor in to generator action otherwise it would be lost to the brake discs as heat. In addition to improving the overall efficiency of the vehicle, regeneration can significantly extend the life of the braking system as the mechanical parts will not wear out very quickly.
The most common form of regenerative brake involves an electric motor functioning as an electric generator. In electric railways, the electricity generated is fed back into the traction power supply. In battery electric and hybrid electric vehicles, the energy is stored chemically in a battery, electrically in a bank of capacitors.
Coordination of Electric and Mechanical Brake :
In an electric Motor, the Total Brake distribution is in two parts, first one is Electrical Brake which is called Regenerative Braking, and second one is called Mechanical Brake or Classical Brake with a hydraulic cylindrical system. Brake Force distribution must be uniform, If the Regenerative braking is developing voltage more than requirement of the voltage charging limit of the battery or more than the regenerative capacity of the machine then it may damage battery system so in this situations we must apply Mechanical brakes as well. In a practical case, the combination of these two brakes is applied. So usually it is a combined response of Mechanical brake and Regenerative brake. The reason for how this braking force is combined, that particular phenomena are called Brake Control Strategies. There are two Brake Control Strategies, which are Series - In case of Series, we apply Mechanical brake and Regenerative electric brake one after another. We can apply only one brake strategy at a time either apply Regeneratively or apply Mechanical brake. The Series Brake Control Strategy has a further classification, that is based on whether we want the comfort of driver or Brake behavior compared to energy efficiency. Parallel - In the case of Parallel, we apply both brakes simultaneously. This Particular Parallel braking is going to happen both at a time. Electric Driven Intelligent Brake (EDIB) is a combination of Hydraulic brake or Mechanical brake along with a Regenerative brake. It is a Parallel braking technique.
Answer 3.
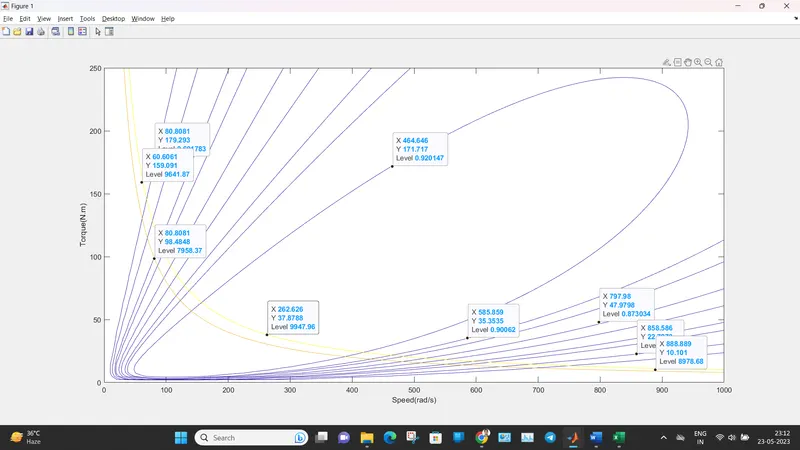
To plot contour line for a given Motor, we need to have various types of losses happening inside a motor. The various types of losses are:
Copper Losses = I^2 * R, watts
where I is the armature current and R is the Armature resistance and we say that Torque is proportional to Current, this copper loss can be consider as .
Copper losses = Kc*T^2 watts
where T is the torque of motor and Kc is combine effect of all resistances.
Iron Losses - Iron Losses are nothing but Magnetic losses, which is proportional to the angular speed. so
Iron Losses = Ki*w watts
where w is the angular speed of motor, Ki is the proportionality constant.
Windage Losses - This is a Mechanical or friction of Windage losses. This is based on size of shape of Motor and the amount of windage losses that the motor is going to experience is-
Windage Losses = Kw*w^3 watts
where w is the angular speed of motor, Kw is the proportionality constant.
Constant Losses - This is denoted as C.
Total Losses - The Total Losses are considering the above four losses and denoted as,
Total Losses = Kc*T^2 + Ki*w + Kw*w^3 + C watts
Matlab Contour for calculating loss is given below-