Project - Position control of mass spring damper system
Answer-
The value of Parameters of a Spring Mass Damper System is given below.
m = 3.6 in kg
k = 400 in N/m
c = 100 in Ns/m
the transfer function of Spring Mass Damper System is
X(s)/F(s)=1/(ms^2 + cs+ k)=1/(3.6s^2 + 100s + 400)
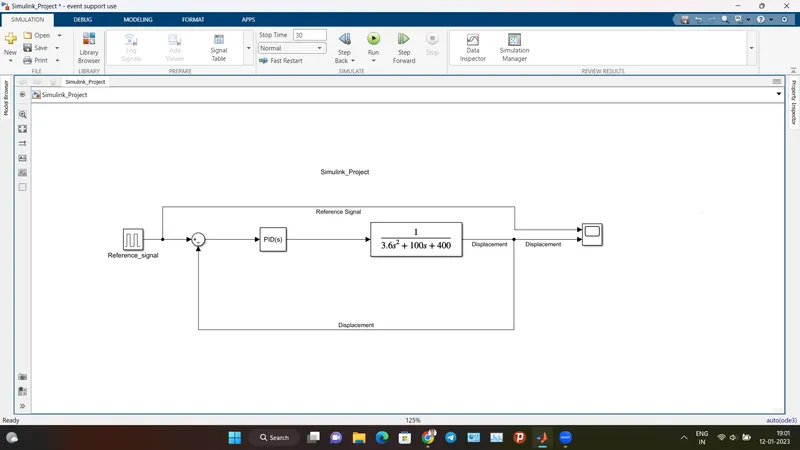
The Model is -
1) I am using transfer function block to use transfer function of spring mass damper system.
2) I will campare output to the given reference input then fed it to PID controller.
3) After auto tuning the PID controller, the output is fed to Transfer function block.
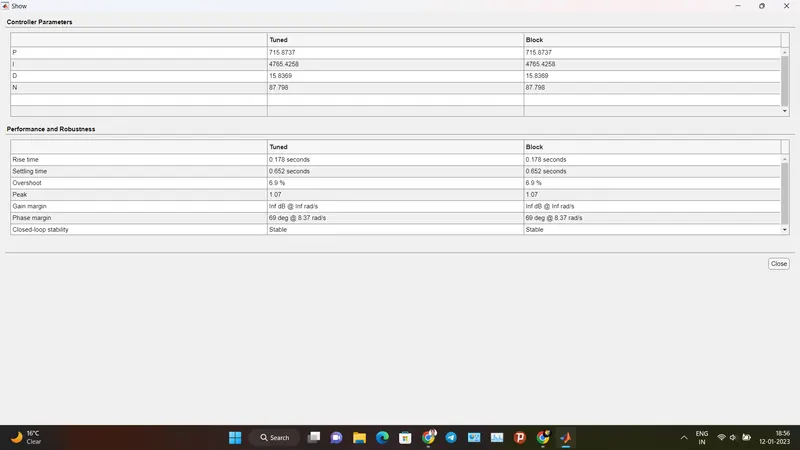
After desiging the PID controller to follow the reference input as given in problem the values of Proportional Gain Kp, Intigral Gain Ki, Derivative Gain Kd using auto tuneing of PID controller is given below-
Kp = 715.8737
Ki = 4765.4258
Kd =15.8369
The corrosponding Transfer Function parameters are given below-
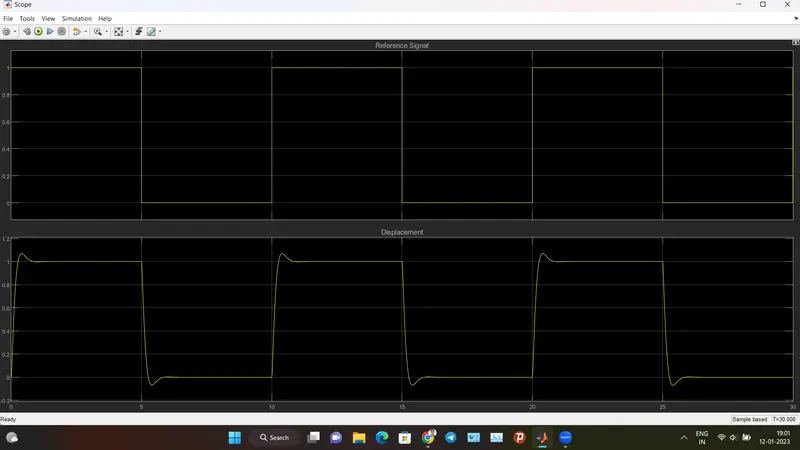
The Scope is -