Week-11 Challenge: Braking
- For a defined driving cycle, calculate the energy required for braking.
Answer:-
The breaking distance increaases four times each time the starting speed doubles.This is beacause the work done in bringing a car to rest means removing all of its kinetic energy.
Kinetic energy is the force that keeps the vehicle moving.This energy is provided by the engine in order to accelerate the vehicle from a standstill to the desired speed.Kinetic energy is dissipated as heat by the brakes during the application of breaks.
Work done(Brake Energy)=Kinetic energy=`(1/2)mV^2`
Where,
m=Mass of vehicle
V=Velocity difference (V_final-V_initial)
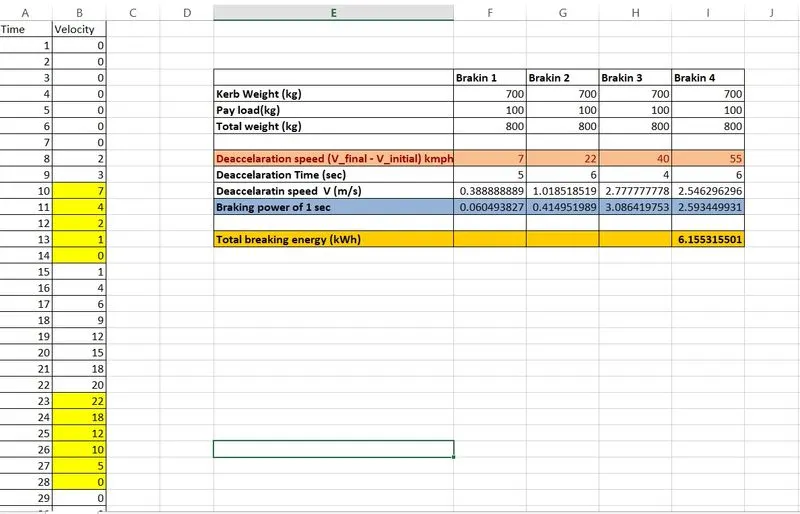
We define a drive cycle for 120 secs.
We take the total weight of the vehicle as 800 kgs
We have 4 cases in the drive cycle where the vehicle brakes.
We calculate V in m/s by multiplying it by 5/18.
First instance Velocity = 7 to 0 kmph
V=7-0=7 in 5 sec=0.388 m/s
`BE1=(1/2)*((800*0.388)/1000)=0.0605`
Second instance Velocity=22 to 0 kmph
V=22-0=22 in 6 sec=1.019 m/s
`BE2=(1/2)*((800*1.019)/1000)=0.415`
Third instance Velocity=45 to 5 kmph
V=45-5=40 in 4 sec=2.778 m/s
`BE3=(1/2)*((800*2.77)/1000)=3.087`
Fourth instance Velocity=55 to 0 kmph
V=55-0=55 in 6 sec =2.55 m/s
`BE4=(1/2)*((800*2.55)/1000)=2.56`
Total Brake power=Sum of all Brake Powers
BE=0.0605+0.415+3.087+2.56=6.1225
Hence,The energy required for braking is 6.1225 kWh.
The above excel file is attached below.
2)Why electric motor can’t develop braking torque at high speed similar to starting? How electric and mechanical brakes are coordinated?
Answer:-
Braking is achieved by using a Mechanical brake or Regenerative Brake.
In DC motors when the load on the motor is constant,Speed is proportional to supply voltage.And when the supply voltage is constant,speed is inversly proposrtional to the load on the motor.
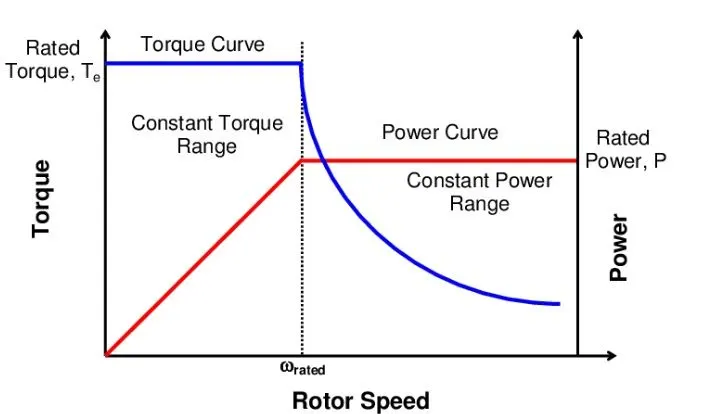
In the constant torque region higher accelerayion is possiable and then the vehicle reaches the point of constant power.When it comes to breaking,Where the torque is negative,the braking torque required goes down as the vehicle is in the constant power region lower than the torque which was during acceleration,So while braking the peak torque is less than tha torque required during acceleration.
Therefore peak acceleration and peak deceleration torque are not the same.
Braking Control:
- Usually,Front-Wheel frives have a higher Braking force hence it is advisable for the front braking to not be increased.
- Braking should be distributed in both and rear wheel independently,So the direction of driving will not be sacrificed for the safety of the vehicle.
- Braking is achieved bu using a Mechanical brake or Regenerative Brake.
- In practice,if the regenerative braking power requirement is more than the charging limit of the battery or more than the regenerative capacity of the machine then the comnination of both mechinical brake & Regenerative brake is applicable.
- As the acceleration torque is higher than deceleration torque,only electric vraking is not sufficant to stop the vehicle.Also while redusing the speed,The speed is not directly reduced,as a process,The regeneration takes place,where the curve enetrs into the 2nd quadrant and again eneters to 3rd to a reduced speed.
- In practice,the same motor cannot produce the same barking power,Which means if the motor accelerations to 100 kmph in 10 sec,it cannot give the equal torque as accelerations in deaccelaration.(T.Braking < T.Acceleration).
Limitations:
- The battery charge rate is lower as compared to the peak discharge rate.
- Power converter limitations while reverse power flow.
Braking control strategies:
- Series Braking (one after another):- In the case of the series brake,We apply a Mechanical brake and regenerativebrake in series one after the other. i.e, Appliying one brake at a time.
- Parallel Brakeing (Both at a time):- In the case of the parallel brake,We apply Mechanical brake and regenerative brake at a time. i.e, Both brakes are applied at the same time.
Finally, We can conclude that Electric and Mechanical brakes are coordinated when being used in EV & HEV
The coordination is based on the requirement,Which is either comfort braking or efficient braking.
If we take an example of "Nissan Leaf"
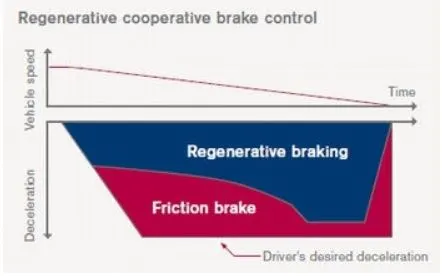
Nissan Leaf is made with the regenerative cooperative brake control method which is an intelligent brake control method developed by the company.
This method is an intelligent automatic control method,designed by Nisan company,in this method when speed is low on Generation braking is done when applied brakes,and when the speed is high to a certain point mechanical and regenerative braking will work simultaneously.
3)Make a MATLAB program which plots contour of given motor speed, torque and efficiency values. Attach the code as a .m file attach a screenshot of all the plots.
Answer:-
Matlab Program:
%Program to calculate Efficiency of Motor and Plot its contour graph
closs all
clear all
clc
%Constant values of Torque array
s=linspace(1,1000); %speed [rad/s]
t=linspace(1,250); %Torque [N.m]
%Constant values of Motor Losses
kc=0.2;
ki=0.008;
kw=0.00001;
Constant_loss=20;
%Creating Mesh
[S,T]=meshgrid(s,t);
Output_power=(S.*T); %Power=speed*torque
Cu_loss=(T.^2)*kc; %Copper loss
Fe_loss=S*ki; %Iron loss
Wind_loss=(S.^3)*kw; %Windage loss
In_power=Output_power+Cu_loss+Fe_loss+Wind_loss+Constant_loss;
z=Output_power./In_power;
%Plot the contour Graph for Efficiency
V=[0.70,0.80,0.85,0.90,0.91,0.92,0.925,0.93];
box off
grid off
contour(S,T,Z,V);
xlabel('Speed [rad/s]');
ylabel('Torque [N.m]');
title('Efficiency Contour of Electric Motor');
hold on
%Plot the contour Graph for Power Output
%plot 4kW and *kw
V=[4000,8000];
contour(S,T,Output_power,V)
shading interp
Idea behind the code:
While calculating the input ,the losses also need to take into consideration
The losses are iron losses,copper losses,windage losses.
Copper losses (Cu_loss) = Kc.T^2
Where Kc is the constant of copper loss
Iron losses (Fe_loss) = Ki.w
Where Ki is the constant of iron loss,This varies with speed.
Windage losses (Win_loss) = Kw.W^3
Where Kw is the constant of windage loss,It depends on the size and shape of the motor.
Constant losses (Const_loss) = 20
Total losses = Kc.T^2+Ki.w+Kw.W^3+20
Variable z is the efficiency points we are giving,Efficiency is the ratio of output power to input power
Output Plots:
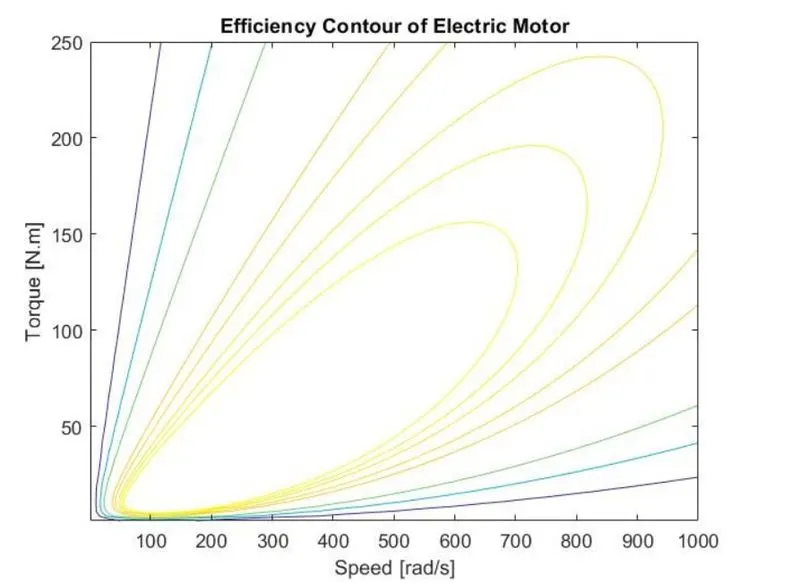
Fig.Contour Graph For Efficiency
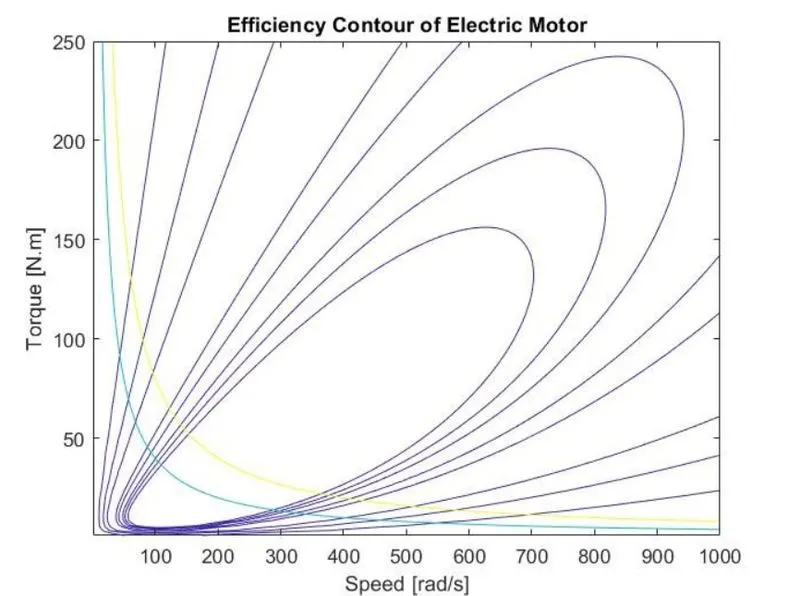
Fig.Contour Graph For Efficiency Showing The Power Output Of 4KW & 8KW