Week-11 Challenge: Braking
WEEK – 11
Q1. For a defined driving cycle, calculate the energy required for braking.
We require some amount of power, which is used for accelerating the vehicle and also braking of vehicle. Here we consider the drive cycle which is predefined as FTP75 drive cycle.
Work done = kinetic energy = 0.5 m*v²
For calculating the energy, the formula is E = 0.5 m*v²
m = mass of the vehicle = 1000 kg
v = velocity of vehicle = Vf – vi (here the vehicle is decelerating from 100 to 0 speed so, Vf = final velocity = 100 kmph, vi = initial velocity = 0 kmph)
t = time required from 100 to 0 speed is = 10 sec
power required is p = E/t
p = (0.5*1000*(100*0.277) ²) / (10))
= 38.36 kw
Energy required for braking of vehicle from 100 to 0 speed in 10 sec os
E = 0.0106 kwhr
Energy required for braking of vehicle from 100 to 0 speed in 1 sec is
E = 0.106 kwhr
Q2. Why electric motor can’t develop braking torque at high speed similar to starting? How electric and mechanical brakes are coordinated?
Regenerative braking:
Regenerative braking takes place whenever the speed of the motor exceeds the synchronous speed. The braking method is called regenerative braking because the motor works as generator and supply itself is given power from the load i.e.., motors. The main criteria for the regenerative braking is that the rotor has to rotate at a speed higher than synchronous speed, only then the motor will act as a generator and the direction of the current flow through the circuit and direction of the torque reverses and braking takes place.
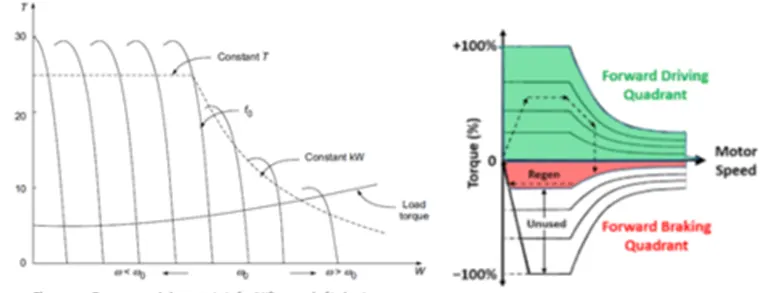
This braking systems for electric vehicles enable the range of the vehicle to be extended, but experience has indicated that the benefits are not always as great as might be expected because of inefficiencies in the power conversion processes. Extra mass and cost can often combine to limit the financial viability of a regenerative braking system. To measure the efficiency of a regenerative braking system, the Tata Ace Electric Vehicle has been tested on a hub-mounted chassis dynamometer, and instrumented to enable calculations for plug-to-wheel efficiency and total range (compared to the same vehicle with little or no regenerative braking).
Previously the Tata Ace EV has been tested on the road to optimise the regenerative braking settings for energy recovery. The vehicle’s motor controller allows the field map of the motor to be adjusted, giving full control over the deceleration of the vehicle when the accelerator pedal is released (and subsequent levels of recovered energy). By mounting the vehicle to a calibrated dynamometer, these settings can be validated by monitoring range and efficiency under controlled conditions.
Coordination control strategy for Mode switch in braking:
According to whether or not the hydraulic braking system is involved in braking, the braking mode-switch type is divided into two categories. Braking mode-switch coordination control strategies are developed for different braking mode switch types.
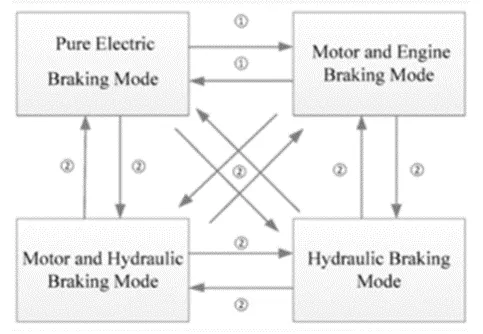
- Braking mode switch without hydraulic braking system participation. In this type of mode switching, it is necessary to control the engagement of the clutch and the change rate of the motor torque. Thus, the fluctuation caused by mode switch can be reduced.
- The braking mode switch with hydraulic braking system participation. Due to the different dynamic response characteristics of the motor and the hydraulic braking system, this switch mode is difficult to coordinate. The idea of coordinating control is to take full advantages of control the characteristics of the braking system. The hydraulic system can provide large and stable torque, and the motor braking system’s torque response is quick and accurate, reducing the fluctuation.
Coordination control strategy of type one:
In this type of mode, the motor braking torque and the engine drag resistance torque, transmitted by clutch II, are the main sources of the braking torque fluctuations. Therefore, the braking torque fluctuation is coordinated by controlling the change rate of the clutch hold-down force and motor brake force.
Coordination control strategy of type two:
The dynamic response of the hydraulic braking system is low and stable while the response of the motor braking is fast and accurate. The hydraulic brake system has been developed for a long time, its technology is mature and stable, and its dynamic response characteristics have been well researched. Therefore, in order to make full use characteristics of the motor and the hydraulic braking system, the coordinated control process of braking mode switch is divided into two stages: this achieved by modifying the target braking torque.
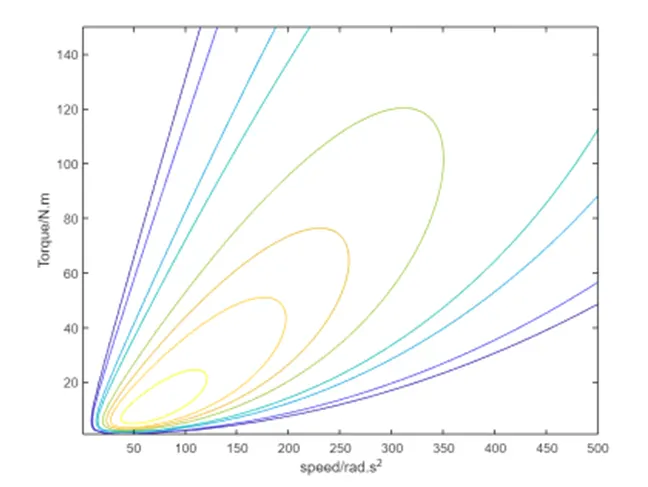
Q3. Make a MATLAB program which plots contour of given motor speed, torque and efficiency values. Attach the code as a .m file attach a screenshot of all the plots.
Copper losses = I²R
Where the armature resistance and torque is proportional to current, the copper losses can be considered as
Copper losses:
Ke*T²
Iron losses are nothing but magnetic losses, which is denoted by
Iron losses:
Ki*ω
Windage losses is the mechanical or friction of windage losses. This is based on size of shape of motor and the amount of windage losses that the motor is going to experiences.
Windage losses:
Kw*ω³
Total losses:
Ke*T² + Ki*ω + Kw*ω³ + C
All the motors are model as per the above equation of losses.
MATLAB program:
% plot effeciency contour sor electric motors
% let x-axis denote the speed of the motor w
% y-axis torque T
x=linspace(1,500);
y=linspace(1,150);
%motor loss constants
kc=0.5;
ki=0.004;
kw=0.00012;
constloss=15;
%making mesh
[x,y]=meshgrid(x,y);
outputpow=(x.*y);
B=(y.^2)*kc;
C=x*ki;
D=(x.^3)*kw;
inputpow=outputpow+B+C+D+constloss
z=outputpow./inputpow;
v=[0.6,0.63,0.7,0.725,0.775,0.8,0.82,0.85,0.9,0.925,0.95,0.99];
box off
grid off
contour(x,y,z,v);
xlabel('speed/rad.s^2')
ylabel('Torque/N.m');
plot: