Project 1 (Mini Project on Vehicle Direction Detection
AIM:
To create a Vehicle Direction Detection system with Requirements and using Matlab Simulink.
OBJECTIVE:
- Developing a model using Simulink and as well as the requirements
- Tag the requirements to the Simulink model, tagging the requirement 1 and requirements 2 to their corresponding subsystem.
- Choosing sample time as 0.01s
OVERVIEW:
Vehicle direction detection system is important and diverse features in Advanced Driver Assistance features. This particular feature identifies the direction of vehicle is basically identifying the direction the vehicle is taking based on the camera input.
Where, the camera reads the road signs and stores into the memory with unique values for left turn, right turn and straight drive. Depending on the direction it is taking, final indication is given to the driver as an indication if he is driving in the recommended direction or not. vehicle direction detection can be also coupled along side features like some other tracking systems to identify whether the vehicle is reaching its destination in an optimized manner. This feature can be also be used with lane detection, highway warning, etc.
OVERVIEW THROUGHT THE MODELLING:
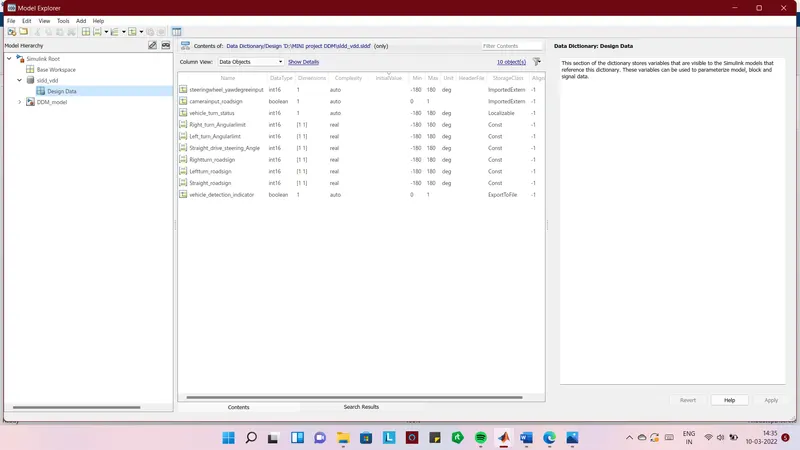
STEP 1: CREATING A SIMULINK DATA DICTIONARY
- Loading the signal and calibration values list into a data dictionary
- Click on the modelling on the top in the file menu > select link to data dictionary
- A pop-up box opens click new and create a file with a name as sldd_vdd is given as per my choice.
- Open the same modelling > select the drop down > next to model workspace data dictionary is created click on that.
- Click on saved sldd > select design data > and create manually required data in the given objectives.
SIMULINK DATA DICTIONARY:
STEP2: SOLVER SETTINGS
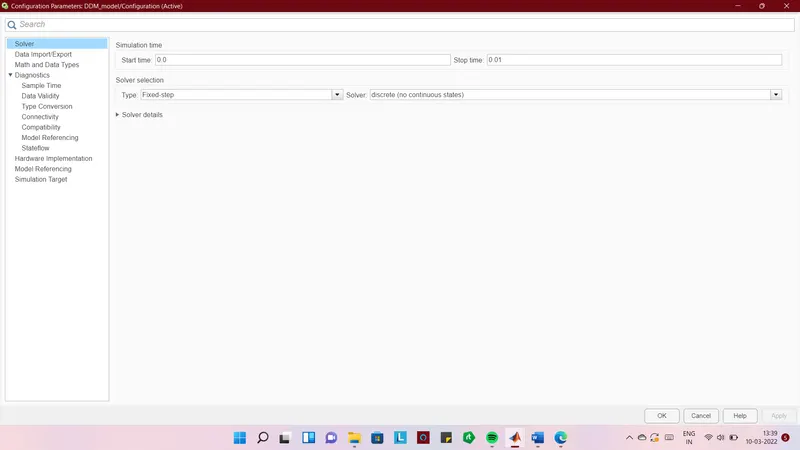
- Click on the modelling option in the file menu > click on the model properties > a pop-up box opens with many options click on solver
- Select solver type as fixed and solver as discrete
- Set the simulation stop time to 0.01s
STEP3: CREATING A SIMULINK MODEL
- Create a subsystem with two imports and one outport
- Also create two other subsystem tag as requirement 1 and requirement 2.
- Name the blocks and signals
- Connect the blocks and signal
- Name the model and save in the required file and name.
SIMULINK MODEL:
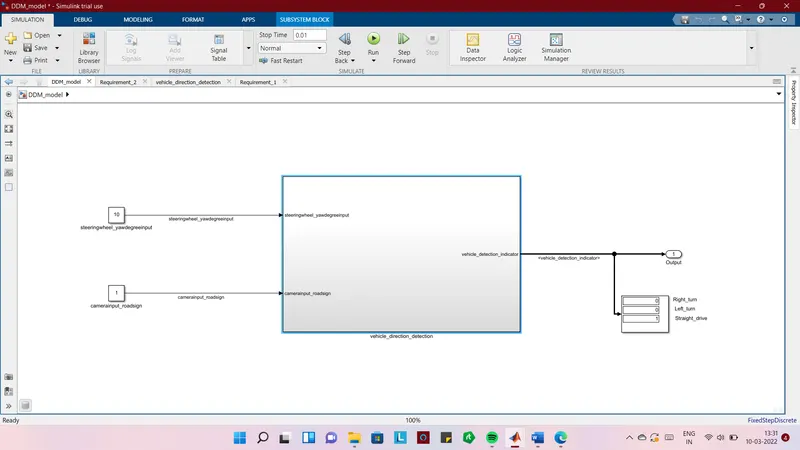
- This is model representation of the vehicle direction detection system
- Whereas, we have two inports and one outport connected to the subsystem
- The first inport is steeringwheel_yawdegreeinput and second import is camerainput_roadsign.
- The first inport deal with the vehicle movement and the second inport calibrates the road sign and send signals to the vehicle direction detection system
- The output of the system is the vehicle direction indicator, the chosen direction to turn will be indicated with 1 in the display block.
VEHICLE DETECTION DETECTOR:
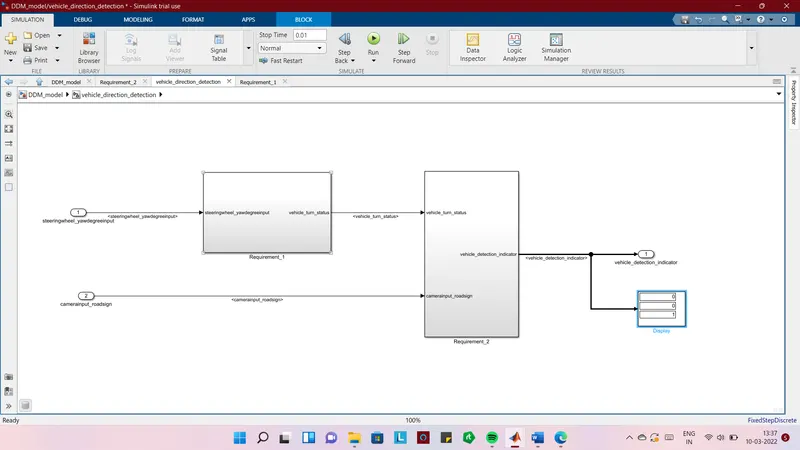
- This vehicle detection detector subsystem is designed as per the objectives given
- We have the two subsystems as requirement 1 and requirement 2
- The first inport is steeringwheel_yawdegreeinput and second import is camerainput_roadsign.
- And finally, the output is Vehicle detection detector
REQUIREMENT 1:
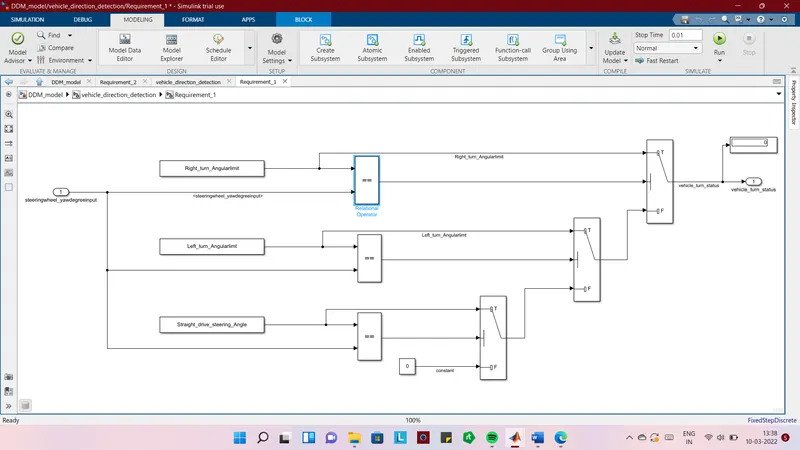
- Steeringwheel_yawdegreeinput is the input for this system
- This is compared against 3 angular values, one each for the left turn, right turn, and straight drive to say which specific direction the steering wheel is turning towards
- Using constant blocks, relational operators and switch block to create this system
- Keep this requirement in a subsystem and output of this requirement is a local signal
REQUIREMENT 2:
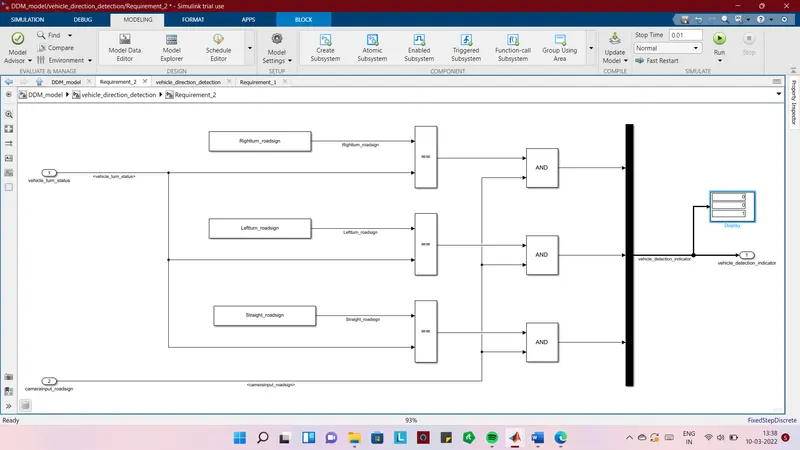
- The input signal for this requirement is from the local signal output of requirement 1 and an input signal from the camera which, confirms the occurrence of a road sign.
- The first input is vehicle_turn_status and the second input are camerainput_roadsign.
- The vehicle_turn_status value is compared against the three calibration values (Rightturn_roadsign, Leftturn_roadsign and straight_roadsign) if each of them is found equal, then each of the three correspond output is compared against the camera input signal
- At final the output of vehicle_detection_indicator is shown in the display block
STEP 4: MODEL ADVISOR CHECK
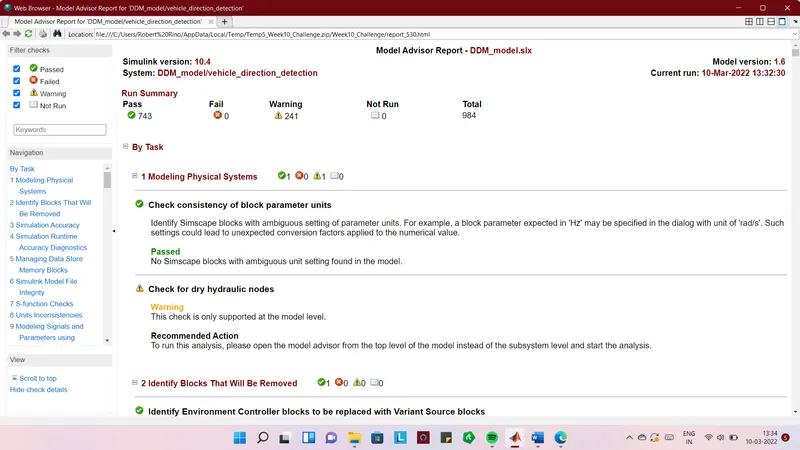
- Click on the modelling option on the file menu
- Select the model advisor
- Click on system selector > vehicle_derection_detector > click ok
- Click on the by task box option > click run the selected check
- After the run > click on Generate report
OUTPUT:
- Run the Simulink model
- To find the concept and working of the system use constant blocks as the imports for the model
- Give values to the constant blocks and the output will be shown in the display block
- Whereas, the camera reads the road signs and stores into its memory with unique values for the left turn, right turn and straight drive
RESULT:
Thus, the modelling of the Vehicle Direction Detection system is completed and the output is verified successfully.