Week-11 Challenge: Braking
Aim: Explanation about Braking, Electric and Mechanical, Braking and Motor Speed - Torque Contour Efficiency Plot.
Objectives:
- For a defined driving cycle, calculate the energy required for braking.
- Why electric motor can’t develop braking torque at high speed similar to starting? How electric and mechanical brakes are coordinated?
- Make a MATLAB program which plots contour of given motor speed, torque and efficiency values. Attach the code as a .m file attach a screenshot of all the plots.
Study 1: Energy required for braking
Define driving cycle:
A driving cycle is a series of data point representing the speed of a vehicle Vs time. Driving cycles are produced to assess the performance of vehicles in various ways, including fuel consumption and pollutant emissions.
Energy required for braking
Braking -: Braking is a condition to slow down or stops a moving vehicle as required. There are several techniques to apply brakes, which can be mechanical or electrical. The consumed kinetic Energy can be derived as following equation:
Braking Energy = (1/2)*m*v^2
where,
Braking Energy is the kinetic energy in of Joule.
m= Total Mass of the Vehicle(Vehicle Mass +Pay Load) in unit of Kg.
v= (Initial Velocity- final Velocity) in unit m/s.
For Example if initial speed of a vehicle is 20m/s and final speed is 10m/s. The mass of the vehicle is 500 kg. Then required Kinetic energy for Braking is
BE = (1/2)*500*(20-10)^2
= 25000J
= 25 KJ
Here for a Drive cycle was created by using excel sheet and the representation of that is given below.
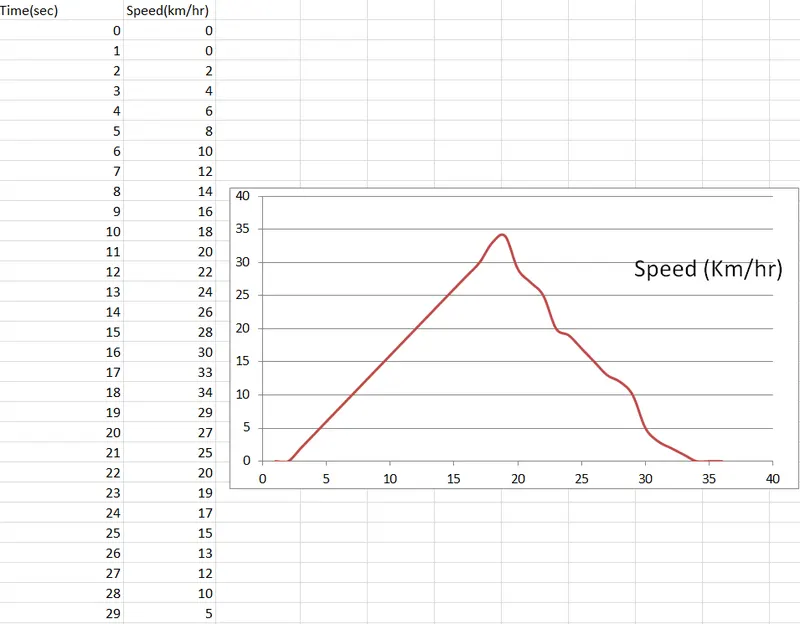
Here we ned to calculate the energy required for braking. So the deceleration situation is taken. Vehicle took 7 second to come to rest. By the help of the another excel sheet, we can calculate the energy or braking and it is given below.
Required assumption are also considered.
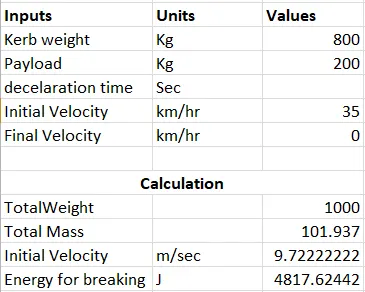
So for the considered condition, the braking energy is 4.8 KJ.
Study 2:
Electric Motor Braking
Electric motor can't develope braking torque at high speed similar to starting, because braking torque is applied in the opposite direction of the rotation.
We can use a mechanical brake to produce a braking torque. We can also do it electrically.
Regenerative braking:
It is a form of braking in which the kinetic energy of the motor is returned to the power supply system.
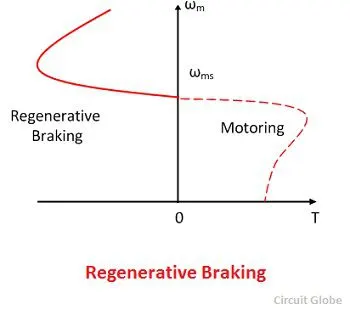
Fig. Regenerative Braking
- Regenerative braking take place whenever the speed of the motor exceeds the synchronous speed.
- This braking method is called regenerative braking because here the motor works as generator and supply itself is given power from the load, i.e. motors.
- The main criteria for regenrative braking is that the rotor has to rotate at a speed higher than synchronous speed, only then the motor will act as a generator and the direction of the current flow through the circuit and direction of the torque reverses and braking takes place.
- Sometimes after accelerating you can't reach the maximum torque.
- The reason is that no matter how much the current loop wants to increases current (proportional to the torque) by increasing the PWM duty cycle of the power stage, the Vmotor is too close to Vbemf and therefore current can't increases more.
- This situation does not occure at the beginning of an acceleration because most of the torque is used to increases the kinetic energy of the load (and motor).
- But when the speed is already high and no extra load is applied it is not possible to increases the torque.
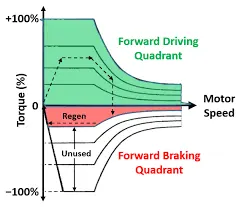
Fig. Acceleration Torque VS Deceleration Torque
- Peak acceleration Torque and Peak Deceleration torque are not equal for Electric Vehicle Motor.
- So the peak torque during acceleration and the peak torque during deceleration or braking are not equal.
- Acceleration is usually higher, at low speed we get higher Torque but high speed the value of the torque gets lower.
- So we cannot say that the which is producing 7Nm Torque for Accelerating can also produce 7Nm of Braking Torque.
- So beacause we operating the motor in field weakeninig region or we are operating the motor above base speed we must know that the torque is compromised or the Torque value is lower.
- So Electric motor cannot be develop braking torque at high speed similar to stating, because Braking torque of an EV motor is not as high as the acceleration Torque.
- Therefore Regenerative braking is cannot happen so effective that we can get all the power back to the battery.
Co-ordination of Electric and Mechanical Brake:
In an electric motor the Total Brake Distribution is in two aspcts which are Electrical Break which is called as Regenerative Brake and Mechanical Brake or Classical Brake with hydraulic cylindrical system
Brake Force distribution must be uniform, if the Regenrative braking power requirement is more thn the charging limit of the battery or more than regenrative capacity of the machine we must apply Mechanical rakes as well.
In practice case the combination of these two is applid.so usually it is combined response of Mechanical brake and Regenerative brake.
The reason for how these brake force are combined, that perticular phenomena is called Brake Control Strategies. There are two Brake Control Strategies, which are
Series - In case of series we apply Mechanical Brake and Regenerative Electric Brake one after another. We can apply only one brake strategy at a time either apply Regenerative or apply Mechanical brake.
The Series Brake Control Strategy has further classification, that is based on whether we want comfort of driver or Brake behaviour compared to energy efficiency.
Parallel - In case of Parallel we apply both brakes simultaneously. This particular Parallel Braking is going to happen both at a time.
Electric Driven Intelligent Brake(EDIB) - A combination of Hydrulic brake or Mechanical brake along with a Regenerative brake. It is parallel braking technique. The Cntrol criteria such that at low speed use regenerative braking higher and at high speed or during initial braking period we actually combine the both.
Study -3: Making contour
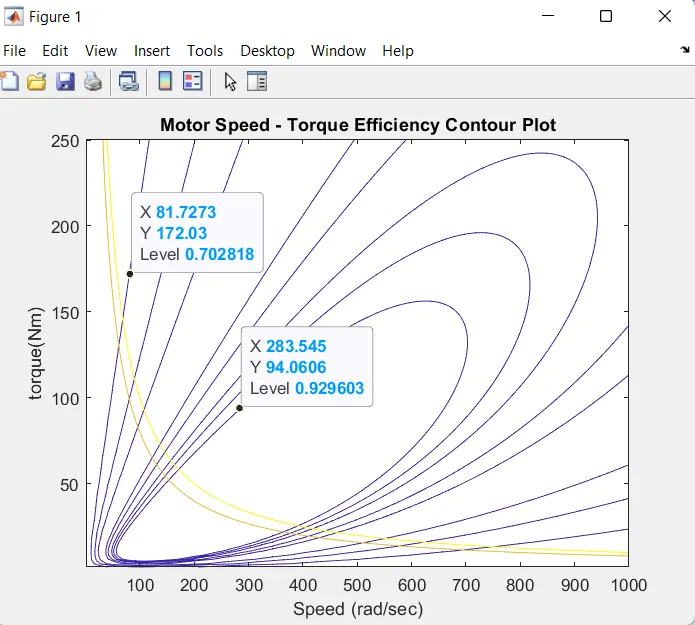
Now, we have to make a MATLAB programme which plots contour pf given motor speed, torque and efficiency values. The code is given below.
% Plotting efficiency Contour for Electric Motor
% Input of Speed and Torque
close all
clear
clc
x=linspace(1,1000);
y=linspace(1,250);
% Losses
kc=0.2;
ki=0.008;
kw=0.00001;
conL=20;
% Meshing
[X,Y]=meshgrid(x,y);
% calculating Power
outputpower=(X.*Y);
% Calculating losses
%copper loss
Cu=(Y.^2)*kc;
% Iron loss
Fe=X*ki;
% Windage loss
W=(X.^3) * kw;
Inputpower=outputpower+Cu+Fe+W+conL;
Z=outputpower./Inputpower;
% Now set the Efficiency to plot contour
V=[0.70,0.80,0.85,0.90,0.91,0.92,0.925,0.93];
box off
grid off
contour(X,Y,Z,V)
xlabel('Speed (rad/sec)')
ylabel('torque(Nm)')
title('Motor Speed - Torque Efficiency Contour Plot')
hold on
% Now plot a contour of power output
% Additionally plotting contour of 8kw and 10kw
V=[8000,10000];
contour(X,Y,outputpower,V)
- First of all range for the plotswas defined as array by linspace command.Then the required constants for calculations were given.
- All the equations for the calculation were given order. Contour efficiency range was also specified.
- Colorbar command was used to get the plot in color bar.
- Surf command was used in efficiency plot.
- Label command and title commands were given for specifications.
- Result is obtained when the code as executed and the plots are represented below.
Output
Conclusion:
Energy for braking was calculated with a defined driving cycle. Electric motor characteristics and their relation with mechanical brakes were studied. A program for plotting contour of given motor speed, torque and efficiency values was also created.