Project
AIM: To study the system level simulation of an all terrain vehicle.
KEYWORD: CVT, Lookup table, Dashboard Baja ATV.
SOFTWARE: MATLAB, Simulink
OBJECTIVE:
1. Study the baja ATV model without dashboard.
2. Study the baja ATV model with dashboard.
3. Study the baja ATV model using lookup table without dashboard.
4. Study the baja ATV model using lookup table without dashboard.
INTRODUCTION: Transmission, which transmit the power from engine to the wheels through the shafts. It consists of 4 types mainly,
1.Manual Transmission
2.Continuous Variable Transmission
3.Semi-Automatic Transmission
4.Automatic Transmission
A continuous variable transmission or CVT, is a type of automatic transmission that provides the more useable power,better fuel economy and asmoother driving experience than a traditional automatic transmission. The CVT is a system that makes it possible to vary stepless the transmission ratio without interruption of the torque flow.Therefore an infinite ratios (between minimum and maximum value) are possible. It is an automatic, single speed and gearless transmission that can shift throgh the infinite number of gear ratios. This ability to seamlessly shift through these different gears provides a number of benifits including extramly smooth shift and exceptional fuel eonomy. A CVT draws top engine power from a small engine, which gives a drivers quicker accelaration than standard automatic transmissions. Because of their greater ability to controlthe engine speed range, CVTs produce fewer emissions. CVTs are also lighter weight than traditional automatic transmissions.
STUDY-1:
1. Study the baja ATV model without dashboard.
By using simulink model of CVT consists of Signal builder, Generic engine, motion sensors, vehicle transmission, vehicle body, tyres and solver configuration blocks etc.,as shown in fig.1. The CVT subsystem includes Transmission block, input and output shaft inertia and motion sensors as shown in fig.2. The vehicle body subsystem includes vehicle body block, double drum break and tyres as shown in fig.3. The initial engine speed is given as 2100rpm, mechanical rotation for driven pully and driver pully as 0.8 and 0.7 respectively. The mass of the vehicle as 250kg and 2 axles which connects 4 wheels accordingly.
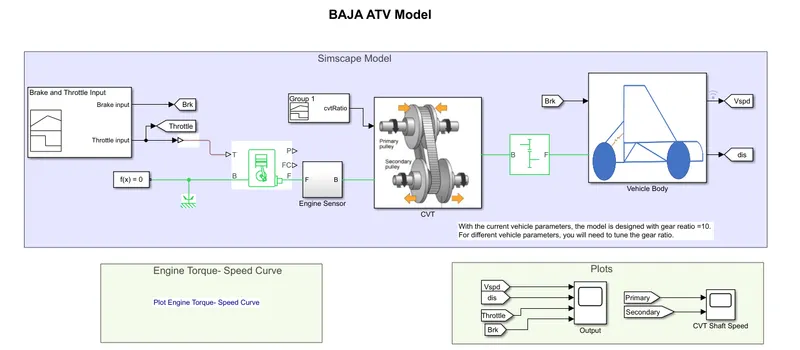
Figure-1
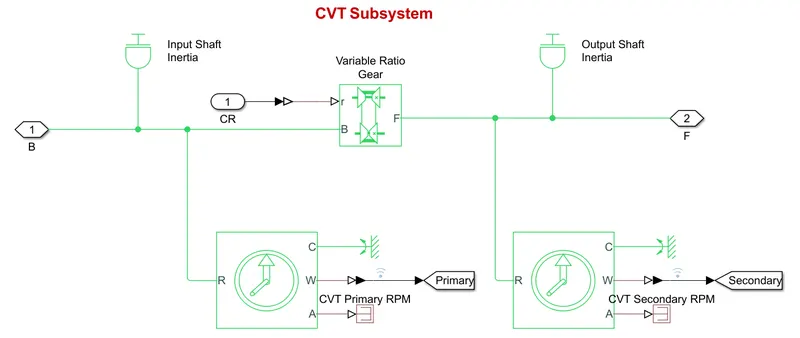
Figure-2
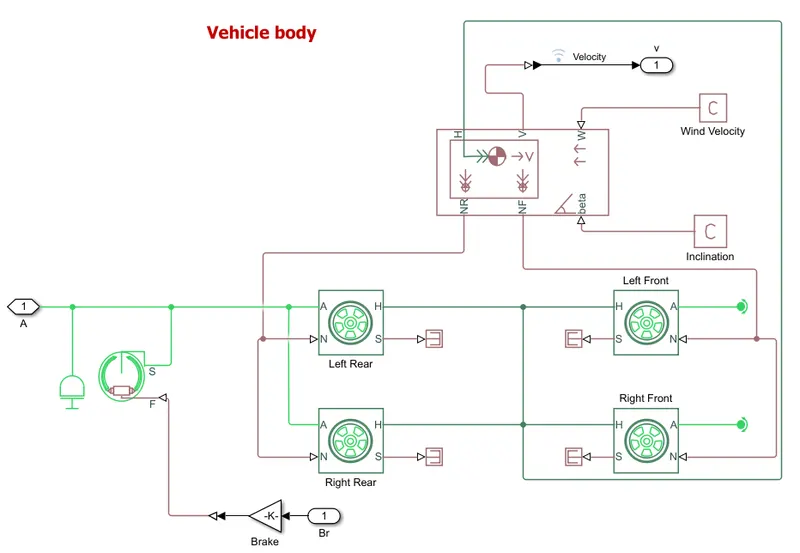
Figure-3
The signal builder is used as input for brake, throttle and gear ratio. Break input is maintained as o for overall simulation. The throttle input is given as 0.3 for 20 secs and increases to 1 for overall simulation The throttle valve is mainly to control the flow or amount of fuel into the engine, if the throttle valve increases the flow increases to the IC engine which in turn increses the power of the engine. THe gear ratio is maintained as 2.3 for 5 secs and linearly decreases to 1.8 and maintained constant for overall simulation in figure (4 and 5).
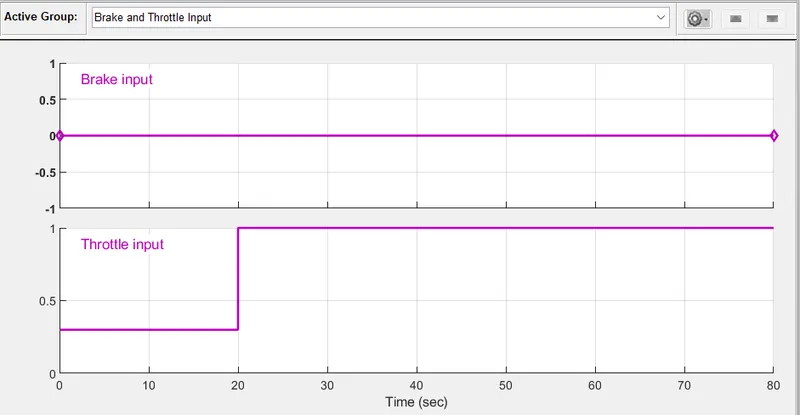
Figure-4
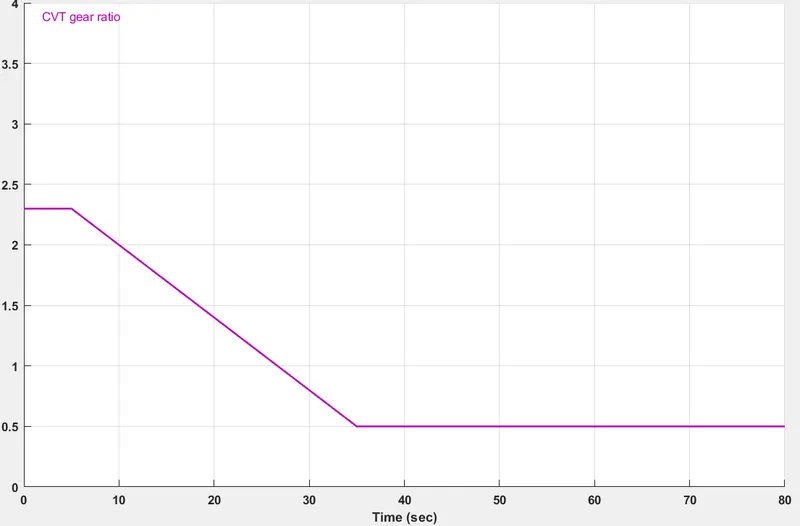
Figure-5
Study-2
2. Study the baja ATV model with dashboard.
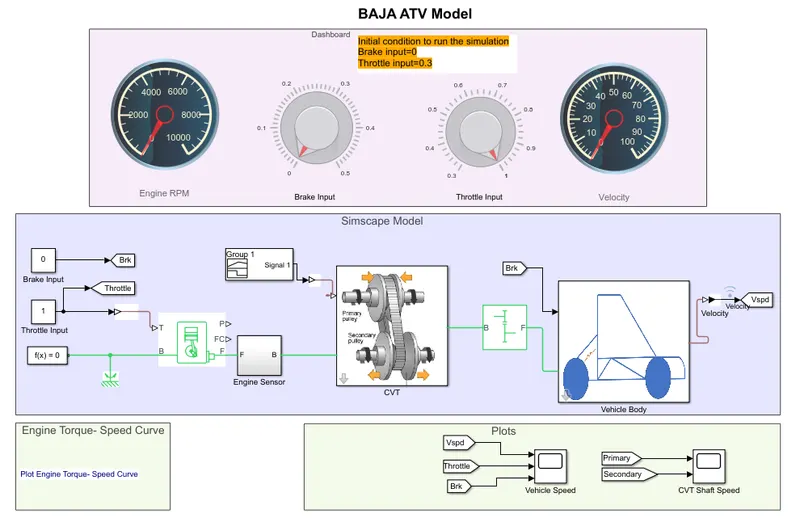
Figure-6
The above figure shows 'BAJA ATV with dashboard' model which consists throttle meter and brake input in the dashboard instead of giving input through signal builder. Rest of the blocks and subsystem are comman in the above baja atv model with dashboard as shown in figure 2 & figure 3. The main cancept of using dashboard is study the result by varying the input of break and throttle, which shows that the velocity and speed of the engine. The gear ratio is maintained as 2.3 for 5 secs and linearly decreases to 1.8 and maintained constant for overall simulation as shown in figure 5. As the break input varies from 0 - 0.5, the velocity and speed decreases accordingly. By increasing the throttle the velocity and speed of the engine & shaft increases.
Study-3
3. Study the baja ATV model using lookup table without dashboard.
By using simulink model of CVT consists of Step time, Generic engine, motion sensors, vehicle transmission, vehicle body, tyres and solver configuration blocks etc.,as shown in fig.7. The CVT subsystem includes the Lookup Table, Transmission block, input and output shaft inertia and motion sensors as shown in figure 8. The vehicle body subsystem includes vehicle body block, double drum break and tyres as shown in figure 9. The initial engine speed is given as 2100rpm, mechanical rotation for driven pully and driver pully as 0.8 and 0.7 respectively. The mass of the vehicle as 250kg and 2 axles which connects 4 wheels accordingly.
A lookup table is an array of data that mass of inpu values to output values, thereby approximating a mathematical function. Given a set of input values, a lookup operation retrieves the corresponding output values from the table. If the lookup table does not explicity define input values, simulink can estimate an output value using interpolation, extrapolation or rounding, where:
- A interpolation is a process for estimating values that lie between known data points.
- A interpolation is a process for estimating values that lie beyond the range of known data points.
- A roundind is a process for approximating a value of altering its digit according to a known rule.
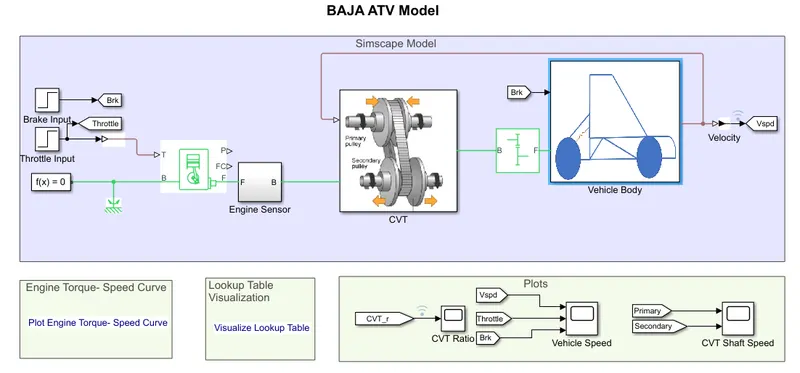
Figure-7
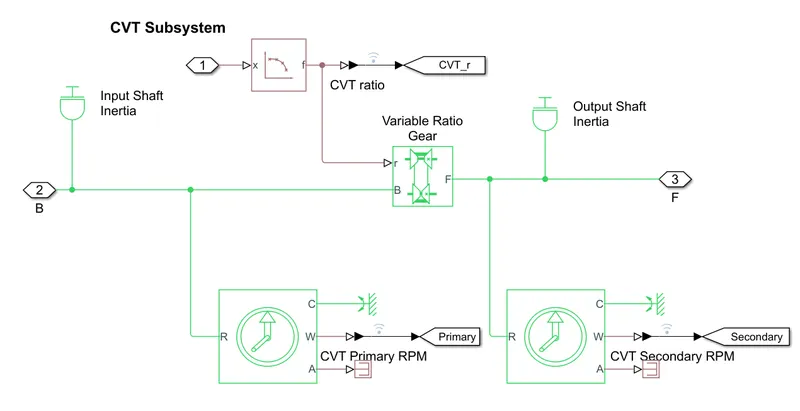
Figure-8
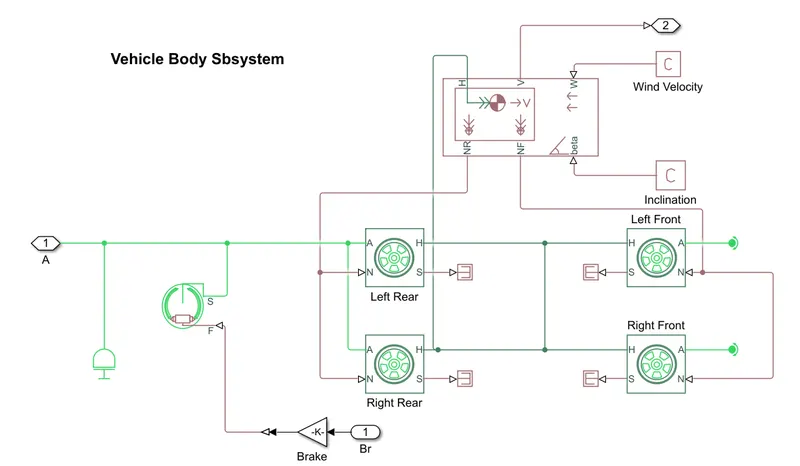
Figure-9
The break input and throttle input is given by step time, which dpends on run time and varries accordingly. By using lookup table for gear ratiowhich takes as input to the CVT and works according to the input gear ratio and obtained the output. This methos is very effective which can avoid the unusal torque at the certain speed and very easy to achieve greater velocity and engine speed. It works as closed loop when the input is given by look up table. The simulink get the input values from lookup table and obtained the result according to the input values of gear ratio. The gear ratio varies from 2.3 o 1.8 as taken as input and output interms of velocity. The maximum velocity reached as 57 kmph approximately.
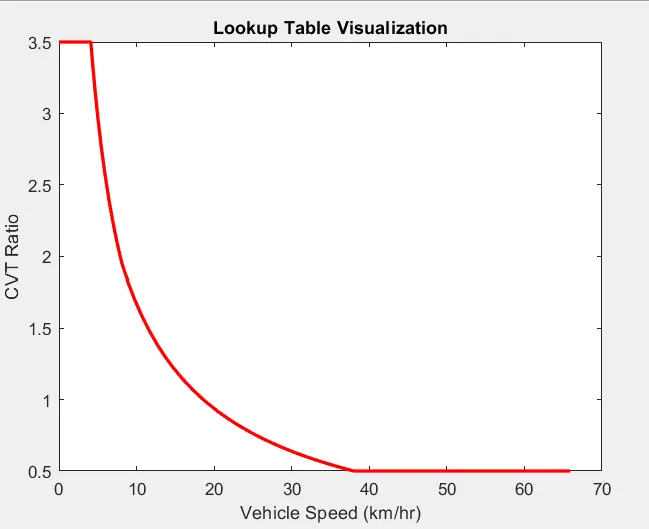
Figure-10
Study-4
4. Study the baja ATV model using lookup table without dashboard.
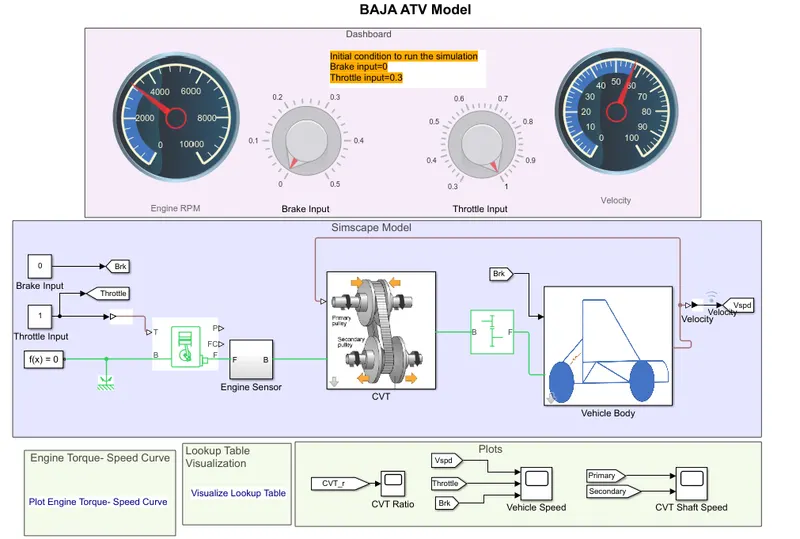
Figure-11
The above figure shows 'BAJA ATV with dashboard' model using lookup table which consists throttle meter and brake input in the dashboard and indicate as constant block. Rest of the blocks and subsystem are comman in the above baja atv model without dashboard as shown in figure 8 & figure 9. The main cancept of using dashboard is study the result by varying the input of break and throttle, which shows that the velocity and speed of the engine. The gear ratio is given by lookup table and obtain the result according to the lookup table. As the break input varies from 0 - 0.5, the velocity and speed decreasesaccordingly which inturn the gear ratioalso decreases. By increasing the throttle, the velocity and speed of the engine & shaft increases. The transmission as primary pully and secondary pully, in which the redius of primary pully increases by compacting and the redius of seondar pully decreses. As the gear ratio varies, torque also varies. gear ratio is directly proportional to the torque, the speed and velocity is decreses.
Output :
Study1 : Variations of Velocity and Shaft Speed
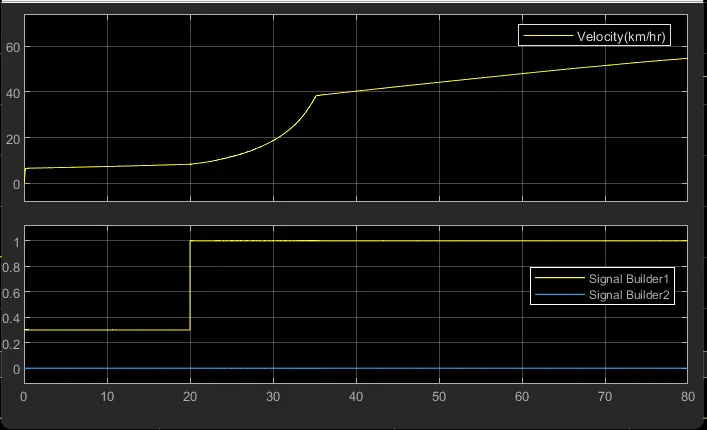
Figure-12
In the above figure, the break is maintained as constant and increase in throttle which shows increase in velociy. The flow of fuel is increases when the throttle increases from 0.3 to 1, thus the power in the engine increases. The torque Reaches apporximetly 7N-m at 1.8 gear ratio, Which Define that gear ratio is directly proportional to the torque. By this gear ratio, The speed & Velocity can achieve maximum.
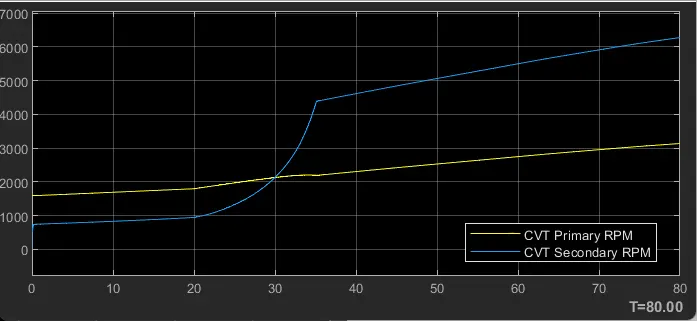
Figure 13 :
In the above figure, the primary shaft reaches high speed and seondary shaft as low rotational speed because te redius of the primary shaft as more than the secondery shaft, the speed is directly the proportional to the redius of the shaft. As the redius increses the speed of the shaft also increases.
Study 2 : Variations of Velocity and Shaft Speed
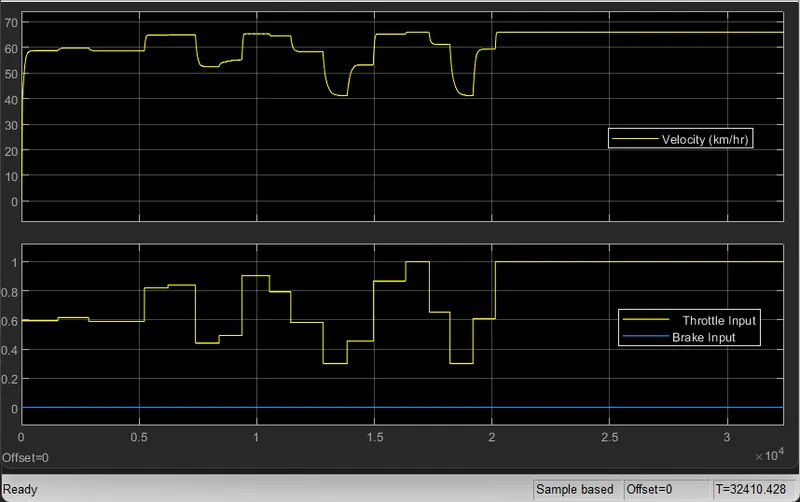
Figure -14
In the above figure, the velocity of the vehicle is maintained as constant for constant throttle value as 0.3 and varing by increasing the value of throttle which increases the velocity of vehicle. By the increasing the break input, the velocity of the vehicle decreasing accordingly which shown in figure 14.
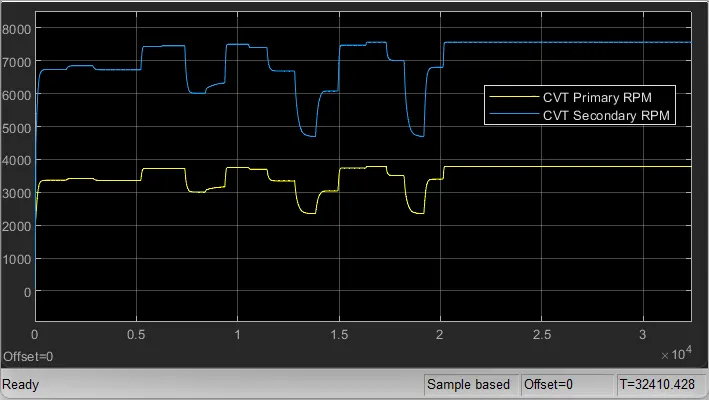
Figure-15
In the above figure the primary shaft speed increases by increasing throttle and decreasing by increasing break input value, which defines that the throttle can flow more amont of fuel which increases the power of the engine and similar to the secondary shaft. The redius of the primary shaft as more than the secondary shaft, the speed is direcly proportional to the redius of the shaft. As the redius increases the speed of the shaft also increases.
Study 3 : Variations of Velocity and Shaft Speed
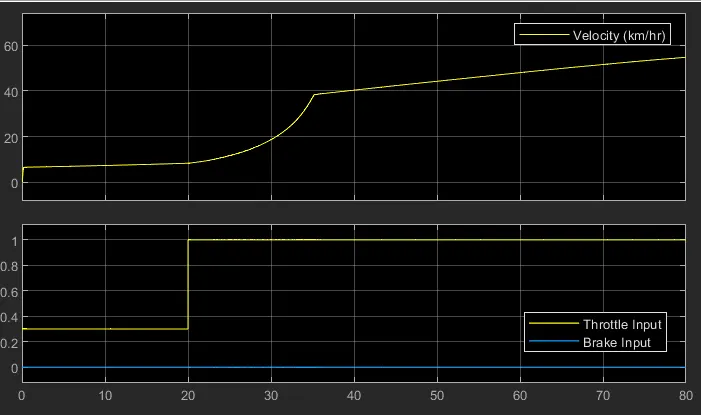
Figure-16
In the above figure, the break is maintained as constant and increases in throttle which shows increase in velociy. The flow of fuel is increases when the throttle increases from 0.3 to 1, thus the power in the engine increases. The torque Reaches apporximetly 7N-m at 1.8 gear ratio, Which Define that gear ratio is directly proportional to the torque. By this gear ratio, The speed & Velocity can achieve maximum.The gear ratio is assigned in lookup table and given as input to the simulink which reads every input value and obtain the result according to the input.
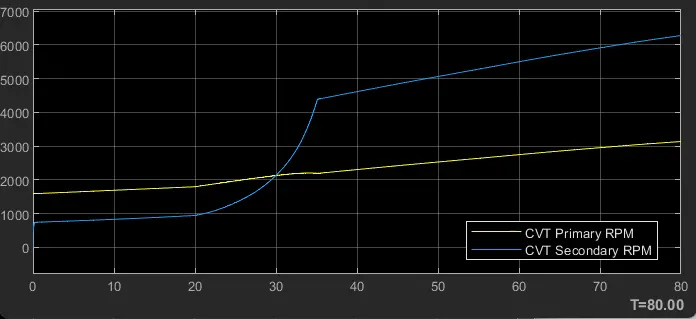
Figure-17
In the above figure the primary shaft speed increases by increasing throttle and decreasing by increasing break input value, which defines that the throttle can flow more amont of fuel which increases the power of the engine and similar to the secondary shaft. The redius of the primary shaft as more than the secondary shaft, the speed is direcly proportional to the redius of the shaft. As the redius increases the speed of the shaft also increases.
Study 4 : Variations of Velocity and Shaft Speed
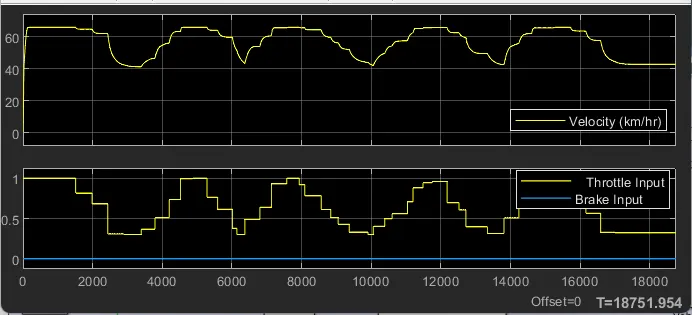
Figure-18
In the above figure , the velocity of the vehicle is maintained as constant for constant throttle value as 0.3 and varying by increasing the value of throttle which increases the velocity of vehicle. By increasing the break input, thevelocity of the vehicle decreasing accordingly which shown in figure 18. By using lookup table it works as a closed loop by recording the velocity value and we can get at any perticular value of gear ration which beyond the range or any random velue with in the range by using extrapolation and interpolation by look table.
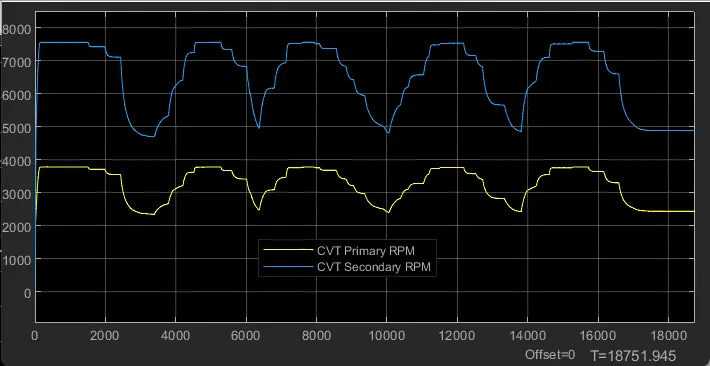
Figure-19
In the above figure the primary shaft speed increases by increasing throttle and decreasing by increasing break input value, which defines that the throttle can flow more amont of fuel which increases the power of the engine and similar to the secondary shaft. The redius of the primary shaft as more than the secondary shaft, the speed is direcly proportional to the redius of the shaft. As the redius increases the speed of the shaft also increases. The throttle value and the break input value can be varying in dashboard , so we can get perticular value for input.
Result:
1. As the throttle increases, the velocity also increases which inturn the power in the engine also increases.
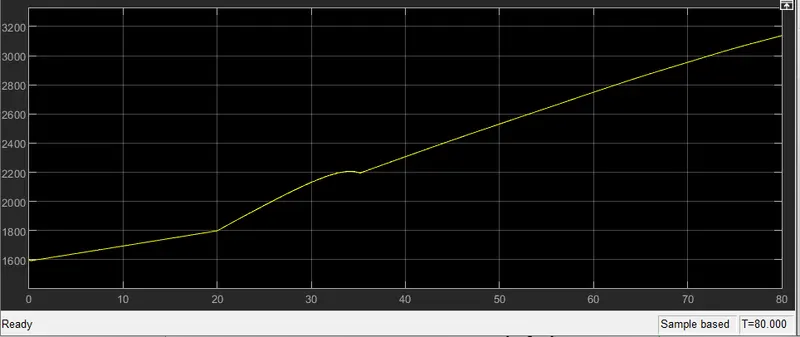
Figure-20
2. As the gear ratio increases, torque increases which inturn the velocity decreases.
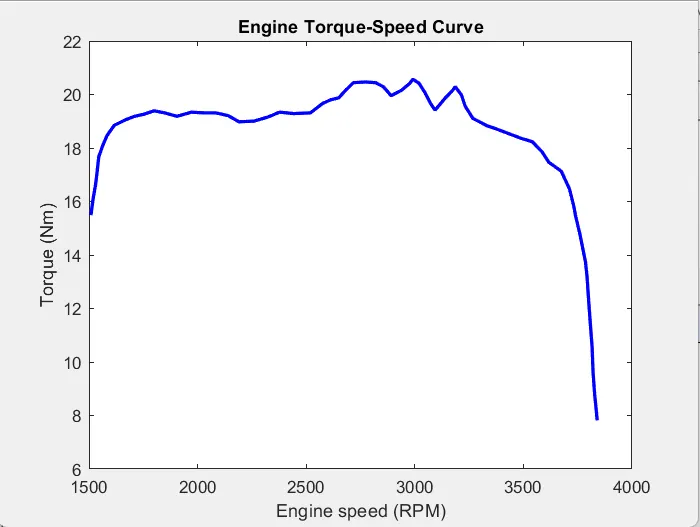
Figure-21
In the above figure, the torque is increasing by increas in engine speed. At perticular point torque is a deceasing when the gear ratio increases in order to achieve maximum velocity.
Figure-22
In the above figure, the velocity is varying with respect to gear ratio. For the higher gear ratio, the torque is more which decreases the velocity. By changing the high gear, the gear ratio become less parallely to the torque also less which can get high velocity.
3. With help of the lookup table, we can vary any input value and also get the output value by using interpolation and extrapolation method which the simulink can solve.