Week-11 Challenge: Braking
Question 2)
A. Why an electric motor can’t develop braking torque at a high speed similar to starting?
- Ans -
1. Peak torque during acceleration and peak torque during deacceleration are not equal we get some less torque while deaccelerating or breaking the vehicle.
2. Because while accelerating the vehicle, speed is low so ultimately we get the high torque but in case of decelerating we are already at high speed so when speed is high we are in the constant power region where torque developed is usually low as compared to constant torque region.
3. So that is why the regenerative breaking does not happen so effectively that we can get all the power back through regenerative breaking. There are also some parameter that affects the regeneration power, such as battery charging limitations as well as complexity in the power converter.
B. How electric and mechanical brakes are coordinated?
- Ans -
There are two types are breaking control strategies which are
1. Series Breaking :- In this breaking both breaks are not applied simultaneously instead one break is applied after another. so at a time, only one break is in actual functioning Regenerative breaking or Friction break.
2. Parallel Breaking :- In this breaking strategies both the breaks can be simultaneously applied.
For Example -
"Electric Driven Intelligent Brake" (EDIB) [NISSAN LEAD Vehicle]
The Electric Driven Intelligent Brake allows and controls optimization of the regenerative brake and regular friction brake. Electric Driven Intelligent Brake controls the regenerative brake and friction brake to support both of these requirements. Further, it also controls the reactive force from the pedal in order to unify the feeling when stepping down on the pedal and the sense of deceleration.
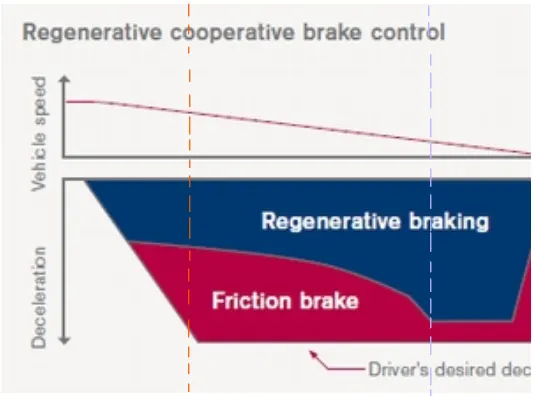
When the speed is high(orange line in above fig) then the contribution of friction break is more and when the speed becomes low(purple line in above fig) then the contribution of regenerative breaking increases. So we can say in the low-speed breaking we can maximum apply regenerative break and charge our battery in an efficient manner.
Question 3)
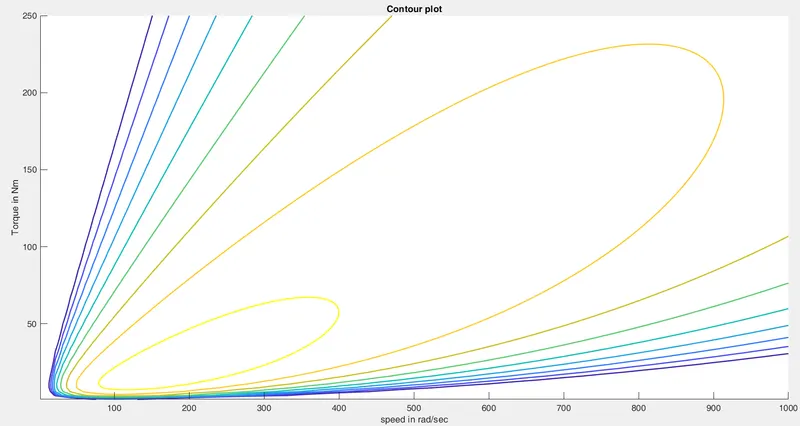
Make a MATLAB program that plots the contour of given motor speed, torque, and efficiency values. Attach the code as a .m file attach a screenshot of all the plots.
- Ans -
Given data taken from video no - 54
What are contour lines - Countour lines define the height for the 3rd element present in the 2D graph of XY plane.
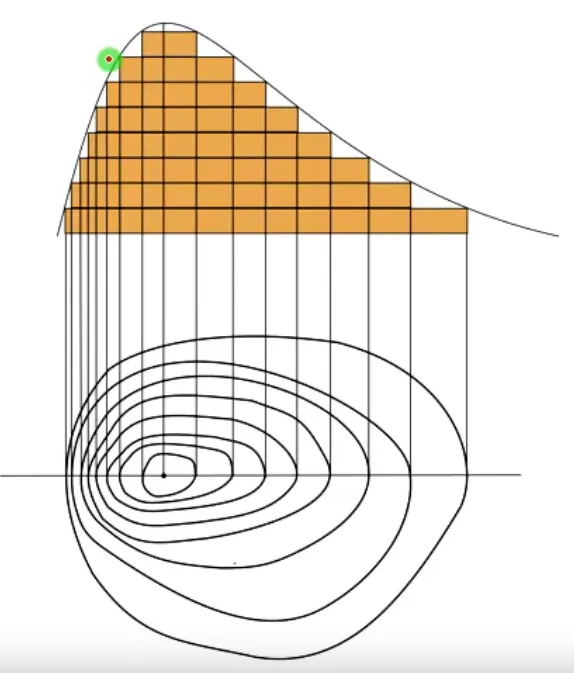
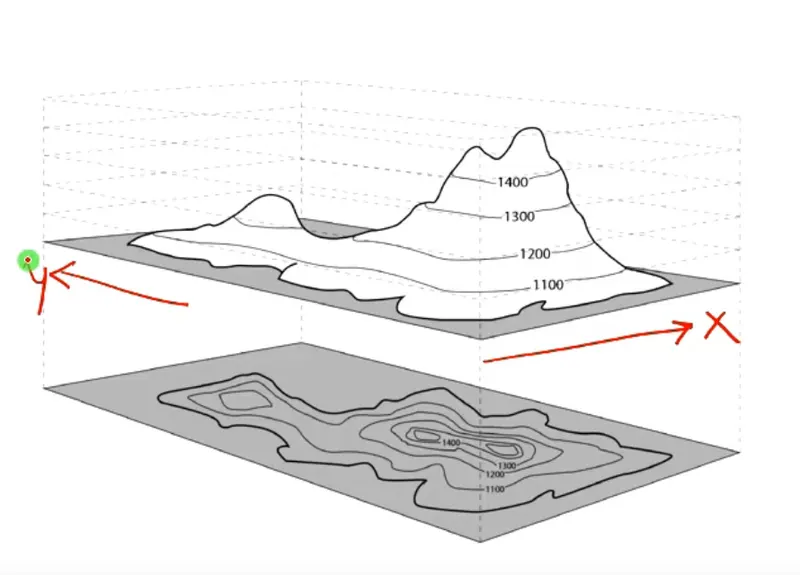
Given data - Kc (Copper loss) =0.2 , Kw (windage loss)=0.00001 ,Ki (Iron loss)= 0.08, Constant motor loss = 20
clc
clear all

speed  = linspace(1,1000);
torque = linspace(1,250);

%given data
kc = 0.2;      %const for copper loss
ki = 0.008;    %const for iron loss
kw = 0.00001; %const for windage loss
con= 20;       %constant loss of motor

%making mesh
[P, Q]    = meshgrid(speed,torque);

%for output power
out_power = P.*Q; %outputpower = speed * torque

%for input power
a = (Q.^2)*kc;   %coppper loss
b = (P)*ki;      %iron loss
c = (P.^3)*kw;   %windage loss
in_power  = a + b + c + con +out_power;

%to find out efficiency
efficiency = (out_power./in_power);

%contour will be ploted for this 10 points
v = linspace(0.75,0.97,10);

%plotting countour
box off
grid off
contour(P,Q,efficiency,v,"linewidth",1.5);
xlabel("speed in rad/sec");
ylabel("Torque in Nm");
title("Contour plot");
Counter Plot for different efficiencies.
Question 1)
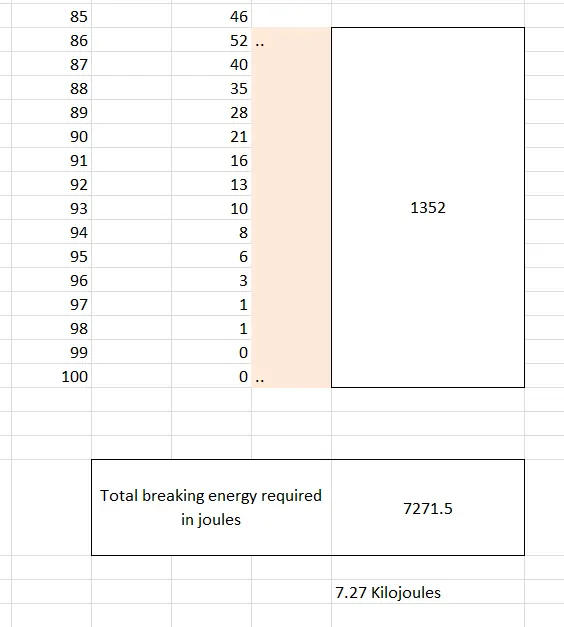
For a defined driving cycle, calculate the energy required for braking.
- Ans -
Duty cycle time period = 100sec
For simplicity mass of the vehicle is considered to be 1000Kg
Total Breaking Energy required = 7.27 kilojoules
breaking is considered only when there is deacceleration happens.