Week-11 Challenge: Braking
Aim:
- For a defined driving cycle, calculate the energy required for braking.
- Why electric motor can’t develop braking torque at high speed similar to starting? How electric and mechanical brakes are coordinated?
- Make a MATLAB program which plots contour of given motor speed, torque and efficiency values. Attach the code as a .m file attach a screenshot of all the plots.
1.For a defined driving cycle, calculate the energy required for braking.
braking energy:
- braking is a process in which the motion of a vehicle is restricted.
- when the vehicle is in motion, the kinetic energy of the vehicle is very high.
- to slow down the vehicle having high kinetic nergy, the application of brakes are applied.
- these brakes are used to convert the kinetic energy of the other form of energy.
- the main form of brakes are the mechanical brakes, which converts the kinetic energy into thermal energy and is released to the atmosphere.
- the kinetic energy of the vehicle is calcualated by using:
kinetic energy = `(1/2)*m*(v^2)`
where,
m = mass of the vehicle in kg
v = velocity of the vehicle in m/sec.
drive cycle data:
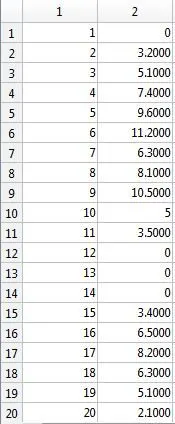
code for braking enrgy:
m = 300;                                           %mass of the vehcle in kg


t = drivecycle1(:,1);                              %time of the drive cycle
v = drivecycle1(:,2);                              %velocities of the vehcile

%calculating the breaking efficiency of the vehicle
for  i = (length(drivecycle1) -1)
    if v(i)>v(i+1)
        B_E(i) = 0.5*m*(v(i)-v(i+1))^2;
    end
end

%printing the total brakig energy
fprintf('total brake energy = %d kwh',sum(B_E));

%ploting time vs velocity plot
figure(1)
plot(t,v,'linewidth',2,'color','g');
grid on
xlabel('time in sec');
ylabel('velocity in (m/sec)')
title('drivecycle')
code explanation:
- mass of the vehicle is 300 kg
- from the drive cycle, the first column of the drive cycle is considered as time matrix.
- from the drive cycle the second column is considered as the velocity matrix.
- for loop is used to calculate the braking energy of the vehicle.
- the fprintf command is used to print the total braking energy.
- plot command is used to plot the time vs velocity.
results:
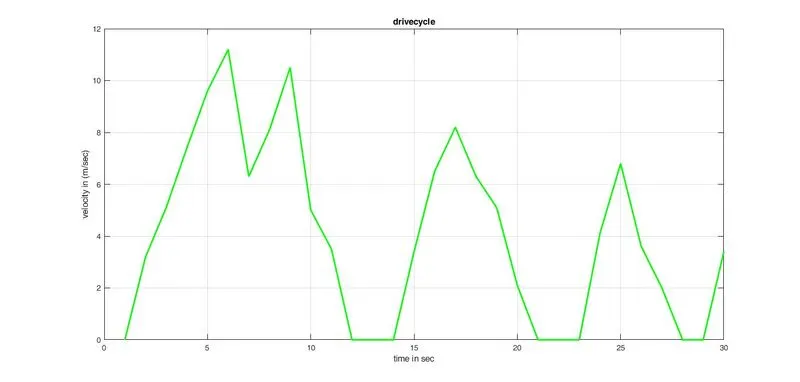
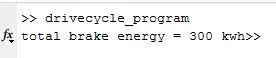
- the above plot gives the time vs velocity and the total braking energy of 300 kwh.
2.Why electric motor can’t develop braking torque at high speed similar to starting? How electric and mechanical brakes are coordinated?
Why electric motor can’t develop braking torque at high speed similar to starting?
- at the time of starting there will be initial load which the vehicle has to over come.
- for this the driver has to give more acceleration in the form of torque, which it has to over come the load of the vehicle.
- once it over come the load, the vehicle will start to move forward.
- when the speed increases, the torque is inversely proportional to the square root of the speed.
- so at higher speeds the torque will be less.
- so at higher speed the vehicle will not produce the braking torque at the starting.
mechanical brakes:
- the mechanical brakes are called as the frictional brakes, as the two surfaces are rubbed against each other and makes the vehicle to stop based upon the activation energy produced by the driver.
- there are 4 types of mechanical brakes:
- drum brake
- disc brake
- emergency brake
- anti-lock brakes.
hydralic brakes:
- these type of brakes are used when we want to stop the vehicle by using the activating cylinders.
- these brakes works on the principle of multiplying the force that is applied by the vehicle.
electrical brakes:
- these brakes are used to slow down the vehicle deperending upon the flus and torque.
- A convemtional braking system are Disc or drum type brakes which used the friction to slow or stop the vehicle.
- these type of brakes which can recharge the battery by using the eddy current which can develop the magnetic field.
- these magnetic field is used to charge the battery.
- by placing the electric motor in the reverse mode, which runs back ward direction.
- these moment creates an opposite direction to the vehicle moment.
- these makes the motor to work as a generter which produces the power to thebattery.
how electrical and mechanical brakes are co ordianted?
- the electric motor must be controlled to produce necessary amount of energy that meets the braking power which is required to decelerate the vehicle or stop the vehicle.
- this can be done by using the mechanical brakes and electrical brakes in two modes.
- series mode: in this mode, the brakes are applied in series manner. in this mode the mechanical brakes are applied first and the electrical brakes are applied second.
- parallel mode: in this mode, the brakes are applied in the parallel mode that means simulatniously.
- when the brakes are applied, the mechanical brakes bring the vehcile to the slow speeds, where the electrical motor operates in the reverse direction, which produces the edddy current which can charge the vehicle battery at the time of runnung.
- there are different type of braking can be done: plugging type, dynamic, regenerative braking.
3.Make a MATLAB program which plots contour of given motor speed, torque and efficiency values. Attach the code as a .m file attach a screenshot of all the plots.
- there are three different type of losses that are present in motor/;
- copper loss
- iron loss
- windage loss
clear all
close all
clc

w=linspace(1,1000);                   % speed in rpm
T=linspace(1,250);                    % torque in Nm

% motor loss constants.
kc=1.5;                               % For copper losses
ki=0.1;                               % For iron losses
kw=0.00001;                           % For windage losses
ConL=20;                              % For constant motor losses

[X,Y]=meshgrid(w,T);                  % Now make mesh

Output_power=(X.*Y);                  % Torque x speed = power
B=(Y.^2)*kc;                          % Copper losses
C=X*ki;                               % Iron losses
D=(X.^3)*kw;                          % Windage losses

Input_power = Output_power + B + C + D + ConL;
Z = Output_power./Input_power;

%plots
V=[0.5,0.6,0.7,0.75,0.8,0.85,0.88];
box off
grid off
contour(X,Y,Z,V);
xlabel('Speed/rad.s^-^1'), ylabel('Torque/N.m');
hold on
% Now plot a contour of the power output
% The array Output Power has
% already been calculated. We draw contours at
% 3 and 5 kW.
V=[3000,5000];
contour(X,Y,Output_power,V);
code explanation:
- clear all, close all, clc are used to close the windows and clear the work space and plots.
- A torque matrix and speed matrix are created using the linspace command.
- motor losses constants such as copper losses(kc), iron losses(Ki), windage losses(win), constant losses(con) are given.
- to get a contour plot a 2D matrix is required to plot which is created by mesh grid command.
- the output power and losses are calculated by the necessary formulas.
- the input power and the efficiency are calculated by using the formulas.
- the contour command is used to plot the necessary graphs based on the inputs that are related to the motor losses.
result:
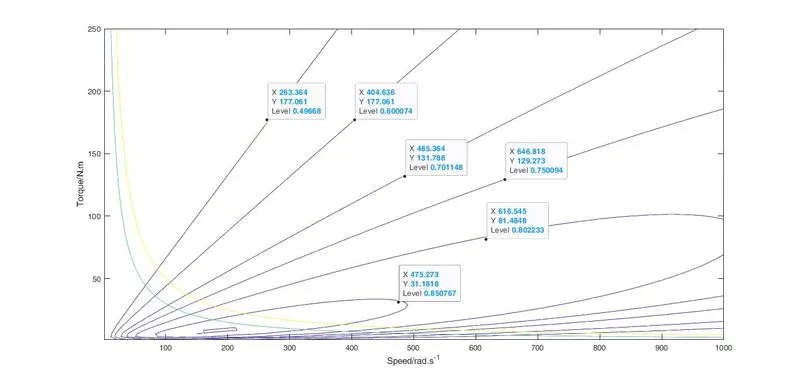
- the above graph, tells about the speed vs torque characteristics of the vehicle.
- the small contour is having the highest efficency of the vehicle.