Project - Position control of mass spring damper system
OBJECTIVE: Obtain the transfer function of a mass spring damper system and use it in the model. Add a PID controller to adjust the force on mass so that its position follows a reference signal.
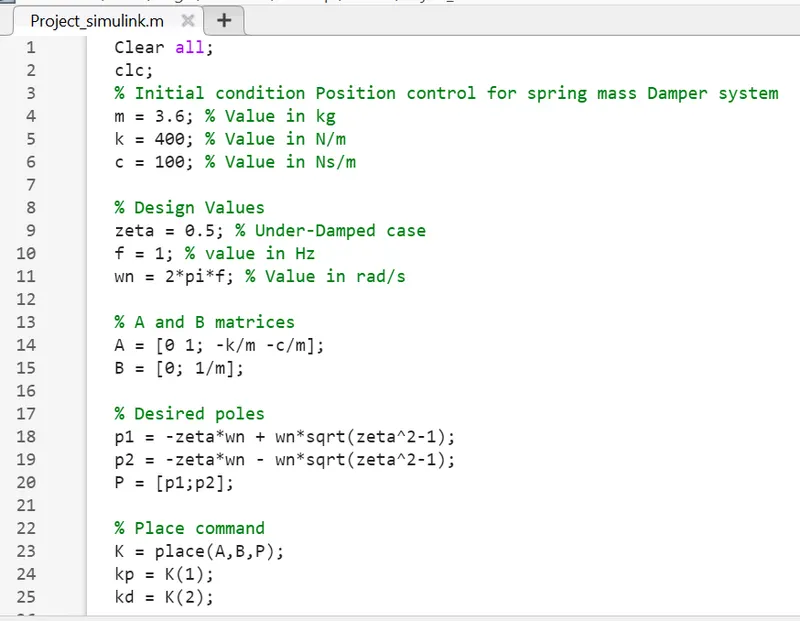
Pulse Generator:
Amplitude: 1
Period: 10
Pulse Width: 50%
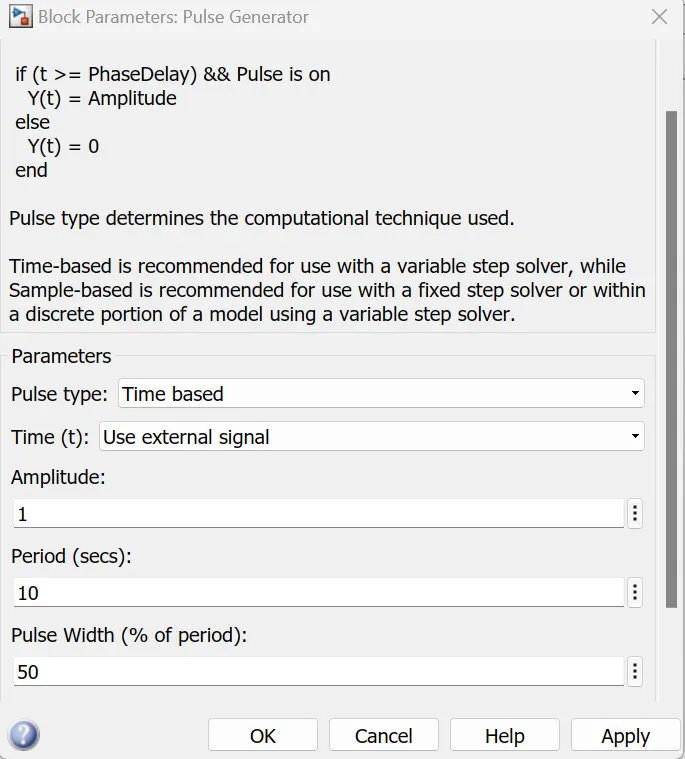
>> A
A =
0 1.0000
-111.1111 -27.7778
>> B
B =
0
0.2778
>> P
P =
-3.1416 + 5.4414i
-3.1416 - 5.4414i
>> K
K =
-257.8777 -77.3805
>> k
k =
400
>> c
c =
100
>> m
m =
3.6000
>> f
f =
1
>> wn
wn =
6.2832
>> kd
kd =
-77.3805
>> kp
kp =
-257.8777
>> p1
p1 =
-3.1416 + 5.4414i
>> p2
p2 =
-3.1416 - 5.4414i
Model Settings:
Start time = 0
Stop time = 30
Fixed type with step time = 0.01
Ki is manually selected and given the value of 470
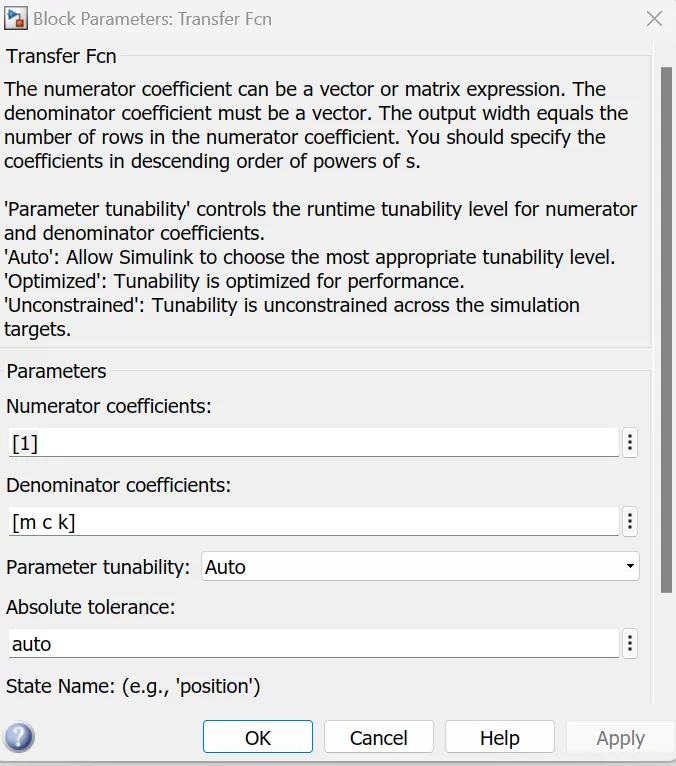
Transfer Funtion = 1/(m*s^2+c*s+k)
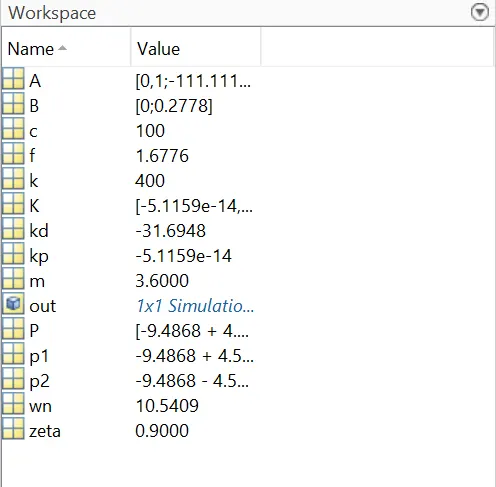
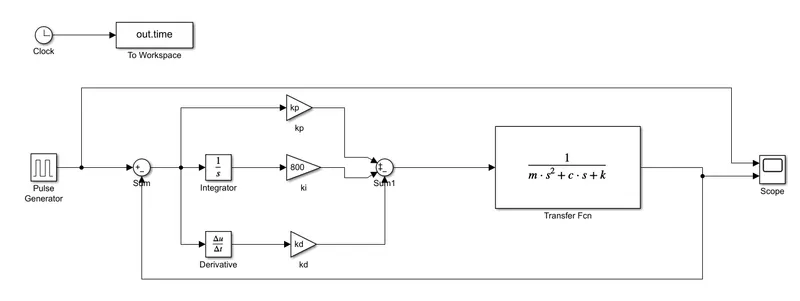
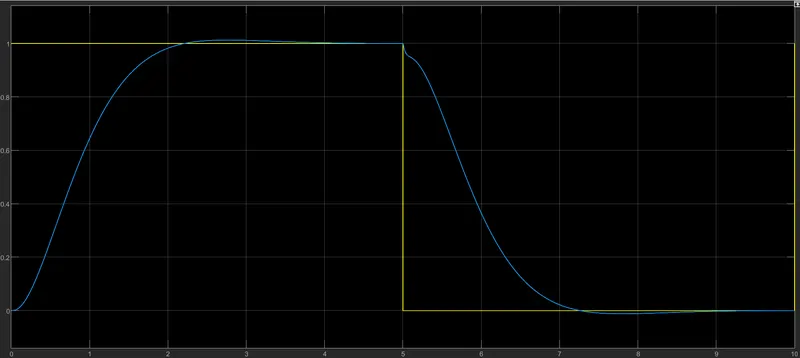
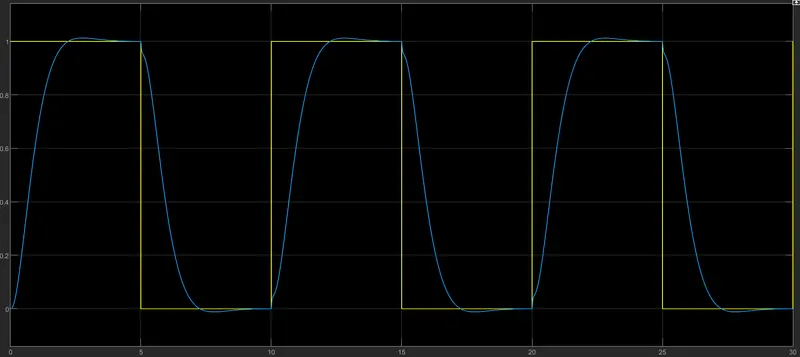
CONCLUSION: Overshoot is under 10% and settling time is also in range. Adjusted force, on mass so that its position follows a reference signal. Ki is 470 for the value of zeta = 0.9. Graph is for two cycle times 10sec and 30 sec respectively.