Project
BAJA PROJECT
AIM: To carry out the system-level simulation of all-terrain vehicle in the Simulink.
OBJECTIVE: To prepare a technical report explaining the Baja ATV model properties are as follows-
- Without using lookup table
- With using lookup table
THEORY-
ATV: An all-terrain vehicle is referred as motorized off-road capability four low pressure quadricycle single seat bike designed to have a straddled by the operator and handlebars for steering control. It is also known as Life Utility Vehicle by American National Standard Institute (ANSI).
ATVs are subdivided into two types as designated by the manufacturer.
- Type I ATVs:- The manufacturer intended to manufacture single operator with no passenger.
- Type II ATVs:- The manufacturer intended to manufacture an operator
& a passenger, and are equipped with a designated seating position behind the operator.
They can customized or modified according specification by the purpose which is suitable to use like for recreation purpose especially for kids, agricultural purpose, Military application for different terrain, Motor-sport purpose etc.
CVT: A CVT, or continuously variable transmission, seamlessly changes through an unending range of effective gear ratios while you drive, whereas other kinds of mechanical transmissions offer a fixed number of gear ratios and have hard shifts between each as explained by Certified Transmission Repair. CVT transmission systems are also known as single-speed, shiftless, and stepless transmissions.
The shiftless nature of a CVT offers unparalleled flexibility that maintains constant angular velocity regardless of output speed. Additionally, a continuously variable transmission makes accelerating smooth and offers enhanced fuel economy.
CVT systems work through a pulley system. This system consists of cones at each pulley connected via a chain belt. The cones can move to increase or decrease the belt diameter to change gear ratios, allow for quick shifting into the needed ratio for increased power, and boost fuel economy.
One pulley in the CVT is connected to the engine and the other directs power to the wheels. The width of these pulleys changes based on the needed power; as one gets larger, the other gets smaller.
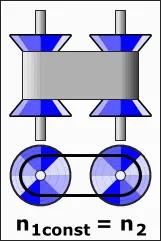
CONTINIOUSLY VARIABLE TRANSMISSION (CVT)
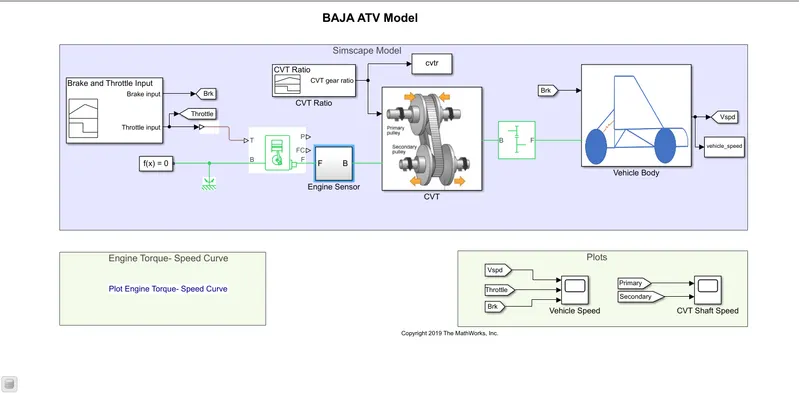
ATV SIMSCAPE MODEL
- SIGNAL BUILDER- The signal builder allows you to create interchangeable groups of piecewise linear signal sources & use them in a model. You can quickly switch the signal group into and out of a model to facilitate testing.
- GENERIC ENGINE- The Generic Engineblock represents a general internal combustion engine. This block is a suitable generic engine for spark-ignition and diesel. Speed-power and speed-torque parameter are also included.
The throttle input signal ‘T’ lies between zero and one and specifies the torque demanded from the engine as a fraction of the maximum possible torque. If engine falls below the stall speed, the engine torque comes to zero. If the engine speed exceeds maximum speed, the simulation stops and shows error message.
Connection F and B are mechanical rotational conserving ports associated with engine crankshaft and engine block, respectively. Connections p and FC are physical signal output through which power and fuel consumption rate are reported.
Speed vector and torque vector are the assignment parameters.
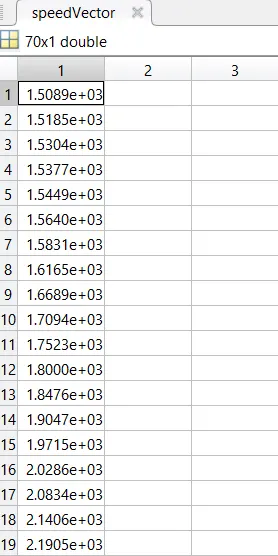
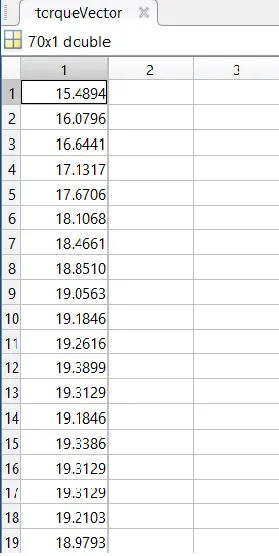
SPEED VECTOR AND TORQUE VECTOR
ENGINE SENSOR:
- Ideal Rotational Motion Sensor- The block represents an ideal mechanical rotational motion sensor, this device converts an across variable measured between rotational nodes into a control signal proportional to angular velocity. The sensor is ideal since it does not account for inertia, friction, delay, energy consumption etc.
Connection R and C are mechanical rotational conserving ports and connections W and A are physical signal output ports for velocity and angular displacement, respectively.
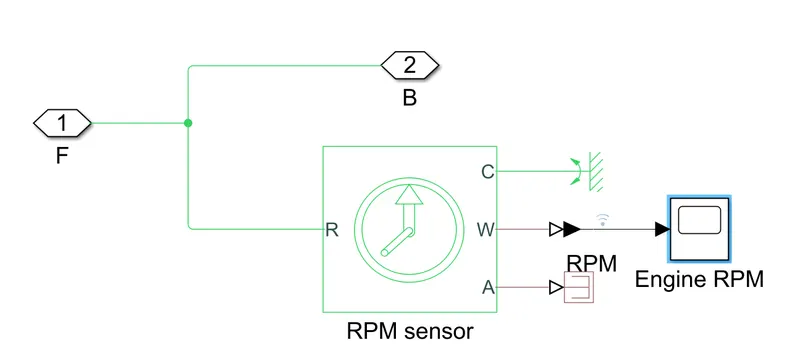
ENGINE SENSOR SUB-SYSTEM
- Simple Gear- It represents a fixed-ratio gear or gearbox. No inertia or compliance is modeled in this block. It is optionally include gear meshing and viscous bearing losses.
Connection B (base) and F (follower) are mechanical rotational conserving ports. Specify the relation between base and follower rotational direction with output shaft rotates parameter.
Follower (F) to base (B) teeth ratio (NF/NB).
CVT SUBSYSTEM-
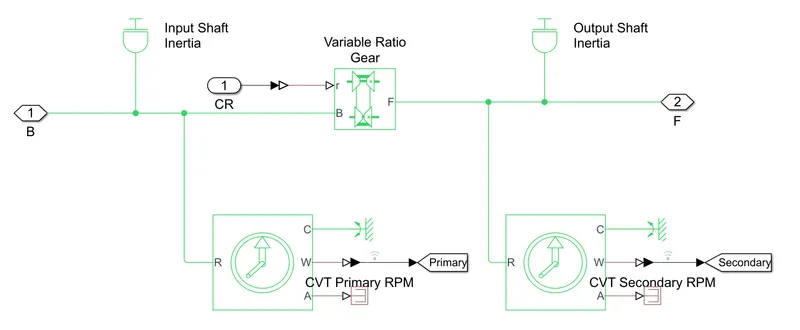
CVT SUB-SYSTEM
The CVT subsystem consist of the following blocks:
- Inertia- The block represents an ideal mechanical rotational inertia. The block has one mechanical rotational conserving port. The block positive direction is from its port to the reference point. This means that the inertia torque is positive if the inertia is accelerated in a positive direction.

INERTIA
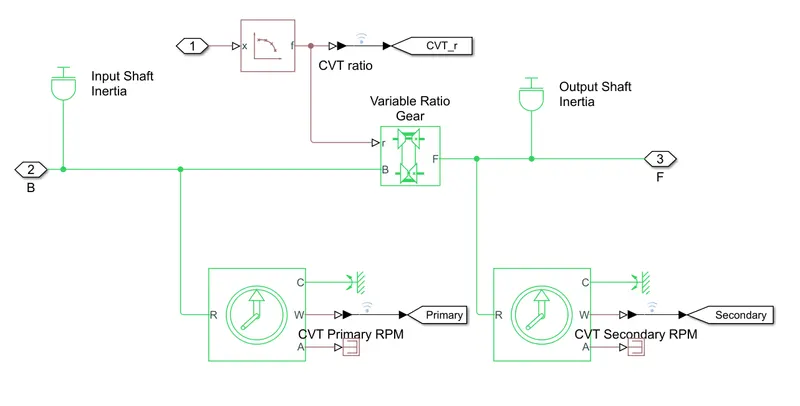
- Variable Ratio Transmission- The Variable Ratio Transmissionblock represents a gearbox that dynamically transfers motion and torque between the two connected driveshaft axes, the base and the follower. It is implemented by mechanical belt CVT, electric or hydraulic transmission. The physical signal input r defines the ratio of input to output angular shaft velocities.
Connections B (base) and F (follower) are mechanical rotational conserving ports. Specify the relation between base and follower rotation direction with the output shaft rotates parameter.
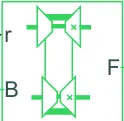
VARIABLE RATIO TRANSMISSION
VEHICLE BODY SUBSYSTEM:
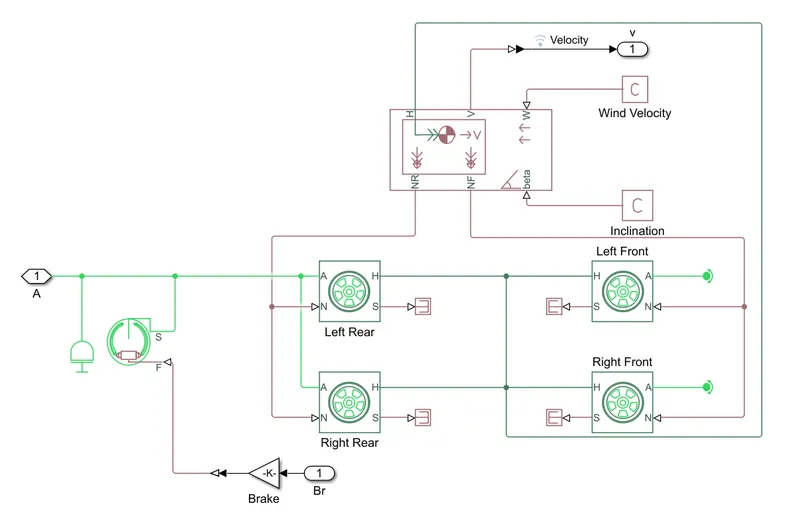
VEHICLE BODY SUB-SYSTEM
- Vehicle Body- It represent two-axle vehicle body in longitudinal motion. The block accounts for body mass, aerodynamics drag, and road incline and weight distribution between axles due to acceleration and road profile. The vehicle can have the same or different no. of wheels on each axle. It also include pitch and suspension dynamics or additional variable mass and inertia. The vehicle does not move vertically relative to the ground.
Connection H is the mechanical translational conserving port associated with the horizontal motion of the vehicle body. The resulting traction motion developed by tires should be connected to this port. Connection V, NF and NR are physical output ports for vehicle velocity & front & rear normal wheel forces, respectively. Wheel forces are considered positive, if acting downwards. Connections W and beta are physical signal input ports corresponding to headwind speed and road inclination angle, respectively. If the variable mass is modeled, the physical input ports CG and M are exposed. CG accepts a two-element vector representing the x and y distance offsets from the vehicle CG to additional load mass CG. M represents the additional mass. If both variable mass and pitch dynamics are included, the physical signal pots J accepts the inertia of the additional mass about its own CG.
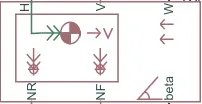
VEHICLE BODY
Parameters:
Mass: 250 kg
Number of wheels per axle: 2
Horizontal distance from CG to front axle: 1 m
Horizontal distance from CG to rear axle: 0.35 m
CG height above ground: 0.7 m
Gravitational acceleration: 9.81m/s^2
- Tire- The longitudinal behavior of a highway tire characterized by tire magic formula. The block is built from the Tire Road Interaction (magic formula) and simpscape Foundation Library, wheel and axle block. Optionally, the effect of tire inertia, stiffness and damping can be included.
Connection A is the mechanical rotational conserving port fort the wheel axle. Connection H is the mechanical translational conserving port for the wheel hub through which the thrust developed by the tire is applied to the vehicle. Connection N is a physical signal input port that applies the normal force acting on the tire. The Force is considered positive if it act downwards. Connection S is a physical signal output port that report the tire slip. Optionally expose physical signal port M by setting parameterize by physical signal Magic Formula coefficients.

TIRE
Parameters:
Parameterize by: Constant Magic Formula coefficients
Magic Formula B coefficient: 10
Magic Formula C coefficient: 1.9
Magic Formula D coefficient: 1
Magic Formula E coefficient: 0.97
- Double-Shoe Brake- The brake arrangement is of 2-pivot rigid shoes symmetrically installed inside or outside a drum and operated by the one actuator. The actuator force causes the shoes to exert a friction torque on a shaft connected to the drum.
Connection S is a conserving rotational terminal associated with the drum shaft. Connection F is a physical signal port representing the force input to the actuator. Positive force creates friction torque that resist shaft rotation. Thermal effect & expose thermal conserving port H by setting Thermal port to model.
Parameter:
Drum radius: 150 mm
Actuator location radius: 100 mm
Pin location radius: 125 mm
Pin location angle: 15 deg
Shoe beginning angle: 5 deg
Shoe span angle: 120 deg
CASE STUDY-
CASE 1: ATV WITH CVT
ATV SIMSCAPE MODEL WITH CVT
Torque vs Speed characteristics:
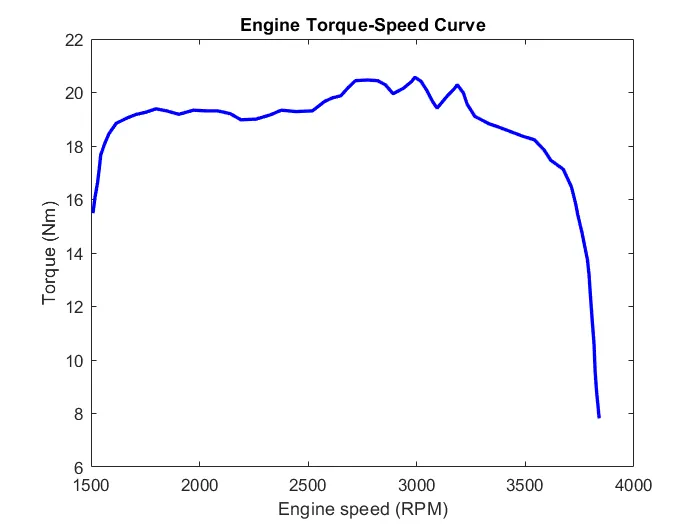
In the above plot maximum velocity reaches to 3840 RPM. Vehicle speed is depend on the CVT Ratio.
1.1 INPUT
BRAKE & THROTTLE INPUT
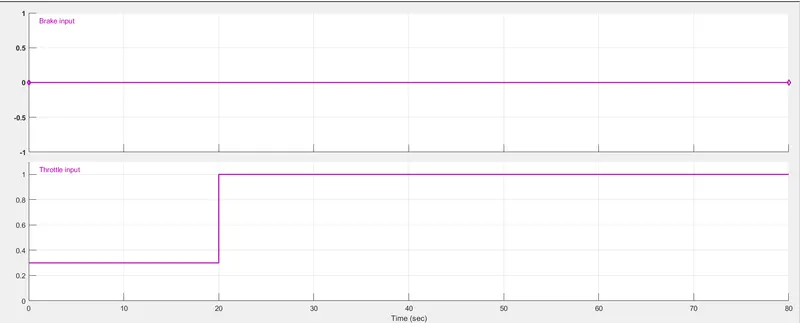
THROTTLE & BRAKE INPUT
Brake input is constant i.e. ‘0’ throughout the time 80 sec.
Throttle input is 0.3 for first 20 sec, accelerates to ‘1’ at the same and remains constant throughout the remaining time till 80 sec.
CVT RATIO:
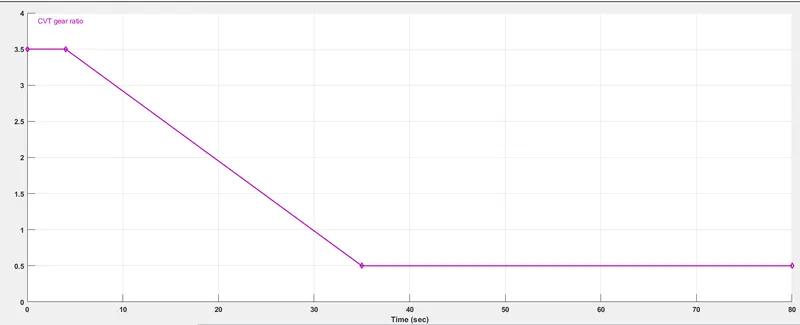
CVT GEAR RATIO INPUT
The CVT gear ratio 2.3 for the first 4 sec, then drops down to 1.8 till 35 sec and remains constant till 80 sec.
1.1 OUTPUT
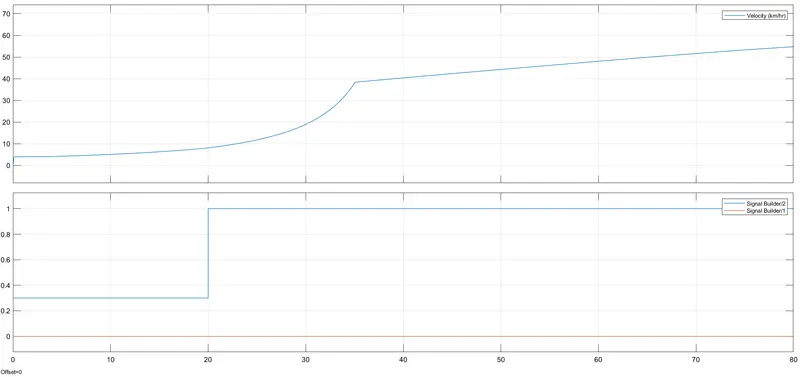
THROTTLE & BRAKE OUTPUT
In the above plot, brake input ‘0’ and throttle input is 0.3 for 20 sec velocity will reach 20 and slowly throttle input is increase to value ‘1’, then velocity value will increase and reaches its maximum velocity.
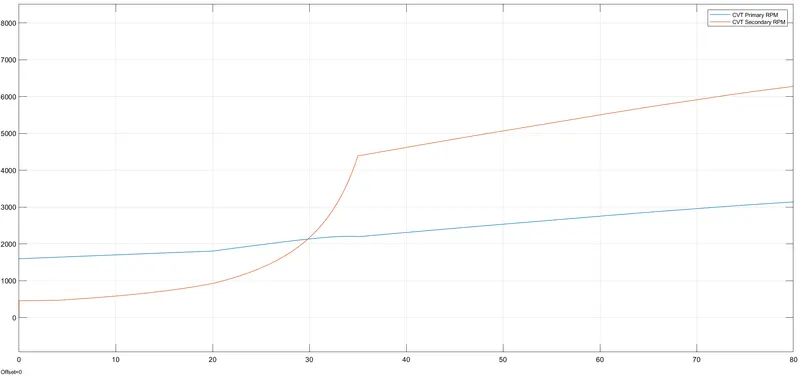
CVT SHAFT SPEED OUTPUT
In the above plot, cvt variator of primary pulley goes inward and secondary pulley goes outward which is overlapping with each other.
Primary pulley radius increases and secondary pulley radius decreases. So the speed of primary pulley is greater than secondary pulley.
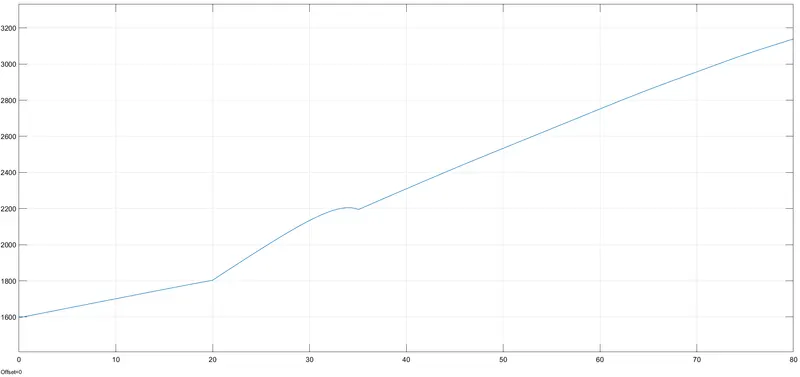
ENGINE SPEED RPM
In the above plot, brake input is ‘0’ and the throttle input is ‘0.3’ for 20sec, initially at beginning engine speed decreases due to increase in gear ratio which increases the torque and by increases to the value to ‘0.3’ then engine speed value will increases and reaches it’s maximum engine speed.
CASE 2: ATV WITH CVT (DASHBOARD)
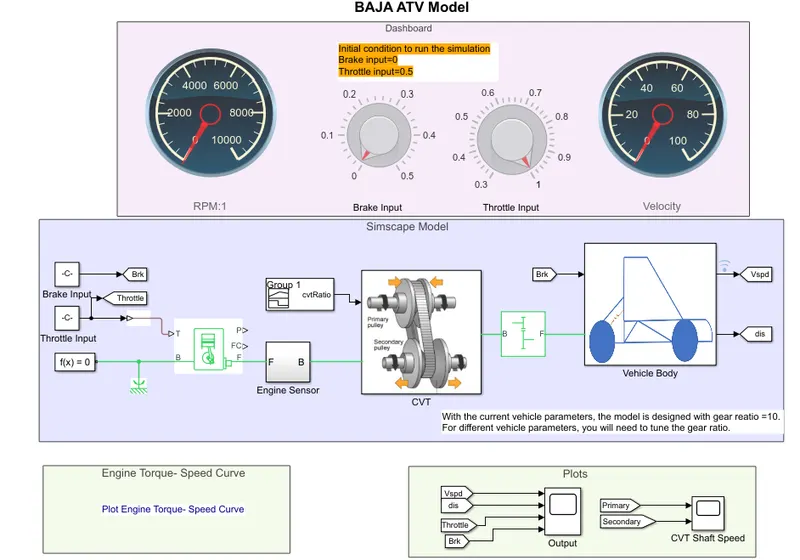
ATV SIMSCAPE MODEL WITH CVT (DASHBOARD)
In the above Simulink model, RPM (Speed) gauge, Brake input gauge, Throttle input gauge and velocity gauge is connected in the dashboard. Brake input is ‘0’, throttle input is 0.5 for initial condition to run the simulation.
Dashboard is connected with BAJA All-terrain Vehicle using CVT in Simulink model. With the help of dashboard, variation of speed and velocity will display in the RPM:1 gauge and velocity gauge, while running the simulation.
RPM gauge refers the speed of the primary & secondary pulley and velocity gauge refers the speed of the vehicle.
1.2 OUTPUT-
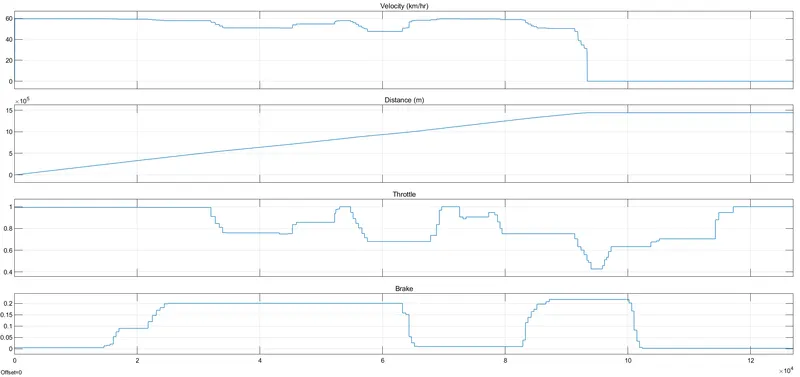
THROTTLE & BRAKE OUTPUT
From the above plot, we observed that by increasing the throttle input value, increase the velocity and by increasing the brake input value it will decrease the velocity.
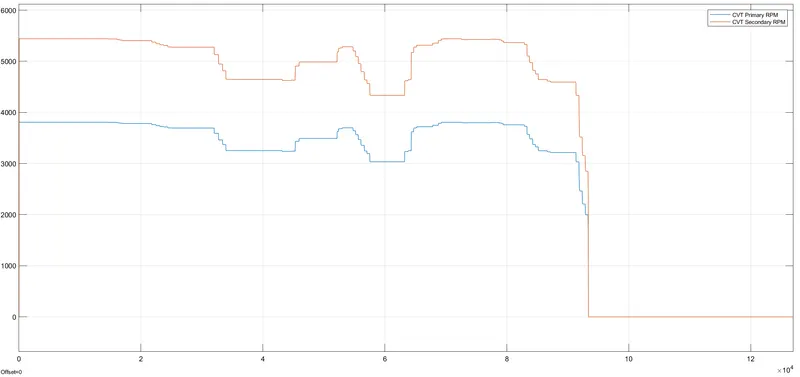
CVT SHAFT SPEED OUTPUT
From the above CVT Shaft speed plot, we observed that by increasing the throttle input value, it will increase the RPM of the primary and secondary pulley and by increasing the brake input value it will decrease the RPM of the primary and secondary pulley.
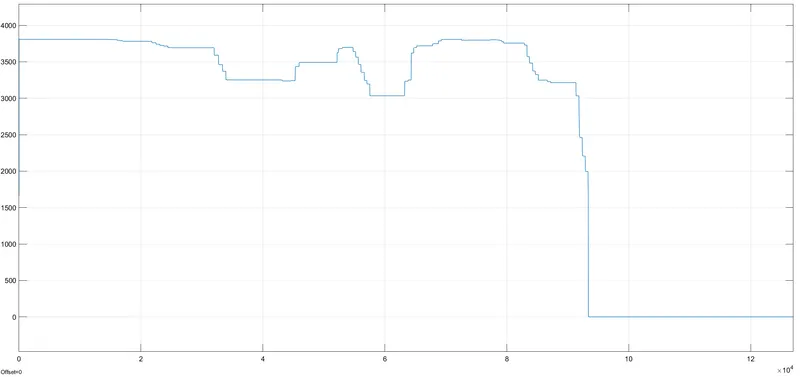
ENGINE SPEED RPM
From the above Engine speed plot, we observed that by increasing the throttle input value, it will increase the Engine Speed and by increasing the brake input value it will decrease the Engine Speed.
CASE 3: ATV WITH CVT (LOOK-UP TABLE)
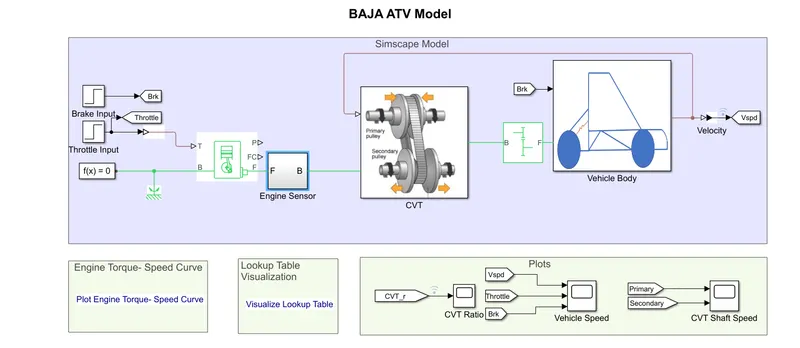
ATV SIMSCAPE MODEL WITH CVT (LOOKUP-TABLE)
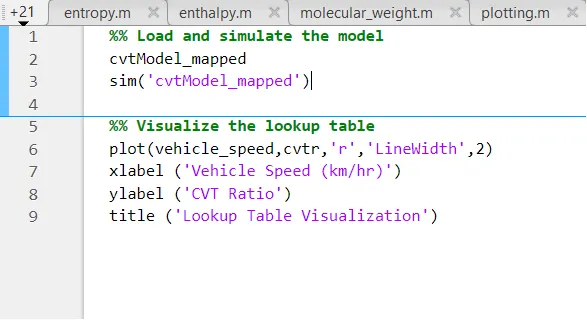
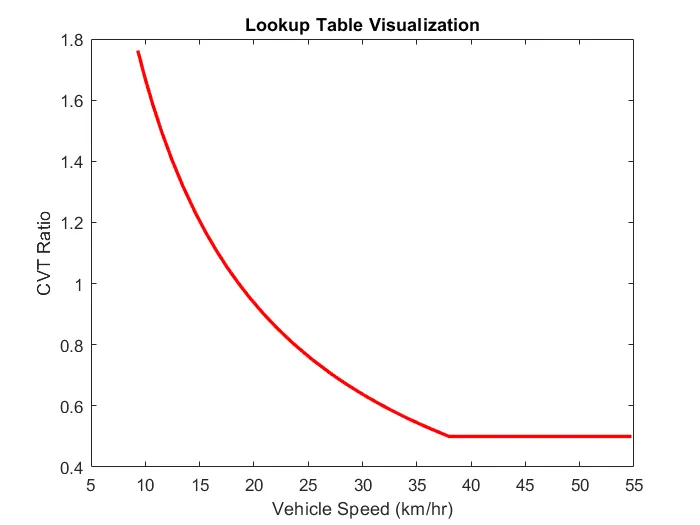
In the above model look-up table data has been assigned as input to the CVT instead of giving cvt ratio. For giving input of look up table by creating a program in the MATLAB and data has been assigned as input to the CVT.
LOOK-UP TABLE PROGRAM IN MATLAB:
GIVING INPUT TO CVT USING LOOK-UP TABLE:
1.3 OUTPUT-
Look-up Table Visualization Plot:
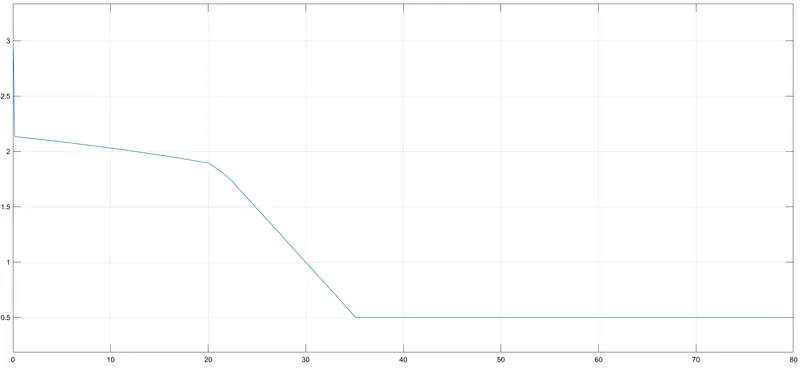
CVT GEAR RATIO OUTPUT
The above plot shows the value of Look-up table input data to the CVT.
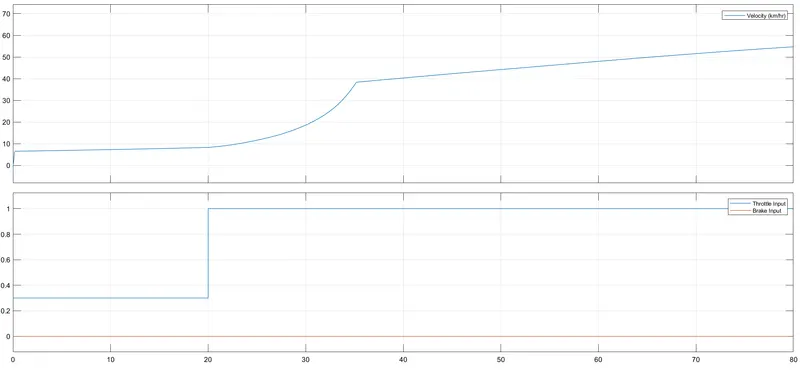
THROTTLE & BRAKE OUTPUT
In the above plot, brake input is ‘0’ and throttle input is 0.3 for 20 sec, velocity will reach 20 and slowly throttle input is increase to value ‘1’, then velocity value will increase and reaches its maximum velocity.
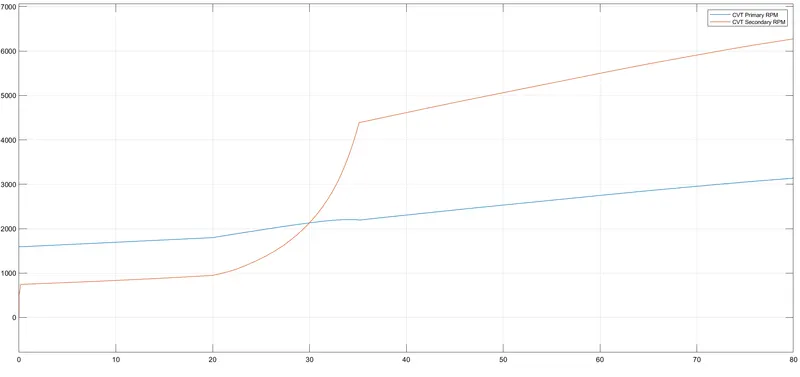
CVT SHAFT SPEED OUTPUT
In the above plot, cvt variator of primary pulley goes inward and secondary pulley goes outward which is overlapping with each other.
Primary pulley radius increases and secondary pulley radius decreases. So the speed of primary pulley is greater than secondary pulley.
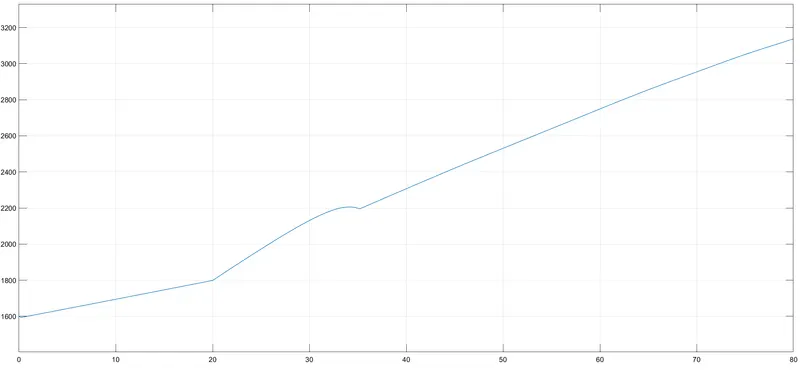
ENGINE SPEED RPM
In the above plot, brake input is ‘0’ and the throttle input is ‘0.3’ for 20sec, initially at beginning engine speed decreases due to increase in gear ratio which increases the torque and by increases to the value to ‘0.3’ then engine speed value will increases and reaches it’s maximum engine speed.
CASE 4: ATV WITH CVT (DASHBOARD) LOOK-UP TABLE
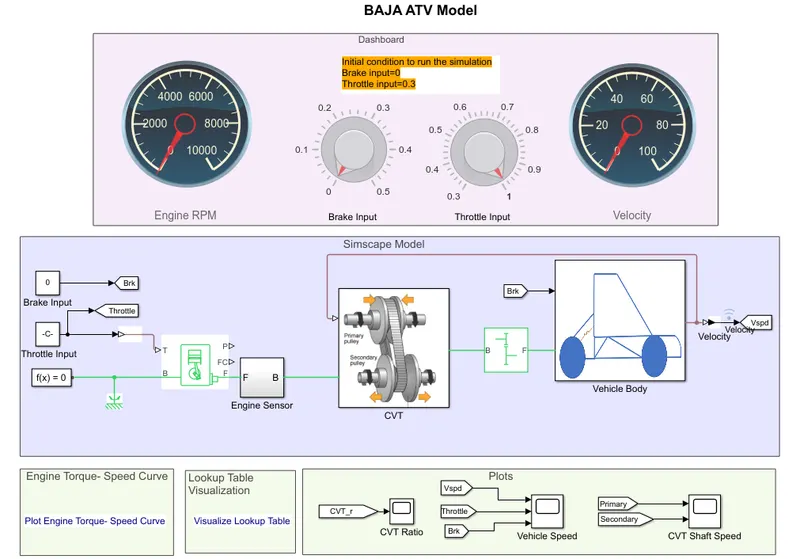
ATV SIMSCAPE MODEL WITH CVT (DASHBOARD) LOOK-UP TABLE
In the above Simulink model, RPM (Speed) gauge, Brake input gauge, Throttle input gauge and velocity gauge is connected in the dashboard. Brake input is 0, throttle input is 0.3 for initial condition for run the simulation.
Also, the above Simulink model look-up table data has been assigned as input to the CVT instead of giving cvt ratio. For giving on Look-up table by creating a program in the MATLAB and the data has been assigned as input to the CVT.
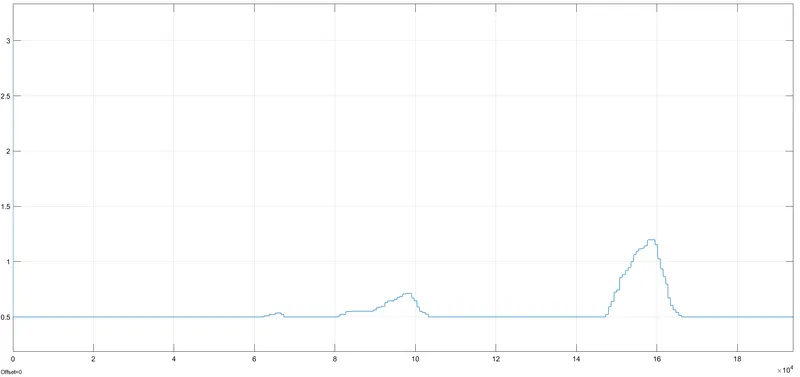
CVT GEAR RATIO OUTPUT
In the above plot, CVT Ratio will vary by changing the throttle gauge. If throttle value increases CVT ratio decreases. If throttle value decreases CVT Ratio increases.
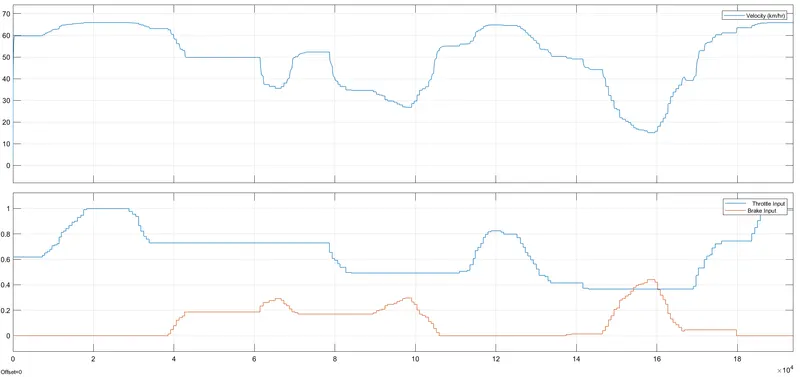
THROTTLE & BRAKE OUTPUT
From the above vehicle speed plot, observed that by increasing the throttle input value, it will increase the velocity and by increasing the brake input value it will decreases the velocity.
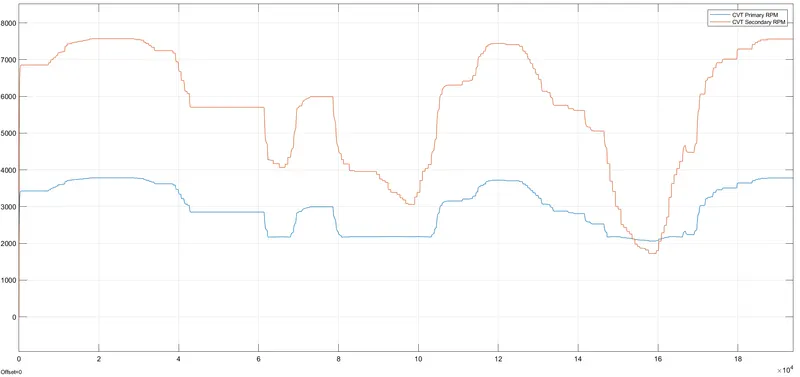
CVT SHAFT SPEED OUTPUT
From the above plot, we observed that by increasing the throttle input value, it will increase the RPM of the primary & secondary pulley and by increasing the brake input value it will decrease the RPM of the primary & secondary pulley.
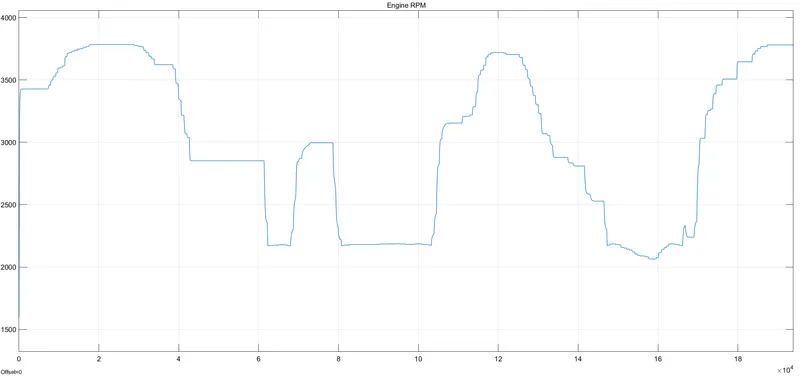
ENGINE SPEED RPM
From the above plot, we observed that by increasing the throttle input value, it will increase the engine speed and by increasing thr brake input value it will decrease the Engine speed.
CONSLUSION-
- System level simulation of an BAJA all-terrain vehicle without using look-up table is done and the result are plotted.
- System level simulation of an BAJA all-terrain vehicle using look-up table is done and results are plotted.
- All the result are satisfactory.