Project
Outlining of the model
1)The All-terrain vehicle is made, in this, a generic engine (having crankshaft & engine) takes its input as the throttle speed and feeds the data to the variable gear ratio unit at the engine conserving port.
2) The variable gear ratio also takes the primary to secondary shaft rpm ratio as the input and gives the output to the simple gear that is directly connected to the rear end wheels.
3) the gear ratio is taken as 10 for this simulation.
4) Various sensors like rotational motion sensors, and translational velocity sensors are used to get the data at various nodes.
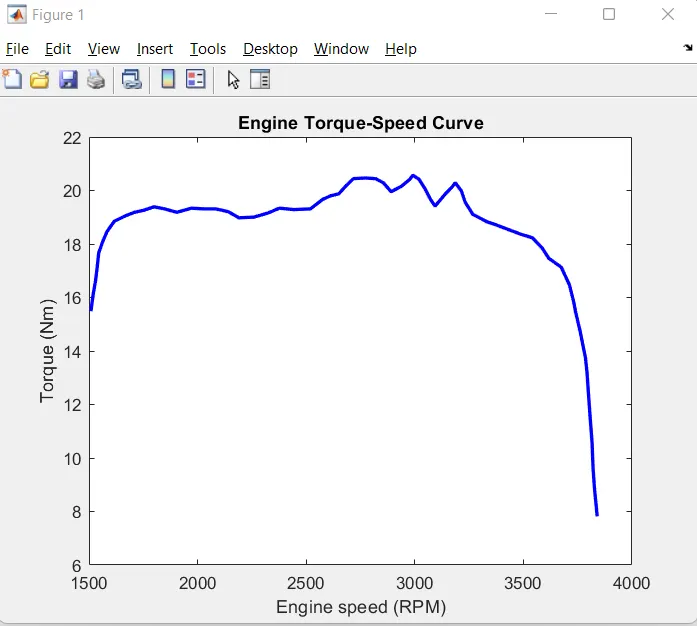
The values for torque vs engine speed are extracted from the following graph.
We are analyzing the vehicle condition for t=200 sec.
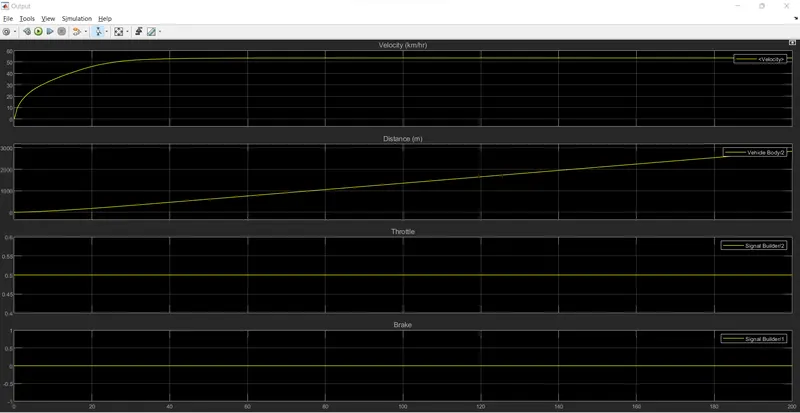
The initial condition is, the constant throttle of 0.5 is provided and no deacceleration(No braking condition)
At about t=40sec, when the distance traveled by the vehicle will be around 460m, the vehicle reaches its top speed of 53.25kmph. Refer below graph
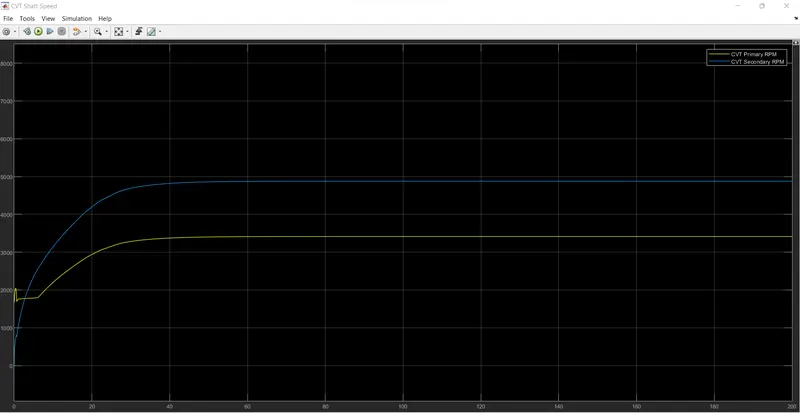
From the CVT shaft graph, we can say that it is the over-ride condition, i.e, secondary shaft rpm > primary shaft rpm and we equilibrium is reached at t=40 sec in both the rpm, the velocity becomes constant. Refer graph below