Project
Aim :To study & Analyze the Baja All Terrian Vehicle (AVT) using Matalab.
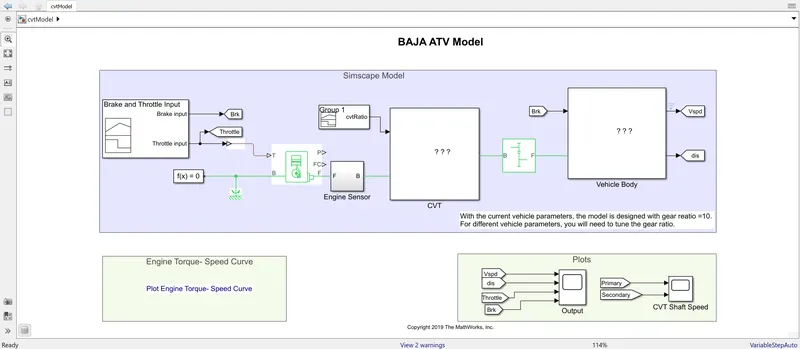
# AVT Model Without Dashboard:
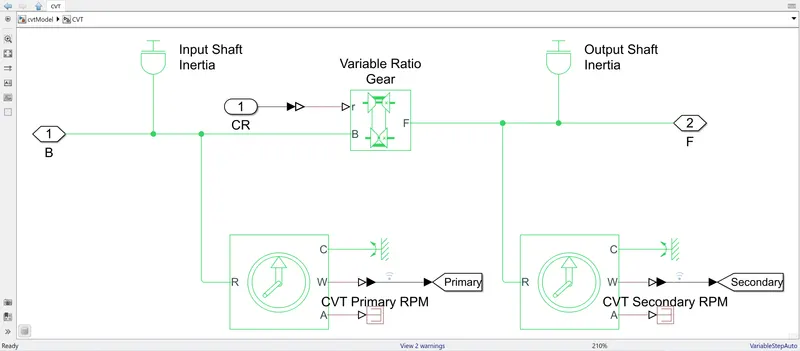
CVT Assembly Model:
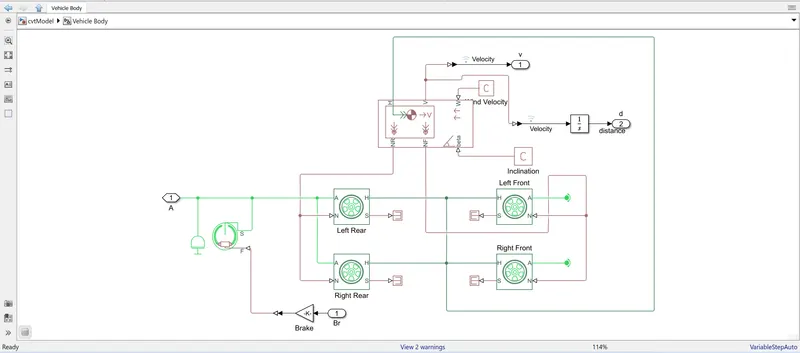
Vehicle Body:
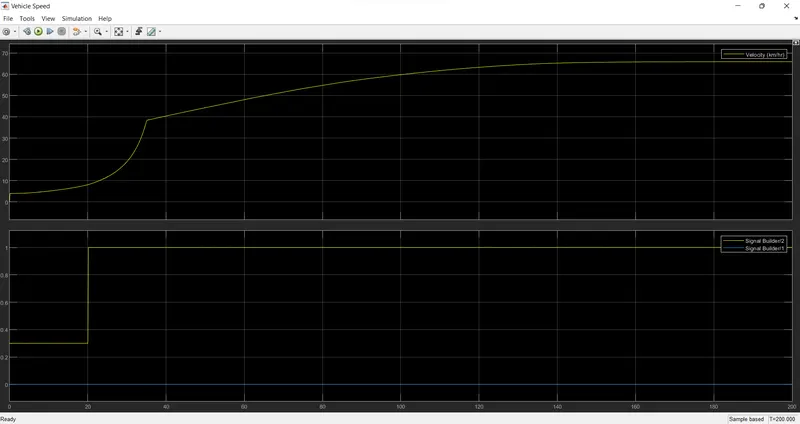
Output:
# AVT Model With Dashboard:
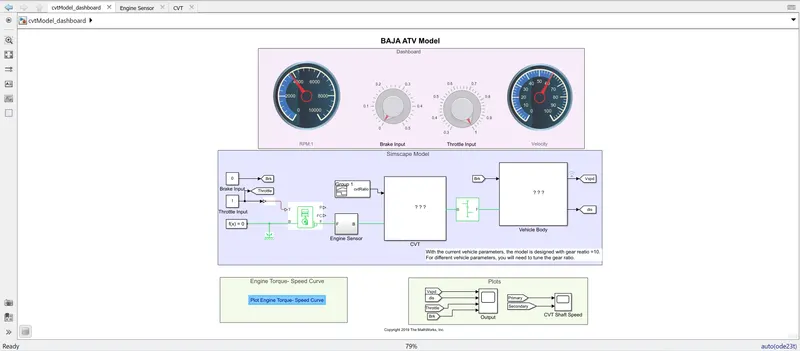
- We can change the velocity by varying throtle input.
- throtle input increase than velocity will be increase
- In CVT Following component consist.
- Primary pully,Variator,Secondary pully & Belt.
- Rp(primary pully speed) < RS(Secondary pully speed) in these case Speed Reduction Take Place.
- Rp>RS in these Case overdrive take place.
- To varying the speed gear ration will be provide in CVT.