System-level Simulation of an All-Terrain Vehicle (ATV)
AIM: To carry out a system-level simulation of an All-Terrain Vehicle (ATV).
OBJECTIVES :
- To carry out a Simulation of ATV.
- To prepare a technical report explaining the model properties & comments on the results.
THEORY :
All-Terrain Vehicle (ATV)
An All-Terrain Vehicle (ATV), also known as a light utility vehicle (LUV), a quad bike, or simply a quad. It is a vehicle that travels on low-pressure tyres and has a seat that is straddled by the operator along with handlebars for steering control. It is mainly built for a broader range of terrain.
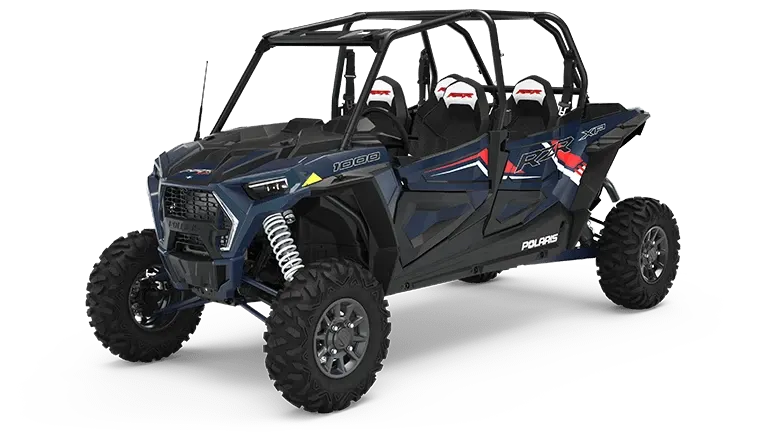
Components of ATV
Here is the list of components used in the ATV:
- Vehicle Body
- Suspension
- Tire
- Engine
- Continuously Variable Transmission (CVT)
MODEL :
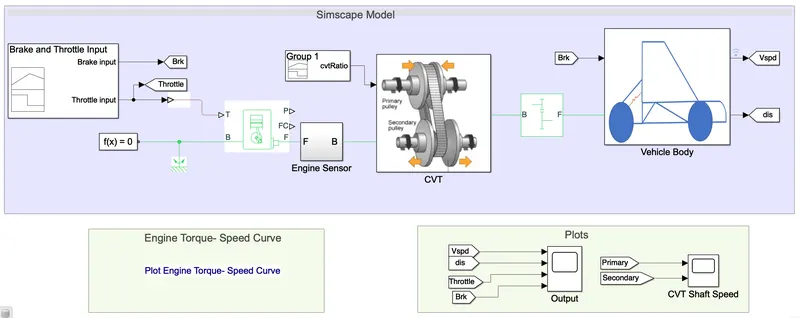
BLOCKS USED :
Here is the list of blocks used in this model -
- Signal Builder
- GoTo
- Simulink-PS Converter
- Generic Engine
- Solver Configuration
- Mechanical Rotational Reference
- Engine Sensor
- Simple Gear
- Chart
- From
- Scope
Signal Builder -
The Signal Builder block allows you to create interchangeable groups of piecewise linear signal sources and use them in a model. It can quickly switch the signal groups into and out of a model to facilitate testing. In this model, there are two inputs named Brake and Throttle Input.
Generic Engine -
Represents a system-level model of spark-ignition and diesel engines suitable for use at the initial stages of modelling when only the basic parameters are available. Optional idle speed and red line controllers are included.
The throttle input signal T lies between zero and one and specifies the torque demanded from the engine as a fraction of the maximum possible torque. If the engine speed falls below the Stall speed, the engine torque is blended to zero. If the engine speed exceeds the maximum speed, the simulation stops and issues an error message.
Connections F and B are mechanical rotational conserving ports associated with the engine crankshaft and engine block, respectively. Connections P and FC are physical signal output ports through which engine power and fuel consumption rate are reported.
Engine Sensor -
This sensor is connected with a Generic Engine. It consists of
- Physical Modeling Connection Port block for subsystems.
- Ideal Mechanical Rotational Sensor block measures angular velocity or angle in a mechanical rotational network. The sensor is ideal since it does not account for inertia, friction, delays, energy consumption & so on.
- PS Terminator block is used to terminate physical signal outputs. Unconnected physical signal output ports do not generate warnings, but a connection to a PS Terminator can be used to indicate that the signal was not inadvertently left unconnected
- This sensor is further connected with a CVT Subsystem.
CVT Subsystem -
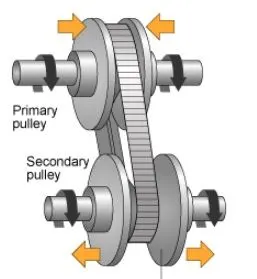
The CVT mainly consists of
- Primary Pulley
- Variator
- Secondary Pulley
- Belt
Conditions :
- If the primary pulley moves inward while the secondary pulley moves outward then it will lead to Overdrive. (`R_p> R_s`).
- If the primary pulley moves outward and the secondary pulley moves inward then it will lead to Speed Reduction. (`R_p < R_s`).
This CVT Subsystem consists of various blocks such as Input & Output Shaft Inertia, Variable Gear Transmission, Ideal Rotational Motion Sensors and PS Terminator along with Mechanical Rotational Reference.
Simple Gear -
Represents a fixed-ratio gear or gearbox. No inertia or compliance is modelled in this block. It includes gear meshing, backlash, and viscous bearing losses. Connections B (base) is connected to the CVT subsystem while Connection F (follower) is connected to the Vehicle Body. The connections are mechanical rotational conserving ports that specify the relation between base and follower rotation directions with the Output shaft rotates parameter.
Vehicle Body -
Represents a two-axle vehicle body in longitudinal motion. The block accounts for body mass, aerodynamic drag, road incline, and weight distribution between axles due to acceleration and road profile. The vehicle can have the same or a different number of wheels on each axle. Optionally include pitch and suspension dynamics or additional variable mass and inertia. The vehicle does not move vertically relative to the ground.
It consists of four wheels, two wheels at the rear and the other at the front. The Rear wheel is connected with a Double Shoe Brake which represents a brake arranged as two pivoted rigid shoes symmetrically installed inside or outside a drum and operated by one actuator. The actuator force causes the shoes to exert friction torque on a shaft connected to the drum.
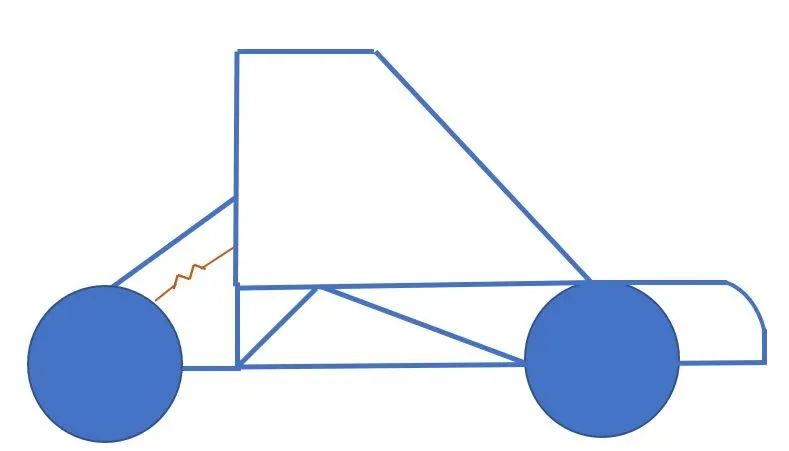
STUDY 1: All-Terrain Vehicle (ATV) with CVT
Signal Builder
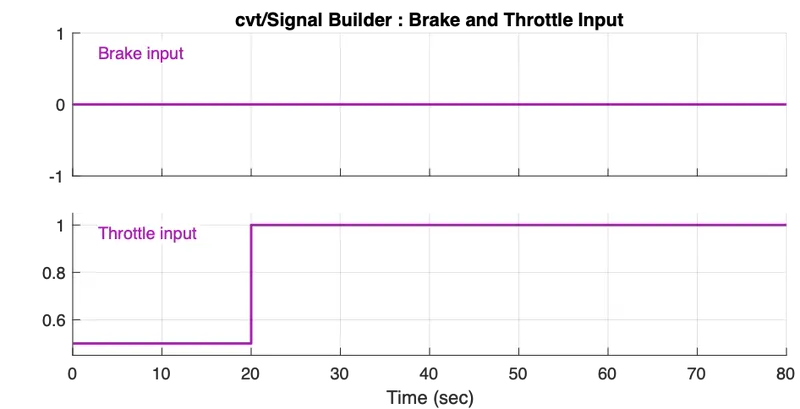
- Brake Input is constant i.e Zero throughout the given sample time which is 80 seconds.
- Throttle Input is 0.5 for 20 seconds, later it increases to 1 for the remaining time till 80 seconds.
Engine Torque - Speed Curve
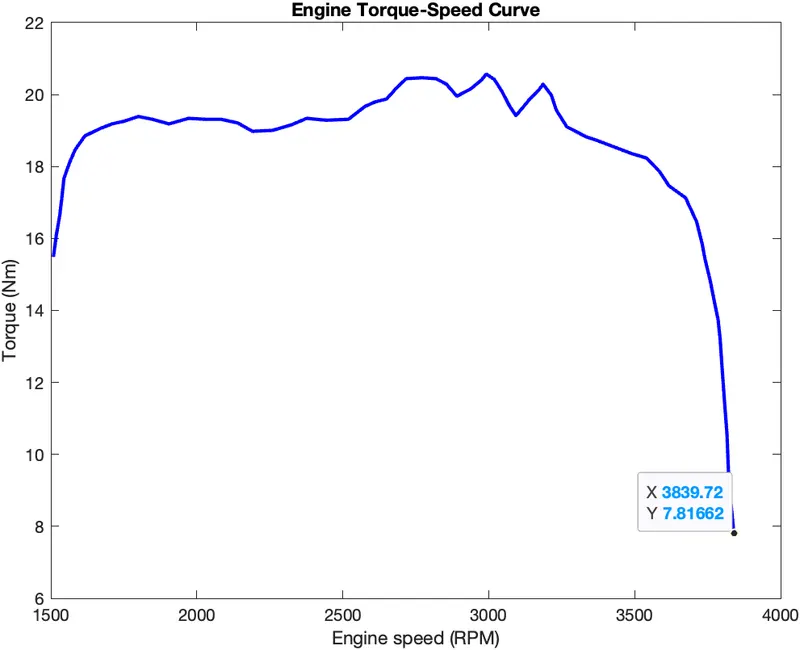
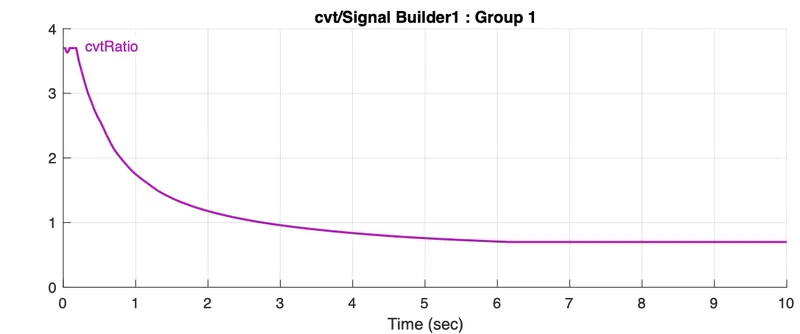
Vehicle Speed depends on CVT Ratio. The data is extracted using the GRABIT command which is available in the workspace. From the above graph, we have got the Maximum Velocity which is 3839.72 RPM.
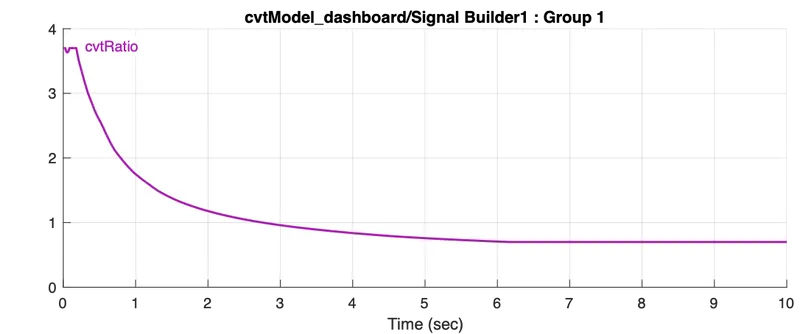
CVT RATIO
RESULTS :
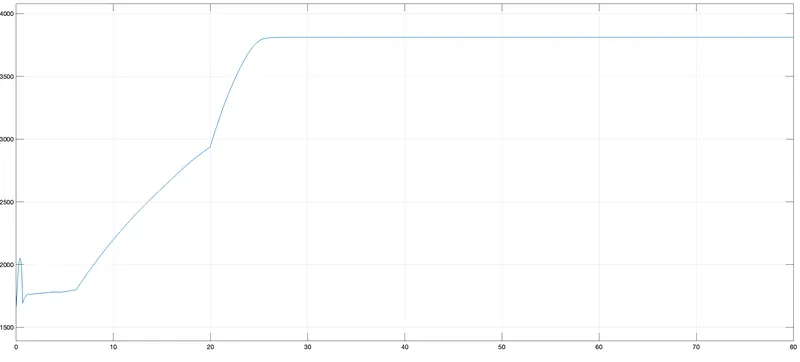
Engine Speed
Vehicle Speed
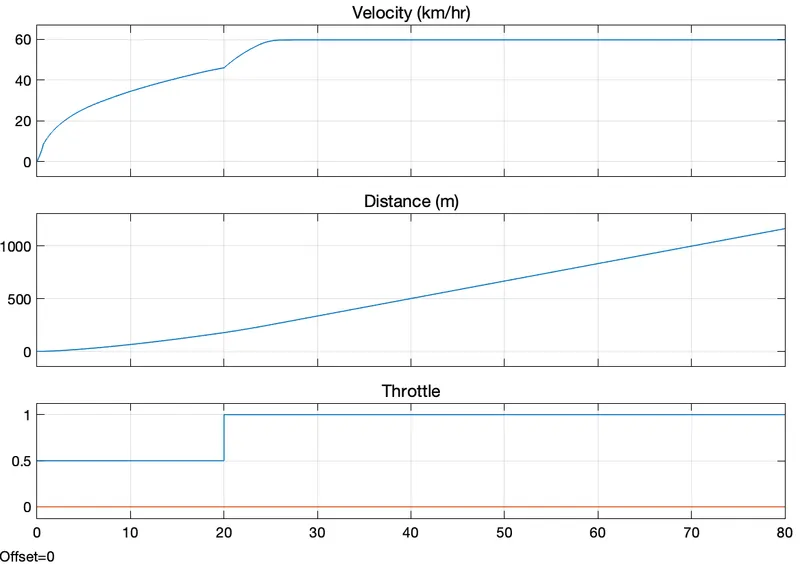
While providing Throttle Input, we observed if the value 0.3 is considered then the velocity shows a sudden drop in the speed hence we changed it to 0.5 to get the smooth flow of velocity.
CVT Shaft Speed
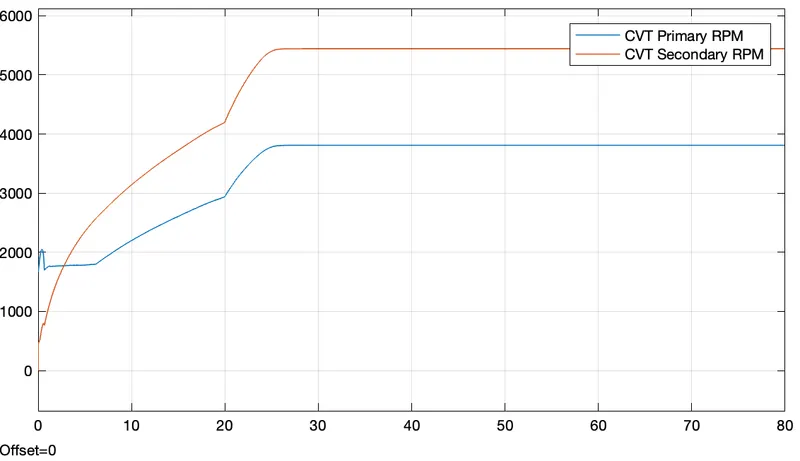
The CVT shows variations with respect to primary and secondary RMP based on their Gear Ratio.
STUDY 2: All-Terrain Vehicle (ATV) with CVT and Dashboard
Model :
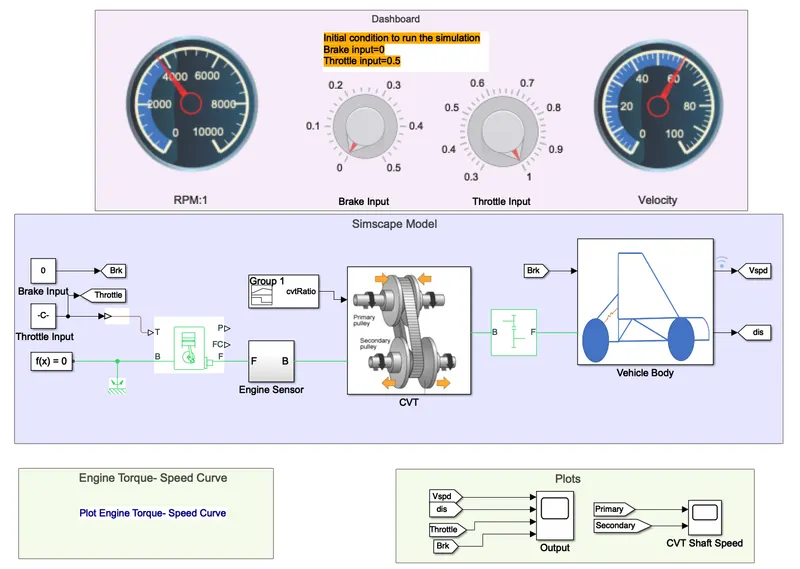
Explanation :
- This model is similar to that of the previous one, the one extra that is added over here is Dashboard which has Brake and Throttle Input knobs that allows the user to change the input values while the simulation is running.
- We kept the brake input as zero whereas the throttle keeps on changing based on the input by the user.
- The change in throttle inputs results in the changes in the vehicle speed which varies simultaneously with it.
Results :
CVT
Engine Speed
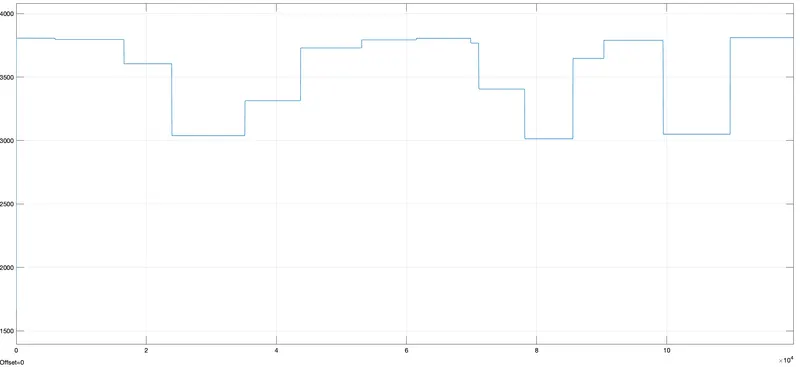
Vehicle Speed
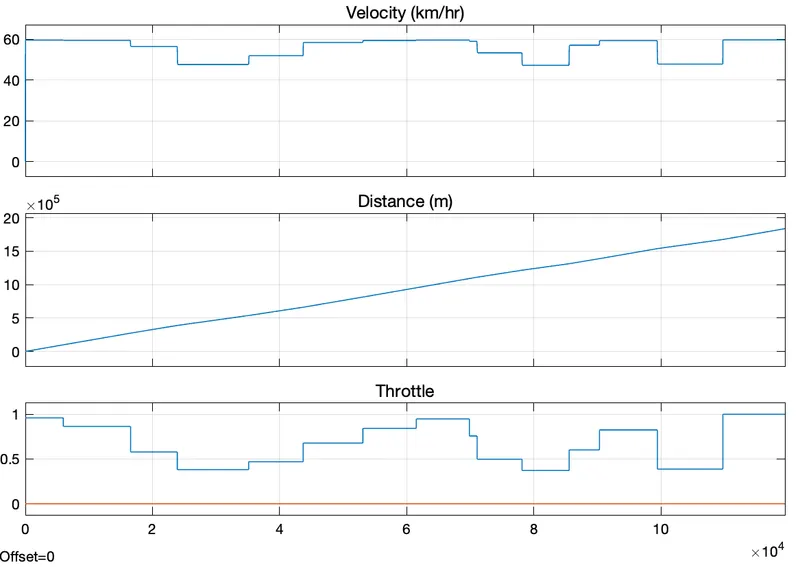
In this, Brake Input is 0 and the Throttle Input is variable with the help of the knob. The change in the throttle input reflects in the Velocity as well.
CVT Shaft Speed
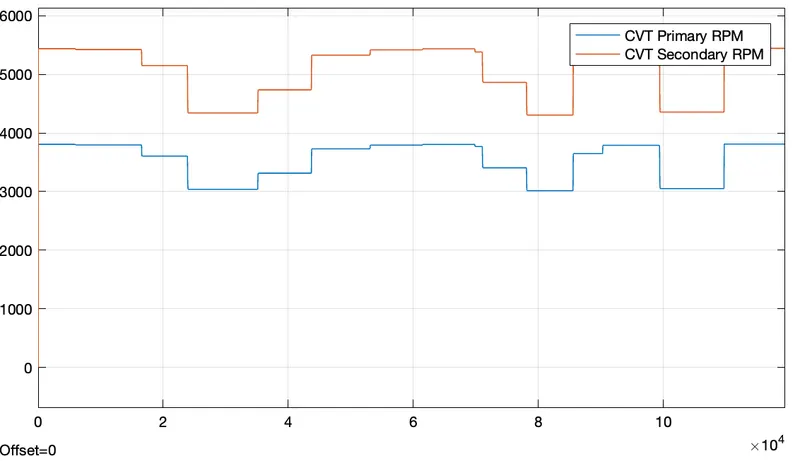
The CVT shows variations with respect to primary and secondary RMP based on their Gear Ratio.
STUDY 3: All-Terrain Vehicle (ATV) with CVT using Lookup Table
Model :
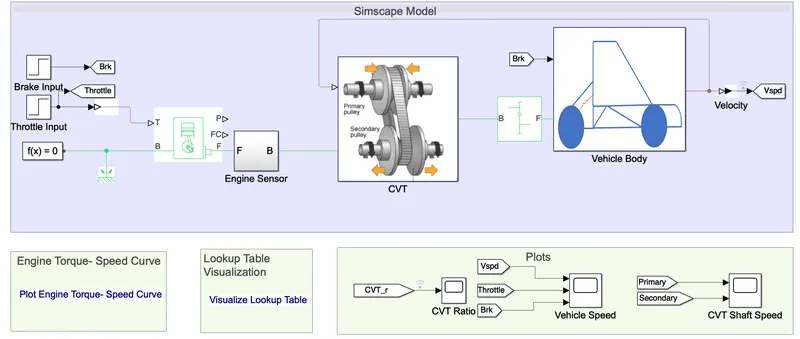
Explanation :
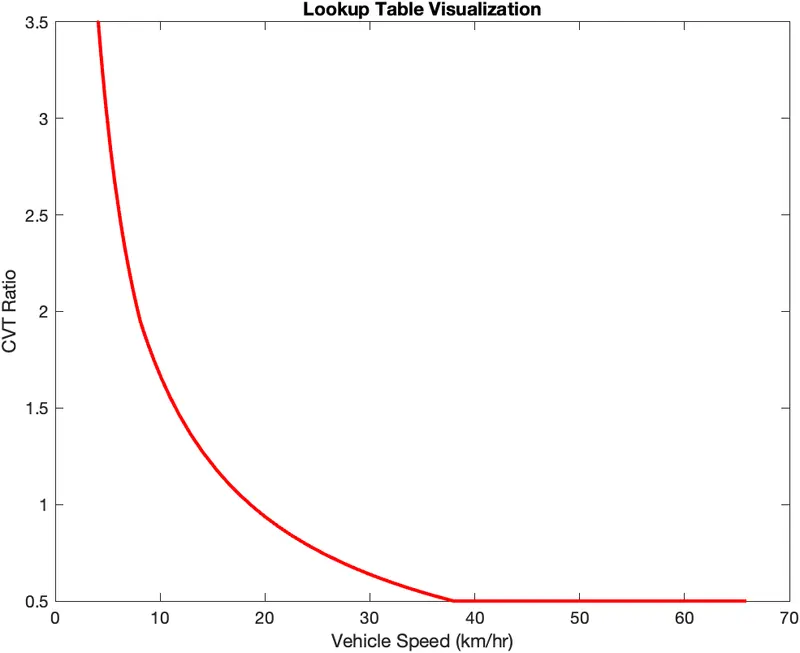
- In this model, the Brake and Throttle use a step signal as an input. Having a Lookup table with CVT Ratio vs Vehicle Speed as a visualization table helps to specify the CVT Ratio.
- Then model runs for 200 seconds and gave us the output in the form of various plots.
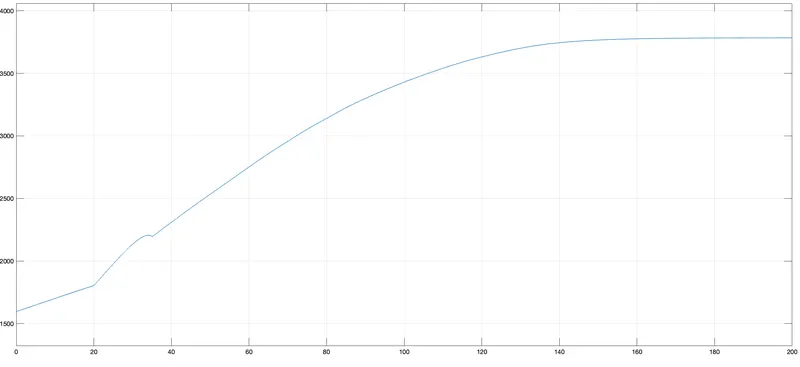
- They are Engine Speed, Vehicle speed and CVT Shaft speed.
Results :
LookUP Table
CVT Ratio
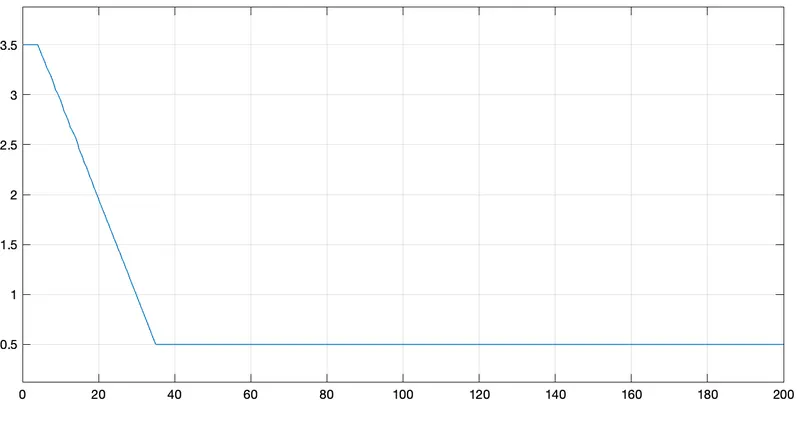
The lookup plot and the CVT Ratio plot is similar
Engine Speed
Vehicle Speed
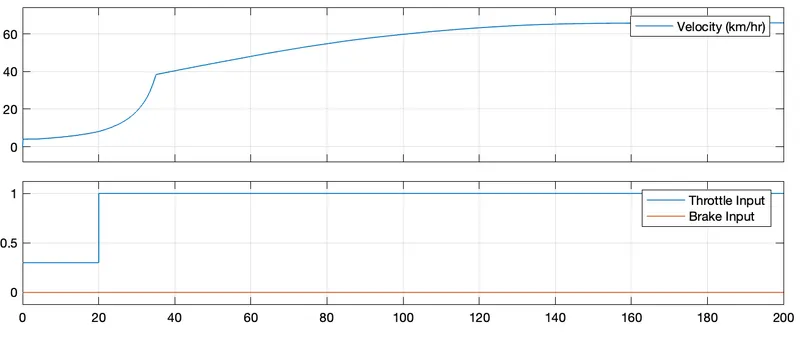
In this, Brake Input is 0 and the Throttle Input is 0.3 for 20 seconds later 1 for rest. The velocity of the vehicle shows gradual growth for the first 20 seconds later on it increases from 20-40 seconds till the speed gets stable.
CVT Shaft Speed
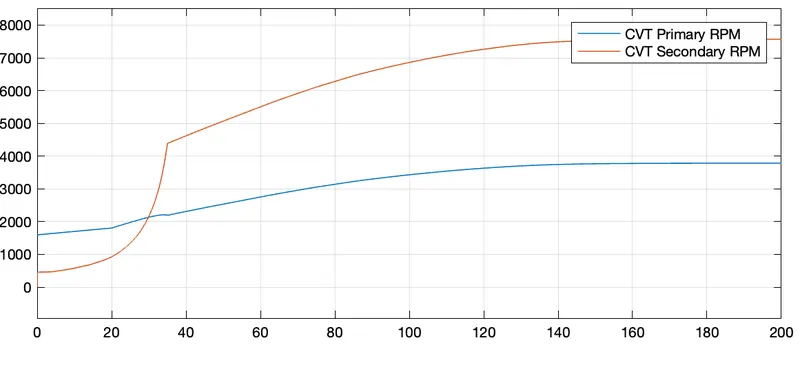
The CVT shows variations with respect to primary and secondary RMP based on their Gear Ratio.
STUDY 4: All-Terrain Vehicle (ATV) with CVT and Dashboard using Lookup Table
Model :
Explanation :
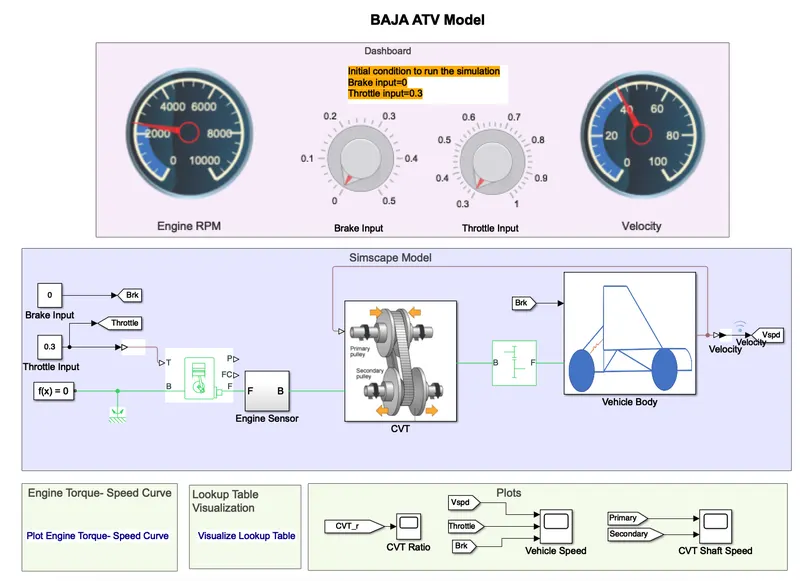
- This model is similar to the previous models. The only difference is Dashboard along with a Lookup Table.
- Here the inputs can be given using the knobs on the dashboard. One is for Brake and the other is for Throttle Inputs. The simultaneous changes will show us the impact on Vehicle Speed.
- Here Brake Input = 0 and Throttle Input can be increased or decreased during the simulation.
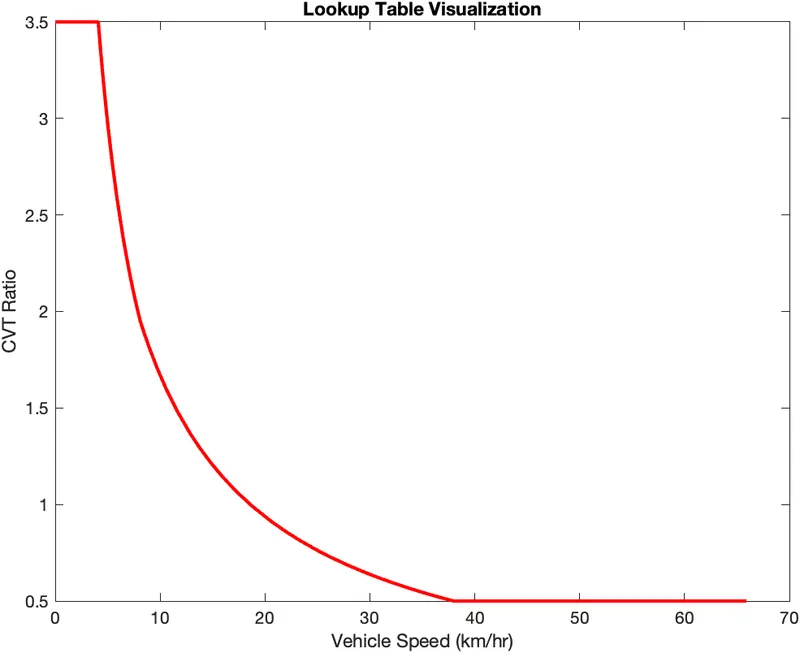
- The Lookup table values need to be arranged in ascending or descending order to work.
- We simulated for an inf period and gave Throttle input to get the final results.
Results :
Look UP table Visualization
Engine Speed
Vehicle Speed
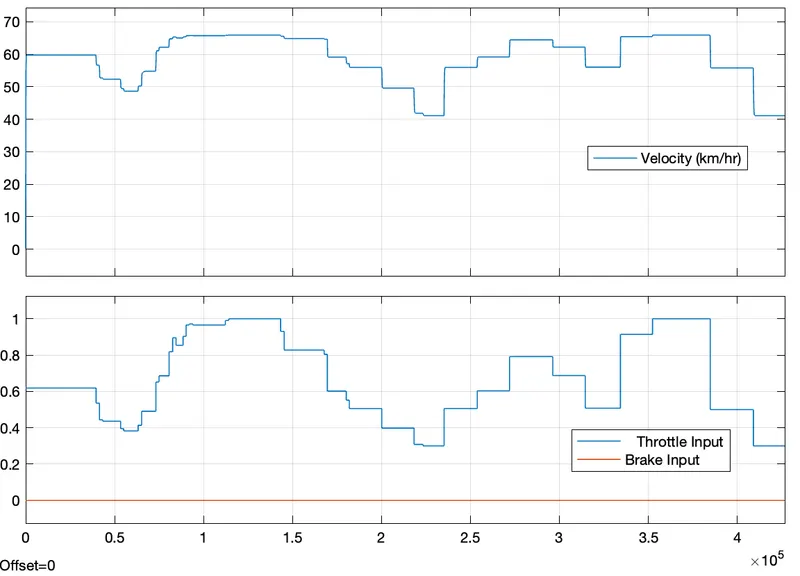
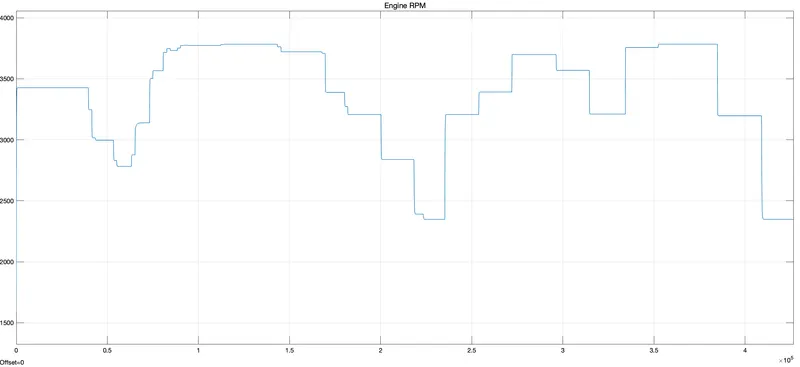
From the graph, once the throttle is increased the speed is increased and vice-versa for the decrease in the throttle input. The brake remains zero throughout the simulation. The Vehicle shows similar changes with reference to the throttle input.
CVT Shaft Speed
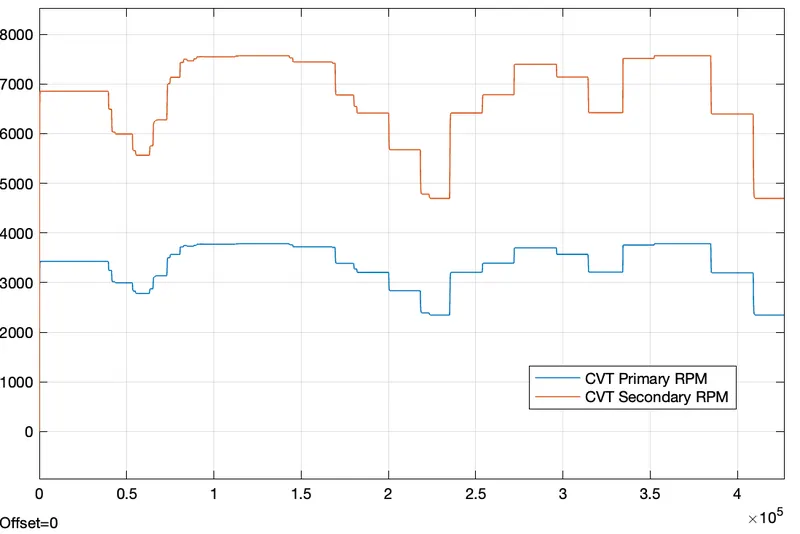
The CVT shows variations with respect to primary and secondary RMP based on their Gear Ratio.
CONCLUSION :
We ran a system-level simulation for a BAJA All-Terrain Vehicle (ATV) model using CVT with or without Dashboard and Lookup Table based on the above-obtained results in the form of Engine Speed, Vehicle Speed, and CVT Shaft Speed helped to determine the vehicle's performance.
REFERENCES :