Project
AIM:
- To carry out a system level simulation of an All-Terrain Vehicle (ATV).
OBJECTIVE:
- To prepare a technical report explaining the different models and its properties and observing the results obtained from them.
INTRODUCTION:
ALL-TERRAIN VEHICLE (ATV):
- An all-terrain vehicle (ATV), also known as a light utility vehicle (LUV), a quad bike, or simply a quad, as defined by the American National Standard Institute (ANSI); is a vehicle that travels on low-pressure tires, with a seat that is straddled by the operator, along with handlebars for steering control. As the name implies, it is designed to handle a wider variety of terrain than most other vehicles. Although it is a street legal vehicle in some countries, it is not street-legal within most states, territories, and provinces of Australia, the United States or Canada.
- By the current ANSI definition, ATVs are intended for use by a single operator, although some companies have developed ATVs intended for use by the operator and one passenger. These ATVs are referred to as tandem ATVs.
- The rider sits on and operates these vehicles like a motorcycle, but the extra wheels give more stability at slower speeds. Although most are equipped with three or four wheels, six-wheel models exist for specialized applications. Multiple-user analogues with side-by-side seating are called Utility Terrain Vehicle (UTV) to distinguish the classes of vehicle. Both classes tend to have similar powertrain parts.
- An all-terrain vehicle (ATV) is defined as a motorized off-highway vehicle designed to travel on four low-pressure or non-pneumatic tires, having a seat designed to be straddled by the operator and handlebars for steering control. ATVs are subdivided into two types as designated by the manufacturer. Type I ATVs are intended by the manufacturer for use by a single operator and no passenger. Type II ATVs are intended by the manufacturer for use by an operator and a passenger, and are equipped with a designated seating position behind the operator. Similarly, riders must also consider the various ATV sizes.
- ATVs are not “one size fits all.” The ATV industry recommends all riders operate an ATV intended for their age. Youth model ATVs are designed for smaller hands and feet, and travel at slower speeds appropriate for their age.
MODELS:
1. CVT MODEL:
- Contains Simscape model of BAJA ATV with Continuous Variable Transmission.
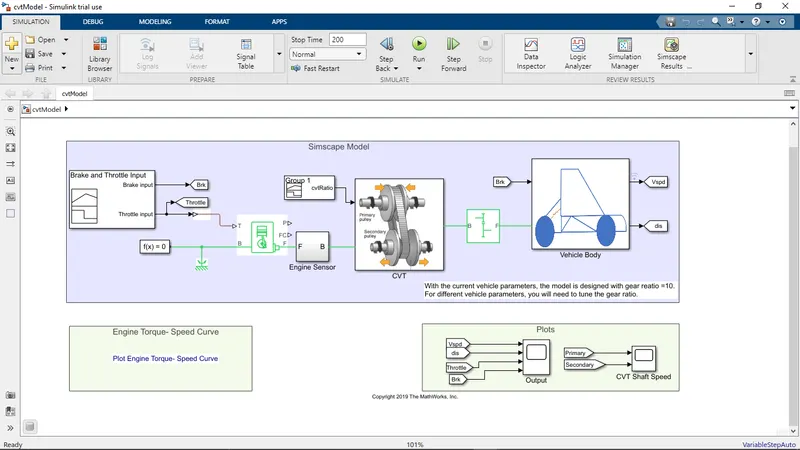
- In this model we can observe the working of BAJA ATV Model with Continuous Variable Transmission.
- While modelling the ATV we need to define the required Gear Ratio and also observe the effect of different parameter variations.
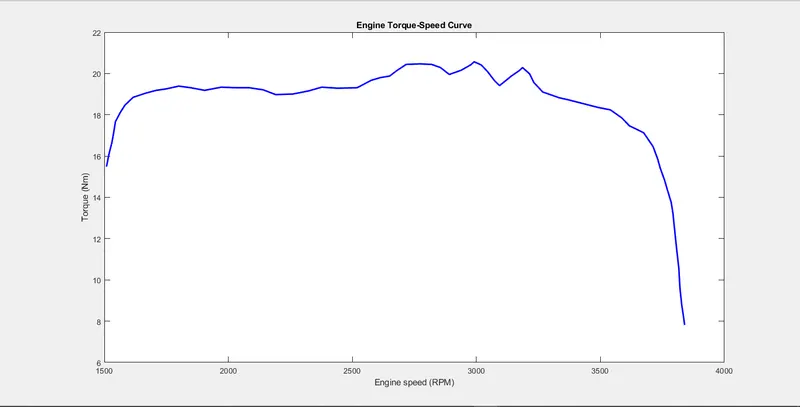
- Using GRABIT tool we can convert the Graphical plots to data values.
- This is required for the Engine Torque - Speed Curve.
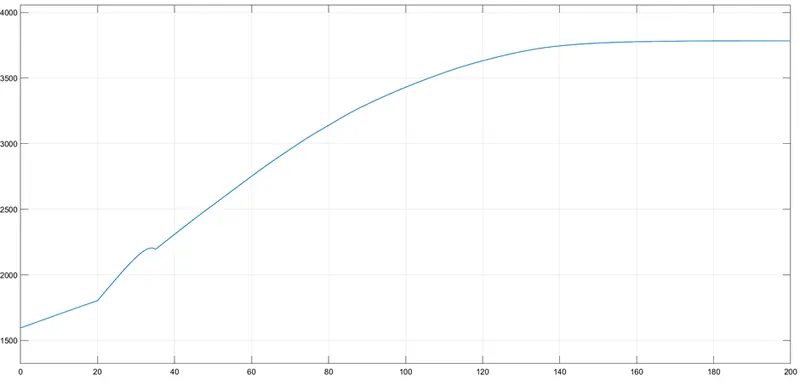
- For practical application or Realistic approach we need the proper speed to achieve the required Engine Torque in order to move the ATV.
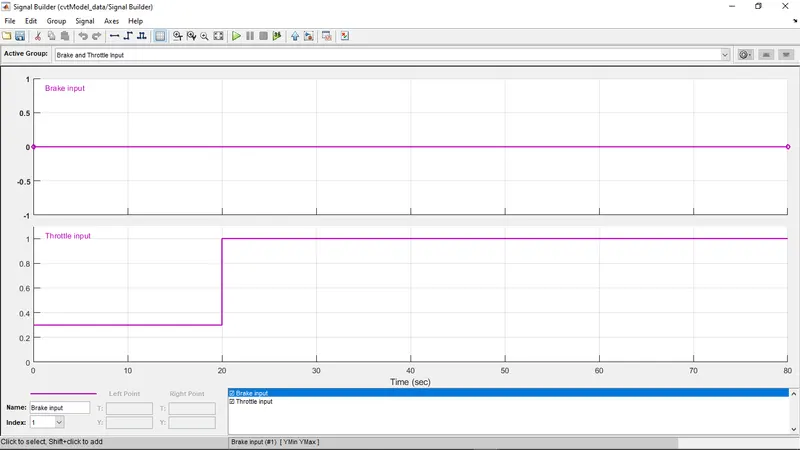
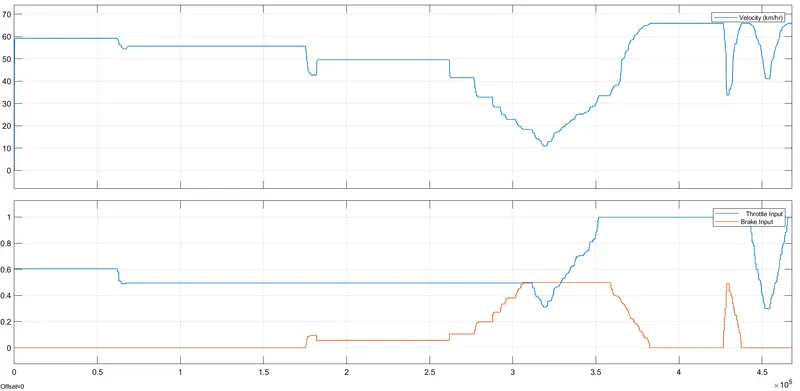
- In this model first a Signal builder is used to generate the throttle and brake value that is given as the input to the Engine.
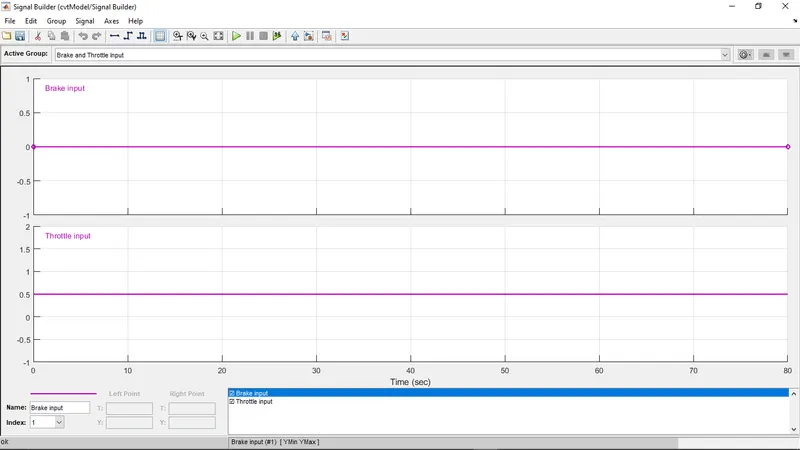
- This Throttle and Brake input generated by the Signal Builder is given to the Generic Engine block.
Generic Engine:
- Represents a system-level model of spark-ignition and diesel engines suitable for use at initial stages of modeling when only the basic parameters are available. Optional idle speed and red line controllers are included.
- The throttle input signal T lies between zero and one and specifies the torque demanded from the engine as a fraction of the maximum possible torque. If the engine speed falls below the Stall speed, the engine torque is blended to zero. If the engine speed exceeds the Maximum speed, the simulation stops and issues an error message.
- Connections F and B are mechanical rotational conserving ports associated with the engine crankshaft and engine block, respectively. Connections P and FC are physical signal output ports through which engine power and fuel consumption rate are reported.
- The values of Torque Vector and Engine Vector can be obtained from the Engine Torque - Speed Curve.
Engine Sensor:
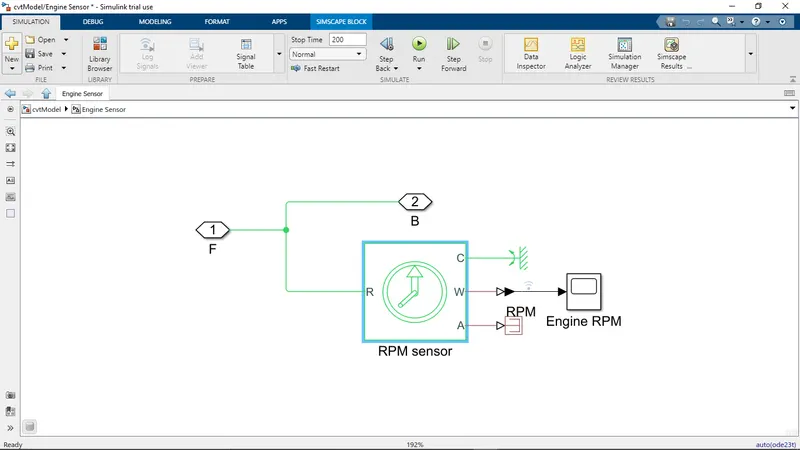
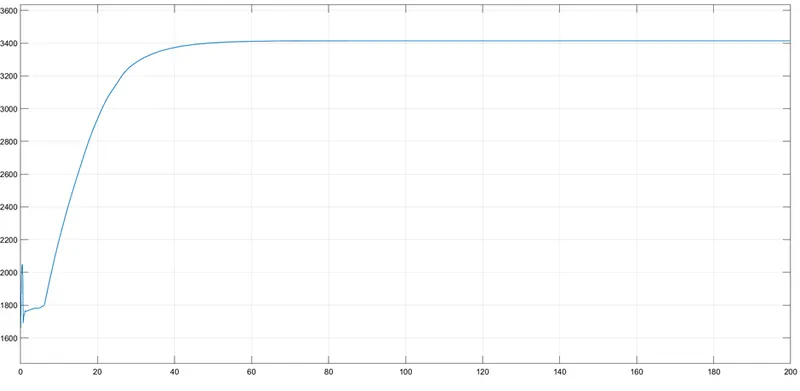
- The Engine Sensor is attached to the Generic Engine in order to observe the RPM of the Engine.
- The Engine Sensor contains an Ideal Rotational motion Sensor with a Scope connected to it to check the Engine RPM value.
CVT: CONTINUOUS VARIABLE TRANSMISSION:
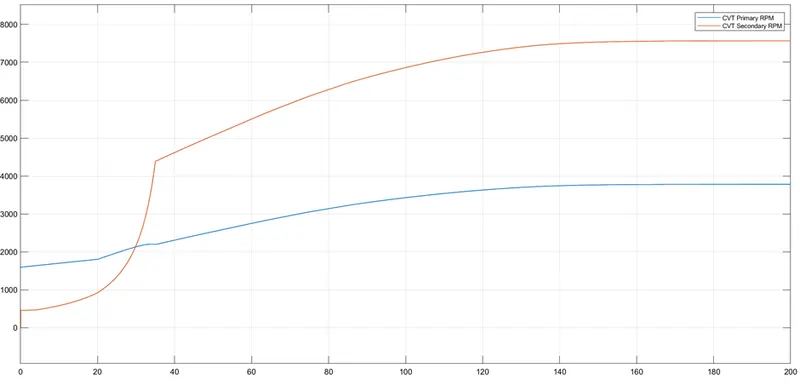
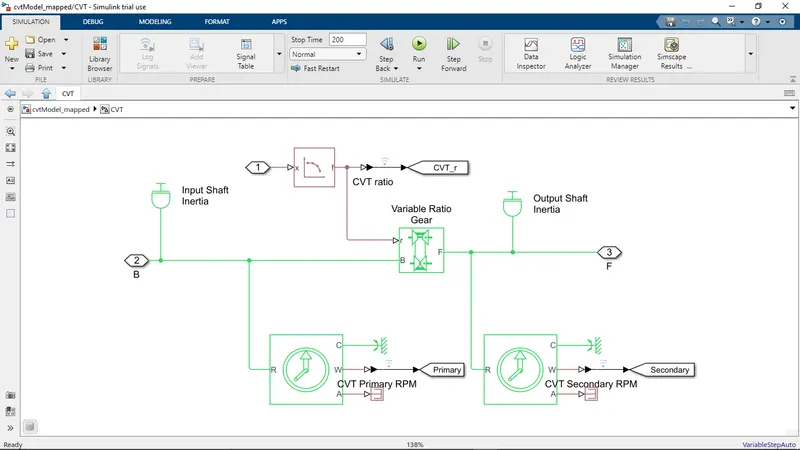
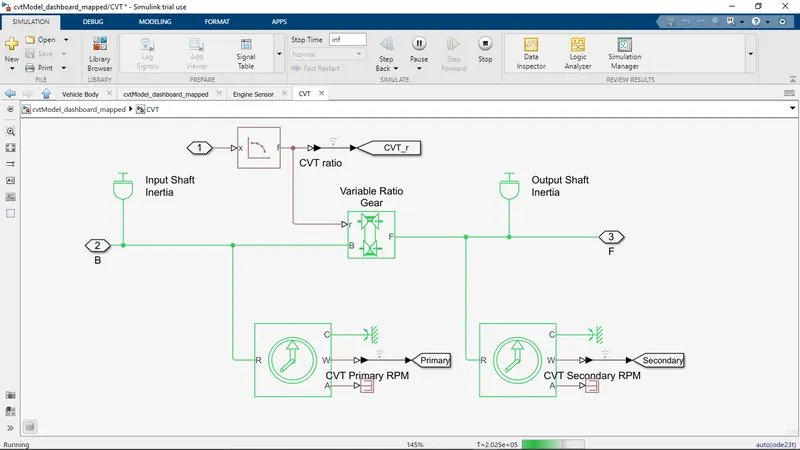
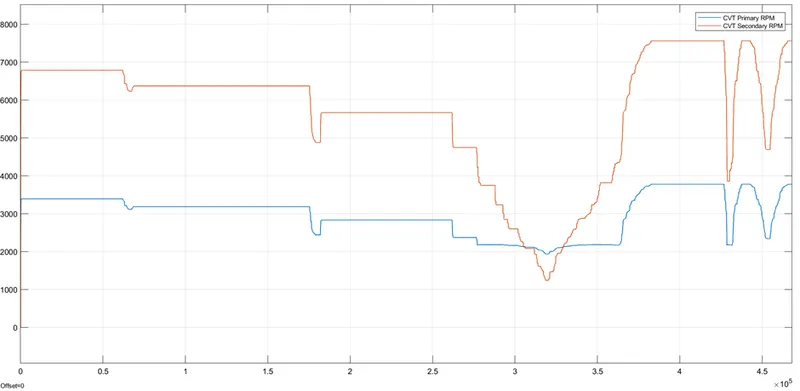
- The CVT block consists of Input shaft inertia which is the Primary Pulley and the Output shaft inertia which is the Secondary Pulley.
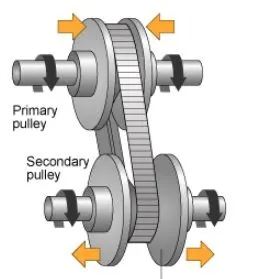
- The Variable Ratio Transmission represents a variable ratio gearbox such as implemented by mechanical belt CVT, electric, or hydraulic transmissions. The physical signal input r defines the ratio of input to output angular shaft velocities.
- Connections B (base) and F (follower) are mechanical rotational conserving ports. Specify the relation between base and follower rotation directions with the Output shaft rotates parameter.
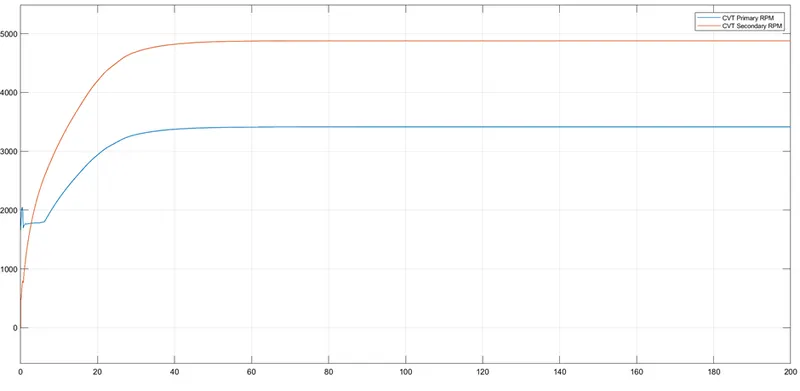
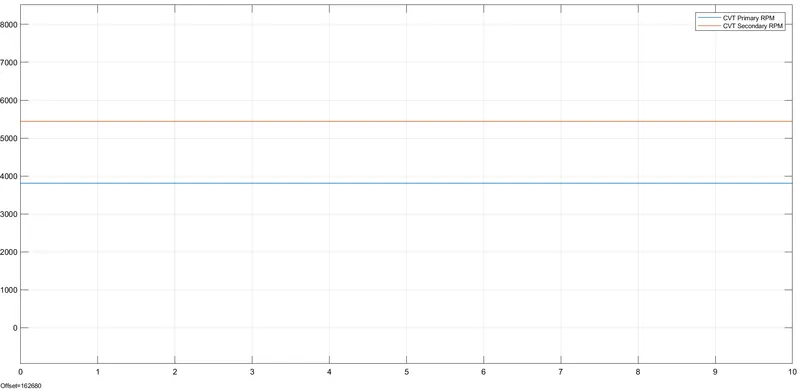
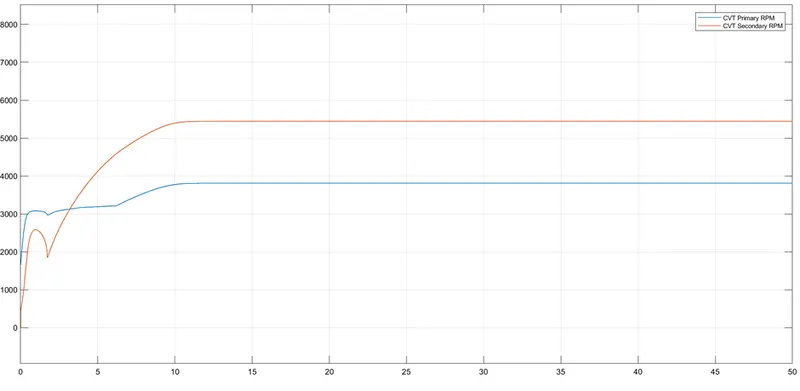
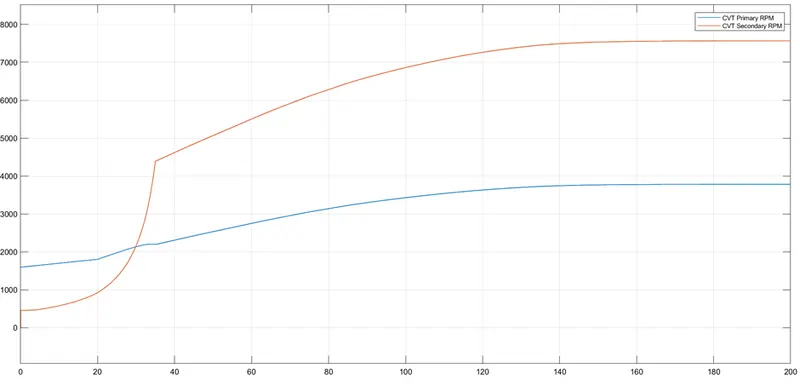
- Ideal Rotational Motion Sensors are connected across both the Input shaft and Output shaft in order to check the RPM value of the Primary and Secondary Pulleys.
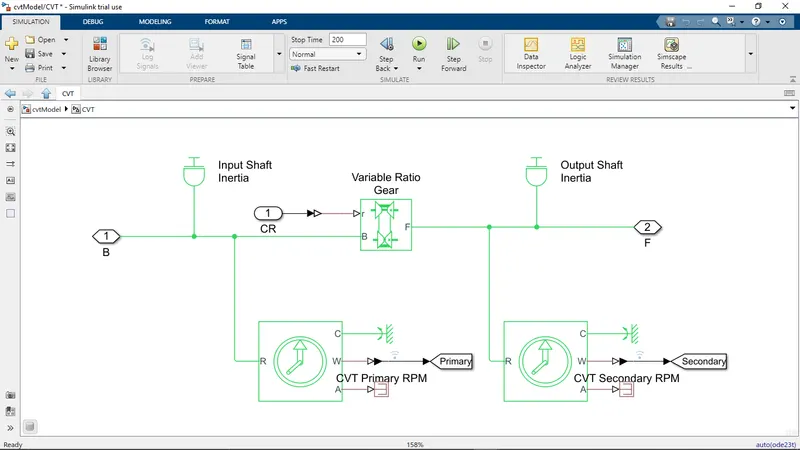
- The CVT block needs an input from the Engine Sensor block and CVT ratio signal for different speeds in order to operate the Primary and Secondary Pulley.
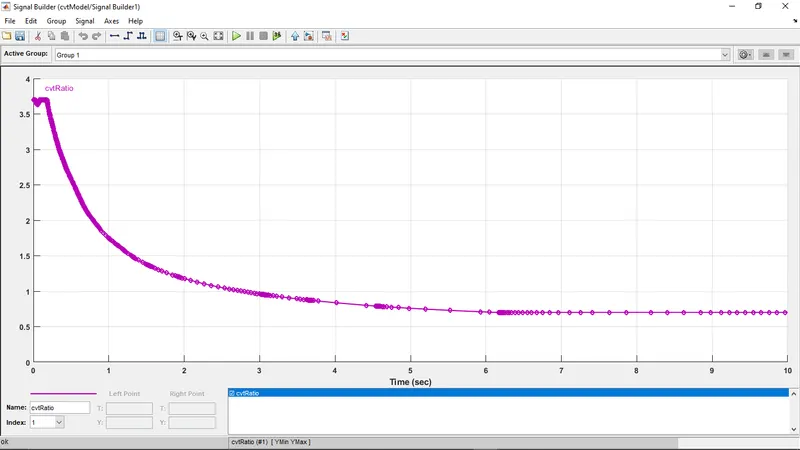
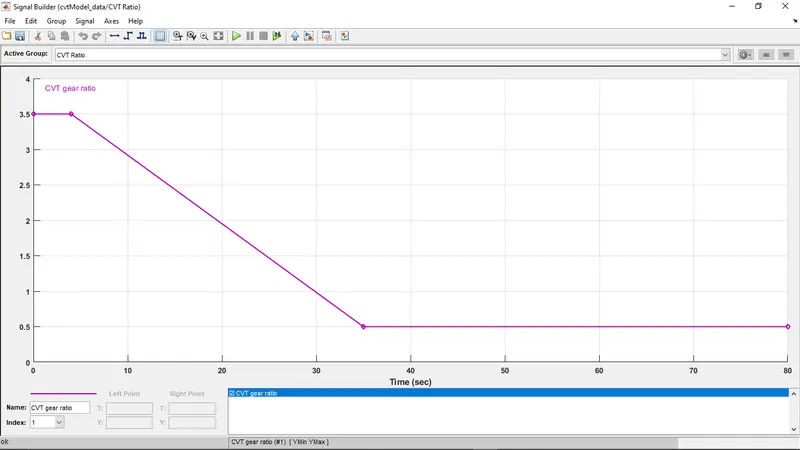
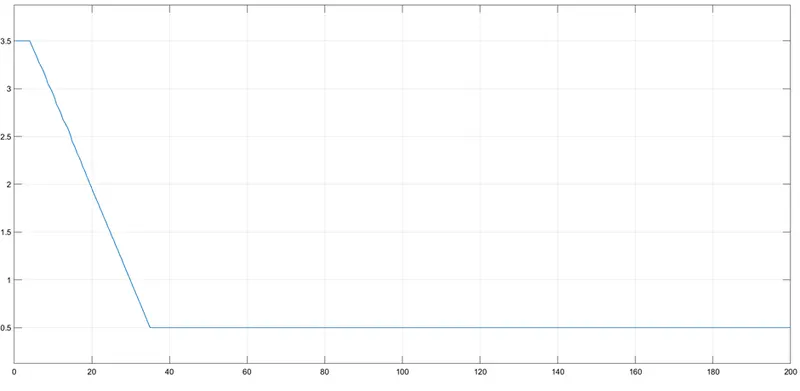
- CVT ratio is required for the operation of the Primary Pulley and the Secondary Pulley for a particular speed.
- According to the Engine RPM the position of the Primary Pulley and the Secondary Pulley should vary in order to have proper velocity of the vehicle and give proper torque to the vehicle to overcome obstacles.
- This Speed Reduction and Over Drive is dependent upon the CVT Ratio.
CVT RATIO SIGNAL BUILDER:
- CVT Ratio is obtained through the help of a Signal Builder block and this signal is given as the input to the CVT block.
SIMPLE GEAR:
- A gear box is attached between the Engine and the Differential to help achieve the speed and torque required by the vehicle.
- Represents a fixed-ratio gear or gear box. No inertia or compliance is modeled in this block. You can optionally include gear meshing, backlash, and viscous bearing losses.
- Connections B (base) and F (follower) are mechanical rotational conserving ports. Specify the relation between base and follower rotation directions with the Output shaft rotates parameter. Optionally include thermal effects and expose thermal conserving port H by setting Friction model to a temperature-dependent setting.
VEHICLE BODY:
- The Vehicle Body consists of different components of an automobile such as Double Shoe Brake, Wheels etc.
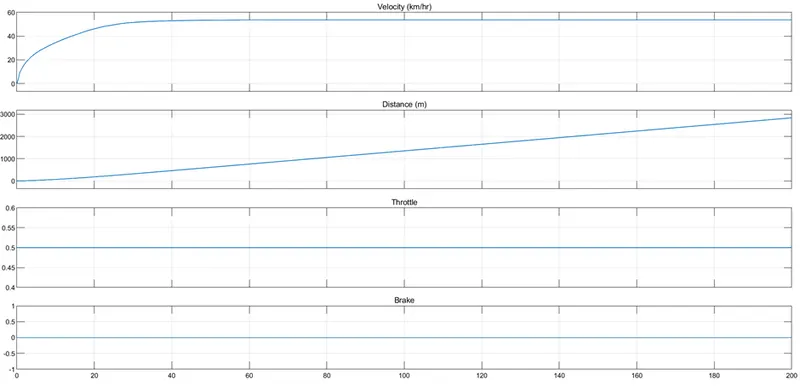
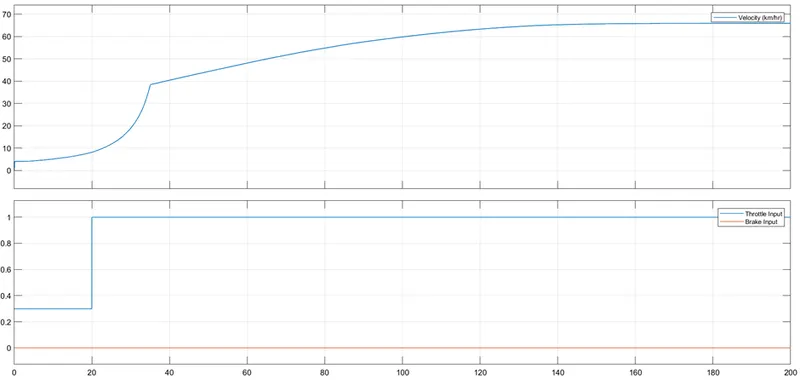
- Represents a two-axle vehicle body in longitudinal motion. The block accounts for body mass, aerodynamic drag, road incline, and weight distribution between axles due to acceleration and road profile. The vehicle can have the same or a different number of wheels on each axle. Optionally include pitch and suspension dynamics or additional variable mass and inertia. The vehicle does not move vertically relative to the ground.
- Connection H is the mechanical translational conserving port associated with the horizontal motion of the vehicle body. The resulting traction motion developed by tires should be connected to this port. Connections V, NF, and NR are physical signal output ports for vehicle velocity and front and rear normal wheel forces, respectively. Wheel forces are considered positive if acting downwards. Connections W and beta are physical signal input ports corresponding to headwind speed and road inclination angle, respectively. If variable mass is modeled, the physical signal input ports CG and M are exposed. CG accepts a two- element vector representing the x and y distance offsets from vehicle CG to additional load mass CG. M represents the additional mass. If both variable mass and pitch dynamics are included, the physical signal port J accepts the inertia of the additional mass about its own CG.
- The different properties of the Vehicle Body such as mass, Number of Wheels per axle, drag and pitch can be set according to our requirement in this block.
RESULT:
INPUT:
BRAKE AND THROTTLE INPUT SIGNAL:
ENGINE TORQUE - SPEED CURVE:
ENGINE RPM:
CVT RATIO:
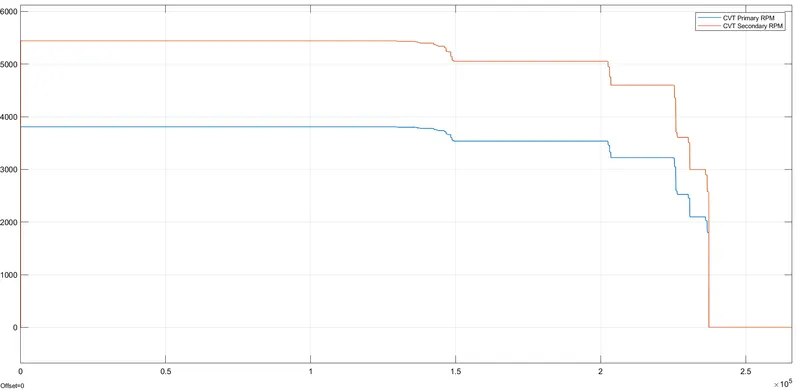
RPM OF PRIMARY AND SECONDARY PULLEY OF CVT BLOCK:
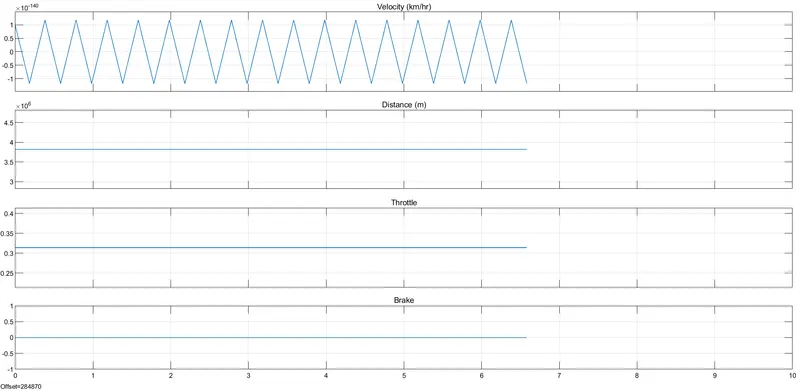
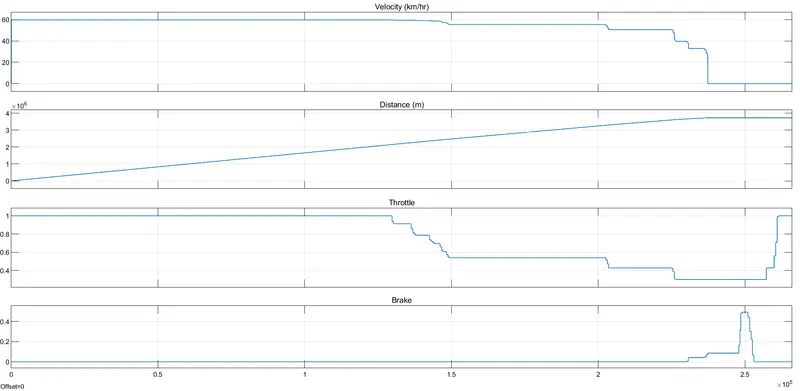
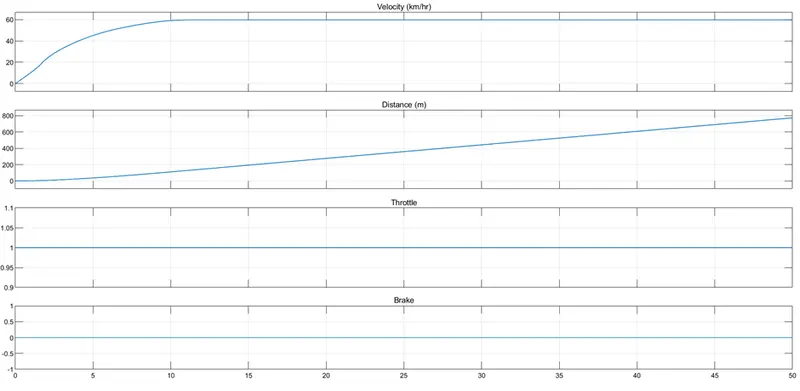
OUTPUT FROM VEHICLE BODY:
2. CVT MODEL WITH DASHBOARD:
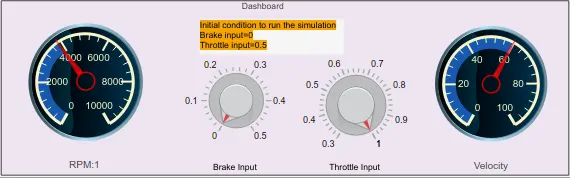
- The model is similar to, "CVT Model" with addition of dashboards.
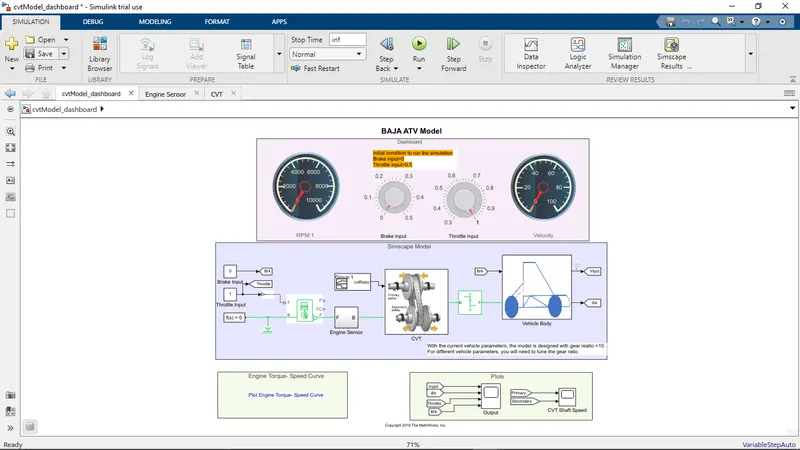
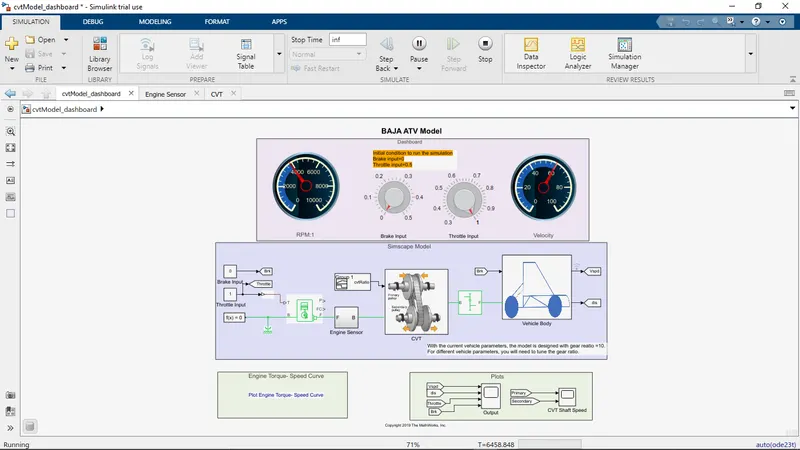
- In this model we can control the Brake Input and the Throttle Input my rotating the Knob present in the dashboard.
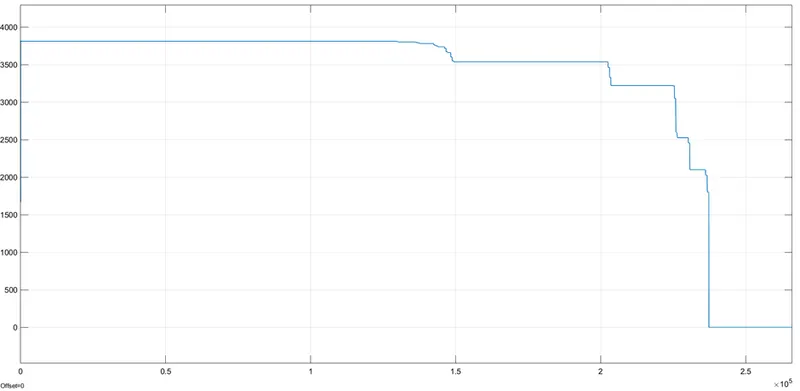
- By varying the Throttle and the Brake Input Engine RPM will change so as the Velocity of the Vehicle Body and distance travelled by the Vehicle Body.
- This model has a simulation time of infinity i.e. we can simulate the model by varying the throttle input and brake input through the simulation running as per our requirement.
- The previous model has a particular input signal of Throttle and Brake but in this model we can change it to any value as per our requirement.
RESULT:
INPUT:
BRAKE AND THROTTLE INPUT SIGNAL:
ENGINE TORQUE - SPEED CURVE:
ENGINE RPM:
CVT RATIO:
RPM OF PRIMARY AND SECONDARY PULLEY OF CVT BLOCK:
OUTPUT FROM VEHICLE BODY:
3. CVT MODEL WITH LOOK-UP TABLE CREATION:
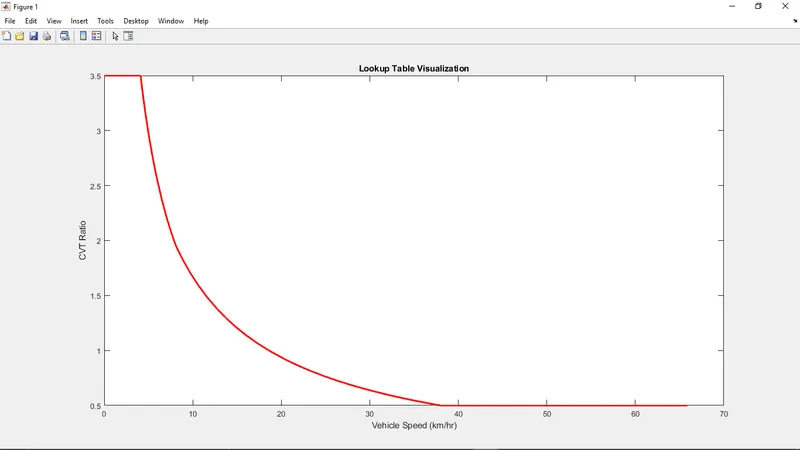
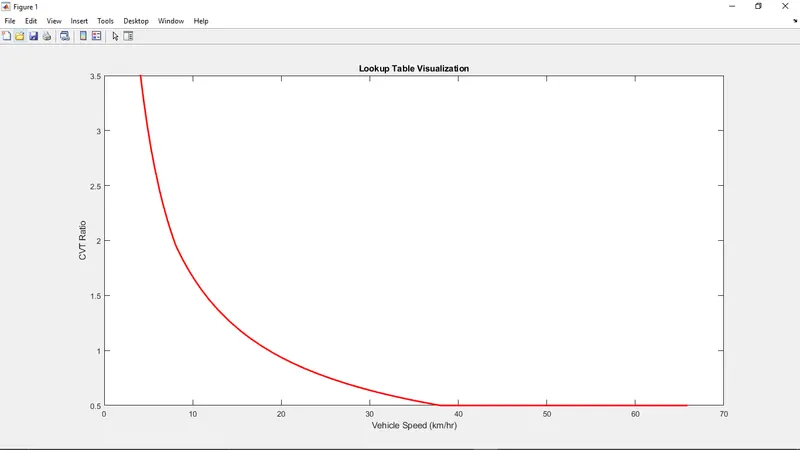
- This model is used to log the CVT ratio and vehicle speed for the look table visualization.
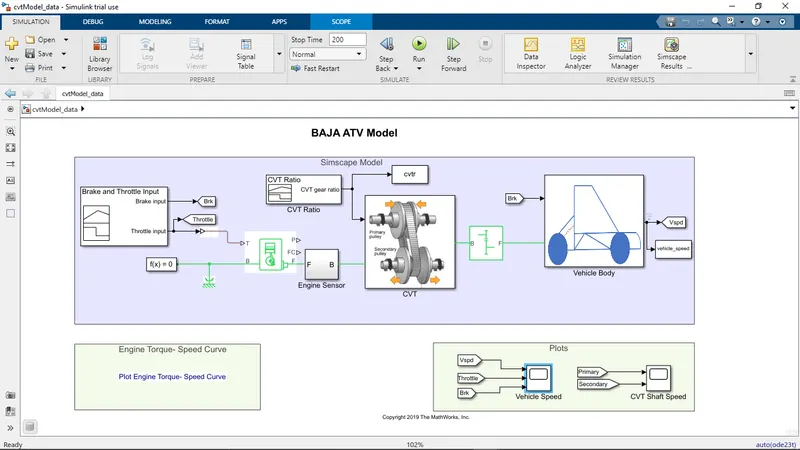
- In practical condition the CVT ratio depends upon the Vehicle velocity.
- So here in this model a look-up table is made so that the CVT ratio corresponding to the Vehicle velocity can be logged and later can be used to simulate another BAJA ATV model with the look-up table as the input to the CVT block.
- The look-up table is used for a closed loop model.
- To create a look-up table a script is written where the previous open loop model is used and the CVT ratio for the corresponding vehicle speed can be stored or logged and then this data can be used for the look-up table as an input to the CVT block.
RESULT:
THROTTLE AND BRAKE INPUT SIGNAL:
ENGINE TORQUE - SPEED CURVE:
ENGINE RPM:
CVT RATIO:
RPM OF PRIMARY AND SECONDARY PULLEY OF CVT BLOCK:
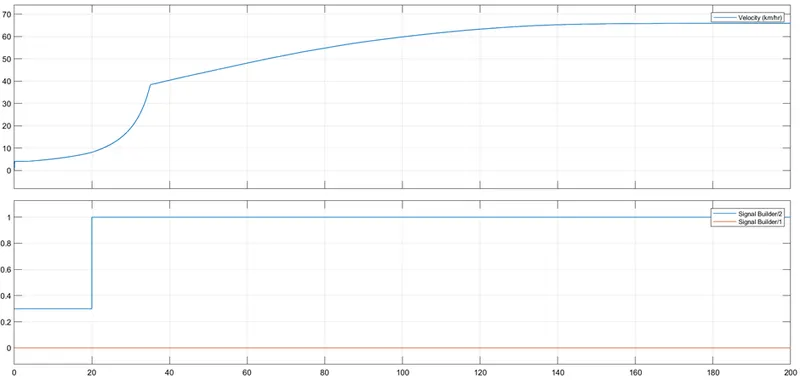
OUTPUT FROM VEHICLE BODY:
LOOK-UP TABLE VISUALIZATION:
4. CVT MODEL BASED ON LOOK-UP TABLE:
- This model contains model based on CVT ratio and engine rpm lookup table.
- This model is a closed loop model in which the input is given from the Look-Up table that we obtained from the previous model.
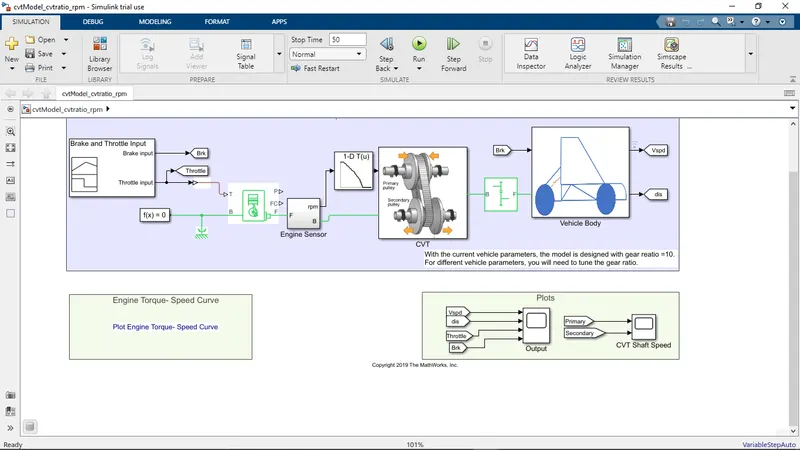
- In the previous model we have created a Look-Up table which stored the data of CVT ratio for the corresponding Vehicle Velocity.
- As we know that the CVT ratio is dependent upon the Vehicle velocity so this model will provide a practical result of the BAJA ATV model.
- Based on the data given to the Look-Up table it will calculate the required amount of CVT ratio that will be given as the input to the CVT blocks.
RESULT:
INPUT:
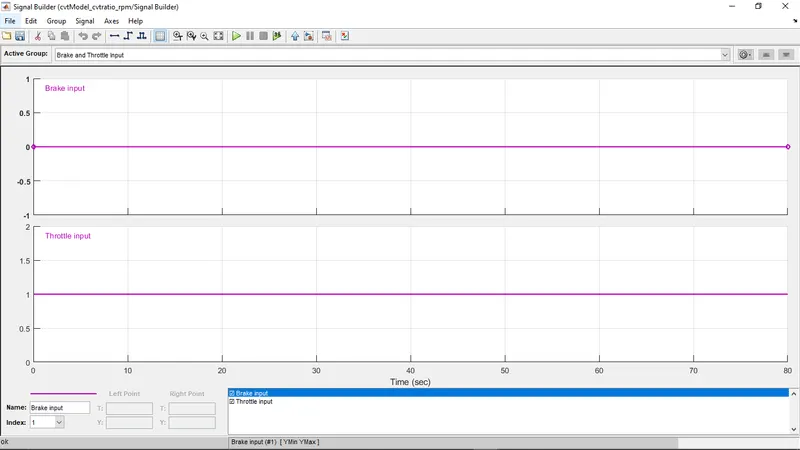
THROTTLE AND BRAKE INPUT SIGNAL:
ENGINE TORQUE - SPEED CURVE:
ENGINE RPM:
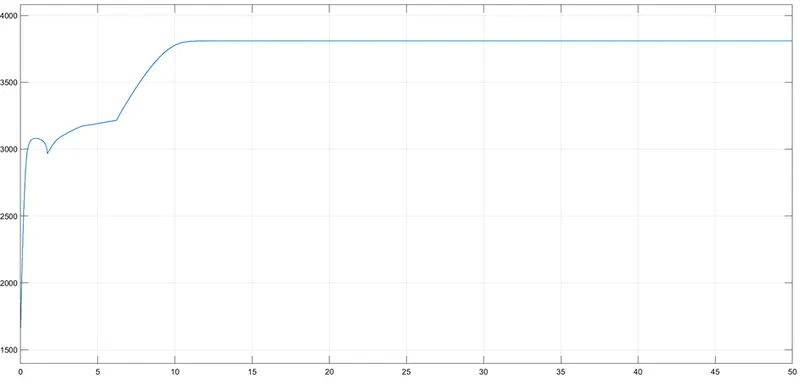
RPM OF PRIMARY AND SECONDARY PULLEY OF CVT BLOCK:
OUTPUT FROM VEHICLE BODY:
5. CVT MODEL WITH FEEDBACK:
- This model contains Simscape model of BAJA ATV with Continuous Variable Transmission where the CVT ratio varies based on 1D lookup table.
- As we know that the CVT ratio depends upon the Vehicle velocity so in this model the velocity obtained from the Vehicle Body is given as feedback to the CVT block where it generates the CVT ratio as per the given feedback.
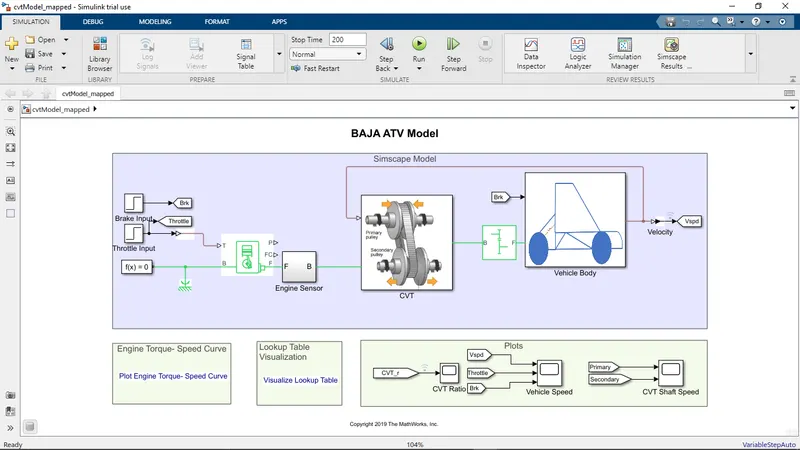
- In this model we can see that the Throttle and the Brake Input are given as a Step signal to the Generic Engine and according to the signal provided it produces the Engine RPM that can be seen using the Ideal Rotational Motion Sensor.
- We also can observe that the Output velocity from the Vehicle body is given as a feedback input to the CVT block.
- Also, in this model the Look-Up table is present inside the CVT block which takes feedback Velocity from the Vehicle body and provides the CVT ratio to the CVT module which then drives the Vehicle.
- Based on the data given to the Look-Up table it will calculate the required amount of CVT ratio that will be given as the input to the CVT blocks.
RESULT:
ENGINE TORQUE - SPEED CURVE:
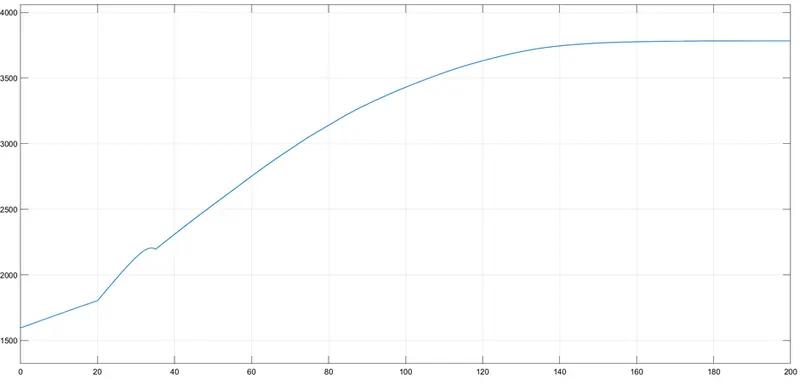
ENGINE RPM:
CVT RATIO:
RPM OF PRIMARY AND SECONDARY PULLEY OF CVT BLOCK:
OUTPUT FROM VEHICLE BODY:
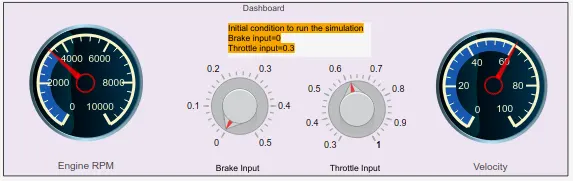
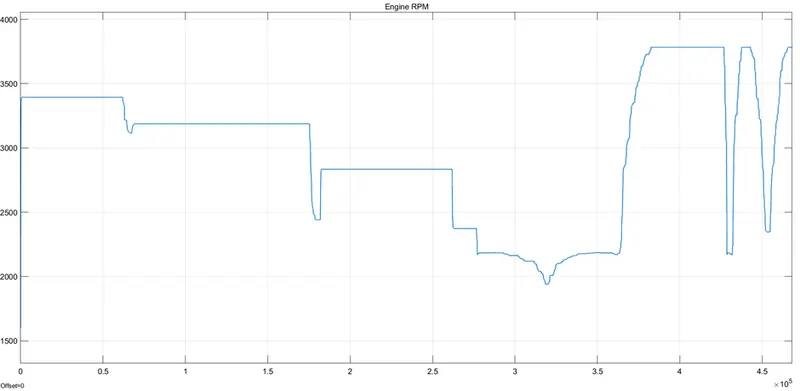
6. CVT MODEL WITH FEEDBACK AND DASHBOARD:
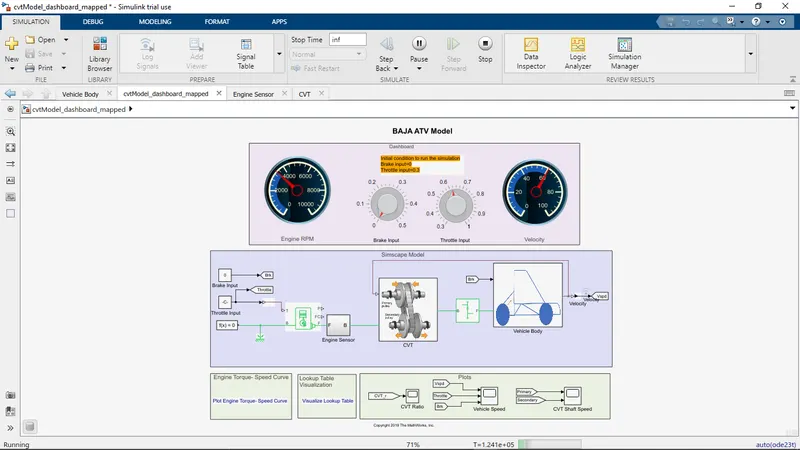
- The model is similar to, "CVT Model feedback" with addition of dashboards.
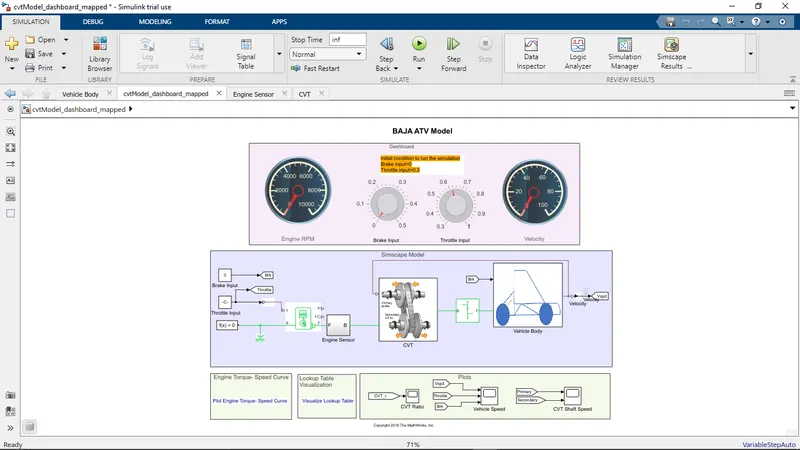
- In this model we can control the Brake Input and the Throttle Input my rotating the Knob present in the dashboard.
- By varying the Throttle and the Brake Input Engine RPM will change so as the Velocity of the Vehicle Body and distance travelled by the Vehicle Body.
- This model has a simulation time of infinity i.e. we can simulate the model by varying the throttle input and brake input through the simulation running as per our requirement.
- The previous model has a particular input signal of Throttle and Brake but in this model we can change it to any value as per our requirement.
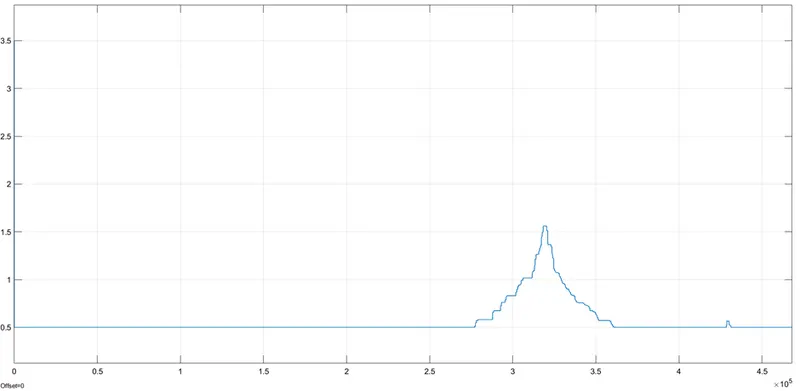
- We also can observe that the Output velocity from the Vehicle body is given as a feedback input to the CVT block.
- Also, in this model the Look-Up table is present inside the CVT block which takes feedback Velocity from the Vehicle body and provides the CVT ratio to the CVT module which then drives the Vehicle.
- Based on the data given to the Look-Up table it will calculate the required amount of CVT ratio that will be given as the input to the CVT blocks.
RESULT:
INPUT SIGNAL:
ENGINE TORQUE - SPEED CURVE:
ENGINE RPM:
CVT RATIO:
RPM OF PRIMARY AND SECONDARY PULLEY OF CVT BLOCK:
OUTPUT FROM VEHICLE BODY:
LOOK-UP TABLE VISUALIZATION:
CONCLUSION:
- From the above study we learnt about the Continuous Variable Transmission (CVT) system and its components.
- In the above study we performed simulation on 6 types of BAJA ATV CVT Models.
- We learnt how the CVT ratio depends upon the Vehicle Velocity.
- We also learnt how the Vehicle velocity varies by the CVT ratio.
- We learnt about the two types of models that is the Open Loop Model and the Closed Loop model.
- In Open Loop model the CVT ratio is given as the input to the CVT block whereas in the Closed Loop Model a Look-Up table is used to give the CVT ratio to the CVT blocks.
- We also created a Look-Up table where the CVT ratio for the corresponding velocity from the Vehicle body is logged or stored.
- We also learnt how to create a Look-Up table from the Open Loop Model so that it can be used in the Closed Loop Model so that based on the data given to the Look-Up table it calculates the required amount of CVT ratio.