Project
Carry out a system-level simulation of an all-terrain vehicle.
Download the model from the given link:
https://www.mathworks.com/matlabcentral/fileexchange/70576-baja-all-terrain-vehicle-atv-model
Prepare a technical report explaining the model properties & comments on the results.
Aim:
To prepare a technical simulation report on a BAJA all-terrain vehicle for a different conditions.
Objective:
To carry outa system level simulation of an BAJA all-terrain vehicle and prepare a technical report by explaining all the model properties used in it.i.e about the dashboard and llokup table.
ALL-TERRAIN VEHICLE:
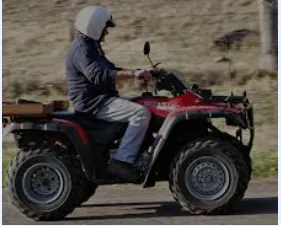
An all-terrain vehicle (ATV) is a small opened motor vehicle with one seat and three or four wheels fitted with large tyres for use on rough ground.It is an motorized off highway vehicle designed to travel on four low pressure tyres with a seat straddled by the operator and handlebars for steering control.In agriculture fields we use this type of vehicles.In this motor bike they used CVT transmission system.
CVT: Continuously Variable Transmission System.
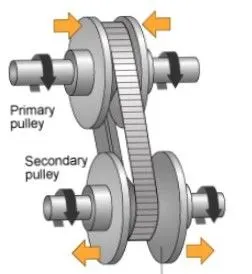
It is a transmission system, in which the power from engine transmitts to the wheels through the shaft.It is also type of automatic power transmission that provides more usable power,better fuel economy and a smoother driving experience than all the oldage designed vehicles.This system makes the possible way to vary the stepless the transmission ratio without altering the torque,therefore infinite number of minimum and maximum values are possible.It is an automatic,single speed gearless transmission throug a infinite number of gear shifts is possible,therefore it has smooth gear shifts even though we change the gear shift continuously and exceptional fuel economy.It draws top engine power from a small engine which gives drivers quicker acceleration than the traditional automatic transmission system.It has a greater ability to control the engine speed range,this system produces a fewer emissions.This system is also an weightless transmission system. When it is in a low gear provides more acceleration ,when it is in the high gears,can maximise the fuel economy.
STUDY1:
#Case1 Simulink Model for BAJA ATV with CVT
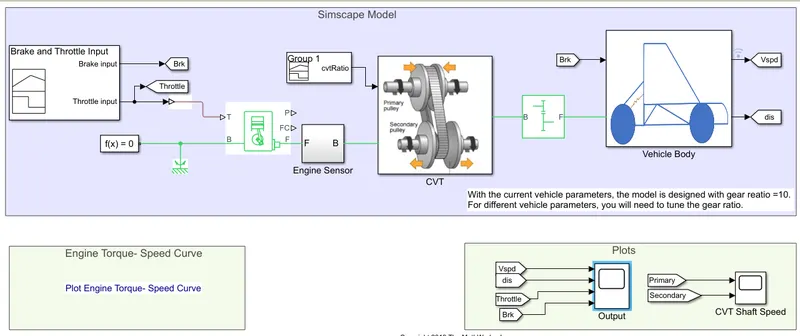
In this simulink model of CVT,it consists of signal buider,engine sensor,vehicle transmission,vehicle body,generic engine,motion sensor,tyresand solver configuration block etc..
CVT SUBSYSTEM
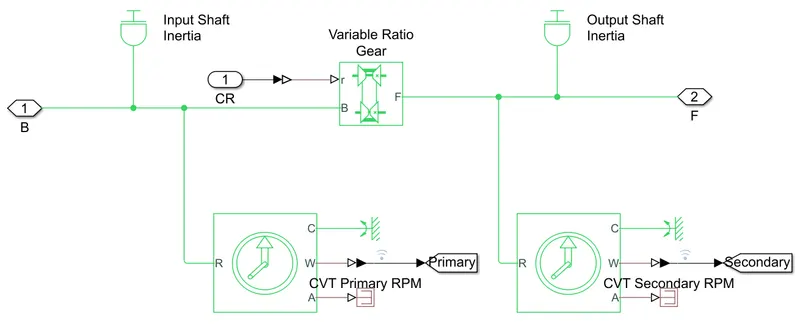
In this,CVT substem consists of input and output shaft inertia,variable gear ratio,transmission block and motion sensor.
VEHICLE BODY SUBSTEM:
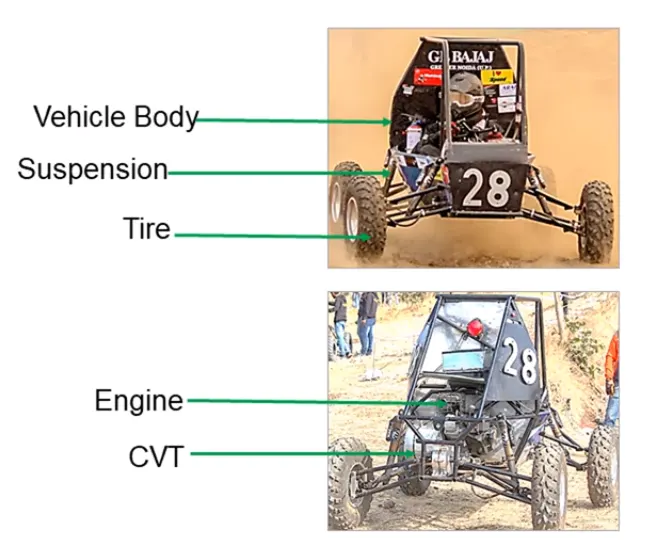
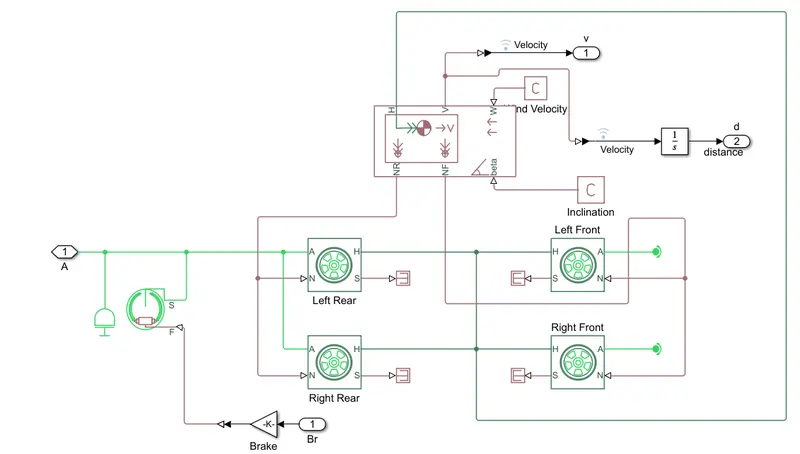
In this Vehicle body subsystem,vehicle body block,double drum brake and tyres.
Variable Transmission Ratio:
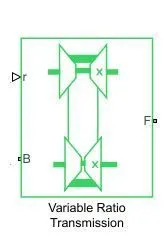
It represents a variable ratio gear box,such as implemented by mechanical belt CVT transmissions.The physical signal input r defines the ratio input to output angular shaft velocities.Connecting ports base(B) and (F)follower are mechanical rotational conserving ports.Specify the relation between base and the follower rotation direction with the output shaft rotates parameter.
GENERIC ENGINE:
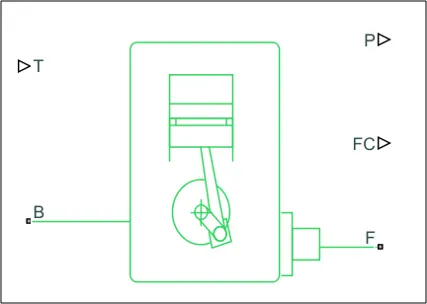
It represents a system level model of spark-ignition and diesel engine suitable for use at initial stages modelling when only the basic parameters are available.Optional idle speed and red controllers are included.THe throttle input signal Tis lies between 0 and 1 and specifies the torque demand from the engine as a fraction of the maximum possible torque.F is the mechanical rotational conserving port engine crank shaft and B is the engine block.Connections P and FC are physical signal output ports through which engine power and fuel consumption rates are reported.
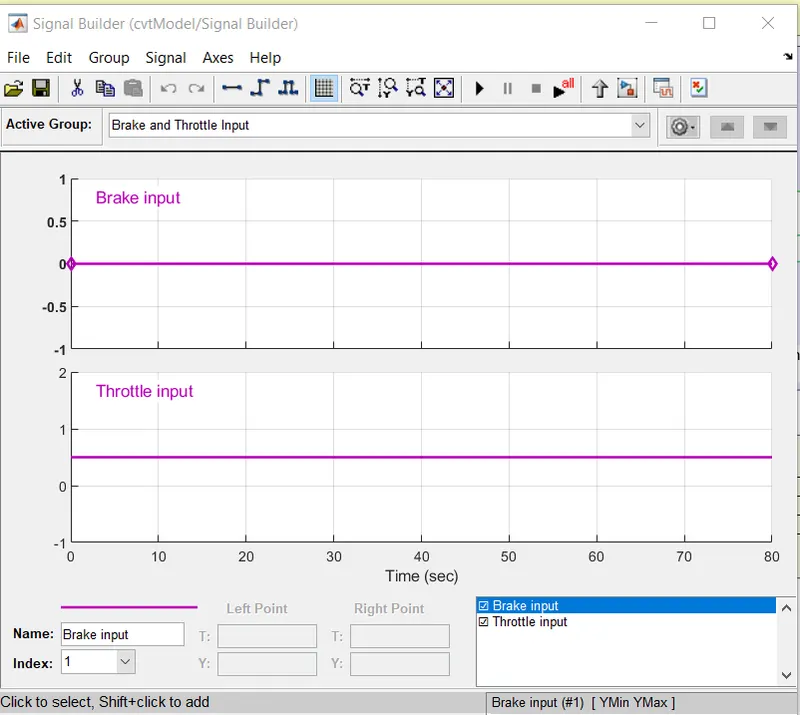
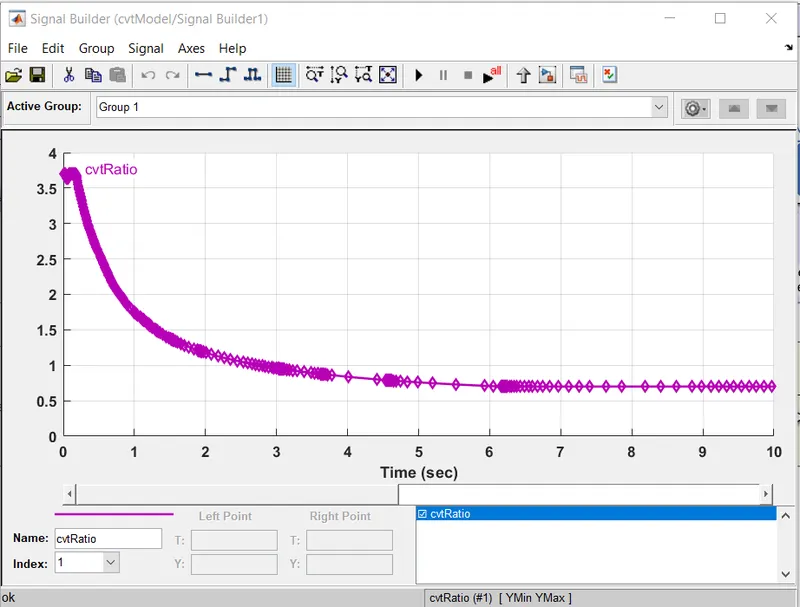
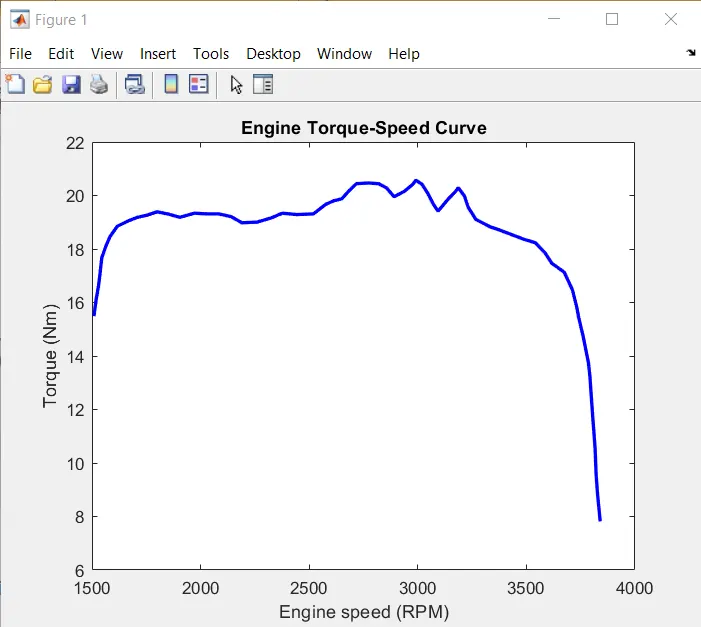
The signal builder is used to give the input for brake,throttle and gear ratio.
Brake input=0,Throttle input=0.5
CVT Gear Ratio input:
Torque V/s Speed Engine Input:
Output
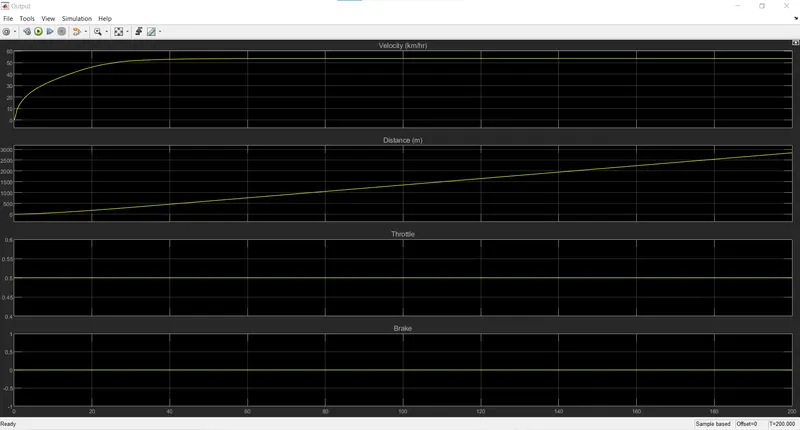
It is clear from the graph vehicle attain a maximum speed of the velocity 55km/h full throttle constant at 0.5 even though break input is 0,it doesnot affect on the vehicle speed for the given total period of time is 200sec.
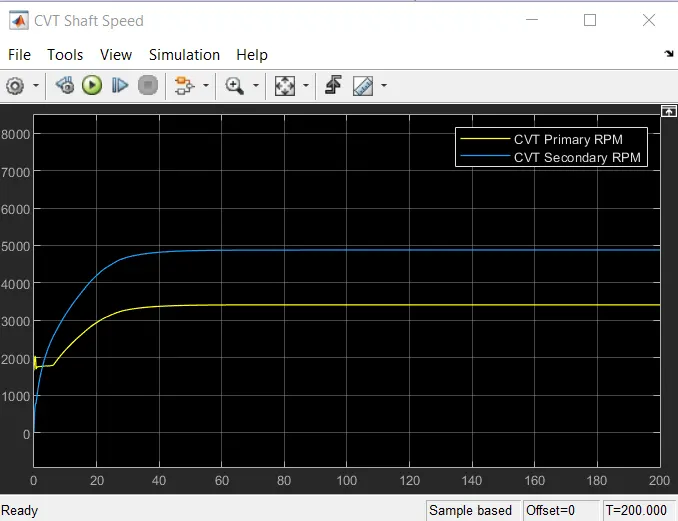
This graph shows the variation in angular velocities input and output shafts of the variable gear transmission system.This value differ with respect to the gear ratio.This model is designed with gear ratio 1.
SIMULINK MODEL OF BAJA AVT WITH CVT USING DASHBOARD
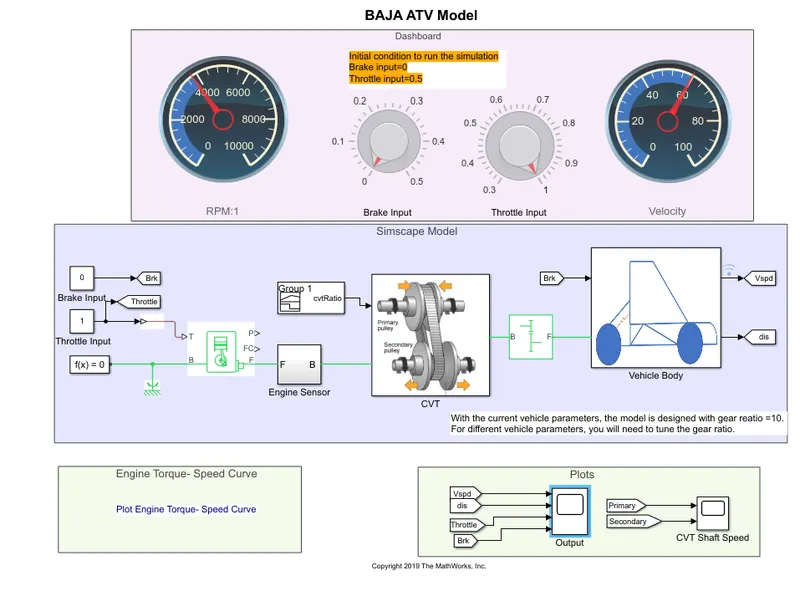
In this model,we have dashboard which contains a knob to control the inputs.This knob controls the input parameter brake and throttle inputs.
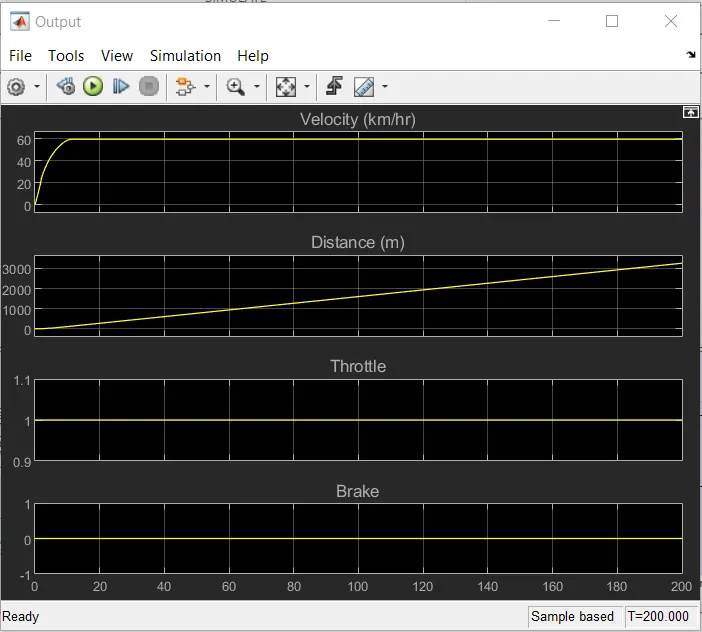
In this graph,the brake input =0,throttle input=1 and both are kept constant,the velocity of the vehicle upto 10sec gradually increases after that it will be also constanti.e 60kmph.If we vary the brake and throttle input then the velocity of the vehicle also vary if we give sudden bake at any point.therefore the velocity of the vehicle depends on the throttle and brake inputs.
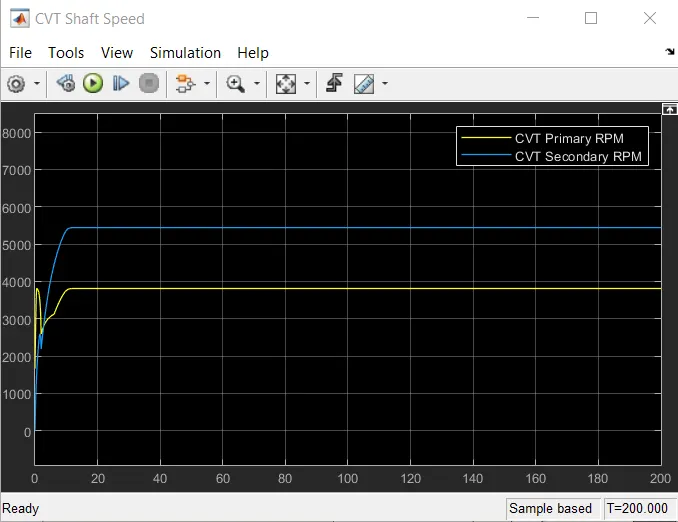
SIMULINK MODEL BAJA ATV WITH CVT USING LOOKUPTABLE:
CASE2
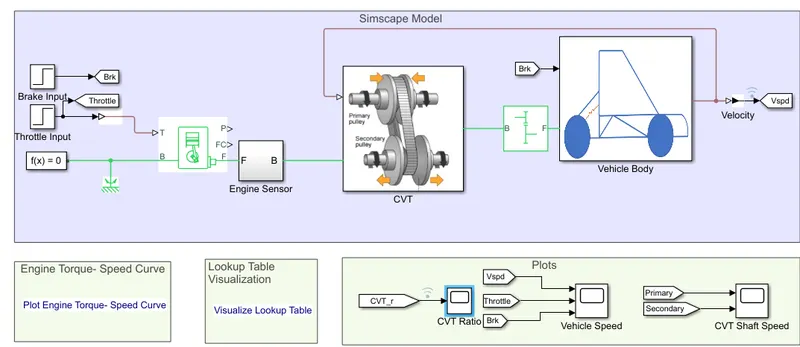
CVT WITH LOOKUP TABLE:
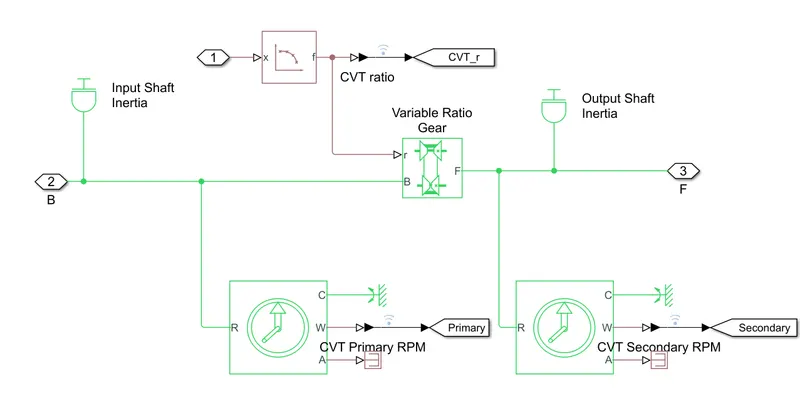
The only difference between this model and the first model,the gear input to cvt is given by lookup table.
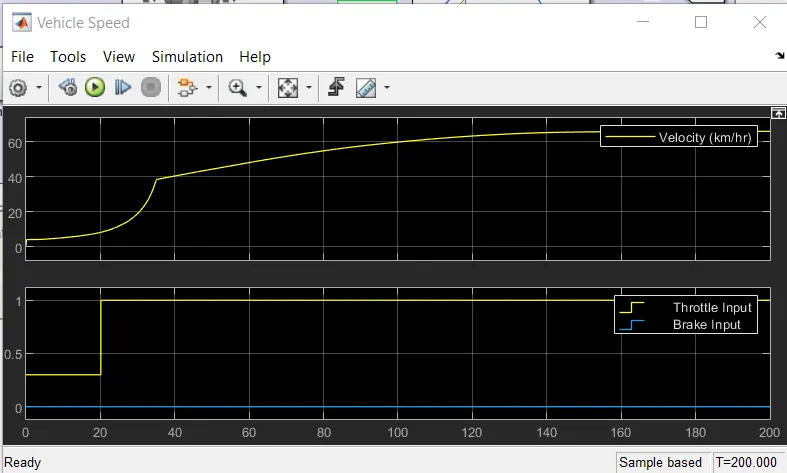
The vehicle velocity and the output rpm shafts are sameas before.
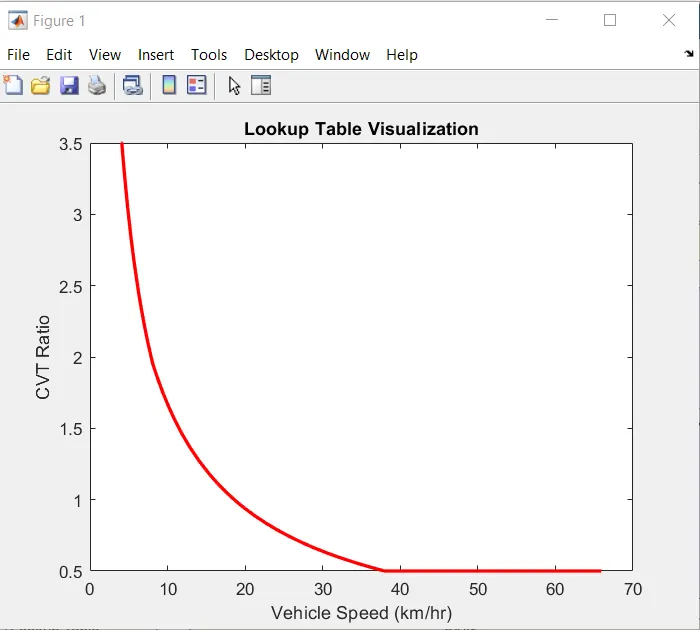
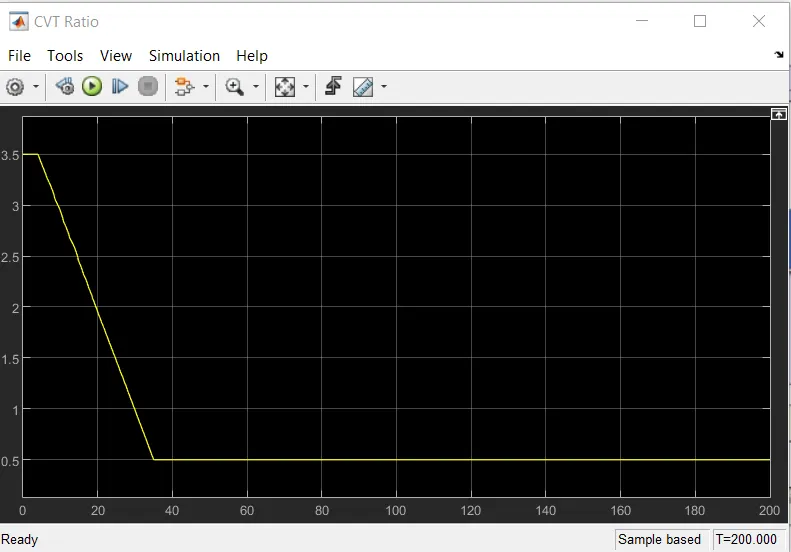
CVT GEAR RATIO:
VEHICLE SPEED:
CVT SHAFT RPM:
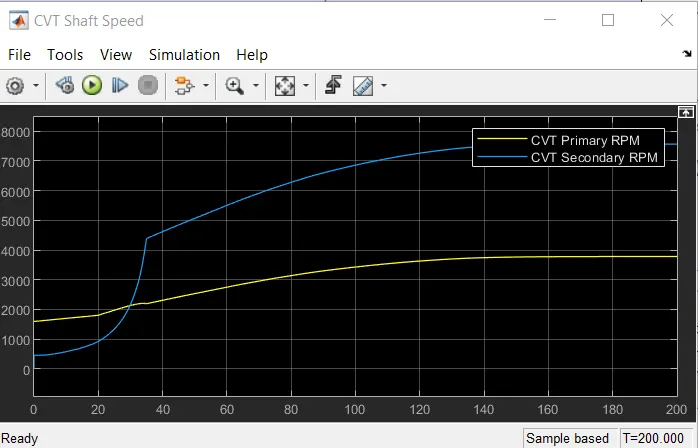
Both the outputs are same because the input parameters are same for both the cases.
SIMULINK MODEL BAJA ATV WITH CVT USING BOTH DASHBOARD AND LOOKUPTABLE:
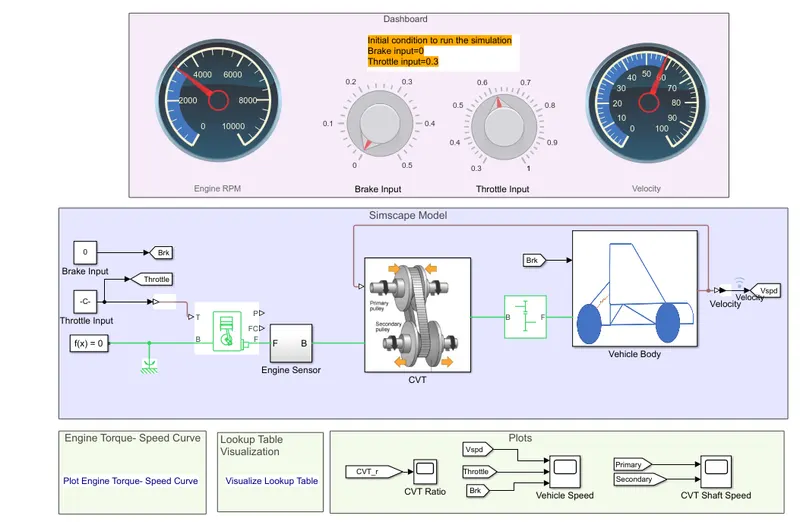
In this model dashboard controls the knob of brake and throttle input.
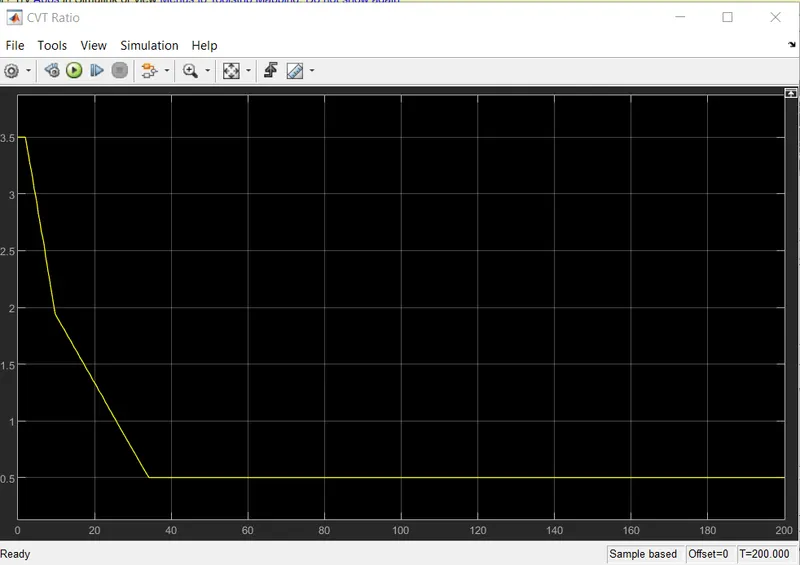
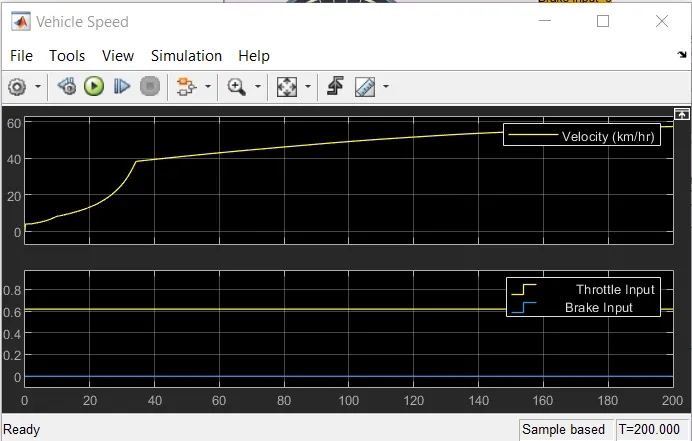
This graph shows that,as the velocity of the vehicle increases rapidly from 0 to 4, then it goes on increasing gradually from 0 to 33sec as the throttle and the brake points increases constantly.
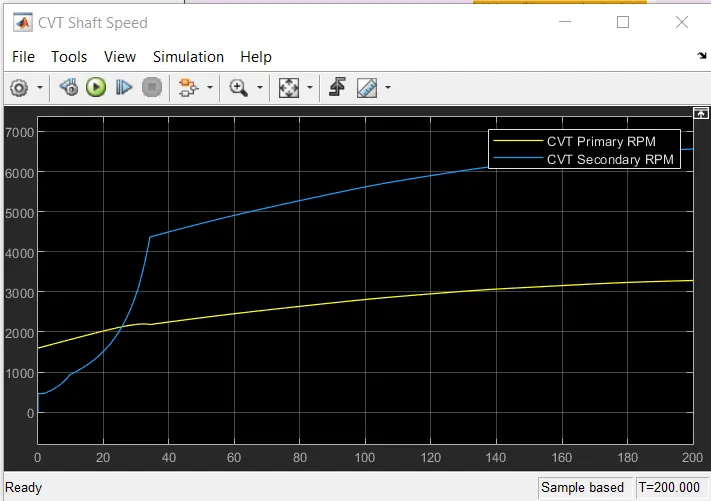
This rpm primary and secondary shafts vary with the input parameters.
CONCLUSION:
We analyzed the four types of BAJA ATV WITH CVT models and reporting all the outputs of vehicle velocity and rpm shaft with respect to the throttle,brake input parameters.