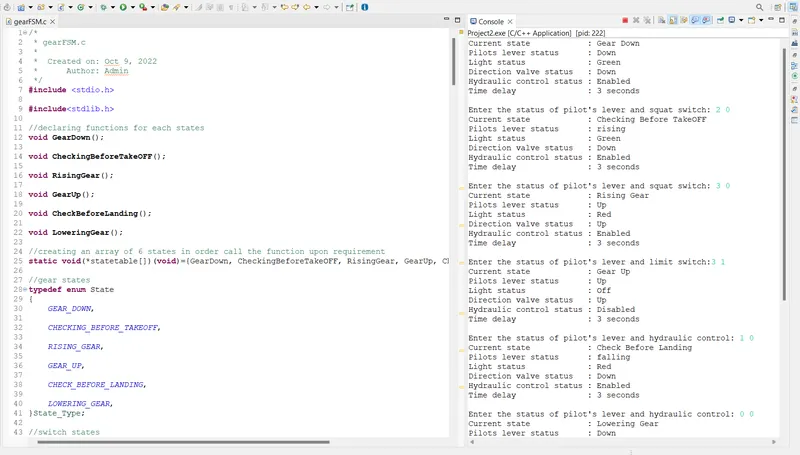
Project 2 - Implement the Code for controlling the retraction and extension of Airplane’s landing gear
LIVE BATCH 14 EMBEDDED SYSTEMS
Program:
/*
 * gearFSM.c
 *
 *  Created on: Oct 9, 2022
 *      Author: Admin
 */
#include

#include

//declaring functions for each states
void GearDown();

void CheckingBeforeTakeOFF();

void RisingGear();

void GearUp();

void CheckBeforeLanding();

void LoweringGear();

//creating an array of 6 states in order call the function upon requirement
static void(*statetable[])(void)={GearDown, CheckingBeforeTakeOFF, RisingGear, GearUp, CheckBeforeLanding, LoweringGear};

//gear states
typedef enum State
{
	GEAR_DOWN,

	CHECKING_BEFORE_TAKEOFF,

	RISING_GEAR,

	GEAR_UP,

	CHECK_BEFORE_LANDING,

	LOWERING_GEAR,
}State_Type;

//switch states
typedef enum Switch
{
	open, closed

}Switch_status;

//pilot lever states
typedef enum pilot_lever
{
	down, falling, rising, up

}pilot_lever;

//hydraulic control states
typedef enum hydraulic_mechanism
{
	enabled, disabled

}hydraulic_mechanism;

static volatile Switch_status squat_switch;

static volatile Switch_status limit_switch;

static volatile pilot_lever pl;

static volatile hydraulic_mechanism hm;

State_Type current_state;

//state table elements
typedef struct
{
	char* current_state_indication;

	char* light;

	char* direction_valve_status;

	int time;

	char* hydraulic_control;

	char* pilot_lever_status;

}State_Table;

//creating state table
static State_Table State_Machine[6]={

		{"Gear Down", "Green", "Down", 3, "Enabled", "Down"},

		{"Checking Before TakeOFF", "Green", "Down", 3, "Enabled", "rising"},

		{"Rising Gear", "Red", "Up", 3, "Enabled", "Up"},

		{"Gear Up", "Off", "Up", 3, "Disabled", "Up"},

		{"Check Before Landing", "Red", "Down", 3, "Enabled", "falling"},

		{"Lowering Gear", "Green", "Down", 3, "Enabled", "Down"}
};

int main()
{

	while(1)
	{
		statetable[current_state](); //calling each state functions
	}
}

//when airplane is grounded or parked
void GearDown(void)
{
	current_state = GEAR_DOWN;

	printf("Current state            : %s\n",State_Machine[current_state].current_state_indication);

	printf("Pilots lever status      : %s\n",State_Machine[current_state].pilot_lever_status);

	printf("Light status             : %s\n", State_Machine[current_state].light);

	printf("Direction valve status   : %s\n", State_Machine[current_state].direction_valve_status);

	printf("Hydraulic control status : %s\n", State_Machine[current_state].hydraulic_control);

	printf("Time delay               : %d seconds\n\n", State_Machine[current_state].time);

	printf("Enter the status of pilot's lever and squat switch: ");

	fflush(stdout);

	scanf("%d %d", &pl, &squat_switch);

	if(pl == rising && squat_switch == open)
	{
		current_state = CHECKING_BEFORE_TAKEOFF;

		printf("Current state            : %s\n",State_Machine[current_state].current_state_indication);

		printf("Pilots lever status      : %s\n",State_Machine[current_state].pilot_lever_status);

		printf("Light status             : %s\n", State_Machine[current_state].light);

		printf("Direction valve status   : %s\n", State_Machine[current_state].direction_valve_status);

		printf("Hydraulic control status : %s\n", State_Machine[current_state].hydraulic_control);

		printf("Time delay               : %d seconds\n\n", State_Machine[current_state].time);

	}
	else
	{
		GearDown();
	}
}

//when airplane is about to take off
void CheckingBeforeTakeOFF(void)
{
	current_state = CHECKING_BEFORE_TAKEOFF;

	printf("Enter the status of pilot's lever and squat switch: ");

	fflush(stdout);

	scanf("%d %d", &pl, &squat_switch);

	if(pl == falling && squat_switch == closed)
	{
		GearDown();
	}
	else if(pl == up && squat_switch == open)
	{
		current_state = RISING_GEAR;

		printf("Current state            : %s\n",State_Machine[current_state].current_state_indication);

		printf("Pilots lever status      : %s\n",State_Machine[current_state].pilot_lever_status);

		printf("Light status             : %s\n", State_Machine[current_state].light);

		printf("Direction valve status   : %s\n", State_Machine[current_state].direction_valve_status);

		printf("Hydraulic control status : %s\n", State_Machine[current_state].hydraulic_control);

		printf("Time delay               : %d seconds\n\n", State_Machine[current_state].time);
	}

}

//when airplane is taking off
void RisingGear(void)
{
	current_state = RISING_GEAR;

	printf("Enter the status of pilot's lever and limit switch:");

	fflush(stdout);

	scanf("%d %d", &pl, &limit_switch);

	if(pl == falling && limit_switch == closed)
	{
		current_state = CHECK_BEFORE_LANDING;

		printf("Current state            : %s\n",State_Machine[current_state].current_state_indication);

		printf("Pilots lever status      : %s\n",State_Machine[current_state].pilot_lever_status);

		printf("Light status             : %s\n", State_Machine[current_state].light);

		printf("Direction valve status   : %s\n", State_Machine[current_state].direction_valve_status);

		printf("Hydraulic control status : %s\n", State_Machine[current_state].hydraulic_control);

		printf("Time delay               : %d seconds\n\n", State_Machine[current_state].time);
	}
	else if(pl == up && limit_switch == closed)
	{
		current_state = GEAR_UP;

		printf("Current state            : %s\n",State_Machine[current_state].current_state_indication);

		printf("Pilots lever status      : %s\n",State_Machine[current_state].pilot_lever_status);

		printf("Light status             : %s\n", State_Machine[current_state].light);

		printf("Direction valve status   : %s\n", State_Machine[current_state].direction_valve_status);

		printf("Hydraulic control status : %s\n", State_Machine[current_state].hydraulic_control);

		printf("Time delay               : %d seconds\n\n", State_Machine[current_state].time);
	}

}

//when airplane is in airborne
void GearUp(void)
{
	current_state = GEAR_UP;

	printf("Enter the status of pilot's lever and hydraulic control: ");

	fflush(stdout);

	scanf("%d %d",&pl, &hm);

	if(pl == falling && hm == enabled)
	{
	current_state = CHECK_BEFORE_LANDING;

	printf("Current state            : %s\n",State_Machine[current_state].current_state_indication);

	printf("Pilots lever status      : %s\n",State_Machine[current_state].pilot_lever_status);

	printf("Light status             : %s\n", State_Machine[current_state].light);

	printf("Direction valve status   : %s\n", State_Machine[current_state].direction_valve_status);

	printf("Hydraulic control status : %s\n", State_Machine[current_state].hydraulic_control);

	printf("Time delay               : %d seconds\n\n", State_Machine[current_state].time);
    }
	else if(pl == up && hm == disabled)
	{
		GearUp();
	}

}

//when airplane is about to land
void CheckBeforeLanding(void)
{
	current_state = CHECK_BEFORE_LANDING;

	printf("Enter the status of pilot's lever and hydraulic control: ");

	fflush(stdout);

	scanf("%d %d", &pl, &hm);

	if(pl == down)
	{
		current_state = LOWERING_GEAR;

		printf("Current state            : %s\n",State_Machine[current_state].current_state_indication);

		printf("Pilots lever status      : %s\n",State_Machine[current_state].pilot_lever_status);

		printf("Light status             : %s\n", State_Machine[current_state].light);

		printf("Direction valve status   : %s\n", State_Machine[current_state].direction_valve_status);

		printf("Hydraulic control status : %s\n", State_Machine[current_state].hydraulic_control);

		printf("Time delay               : %d seconds\n\n", State_Machine[current_state].time);
	}
	else if(pl == falling)
	{
		CheckBeforeLanding();
	}
}

//when airplane is landing
void LoweringGear(void)
{
	current_state = LOWERING_GEAR;

	printf("Enter the status of pilot's lever and limit switch:");

	fflush(stdout);

	scanf("%d %d", &pl, &limit_switch);

	if(pl == rising)
	{
		current_state = CHECKING_BEFORE_TAKEOFF;

		printf("Current state            : %s\n",State_Machine[current_state].current_state_indication);

		printf("Pilots lever status      : %s\n",State_Machine[current_state].pilot_lever_status);

		printf("Light status             : %s\n", State_Machine[current_state].light);

		printf("Direction valve status   : %s\n", State_Machine[current_state].direction_valve_status);

		printf("Hydraulic control status : %s\n", State_Machine[current_state].hydraulic_control);

		printf("Time delay               : %d seconds\n\n", State_Machine[current_state].time);
	}
	else if(pl == down && limit_switch == open)
	{
		current_state = GEAR_DOWN;

		printf("Current state            : %s\n",State_Machine[current_state].current_state_indication);

		printf("Pilots lever status      : %s\n",State_Machine[current_state].pilot_lever_status);

		printf("Light status             : %s\n", State_Machine[current_state].light);

		printf("Direction valve status   : %s\n", State_Machine[current_state].direction_valve_status);

		printf("Hydraulic control status : %s\n", State_Machine[current_state].hydraulic_control);

		printf("Time delay               : %d seconds\n\n", State_Machine[current_state].time);
	}
}
Output: