Project 2 - Implement the Code for controlling the retraction and extension of Airplane’s landing gear
PROGRAM:
#include<stdio.h>
#include<string.h>
//limit switch and squat switch outputs are declared as enum datatype
enum limit_switch
{
Close=1,
Open=0
}squat_switch,ls;
//pilot lever inputs are declared as enum datatype
enum pilot_lever
{
Raising=1,
Falling=0
}pilot_lever;
//squat switch and pilot lever input are declared as global variables
char *squat_switch_temp,*pilot_lever_temp;
//finite states are declared in enum datatype
enum states
{
Gear_down,
Check_before_takeoff,
Raising_gear,
Gear_up,
Check_before_landing,
Lowering_gear
}current_state;
//output parameters in each state is declared in struct datatype
struct state_machine
{
char *state_name;
char *ng_light,*lg_light,*rg_light;
char *direction_valve;
char *landing_gear;
}states[6];
//the struct elements are declared for each finite states
struct state_machine states[6] =
{
{"Gear_down","Green","Green","Green","Down","Enabled"},
{"Check_before_takeoff","Green","Green","Green","Down","Enabled"},
{"Raising_gear","Red","Red","Red","Up","Enabled"},
{"Gear_up","OFF","OFF","OFF","Null","Disabled"},
{"Check_before_landing","Red","Red","Red","Down","Enabled"},
{"Lowering_gear","Red","Red","Red","Down","Enabled"}
};
//declaration of each state function prototype
void gear_down();
void check_before_takeoff();
void raising_gear();
void gear_up();
void check_before_landing();
void lowering_gear();
//Initializing finite state machine
void Init_State_Machine()
{
current_state = Gear_down;
printf("\n*** The Finite state machine is initialized ***\nThe current state is %s ",states[current_state].state_name);
printf("\nNose gear light %s\nLeft gear light %s\nRight gear light %s",states[current_state].ng_light,states[current_state].lg_light,states[current_state].rg_light);
}
//FSM in gear down state and computing the inputs to move to next state
void gear_down()
{
current_state = Gear_down;
printf("\nEnter pilot lever condition\n0 - Falling\t1 - Raising\n");
scanf("%d",&pilot_lever);
printf("\nEnter squat switch condition\n0 - Open\t1 - Close\n");
scanf("%d",&squat_switch);
if(pilot_lever&&squat_switch)
{
current_state = Check_before_takeoff;
printf("\nThe current state is %s ",states[current_state].state_name);
printf("\nNose gear light %s\nLeft gear light %s\nRight gear light %s",states[current_state].ng_light,states[current_state].lg_light,states[current_state].rg_light);
check_before_takeoff();
}
else
{
gear_down();
}
}
//FSM in checking before takeoff state and checking the inputs to move to next state
void check_before_takeoff()
{
current_state = Check_before_takeoff;
printf("\nEnter pilot lever condition\n0 - Falling\t1 - Raising\n");
scanf("%d",&pilot_lever);
printf("\nEnter squat switch condition\n0 - Open\t1 - Close\n");
scanf("%d",&squat_switch);
if(pilot_lever&&squat_switch)
{
current_state = Raising_gear;
printf("\nThe current state is %s ",states[current_state].state_name);
printf("\nNose gear light %s\nLeft gear light %s\nRight gear light %s",states[current_state].ng_light,states[current_state].lg_light,states[current_state].rg_light);
printf("\n Direction valve is %s",states[current_state].direction_valve);
raising_gear();
}
else
{
current_state = Gear_down;
printf("\nThe current state is %s ",states[current_state].state_name);
printf("\nNose gear light %s\nLeft gear light %s\nRight gear light %s",states[current_state].ng_light,states[current_state].lg_light,states[current_state].rg_light);
gear_down();
}
}
//FSM in raising_gear state and computing the inputs to move to next state
void raising_gear()
{
current_state = Raising_gear;
printf("\nEnter pilot lever condition\n0 - Falling\t1 - Raising\n");
scanf("%d",&pilot_lever);
printf("\nEnter limit switch condition\n0 - Open\t1 - Close\n");
scanf("%d",&ls);
if(pilot_lever==0)
{
current_state = Check_before_landing;
printf("\nThe current state is %s ",states[current_state].state_name);
printf("\nNose gear light %s\nLeft gear light %s\nRight gear light %s",states[current_state].ng_light,states[current_state].lg_light,states[current_state].rg_light);
check_before_landing();
}
else if(ls)
{
current_state = Gear_up;
printf("\nThe current state is %s ",states[current_state].state_name);
printf("\nNose gear light %s\nLeft gear light %s\nRight gear light %s",states[current_state].ng_light,states[current_state].lg_light,states[current_state].rg_light);
printf("\n Landing gear is %s",states[current_state].landing_gear);
gear_up();
}
else
{
raising_gear();
}
}
//FSM in gear up state and checking the inputs to move to next state
void gear_up()
{
current_state = Gear_up;
printf("\nEnter pilot lever condition\n0 - Falling\t1 - Raising\n");
scanf("%d",&pilot_lever);
if(pilot_lever==0)
{
current_state = Check_before_landing;
printf("\nThe current state is %s ",states[current_state].state_name);
printf("\nNose gear light %s\nLeft gear light %s\nRight gear light %s",states[current_state].ng_light,states[current_state].lg_light,states[current_state].rg_light);
check_before_landing();
}
else
gear_up();
}
//FSM in checking before landing state and computing the inputs to move to next state
void check_before_landing()
{
current_state = Check_before_landing;
printf("\nEnter pilot lever condition\n0 - Falling\t1 - Raising\n");
scanf("%d",&pilot_lever);
if(pilot_lever==0)
{
current_state = Lowering_gear;
printf("\nThe current state is %s ",states[current_state].state_name);
printf("\nNose gear light %s\nLeft gear light %s\nRight gear light %s",states[current_state].ng_light,states[current_state].lg_light,states[current_state].rg_light);
printf("\n Direction valve is %s",states[current_state].direction_valve);
lowering_gear();
}
else
check_before_landing();
}
//FSM in lowering gear state and computing the inputs to move to next state
void lowering_gear()
{
current_state = Lowering_gear;
printf("\nEnter pilot lever condition\n0 - Falling\t1 - Raising\n");
scanf("%d",&pilot_lever);
printf("\nEnter limit switch condition\n0 - Open\t1 - Close\n");
scanf("%d",&ls);
if(pilot_lever)
{
current_state = Check_before_takeoff;
printf("\nThe current state is %s ",states[current_state].state_name);
printf("\nNose gear light %s\nLeft gear light %s\nRight gear light %s",states[current_state].ng_light,states[current_state].lg_light,states[current_state].rg_light);
check_before_takeoff();
}
else if(ls==0)
{
current_state = Gear_down;
printf("\nThe current state is %s ",states[current_state].state_name);
printf("\nNose gear light %s\nLeft gear light %s\nRight gear light %s",states[current_state].ng_light,states[current_state].lg_light,states[current_state].rg_light);
printf("\n Direction valve is %s",states[current_state].direction_valve);
gear_down();
}
}
int main()
{
Init_State_Machine();//Initializing lift and its parameter
gear_down(); //calling the default state of FSM
}
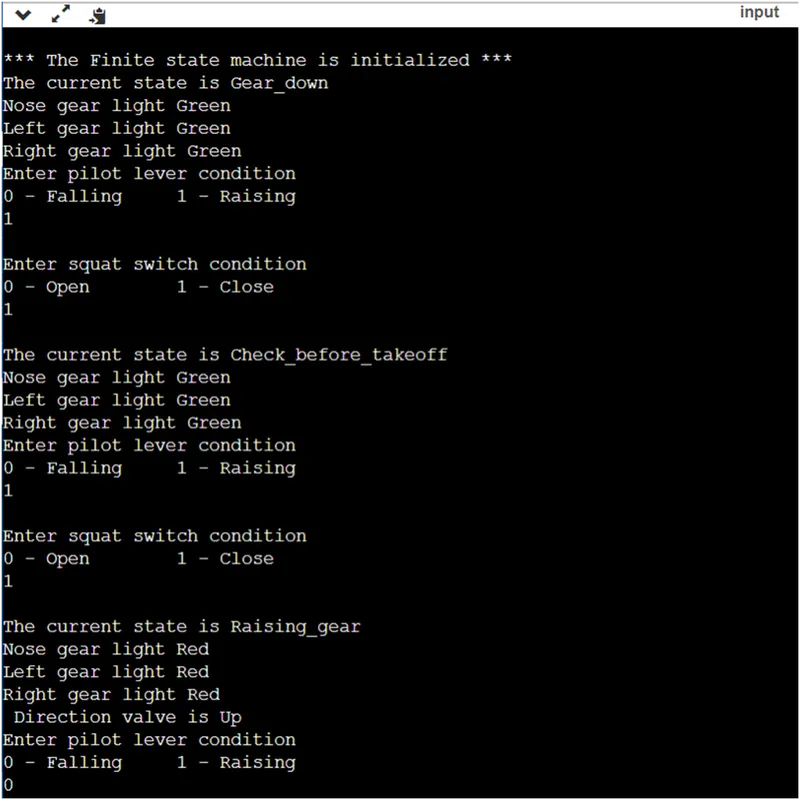
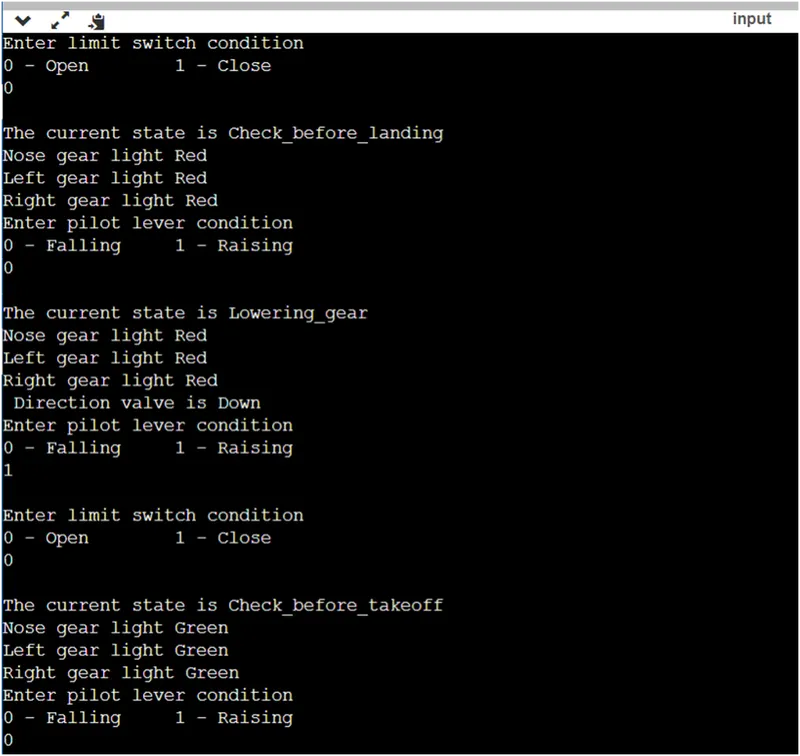
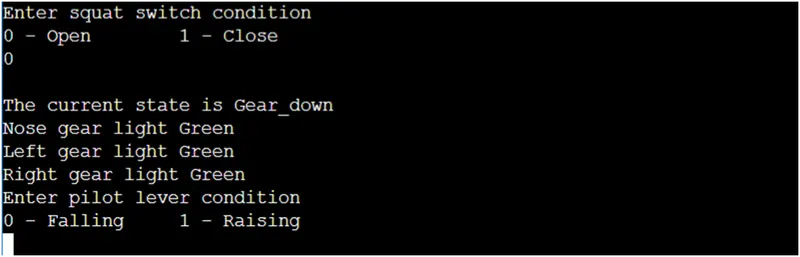
OUTPUT: