Project 2 - Implement the Code for controlling the retraction and extension of Airplane’s landing gear
implementing code for controlling 'retraction' and 'extension' of Airplanes landing gear:
program:
#include<stdio.h>           //header file


typedef enum                //creation of enumerated data type
{
	gear_down,
	checking_before_takeoff,
	raising_gear,
	gear_up,
	checking_before_landing,
	lowering_gear,
}gear;

gear gear_status;           //declaration of enumerated datatype variable

typedef struct              //creation of structure
{
	char *limit_switch[2];
	char *squat_switch[4];
	gear gear_position[6];
	char *l_position[4];
	char *light[4];
	char *direction_valve;
	char *position;
}airoplane;

airoplane states[6]=        //declaration and initialization of structure with each datatype
{
  {{"close","open"},{"close","open"},{gear_down,checking_before_takeoff,raising_gear,gear_down,checking_before_landing,lowering_gear},{"landed","take0ff","airborne","landed"},{"green","green"},"up","gear_down"},
  {{"close","open"},{"close","open"},{gear_down,checking_before_takeoff,raising_gear,gear_down,checking_before_landing,lowering_gear},{"landed","take0ff","airborne","landed"},{"red","red"},"up","checking_before_takeoff"},
  {{"close","open"},{"close","open"},{gear_down,checking_before_takeoff,gear_up,checking_before_landing,lowering_gear,raising_gear},{"landed","take0ff","airborne","landing"},{"off","red"},"down","raising_gear"},
  {{"open","open"},{"close","open"},{gear_down,checking_before_takeoff,raising_gear,checking_before_landing,gear_up,lowering_gear},{"landed","take0ff","airborne","landing"},{"red","red"},"enable","gear_up"},
  {{"open","open"},{"close","open"},{lowering_gear,checking_before_takeoff,raising_gear,gear_up,checking_before_landing,lowering_gear},{"landing","take0ff","airborne","landed"},{"green","red"},"Down","cheking_before_landing"},
  {{"close","open"},{"close","close"},{gear_down,checking_before_takeoff,raising_gear,gear_up,checking_before_landing,lowering_gear},{"landed","take0ff","airborne","landing"},{"red","red"},"up","lowering_gear"}
};

int main()                  //main function
{
	gear_status=gear_down;  //assigning value to the variable
	int n,m,q;              //declaration of integer variables
	int p=1;                //declaration and initialization of variable 'p'
	while(1){               //unconditional loop
		printf("present current_state: %s\n",states[gear_status].position);//to print in console
		printf("\nenter the pilot_position\n");                            //to read data from console
		printf("down=1, raising=2, up=3, falling=4\n");
		fflush(stdout);
		scanf("%d",&n);              //assigning value to 'n'

		if(gear_status== 0)          //conditional statement for gear_down
		{
			printf("enter squat switch \n close=0, open=1\n");         //to read data from console
			fflush(stdout);
			scanf("%d",&m);          //assigning value to m
			if(n != 2 && m != 1)     //nested if condition
			{
                gear_status=gear_down;
			}
		}
		q=m;                //assigning 'm' value to 'q'

		if( gear_status== 1)         //conditional if statement for checking_before_landing
		{
			if(n != 3)               //nested if conditional statement
			{
				printf("enter squat switch \n close=0, open=1\n");      //to read data from console
				fflush(stdout);
				scanf("%d",&m);      //assigning value to 'm'
				if(m == 0 || n==4)   //nested if condition
				{
					states[gear_status].direction_valve="down";
					states[gear_status].light[q]="red";
				}
			}
			else
			{
				states[gear_status].direction_valve="up";
			}
			printf("time delay is 3 sec\n");
		}

		if( gear_status== 2 )        //condition statement for raising_gear
		{
			if(n != 4)
			{
				printf("enter limit switch \n close=0, open=1\n");
				fflush(stdout);
				scanf("%d",&p);
				states[gear_status].direction_valve="disable";
				if( p != 0)
				{
					gear_status=raising_gear;
				}
				else{
					q=p;
				}
			}
			else
			{
				states[gear_status].direction_valve="down";
			}
		}

		if( gear_status== 5 )        //conditional statement for lowering_gear
		{
			if(n ==1)
			{
				printf("enter limit switch \n close=0, open=1\n");
				fflush(stdout);
				scanf("%d",&p);
				states[gear_status].light[q]="green";
				states[gear_status].direction_valve="down";
				if( p != 1)
				{
					gear_status=lowering_gear;
				}
				else
				{
					q=n;
					m=1;
				}
			}
			else
			{
				states[gear_status].light[q]="red";
				states[gear_status].direction_valve="up";
			}
		}

		n=n-1;
		//to print o/p on console
		printf("plain is: %s\n",states[gear_status].l_position[n]);
		printf("direction_valve: %s\n",states[gear_status].direction_valve);
		printf("limit-switch: %s\n",states[gear_status].limit_switch[p]);
		printf("squat-switch: %s\n",states[gear_status].squat_switch[m]);
		printf("lighting: %s\n",states[gear_status].light[q]);
		gear_status=states[gear_status].gear_position[n];                   //assigning gear position to next statement
		printf("\n");
	}
	return 0;
}
#include<stdio.h> //header file
typedef enum //creation of enumerated data type
{
gear_down,
checking_before_takeoff,
raising_gear,
gear_up,
checking_before_landing,
lowering_gear,
}gear;
gear gear_status; //declaration of enumerated datatype variable
typedef struct //creation of structure
{
char *limit_switch[2];
char *squat_switch[4];
gear gear_position[6];
char *l_position[4];
char *light[4];
char *direction_valve;
char *position;
}airoplane;
airoplane states[6]= //declaration and initialization of structure with each datatype
{
{{"close","open"},{"close","open"},{gear_down,checking_before_takeoff,raising_gear,gear_down,checking_before_landing,lowering_gear},{"landed","take0ff","airborne","landed"},{"green","green"},"up","gear_down"},
{{"close","open"},{"close","open"},{gear_down,checking_before_takeoff,raising_gear,gear_down,checking_before_landing,lowering_gear},{"landed","take0ff","airborne","landed"},{"red","red"},"up","checking_before_takeoff"},
{{"close","open"},{"close","open"},{gear_down,checking_before_takeoff,gear_up,checking_before_landing,lowering_gear,raising_gear},{"landed","take0ff","airborne","landing"},{"off","red"},"down","raising_gear"},
{{"open","open"},{"close","open"},{gear_down,checking_before_takeoff,raising_gear,checking_before_landing,gear_up,lowering_gear},{"landed","take0ff","airborne","landing"},{"red","red"},"enable","gear_up"},
{{"open","open"},{"close","open"},{lowering_gear,checking_before_takeoff,raising_gear,gear_up,checking_before_landing,lowering_gear},{"landing","take0ff","airborne","landed"},{"green","red"},"Down","cheking_before_landing"},
{{"close","open"},{"close","close"},{gear_down,checking_before_takeoff,raising_gear,gear_up,checking_before_landing,lowering_gear},{"landed","take0ff","airborne","landing"},{"red","red"},"up","lowering_gear"}
};
int main() //main function
{
gear_status=gear_down; //assigning value to the variable
int n,m,q; //declaration of integer variables
int p=1; //declaration and initialization of variable 'p'
while(1){ //unconditional loop
printf("present current_state: %s\n",states[gear_status].position);//to print in console
printf("\nenter the pilot_position\n"); //to read data from console
printf("down=1, raising=2, up=3, falling=4\n");
fflush(stdout);
scanf("%d",&n); //assigning value to 'n'
if(gear_status== 0) //conditional statement for gear_down
{
printf("enter squat switch \n close=0, open=1\n"); //to read data from console
fflush(stdout);
scanf("%d",&m); //assigning value to m
if(n != 2 && m != 1) //nested if condition
{
gear_status=gear_down;
}
}
q=m; //assigning 'm' value to 'q'
if( gear_status== 1) //conditional if statement for checking_before_landing
{
if(n != 3) //nested if conditional statement
{
printf("enter squat switch \n close=0, open=1\n"); //to read data from console
fflush(stdout);
scanf("%d",&m); //assigning value to 'm'
if(m == 0 || n==4) //nested if condition
{
states[gear_status].direction_valve="down";
states[gear_status].light[q]="red";
}
}
else
{
states[gear_status].direction_valve="up";
}
printf("time delay is 3 sec\n");
}
if( gear_status== 2 ) //condition statement for raising_gear
{
if(n != 4)
{
printf("enter limit switch \n close=0, open=1\n");
fflush(stdout);
scanf("%d",&p);
states[gear_status].direction_valve="disable";
if( p != 0)
{
gear_status=raising_gear;
}
else{
q=p;
}
}
else
{
states[gear_status].direction_valve="down";
}
}
if( gear_status== 5 ) //conditional statement for lowering_gear
{
if(n ==1)
{
printf("enter limit switch \n close=0, open=1\n");
fflush(stdout);
scanf("%d",&p);
states[gear_status].light[q]="green";
states[gear_status].direction_valve="down";
if( p != 1)
{
gear_status=lowering_gear;
}
else
{
q=n;
m=1;
}
}
else
{
states[gear_status].light[q]="red";
states[gear_status].direction_valve="up";
}
}
n=n-1;
//to print o/p on console
printf("plain is: %s\n",states[gear_status].l_position[n]);
printf("direction_valve: %s\n",states[gear_status].direction_valve);
printf("limit-switch: %s\n",states[gear_status].limit_switch[p]);
printf("squat-switch: %s\n",states[gear_status].squat_switch[m]);
printf("lighting: %s\n",states[gear_status].light[q]);
gear_status=states[gear_status].gear_position[n]; //assigning gear position to next statement
printf("\n");
}
return 0;
}
the output of the program is:
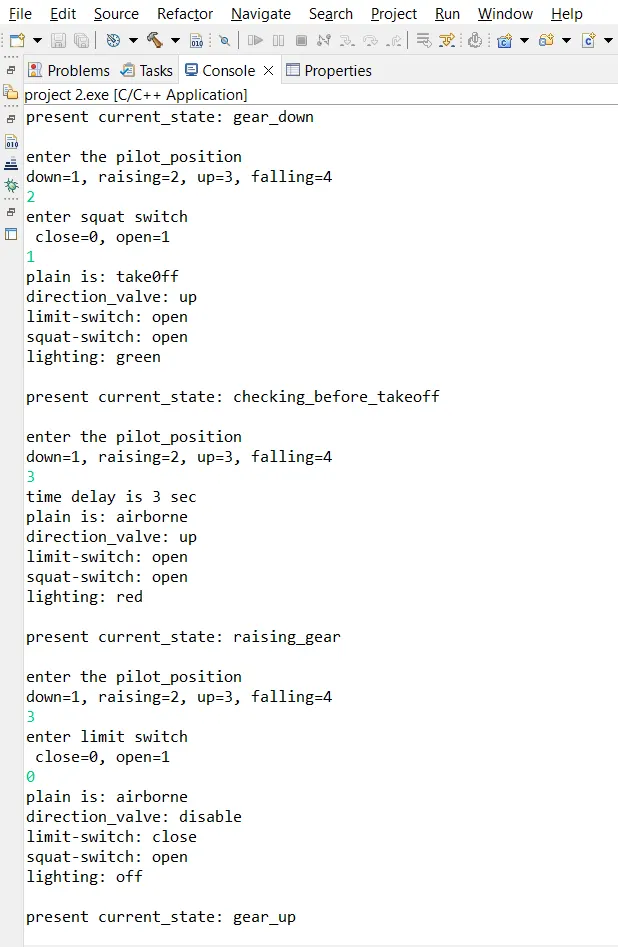
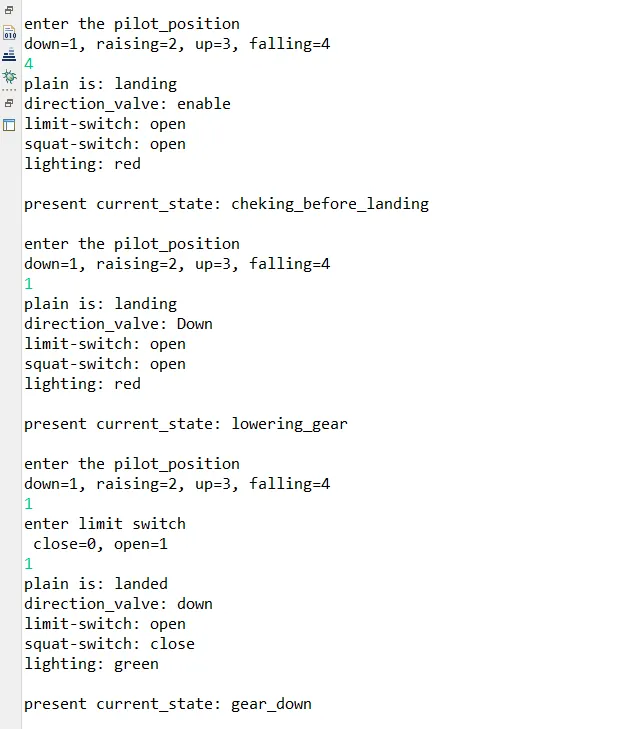
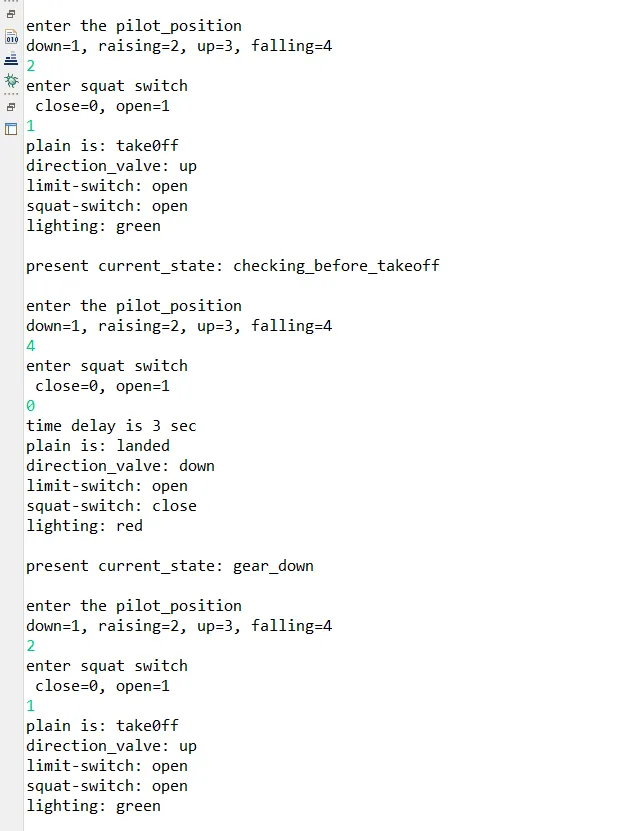
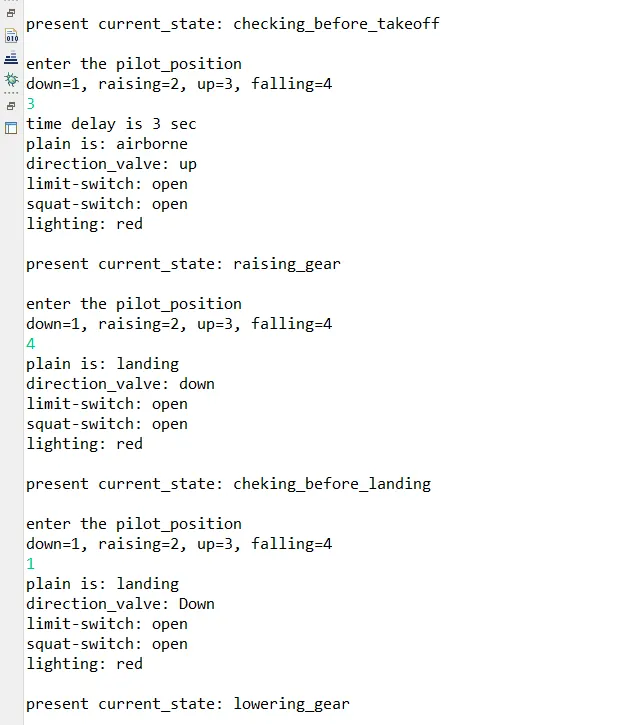
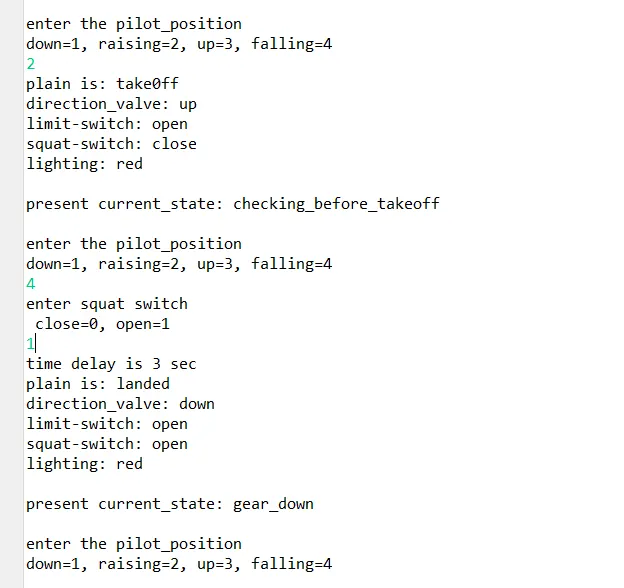
output:
present current_state: gear_down

enter the pilot_position
down=1, raising=2, up=3, falling=4
2
enter squat switch
 close=0, open=1
1
plain is: take0ff
direction_valve: up
limit-switch: open
squat-switch: open
lighting: green

present current_state: checking_before_takeoff

enter the pilot_position
down=1, raising=2, up=3, falling=4
3
time delay is 3 sec
plain is: airborne
direction_valve: up
limit-switch: open
squat-switch: open
lighting: red

present current_state: raising_gear

enter the pilot_position
down=1, raising=2, up=3, falling=4
3
enter limit switch
 close=0, open=1
0
plain is: airborne
direction_valve: disable
limit-switch: close
squat-switch: open
lighting: off

present current_state: gear_up

enter the pilot_position
down=1, raising=2, up=3, falling=4
4
plain is: landing
direction_valve: enable
limit-switch: open
squat-switch: open
lighting: red

present current_state: cheking_before_landing

enter the pilot_position
down=1, raising=2, up=3, falling=4
1
plain is: landing
direction_valve: Down
limit-switch: open
squat-switch: open
lighting: red

present current_state: lowering_gear

enter the pilot_position
down=1, raising=2, up=3, falling=4
1
enter limit switch
 close=0, open=1
1
plain is: landed
direction_valve: down
limit-switch: open
squat-switch: close
lighting: green

present current_state: gear_down

enter the pilot_position
down=1, raising=2, up=3, falling=4
2
enter squat switch
 close=0, open=1
1
plain is: take0ff
direction_valve: up
limit-switch: open
squat-switch: open
lighting: green

present current_state: checking_before_takeoff

enter the pilot_position
down=1, raising=2, up=3, falling=4
4
enter squat switch
 close=0, open=1
0
time delay is 3 sec
plain is: landed
direction_valve: down
limit-switch: open
squat-switch: close
lighting: red

present current_state: gear_down

enter the pilot_position
down=1, raising=2, up=3, falling=4
2
enter squat switch
 close=0, open=1
1
plain is: take0ff
direction_valve: up
limit-switch: open
squat-switch: open
lighting: green

present current_state: checking_before_takeoff

enter the pilot_position
down=1, raising=2, up=3, falling=4
3
time delay is 3 sec
plain is: airborne
direction_valve: up
limit-switch: open
squat-switch: open
lighting: red

present current_state: raising_gear

enter the pilot_position
down=1, raising=2, up=3, falling=4
4
plain is: landing
direction_valve: down
limit-switch: open
squat-switch: open
lighting: red

present current_state: cheking_before_landing

enter the pilot_position
down=1, raising=2, up=3, falling=4
1
plain is: landing
direction_valve: Down
limit-switch: open
squat-switch: open
lighting: red

present current_state: lowering_gear

enter the pilot_position
down=1, raising=2, up=3, falling=4
2
plain is: take0ff
direction_valve: up
limit-switch: open
squat-switch: close
lighting: red

present current_state: checking_before_takeoff

enter the pilot_position
down=1, raising=2, up=3, falling=4
4
enter squat switch
 close=0, open=1
1
time delay is 3 sec
plain is: landed
direction_valve: down
limit-switch: open
squat-switch: open
lighting: red

present current_state: gear_down

enter the pilot_position
down=1, raising=2, up=3, falling=4