Project 2 - Implement the Code for controlling the retraction and extension of Airplane’s landing gear
Program for extraction and retraction of airplane landing gear
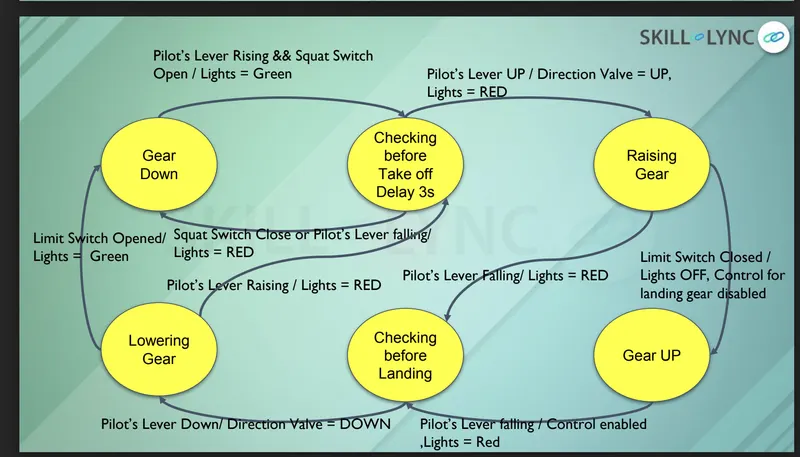
program-
//to go from gear down to checking state we need to press 1
//to go from checking state to gear down we need to press 0
//to go from checking state to rising gear we need to press 2
//to go from rising gear to gear up we need to give limit switch 1
// to go from rising state to checking before landing we need to give limit_switch=0
//to go from gear_up to checking state we need to give pilot_lever=3
//to go from checking state to lowering gear we need to give pilot_lever=4
//from lowering gear to checking before landing pilot lever=1
//from lowering gear to gear up limit switch =0
#include<stdio.h>
#include<stdlib.h> //header file
void m (); //function
typedef enum
{
gear_down,
checking_before_take_off,
raising_gear,
gear_up,
checking_before_landing,
lowering_gear
} gear; //Enumerated data type
typedef enum
{
off,
green,
red
} light; //Enumerated data type
typedef enum
{
valve_up,
valve_down
} valve; //Enumerated data type
typedef struct
{
gear output;
gear next_state[6];
int time;
light l[3];
char *a[10];
} State; //Enumerated data type
State state_[6] = {
{gear_down, {gear_down, checking_before_take_off}, 3, {off, green, red},
{"gear down", "checking before take off", "airplan is on ground", "green",
"red"}},
{checking_before_take_off, {gear_down, raising_gear}, 3, {off, green, red},
{"gear down", "checking before take off", "raising_gear", "red"}},
{raising_gear, {gear_up, checking_before_landing}, 3, {off, green, red},
{"checking before take off", "gear up", "off"}},
{gear_up, {checking_before_landing}, 3, {off, green, red},
{"checking before landing", "gear up", "red"}},
{checking_before_landing, {lowering_gear}, 3, {off, green, red},
{"checking before landing", "lowering_gear", "gear up", "red"}},
{lowering_gear, {gear_up, checking_before_take_off}, 3, {off, green, red},
{"gear up", "checking before take off", "lowering_gear", "red"}},
};
//FSM (finite state machine
int squat_switch, current_state, pilot_lever, pilot_lever_up, limit_switch,
pilot_lever_falling, pilot_lever_down;
//global variable
int main ()
{
while (1)
{
printf ("squat switch=");
scanf ("%d", &squat_switch);
if (0 == squat_switch) //plane is on ground squat switch off
{
printf ("\nlight=(%d)%s\n", state_[0].l[1], state_[0].a[3]);
printf ("\n%s", state_[0].a[0]);
printf ("\n%s\n", state_[0].a[2]);
current_state = state_[0].next_state[0];
continue;
} //condition to be in ground till squat switch is not closed
else if (1 == squat_switch) //plane is taking off or landing or airborn
{
printf
("\npilot lever for checking before take off or stay at ground=");
scanf ("%d", &pilot_lever);
if (1 == pilot_lever && 1 == squat_switch) //condition to change state from down to rising
{
{
printf ("%s\n", state_[0].a[1]);
printf ("\nlight=(%d)%s\n", state_[0].l[2], state_[0].a[4]);
printf ("delay=%d\n", state_[0].time);
current_state = checking_before_take_off;
} //state has been changed
printf
("pilot lever condtion for rising gear or gear down status =");
scanf ("%d", &pilot_lever);
if (2 == pilot_lever && 1 == squat_switch) //condition to change state 2 for lever up
{
printf ("\n%s", state_[1].a[2]);
printf ("\nlight=(%d)%s\n", state_[1].l[2], state_[1].a[3]);
current_state = raising_gear;
printf
("\nlimit_switch to go at gear up or gear down before landing=");
scanf ("%d", &limit_switch);
if (1 == limit_switch) //condition to change state from rising to gear up
{
{
printf ("\n%s", state_[2].a[1]);
printf ("\nlight=(%d)%s\n", state_[2].l[0],
state_[2].a[2]);
printf ("control for landing gear disabled");
current_state = gear_up;
//3 for falling
}
printf ("\npilot lever before landing condition=");
scanf ("%d", &pilot_lever);
if (pilot_lever == 3) //condition to change state from gear up to check before landing
{
printf ("\n%s", state_[3].a[0]);
printf ("\nlight=(%d)%s\n", state_[3].l[2],
state_[3].a[2]);
current_state = checking_before_landing;
// 4 for down
}
}
else if (1 == limit_switch || 0 == limit_switch) //condition to change state from rising to check before landing
{
printf ("\n%s", state_[3].a[0]);
printf ("\nlight=(%d)%s\n", state_[3].l[1],
state_[3].a[3]);
current_state = checking_before_landing;
// 4 for down
}
printf ("\npilot_lever before lowering gear condition="); //4 for landing
scanf ("%d", &pilot_lever);
if (4 == pilot_lever) //condition to change state from check before landing to lowering gear
{
printf ("\n%s\n", state_[4].a[1]);
printf ("\nlight=(%d)%s\n", state_[4].l[1],
state_[4].a[3]);
current_state = lowering_gear;
//0 for open
}
printf ("limit switch ");
scanf ("%d", &limit_switch);
printf ("pilot_lever");
scanf ("%d", &pilot_lever);
if (0 == limit_switch || 0==pilot_lever) //condition to change state from lowering gear to gear down state
{
printf ("\nlight=(%d)%s\n", state_[0].l[1],
state_[0].a[3]);
printf ("\n%s", state_[0].a[0]);
printf ("\n%s\n", state_[0].a[2]);
current_state = state_[0].next_state[0];
continue;
}
if (1 == pilot_lever || 1 == limit_switch)
{
m (); //called function
continue;
}
}
}
}
}
}
void
m () //called function
{
while(1)
{
squat_switch = 1;
printf ("pilot lever condtion for rising gear or gear down status =");
scanf ("%d", &pilot_lever);
if (2 == pilot_lever && 1 == squat_switch) //condition to change state 2 for lever up
{
printf ("\nlight=(%d)%s\n", state_[1].l[2], state_[1].a[3]);
printf ("\n%s", state_[1].a[2]);
current_state = raising_gear;
printf ("\nlimit_switch to go at gear up or gear down before landing=");
scanf ("%d", &limit_switch);
if (1 == limit_switch) //condition to change state from rising to gear up
{
{
printf ("\n%s", state_[2].a[1]);
printf ("\nlight=(%d)%s\n", state_[2].l[1], state_[2].a[3]);
printf ("control for landing gear disabled");
current_state = gear_up;
printf ("control for for landing gear are disabled");;
//3 for falling
}
printf ("\npilot lever checking before landing condition=");
scanf ("%d", &pilot_lever);
if (pilot_lever == 3) //condition to change state from gear upm to check before landing
{
printf ("\n%s", state_[3].a[0]);
printf ("\nlight=(%d)%s\n", state_[3].l[1], state_[3].a[3]);
current_state = checking_before_landing;
// 4 for down
}
}
else if (1 == limit_switch || 0 == limit_switch) //condition to change state from rising to check before landing
{
printf ("\n%s", state_[3].a[0]);
printf ("\nlight=(%d)%s\n", state_[3].l[1], state_[3].a[3]);
current_state = checking_before_landing;
// 4 for down
}
printf ("\npilot_lever before lowering gear condition="); //4 for landing
scanf ("%d", &pilot_lever);
if (4 == pilot_lever) //condition to change state from check before landing to lowering gear
{
printf ("\n%s", state_[4].a[1]);
printf ("\nlight=(%d)%s\n", state_[4].l[1], state_[4].a[3]);
current_state = lowering_gear;
//0 for open
}
printf ("limit switch ");
scanf ("%d", &limit_switch);
printf("pilot lever");
scanf("%d",&pilot_lever);
if (0 == limit_switch || 0== pilot_lever) //condition to change state from lowering gear to gear down state
{
printf ("\nlight=(%d)%s\n", state_[0].l[1], state_[0].a[3]);
printf ("\n%s", state_[0].a[0]);
printf ("\n%s\n", state_[0].a[2]);
current_state = state_[0].next_state[0];
break;
}
}
}
}
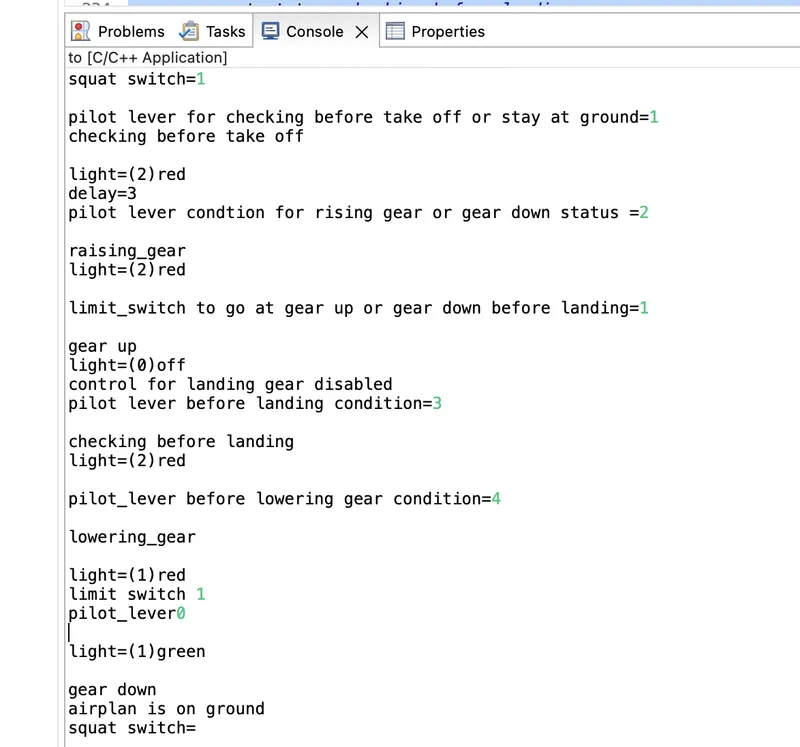
output-