Project 2 Adaptive Cruise Control
Aim:
- To create the Simulink Model according the requirement given.
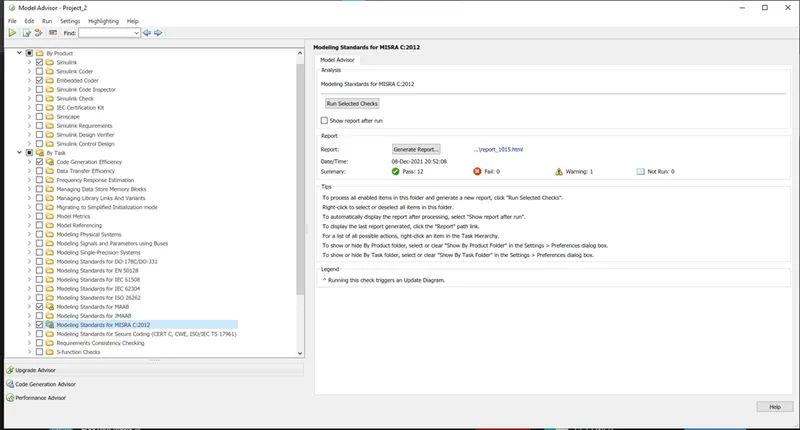
- To create the Model Advisor report.
- To create the code generation report.
Simulink Model:
- The Simulink model has 3 subsystems: Lead vehicle logic, Drive vehicle logic and the Adaptive cruise control logic:
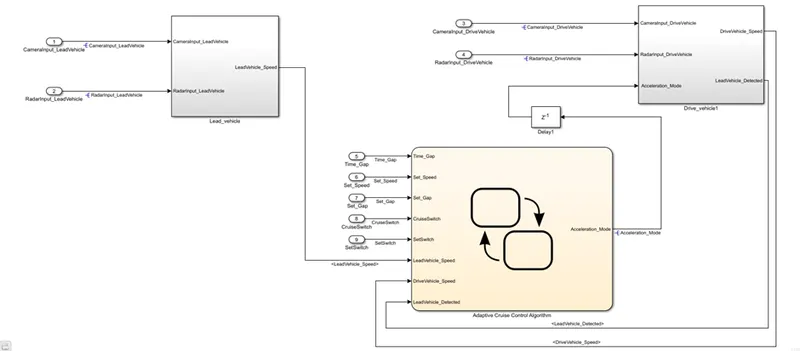
Lead Vehicle:
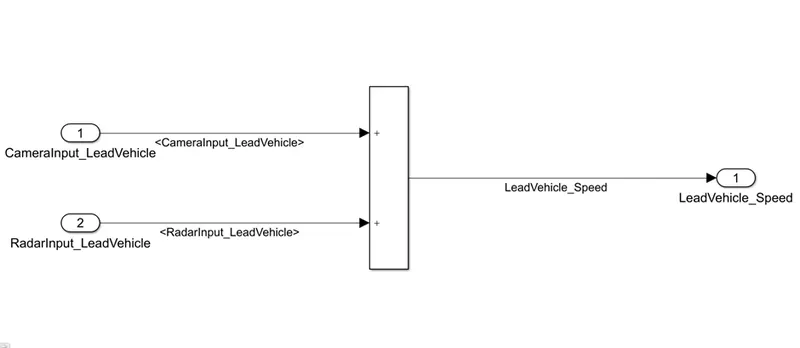
- The lead vehicle has 2 inputs: CameraInput_LeadVehicle and RadarInput_LeadVehicle.
- The output of this subsystem is LeadVehicle_Speed.
- The 2 input has summed up to get the output.
Drive vehicle:
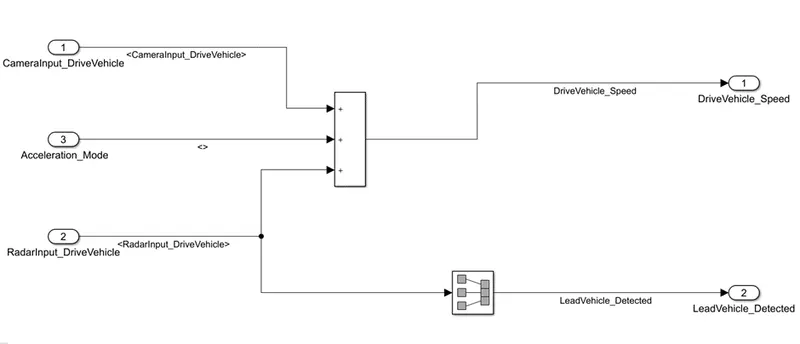
- This subsystem has 3 inputs: CameraInput_DriveVehicle, RadarInput_DriveVehicle and Acceleration_Mode.
- The output of this subsystem is DriveVehicle_Speed and LeadVehicle_Detected.
- The CameraInput_DriveVehicle and Acceleration_Mode are summed up to get the output DriveVehicle_Speed.
- Acceleration_Mode is inputed to the signal conversion block and the output is the DriveVehicle_Speed.
Adaptive Cruise Control:
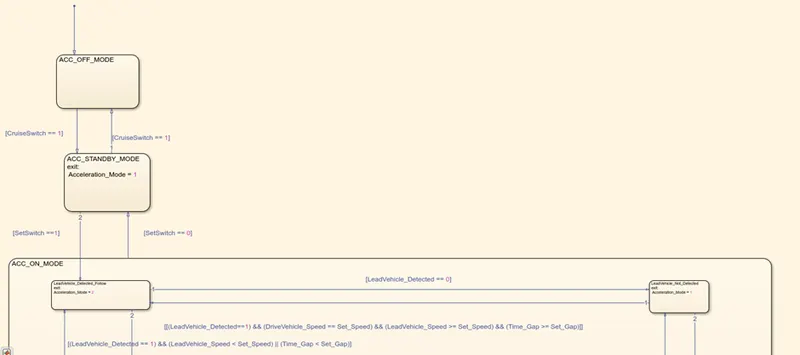
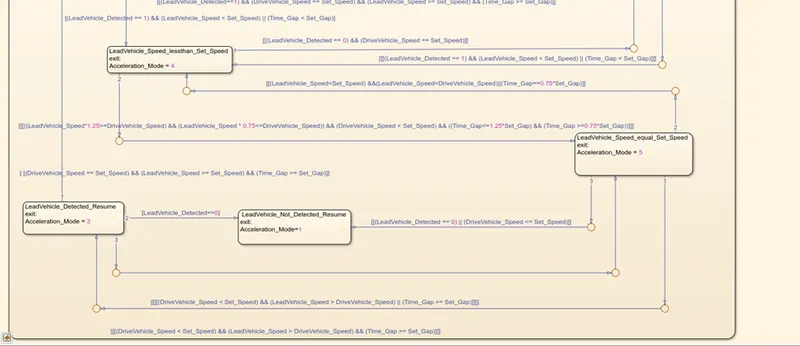
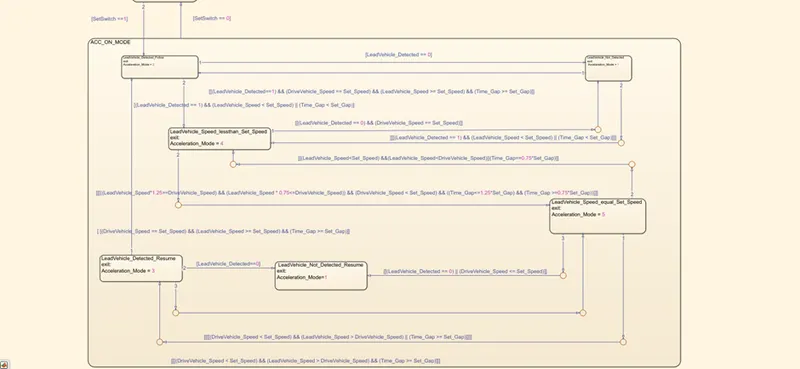
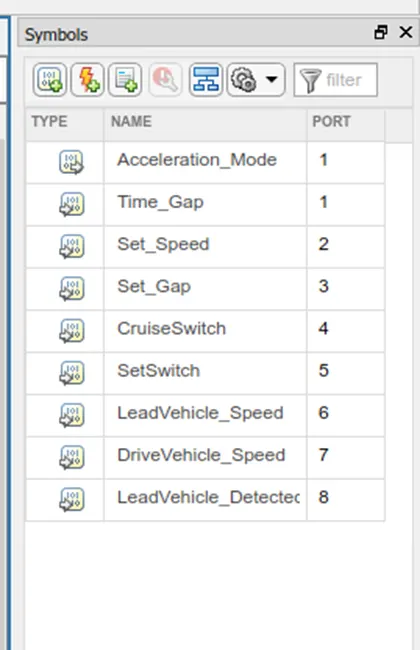
- The stateflow is developed according to the logic mentioned in the question.
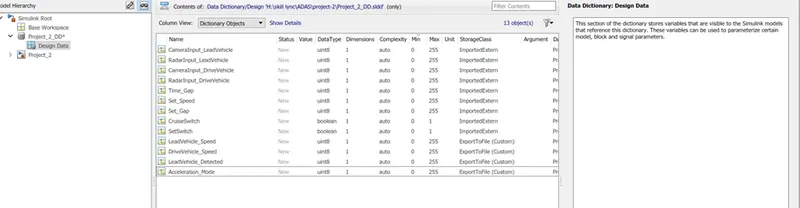
SLDD :
Advisor check: