Project 2
Aim: To develop a forward energy-based fuel consumption model of a P1 hybrid vehicle.
Objective:
-
Build a Simulink model using blocks and complete the vehicle model.
-
Writing scripts in MATLAB to load all the variables required for running the Simulink model.
-
Tabulate the fuel economy numbers (kmpl) for UDDS and HWFET cycles.
-
Plot the time trace for the engine, transmission input, transmission output, and wheel speed on one plot.
-
Plot engine torque, engine power, fuel rate, and fuel consumption using subplots.
-
Plot accelerator and brake pedal, gear command, vehicle desired and actual speed, and vehicle distance using subplots.
-
Plot the engine operating points on the engine fuel map.
-
Plot motor speed, torque, and motor input power using subplots.
-
Plot pack voltage, current, and SoC using subplots.
-
Plot the motor operating points on the motor input power map, with the motor max motoring and generating torque curves.
-
Write down appropriate brief comments on each of these plots, describing the vehicle behavior throughout the drive cycle.
-
Generate the plots for both drive cycles
Solution:
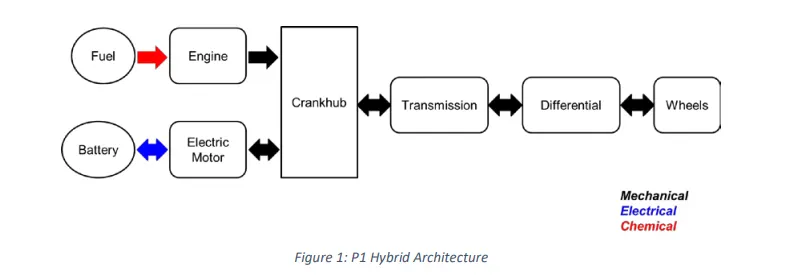
P1 Mild Hybrid Model: The P1 architecture, with the electric machine connected directly to the crankshaft, is the solution adopted by Honda on their first generation Integrated Motor Assist (IMA) technology. The electric motor functions as a generator, during vehicle deceleration, as an engine starter, and as a motor (to assist the engine) during vehicle accelerations. One of the biggest advantages of this solution is that the electric motor can provide higher torque than the BiSG, since there is no belt limitation (due to slip). However, since there is no speed/torque ratio between the electric machine and the crankshaft, the torque requirements on the electric motor can be quite demanding.
In this model, We use Forward Model: It is also known as dynamic simulation. Dynamic models are used for detailed simulations. In this model force/torque/power is the input and the vehicle state variable velocity and acceleration are the outputs. The models and simulations are more realistic due to physical casualty hence appropriate for control development. There is a feedback loop to meet the desired vehicle state. It is mainly used to simulate a vehicle on a driving cycle to analyze the dynamic behavior of the system helps significantly in control development.
MATLAB scripts:
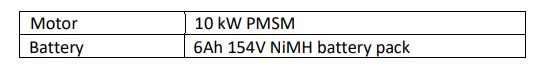
Honda Insight motor and battery are considered for this project. Data is taken from the ADVISOR database developed by NREL, USA. Data is provided in the project files.
The transmission shift map and controller are taken from Matlab/Simulink example database. The Simulink model for the convection model is created using 3 main sub-blocks for the driver model, control model, and powertrain block.
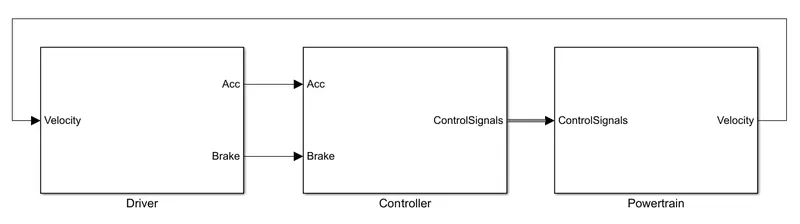
The actual vehicle speed is given as feedback to the driver block, and the driver block gives the controller block the required acceleration or brake output, while the controller block provides control signals for engine torque, gear shifting, and brake torque to the Powertrain model.
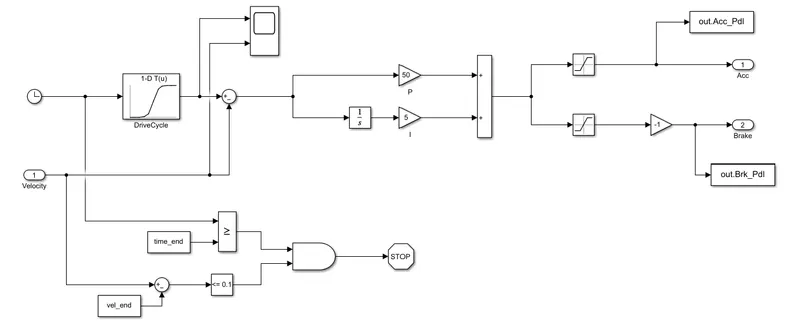
Control Model:
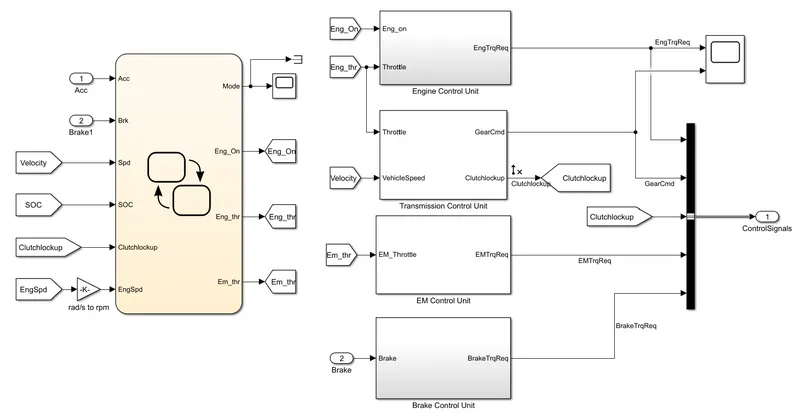
The ‘Controller’ block is the brains of the vehicle, representing the electronic control units. It is based on the driver inputs, it generates desired engine torque, desired transmission gear, and desired brake torque. These inputs are fed to the ‘Powertrain’ block which represents the drivetrain of the vehicle.
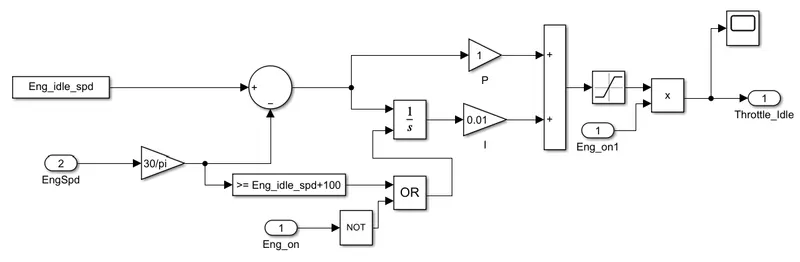
- Engine Control Unit: In this control model We use an engine control unit that gives input Engine speed by creating a look-up table. in that table, we give input Maximum torque and map speed then also create a 2nd lookup table that gives input ct torque and map speed then it substracts and multiplied. the engine speed also gives to ideal control speed to integrate from this we meet the output of the engine's required torque.
-
Idle Speed Controller: Engine Control Unit Compare engine speed with the maximum torque and minimum torque curves of the lookup table and give the required torque command to the engine block. The throttle input is combined with the idle speed throttle and gains with the torque output from the lookup table to estimate the torque input required for the engine. Throttle input, idle throttle, and their sum can be scoped from this block.
-
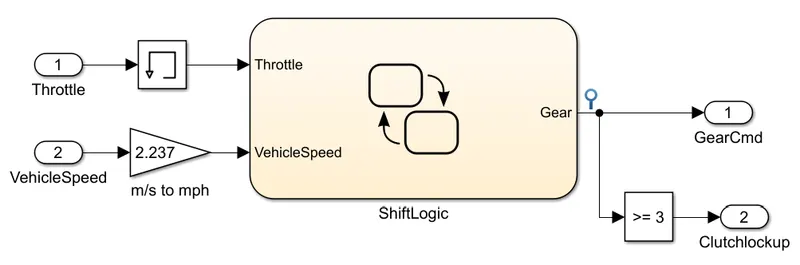
- Transmission Control Unit: In this unit, we create a steady flow variable state for controlling of gears of the vehicle in ascending and descending order with respect to time, speed, and distance. and give input to this steady state is vehicle speed in m/s to mph.
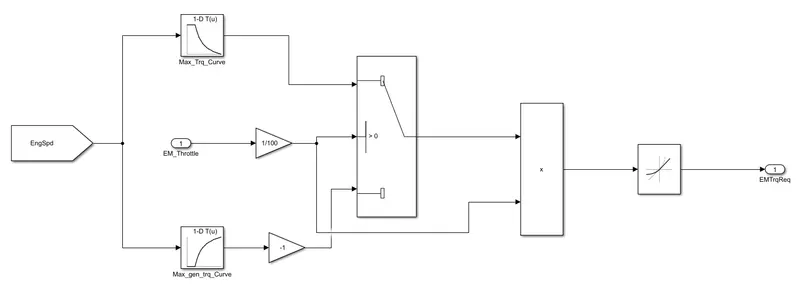
- Electric Motor Control Unit: Motor Control Unit compares EM speed with the maximum torque curve and maximum torque generation curves of the lookup table and gives the required torque command to the Electric Motor. The EM throttle input is used to compare the lookup tables and to estimate the torque input required for the E-Motor.
- Brake Control Unit: In this calculate brake torque and then all three control signals output is given to the powertrain.
- Stateflow for Controller: A state flow machine is used to represent the supervisory control unit, which decides the operating mode. Whether it is starts/stops mode or cruising mode or regen braking mode. for each mode, the Engine drive and the motor drive are controlled. The Input to the state flow charts is Acceleration and Brake pedal input from the driver unit, Engine actual speed, Actual vehicle speed, SOC status, and the clutch lockup state. And the State flow Outputs to the individual controllers are the Mode, Engine On/ off request, Engine input throttle, and Electric motor input Throttle The controller consists of an engine control unit, a transmission control unit, an Electric Motor control unit, and a brake control unit. All control signals are passed to the transmission model which represents the drive train.
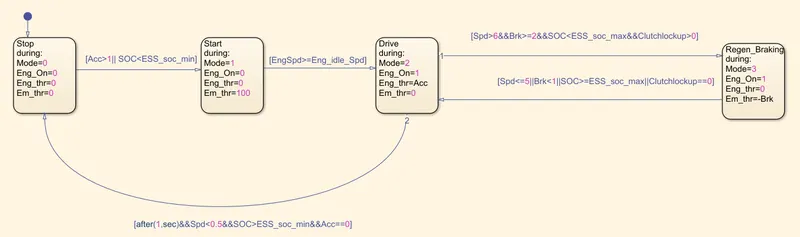
Powertrain:
The powertrain encompasses every component that converts the engine's power into movement. This includes the engine, motor, battery, transmission, driveshaft, differentials, axles; basically anything from the engine through to the rotating wheels.
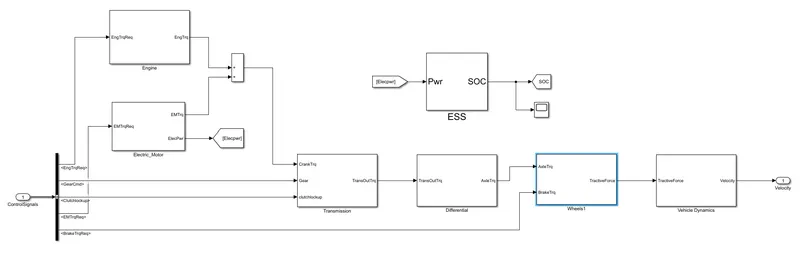
Engine
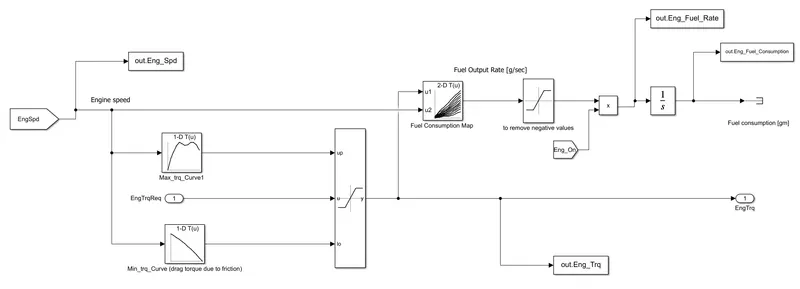
In this model, we used the map-based model to model the fuel consumption of the engine. It is based on maximum Torque and minimum torque from the controller. and then it saturated torque and gives output then saturated torque and the speed map gives fuel consumption takes the speed and torque then the output goes into saturated then it's integrated.
Electric Motor
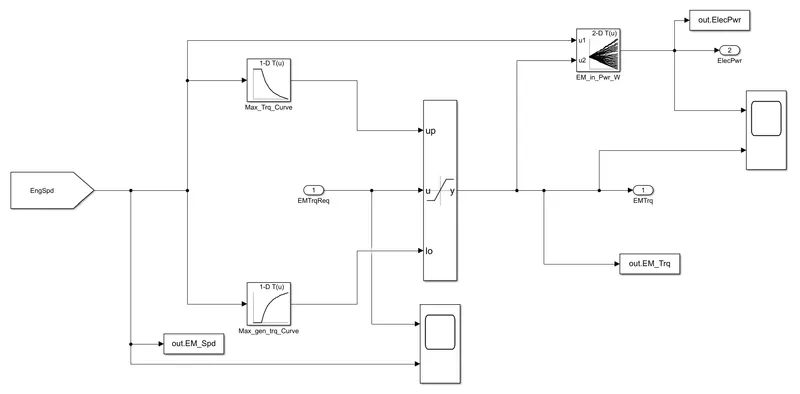
Based on the Engine speed The required EM torque from the controller is saturated between the Max EM torque curve and max EM torque Generation curve and passes the EM torque to the Crank Hub. The 2D lookup table is used to calculate the Input of Electric Power to the Motor based on EM speed and EM torque.
Transmission
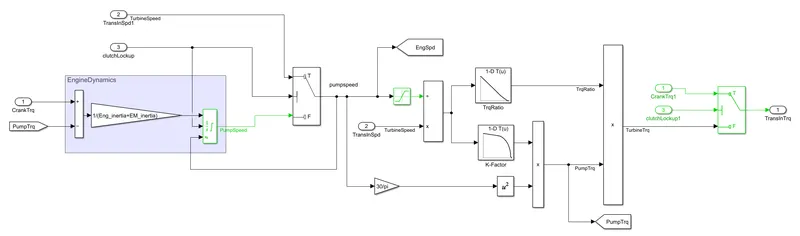
In these models, we take engine torque, and gear selector from the controller for transmission of gear ratio. The ratio is multiplied by the transmission input torque and then the transmission efficiency positive torque and negative torque give the transmission input speed. In this case, the torque converter connects the engine to the transmission it is part of the transmission. In it basically, engine dynamics are decoupled.
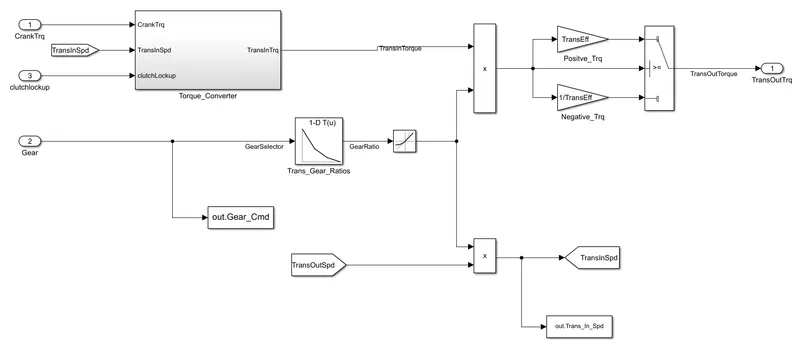
Torque Converter: The torque converter defines the pump and turbine torque by the clutch lock-up status, and the combination gives us the desired transmission torque.
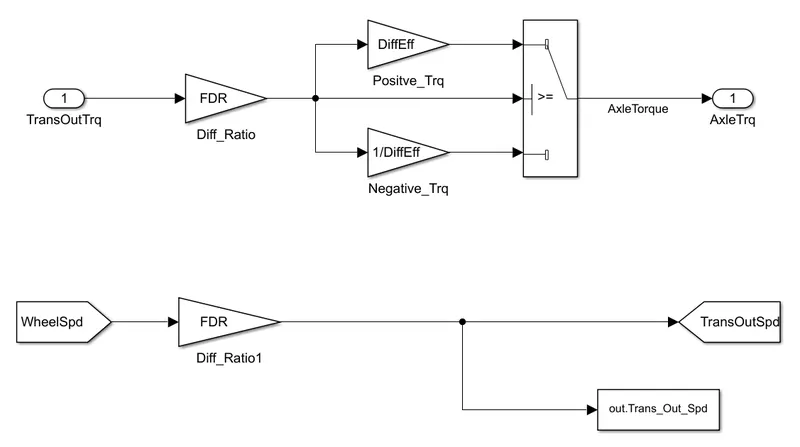
Differential
In this taking input is the transmission output then it's going to the differential ratio multiplied by the output and input torque then meets axle torque. The axle torque is lower than the transmission torque and differential ratio.
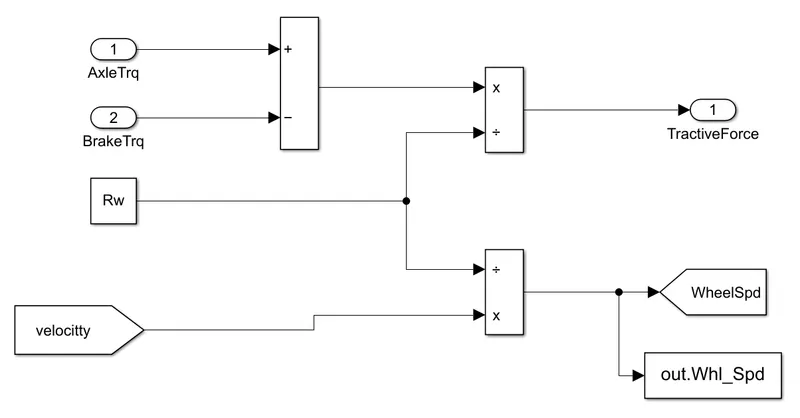
Wheels
In this model, we take the axle torque from the differential and the brake torque from the controller. it is substracted and multiplied by the rolling radius and velocity then we meet the tractive force from the axle and brake torque. and the wheel speed is met using velocity.
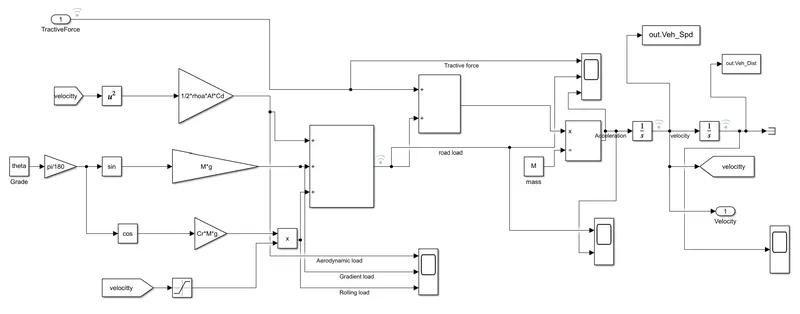
Vehicle Dynamics
This takes tractive force and road load. It dictates vehicle speed based on tractive force and road load. The dynamic equation for calculating road load is
Meq(dVveh/dt) = [(ηt*λtot)/(Rw)] *Tm− [0.5*ρ*A*Cd*(Vveh+Vwnd) ^2+Cr*M*g*cos(θ)+M*g*sin(θ)]
where,
p = air density [kg/m^3]
A = Frontal area [m^2]
Cd = Drag Coefficient
Vveh = velocity of vehicle [m/s^2]
Vwind = velocity of wind [m/s^2]
Cr = rolling resistance coefficient
M = mass in [Kg]
g = gravity.
Then we calculate and integrate we meet acceleration of the vehicle and velocity of the vehicle which means vehicle distance and vehicle speed.
Battery Modeling
A Battery pack Subsystem is created with Electric power input and Battery SOC as output. 2 different subblocks have been created to determine the SOC and terminal voltage separately, the SOC being
used to calculate the terminal voltage.
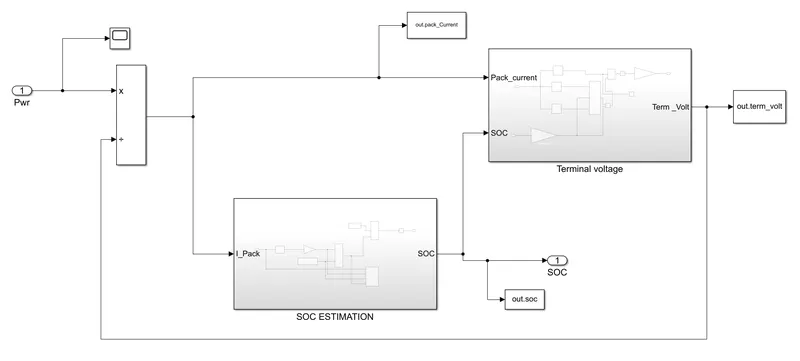
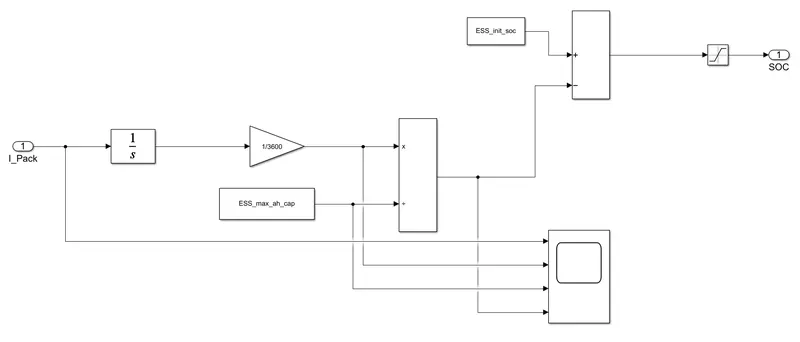
SOC Estimation Model: In this, we give input as power then multiply and give to pack current. then from soc estimation meets output SOC is given to terminal voltage as input and then meets terminal voltage as output.
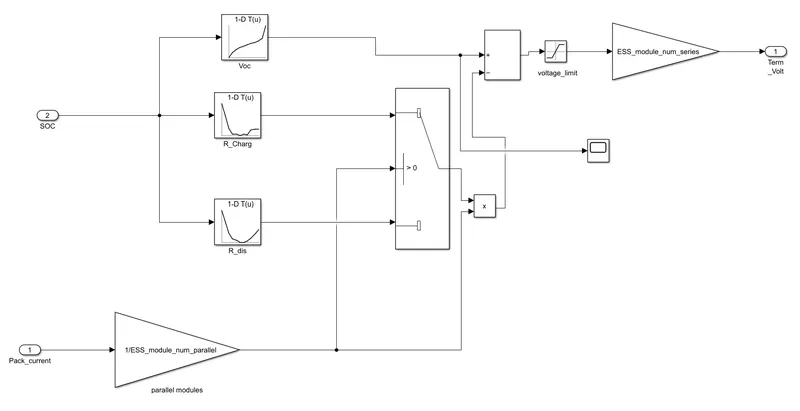
Terminal Voltage Model: In this use input SOC it is connected to the 1d lookup table 1st table variable is interpolated as the state of charge and open voltage circuit. In the 2nd table, the variable is interpolated as resistance discharge and state of charge and in the 3rd table, the variable is interpolated as resistance charge and state of charge. Then it is passed to the switch block for controlling the threshold. then they give voltage limits as max volts and min volts. then meet terminal Voltage.
MATLAB scripts:
Fuel economy numbers:
As we see, the fuel economy is high in HWFET compared to UDDS, it is because, in urban driving, the vehicle encounters more traffic and it has to stop for fewer distances and it consumes more fuel at the start. In HWFET, the vehicle encounters no traffic and it moves without the use of too much braking, so it will have more fuel economy number.
Fuel Economy Numbers for project 2
| S.No | Drive cycle | Fuel Economy Number (KMpl) |
| 1 | UDDS | 18.9336 |
| 2 | HWFET | 27.1179 |
Comparing with fuel economy numbers for project 1
| S.No | Drive cycle | Fuel Economy Number (KMpl) |
| 1 | UDDS | 16.89 |
| 2 | HWFET | 21.228 |
As we see the fuel economy numbers for project 2 are a bit higher when compared to project 1 because implementing the electric motor as it is a P1 hybrid may not have many variations in the fuel economy but as we implement other architecture it will increase by a huge amount.
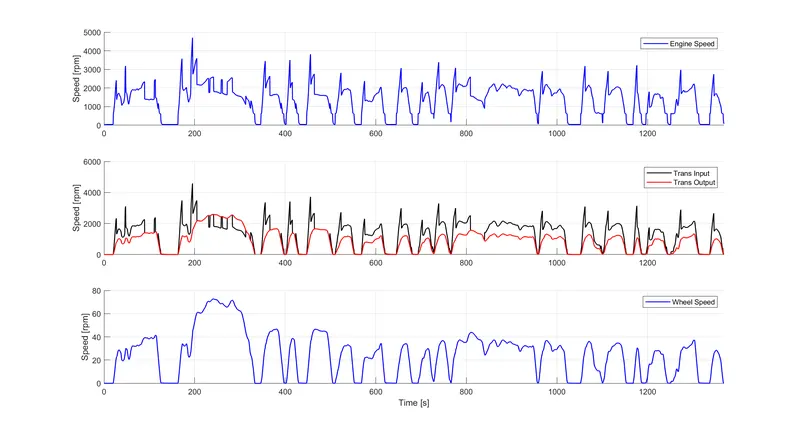
Plotting vehicle characteristics time trace for engine, transmission input, transmission output, and wheel speed:
UDDS drive cycle:
HWFET drive cycle:
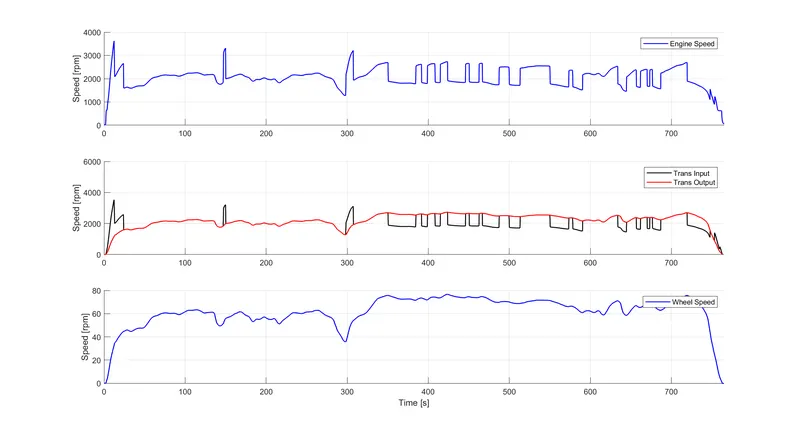
- We can see that the graph has more fluctuations in UDDS compared to the HWFET cycle.
- Braking is high in UDDS when compared to HWFET due to traffic Peak.
- Much of the fluctuating input speed is facilitated by the torque converter, and the transmission input speed fluctuates according to the engine torque required to achieve the drive cycle.
- The wheel speed and transmission output speed vary according to gear and differential ratio.
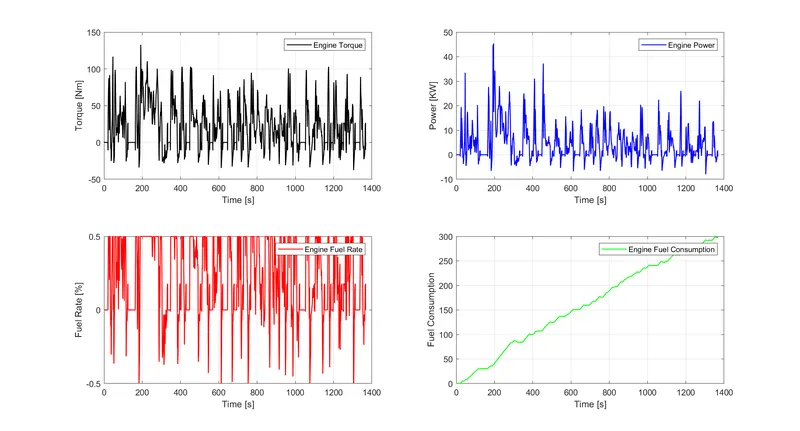
Plotting engine torque, engine power, fuel rate, and fuel consumption:
UDDS drive cycle:
HWFET drive cycle:
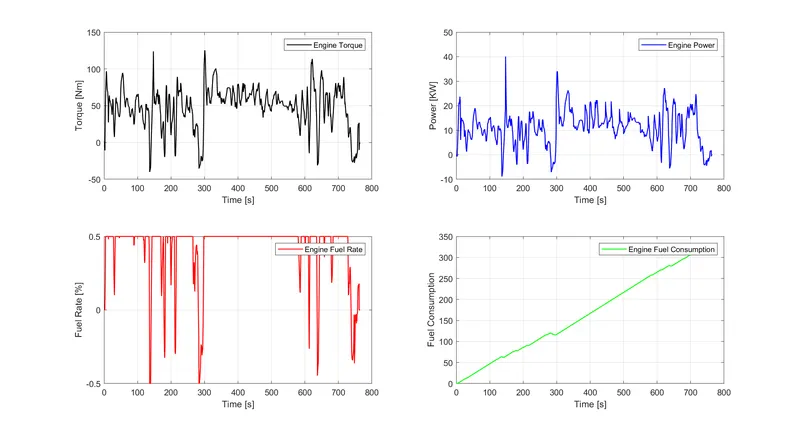
- The vehicle consumed more power in the UDDS compared to the HWFET cycle because it has too many starts and stops compared to HWFET.
- Engine torque is also high in UDDS because while starting from rest, the vehicle requires more torque to overcome static friction.
- The fuel rate is high in HWFET because the vehicle will be in continuous movement, and it consumes more fuel.
- The fuel economy will be high in HWFET compared to UDDS because there are many stops and starts in UDDS and more fuel is consumed when the vehicle is in an idle position.
HWFET drive cycle:
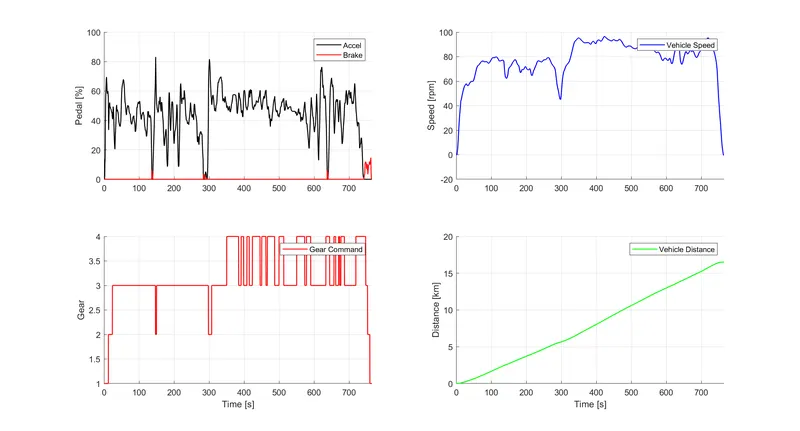
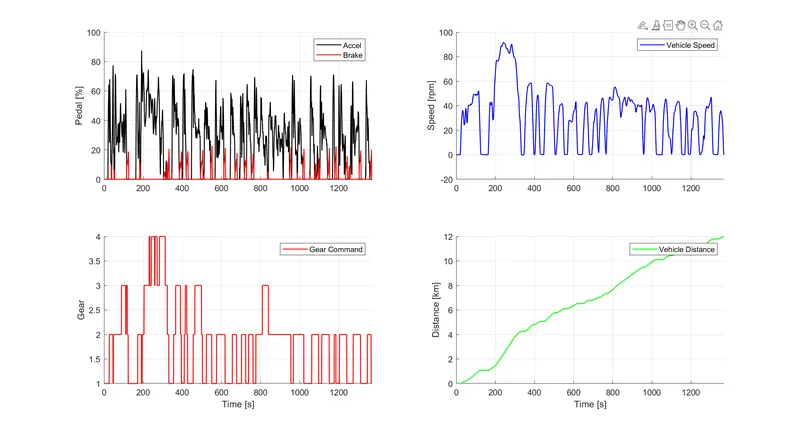
- For UDDS, the accelerator and the brake pedal have more fluctuations because of frequent starts and stops. But in HWFET, the brake pedal fluctuations are almost near the zero line as there will be no frequent stops.
- UDDS cycle mostly runs on 1st, and 2nd gears, and uses 3rd, and 4th gears very rarely as it does not achieve high speeds in that traffic. In the HWFET cycle, the vehicle mostly runs on 3rd, and 4th gears as it will be moving at high speeds. It uses 1st, and 2nd gears very frequently when braking is required.
- The vehicle speeds will be high in HWFET compared to UDDS. UDDS also has more fluctuations in speed due to frequent braking.
- The distance traveled in the given time will be high in HWFET than in UDDS because of the traffic barrier in UDDS.
Plotting engine operating points on the engine fuel map:
UDDS drive cycle:
HWFET drive cycle:
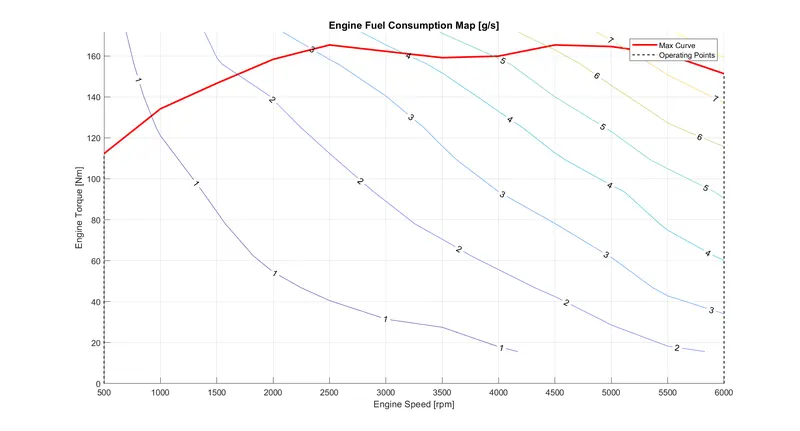
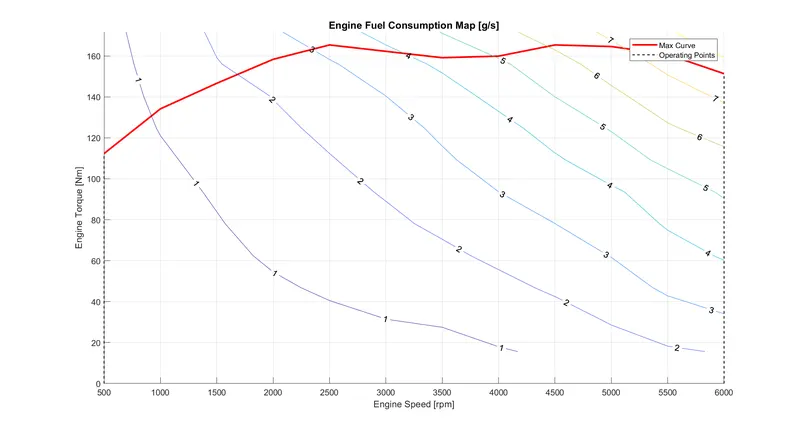
- By this, it is clear that as torque decreases speed increases.
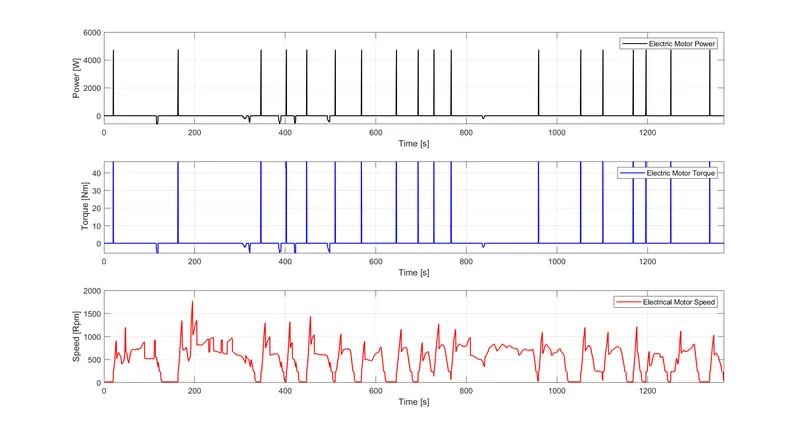
Plotting motor speed, torque, and motor input power:
UDDS drive cycle:
HWFET drive cycle:
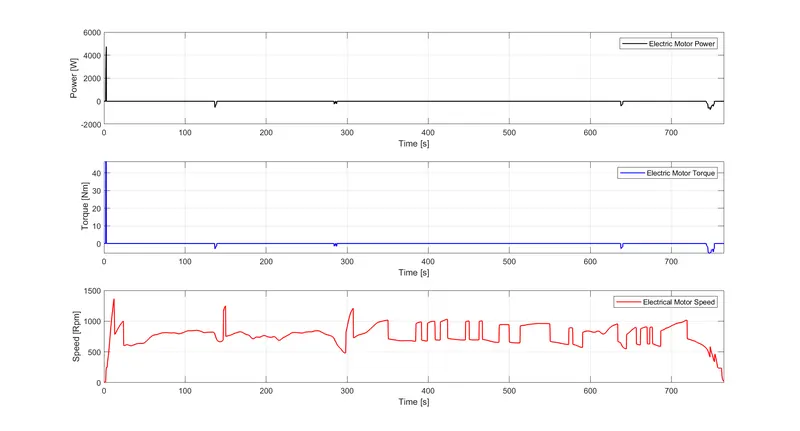
- The fluctuations will be more in the UDDS cycle compared to the HWFET cycle because UDDS has many starts and stops due to traffic as the purpose of the motor in P1 hybrid is the initiation of crank rotation and they are more in the UDDS cycle when compared to HWFET cycle.
- If the purpose of the motor is to provide traction then both cycles would have more fluctuations.
- The motor torque request is for engine start and region braking only. Electric input power is calculated by referring to the motor speed according to the EM motor torque request.
- EM motor torque demand is low as the vehicle moves at high speeds and is less idle on highway drive.
- We can observe that the motor power and torque are very high in HWFET at the start and they are almost zero after a few seconds but in UDDS it has continued fluctuations this is because of frequent braking in UDDS.
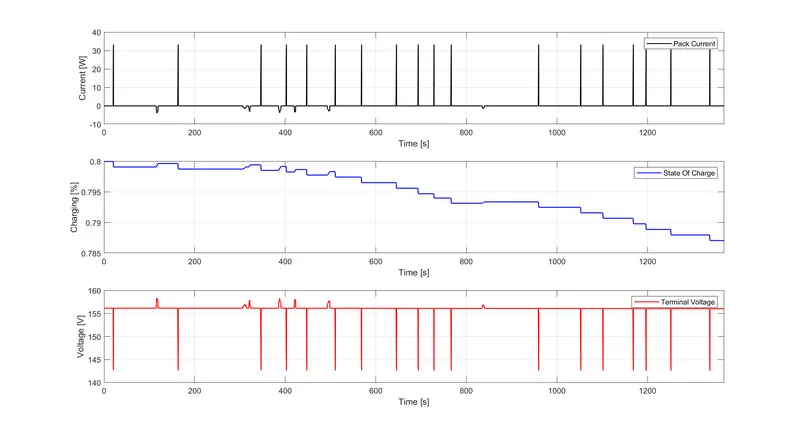
Plotting pack voltage, current, and SoC:
UDDS drive cycle:
HWFET drive cycle:
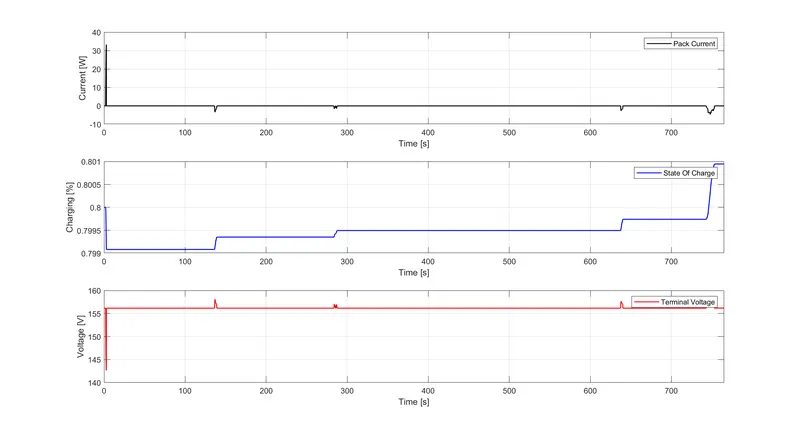
- The pack voltage and current will have more fluctuations in UDDS as compared to the HWFET cycle because of the frequent start and stops throughout the drive and the battery has to provide the energy every time when the car is starting from the idle position.
- SOC decreased in the UDDS cycle wrt time but it has increased in the HWFET cycle. It is because in UDDS we have frequent starts and stops and the battery has to provide the energy every time when the car starts from the idle position and the SOC decreases but in the HWFET cycle The Vehicle will be moving continuously without braking frequently and the alternator is utilized to transfer some engine power to the battery through motor so SOC increase in the HWFET cycle.
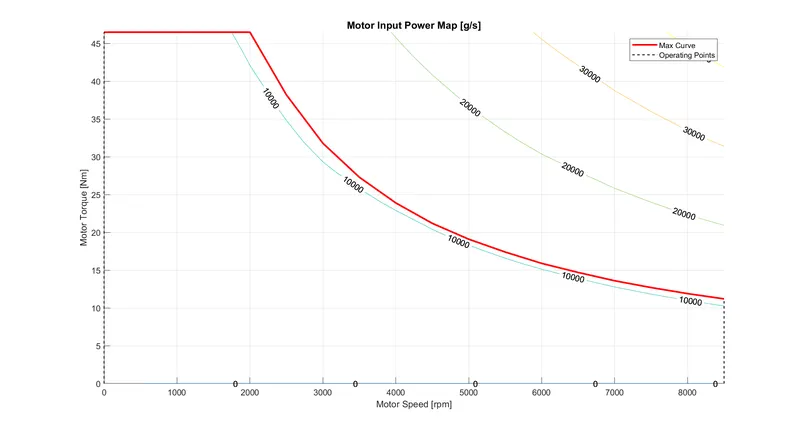
Plotting the motor operating points on the motor input power map, with the motor max motoring and generating torque curves:
UDDS drive cycle:
HWFET drive cycle:
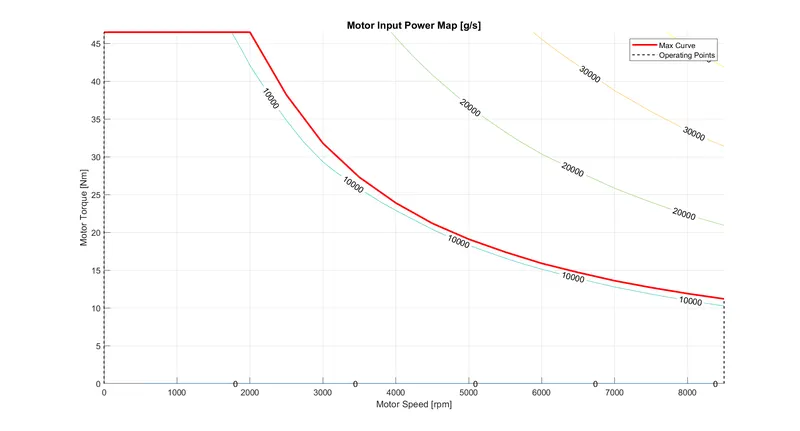
- The electric motor can operate between the max motoring torque curve and the max generating torque curve.
Conclusion:
- The fuel consumption rate is more in UDDS than in HWFET.
- The UDDS drive cycle is best for asses of fuel consumption and Pollutant emissions of vehicles in a normalized way.
- Distance traveled is more in HWEFT than in UDDS.
- We can observe that in UDDS the efficiency of the engine & fuel consumption is lost in braking & gear changing the vehicle.
- Implementing the electric motor as it is a P1 hybrid may not have many variations in the fuel economy but as we implement other architecture it will increase by a huge amount.