Project 2
Basic vehicle model development using MATLAB and Simulink
1.AIM
To create a complete Hybrid Electric Vehicle model including Driver , Electric Power Train and Vehicle model.
Analyse the performance of the vehicle for a US06 drive cycle and plot the Actual velocity and Power distribution curves. Also analyse the performace and fuel consumption of fuel cell, Ultracapacitor and battery.
2.Objective
2.1 To observe the following plots of the Vehicle for the US06 drive cycle.
- Acceleration / Brake
- Torque required
- Power required
- Power distribution among three energy sources
- Fuel cell voltage, current, power and fuel consumption
2.2 Energy Management distribution algorithm for positive power distribution
The Energy management system implemented here will follow rule based algorithm for the implementation of series parallel hybrid systems.
The implementation algorithm and flow chart are explained below.
The operating range of the sources is as follows.
- Fuel cell 23kW - 55kW
- Battery - less than 23kW when SOC is more than 35%.
- Ultra Capacitor - above 55kW when SOC is more than 35%
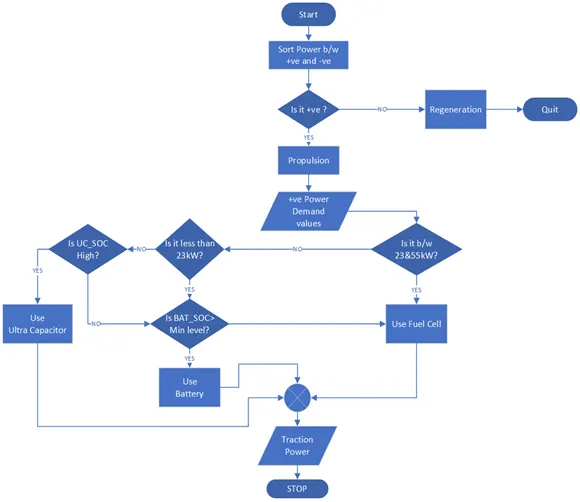
Figure 1: Flow chart for Positive Power Distribution
The flowchart for positive power distribution is as shown above.
- SIMULINK Modeling
The complete Simulink model of the vehicle is shown below. There are 3 main subsystems.
- Driver 2. Electric power train 3. Vehicle
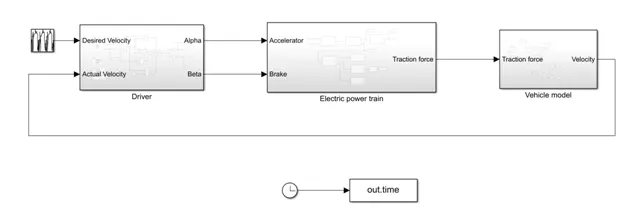
Figure 2 : Basic vehicle model
Each of these subsystems modeling in Simulink is explained below.
3.1 Driver Model
The basic function of driver block is to generate Acceleration (Alpha) and Brake (Beta) signals according to Desired velocity and Actual velocity commands.
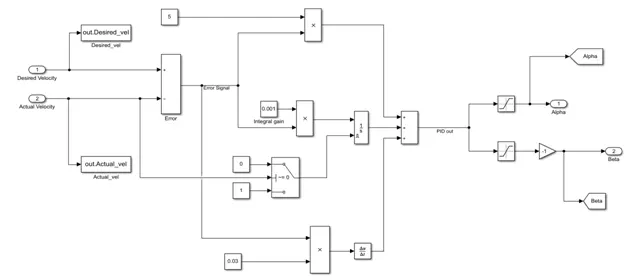
Figure 3 : Driver
The input to the driver model is desired velocity and actual velocity. The desired velocity is the driving cycle input provided through a repeating sequence of which velocity and time profiles are declared in workspace. In our model, the input is given by US06 drive cycle. The US06 Supplemental Federal Test Procedure (SFTP) was developed to address the shortcomings with the FTP-75 test cycle in the representation of aggressive, high speed and/or high acceleration driving behavior, rapid speed fluctuations, and driving behavior following startup [15].
Actual velocity is the velocity of the vehicle which is taken as a feedback from output. The error signal which is the difference between desired and actual velocity is fed through a PID controller.
If the integral block does not reset properly, it may cause integral wind up problem. It occurs due to the limitation in actuators. The correction from the integral term of PID controller increases a lot which causes the system output to go beyond the set point. It is known as overshoot and it increases with time.
To avoid these problems, external reset is provided to the integral block. Whenever the velocity becomes zero, this integral block gets reset. It is implemented through a switch. It passes a zero to the integral block whenever velocity gets zero.
The output of the PID controller is fed to the saturation block to get positive values. The Alpha can have any value from 0 to 1 and Beta from 0 to -1. The values of PID controller are optimized by observing the output velocity and input velocity profiles.
3.1.1 Observation
When desired velocity > Actual velocity, Acceleration is ‘1’ and Brake is ‘0’.
If Desired velocity < Actual velocity, Acceleration is ‘0’ and Brake is ‘1’.
When both Desired and Actual velocities are same, Acceleration = Brake = 0
3.2 Electric Power Train
The Electric power train contains the following blocks.
- Controller
- Power Calculation
- Tractive Force
- EMS (Energy Management System)
- UC model
- Fuel cell
- Battery model
The input/output signal arrangements inside ‘Electric power train’ subsystem is as shown below.
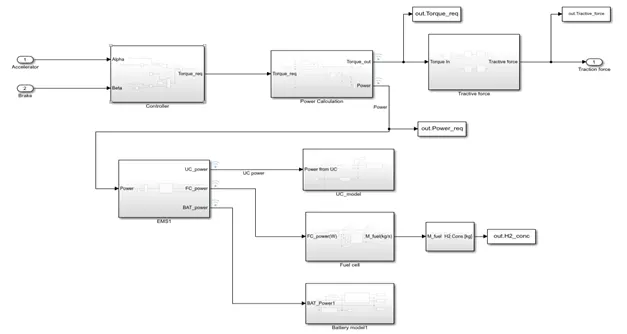
Figure 4: Electric Power Train
3.2.1 Controller
The controller block generates required torque signal from Acceleration and Brake commands. Electric motor torque (positive) values are declared in workspace as variable ‘EM_new.maxT_T’ array and negative values are declared as variable ‘EM_new.minT_T’ array.
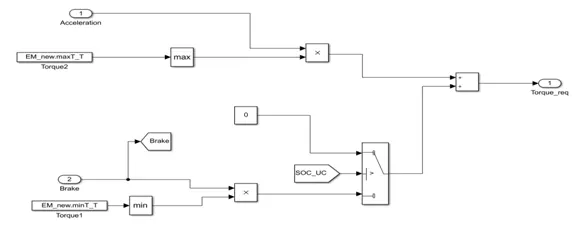
Figure 5 : Controller
The Acceleration and brake outputs of ‘Driver’ subsystem is fed to ‘Controller’ block. The ‘max’ block will take the maximum value and ‘min’ block will take the minimum value.
The SOC of ultracapacitor is being checked for regenerative braking. If the SOC_UC > 0.8, then it won’t be further charged while braking. If the SOC_UC <0.8, then UC will get charged when braking occurs.
While Acceleration positive torque request will be generated and while braking, negative torque will be generated. This torque request is fed to ‘Power Calculation’ block.
3.2.2 Power Calculation
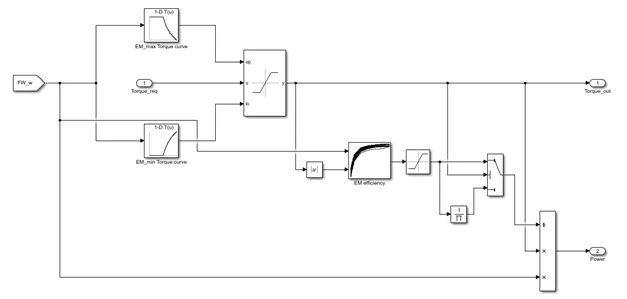
Figure 6 : Power Calculation
This subsystem will calculate required power for a given angular velocity and Torque.
In order to calculate power, we need angular velocity, torque and efficiency.
Power = (Torque * Angular velocity) / Efficiency
3.2.2.1 Angular velocity (w)
Angular velocity of the wheel is calculated inside ‘Tractive force‘ block and fed to this block.
3.2.2.2 Torque
For a given acceleration/brake the required torque being calculated by ‘Controller’ subsystem and fed to the ‘Power calculation’ block. Inside this there is a dynamic saturation block which will check whether the required torque is in the limits of torque that can be supplied by the Electric Motor. This is done by comparing the ‘Torque req’ with two curves of ‘w’ Vs ‘Torque’. Where ‘w’ is the Angular velocity in ‘rad/s’. One curve gives the values of positive torque for particular ‘w’ and other one gives the values of negative torque. While acceleration, torque will be positive and while braking, negative.
This dynamic saturation block will give the torque request value which can be supplied by the electric motor. This is given as ‘Torque out’ signal.
3.2.2.3 EM efficiency
This table will do some extrapolation and interpolation methods to give the value of Electric Motor efficiency for a particular toque and angular velocity. This can give efficiency values for torque and w values which are not listed in the table. A saturation block is provided at the output of this block to ensure that the efficiency value is positive.
If the ‘Torque req’ is positive (Acceleration), Power = (Torque * Angular velocity) / Efficiency
If the ‘Torque req’ is negative (Braking), Power = (Torque * Angular velocity) *Efficiency. Since the motor will act in “Generator mode’.
This condition is implemented through a switch as shown in figure 6.
3.2.3 Tractive Force
The Torque to Tractive force calculation can be done in ‘Tractive force’ subsystem which includes 1. Gear box model, 2. Front brakes 3. Front wheels 4. Rear brakes 5. Rear wheels.
The total tractive force generated will be the sum of forces in front wheels and rear wheels.
We consider that electric motor is coupled to the front wheels and so the braking torque will be provided to front wheels alone. The rear wheels will only have mechanical braking.
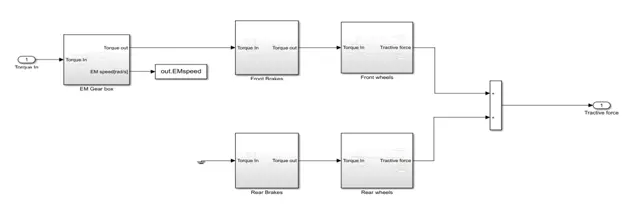
Figure 7 : Tractive Force
The ‘Tractive force’ subsystem is as shown above.
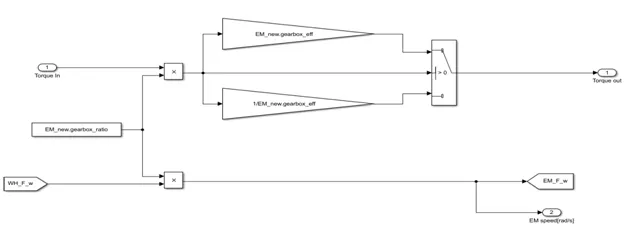
Figure 8 : Gear Box
The output of the gear box depends upon the torque input from electric motor and the efficiency of the gear box.
The output of the gear box,
Torque out = Torque * Gear box ratio * Efficiency [For +ve Torque]
Torque out = Torque * Gear box ratio / Efficiency [For -ve Torque]
The electric motor speed, EM speed = Gear box ratio * wheel speed
The wheel speed (angular velocity) is calculated in front wheel model.
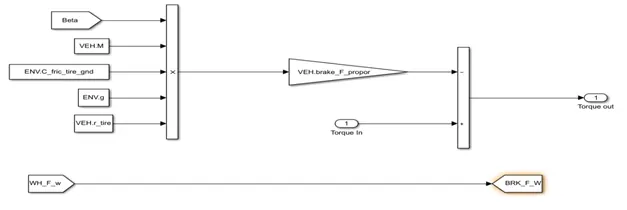
Figure 9: Front Brakes
The front brakes model is as shown above. The traction force in front wheels is provided by regenerative braking and mechanical braking.
The braking torque is given by,
Braking Torque = Brake signal * vehicle mass * ground friction * gravity * tire radius.
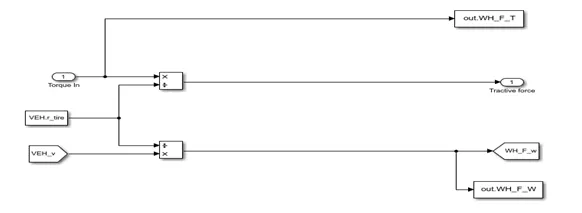
Figure 10 : Front wheels
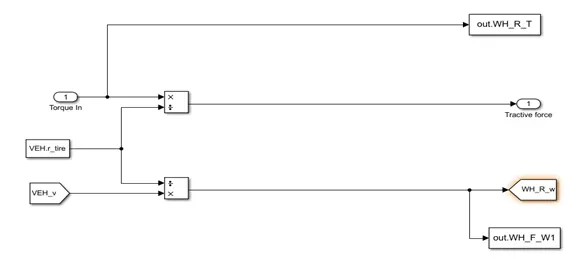
Figure 11 : Rear Wheels
The front and rear wheels model is as shown above. The tractive force can be calculated as
Tractive force = Torque / radius of tire
The angular velocity of the vehicle calculated as
Angular velocity = Vehicle velocity / radius of tire
This is being fed to the gear box block to find the electric motor speed.
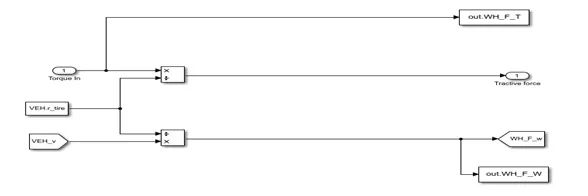
Figure 12 : Rear Brakes
Only mechanical braking is applied to rear wheels. So the torque input is connected to ground. And the tractive force is calculated similarly as front brakes block in figure 11.
Since the Torque input is zero, there won ‘be any tractive force generated in this block shown in figure12.
3.2.4 Energy Management System
The Energy Management system should allow energy sources to operate in their optimum performance range and at the same time it should be able to provide power even if any sources are not available. Hybrid energy management system has the advantage of providing uninterruptible power in almost all cases.
In our case we are considering three energy sources for power distribution.
The operating range of each of the sources are as follows.
- Fuel cell 23kW - 55kW
- Battery - less than 23kW when SOC is more than 35%.
- Ultra Capacitor - above 55kW when SOC is more than 35%
Back up power distribution is as follows.
|
Power Demand |
Conditions |
Actions |
|
Power<23kW |
if SOC of battery high else SOC of battery low |
Power delivered by battery Power delivered by fuel cell |
|
23kW<=Power<55kw |
NA |
Power delivered by fuel cell |
|
Power>=55kW |
if SOC of UC is high else if SOC of BAT is high else |
Power delivered by UC Power delivered by battery Power delivered by Fuel cell |
The flowchart for positive power distribution is as shown in figure1.
Inside 'Positive power subsystem, Power has been comapred using interval test block and switches. The primary power distribution is as shown in table above.
Inside 'Positive power' subsystem, there is another subsystem called 'Backup_power'. Inside that the battery SOC and fuel cell SOC have considered and back up power options are provided for each condition as explained in table above.
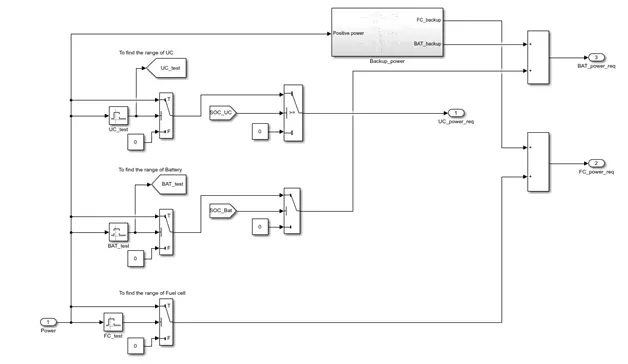
Figure 13 : EMS
3.2.5 Fuel cell Modeling
Fuel cell modeling is helpful for fuel cell developers because it can lead to fuel cell design improvements, as well as cheaper, better, and more efficient fuel cells. The model must be robust and accurate and be able to provide solutions to fuel cell problems quickly. A good model should predict fuel cell performance under a wide range of fuel cell operating conditions[2].
There are two different types of models: engineering or scientific models and statistical models. Engineering and scientific models are often built using equations from the literature and from derived equations. In this model type, there is often a combination of equations that are used to calculate the natural phenomena that is occurring -- and there is often little to no available data to help build the model. The other model type is a statistical or empirical model. These models are generated from known datasets[6].
There are many statistical tools that can be used for model validation. One of the most useful tools is graphical residual analysis.
The model implemented in this project is statistical model. It several values from datasheet or experimental analysis. The details of this model are explained below.
There are mainly 3 systems involved in the modelling of fuel cell
- Compressor model
- Fuel cell stack
- Feedback control
Actual fuel cell includes lots of other components also. But here only main components have been modelled and the performance optimisation is done by adding datasheet values/ plots.
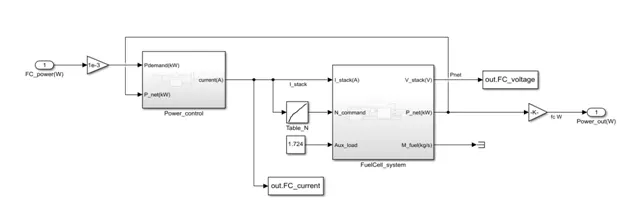
Figure 14 : Fuel cell subsystem
Inside ‘fuelcell’ subsystem, there are two subsystems.
- ‘Power_control’ ‘FuelCell_system’
The Energy Management System (EMS) will calculate the power required from fuel cell and fed to the fuelcell subsystem.
3.2.5.1 Power_control subsystem
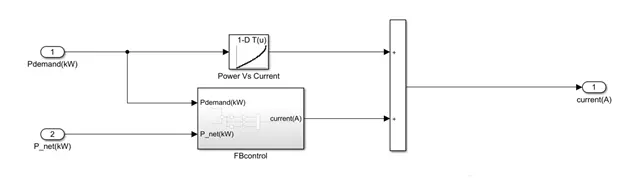
Figure 15 : Power_control subsystem
The desired current of fuel cell is calculated from the power request and feedback values inside this block.
There is a lookup table which gives fuel cell current value to the corresponding power input. The power Vs current curve will be provided by the manufacturer.
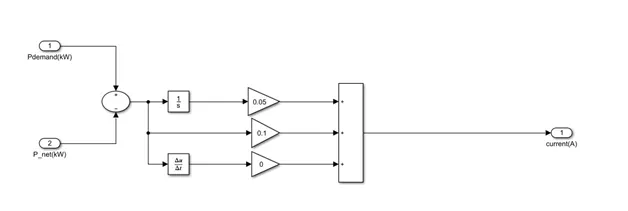
Figure 16 : FBcontrol subsystem
The feedback control loop takes the feedback power and the difference between power demand and output power is fed through a PID controller to get the corresponding current. Both of these currents are added together to get the total current.
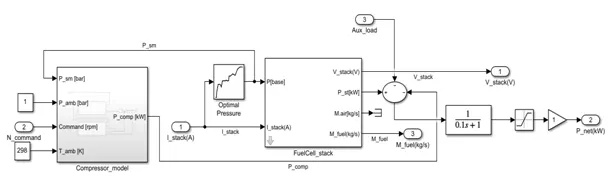
Figure 17 : Fuelcell _system
3.2.5.2 Compressor model
The simplest type of pressurised PEM fuel cell is that in which the hydrogen gas comes
from a high-pressure cylinder. Only the air has to be compressed. The hydrogen gas is
coming from a pressurised container, and thus its compression ‘comes free’[3].
Running a fuel cell at higher pressure will increase the power, but it also involves the
expenditure of power, and there is the cost, weight, and space taken up by the compression equipment.
The increase in power resulting from operating a PEM fuel cell at higher pressure is
mainly the result of the reduction in the cathode activation overvoltage. The increased pressure raises the exchange current density, which has the apparent effect of lifting the open circuit voltage (OCV). There is also sometimes a reduction in the mass transport losses, with the effect that the voltage begins to fall off at a higher current. In simple terms, for most values of current, the voltage is raised by a fixed value.
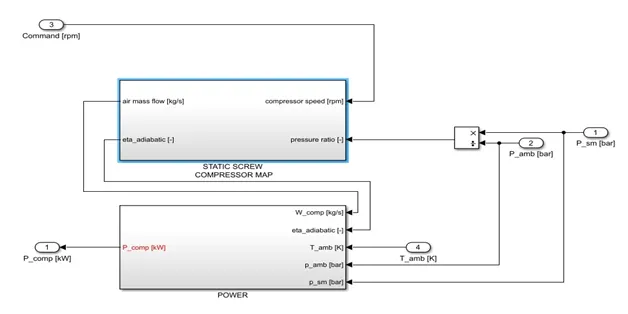
Figure 18 : Compressor_model subsystem
The air flow rate from the compressor depend on the following values.
- Pressure ratio
- Compressor speed
- Adiabatic efficiency
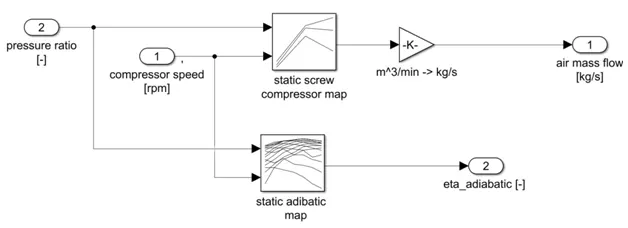
Figure 19: Static screw compressor map
The adiabatic efficiency map gives the efficiency of the compressor for different compressor speed and pressure speed.
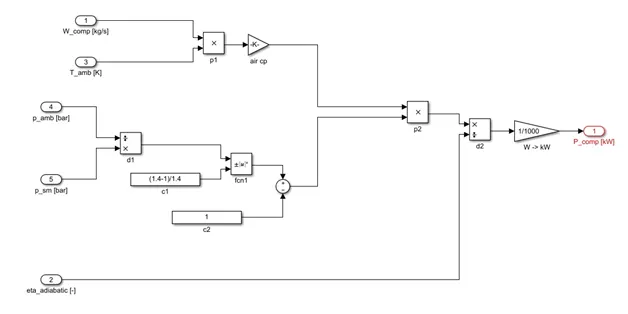
Figure 20: Power
The compressor output power can be calculated as follows[2] :
P_comp = (W_comp * T_amb * Cp) * (((P2/P1) (1.4-1/1.4) -1) / eta_adiabatic)
Where W_comp = air flow rate[kg/s]
T_amb – Ambient temperature
Cp - specific heat at constant pressure (J/gK)
P2 – Raised pressure
P1 – Atmospheric pressure
3.2.3 Fuel Cell stack subsystem
- Stack_voltage
2. Air&H2_consumption
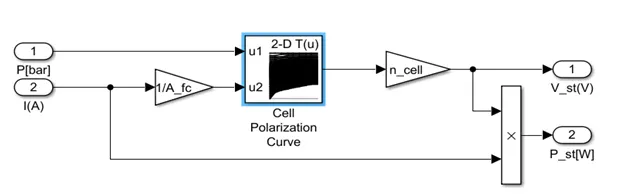
Figure 21 : Stack_voltage
The stack voltage subsystem will give the stack voltage value for different cathode pressures and current density. Where ‘A_fc’ is the area of fuel cell and n_cell is the number of cells in series.
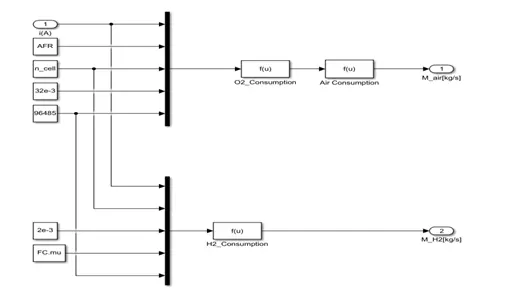
Figure 22 : Air&H2_compression
The Oxygen consumption is given by[2],
O2 Consumption = (I * AFR * no.of cells in series * molar mass of O2 ) / (4* F)
Where I = Stack current
AFR = Air fuel ratio
Molar mass of O2 = 32e-3
F = Faradays constant = 96485
The Air consumption is given by,
Air Consumption = O2 consumption / (0.21*32/(0.21*32 + 0.79*28))
Where Approximate Air:
0.21 02 + 0.79 N2 (mole basis)
Molar mass of O2 = 32 and N2 = 28
The Hydrogen consumption is given by,
H2 consumption = I * no.of cells in series * molar mass of H2 / 2* FC.mu*F
Where FC.mu = Hydrogen utility factor
Molar mass of H2 = 2e-3
F = Faradays constant
3.2.6 Battery model
The Li-Ion battery model is as shown in figure13. The input to the model is the power request from the EMS. There are two subsystems inside it.
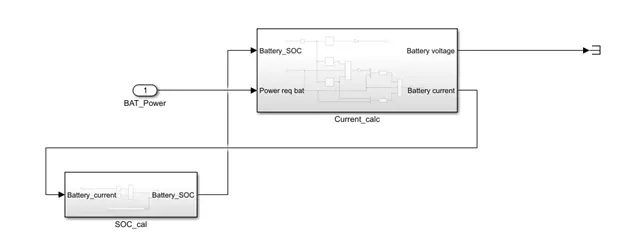
Figure 23 : Battery model
- Current_calc
- SOC_cal
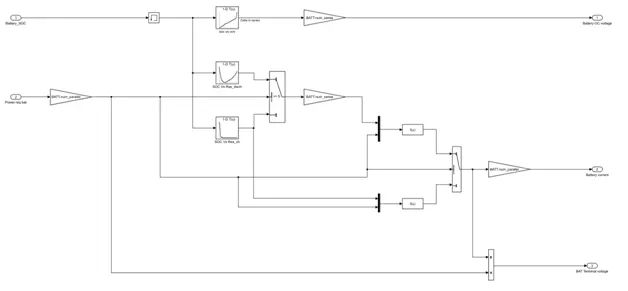
Figure 24 : Current calc
The current calculation subsystem is as shown above. Battery voltage is determined from SOC[5]. The open circuit voltage with SOC data for a single cell will be available from the datasheet. It has to be multiplies with total number of cells in series to get the total voltage of the battery pack.
There are 3 plots used in this model to calculate the current. The open circuit voltage of the battery is determined from the SOC Vs OCV plot.
The internal resistance of the battery will be different while charging and discharging. This value can be obtained from SOC Vs Resistance for discharging and charging curves.
Then current, I = sqrt(Power /R(chg/disch))
The battery terminal voltage = Battery power / current
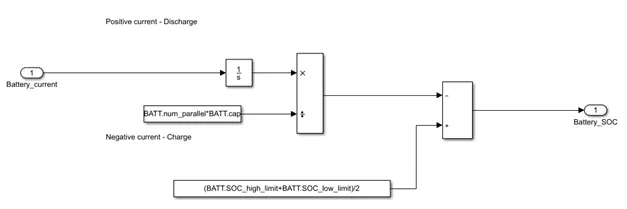
Figure 25 : SOC
The SOC estimation of the battery is as shown above. There are various methods to estimate the SOC of a battery. The method adopted here is the coulomb counting method [5]. The Coulomb counting method measures the discharging current of a battery and integrates the discharging current over time in order to estimate SOC. Coulomb counting method is done to estimate the SOC(𝑡), which is estimated fromthe discharging current, 𝐼(𝑡), and previously estimated SOC values, SOC(𝑡 −1). SOC is calculated by the following equation[5]:
SOC(t) = SOC(t-1) + ( I(t) * Δt ) / Qn
Where Qn is the total Ah capacity of the battery. Here it is given as a constant value of 200Ah. Which is converted to mAh and fed to the block. There should be an initial SOC for the battery to provide emergency power to the vehicle. This is provided by another constant block.
Initial SOC = (Maximum SOC+ Minimum SOC) / 2
This SOC is fed to the current calculation block for current calculation. Since SOC is available after 1st iteration, a memory block is added to avoid computational error.
3.2.7 Ultracapacitors
At the time of designing any system, primary source must be sized in such a manner that it can provide peak demand even though it occurs only for few seconds or minutes as compared to continues or average demand. Sizing whole system based on peak demand in place of average demand is very costly and inefficient as we are unable to utilize its full capacity all the time. But if we design system by storing electrical energy from primary source to some other energy storage device and then delivering that stored energy to the load in forms of burst of power in a controlled manner whenever peak demand occurs for a period of time ranging from fraction of seconds to several minutes, we can improve operation of system significantly.
Fuel cells have an operating range in which gives maximum efficiency. Operating outside this region reduces the efficiency and performance. So it cannot be used for supplying transient power.
Batteries have many limitations like low power density, poor low temperature performance, can’t be charged or discharged at high rate over many hundreds of thousands cycles, requires repeated replacements throughout the life of system.
Ultra capacitors provide simple and highly reliable solution to bridge the short term power mismatches between power available and power required. They have much higher power density, extremely longer cycle life, wide temperature range (-40 to +65 degree) but low energy density.
In our system Ultra capacitors are designed to handle power demand above 55kW.
3.2.7.1 Modeling of Ultracapacitor in SIMULINK
The ultra capacitor model is as shown in the figure below. There are two subsystems inside it to estimate current and SOC.
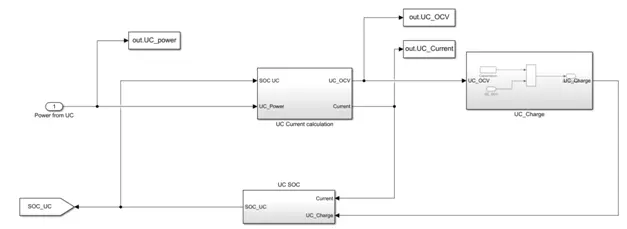
Figure 26 : Ultra capacitor subsystem
There are three main blocks inside this subsystem.
- UC Current calculation
- UC SOC
- UC Charge
Figure 27: UC Current calculation
The stored charge in an ultracapacitor is characterized by a normalized measure called the state of charge, SOC ∈ [0,1]. The state of charge of 0 represents no stored charge and 1 corresponds to full charge. The rate of change in ultracapacitor state of charge is proportional to the discharging or charging current Icap (positive or negative values of current denote discharging or charging respectively)[4]:
d/dt (SOC(t) = (-1 / CVmax)* Icap(t)
where C is the capacitance of the ultracapacitor module in Farads and Vmax is its voltage at full charge.
- UC_Current
- OCV
- Charge on UC
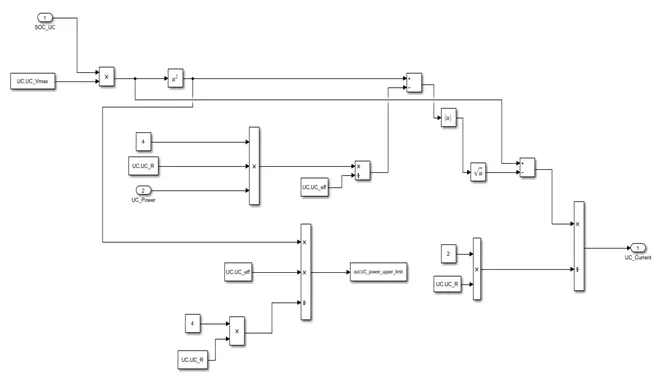
Figure 28: Current
The current of ultra capacitor can be calculated as given below[4].
I = SOC * Vmax – sqrt (SOC * Vmax 2 – 4* R * PUC * eff
Where I = UC current
Vmax = Maximum rated voltage at 100% SOC
R = lumped resistance
PUC = Power requested to ultra capacitor from EMS
Eff = Efficiency of ultra capacitor
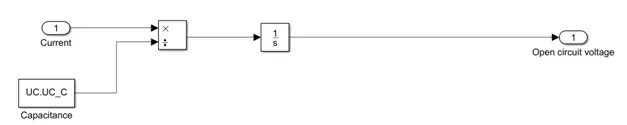
Figure 29: OCV
The open circuit voltage of Ultra capacitor can be estimated as follows[4].
OCV =
This has been implemented above.
Unlike batteries UC doesn’t need complex SOC estimation methods. The SOC is proportional to Open circuit voltage.
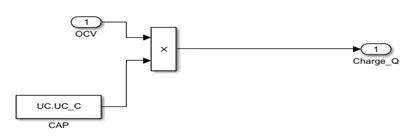
Figure 30 : Charge on UC
The UC charge can be estimated by,
Charge, Q = OCV * C
Where C is the capacitance of UC.
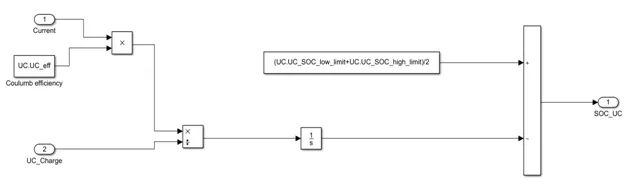
Figure 31 : SOC
There should be an initial SOC for the battery to provide emergency power to the vehicle. This is provided by another constant block.
Initial SOC = (Maximum SOC+ Minimum SOC) / 2
The SOC of UC is given by,
SOC =
Where η= Charging efficiency of UC
As charging and the discharging of the ultracapacitor do not involve any chemical reaction they can be cycled with almost no deterioration. UC can withstand more than 1 million charge and discharge cycle. As the capacitance offered by UC is very high, energy density UC is also very high (10 times) compared to conventional capacitor and the power density is very high (10 times) compared to battery.
3.3Vehicle Model
There are certain resistances which are opposing vehicle movement. This includes rolling resistance of the tires, aerodynamic drag, and grading resistance. All these resistances are discussed below.
- Rolling Resistance (Fp)
The rolling resistance of tires on hard surfaces is primarily caused by hysteresis in the tire materials. This is due to the deflection of the carcass while the tire is rolling. The hysteresis causes an asymmetric distribution of ground reaction forces.
Rolling Resistance can be found as
Fp = M * g * u * cos (α)
Where u= rolling resistance coefficient
α= Grade angle
The rolling resistance coefficient, fr, is a function of the tire material, tire structure, tire temperature, tire inflation pressure, tread geometry, road roughness, road material, and the presence or absence of liquids on the road.
- Aerodynamic Drag (FA)
A vehicle traveling at a particular speed in air encounters a force resisting its motion. This force is referred to as aerodynamic drag. It mainly results from two components: shape drag and skin friction.
Shape drag: The forward motion of the vehicle pushes the air in front of it. However, the air cannot instantaneously move out of the way and its pressure is thus increased, resulting in high air pressure.
Skin friction: Air close to the skin of the vehicle moves almost at the speed of the vehicle while air far from the vehicle remains still. The difference in speed between two air molecules produces a friction that results in the second component of aerodynamic drag.
Aerodynamic Drag
FA = 1/2 * delta * Af * Cd * V2
Where V= vehicle speed
Af = vehicle frontal area
Cd = aerodynamic drag coefficient
Delta = air density
3.3.3 Grading Resistance (Fg)
When a vehicle goes up or down a slope, its weight produces a component and it is always directed to the downward direction. This component either opposes the forward motion (grade climbing) or helps the forward motion (grade descending). In vehicle performance analysis, only uphill operation is considered. This grading force is usually called grading resistance.
Grade Resistance
Fg = M * g * sin (alpha)
Where M = Mass of the vehicle
g= gravitational force
alpha = grading angle
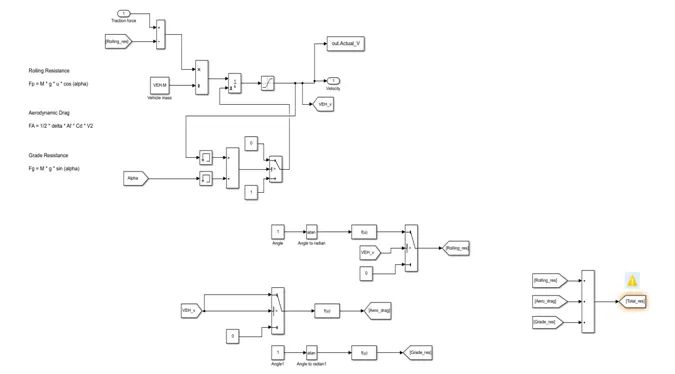
The above shown is the vehicle model. All the resistances mentioned above are implemented in this. The traction force should be more than all these resistances to keep the vehicle moving in forward direction.
The vehicle velocity is also calculated in this block.
Velocity =
Where Ft = Traction force
Fp = Rolling resistance
M = Mass of the vehicle
4. RESULT Analysis
The Actual velocity and desired velocity of the vehicle have been plotted in figure 33 and 34.
It has been understood that the vehicle designed here does not exactly follow the desired velocity. But it is somewhat similar in certain areas.
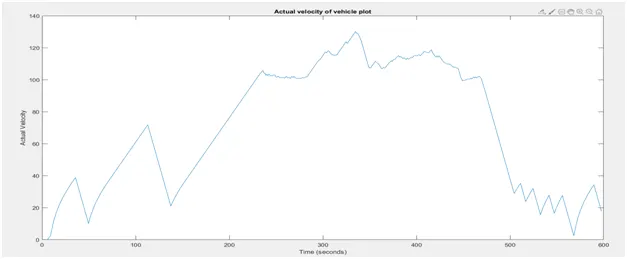
Figure 33 : Actual velocity plot
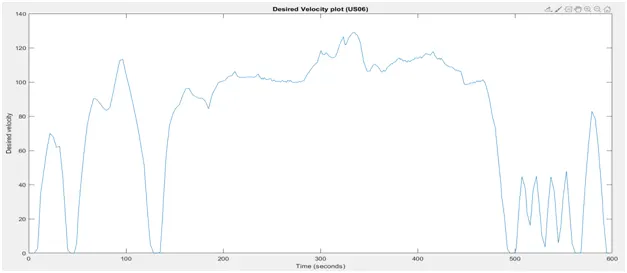
Figure 34 : Desired velocity plot
From this plot we can understand that more fine tuning of PID controller and controller of electrical power train is required to follow the input velocity plot.
The power request to the EMS plot is shown in figure 35. It can be observed that due to the aggressive drive cycle the power is more and it falls in ultracapacitor region.
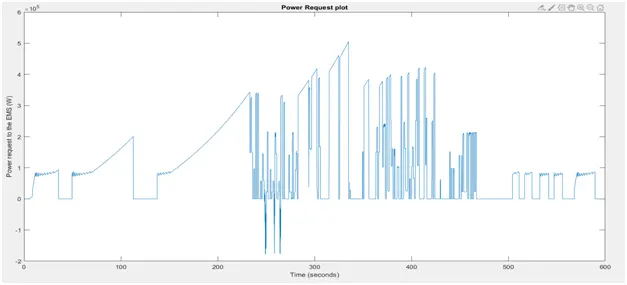
Figure 35 : Power Request to the EMS
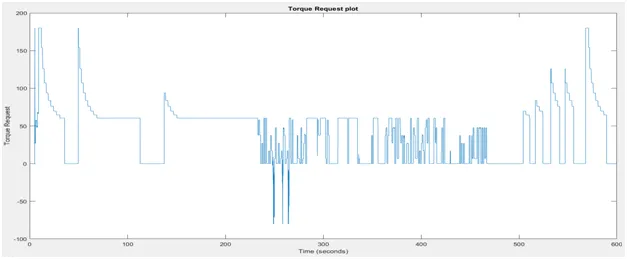
Figure 36 : Torque request for power calculation
The torque request plot is shown above in figure 36. It can be observed that the torque is high for minimum speeds and less for maximum speeds.
The Tractive force plot is shown in figure 37. It can be observed that Accelerating from o to maximum speed requires more tractive force and maintaining in a constant speed require less force.
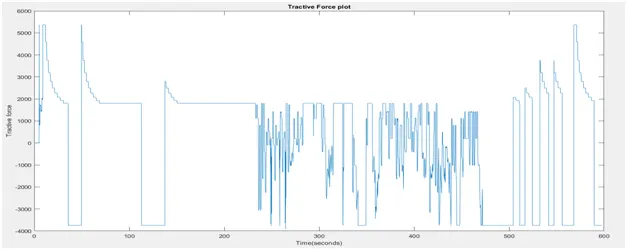
Figure 37 : Tractive force output
4.1 Fuel cell plots
The Fuel cell output power plot is as shown in figure 38. It can be observed that the area which fuel cell can deliver power is very less and fuel cell output is limited from 23kw to 55kw.
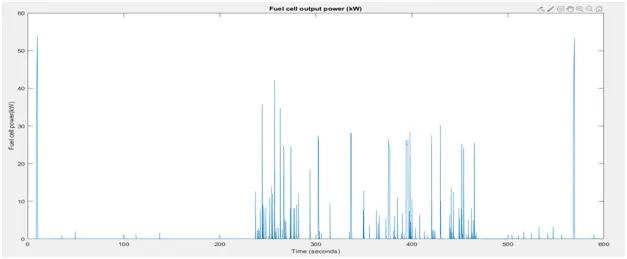
Figure 38 : Fuel cell output power
The fuel cell current and stack voltage plots are as shown in figure 39 and 40. It cab be seen that Fuel cell current goes up to 700A and maximum Stack voltage is 350V.
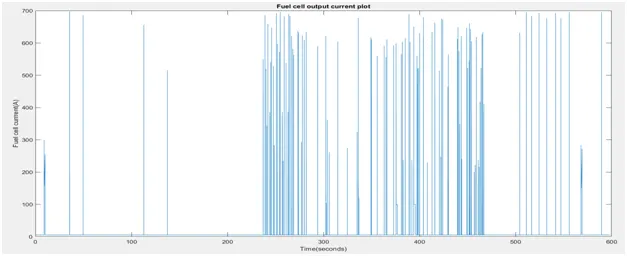
Figure 39 : Fuel cell Current
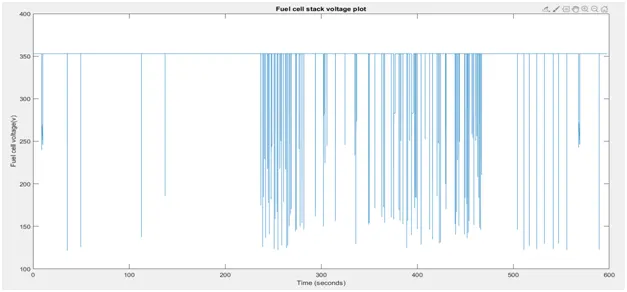
Figure 40 : Fuel cell stack voltage
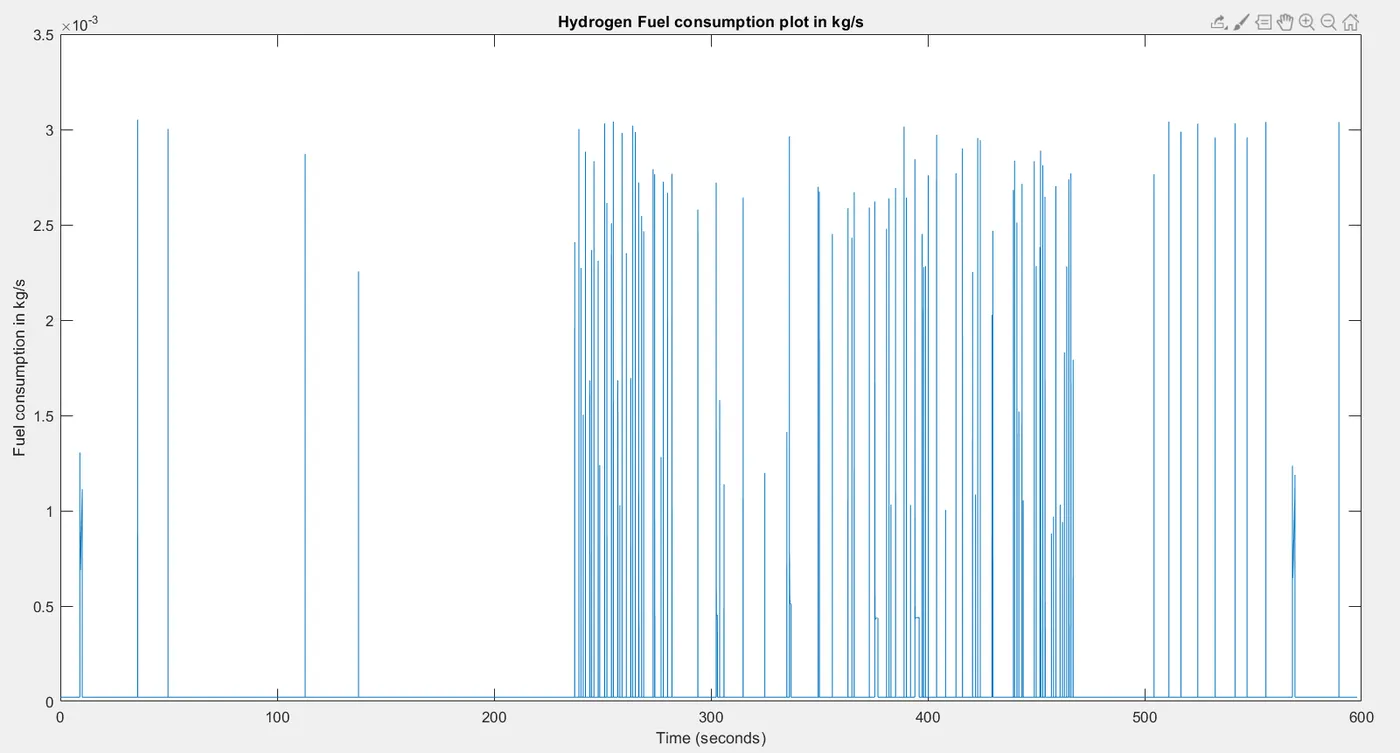
Figure 41A : Hydrogen fuel consumption plot
The above figure shows the Hydrogen fuel consumption in kg/s. We can observe that during maximum power delivery the fuel consumption goes uo to 3.5kg/s.
4.2 Ultracapacitor output plots
The ultracapacitor open circuit voltage, current and power has been plotted in figures 41,42 and 43.
The OCV of ultra capacitor is proportional to State of charge. But here we have implemented only discharge circuits for UC. There is no charging circuit in this model. But we have given some amount of initial SOC so that it can deliver the desired power at all times. This is the reason in figure 41, the OCV does not drop below a certain voltage.
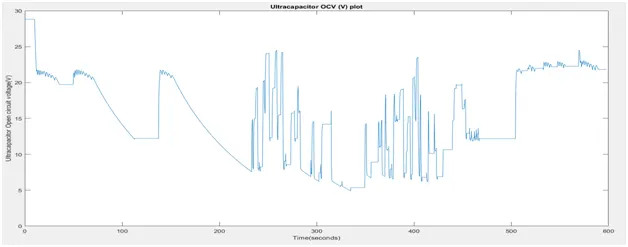
Figure 41 : Ultracapacitor Open Circuit Voltage
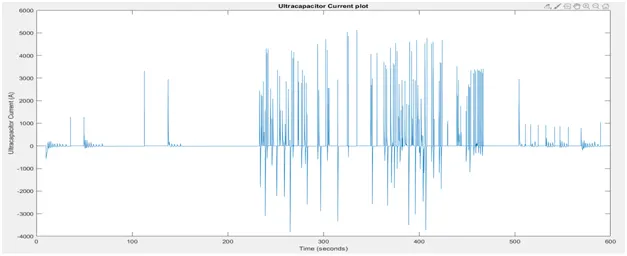
Figure 42 : Ultracapacitor Current
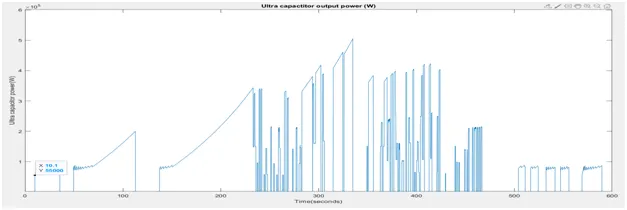
Figure 43 : Ultracapacitor output power
For more accurate analysis we should implement charging circuit also. From the figure 42, we can understand that the current discharged by the ultra capacitor is very high during transient times. And it is un comparable with the current of fuel cell and battery. The Ultra capacitor output power is plotted in figure 43.
4.3 Battery Output plots
The Battery power, voltage, currents are plotted in figures 44,46 and 47. The battery is designed to operate below 23kW. It can be observed that the maximum battery voltage is 130V and maximum current is 175A.
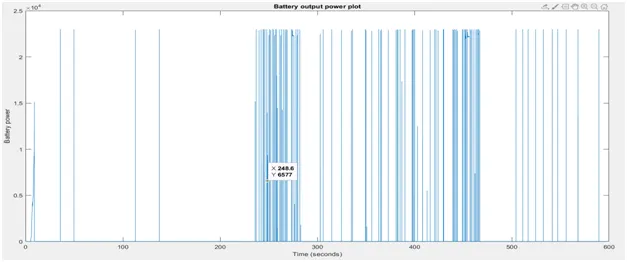
Figure 44 : Battery Power
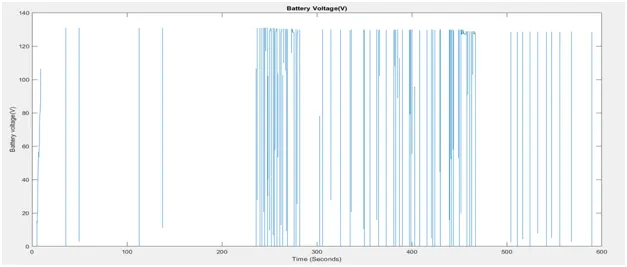
Figure 45 : Battery Voltage
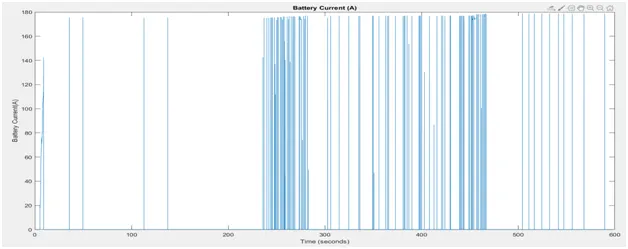
Figure 46 : Battery Current
5. Conclusion
The complete model of Hybrid electric vehicle has been modelled and simulated using MATLAB Simulink. The following components were modelled successfully and analysed the output.
- Driver model with acceleration and brake commands
- Hybrid Electric power train which includes
- Controller
- Energy management for positive power with Fuel cell, Ultracapacitor and Battery
- Tractive force
- Fuel cell model
- Ultracapacitor model
- Battery model
- Vehicle model
The output plots of above blocks have been plotted and analysed. It has been observed that the power distribution among the sources is as per algorithm and the vehicle almost follow the input drive cycle profile.
6. Future Scope
We can observe from output plots that the vehicle does not exactly follow the input voltage profile. Optimization in the vehicle model has to be done to correct this.
The fuel cell control has to be optimised such that it follows the power request demand.
BMS for battery , Ultracapacitor management and charging circuits should be included for better control strategy.
EMS should be modified to handle regenerative power to charge the ultra capacitor.
The other components like Motor model, inverter model should be included for better analysis of vehicle performance.
7. References
- Fuel Cell Handbook, 7th Edition by EG&G Technical Services, Inc.
- Colleen Spiegel , ‘Designing and Building Fuel Cells’
- James Larminie, Andrew Dicks, ‘Fuel Cell Systems Explained’
- Ardalan Vahidi, Wesley Greenwell, ‘A Decentralized Model Predictive Control Approach to Power Management of a Fuel Cell-Ultracapacitor Hybrid’
- Wen-Yeau Chang , ‘ The State of Charge Estimating Methods for Battery: A Review’
- https://www.fuelcellstore.com/blog-section/fuel-cell-modeling-blog-articles/model-validation-using-residuals
- https://www.fuelcellstore.com/blog-section/fuel-cell-modeling-blog-articles/fuel-cell-modeling-basics
- H.J. Bergveld, ‘Battery Management Systems Design by Modelling’.
- Dongdong Zhao, ‘Control of an ultrahigh speed centrifugal compressor for the air management of fuel cell systems’.
- Richard C Dorf, ‘PEM fuel cells: Theory and practise’.
- Mehrdad Ehsani, Yimin Gao, Sebastien E. Gay, ‘Modern Electric, Hybrid Electric, and Fuel Cell Vehicles’
- Reza N. Jazar, ‘Vehicle Dynamics: Theory and Applications’
- Iqbal Husain, ‘ELECTRIC and HYBRID VEHICLES : Design Fundamentals’
- Dr Boris Stojić, ‘Basics of Vehicle Dynamics'
- wikipedia.org/wiki/FTP-75
List of attachments
- Simulink Model for Basic vehicle model
- Workspace file with variable declaration
- Output plots