Project 2
Project 2
Description:
As discussed in Lecture 11, Project 2 deals with the development of a forward energy-based fuel consumption model of a P1 hybrid vehicle. This model is based on the conventional vehicle model from Project 1.
The main goal of this project is to understand the functionality of a P1 hybrid and be able to model it.
Honda Insight motor and battery are considered for this project. Data is taken from ADVISOR data base developed by NREL, USA. Data provided in the project files.
“Project2_InitFile.m” is a Matlab script used to load all the variables required for running the Simulink model and for post-processing. The drive cycle selection is also done here. Before running the Simulink vehicle model, run this initialization script.
Task:
The task of this project is to quantify the improvement in fuel economy numbers for the hybrid vehicle (kmpl), compared to the conventional vehicle, on the urban cycle (UDDS) and highway cycle (HWFET). Also, to analyze and understand the vehicle operating points in terms of engine and motor speed, torque, transmission speeds, pedal positions, gear, distance traveled, battery voltage, current, SoC etc.
To do that, the following steps need to be followed:
1) Load the Project2 folder as the Current Folder in Matlab.
2) Run the “Project2_InitFile.m” Matlab script.
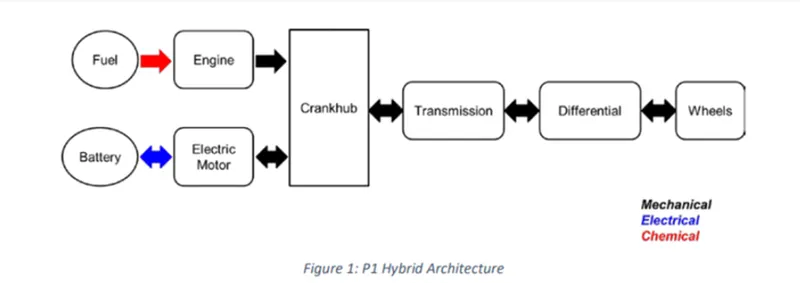
3) Copy the Conventional vehicle Simulink model created for Project 1 in this folder. Figure 1: P1 Hybrid ArchitectureHybrid Drives Development
4) Modify this model into a hybrid vehicle model. The lecture presentations can be used as reference. Battery and Supervisory controller models developed in the assignments can be reused.
5) Add additional ‘To Workspace’ blocks for transferring the desired Simulink vehicle data into the Matlab workspace.
6) Simulate the hybrid model on the desired drive cycles.
7) Write a project report that contains the following:
a. Tabulate the fuel economy numbers (kmpl) for UDDS and HWFET cycle. Compare these numbers with the baseline numbers for conventional vehicle model from Project 1.
b. Plot the time trace for engine, transmission input, transmission output and wheel speed on one plot.
c. Plot engine torque, engine power, fuel rate and fuel consumption using subplots.
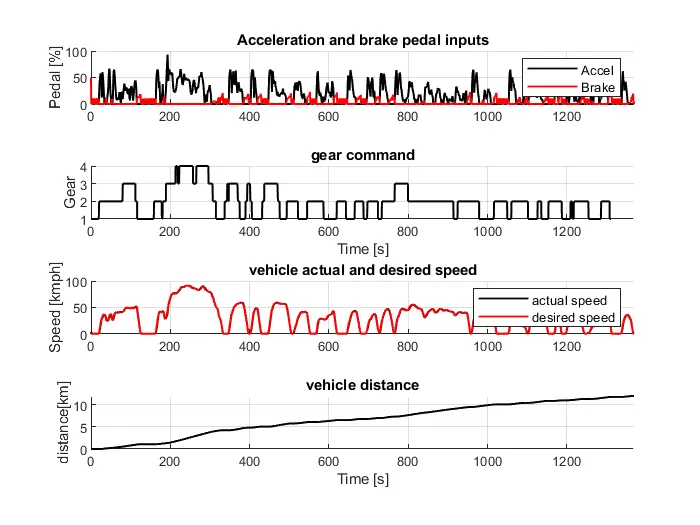
d. Plot accelerator and brake pedal, gear command, vehicle desired and actual speed, vehicle distance using subplots.
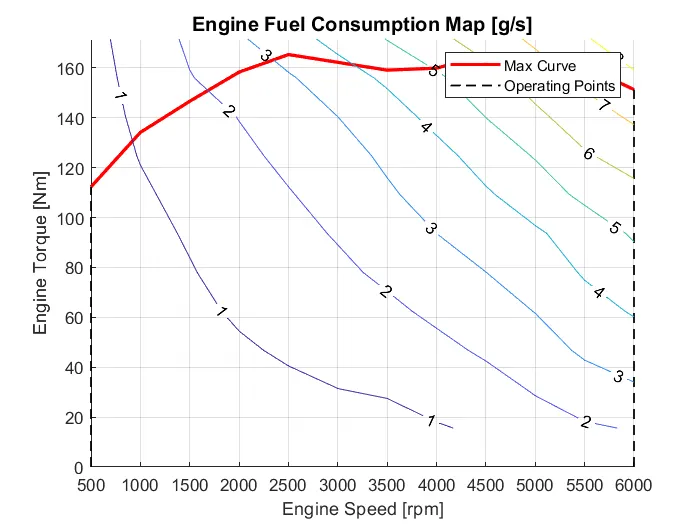
e. Plot the engine operating points on the engine fuel map.
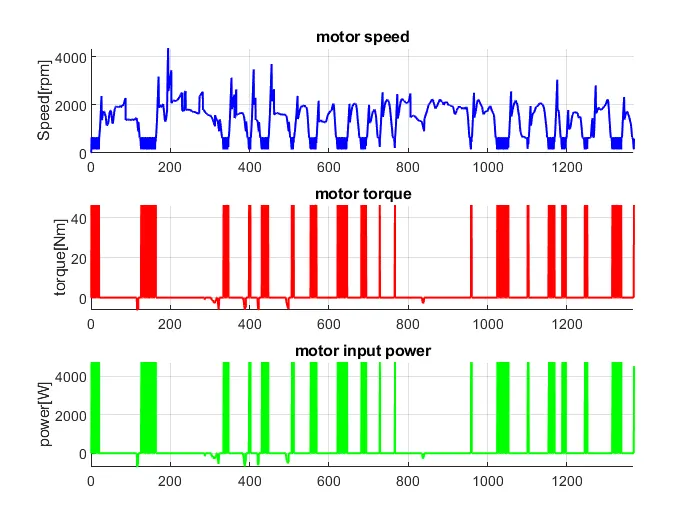
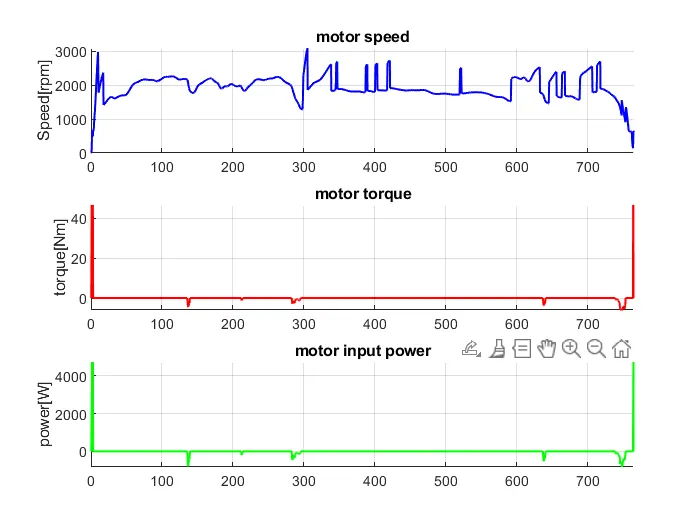
f. Plot motor speed, torque, motor input power using subplots.
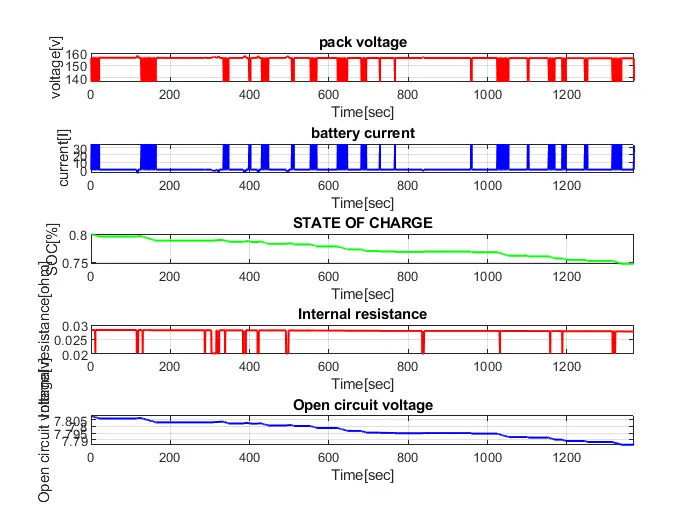
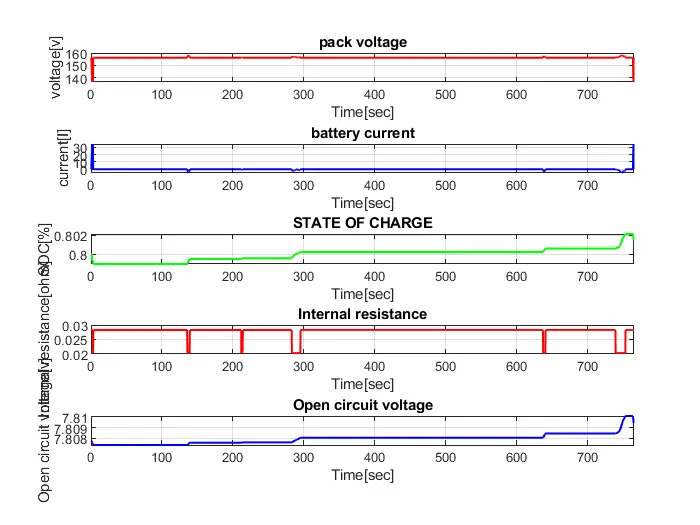
g. Plot pack voltage, current and SoC using subplots.
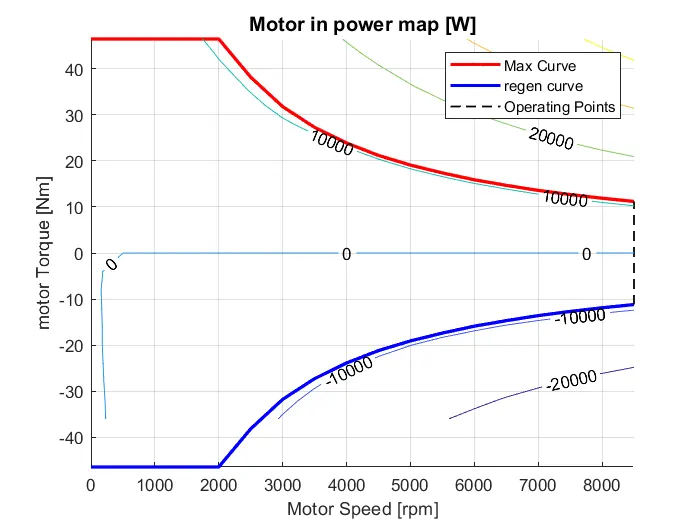
h. Plot the motor operating points on the motor input power map, with the motor max motoring and generating torque curves.
i. Write down appropriate brief comments on each of these plots, describing the vehicle behavior throughout the drive cycle.
j. Generate the plots for both drive cycles
OBJECTIVE:
To develop a forward energy-based fuel consumption model of a P1 hybrid vehicle using matlab and simulink to analyze data and generate plots.
THEORY:
A hybrid electric vehicle (HEV) is a type of hybrid vehicle that combines a conventional internal combustion engine (ICE) system with an electric propulsion system (hybrid vehicle drivetrain). The presence of the electric powertrain is intended to achieve either better fuel economy than a conventional vehicle or better performance. There is a variety of HEV types and the degree to which each function as an electric vehicle (EV) also varies. The most common form of HEV is the hybrid electric car, although hybrid electric trucks (pickups and tractors), buses, boats and aircraft also exist.
In this project, we will deal with the development of an hybrid vehicle with P1 architecture. In this type of architecture ,the electric machine is connected directly with the crankshaft of the internal combustion engine.
MODEL:
INITIAL MATLAB CODE:
- A matlab code “Project2_InitFile.m” was created to load the variable to the workspace. In this project,Honda Insight motor and battery are considered for integrating with a typical midsize car with a 1.9L engine and a 4-speed automatic transmission for the hybrid application. Data is taken from ADVISOR data base developed by NREL, USA. Transmission shift map and controller is taken from Matlab/Simulink example database.
- The model developed has the capability to simulate the vehicle on different drive cycles like UDDS, HWFET, FTP, NEDC, etc.
The CODE:
%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%

%% Skill-Lync -> Hybrid Drives Development

% Project 2 - P1 Hybrid Electric Vehicle Model


% Description:


%% Initialization File

% Initialization file for loading the variables for the Conventional vehicle simulation model


%% Vehicle Parameters

M = 1500;       % Vehicle weight [kg]

Cr = 0.015;     % Rolling resistance coefficient

Rw = 0.35;      % Rolling radius [m]

Cd = 0.33;      % Drag coefficient

Af = 2;         % Frontal area [m2]

rhoa = 1.225;   % Air density [kg/m3]

Vwind = 0;      % Wind velocity [kmph]

g = 9.81;       % Gravitational acceleration [m/s2]

theta = 0;      % Slope [deg]

myu_road_tire = 1; % Coefficient of friction between tire - road interface


%% Powertrain Parameters

FDR = 3.73;                         % Final Drive Ratio / Diff Ratio

DiffEff = 0.99;                     % Differential efficiency (assumed independent of operating conditions)


NumGear = 4;                        % Number of gears in transmission

TransGear = [1:NumGear];            % Transmission Gears

TransRatio = [3.06, 1.62, 1, 0.7];  % Corresponding Transmission ratios

TransEff = 0.90;                    % Transmission efficiency (assumed independent of operating conditions)


TC_SR = [0, .5, .6, .7, .8, .87, .92, .94, .96, .97, 1];   % Torque Converter Speed Ratio (Matlab default) -> TurbSpd/PumpSpd

TC_TR = [2.232, 1.5462, 1.4058, 1.2746, 1.1528, 1.0732, 1.0192, 1, 1, 1, 1];   % Torque Converter Torque Ratio (Matlab default) -> TurbTrq/PumpTrq

TC_Cf = 1e-4 * [.72558, .66322, .63463, .59042, .51331, .4144, .29287, .22444, .12186, .04386, 0]; % Torque Converter Capacity Factor (Matlab default) -> PumpTrq/PumpSpd^2 [Nm/rpm^2]


load Vehicle_Data/Engine_data_1_9L_Saturn_95kW

load Vehicle_Data/Trans_Shift_map

load Vehicle_Data/EM_Honda_Insight_10kW

load Vehicle_Data/ESS_NiMH6


ESS_init_soc = 0.8;

ESS_soc_max = 0.9;

ESS_soc_min = 0.6;


%% Driver Parameters

Kp = 10;                    % P gain for driver PI model

Ki = 1;                     % I gain for driver PI model

Drive_Cycle_Select = 1;     % Drive cycle selection


% Drive cycle values in m/s


if Drive_Cycle_Select == 1

    load DriveCycles/UDDS;


elseif Drive_Cycle_Select == 2

    load DriveCycles/HWFET;


elseif Drive_Cycle_Select == 3

    load DriveCycles/FTP;


elseif Drive_Cycle_Select == 4

    load DriveCycles/US06;


elseif Drive_Cycle_Select == 5

    load DriveCycles/NEDC;


elseif Drive_Cycle_Select == 6

    load DriveCycles/WLTP;


end


time_end = cyc_time(end);

vel_end = cyc_vel(end);
THE SIMULINK MODEL:
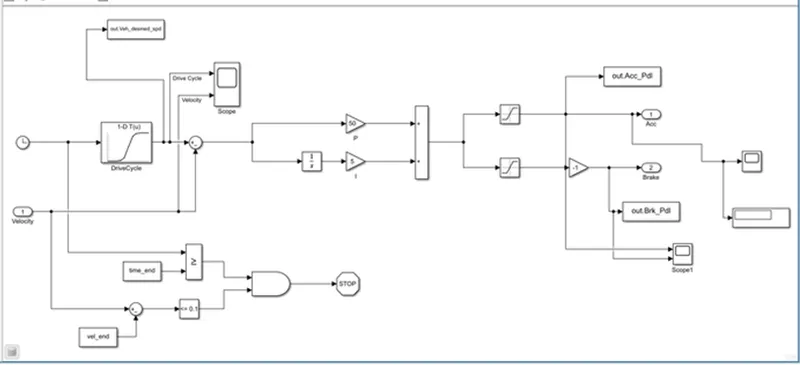
- It is modeled using a ‘Driver’ block, which is a basic PI controller that generates accelerator and brake pedal outputs to match the desired and actual vehicle speeds.
- This accelerator and brake pedaldata is generated using the drive cycle data in which is fed through look up table.
DRIVER BLOCK:
CONTROLLER BLOCK:
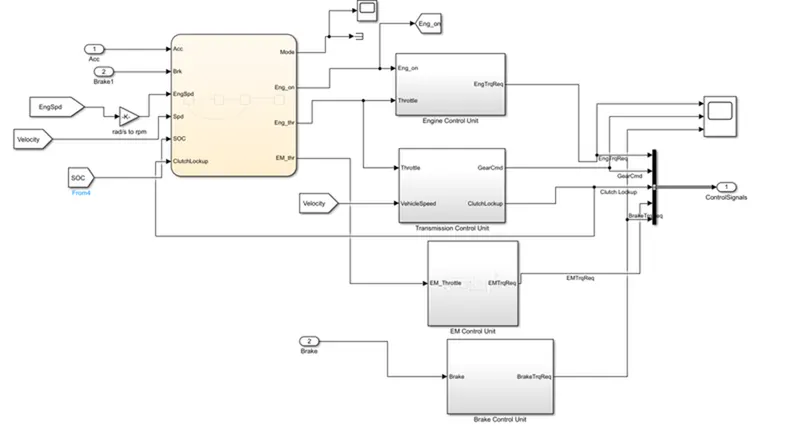
- The ‘Controller’ block is the brains of the vehicle, representing the electronic controls units. Based on the driver inputs, it generates desired engine torque, desired transmission gear and desired brake torque and EM torque and clutch lock by with the help of a supervisory controller .
POWERTRAIN:
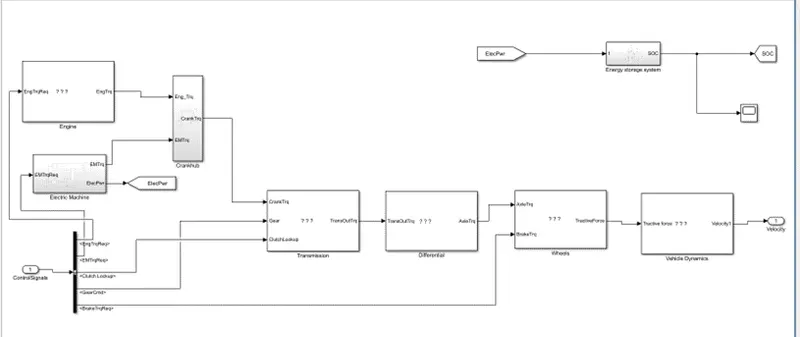
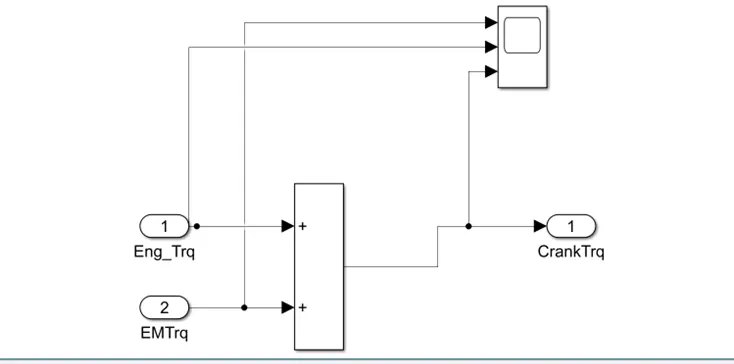
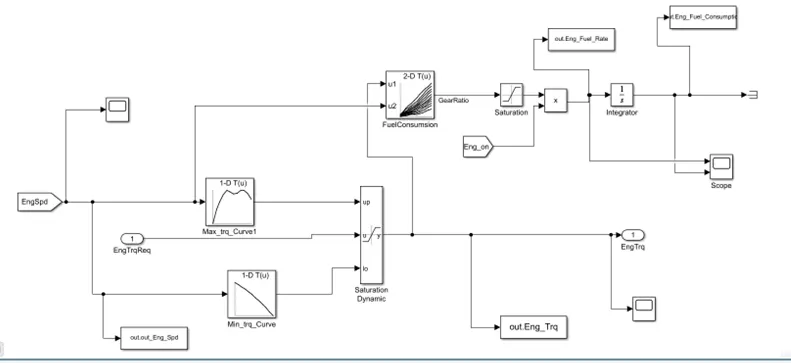
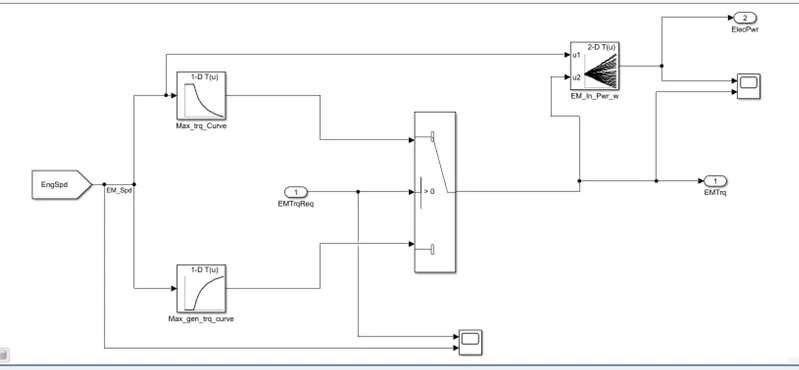
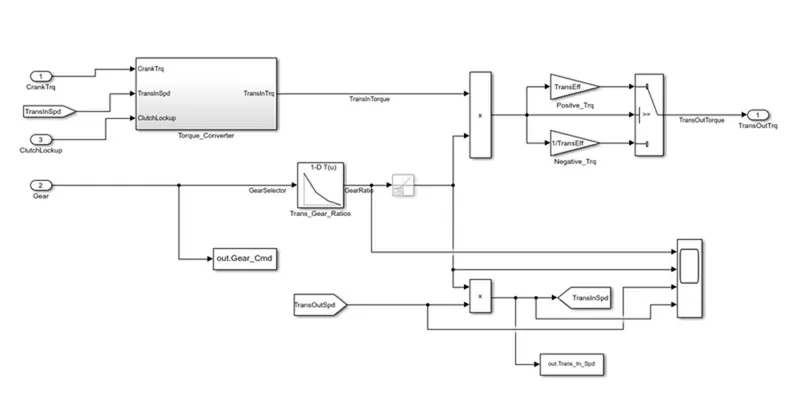
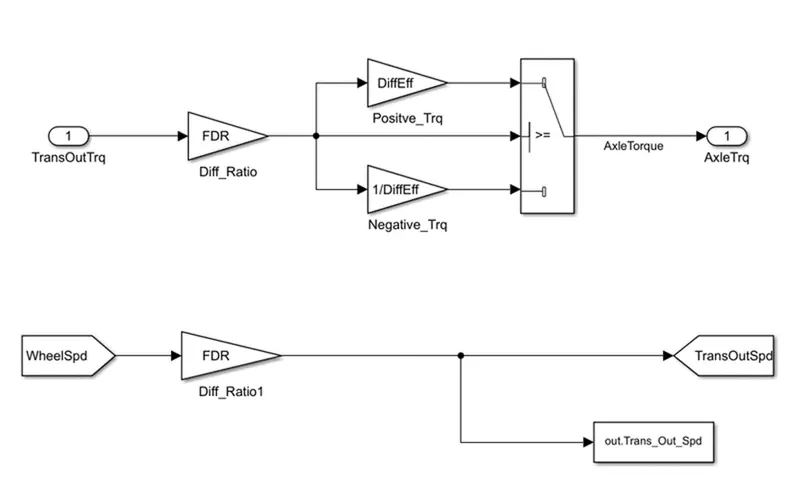
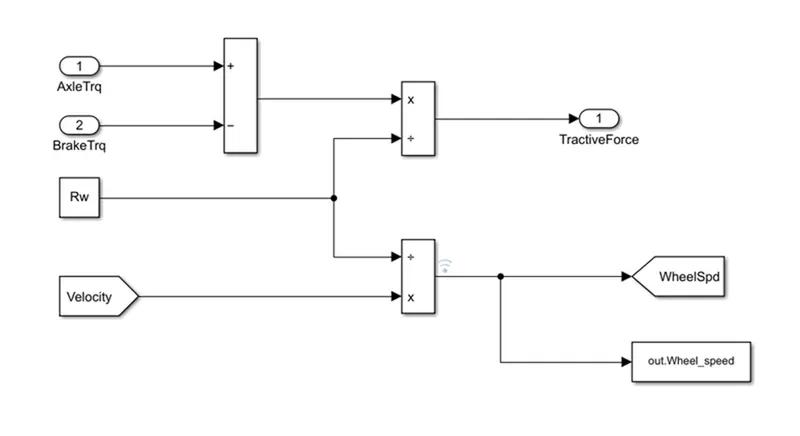
- The data inputs are fed to the ‘Powertrain’ block which represents the drivetrain of the vehicle. It consists of an ‘Engine’ and 'Electric Motor' connected via crank hub and to the ‘Automatic Transmission’ through a ‘Torque Converter’. The output of the transmission is connected to the ’Differential’, which powers the ‘Wheels’, that provides the tractive force for vehicle acceleration. The longitudinal dynamics of the vehicle along with the road load is represented in the ‘Vehicle Dynamics’ block. The solver selected is ode3 with a fixed step size of 0.01 sec.
Crank Hub:
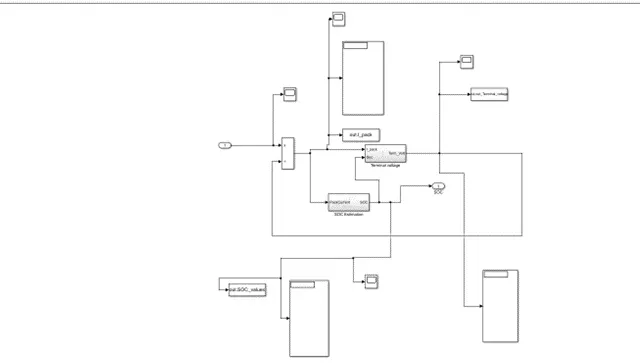
ESS :
THE ENGINE BLOCK:
ELECTRIC MOTOR BLOCK:
THE TRANSMISSION BLOCK:
THE DIFFERENTIAL BLOCK:
THE WHEELS BLOCK:
THE VEHICLE DYNAMICS BLOCK:
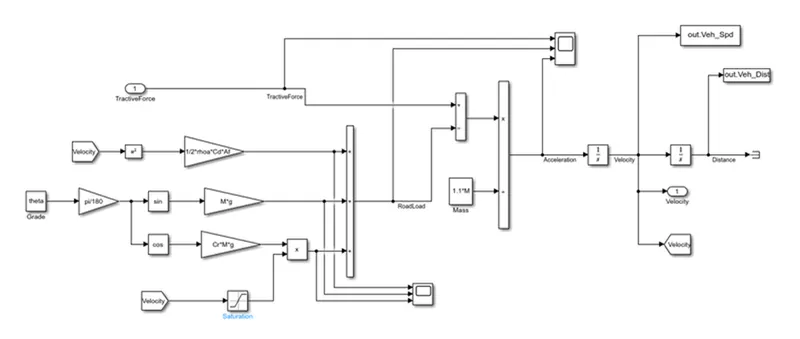
- The equation used here is:
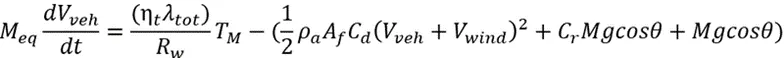
POST PROCESSING:
- The Data from the SIMULINK model was transferred to matlab workspace using 'To Workspace' block
- A post processing MATLAB code was used to generate the necessary plots.
THE CODE:
%% Hybrid Drives Development
% Project 2 - P1 Hybrid Vehicle Model
% By - Nikhil

%% Post-Processing File
%  File for post-processing the P1 Hybrid vehicle simulation model data

%% Renaming variables
Time = out.tout;
Acc_Pdl = out.Acc_Pdl;          % Accelerator pedal [%]
Brk_Pdl = out.Brk_Pdl;          % Brake pedal [%]
Gear_Cmd = out.Gear_Cmd;        % Transmission gear
Trans_In_Spd = out.Trans_In_Spd*30/pi;  % Transmission input speed [rpm]
Trans_Out_Spd = out.Trans_Out_Spd*30/pi;% Transmission output speed [rpm]
Eng_Trq = out.Eng_Trq;          % Engine brake torque [Nm]
Eng_Spd = out.Eng_Spd*30/pi;    % Engine speed [rpm]
Eng_Fuel_Consump = out.Eng_Fuel_Consumption;    % Engine fuel consumption [g]
Eng_Fuel_Rate = out.Eng_Fuel_Rate;   %engine fuel rate
Veh_Dist = out.Veh_Dist/1000;   % Distance traveled by vehicle [km]
Veh_Spd = out.Veh_Spd*18/5;     % Vehicle speed [kmph]
Whl_Spd = out.Whl_Spd*30/pi;     % wheel speed[RPM]
Desired_spd = out.Desired_Velo*18/5 ;  %desired speed [KMPH]
EM_Spd = out.EM_Spd*30/pi;         % E motor speed[rpm]
EM_Trq = out.EM_Trq;               % E motor torque[Nm]
EM_Pwr = out.EM_Pwr;               % E motor input power[W]
V_batt = out.V_battery;              % battery pack voltage [V]
I_batt = out.I_battery;              % battery pack current [I]
SOC = out.SOC;                     % STATE OF CHARGE [%]
RS = out.RS;                       % internal resistance
VOC = out.VOC;                     % open circuit voltage

%% Data Analysis
Eng_Pwr = Eng_Spd.*pi/30.*Eng_Trq/1000;   % Engine brake power [kW]
rho_petrol = 0.7197;                    % Density of petrol [kg/L]
kmpl = Veh_Dist(end)/(Eng_Fuel_Consump(end)/1000/rho_petrol);    % Fuel economy [kmpl];


% display fuel Economy of the cycle
formatspec = 'fuel economy is %2.2f kmpl';
fprintf(formatspec,kmpl);


%% Plotting vehicle characteristics time trace

% ploting transmission input,transmission output and wheel speed
figure(1)
hold on
grid on
plot(Time,Trans_In_Spd,'LineWidth',1,'Color','black');
plot(Time,Trans_Out_Spd,'LineWidth',1,'Color','red');
plot(Time,Whl_Spd,'LineWidth',1,'Color','blue');
xlabel('Time[s]')
ylabel('speed[rpm]')
xlim([0,Time(end)]);
legend('trans input','trans Output','wheel speed');
title('transmission input transmission output and wheel speed')

% plotting engine torque,engine power,fuel rate ,fuel consumption
figure(2)
subplot(4,1,1)
hold on
grid on
plot(Time,Eng_Trq,'LineWidth',1,'Color','black');
ylabel('torque[NM]')
xlim([0,Time(end)]);
title('Engine Torque')

subplot(4,1,2)
hold on
grid on
plot(Time,Eng_Pwr,'LineWidth',1,'Color','black');
ylabel('power[KW]')
xlim([0,Time(end)]);
title('Engine Power')

subplot(4,1,3)
hold on
grid on
plot(Time,Eng_Fuel_Rate,'LineWidth',1,'Color','black');
xlim([0,Time(end)]);
xlabel('Time[s]');
ylabel('Engine fuel rate');
title('Engine fuel rate')

subplot(4,1,4)
hold on
grid on
plot(Time,Eng_Fuel_Consump,'LineWidth',1,'Color','black');
xlim([0,Time(end)]);
xlabel('Time[s]');
ylabel('Engine fuel consumption[g]');
title('Engine Fuel Consumption')

% plotting accelerator and brake pedal gear command vehicle desired and actual speed ,vehicle distance
figure(3)

subplot(4,1,1)
hold on
grid on
plot(Time, Acc_Pdl, 'linewidth', 1, 'Color', 'black');
plot(Time, Brk_Pdl, 'linewidth', 1, 'Color', 'red');
ylabel('Pedal [%]')
xlim([0, Time(end)]);
legend('Accel','Brake');
title('Acceleration and brake pedal inputs')

subplot(4,1,2)
hold on
grid on
plot(Time, Gear_Cmd, 'linewidth', 1, 'Color', 'black');
xlim([0, Time(end)]);
xlabel('Time [s]');
ylabel('Gear');
title('gear command')

subplot(4,1,3)
hold on
grid on
plot(Time, Veh_Spd, 'linewidth', 1, 'Color', 'black');
plot(Time, Desired_spd, 'linewidth', 1, 'Color', 'red');
ylabel('Speed [kmph]')
xlim([0, Time(end)]);
legend('actual speed','desired speed');
title('vehicle actual and desired speed')

subplot(4,1,4)
hold on
grid on
plot(Time, Veh_Dist, 'linewidth', 1, 'Color', 'black');
xlim([0, Time(end)]);
xlabel('Time [s]');
ylabel('distance[km]');
title('vehicle distance')

% plotting drive cycle
figure(4)
hold on
grid on
plot(cyc_time,cyc_vel,'LineWidth',1,'Color','black')
xlabel('time[s]')
ylabel('velocity[mph]')
title('drive cycle')

% test result
Avg_speed = sum(Veh_Spd)/length(Veh_Spd);
Max_speed = maxk(Veh_Spd,1);
table (Avg_speed,Max_speed,kmpl,'variablenames',{'average speed[kmph]','maximum speed[kmph]','fuel economy[kmpl]'})

%% Plotting engine operating points on engine fuel map
figure('Name','Engine Operating Points');
hold on
grid on
title('Engine Operating Points','fontsize',12);
plot(Eng_map_spd*30/pi,Eng_max_trq,'linewidth',2,'color','r');
p2=line([Eng_map_spd(end)*30/pi Eng_map_spd(end)*30/pi],[0 Eng_max_trq(end)]);
set(p2,'linewidth',1,'linestyle','--','color','k');
p3=line([Eng_map_spd(1)*30/pi Eng_map_spd(1)*30/pi],[0 Eng_max_trq(1)]);
set(p3,'linewidth',1,'linestyle','--','color','k');
[c,h] = contour(Eng_map_spd'*30/pi,Eng_map_trq,Eng_fuel_map');
clabel(c,h);
xlabel('Engine Speed [rpm]');
ylabel('Engine Torque [Nm]');
title('Engine Fuel Consumption Map [g/s]');
legend({'Max Curve','Operating Points'});
axis([Eng_map_spd(1)*30/pi Eng_map_spd(end)*30/pi 0 Eng_map_trq(end)]);

%% Electric Motor
% plotting motor speed ,motor torque,motor input power

figure(6)
subplot(3,1,1)
hold on
grid on
plot(Time,EM_Spd,'LineWidth',1,'Color','b');
ylabel('Speed[rpm]')
xlim([0,Time(end)]);
title('motor speed')

subplot(3,1,2)
hold on
grid on
plot(Time,EM_Trq,'LineWidth',1,'Color','r');
ylabel('torque[Nm]')
xlim([0,Time(end)]);
title('motor torque')

subplot(3,1,3)
hold on
grid on
plot(Time,EM_Pwr,'LineWidth',1,'Color','g');
ylabel('power[W]')
xlim([0,Time(end)]);
title('motor input power')

%% BATTERY
% plotting pack current,voltage,soc,internal resistance,open circuit
% voltage

figure(7)

subplot(5,1,1)
plot(Time,V_batt,'LineWidth',1,'Color','r');
xlabel('Time[sec]');
ylabel('voltage[v]');
title('pack voltage')
xlim([0,Time(end)]);
grid on

subplot(5,1,2)
plot(Time,I_batt,'LineWidth',1,'Color','b');
xlabel('Time[sec]');
ylabel('current[I]');
title('battery current')
xlim([0,Time(end)]);
grid on

subplot(5,1,3)
plot(Time,SOC,'LineWidth',1,'Color','g');
xlabel('Time[sec]');
ylabel('SOC[%]');
title('STATE OF CHARGE')
xlim([0,Time(end)]);
grid on

subplot(5,1,4)
plot(Time,RS,'LineWidth',1,'Color','r');
xlabel('Time[sec]');
ylabel('Internal resistance[ohm]');
title('Internal resistance')
xlim([0,Time(end)]);
grid on

subplot(5,1,5)
plot(Time,VOC,'LineWidth',1,'Color','b');
xlabel('Time[sec]');
ylabel('Open circuit voltage[v]');
title('Open circuit voltage')
xlim([0,Time(end)]);
grid on

%% Plotting engine operating points on engine fuel map
figure('Name','Electric motor Operating Points');
hold on
grid on
title('Electric motor Operating Points','fontsize',12);
p1=plot(EM_map_spd*30/pi,EM_max_trq,'linewidth',2,'color','r');
p4=plot(EM_map_spd*30/pi,EM_max_gen_trq,'LineWidth',2,'Color','b');
p2=line([EM_map_spd(end)*30/pi EM_map_spd(end)*30/pi],[EM_max_gen_trq(end) EM_max_trq(end)]);
set(p2,'linewidth',1,'linestyle','--','color','k');
p3=line([EM_map_spd(1)*30/pi EM_map_spd(1)*30/pi],[EM_max_gen_trq(1) EM_max_gen_trq(1)]);
set(p3,'linewidth',1,'linestyle','--','color','k');
[c,h] = contour(EM_map_spd'*30/pi,EM_map_trq,EM_inpwr_map');
clabel(c,h);
xlabel('Motor Speed [rpm]');
ylabel('motor Torque [Nm]');
title('Motor in power map [W]');
legend([p1 p4 p3],{'Max Curve','regen curve','Operating Points'});
xlim([EM_map_spd(1)*30/pi EM_map_spd(end)*30/pi]);
ylim([EM_max_gen_trq(1) EM_max_trq(1)]);
THE PLOTS:
Post Processing Results:
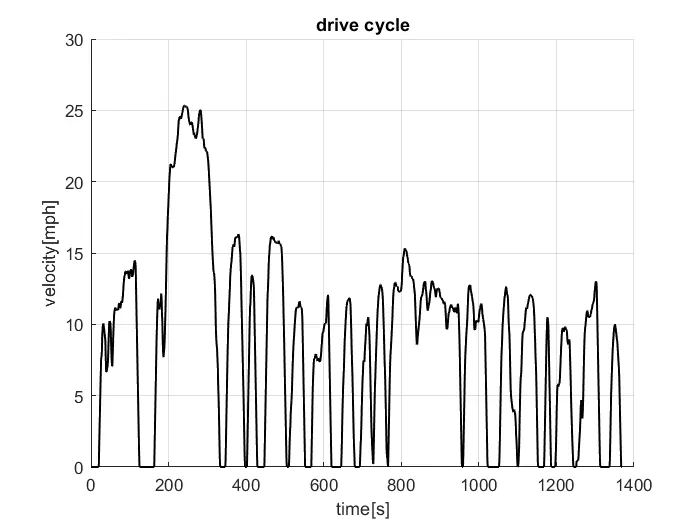
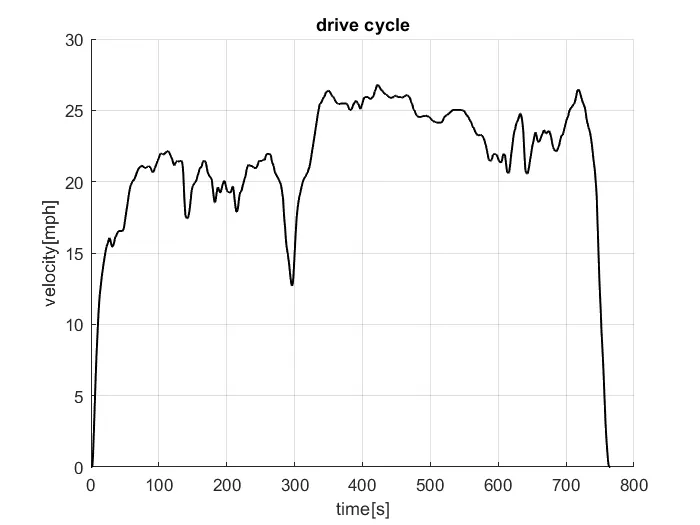
1] drive cycle:
a] UDDS:
b] HWFET:
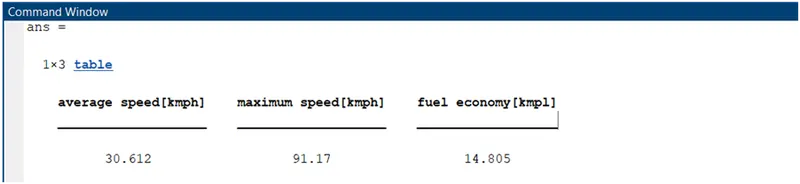
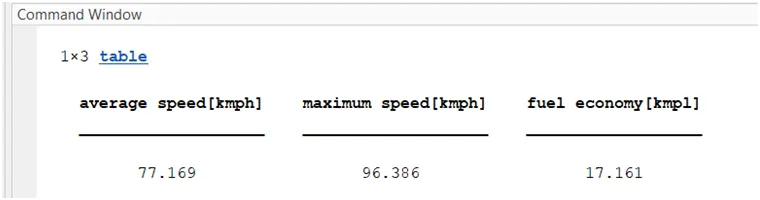
2] fuel economy numbers(KMPL):
a] UDDS:
b] HWFET:
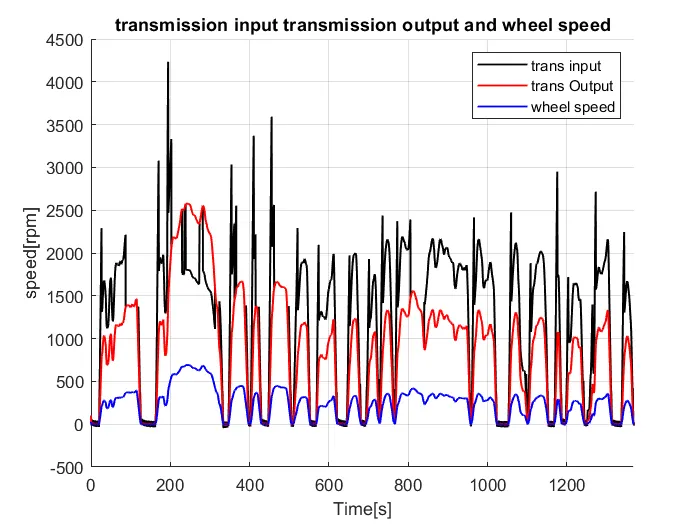
3] the time trace for engine ,transmission input,transmission output,wheel speed:
a] UDDS:
b] HWFET:
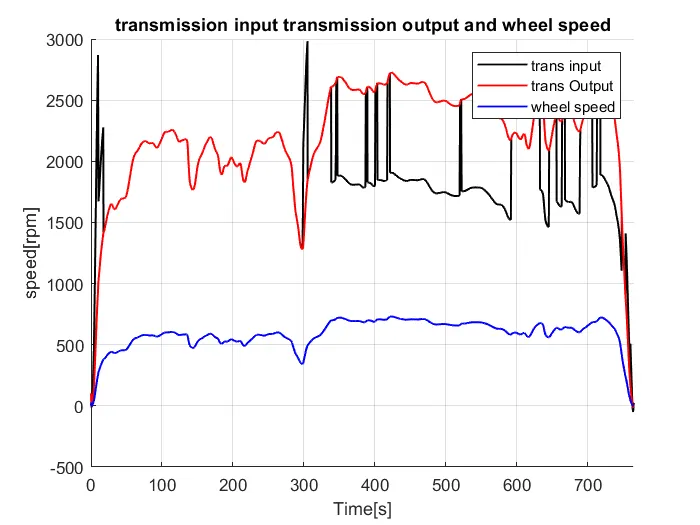
- much of the fluctuating input speed is facilitated by the torque convertor and the transmission input speed fluctuates according to the engine torque required to achive the drive cycle.
- wheel speed and transmision output speed vary according to gear and differential ratio.
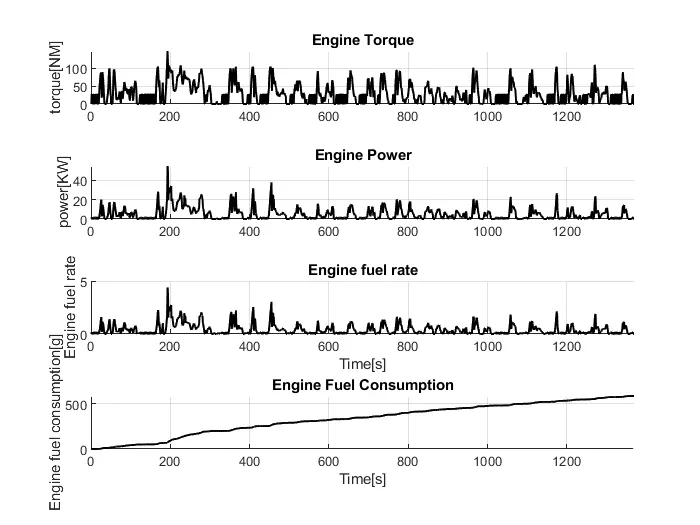
4] engine torque,engine power,fuel rate,fuel consumption:
a] UDDS:
b] HWFET:
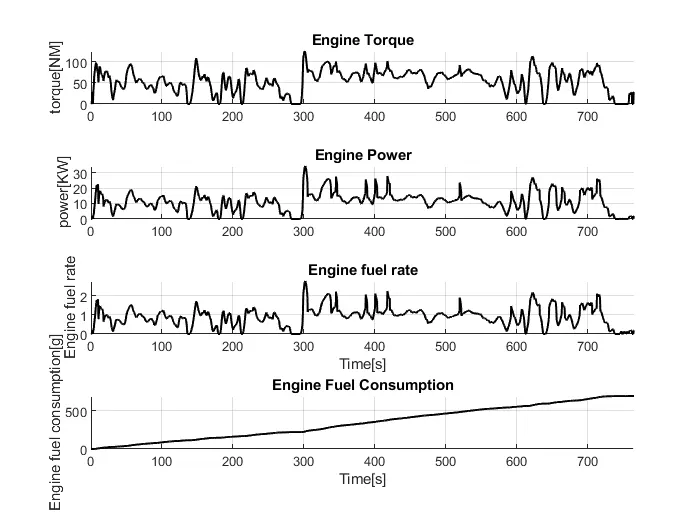
- the torque requirements of the drive cycle are different so the fuel flow rate varies and fuel consumption is calculated.
- the HWFET drive cycle has higher power and torque requirement and less negative torque and power
5] accelerator and brake pedal,gear command,vehicle desired and actual speed,vehicle distance:
a] UDDS:
b] HWFET:
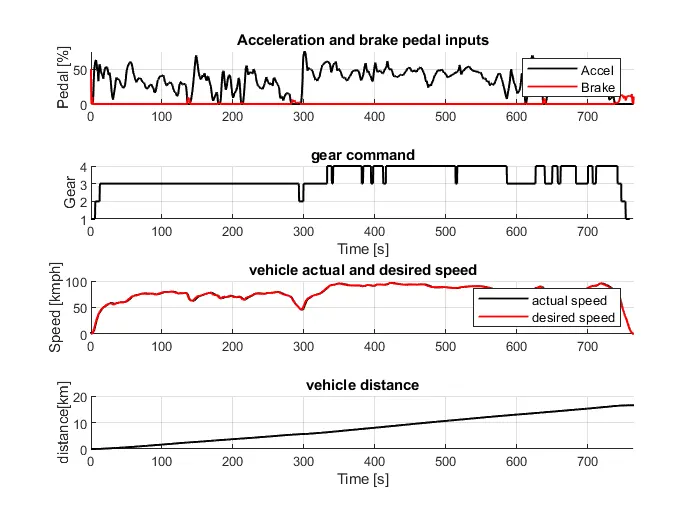
- acceleration and brake pedals are used more bcoz the drive cycle is not very smooth and the gear has to be shifted frequently.
- brake requirement are lower more acceleretor pedal are applied on the highway drive cycle and gear shift often occurs bcoz the drive cycle is smoother.
- acceleration and brake pedal the gear command of the transmission control unit the required speed of the vehicle the actual speed and the actual vehicle distance are plotted.
6] the engine operating points on the engine fuel map:
a] UDDS:
b] HWFET:
- the engine operating points are plotted on the fuel map and the operating points is under the maximum torque curve.
7] the motor speed,motor torque,motor input power:
a] UDDS:
b] HWFET:
8] the pack voltage ,current,SOC, VOC,internal resistance:
a] UDDS:
b] HWFET:
9] the motor operating points on the motor inputs power map,with the motor max motoring and generating torque curves:
CONCLUSION:
- Therefor the forward energy based fuel consumption model of a P1 Hybrid vehicle has been successfully simulated using MATLAB and SIMULINK.
- Analysis and understand vehicle operating points based on engine speed,torque,transmission speed,pedal position,gear,distance,velocity, acceleration,battery,voltage,current,SOC and pedal position.
- Post process calculation were performed and the required graphs were successfully plotted.
- Succesfully calculated vehicle fuel efficiency number[kmpl] for the given city cycle [UDDS] and highway cycle[HWFET].and also compared to the conventional vehicle.
- The Forward energy-based fuel consumption model of a P1 Hybrid ELectric vehicle was developed using MATLAB and SIMULINK and the plots were obtained for UDDS and HWFET cycles.