Project 2
AIM: The main goal of this project is to understand the functionality of a P1 hybrid and be able to model it.
Objective:
As discussed in Lecture 11, Project 2 deals with the development of a forward energy-based fuel consumption model of a P1 hybrid vehicle. This model is based on the conventional vehicle model from Project 1.
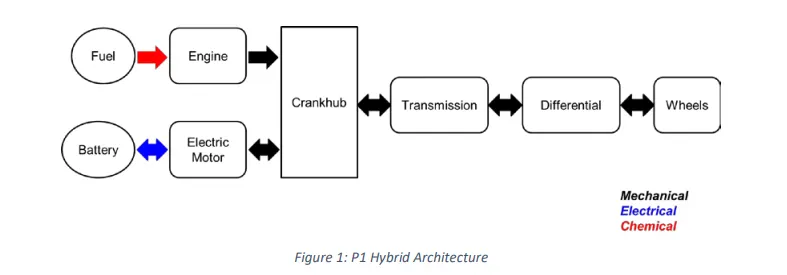
The main goal of this project is to understand the functionality of a P1 hybrid and be able to model it.
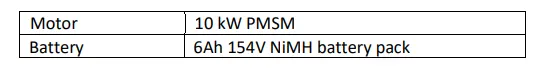
Honda Insight motor and battery are considered for this project. Data is taken from ADVISOR data base developed by NREL, USA. Data provided in the project files.
“Project2_InitFile.m” is a Matlab script used to load all the variables required for running the Simulink model and for post-processing. The drive cycle selection is also done here. Before running the Simulink vehicle model, run this initialization script.
Task:
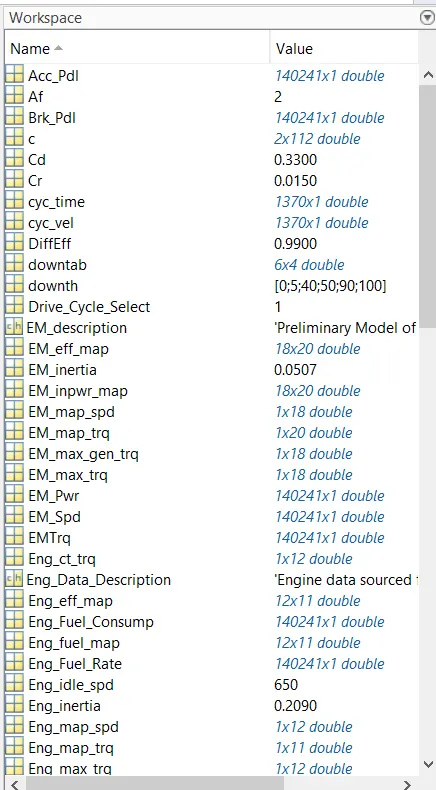
The task of this project is to quantify the improvement in fuel economy numbers for the hybrid vehicle (kmpl), compared to the conventional vehicle, on the urban cycle (UDDS) and highway cycle (HWFET). Also, to analyze and understand the vehicle operating points in terms of engine and motor speed, torque, transmission speeds, pedal positions, gear, distance traveled, battery voltage, current, SoC etc.
To do that, the following steps need to be followed:
1) Load the Project2 folder as the Current Folder in Matlab.
2) Run the “Project2_InitFile.m” Matlab script.
3) Copy the Conventional vehicle Simulink model created for Project 1 in this folder. Figure 1: P1 Hybrid ArchitectureHybrid Drives Development
4) Modify this model into a hybrid vehicle model. The lecture presentations can be used as reference. Battery and Supervisory controller models developed in the assignments can be reused.
5) Add additional ‘To Workspace’ blocks for transferring the desired Simulink vehicle data into the Matlab workspace.
6) Simulate the hybrid model on the desired drive cycles.
7) Write a project report that contains the following:
a. Tabulate the fuel economy numbers (kmpl) for UDDS and HWFET cycle. Compare these numbers with the baseline numbers for conventional vehicle model from Project 1.
b. Plot the time trace for engine, transmission input, transmission output and wheel speed on one plot.
c. Plot engine torque, engine power, fuel rate and fuel consumption using subplots.
d. Plot accelerator and brake pedal, gear command, vehicle desired and actual speed, vehicle distance using subplots.
e. Plot the engine operating points on the engine fuel map.
f. Plot motor speed, torque, motor input power using subplots.
g. Plot pack voltage, current and SoC using subplots.
h. Plot the motor operating points on the motor input power map, with the motor max motoring and generating torque curves.
i. Write down appropriate brief comments on each of these plots, describing the vehicle behavior throughout the drive cycle.
j. Generate the plots for both drive cycles
Answer:
Initial matlab file for hybrid vehicle:
For UDDS Cycle:
%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%
%% Skill-Lync -> Hybrid Drives Development
% Project 2 - hybrid Vehicle Model
% By - Ullekh Gambhira

% Description:

%% Initialization File
% Initialization file for loading the variables for the Conventional vehicle simulation model

%% Vehicle Parameters
M = 1500;       % Vehicle weight [kg]
Cr = 0.015;     % Rolling resistance coefficient
Rw = 0.35;      % Rolling radius [m]
Cd = 0.33;      % Drag coefficient
Af = 2;         % Frontal area [m2]
rhoa = 1.225;   % Air density [kg/m3]
Vwind = 0;      % Wind velocity [kmph]
g = 9.81;       % Gravitational acceleration [m/s2]
theta = 0;      % Slope [deg]
myu_road_tire = 1; % Coefficient of friction between tire - road interface

%% Powertrain Parameters
FDR = 3.73;                         % Final Drive Ratio / Diff Ratio
DiffEff = 0.99;                     % Differential efficiency (assumed independent of operating conditions)

NumGear = 4;                        % Number of gears in transmission
TransGear = [1:NumGear];            % Transmission Gears
TransRatio = [3.06, 1.62, 1, 0.7];  % Corresponding Transmission ratios
TransEff = 0.90;                    % Transmission efficiency (assumed independent of operating conditions)

TC_SR = [0, .5, .6, .7, .8, .87, .92, .94, .96, .97, 1];   % Torque Converter Speed Ratio (Matlab default) -> TurbSpd/PumpSpd
TC_TR = [2.232, 1.5462, 1.4058, 1.2746, 1.1528, 1.0732, 1.0192, 1, 1, 1, 1];   % Torque Converter Torque Ratio (Matlab default) -> TurbTrq/PumpTrq
TC_Cf = 1e-4 * [.72558, .66322, .63463, .59042, .51331, .4144, .29287, .22444, .12186, .04386, 0]; % Torque Converter Capacity Factor (Matlab default) -> PumpTrq/PumpSpd^2 [Nm/rpm^2]

load Vehicle_Data/Engine_data_1_9L_Saturn_95kW
load Vehicle_Data/Trans_Shift_map
load Vehicle_Data/EM_Honda_Insight_10kW
load Vehicle_Data/ESS_NiMH6


ESS_init_soc = 0.8;
ESS_soc_max = 0.9;
ESS_soc_min = 0.6;


%% Driver Parameters
Kp = 10;                    % P gain for driver PI model
Ki = 1;                     % I gain for driver PI model
Drive_Cycle_Select = 1;     % Drive cycle selection

% Drive cycle values in m/s

if Drive_Cycle_Select == 1
    load DriveCycles/UDDS;

elseif Drive_Cycle_Select == 2
    load DriveCycles/HWFET;

elseif Drive_Cycle_Select == 3
    load DriveCycles/FTP;

elseif Drive_Cycle_Select == 4
    load DriveCycles/US06;

elseif Drive_Cycle_Select == 5
    load DriveCycles/NEDC;

elseif Drive_Cycle_Select == 6
    load DriveCycles/WLTP;

end

time_end = cyc_time(end);
vel_end = cyc_vel(end);
For HWFET Cycle:
%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%
%% Skill-Lync -> Hybrid Drives Development
% Project 2 - hybrid Vehicle Model
% By - Ullekh Gambhira

% Description:

%% Initialization File
% Initialization file for loading the variables for the Conventional vehicle simulation model

%% Vehicle Parameters
M = 1500;       % Vehicle weight [kg]
Cr = 0.015;     % Rolling resistance coefficient
Rw = 0.35;      % Rolling radius [m]
Cd = 0.33;      % Drag coefficient
Af = 2;         % Frontal area [m2]
rhoa = 1.225;   % Air density [kg/m3]
Vwind = 0;      % Wind velocity [kmph]
g = 9.81;       % Gravitational acceleration [m/s2]
theta = 0;      % Slope [deg]
myu_road_tire = 1; % Coefficient of friction between tire - road interface

%% Powertrain Parameters
FDR = 3.73;                         % Final Drive Ratio / Diff Ratio
DiffEff = 0.99;                     % Differential efficiency (assumed independent of operating conditions)

NumGear = 4;                        % Number of gears in transmission
TransGear = [1:NumGear];            % Transmission Gears
TransRatio = [3.06, 1.62, 1, 0.7];  % Corresponding Transmission ratios
TransEff = 0.90;                    % Transmission efficiency (assumed independent of operating conditions)

TC_SR = [0, .5, .6, .7, .8, .87, .92, .94, .96, .97, 1];   % Torque Converter Speed Ratio (Matlab default) -> TurbSpd/PumpSpd
TC_TR = [2.232, 1.5462, 1.4058, 1.2746, 1.1528, 1.0732, 1.0192, 1, 1, 1, 1];   % Torque Converter Torque Ratio (Matlab default) -> TurbTrq/PumpTrq
TC_Cf = 1e-4 * [.72558, .66322, .63463, .59042, .51331, .4144, .29287, .22444, .12186, .04386, 0]; % Torque Converter Capacity Factor (Matlab default) -> PumpTrq/PumpSpd^2 [Nm/rpm^2]

load Vehicle_Data/Engine_data_1_9L_Saturn_95kW
load Vehicle_Data/Trans_Shift_map
load Vehicle_Data/EM_Honda_Insight_10kW
load Vehicle_Data/ESS_NiMH6


ESS_init_soc = 0.8;
ESS_soc_max = 0.9;
ESS_soc_min = 0.6;


%% Driver Parameters
Kp = 10;                    % P gain for driver PI model
Ki = 1;                     % I gain for driver PI model
Drive_Cycle_Select = 2;     % Drive cycle selection

% Drive cycle values in m/s

if Drive_Cycle_Select == 1
    load DriveCycles/UDDS;

elseif Drive_Cycle_Select == 2
    load DriveCycles/HWFET;

elseif Drive_Cycle_Select == 3
    load DriveCycles/FTP;

elseif Drive_Cycle_Select == 4
    load DriveCycles/US06;

elseif Drive_Cycle_Select == 5
    load DriveCycles/NEDC;

elseif Drive_Cycle_Select == 6
    load DriveCycles/WLTP;

end

time_end = cyc_time(end);
vel_end = cyc_vel(end);
Simulink model :
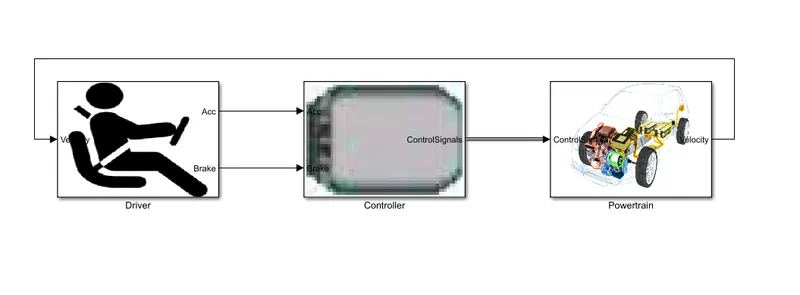
DRIVER MODEL:
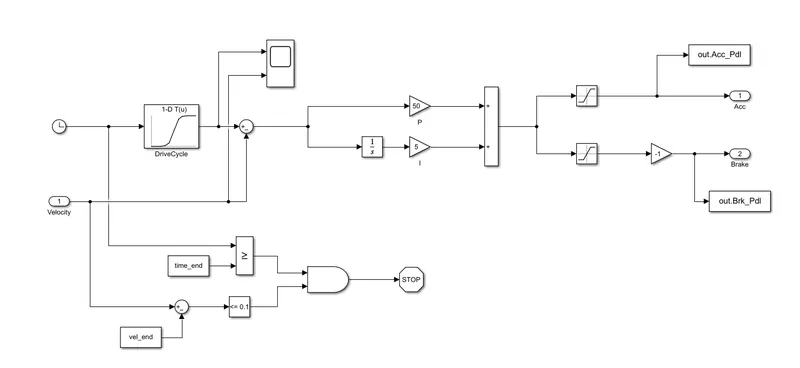
- Basically here is the driver model where driver gives the command as per the desired drivability.
- Here we use simle pi controller where we give accelerator and brake padel as output.
CONTROLLER MODEL:
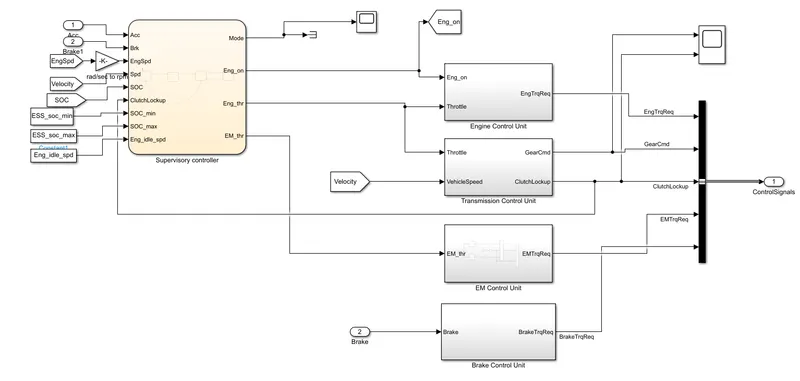
Supervisory controller:
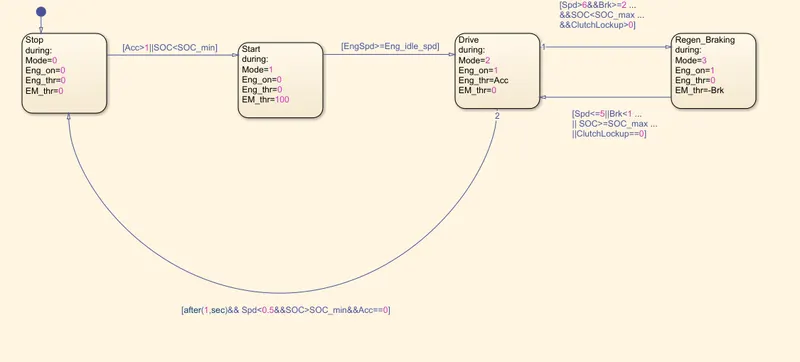
- Here we are selecting the modes of operation
Engine control unit:
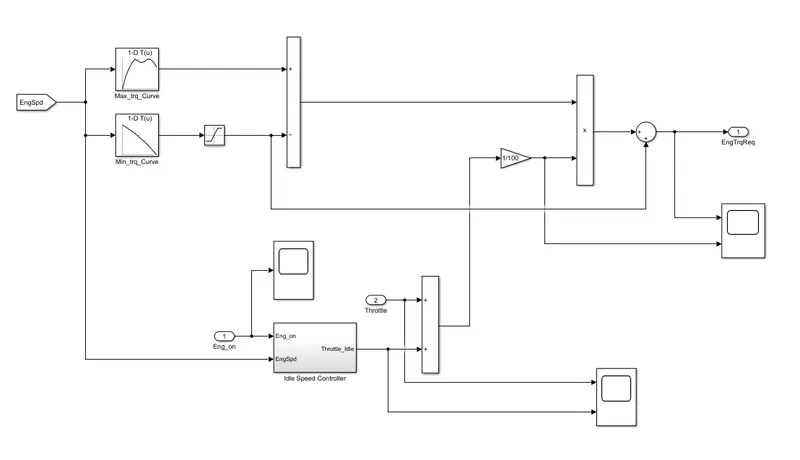
- Engine Control unit has used to control the engine torque require and it send it to the control unit
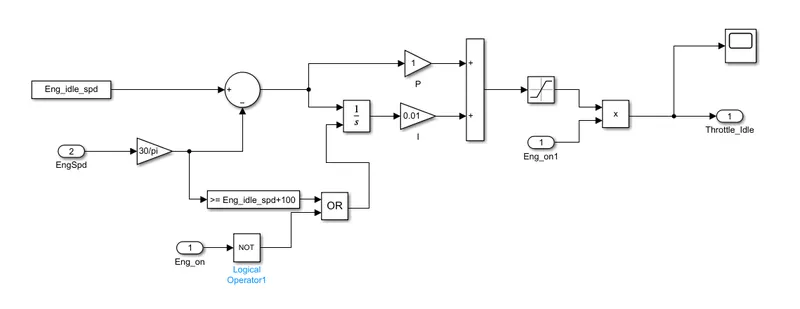
Idle speed controller:
Transmission control unit:
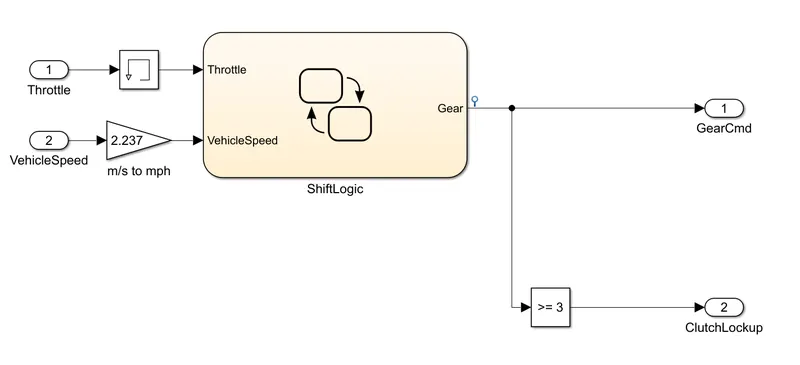
- Here is the automatic gear shift logic as per the throttle and vehicle speed.
- Also here is clutch lockup with the condition of >=3,from gear 3 and upward it is lockedup
Electric motor control unit:
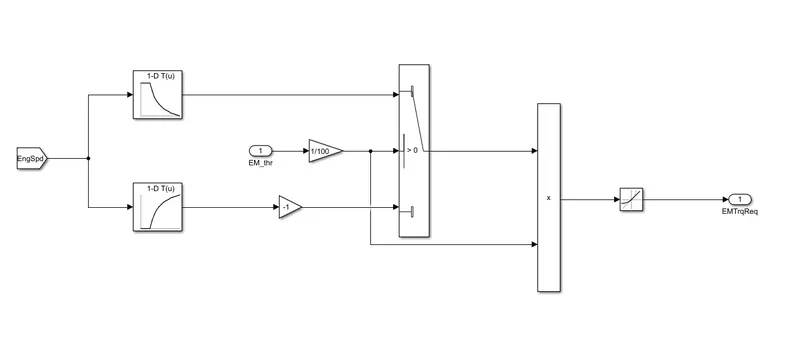
- Simply it will control when to start the motor and when to stop as per the requirment
Brake control unit:
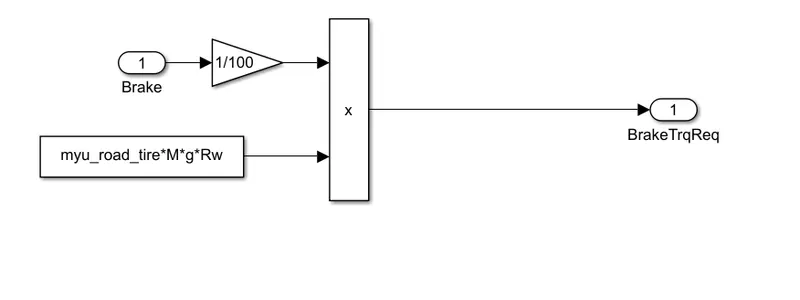
POWERTRAIN MODEL:
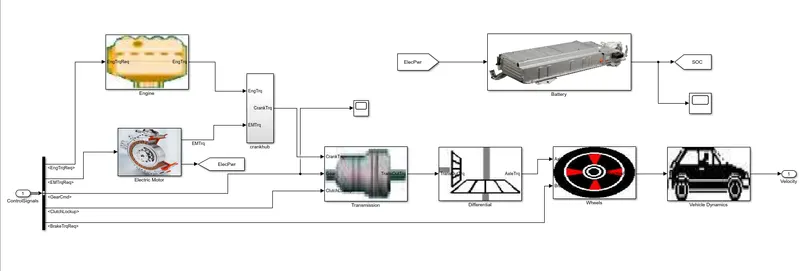
ENGINE MODEL: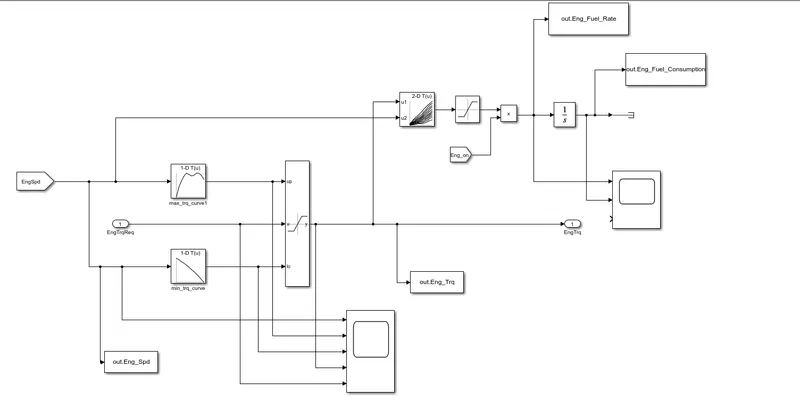
- engine is taking the engine speed as input and output is engine torque
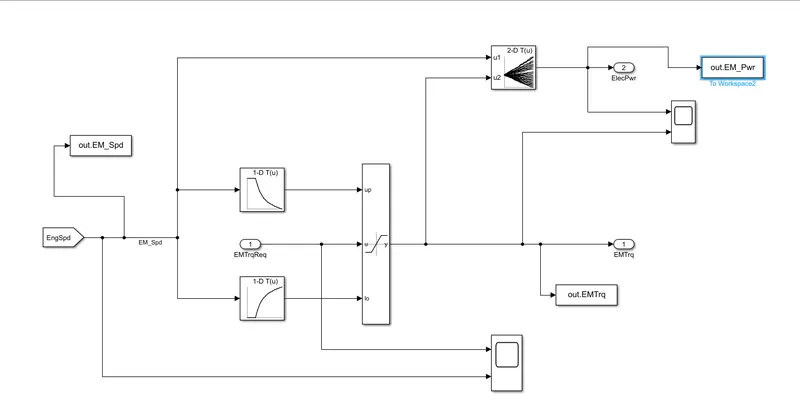
Electric motor model:
Crank hub:
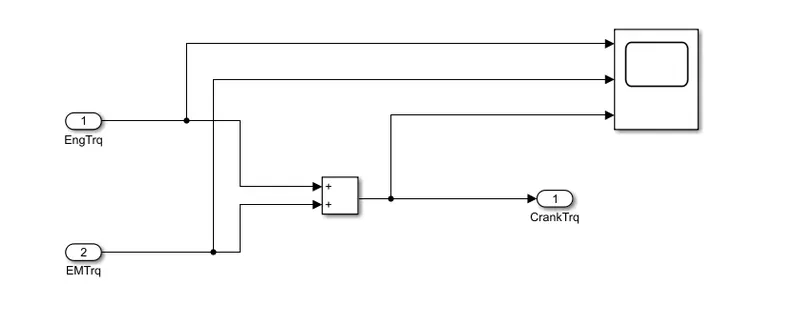
- The electric motor torque and the engine torque here combined and give the crank torque to the transmission.
TRANSMISSION MODEL:
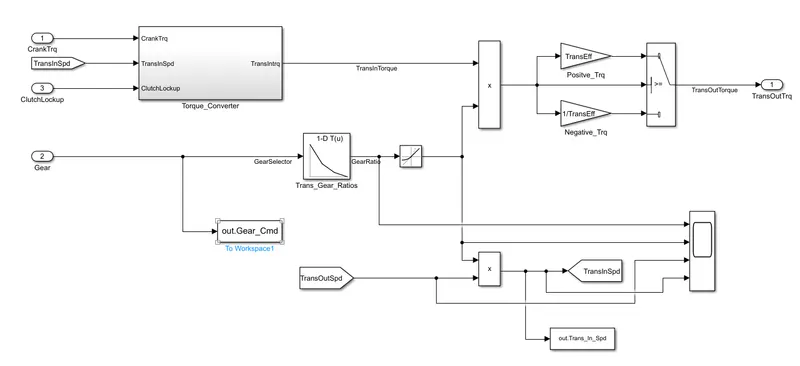
TORQUE CONVERTER: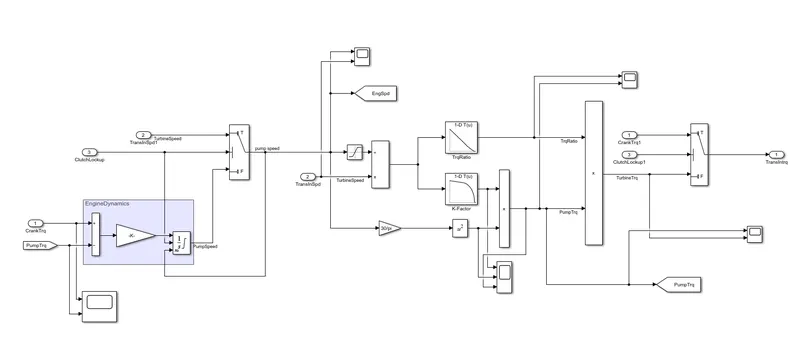
DIFFERENTIAL MODEL:
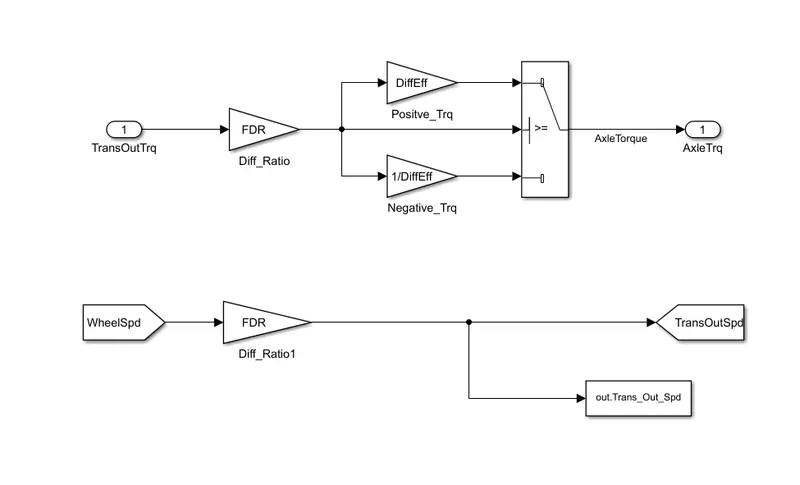
BATTERY MODEL: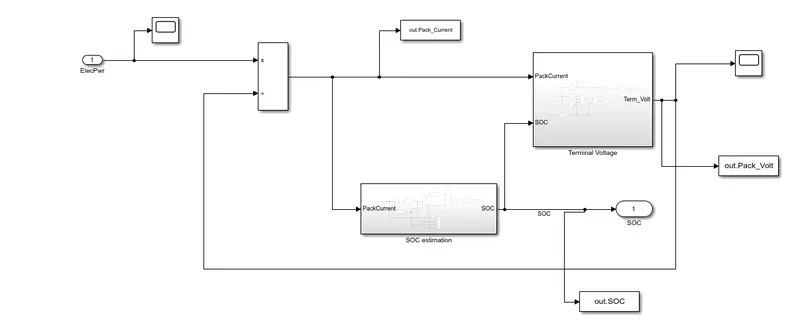
WHEEL MODEL: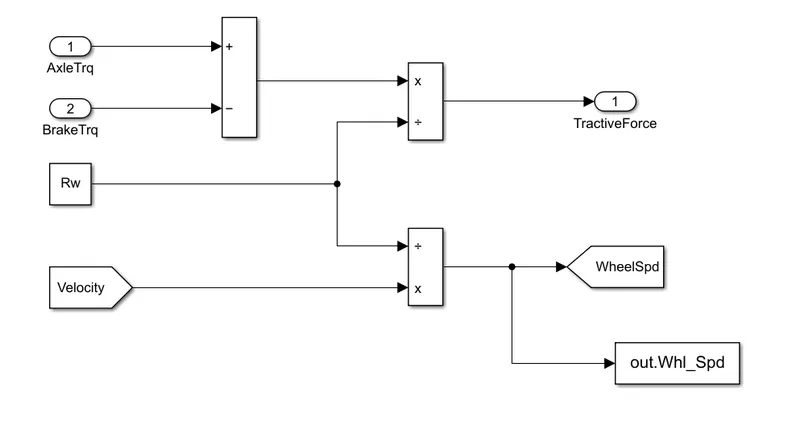
VEHICLE DYNAMICS: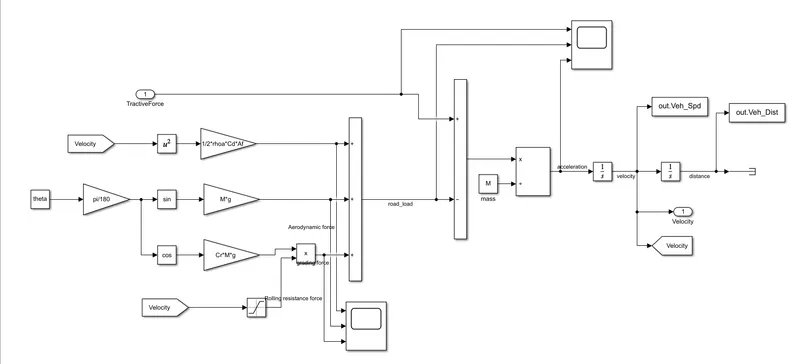
DRIVE LINK FOR SIMULINK MODEL: https://drive.google.com/file/d/1gMVLH9JAXJR15HVYuhfo6vVcUtB4W4Eb/view?usp=sharing
Tabulate the fuel economy numbers (kmpl) for UDDS and HWFET cycle. Compare these numbers with the baseline numbers for conventional vehicle model from Project 1:
| Fuel Economy Numbers (kmpl) For UDDS and HWFET Cycle |
| DRIVE CYCLE | Project 1 | project 2 |
| UDDS | 16.853354680911153 | 18.094535472670730 |
| HWFET | 21.204069050229340 | 22.004521150595570 |
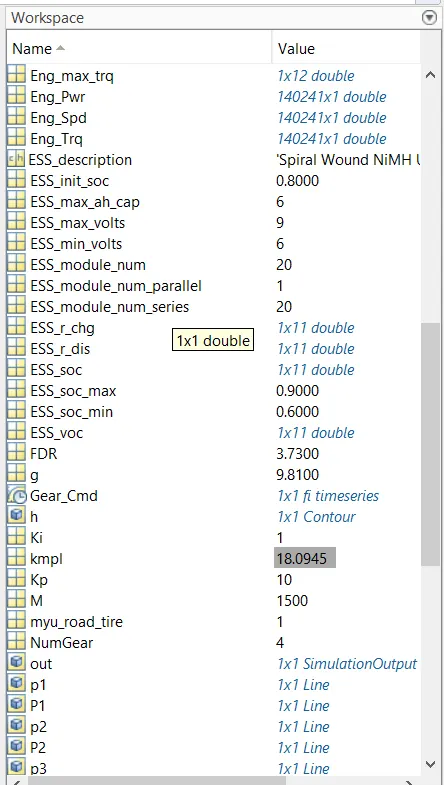
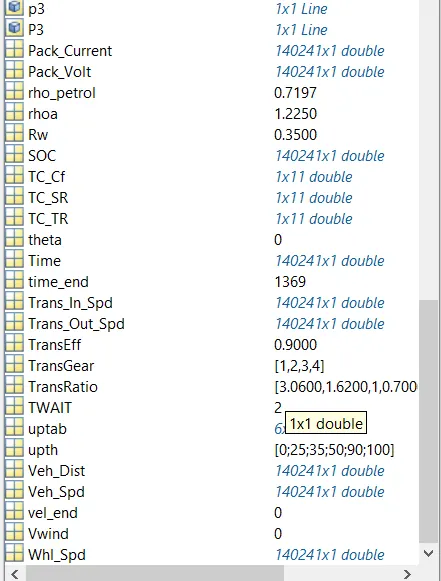
OUTPUT OF UDDS CYCLE WORKSPACE:
PLOTS RESULTS FOR UDDS CYCLE:
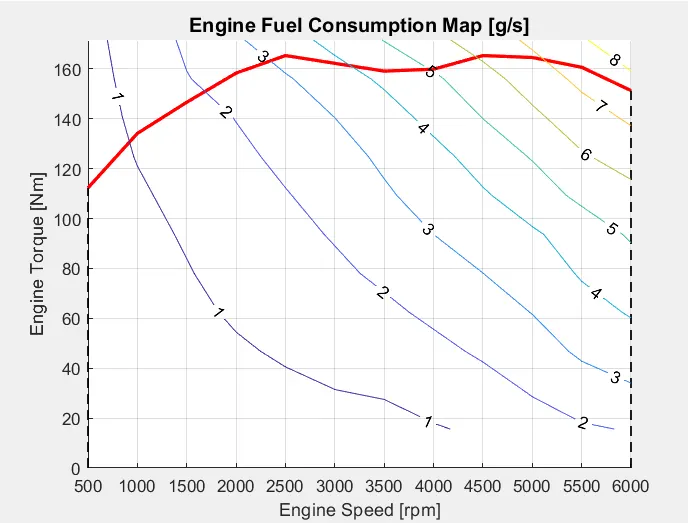
- Engine operating point on the engine fuel map.
- max torque curve is shown on the engine fuel map.
Plot the time trace for engine, transmission input, transmission output and wheel speed on one plot.
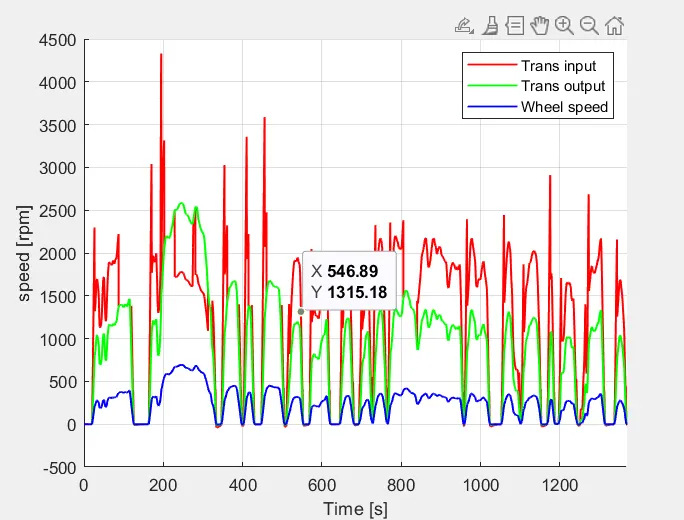
- Here as we can see that the all there trans input,trans output and wheel speed is fluctuating with respect to time.
- The maximum trans input speed around 4250 rpm.
- The maximum trans output speed around 2700 rpm.
- The maximum wheel speed around 750 rpm.
Plot engine torque, engine power, fuel rate and fuel consumption using subplots:
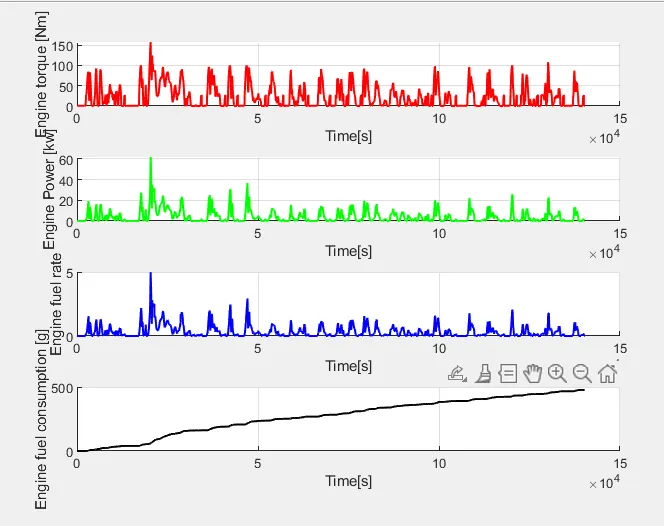
- Engine torque is fluctuating with respect to time and the maximum engine torque is around 150 Nm.
- Engine power is also fluctuating with respect to time and the maximum engine power is around 60kw.
- Engine Fuel rate is also fluctuating with respect to time and the maximum engine Fuel rate is around 4.5.
- Engine Fuel consumption is increasing with respect to time and the maximum engine Fuel consumption is around 500 and non linear.
Plot accelerator and brake pedal, gear command, vehicle desired and actual speed, vehicle distance using subplots:
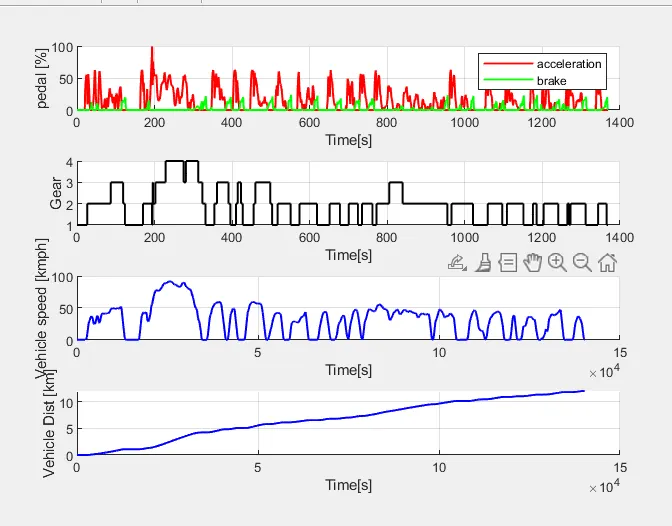
- Acceleration and brake is fluctuating with respect to time and the max acc is 100% and brake is most of the time 20-30%.
- gear shifting is variying but most of the time is in 2nd gear.
- vehicle velocity is fluctuating but the max vehicle speed is about to 95kmph.
- vehicle distance is increasing with respect to time but not linearly.
Plot motor speed, torque, motor input power using subplots:
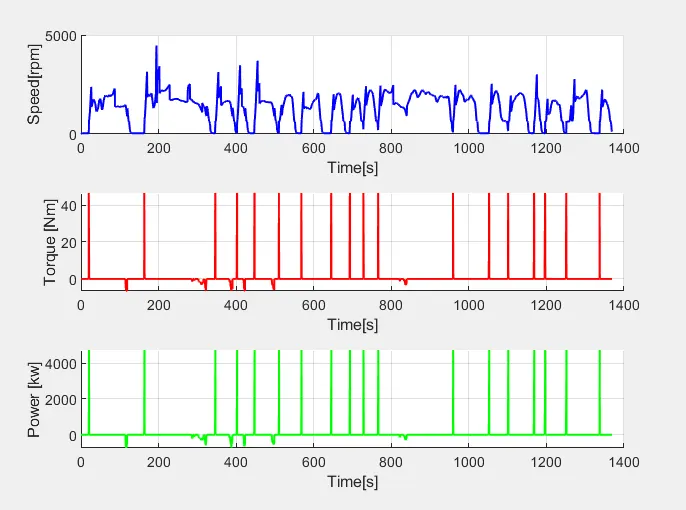
- Motor speed is fluctuating with respect to time and max speed is around 4500rpm.
- Torque is fluctuating in both positive and negative and the negative torque shows work as the generator whenever regen braking.
- power is also same fluctuating in both positive and negative and the negative torque shows work as the generator whenever regen braking.
Plot pack voltage, current and SoC using subplots:
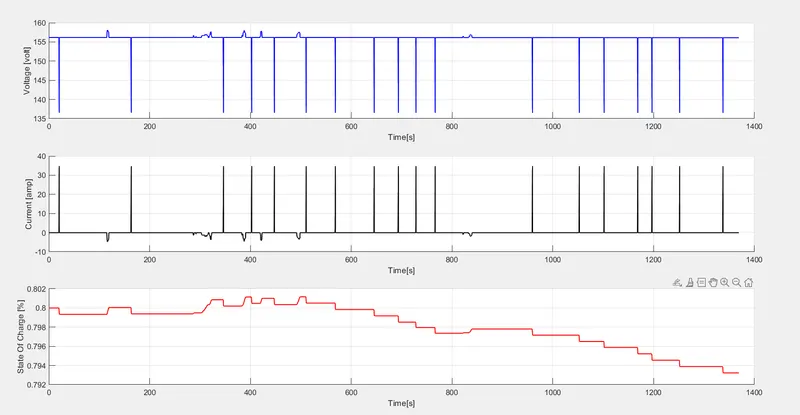
- Voltage is fluctuating continously with respect to time,most of the time is aproxx 156 volt.
- current is fluctuating continously with respect to time, and also went to negative,negative current showes the charging of battery increasimh the soc.
- Soc (state of charge) is decreasing as the motor is running continuously some time it increase because of regen braking.
Plot the motor operating points on the motor input power map, with the motor max motoring and generating torque curves:
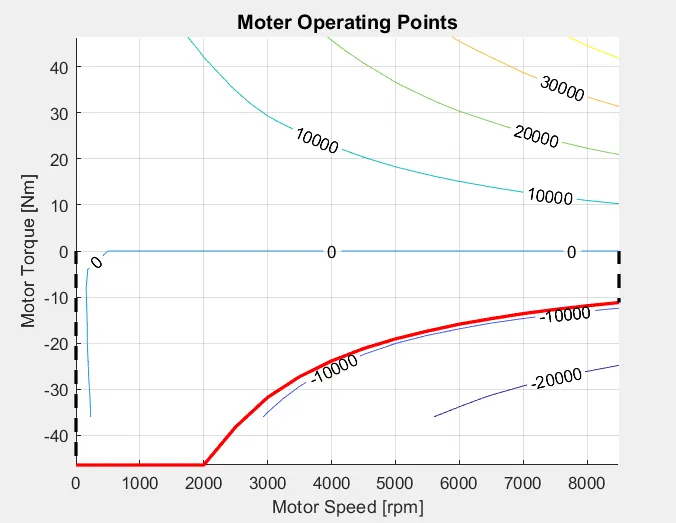
- Motor operating on the input power map.
- because it is asking about the max generation torque thats why the curve is in negative.
Generate the plots for UDDS drive cycles:
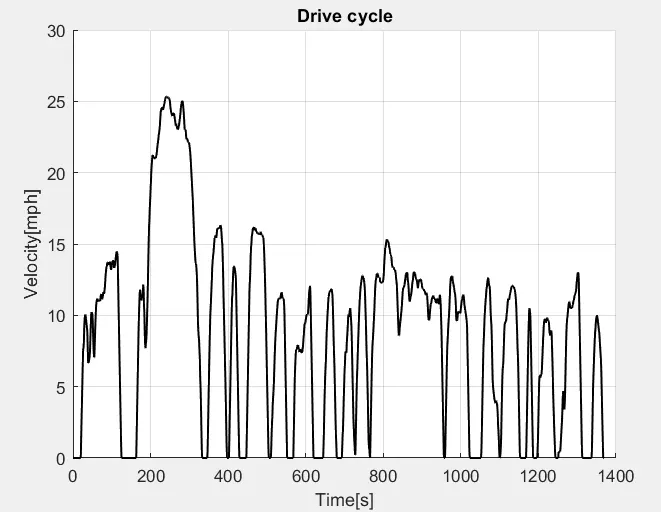
- In Urban drive cycle, the velocity is higly fluctuating with respect to time,because of the road condition some time it also goes to 0.
OUTPUT OF HWFET CYCLE WORKSPACE:
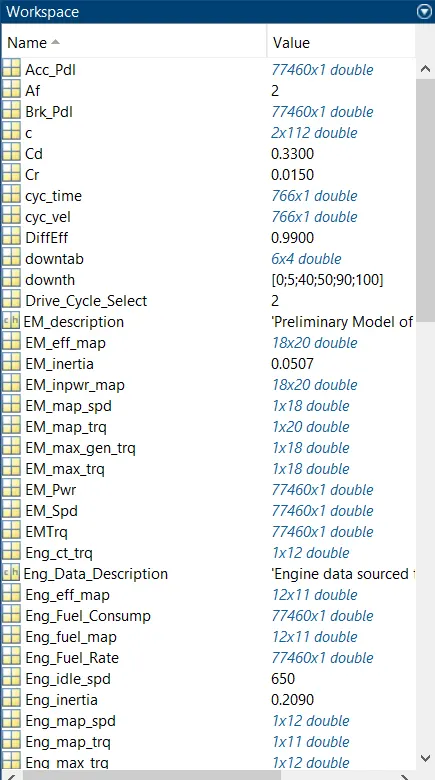
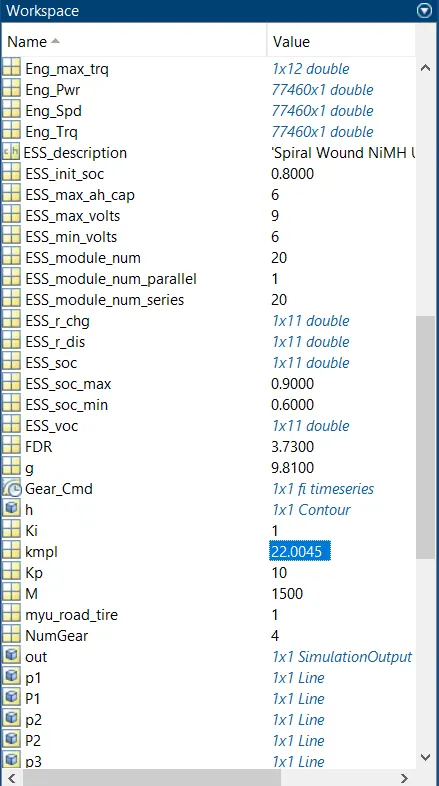
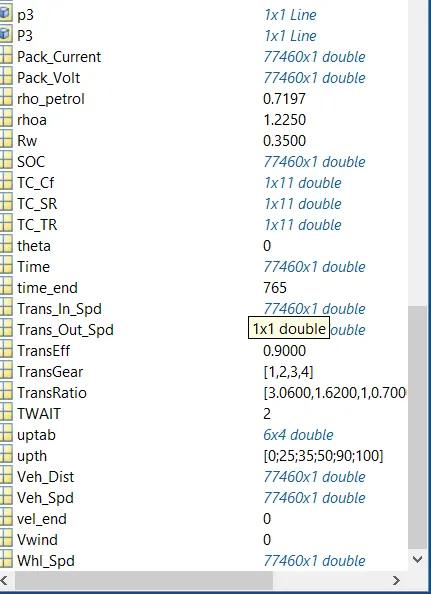
PLOTS RESULTS FOR UDDS CYCLE:
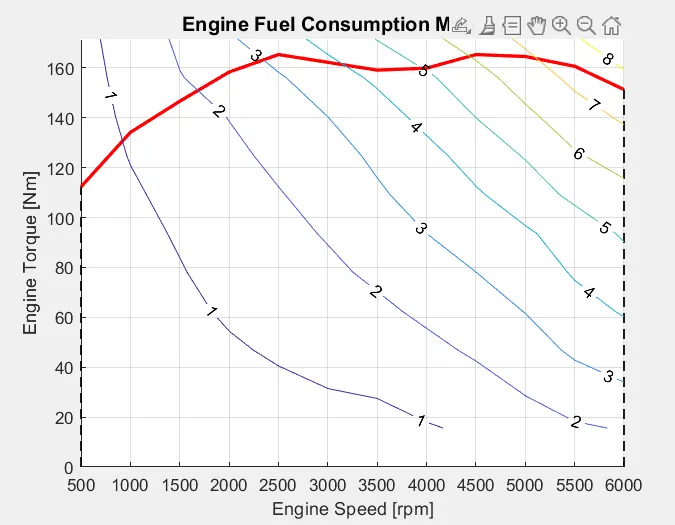
- Engine operating point on the engine fuel map.
- max torque curve is shown on the engine fuel map.
Plot the time trace for engine, transmission input, transmission output and wheel speed on one plot.
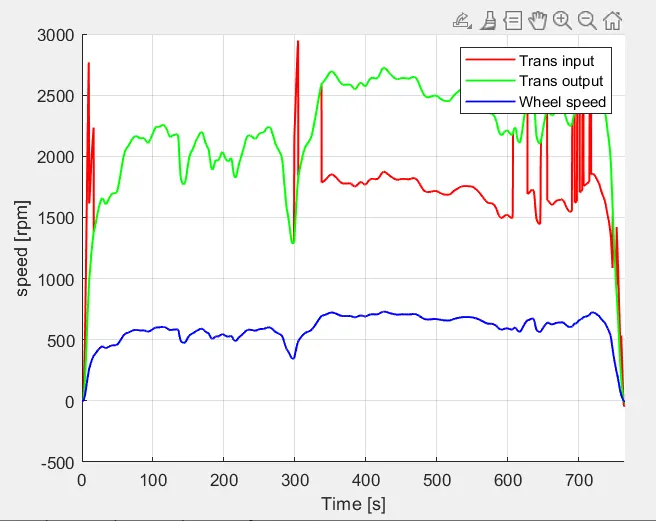
- Here as we can see that the all there trans input,trans output and wheel speed is fluctuating with respect to time.
- The maximum trans input speed around 2900 rpm.
- The maximum trans output speed around 2700 rpm.
- The maximum wheel speed around 725 rpm.
Plot engine torque, engine power, fuel rate and fuel consumption using subplots:
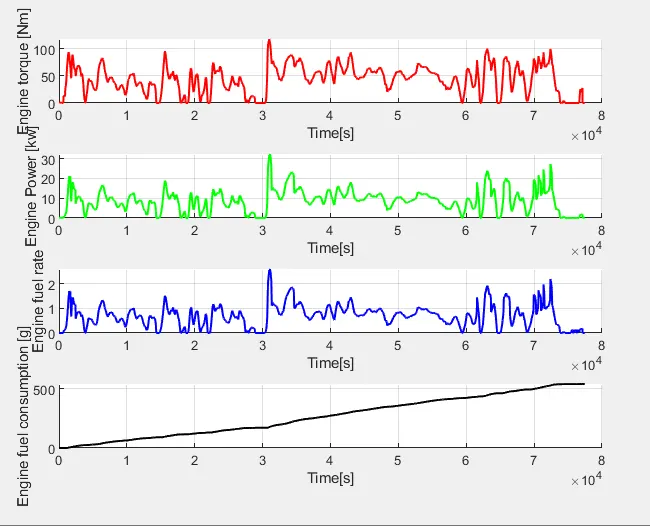
- Engine torque is fluctuating with respect to time and the maximum engine torque is around 115 Nm.
- Engine power is also fluctuating with respect to time and the maximum engine power is around 30kw.
- Engine Fuel rate is also fluctuating with respect to time and the maximum engine Fuel rate is around 2.5.
- Engine Fuel consumption is increasing with respect to time and the maximum engine Fuel consumption is around 500 and non linear.
Plot accelerator and brake pedal, gear command, vehicle desired and actual speed, vehicle distance using subplots:
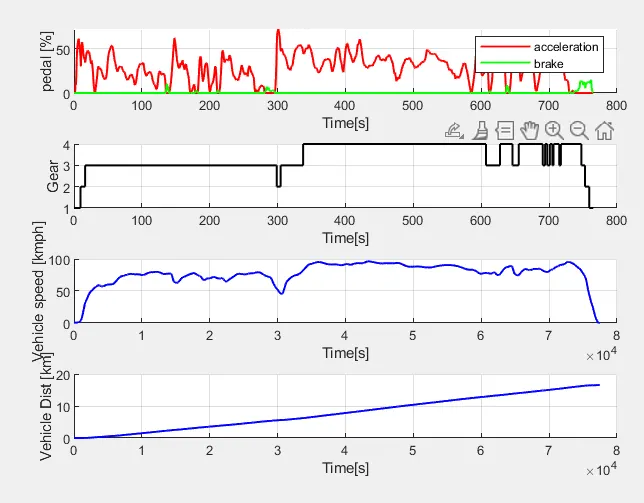
- Acceleration and brake is fluctuating with respect to time and the max acc is 70% and brake is most of the time 0 because it is a highway road conition .
- gear shifting is variying but most of the time is in 2nd and 4th gear.
- vehicle velocity is not much fluctuating but the max vehicle speed most of the time is about to 95-100kmph.
- vehicle distance is increasing with respect to time but not linearly.
Plot motor speed, torque, motor input power using subplots:
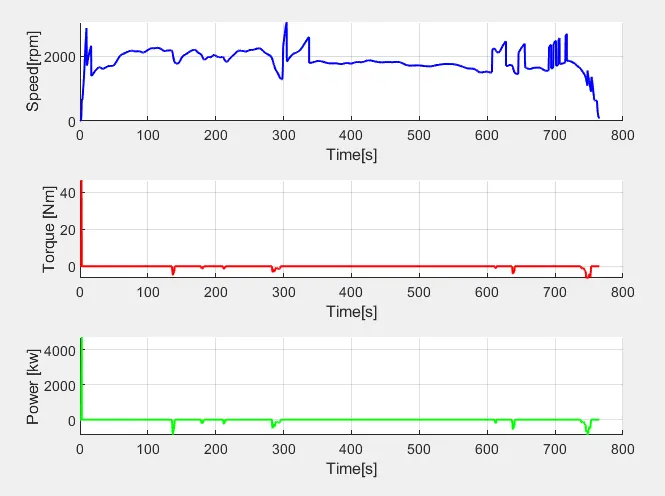
- Motor speed is not much fluctuating with respect to time and max speed is around 3000rpm.
- Torque is fluctuating most time in positive and very less time in negative and the negative torque shows work as the generator whenever regen braking.
- power is also same fluctuating most time in positive and very less time negative and the negative torque shows work as the generator whenever regen braking.
Plot pack voltage, current and SoC using subplots:
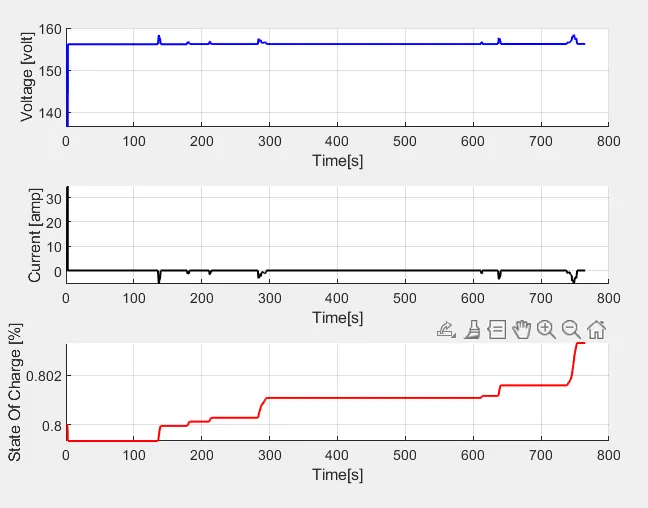
- Voltage is not much fluctuating with respect to time,most of the time is aproxx 155 volt.
- current is not much fluctuating with respect to time, and also went to negative,negative current showes the charging of battery increasimh the soc.
- Soc (state of charge) is increasing continuously because motor is work as generator.
Plot the motor operating points on the motor input power map, with the motor max motoring and generating torque curves:
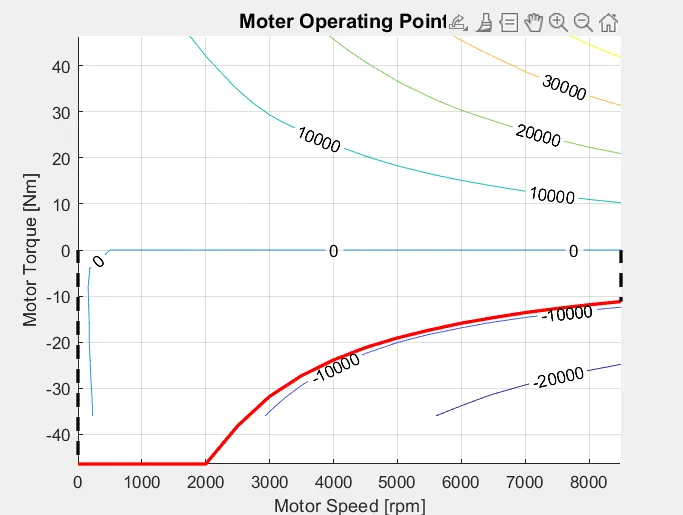
- Motor operating on the input power map.
- because it is asking about the max generation torque thats why the curve is in negative.
Generate the plots for HWFET drive cycles:
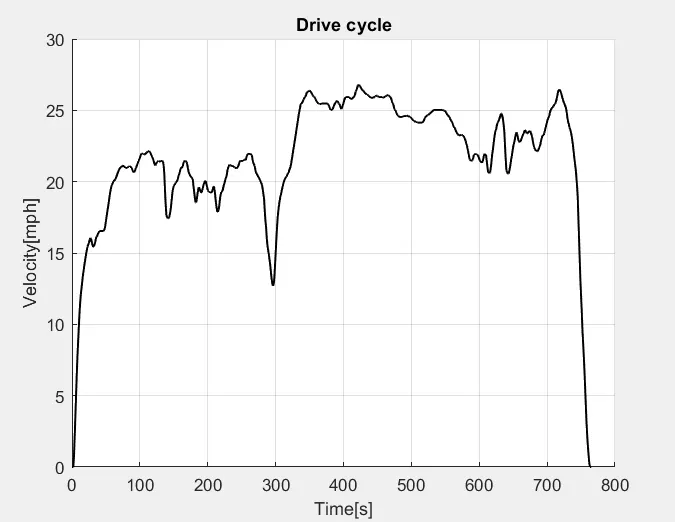
- In Highway drive cycle, the velocity is fluctuating with respect to time but not very much,because of the road condition and it won't goes to zero after starting and before stoping.