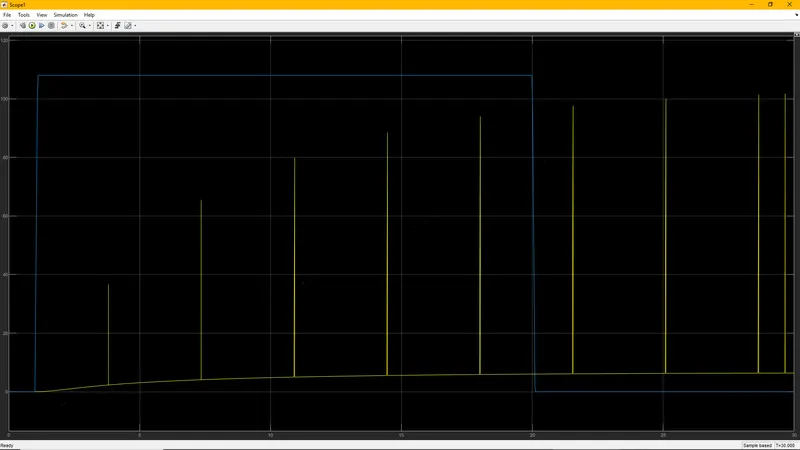
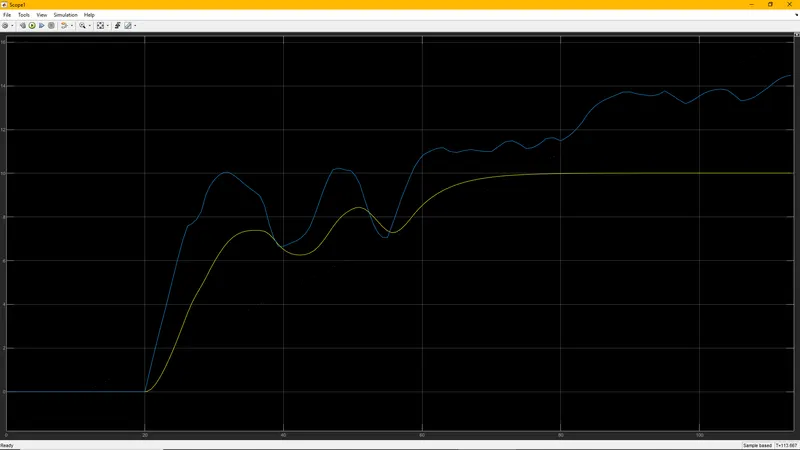
Project-1: Modelling an electric Car with Li-ion battery
AIM: To modell a electric car using LI ION battery.
Steps to be followed:
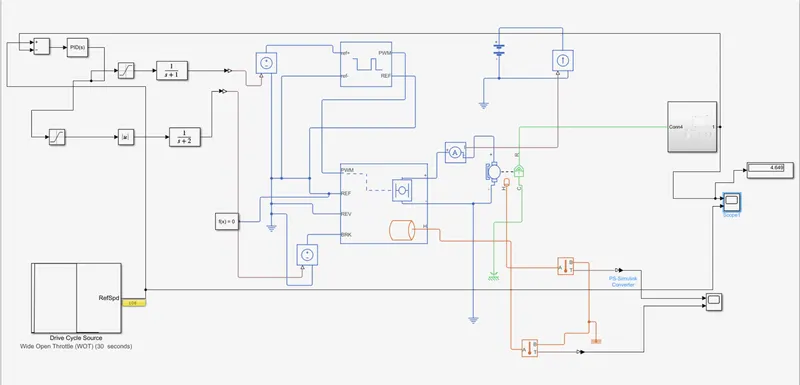
PId block:
 By adjusting the parameters of P, I and D we can vary the errors and for the better controlling.
SATURATION BLOCK WITH TRANSFER FUNCTION:
 The saturation block and transfer function limts the overshoot and is given to acceleration input. The saturation level is set as 0 to 1 for the acceleration. For deceleration the saturation level is set as 0 to -1.
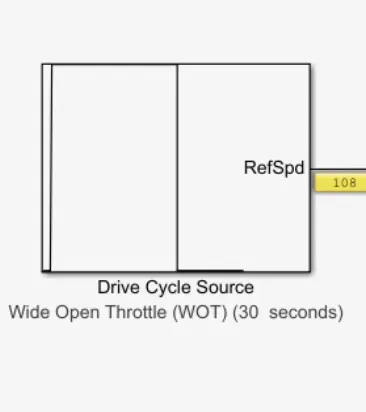
WOT: custom values that is created as referred input.
H BRIDGE:
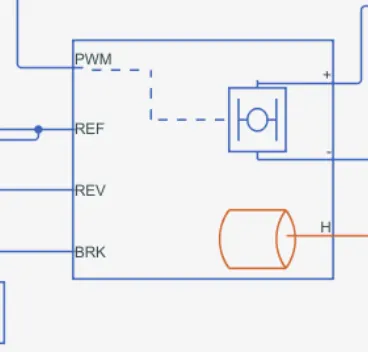
it operates in 4 quadrant where is output voltage is collected at terminals.
CONTROLLED PWM:
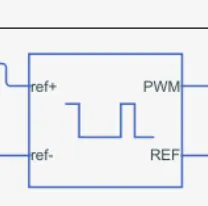 ref+ and ref_ are actuall accelrator and brake command that are given to the pwm through controlled voltage source.
VECHILE BODY: where the mechincal things are connected and velocity is measured.
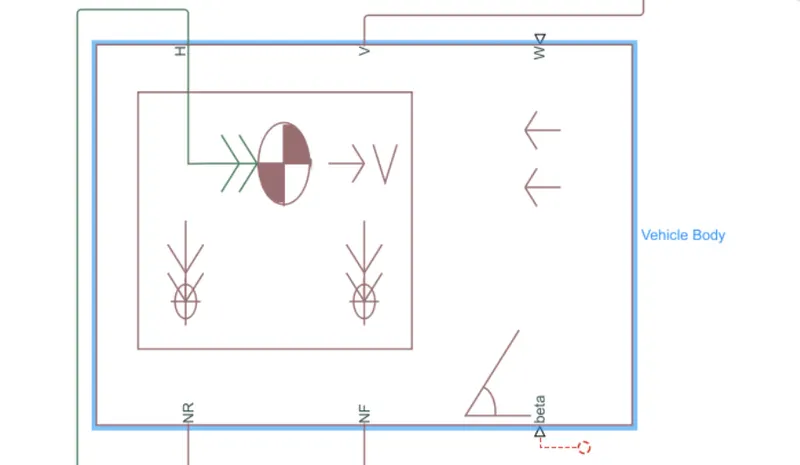
This is the actual implementad model of EV .
The results are shown by using varies inputs.