Project 1 (Mini Project on Vehicle Direction Detection
Aim:
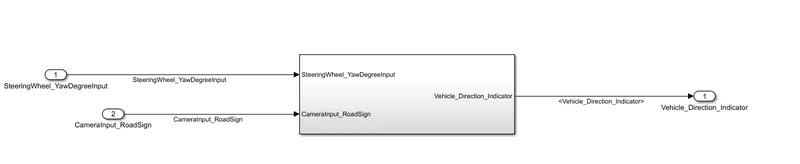
To develop the model for vehicle direction detection and tagging the requirement to the corresponding subsystem.
Model:
Explanation:
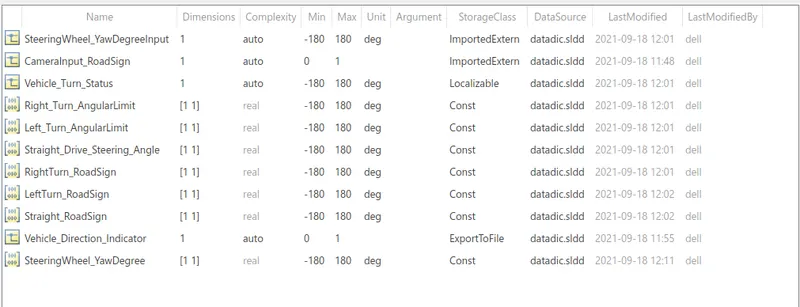
All the signals and constants used in the model are declared using a Data dictionary.
Requirement 1:
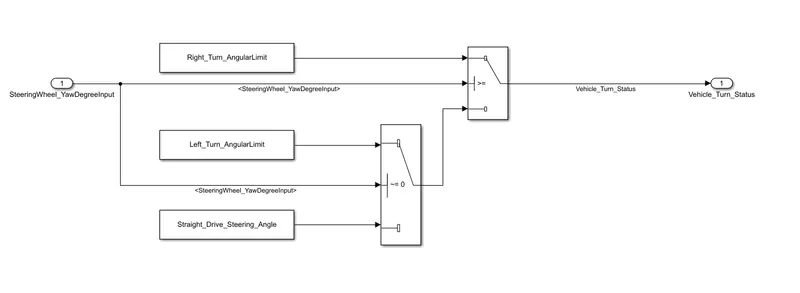
Two switch block is used in this case. In the 1st switch block, the steering wheel yaw input is compared with the right turn limit. In the 2nd switch block, the steering wheel yaw input is checked whether the signal is zero or non-zero. Depending upon the Steering Wheel Yaw input, the particular block is chosen as output as vehicle_turn_status and fed as input to the next subsystem.
Requirement 2:
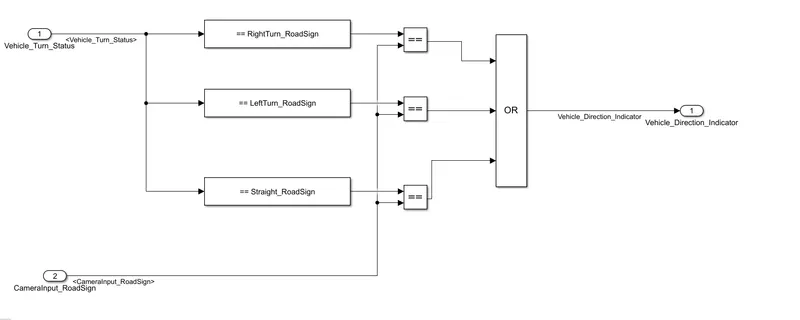
The Signal Vehicle_Turn_Status is compared against calibration values, if each of them is found equal, then each of the three corresponding output is compared against the camera input signal. The OR logical operator block is used as only one among them is finally as an output signal.
Requirement Tagging:
The requirement tagging done by right click on subsystem -> Requirement and choose the particular document or Matlab file.
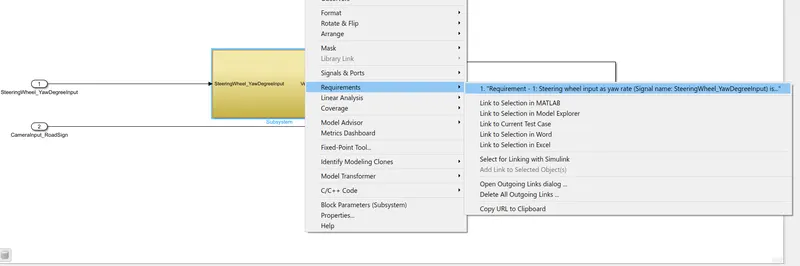
Similarly, The tagging is done for Requirement 2 with help of a word file.
Result:
Depending upon the input steering Yaw signal, the vehicle direction indicator will display the output.