Project 1
1) To develop a double-acting actuator model using Simscape Multibody and Simscape components.
The mechanical system of the cylinder needs to be built using Simscape Multibody library components/blocks, and the hydraulic system needs to be modeled using Simscape library physical components.
Solution:
The below image shows the double-acting actuator working.
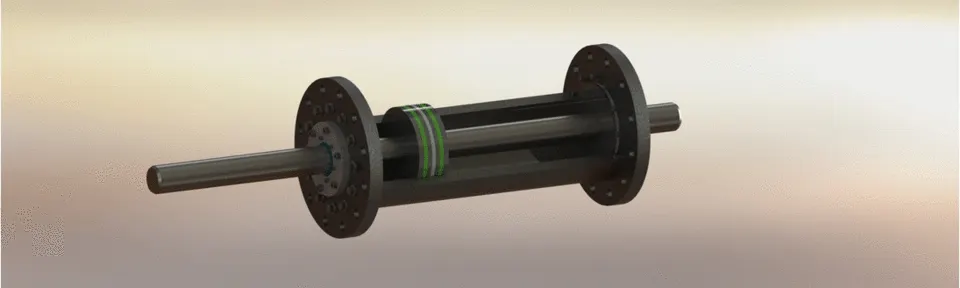
A double-acting cylinder alternates cycles of pressurized fluid to both sides of the piston and creates extend and retract forces to move the piston rod, permitting more control over the movement. Using a control system made up of a 2-, 3-, 4- way position valve would be required to achieve the desired movement for your application.
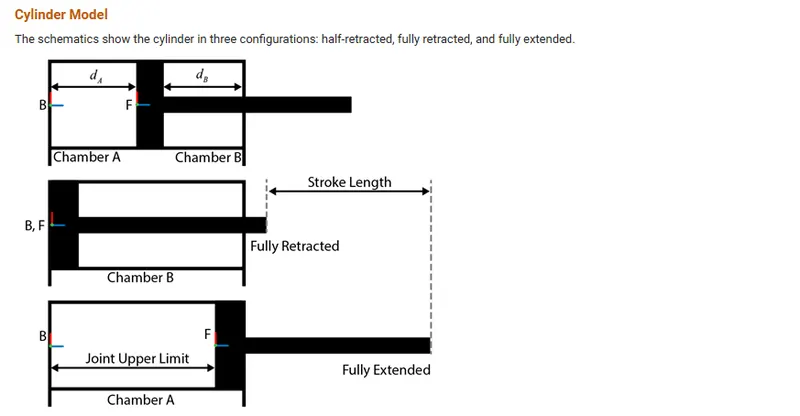
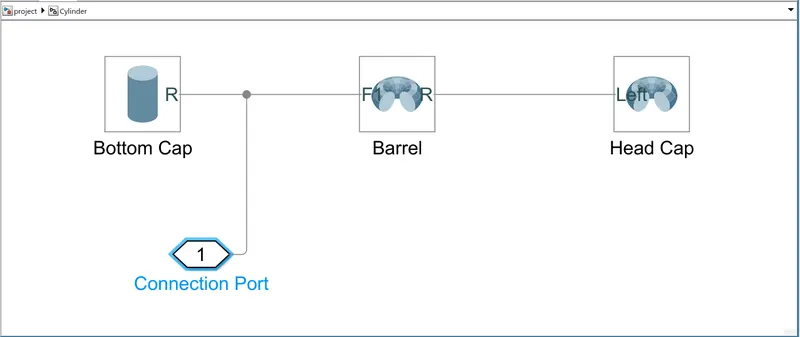
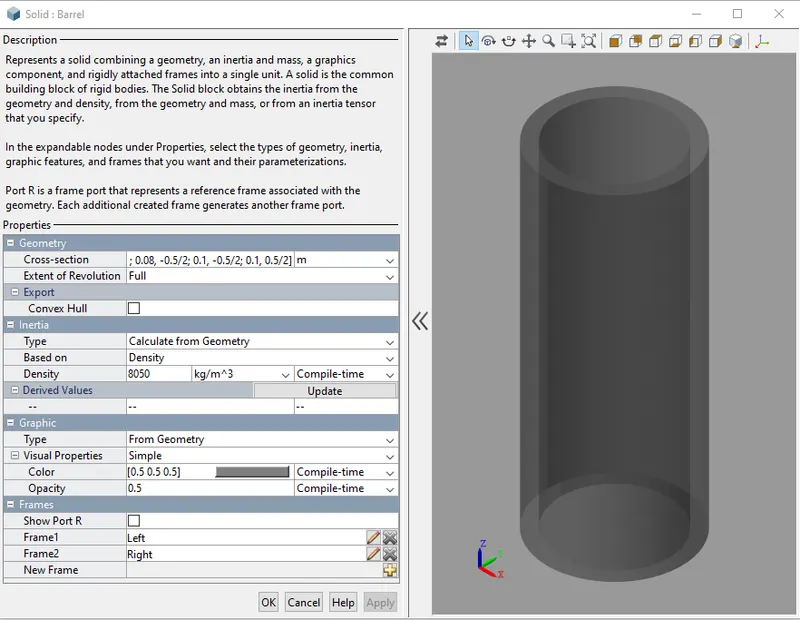
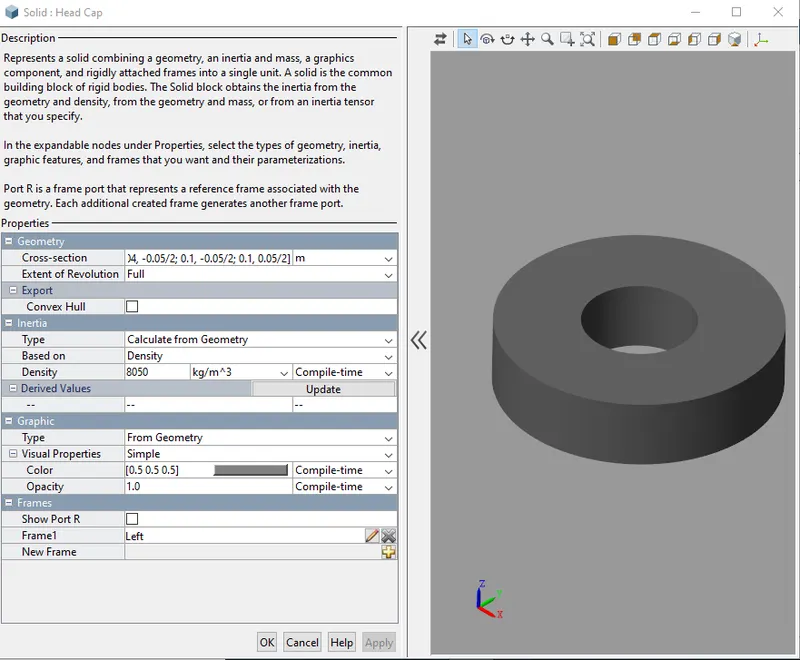
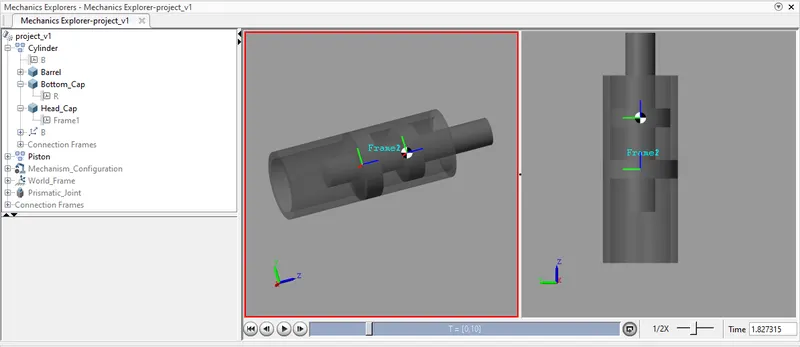
Cylinder subsystem is built using Simscape Multibody library components comprises of bottom cap, barrel and head cap components. Built using the simscape revolve solid and cylinderical solid simscape multibody library.
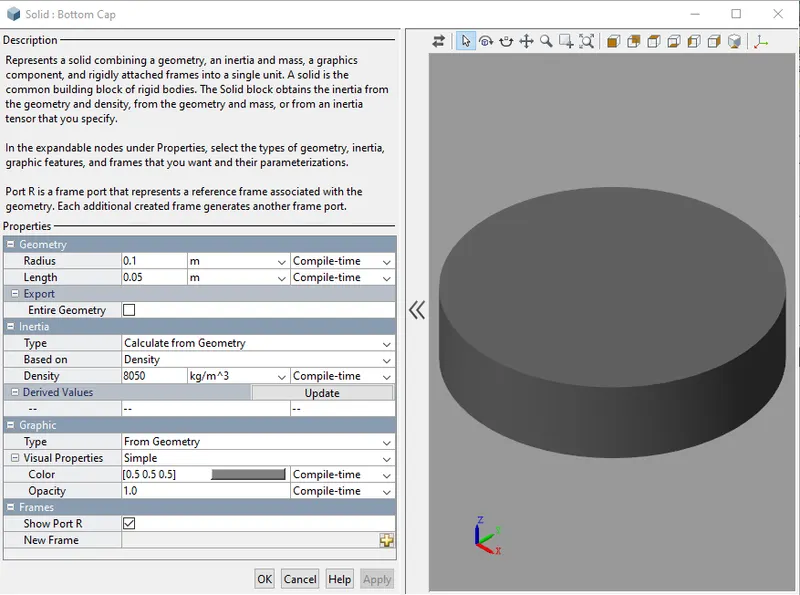
Below image shows the bottom cap construction and its properties defined using multibody elements and its associations configured.
Below image shows the barrel construction and its properties defined using multibody elements and its associations configured.
Below image shows the head Capconstruction and its properties defined using multibody elements and its associations configured.
Piston subsystem is built using Simscape Multibody library components comprises of piston and rod components. Built using the simscape revolve solid and cylinderical solid simscape multibody library.
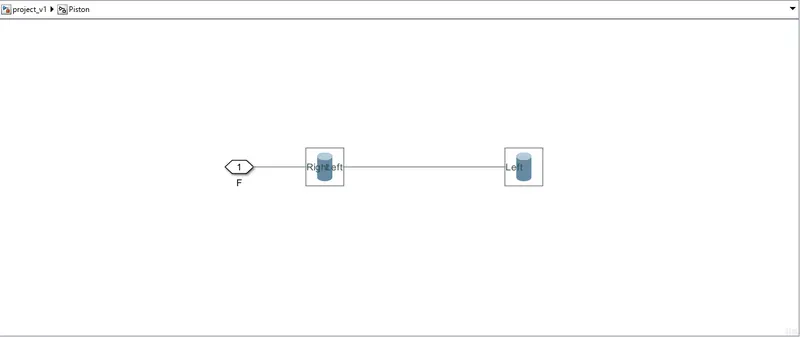
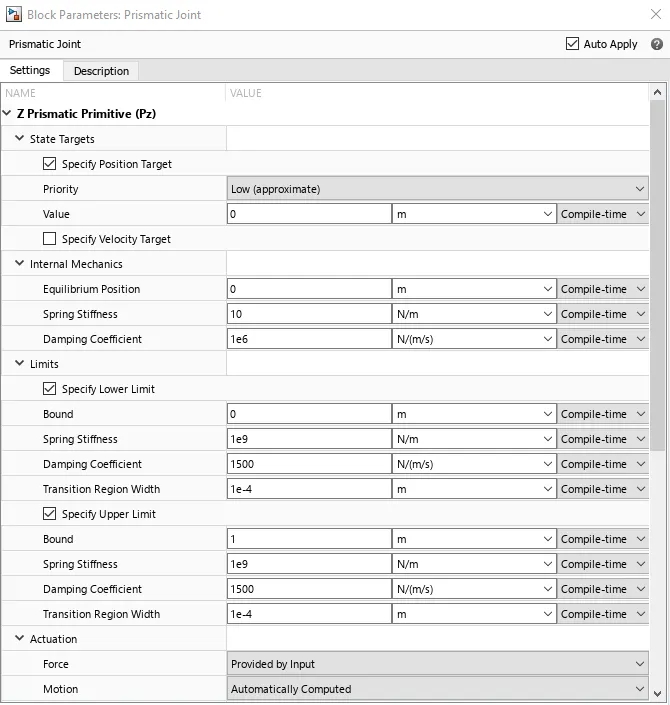
In order to provide translational degree of freedom to the piston prismatic joint block is used and defined as shown in the image below.
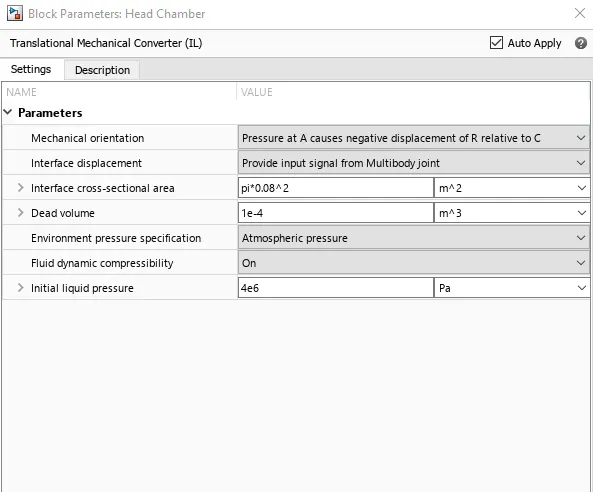
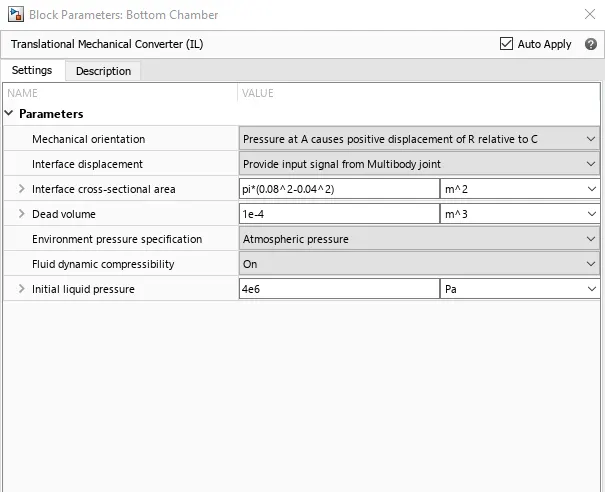
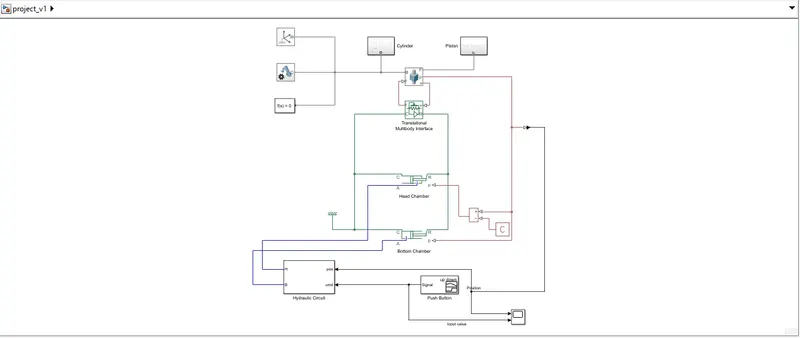
Hydraulic subsystem is built to perform the dynamic actuation based on the input response head and bottom chambers translational mechnaical converter parameters are defined as shown in the image below.
Head Chamber
Bottom Chamber
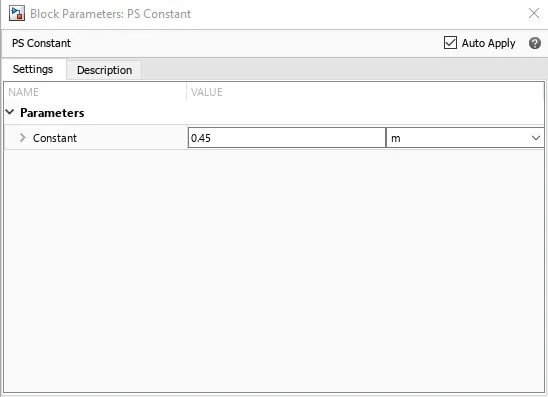
The Strock length of the rod is defines to the value by using PS Constant block as shown in the below image.
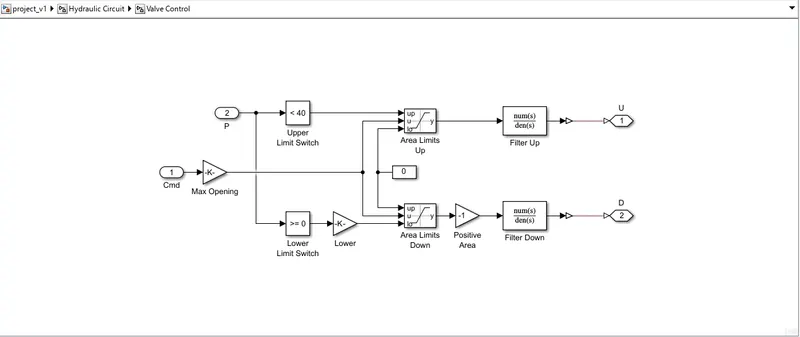
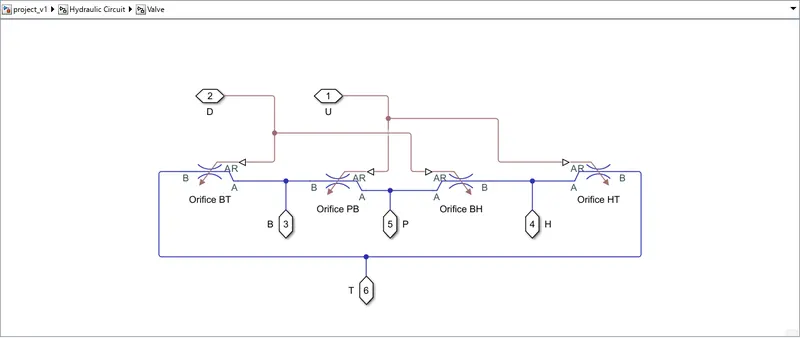
Hydraulic Circuit subsystem is built to perform the fluid control operation based on the limit defined and position of the pistion.
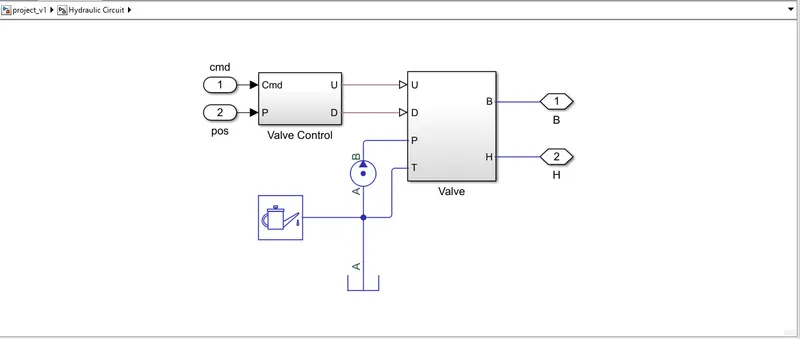
Valve Control
Valve
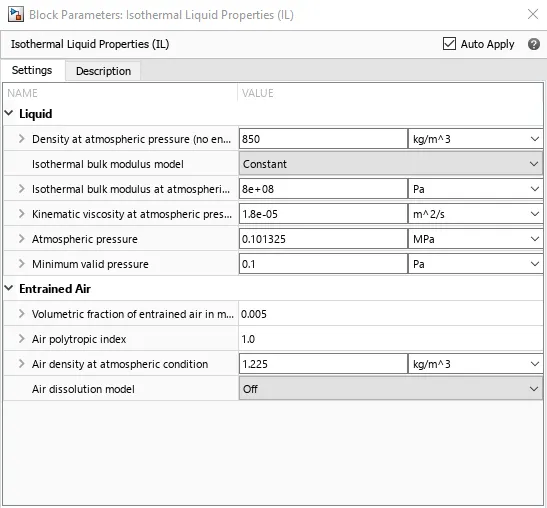
Isothermal Liquid Properties
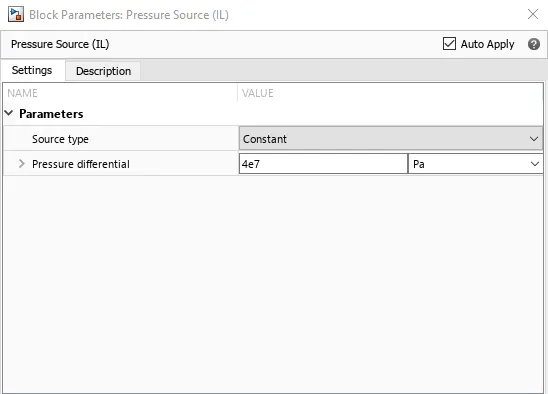
Pressure Source
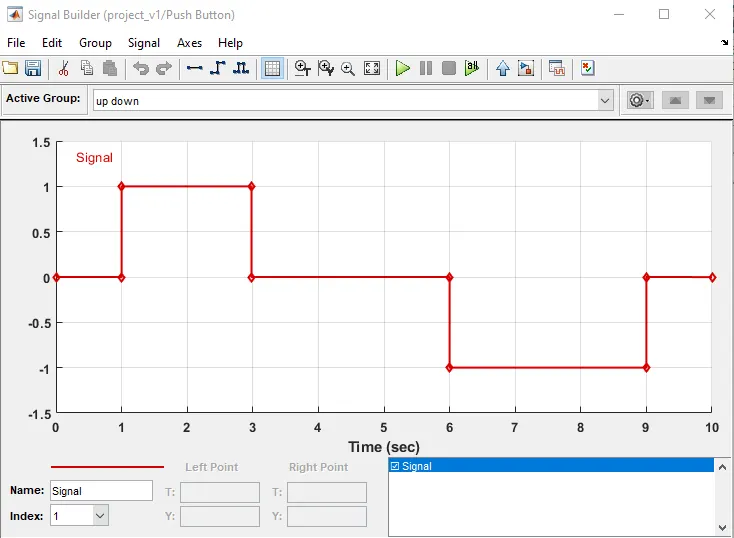
Push Button signal is defined as an input to the system which is as shown below.
The below image shows the double-acting actuator model built using Simscape Multibody and Simscape components.
Simulation Result:
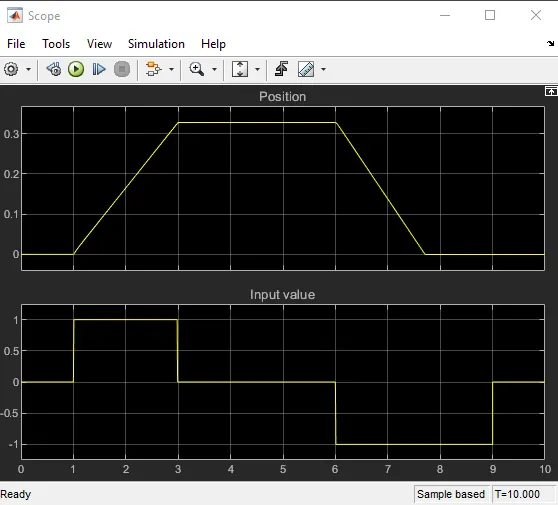
Scope Output:
Dynamic Response of an double acting actuator for the input value as shown in the below plot and the position of the actuator.
Conclusion:
The double-acting actuator model has been built using Simscape Multibody and Simscape components. And the results are as shown in the figures above the double acting response is following the input signal trend.
Reference:
The below refernces found useful to complete the project.
https://in.mathworks.com/help/simscape/ug/modeling-a-double-acting-actuator.html
https://in.mathworks.com/help/sm/ug/hydraulic-interface-dump-trailer-with-hydraulic-cylinder.html