Development of a forward energy-based fuel consumption model of a conventional vehicle
AIM: To develop of a forward energy-based fuel consumption model of a conventional vehicle by writing MATLAB scripts and modelling in SIMULINK, analysing and generating plots.
OBJECTIVES OF THE PROJECT:
1. To develop a forward energy-based fuel consumption model of a conventional vehicle which simulate the vehicle on different drive cycles like UDDS, HWFET, FTP, NEDC, etc.
2. A MATLAB script is used to load all the variables required for running the SIMULINK model.
3. The SIMULINK model of the vehicle is modelled using a Driver, Controller and a Powertrain block.
4. The SIMULINK model is executed and data from the model will be loaded in the MATLAB workspace.
5. The MATLAB script used to analyse the SIMULINK model data and to generate the required plots such as,
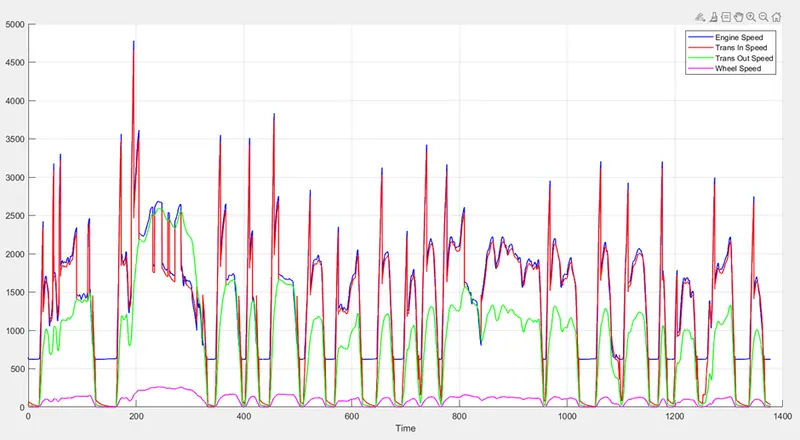
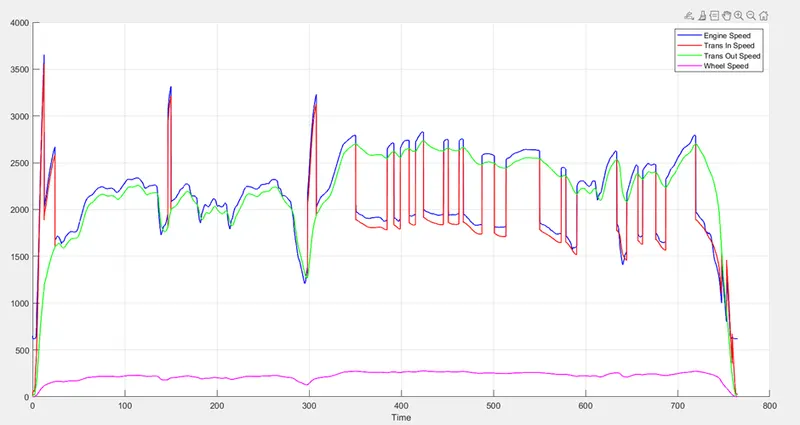
a. Plotting the time trace for engine, transmission input, transmission output and wheel speeds.
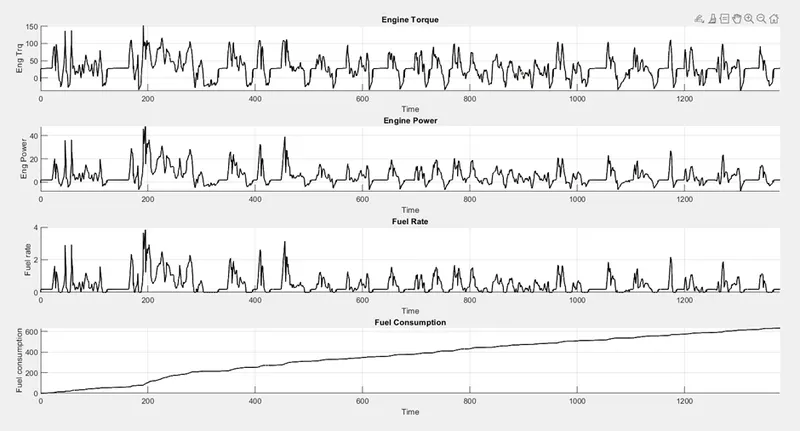
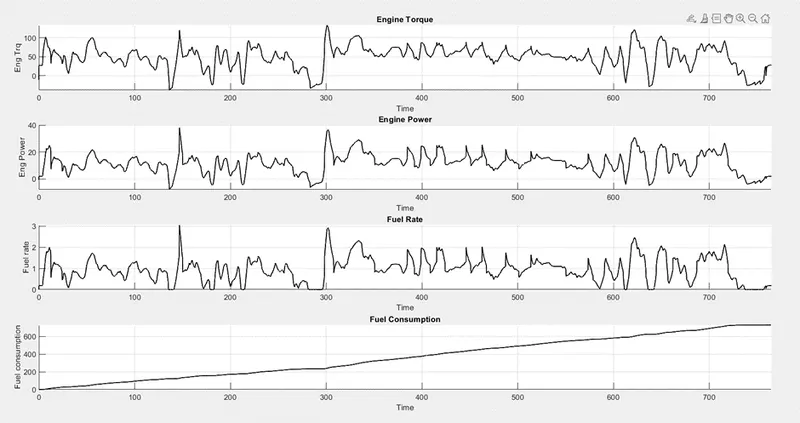
b. Plotting engine torque, engine power, fuel rate and fuel consumption.
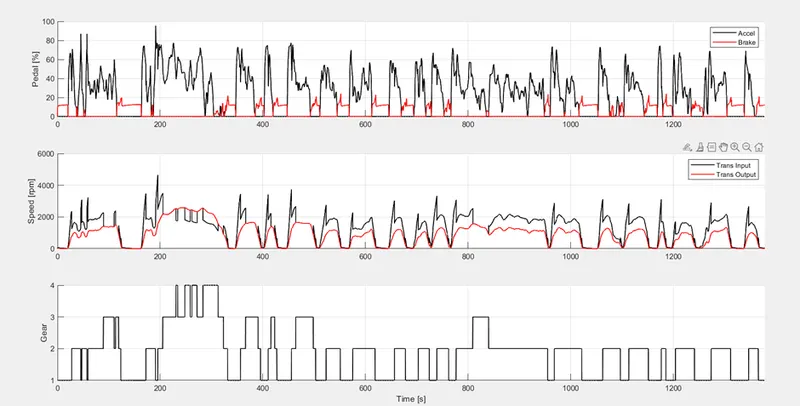
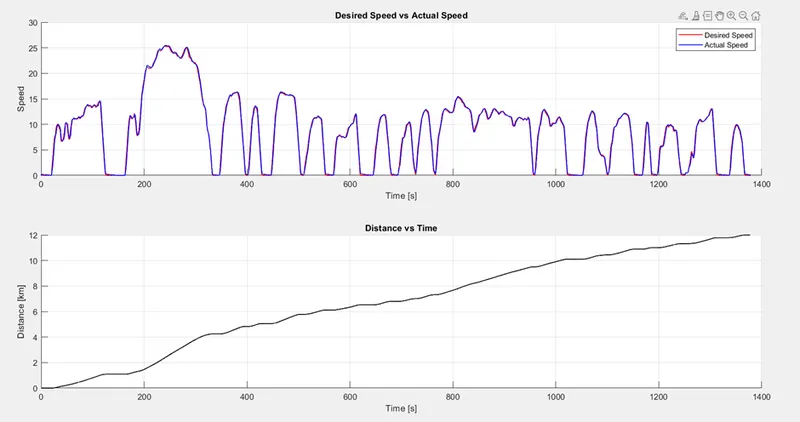
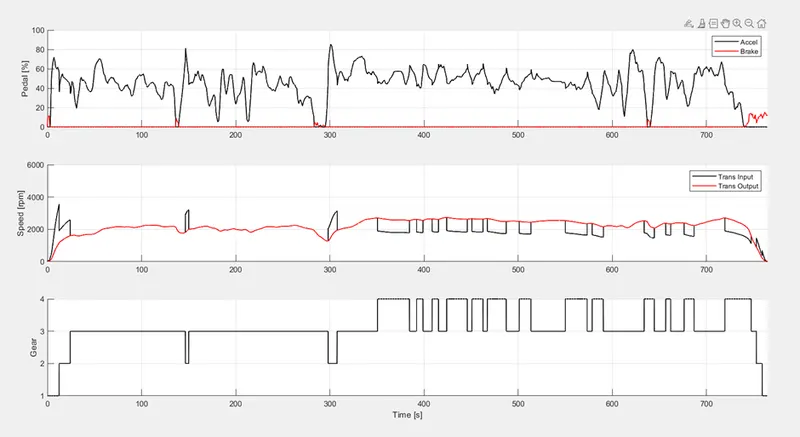
c. Plotting accelerator and brake pedal, gear command, vehicle desired and actual speed, vehicle distance.
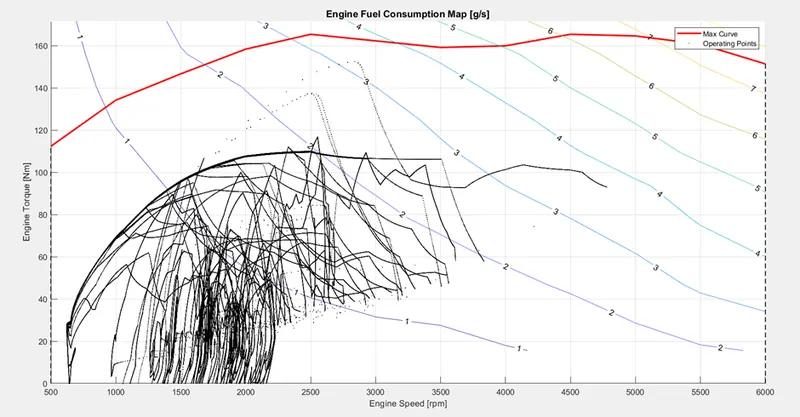
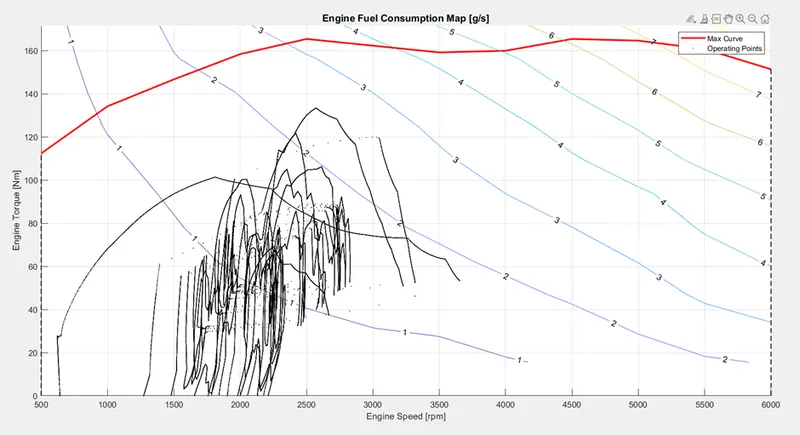
d. Plotting the engine operating points on the engine fuel map.
Energy based models
There are two basic types of structure for the energy based models,
i) Forward Model: Dynamic simulation of the system. Simulate from the source to the sink i.e., starts simulation from the input to the engine to the wheels to determine the performance.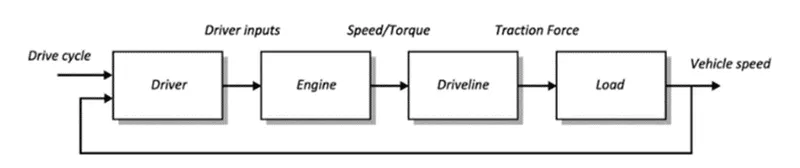
ii) Backward Model: Quasi-Static simulation of the system. Simulate from the sink to the source i.e., input is the vehicle speed and acceleration and the engine input is back calculated.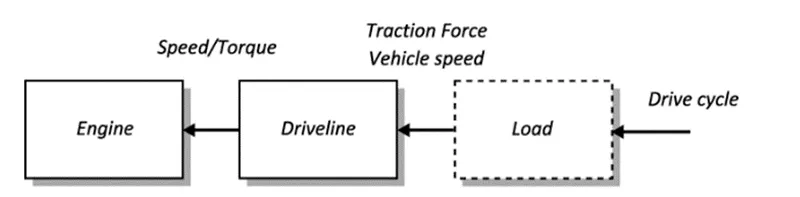
MATLAB INITILIZATION CODE:
In this project, a typical midsize car with a 1.9L engine and a 4-speed automatic transmission is considered. Data is taken from ADVISOR data base developed by NREL, USA. Transmission shift map and controller is taken from MATLAB/SIMULINK example database. The model developed has the capability to simulate the vehicle on different drive cycles like UDDS, HWFET, FTP, NEDC, etc. The file “Project1_InitFile.m” is a MATLAB script which is used to load the variables in order to run the SIMULINK model. Also, the code prompts the user to select the required drive cycle for simulation.
%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%
%% Skill-Lync -> Hybrid Drives Development
% Project 1 - Conventional Vehicle Model


% Description:

%% Initialization File
% Initialization file for loading the variables for the Conventional vehicle simulation model

clear all
clc
%% Vehicle Parameters
M = 1500;       % Vehicle weight [kg]
Cr = 0.015;     % Rolling resistance coefficient
Rw = 0.35;      % Rolling radius [m]
Cd = 0.33;      % Drag coefficient
Af = 2;         % Frontal area [m2]
rhoa = 1.225;   % Air density [kg/m3]
Vwind = 0;      % Wind velocity [kmph]
g = 9.81;       % Gravitational acceleration [m/s2]
theta = 0;      % Slope [deg]
myu_road_tire = 1; % Coefficient of friction between tire - road interface

%% Powertrain Parameters
FDR = 3.73;                         % Final Drive Ratio / Diff Ratio
DiffEff = 0.99;                     % Differential efficiency (assumed independent of operating conditions)

NumGear = 4;                        % Number of gears in transmission
TransGear = [1:NumGear];            % Transmission Gears
TransRatio = [3.06, 1.62, 1, 0.7];  % Corresponding Transmission ratios
TransEff = 0.90;                    % Transmission efficiency (assumed independent of operating conditions)

TC_SR = [0, .5, .6, .7, .8, .87, .92, .94, .96, .97, 1];   % Torque Converter Speed Ratio (Matlab default) -> TurbSpd/PumpSpd
TC_TR = [2.232, 1.5462, 1.4058, 1.2746, 1.1528, 1.0732, 1.0192, 1, 1, 1, 1];   % Torque Converter Torque Ratio (Matlab default) -> TurbTrq/PumpTrq
TC_Cf = 1e-4 * [.72558, .66322, .63463, .59042, .51331, .4144, .29287, .22444, .12186, .04386, 0]; % Torque Converter Capacity Factor (Matlab default) -> PumpTrq/PumpSpd^2 [Nm/rpm^2]

load Vehicle_Data/Engine_data_1_9L_Saturn_95kW
load Vehicle_Data/Trans_Shift_map

%% Driver Parameters
Kp = 10;                    % P gain for driver PI model
Ki = 1;                     % I gain for driver PI model
Drive_Cycle_Select = input(sprintf('Drive cycle for Simulation: n1. UDDS n2. HWFET n3. FTP n4. US06 n5. NEDC n6. WLTP nYour selection:'));     % Drive cycle selection

% Drive cycle values in m/s

if Drive_Cycle_Select == 1
    load DriveCycles/UDDS;

elseif Drive_Cycle_Select == 2
    load DriveCycles/HWFET;

elseif Drive_Cycle_Select == 3
    load DriveCycles/FTP;

elseif Drive_Cycle_Select == 4
    load DriveCycles/US06;

elseif Drive_Cycle_Select == 5
    load DriveCycles/NEDC;

elseif Drive_Cycle_Select == 6
    load DriveCycles/WLTP;

end

time_end = cyc_time(end);
vel_end = cyc_vel(end);
CONVENTIONAL VEHICLE FORWARD MODEL
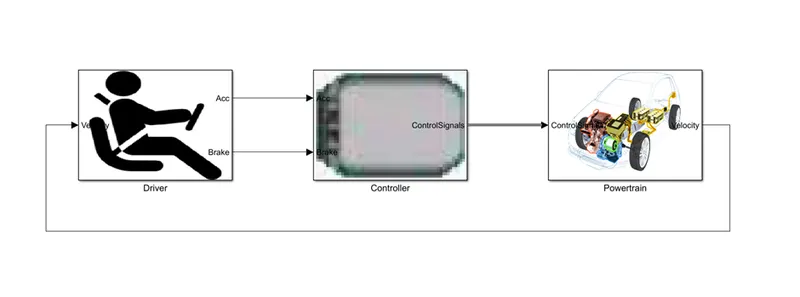
The model consists of 3 main blocks such as Driver, Controller and Powertrain as shown in above figure. The Driver block is a basic PI controller which generates the accelerator and brake pedal outputs required to match the desired and actual vehicle speed.
DRIVER MODEL
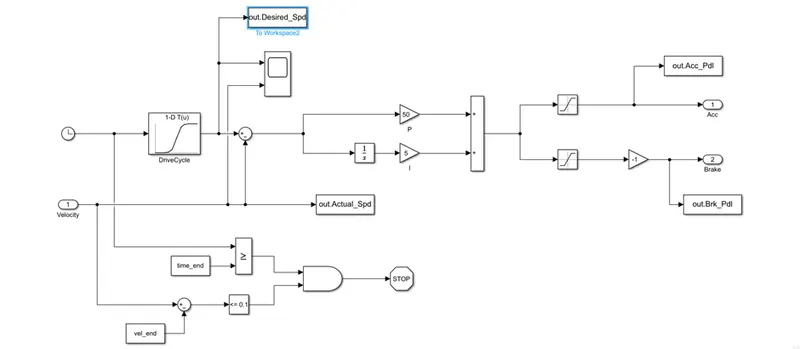
The drive cycle data is fed as input in the driver block and the feedback velocity is given from the powertrain block. The lookup table consists of the drive cycle data, desired speed as a function of time. The positive speed values are given out as acceleration output and the negative speed values are given as brake outputs. The scope block in this subsystem is to check the desired speed and the actual speed. The output of the scope block is shown below. The vehicle velocity traces the drive cycle speed with minimum overshoot and upper shoot.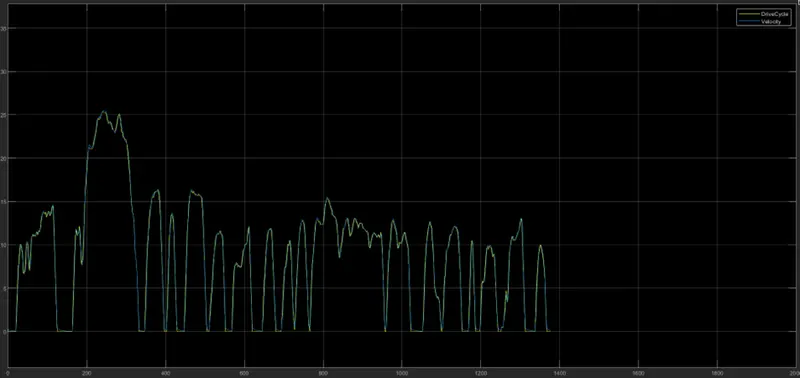
CONTROLLER
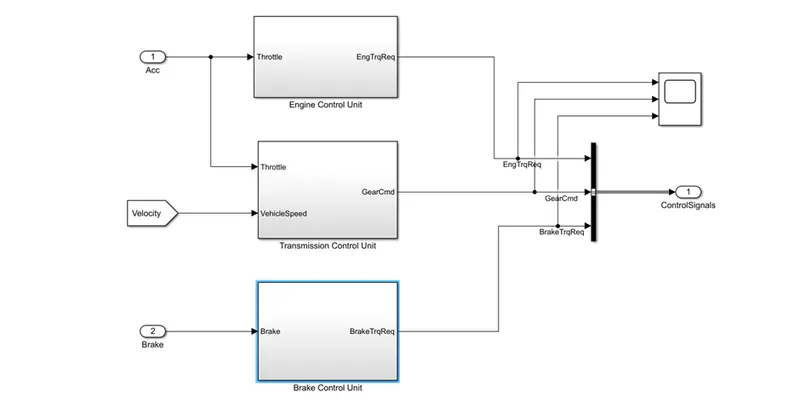
The Controller block represents the electronic control unit of the vehicle. It works based on the driver inputs, it generates desired engine torque, desired transmission gear, and desired brake torque. The outputs from the driver block which are the acceleration and brake pedal signals are passed on to the Controller block. The block has three subsystems namely, the Engine control unit, the Transmission control unit and the brake control unit whose outputs are fed to the powertrain block.
The figure below shows the output of scope block in the controller which shows the time traces of torque required which is output of engine control unit, gear command the output of transmission control unit and the brake torque required the output of brake control unit.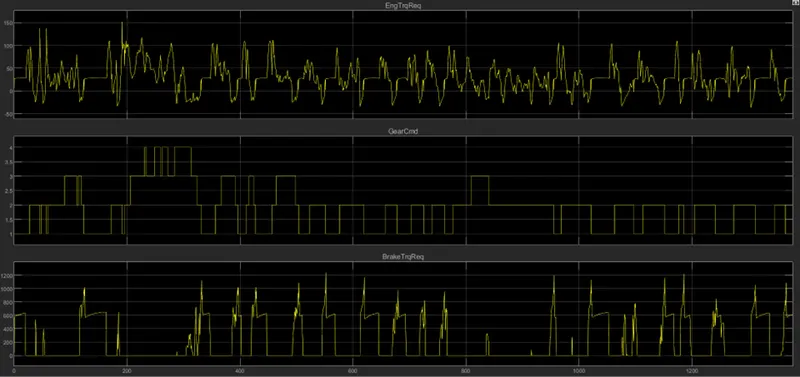
Engine Control
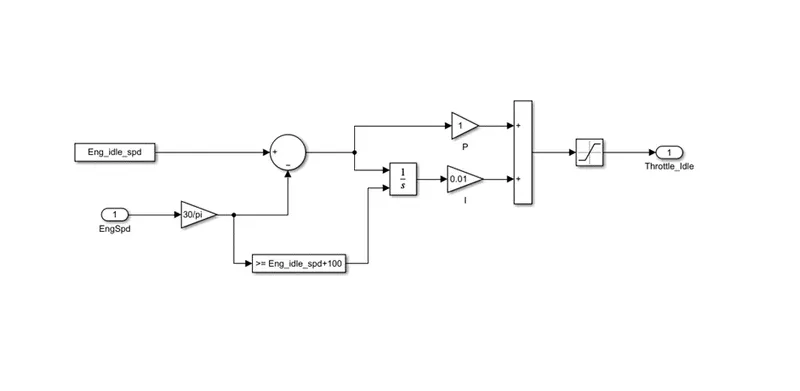
The engine control unit takes the input throttle which is the accelerator output from the driver block. This input is added to the output from the idle speed controller subsystem, which basically maintains the engine speed not to drop below the engine idle speed.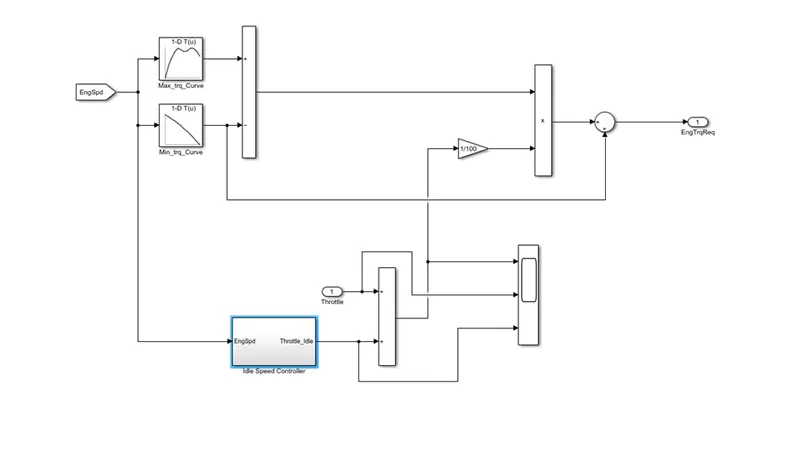
Idle speed controller also has a PI controller to maintain the engine speed. The engine control unit takes the feedback of engine speed and then generates the torque required as output.
Idle Engine Speed controller
Transmission Control
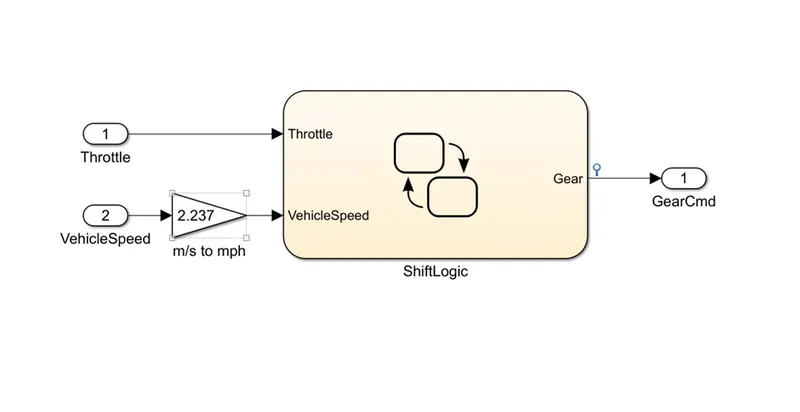
The transmission control unit takes the inputs such as throttle and vehicle speed and provides the output as gear command which indicates the gear at which the vehicle is operating. This subsystem uses a Stateflow which is shown as a shiftlogic in the above figure.
Shift logic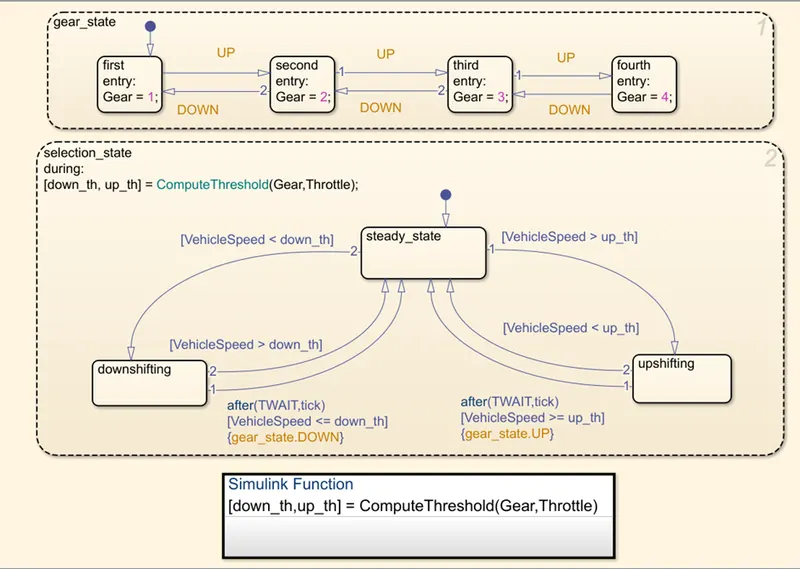
Stateflow is a graphical environment for decision logic modelling, the gear state is a super state and the selection state is the substate. The gear state has four states representing the four gears of the vehicle. The substate selection state is entered and based on the logic whether the vehicle speed is greater or lesser the transition occurs. If the vehicle speed is greater than the up threshold then the transition (UP) occurs and the gear shifts to the next state (i.e., from gear1 to gear2). Similarly, the transition (DOWN) occurs if the vehicle speed is less than the down threshold. These thresholds are specified as s SIMULINK function.
Brake Control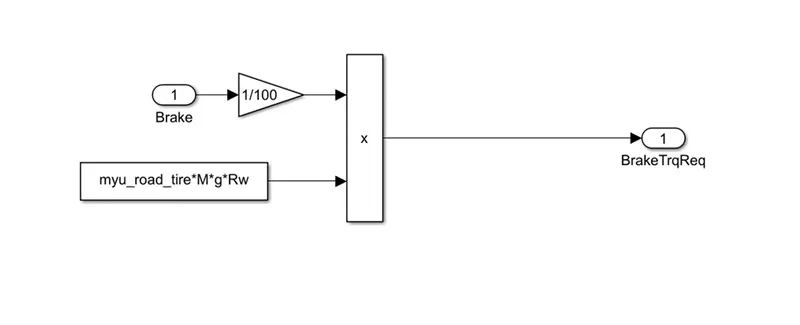
The Brake pedal signal from the driver block is multiplied by the maximum friction, which gives the maximum braking torque. The required break torque is calculated as output.
Power Train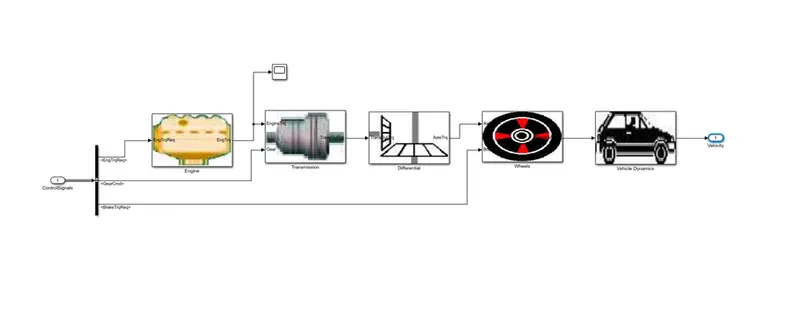
The Powertrain block consists of five subsystems mainly Engine, Transmission, Differential, Wheels and Vehicle Dynamics. The inputs to the powertrain is given by the outputs from the controller block such as the engine torque required is fed to the engine block and the gear command is fed to the transmission block and the brake torque required is fed to the wheels. The output from the powertrain block is the velocity which is fed back to driver block as a feedback.
Engine
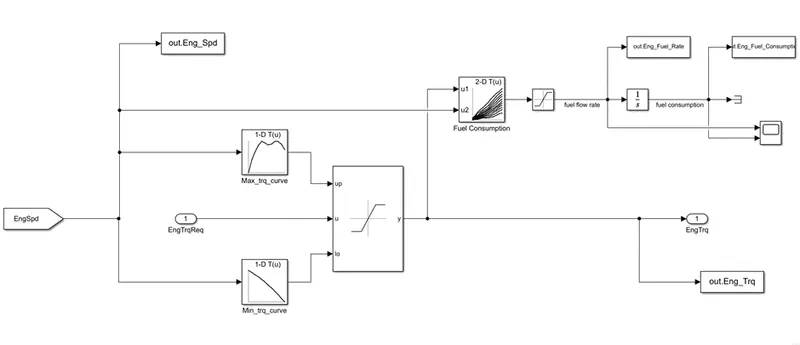
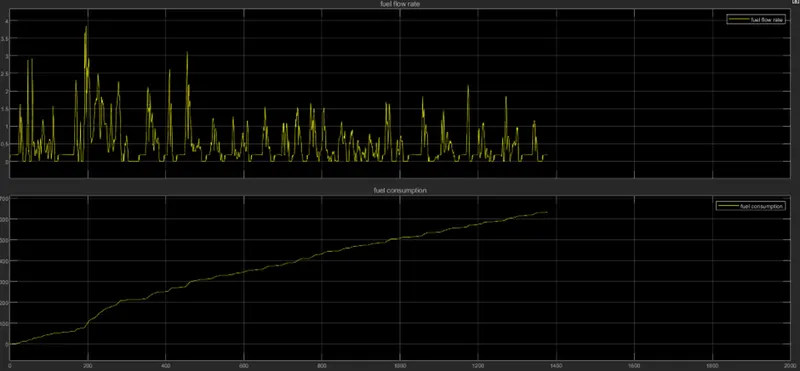
The engine block takes the input as engine torque required from the engine control unit and it is compared with the maximum and minimum torque and maintained between the required range using the dynamic saturation block. Further, with both the engine torque and the engine speed the fuel consumption rate is found through a 2-D lookup table. The saturation block is implemented to take only the positive values. On integrating the engine fuel consumption is determined which is sent to the MATLAB workspace for plotting purposes. The scope block shows the time trace of fule flow rate and engine fuel consumption which is shown below.
Transmission
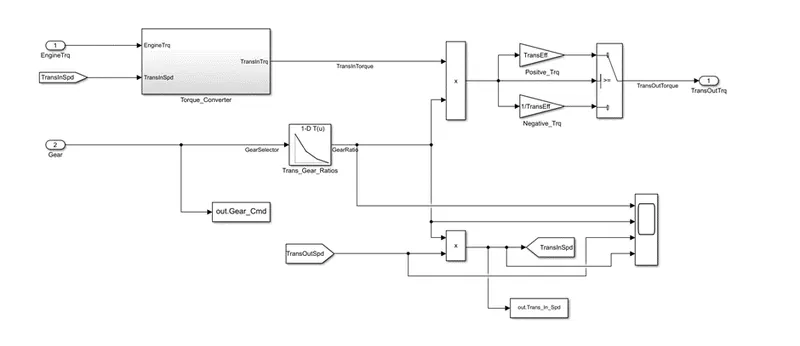
The transmission block takes the input as engine torque from the output of the engine block and the gear as input from the transmission control unit. Further, the signal is passed to the torque converter block which gives out transmission in torque for the selected gear the gear ratio is multiplied to the output from torque converter.
Torque converter
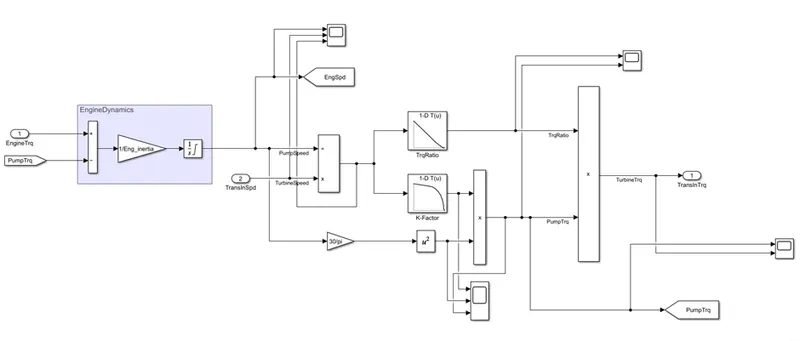
It takes the inputs as engine torque transmission in speed further the turbine speed is divided by the pump speed on further calculations the turbine torque is determined which is given out as transmission in torque.
Differential
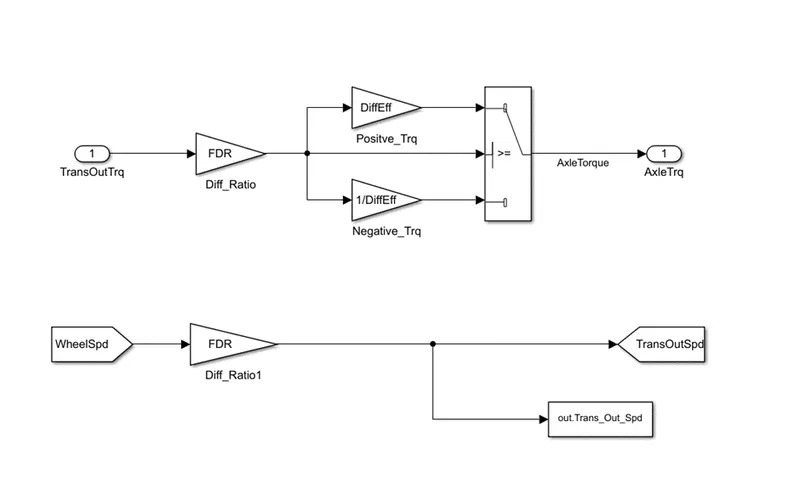
The Differential block takes the input as transmission out torque and computes it by multiplying with differential ratios and the output is given as axle torque. In the same block the transmission out speed is calculated by multiplying the wheel speed with the differential ratio.
Wheels
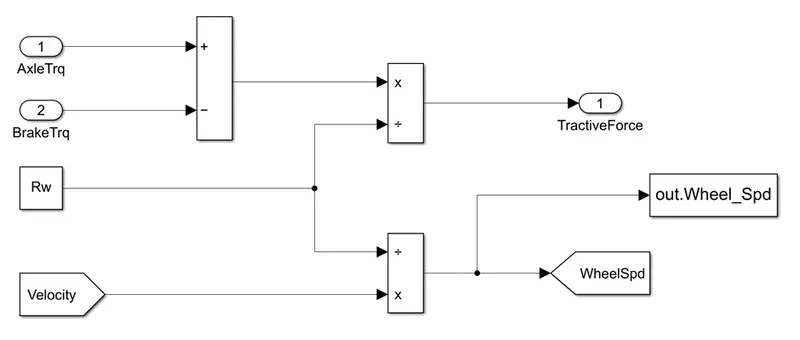
The wheels take the inputs as axle torque and brake torque, where the brake torque is subtracted from the axle torque and divided the rolling friction constant to get Tractive force as output. Similarly on dividing the velocity by the rolling friction constant gives the wheel speed.
Vehicle Dynamics
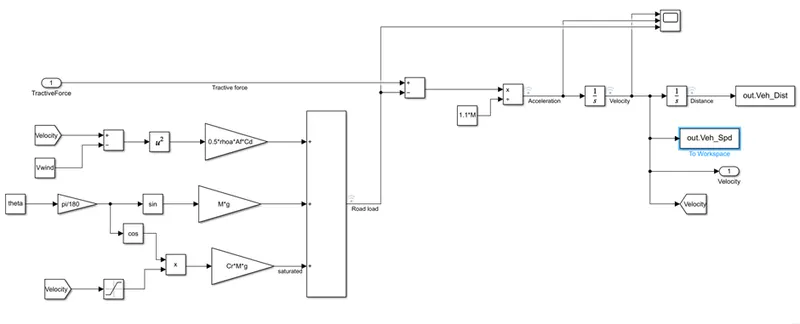
The output from the wheels block which is the tractive force is subtracted by the road load, further on dividing by mass the acceleration is obtained. On integrating the acceleration the velocity is obtained and further integrating it will provide the distance travelled.
The equation for modelling the vehicle dynamic block is shown below,
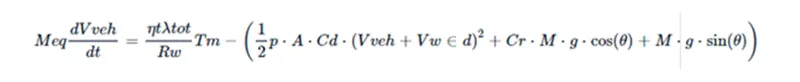
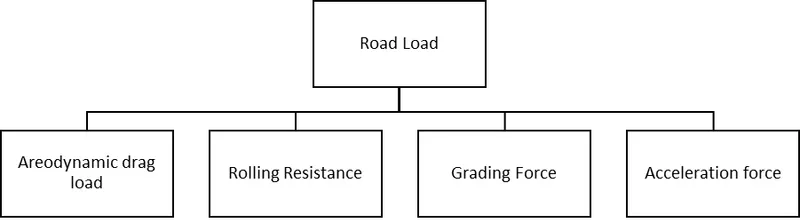
The input variables and system parameters that would be required to calculate the power requirement and energy consumption of the system.
The aerodynamic force is given by,
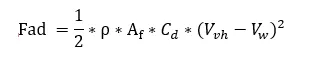
Fad = Aerodynamic drag force
ρ = Density of air
Af = Frontal area
Cd = Drag coefficient
Vvh = Vehicle velocity
Vw = Wind velocity
The Rolling resistance is given by,
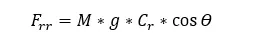
Frr = Rolling force
M = Mass of the vehicle
g = acceleration due to gravity
Cr = rolling coefficient
ϴ = angle of inclination
The grade force is given by,
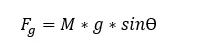
Fg = Grading force
M = Mass of the vehicle
g = acceleration due to gravity
ϴ = angle of inclination
Acceleration force is given by,
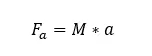
Fa = Acceleration force
M = Mass of the vehicle
a = acceleration
MATLAB Post processing code
The SIMULINK model is executed and in order to analyse and plot the required plots the MATLAB script shown below is executed. The outputs from the SIMULINK model are stored in variables in MATLAB and the same are used for plotting.
%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%
%% Skill-Lync -> Hybrid Drives Development
% Project 1 - Conventional Vehicle Model


% Description:
% The following file is to used with the Initialization file and Simulink
% results for post-processing of the data.
% The file is incomplete, has some examples of how the data is imported
% into a readable format, data analysis and plotting examples.
% Based on the project task, use commands in a similar format as given
% below, to analyse the data and generate required plots.
% You can change variable names if desired

%% Post-Processing File
%  File for post-processing the Conventional vehicle simulation model data
close all
clc
%% Renaming variables
Time = out.tout;
Acc_Pdl = out.Acc_Pdl;          % Accelerator pedal [%]
Brk_Pdl = out.Brk_Pdl;          % Brake pedal [%]
Gear_Cmd = out.Gear_Cmd;        % Transmission gear
Trans_In_Spd = out.Trans_In_Spd*30/pi;  % Transmission input speed [rpm]
Trans_Out_Spd = out.Trans_Out_Spd*30/pi;% Transmission output speed [rpm]
Eng_Trq = out.Eng_Trq;          % Engine brake torque [Nm]
Eng_Spd = out.Eng_Spd*30/pi;    % Engine speed [rpm]
Eng_Fuel_Consump = out.Eng_Fuel_Consumption;    % Engine fuel consumption [g]
Veh_Dist = out.Veh_Dist/1000;   % Distance traveled by vehicle [km]
Veh_Spd = out.Veh_Spd*18/5;     % Vehicle speed [kmph]
Wheel_Spd = out.Wheel_Spd*18/5; % Wheel speed [kmph]
Fuel_rate = out.Eng_Fuel_Rate;  % Fuel flow rate
Fuel_consumption = out.Eng_Fuel_Consumption; % Fuel consumption
Desired_Spd = out.Desired_Spd;  % Desired Speed
Actual_Spd = out.Actual_Spd;    % Actual Speed


%% Data Analysis
Eng_Pwr = Eng_Spd*pi/30.*Eng_Trq/1000;   % Engine brake power [kW] % Element wise operator added
rho_petrol = 0.7197;                    % Density of petrol [kg/L]
kmpl = Veh_Dist(end)/(Eng_Fuel_Consump(end)/1000/rho_petrol);    % Fuel economy [kmpl]


%% Plotting vehicle characteristics time trace
figure('name',"Time Traces")
hold on
grid on
plot(Time,Eng_Spd,'LineWidth',1,'color','b')
plot(Time,Trans_In_Spd,'LineWidth',1,'color','r')
plot(Time,Trans_Out_Spd,'LineWidth',1,'color','g')
plot(Time,Wheel_Spd,'LineWidth',1,'color','m')
xlabel('Time')
legend('Engine Speed','Trans In Speed','Trans Out Speed','Wheel Speed')

figure()
subplot(4,1,1)
hold on
grid on
plot(Time,Eng_Trq,'LineWidth',1,'color','k')
xlabel('Time')
ylabel('Eng Trq')
xlim([0, Time(end)]);
title('Engine Torque')

subplot(4,1,2)
hold on
grid on
plot(Time,Eng_Pwr,'LineWidth',1,'color','k')
xlabel('Time')
ylabel('Eng Power')
xlim([0, Time(end)]);
title('Engine Power')

subplot(4,1,3)
hold on
grid on
plot(Time,Fuel_rate,'LineWidth',1,'color','k')
xlabel('Time')
ylabel('Fuel rate')
xlim([0, Time(end)]);
title('Fuel Rate')

subplot(4,1,4)
hold on
grid on
plot(Time,Fuel_consumption,'LineWidth',1,'color','k')
xlabel('Time')
ylabel('Fuel consumption')
xlim([0, Time(end)]);
title('Fuel Consumption')

figure()
subplot(3,1,1)
hold on
grid on
plot(Time, Acc_Pdl, 'linewidth', 1, 'Color', 'black');
plot(Time, Brk_Pdl, 'linewidth', 1, 'Color', 'red');
ylabel('Pedal [%]')
xlim([0, Time(end)]);
legend('Accel','Brake');
subplot(3,1,2)
hold on
grid on
plot(Time, Trans_In_Spd, 'linewidth', 1, 'Color', 'black');
plot(Time, Trans_Out_Spd, 'linewidth', 1, 'Color', 'red');
ylabel('Speed [rpm]')
xlim([0, Time(end)]);
ylim([0, 6000]);
legend('Trans Input','Trans Output');
subplot(3,1,3)
hold on
grid on
plot(Time, Gear_Cmd, 'linewidth', 1, 'Color', 'black');
xlim([0, Time(end)]);
xlabel('Time [s]');
ylabel('Gear');

figure()
subplot(2,1,1)
hold on
grid on
plot(Time, Desired_Spd, 'linewidth', 1, 'Color', 'r');
plot(Time, Actual_Spd, 'linewidth', 1, 'Color', 'b');
xlabel('Time [s]');
ylabel('Speed');
legend('Desired Speed','Actual Speed')
title('Desired Speed vs Actual Speed')

subplot(2,1,2)
hold on
grid on
plot(Time, Veh_Dist, 'linewidth', 1, 'Color', 'black');
xlabel('Time [s]');
ylabel('Distance [km]');
title('Distance vs Time')


%% Plotting engine operating points on engine fuel map
figure('Name','Engine Operating Points');
hold on
grid on
title('Engine Operating Points','fontsize',12);
p1=plot(Eng_map_spd*30/pi,Eng_max_trq,'linewidth',2,'color','r');
p2=line([Eng_map_spd(end)*30/pi Eng_map_spd(end)*30/pi],[0 Eng_max_trq(end)]);
set(p2,'linewidth',1,'linestyle','--','color','k');
p3=line([Eng_map_spd(1)*30/pi Eng_map_spd(1)*30/pi],[0 Eng_max_trq(1)]);
set(p3,'linewidth',1,'linestyle','--','color','k');
[c,h] = contour(Eng_map_spd'*30/pi,Eng_map_trq,Eng_fuel_map');
clabel(c,h);
xlabel('Engine Speed [rpm]');
ylabel('Engine Torque [Nm]');
title('Engine Fuel Consumption Map [g/s]');
p4 = plot(Eng_Spd,Eng_Trq,'.','MarkerSize',0.1,'color','k');
legend([p1 p4],{'Max Curve','Operating Points'});
axis([Eng_map_spd(1)*30/pi Eng_map_spd(end)*30/pi 0 Eng_map_trq(end)]);

fprintf('Fuel economy for the selected cycle is: %f kmpl',kmpl)
On executing the above script for UDDS drive cycle
- Time trace for engine, transmission input, transmission output and wheel speeds.
- Plotting engine torque, engine power, fuel rate and fuel consumption.
- Plotting accelerator and brake pedal, gear command, vehicle desired and actual speed, vehicle distance.
- Plotting the engine operating points on the engine fuel map.
The same set of plots for the HWFET drive cycle gives outputs as,
- Time trace for engine, transmission input, transmission output and wheel speeds.
- Plotting engine torque, engine power, fuel rate and fuel consumption.
- Plotting accelerator and brake pedal, gear command, vehicle desired and actual speed, vehicle distance.
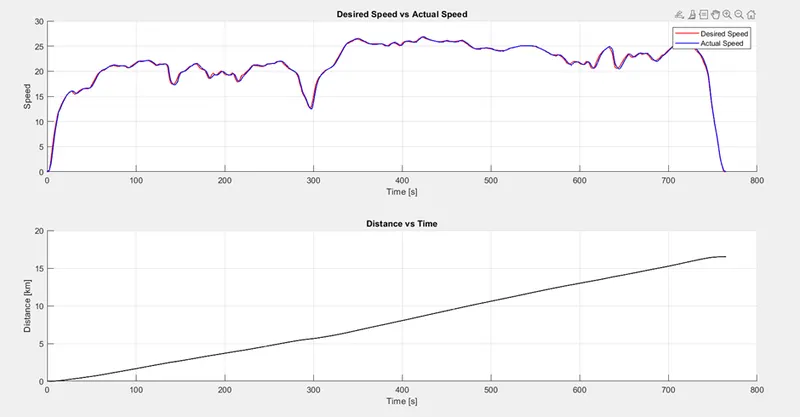
- Plotting the engine operating points on the engine fuel map.
CONCLUSION:
The forward energy-based fuel consumption model of a conventional vehicle is modelled using SIMULINK. And the required plots are plotted for both the mentioned drive cycles (i.e., UDDS and HWFET). The fuel economy for the respective cycles are mentioned below,
1. UDDS: 13.633082 kmpl
2. HWFET: 16.307528 kmpl
From the plot of the engine, transmission in, transmission out and wheel speeds we can see that the engine produces the max speed and due to some losses the transmission in speed is reduced and due to transmission losses the transmission out speed is less than the in speed and finally due to the road load factor the wheel speed is very less when compared other speeds.
The gear vs time indicates the vehicle gear at that particular time period, and from the fuel flow rate, engine power and torque plot it is clearly visible that fuel flow rate increases as power and torque increases. In the plot of pedal % of accelerator and brake we can see when the brake is applied the spike of the brake curve increases and the same of accelerator pedal decreases.
In the plot of actual speed vs desired speed it is seen that our model traces the desired speed and the overshoot and under shoots are minimal.
And finally, the engine operating points are plotted on the engine fuel consumption map all the operating points fall below the max curve and within the range.
REFERENCES: