Project 1
AIM
Develop a double-acting actuator model using Simscape Multibody and Simscape components.
OBJECTIVE
The hydraulic system must be modelled using Simscape library physical components, and the mechanical system of the cylinder must be constructed using Simscape Multibody library components/blocks.
THEORY
The following Cylindrical Model Schematic shows the three different configurations of the piston
Half Retracted, Fully Retracted, Fully Extended
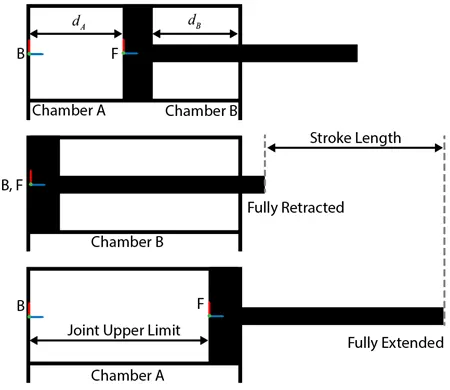
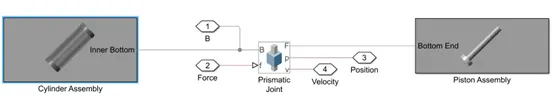
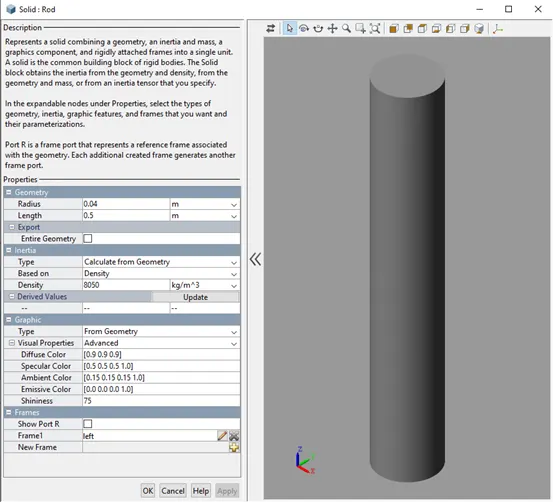
Simscape Multibody allows you to model the system's mechanical component. The Revolved Solid (Simscape Multibody) and Cylindrical Solid (Simscape Multibody) blocks, for instance, can be used to depict the cylinder and piston. Use a Prismatic Joint (Simscape Multibody) block to provide the piston the translational degree of freedom. The base frame (B) and follower frame (F) of the joint can be attached to the centres of the left inner surface of chamber A and the left surface of the piston, respectively, to make it simple to compute the lengths of chambers A and B. Make sure that chamber B is in the centre of both the B and F frames' Z-axes.
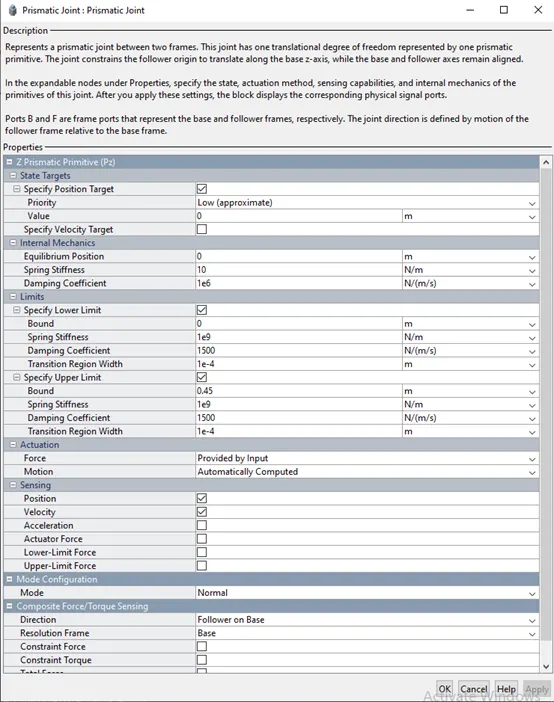
The length of the chamber A, denoted by the letter dA, is the joint block's output position, and the length of the chamber B, denoted by the letter dB, is equal to the difference between the stroke length and dA. You can set the top and lower position limitations of the Prismatic Joint block to make sure the piston doesn't go past the cylinder's ends.
The schematics show the cylinder in three configurations: half-retracted, fully retracted, and fully extended.
DOUBLE-ACTING HYDRAULIC ACTUATOR SYSTEM
Hydraulic cylinder with dual actions Linear hydraulic actuators called double-acting hydraulic cylinders use hydraulic pressure to move in both directions. In double-acting cylinders, the piston stroke is significantly longer than in single-acting cylinders.
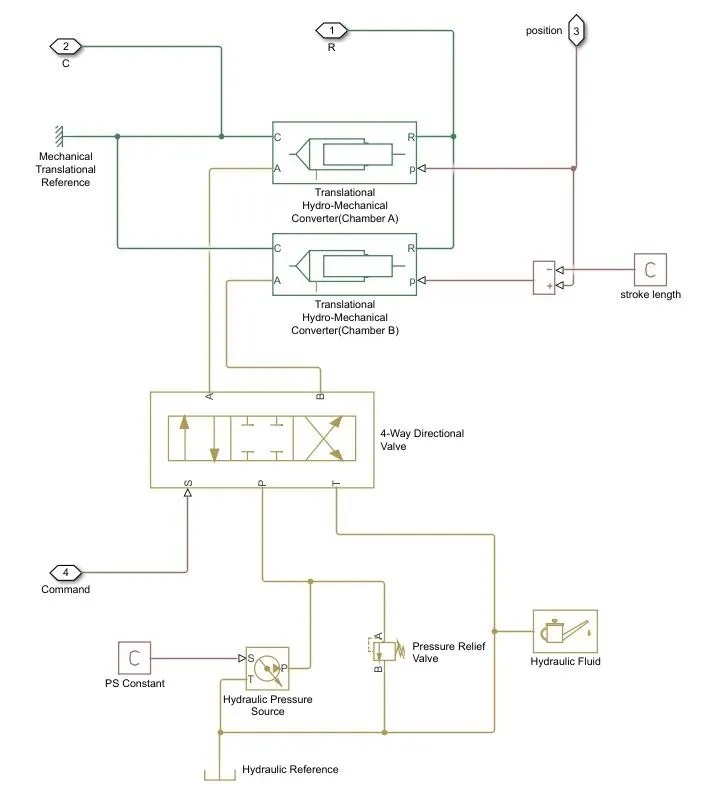
The block schematic for the double-acting cylinder model is shown in this picture. The example models the cylinder's chambers A and B using two Translational Mechanical Converter (IL) blocks. The Translational Mechanical Converter (IL) blocks and the Prismatic Joint block are connected by a Translational Multibody Interface block. For further information on how to utilise the Translational Multibody Interface block, see Connecting Simscape Networks to Simscape Multibody Joints.
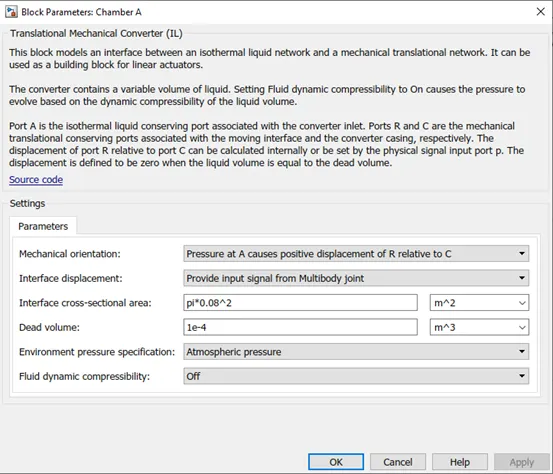
The cylinder is moved from zero to stroke length in chamber A by a tension at port A. The displacement of the cylinder corresponds to the Prismatic Joint block's position outcome. Showing room A
Connect the individual ports C and R of the top Translational Mechanical Converter (IL) block to the ports C and R of the Translational Multibody Interface block.
Set Provide input signal from Multibody joint to empower port p under Interface removal in the Translational Mechanical Converter (IL) block.
The Translational Mechanical Converter (IL) block and the Prismatic Joint block both have interface ports.
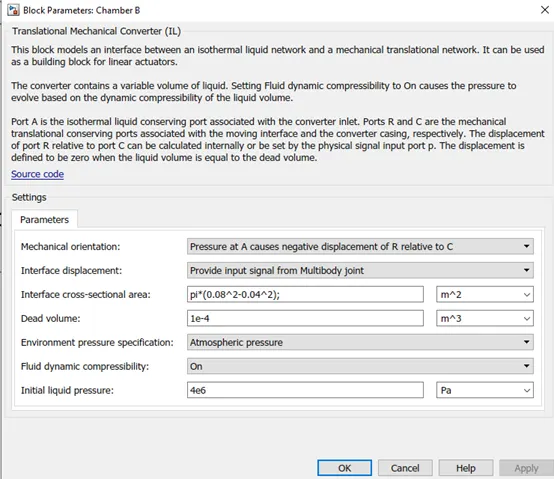
The pressure at port A moves the cylinder in chamber B from 0 to negative stroke length. The information position sign of the lower Translational Mechanical Converter (IL) block's information position sign should then have an offset added to it, and the default direction should be changed. The offset becomes closer to - dB.
When the Mechanical direction is set to Pressure at A in the lower Translational Mechanical Converter (IL) block, R is negatively displaced with respect to C.
Configure the port p's interface uprooting to Provide input signal from Multibody joint.
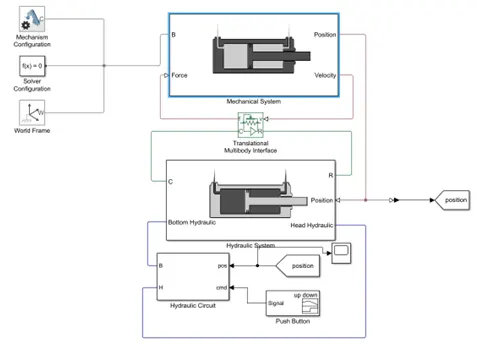
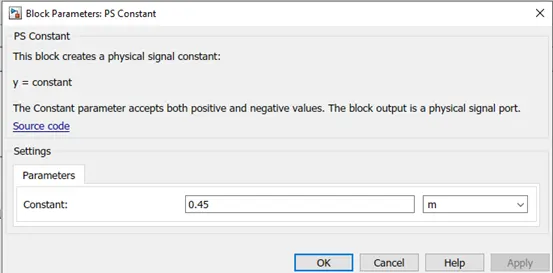
Add a PS Constant block and specify the steady as the chamber's stroke length.
As seen in the graph, add a PS Subtract block and then connect it to the PS Constant and Prismatic Joint blocks. Keep in mind that the PS Subtract block's output climbs to - dB.
To prevent the cylinder from moving:
Select the Specify Lower Limit and Specify Upper Limit bounds in the Prismatic Joint block's Limits segment.
The Bound boundary under the Specify Lower Limit section displays the base separation between the joint block's edges B and F. Choose 0 m for the bound border in this model.
The Bound border under "Specify Upper Limit" displays the largest separation between the Prismatic Joint block's outlines B and F. Determine the Bound boundary in this model as the stroke length of the chamber.
Applications for double acting chamber structures are diverse. A scissor lift device that raises and lowers the landfill bed, for instance, can be activated by a dump trailer's dual acting chamber. For more details, see Hydraulic Interface - Dump Trailer with Hydraulic Cylinder (Simscape Multibody). The mechanical and water-driven subsystems of the scissor raise are hidden beneath the cover of the Double-Acting Hydraulic Cylinder block and are connected via a Translational Multibody Interface block.
The two actuators in the pressure-driven subsystem, Head Chamber and Bottom Chamber, which have the opposite settings for the Mechanical direction boundary, get position information from the mechanical subsystem's prismatic joint block. Given that the Head Chamber is at its most extreme stroke when the Bottom Chamber is at dead volume (where position p = 0), the Constant block C provides a position signal offset to the Head Chamber actuator.
DOUBLE-ACTING HYDRAULIC CYLINDER
A mechanical device called a hydraulic cylinder uses hydraulic pressure to create pressure. They are frequently utilised in a variety of industrial applications as well as hydraulic pumps. They can be employed as actuators or lifting tools, among other things.
The mechanical device known as a double-acting hydraulic cylinder controls pressure by means of two chambers. The user can choose to selectively fill each chamber with pressurised fluid using control valves on each end of the device. As a result, the cylinder can be operated in one of two ways: either by pushing or drawing the lever in the same direction (which mimics the first action of a basic hydraulic cylinder), or by doing the opposite (resembling the second act of a simple hydraulic cylinder).
The cylinder will maintain pressure in one of the chambers in the event of a hydraulic failure until the oil supply is restored, preventing any damage or injuries. Two categories of double-acting cylinders exist:
- Double-acting cylinder with a piston rod on one side.
- Double-acting cylinder with a piston rod on both sides.
APPLICATIONS
- Industrial processes that need a rapid force frequently use double-acting hydraulic cylinders.
- Power steering is accomplished by double-acting cylinders, and the more potent the vehicle, the more power is required to steer it.
- This kind of cylinder is frequently seen in heavy-duty devices like cranes, forklifts, lifts, and other industrial machinery.
- Hydraulic systems that raise and lower items like landing gear, door hinges, etc. require double-acting cylinders.
- A double-acting hydraulic cylinder is frequently used to open or close a type of "flap" on an aeroplane wing.
WORKING
One chamber of a double-acting hydraulic cylinder is filled with oil, while the other is empty. Oil is forced into the empty chamber as the piston rod is withdrawn into the cylinder, creating pressure. The cylinder extends as a result of this pressure pushing the piston rod out. On the other side, a vacuum is produced when the piston rod is pressed into the cylinder and the oil is forced into the chamber that is already filled with oil. The piston rod retracts as a result of the vacuum pulling it into the cylinder. When the force is released in this way, the action is reversed. Double-acting hydraulic cylinders can be used to generate the necessary force to push or pull something.
Double-acting hydraulic cylinders perform two types of operations including:
- Differential types and
- Synchronous types.
DIFFERENTIAL TYPES HYDRAULIC CYLINDERS.
The most popular type of hydraulic cylinder is differential type. There are two pistons in it, one attached to the rod and the other to the body. The rod stretches as the input force rises. The second piston is locked into the cylinder at the same moment, keeping the body still. The output force rises as a result. The rod retracts when the input force lessens. The second piston is locked into the cylinder at the same moment, keeping the body still. The output force decreases as a result. As long as the input force and the output force are equal, the body will always stay in its starting position.
However, depending on whether of the two forces is greater, the rod will travel upward or downward. A hydraulic cylinder of the differential kind is therefore very helpful. For instance, you should utilise a rod attached to the cylinder's body to hoist a heavy box. A safety factor should be there to ensure that the rod's force is always greater than the weight of the thing being raised.
SYNCHRONOUS TYPES HYDRAULIC CYLINDERS.
Cylinders of the synchronous type operate on a different theory. An electrical signal is given to a valve, allowing oil to enter the cylinder and keep the piston moving up and down instead of oil pressure. When the signal is cut off, the piston comes to a stop and the oil stops pouring into the cylinder. As a result, the cylinder uses power quite effectively.
Hydraulic cylinders of the synchronous kind have just one piston. No matter how much hydraulic fluid is present in the cylinder, this piston will expand and compress simultaneously. This makes this kind of cylinder extremely effective but less potent than the other kind. This sort of hydraulic cylinder is typically utilised in automobiles, farms etc.
PHYSICAL MODEL
MECHANICAL SYSTEM
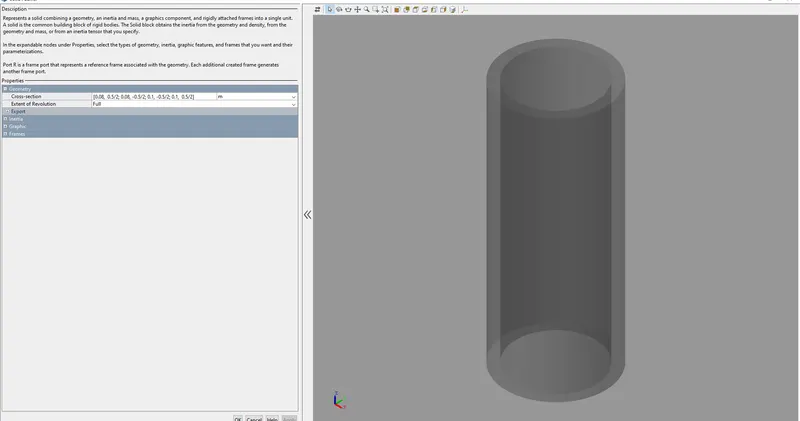
1.CYLINDER ASSEMBLY
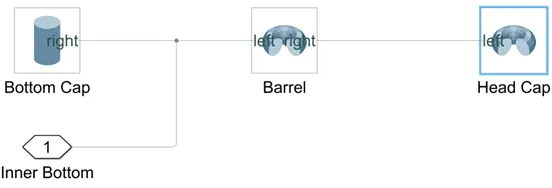
BOTTOM CAP
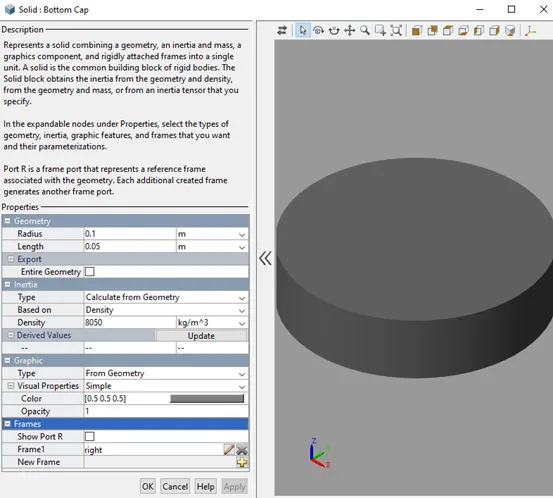
BARREL CAP
HEAD CAP
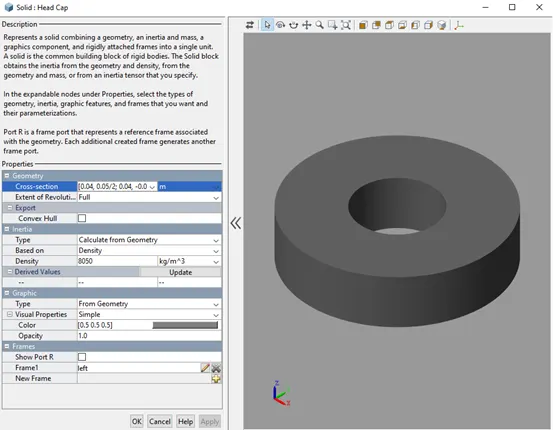
2. PRISMATIC JOINT
When referring to a prismatic joint, a slider is frequently used, as in "crank-slider linkage." This is an idealised example of a kinematic pair that illustrates how motions are restricted in machines.
A prismatic joint can be physically represented in many different ways, including slideways. To enable linear motion while avoiding rotation about the axis of movement, rectangular cross-sections can be utilised in conjunction with plain or rolling bearings.
Prismatic joints are often used to model hydraulic and pneumatic cylinders, though they may also allow rotation about their axis. Higher pairs and lower pairs are two categories for kinematic pairs. A ball or roller rolling over a surface is an example of a higher pair that involves point or line contact. Surface contact is a good way to picture lower pairs.
3. PISTON ASSEMBLY
The piston or plunger of hydraulic cylinders is propelled by the intake or outlet flow inside the barrel. The Rod contracts or expands as the Piston advances to either side of the cylinder.
These make up the fundamental hydraulic cylinders. The manufacturing of more cylinder types is more intricate. However, it is important to understand what these parts are and how they function because they are a necessary part of practically all hydraulic cylinders.
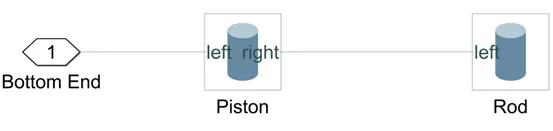
PISTON
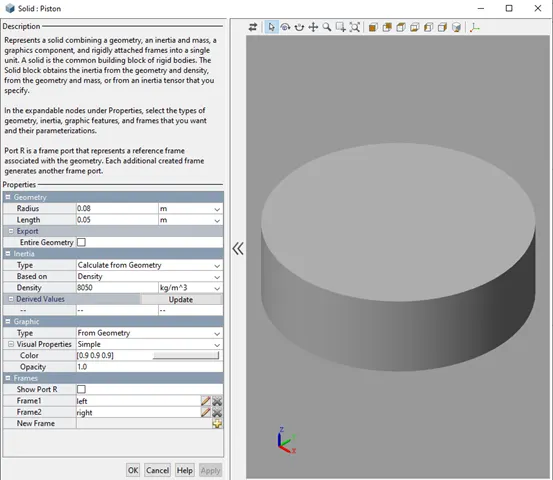
ROD
HYDRAULIC SYSTEM
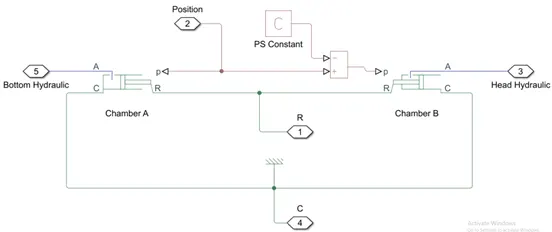
CHAMBER A
CHAMBER B
C
HYDRAULICS
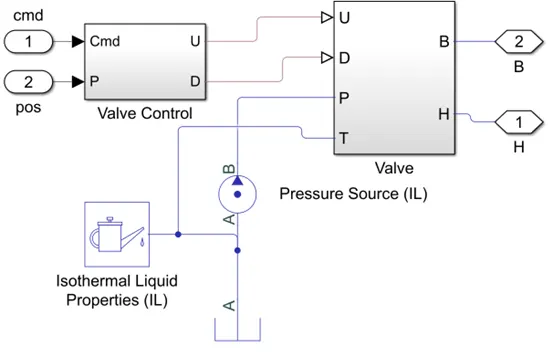
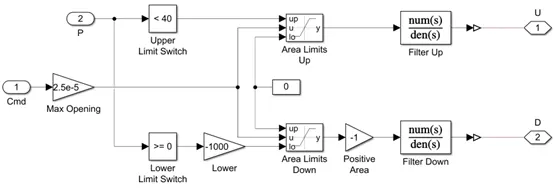
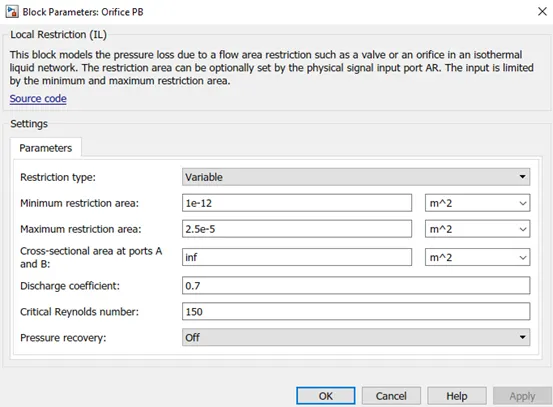
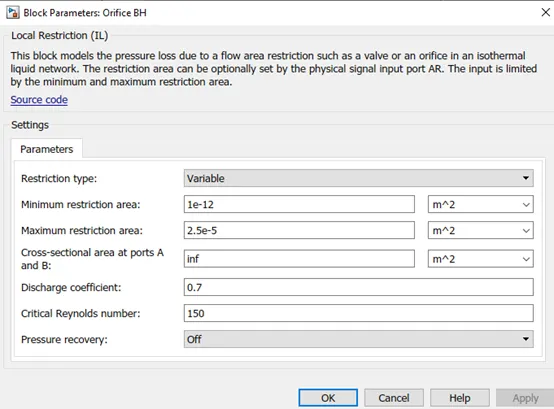
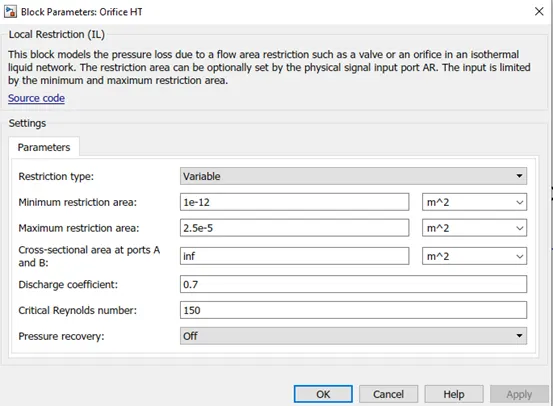
VALVE CONTROL
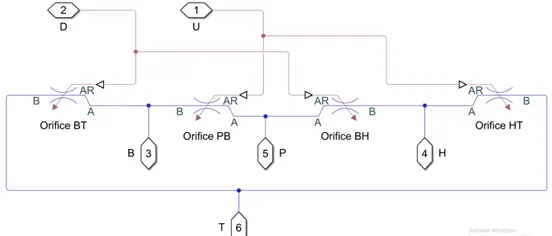
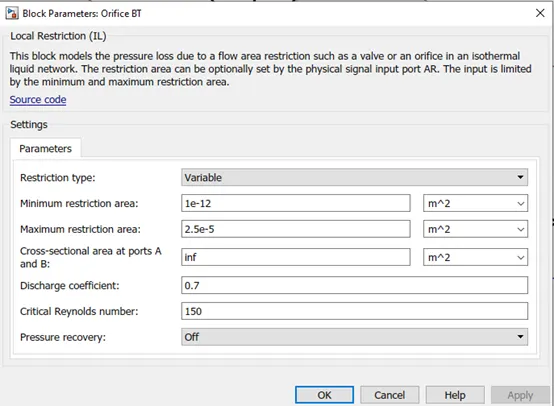
VALVE
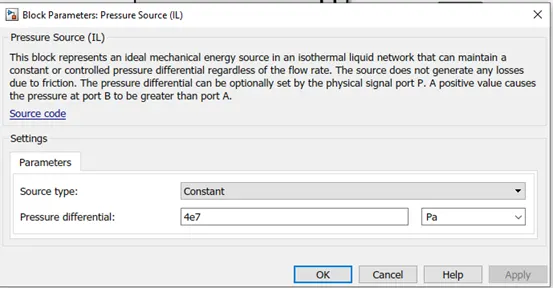
ISOTHERMAL LIQUID PROPERTIES.
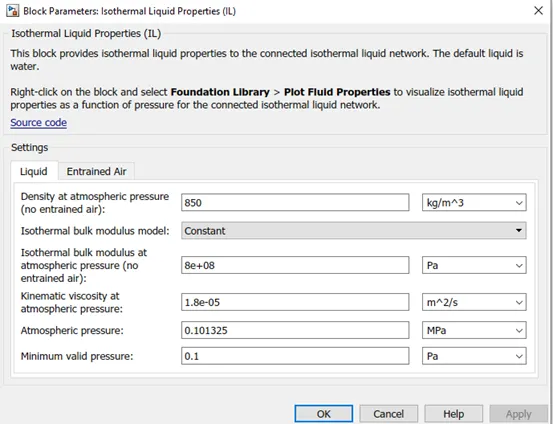
working fluid in the isothermal liquid domain consists of a liquid and a trace amount of entrained air. The proportion of non-dissolved gas that is entrained in the fluid is called entrained air. You can regulate the characteristics of liquids and air separately: You can select no entrained air at all.
RESULT
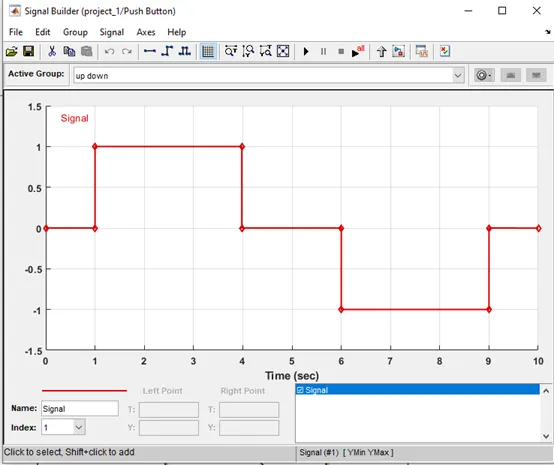
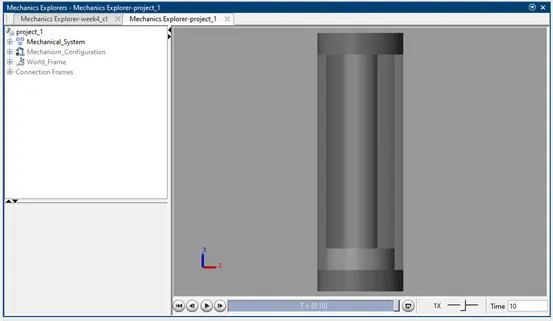
The animation of the acutuator can be observed while running the Simulink file attached below.
SIMULATION MODEL LINK
https://drive.google.com/file/d/1Oe3xoMjZgltoC9CYRq5MAnB6ep3e5a_N/view?usp=sharing