Final Project: Design of an Electric Vehicle
Design of an Electric Vehicle
AIM: To create a Matlab model of an electric vehicle which uses a battery and a DC motor
Objectives:
- To create a simple vehicle for low run time using Simulink components.
- To study the model parameters.
- To observe the model results and concluding their performances.
Introduction:
An electric car is a car that is propelled by one or more electric motors using energy stored in rechargeable batteries. Compared to internal combustion engine vehicles, electric cars are quieter, have no exhaust emissions, and lower emissions overall. Charging of electric cars can be done at a variety of charging stations, these charging stations can be installed in both houses and public areas.
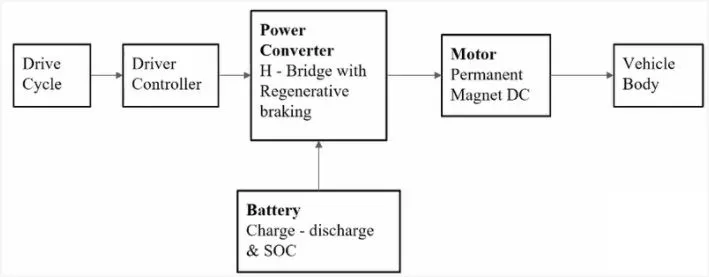
From the above block diagram, we will get an overall idea of the model of the vehicle. Now we can model the vehicle.
Model
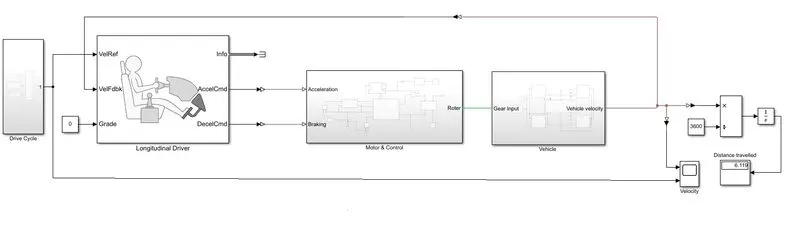
The above diagram represents the electric vehicle model which was created using Simulink components.
Drive Cycle: drive cycle is required to initiate the simulation, therefore the drive cycle is enabled in order to simulate the performance. It will act as a drive input for the iterations. The Drive cycle system which was created is
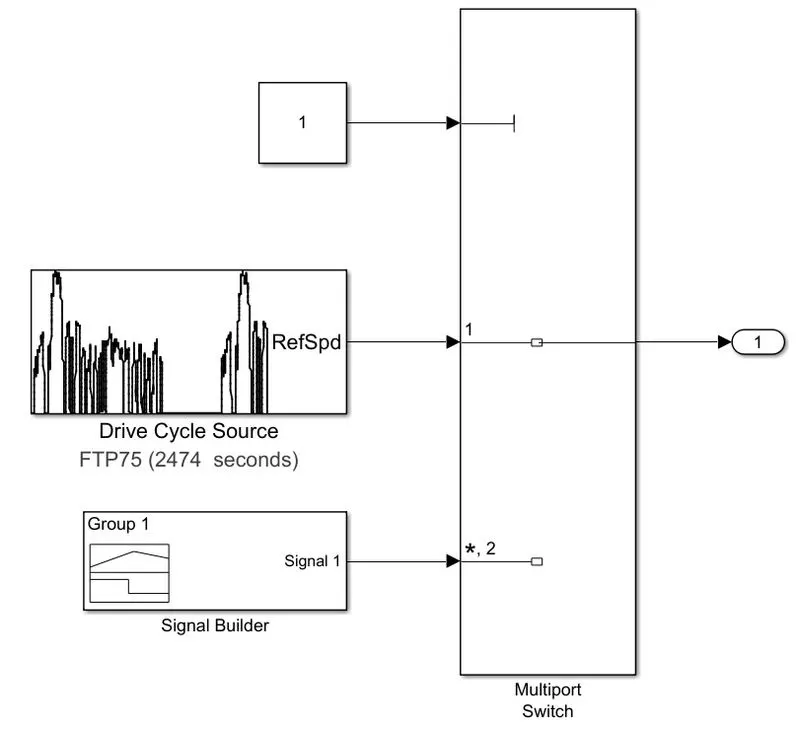
The Drive cycle consists of a drive cycle source and a signal builder. These two blocks are connected to a multiport switch so that we can select one of them. The drive cycle source block generates a standard longitudinal drive cycle. The block output is the vehicle longitudinal speed. Here we have selected the FTP75 cycle and it is given below.
Longitudinal Driver: it is a parametric longitudinal speed tracking controller for generating normalized acceleration and braking commands based on reference and feedback velocities. We have already given the reference velocity as a drive cycle. In this block, we can add any grade values if we want. Acceleration and braking outputs are connected to the motor controlling unit.
Motor unit:
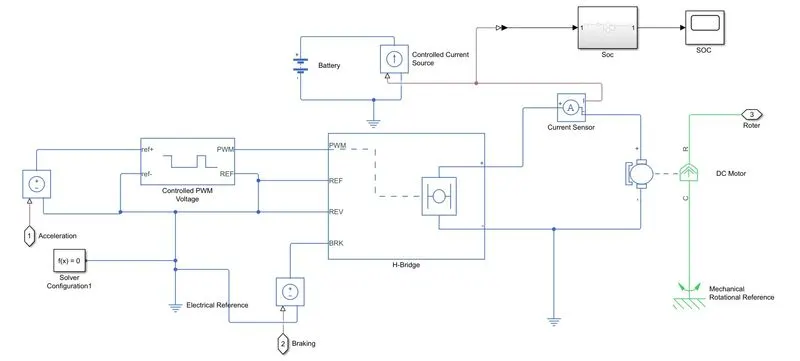
This subsystem drives according to the driver input. The above diagram represents the motor subsystem. And the parameters of the DC motor used in the subsystem is
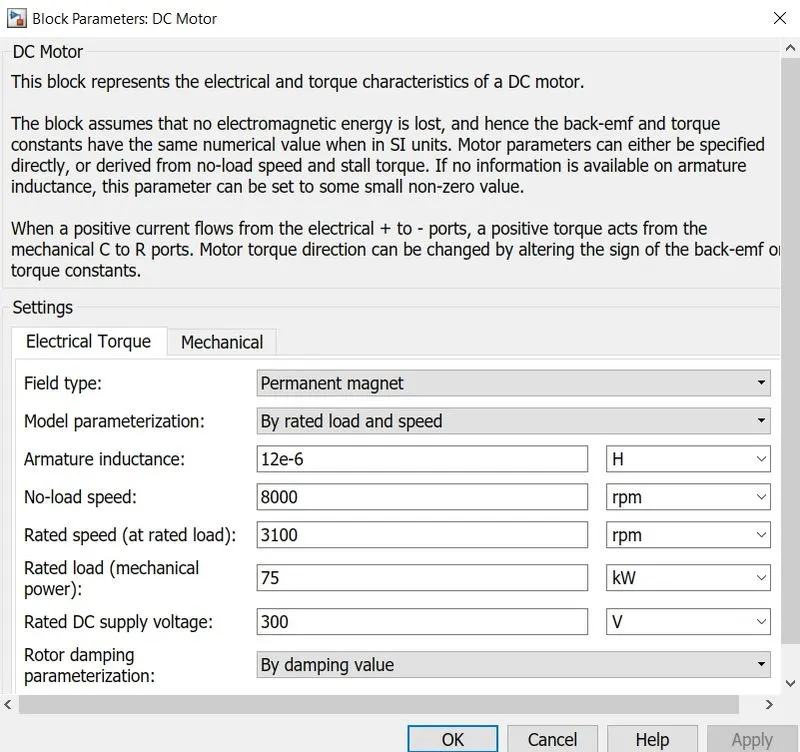
H-bridge block is used to control the DC motor block. H bridge block is driven by a controlled pulse width modulator voltage block. The average mode is selected in the PWM block. In averaged mode the PWM port voltage divided by the PWM signal amplitude parameter defines the ratio of the on-time to the PWM period, using this ratio and assumptions about the load, the block applies an average voltage to the load that achieves the correct average load current. Simulation mode parameters value for the controlled PWM voltage and H-bridge block same. If the REV port voltage is greater than the braking threshold voltage, then the output terminals are short-circuited via one bridge arm in series with the parallel combination of a second bridge arm and a freewheeling diode. Voltages at ports PWM, REV, and BRK are defined relative to the REF port. The parameters for the H bridge are given below.
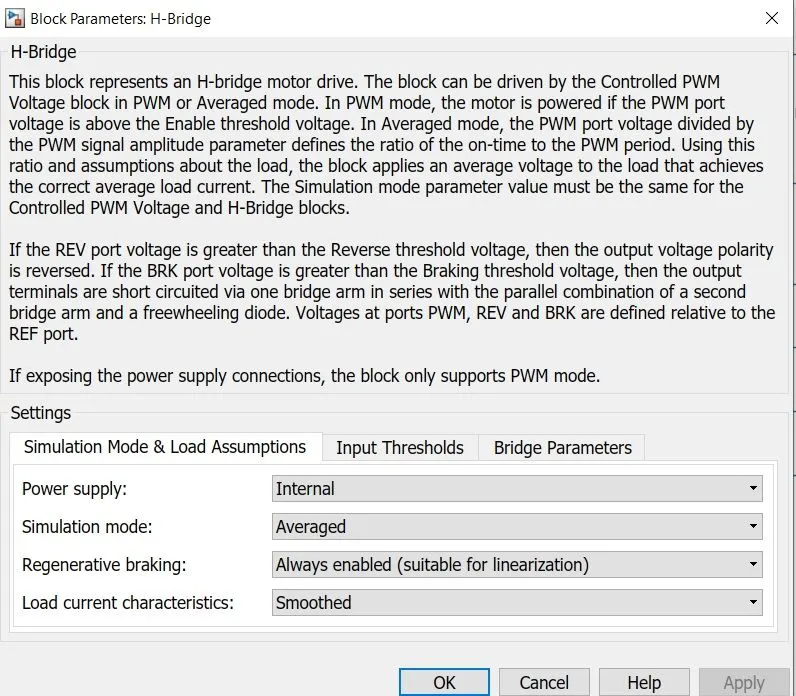
The PWM block will keep the output voltage zero when the pulse is low and equal, to the output voltage amplitude parameter when high. The duty cycle is set by the input value. A controlled current source is given to the modulator so that the power will not be used uncontrollably. The battery is also connected to the DC motor with a monitoring system for the battery.
State Of Charge (SOC): SOC is the level of charge of an electric battery relative to its capacity. This block is used to find out the level of battery after the vehicle completes the drive cycle. The system represents is given below.
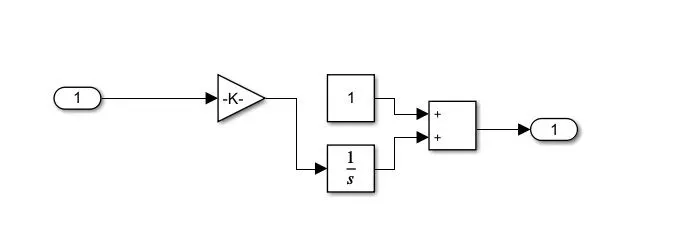
The rotor output of the motor is given as input to the gear system in the vehicle subsystem.
Vehicle:
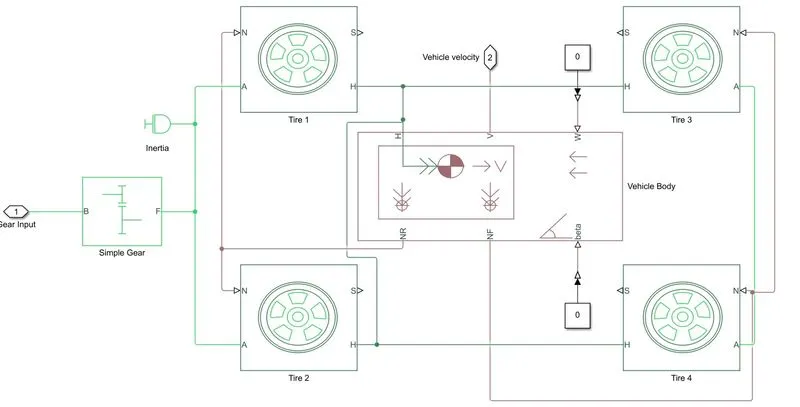
The vehicle subsystem represents the body of the electric car and its model is given above. The vehicle body block represents a two-axle vehicle body in longitudinal motion. The block accounts for body mass, aerodynamic drag, road incline, and weight distribution between axles due to acceleration and toad profile. Connection H is the mechanical translational conserving port associated with the horizontal motion of the vehicle body. The resulting traction motion developed by tires is connected to this port. Connections V, NF, and NR are physical signal output ports for vehicle velocity and front and rear normal wheel forces, respectively. The vehicle body parameters represented below.
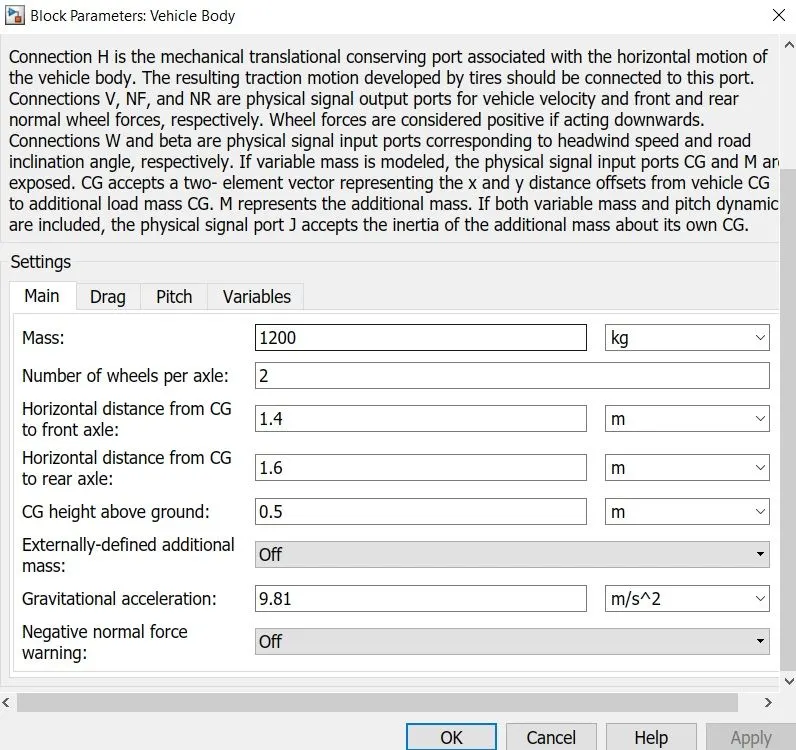
Connections W and beta are physical signal input ports corresponding to wind speed and road inclination angle, respectively. Gear input is given to the wheel blocks. We will get the vehicle velocity from the output port and it is given to the longitudinal driver block as feedback velocity. The feedback and reference velocities are connected to a scope block so that we can compare them. Output velocity is also integrated and converted to distance in kilometers by an integrator block.
Results:
The results obtained from the simulation are given below.
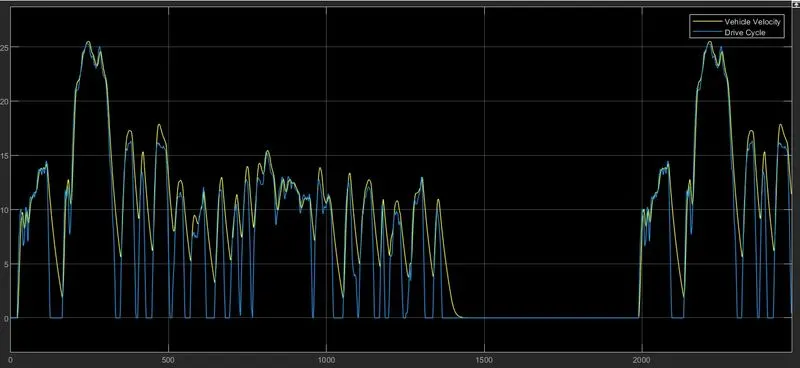
From the plot, it represents which follows the drive cycle. but while observing the results at some moments speed of the vehicle tends to be more than the given input drive cycle, and whereas in someplace vehicle needs some time to attain the minimum velocity more than the given input drive cycle. the vehicle came to rest with a drive cycle only when there was sufficient time. The maximum speed of the drive cycle is 25.35m/s. from the plot, the vehicle demands little more than that. If we look at the deceleration, the vehicle takes more time to reduce its speed because of its inertia. Now we can look into the distance traveled by the vehicle. It is obtained from the display which was connected.
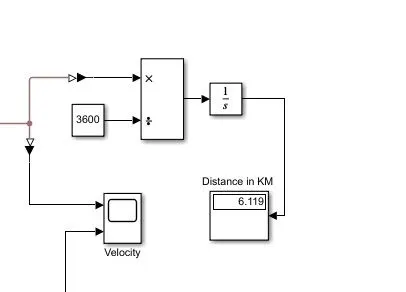
The distance traveled by the vehicle is obtained by a display, from which it is observed that vehicle traveled around 6km. the average speed of the drive cycle was 9.5m/s. so with this speed vehicle traveled 6 km until the battery drained out.
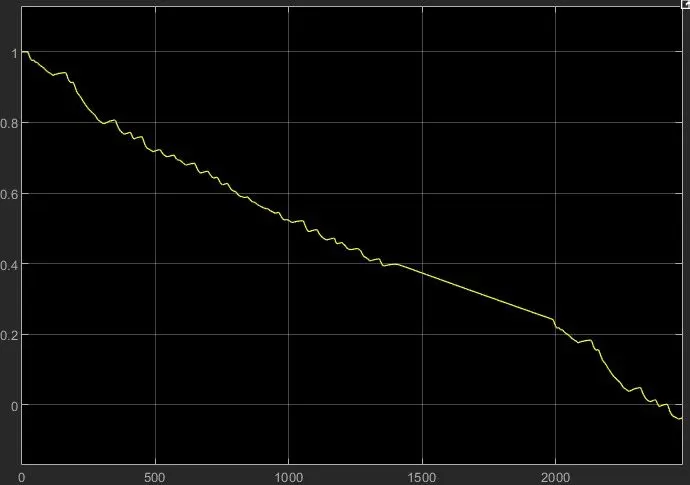
The above diagram represents the SOC plot, the deflection in the horizontal direction represents regenerative braking.
Conclusions:
A simple and low run-time vehicle model using Simulink components is created. The simulated model is able to run 6km, and performance parameters are studied, and obtained results are observed. We can obtain a better-performing vehicle by changing the parameters.
The Matlab file of this model is uploaded to google drive and the access link to the file is https://drive.google.com/file/d/1tsKENikzSR3vWbIfV697pJ9Hmb1_U945/view?usp=sharing