Final Project: Design of an Electric Vehicle
ANSWER :
INTRODUCTION:
The electric vehicle is one that operates on an electric motor instead of an internal combustion engine that generates power by burning a mix of fuel and gaes. EVs use electricity to change their batteries instead of using fossil fuels like petrol or diesel. they use an electric motor for propulsion . the most commonly used motor are three phase induction motor and permanent magnet synchronous motors.
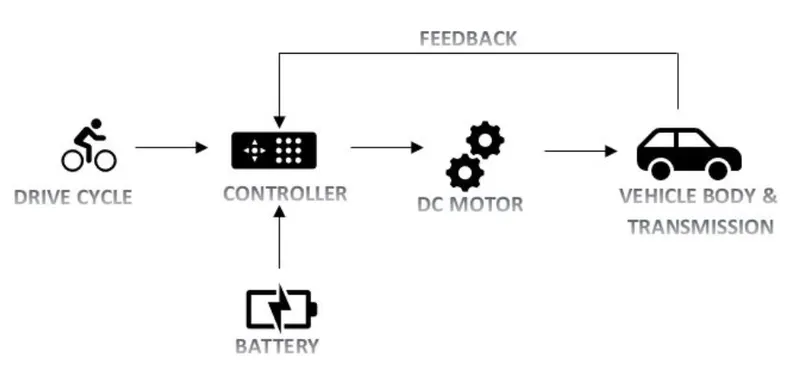
In the designed EV model, the main blocks are drive cycle, controller, DC motor, Vehicle body and Battery. Drive cycle is the driving pattern for which this model is going to be tested or evaluated. The main objective here is to obtain the speed attained by the driver, the SOC (state of charge), distance travelled by the vehicle.
MATLAB MODLE :
VEHICLE :
vehicle body :
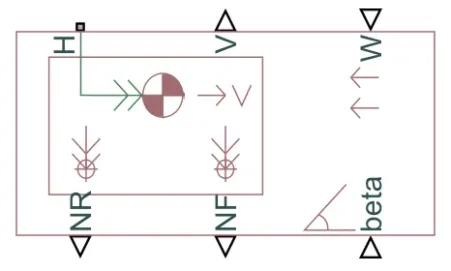
This block contains 6 ports which can be used to model the various aspects of the vehicle body. The ports are mentioned and elaborated below:
- H- This stands for ‘Hub’ and is used to connect the hubs of the wheels to the main body of the vehicle.
- V - This is a physical signal output port which stands for ‘Velocity’ and is used to output the speed/velocity at which the vehicle is moving at.
- W- This is a physical signal input port and allows us to model a ‘headwind' acting on the vehicle by giving a speed for it.
- NR - This is a physical signal output port to model the rear wheel normal forces.
- NF - This is a physical signal output to model the front wheel normal forces.
- beta - This is a physical signal input port and allows us to model the vehicle on an inclination angle to create the effect of a hill climbing force.
tyres : The tyres used in this EV model are 'magical formula' tyres. There are several tyre blocks that can be used for EV modelling but I have used the magical formula ones because it allows us to model the longitudinal behavior of tyres on highways. They also allow us to take into consideration extra effects such as tyre inertia, stiffness, etc which helps in better accuracy of real world conditions.
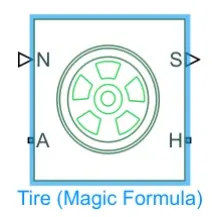
- N-This port stands for ‘Normal’ and is the physical signal input port for the normal force acting on the tire and is considered positive in the downwards direction.
- S-This port stands for ‘Slip’ and is the physical signal output port is that reports the slip acting on the tire.
- A- This port stands for ‘Axle’ and is the mechanical rotational conserving port for the wheel axle.
- H- This port stands for ‘Hub’ and is the mechanical translational conserving port for the wheel hub through which the thrust developed by the tires is applied to the vehicle body
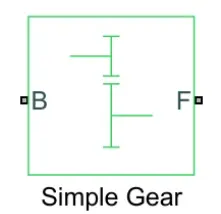
Gear :I have chosen 'Simple Gear' block as to simplify the transmission system parameters. This block models a gear system with a fixed gear ratio and with no inertia effects, however we can modify the effects of meshing of gear teeth. The simple gear block is as shown below:
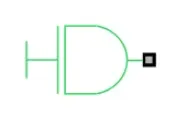
Inertia : An inertia block has been added to the workspace to provide an ideal mechanical rotational inertia for the simple gear block. This block has only one mechanical rotational conserving port and the positive direction of the block is from the port to the reference point which would be the simple gear in this case. The inertia torque acts in the positive direction is the inertia is accelerated in the positive direction. The inertia block is shown below:
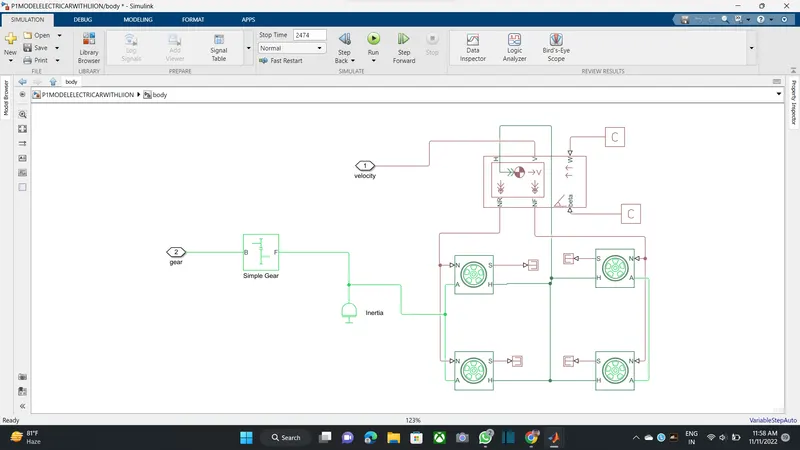
As seen in the diagram above, the various blocks are connected to model the vehicle body. 4 magic formula tire blocks are used as the vehicle will have 4 tires, 2 on each axle. The tires are LR, LF, RR and RF (left rear, left front, right rear, and right front). The normal ports of each tire are connected to the appropriate NR and NF ports on the vehicle body block. The hubs of each tire are connected together and an extra connection is made from them to the vehicle body block.
Motor :
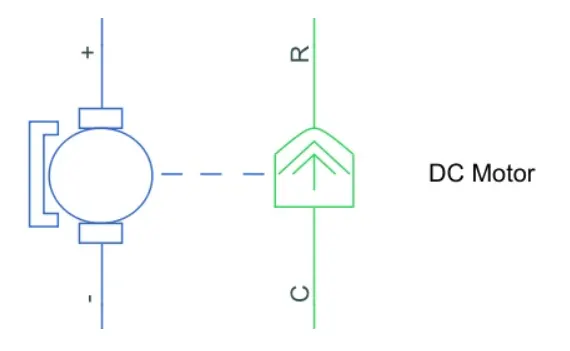
As we can see, there are 2 sides to the block: the mechanical side on the right and the electrical side on the left. The mechanical side has 2 ports, C and R. The C refers to the casing and the R for the rotation of the rotor which produces a torque. The electrical side has a positive and a negative terminal for the voltages to be applied. If a positive voltage is applied to the DC motor block from the positive to the negative terminal, a positive torque will act from the C port to the R port. The direction of the torque produced by the DC motor can be changed by changing the sign of the back emf or the torque constant. The C port of the mechanical side needs to be connected to a mechanical rotational reference because it will be stationary. The R port will be connected to the open connection of the simple gear from the vehicle body block. The positive terminal on the electrical side is connected to the positive terminal of a power converter which in my case will be an ‘H bridge’.
Power converter :The power converter is needed to provide power of the correct form and magnitude from one component to another. In the case of EVs, a power converter is needed to provide a DC voltage from the battery of the EV to the DC motor so that it can operate properly with the required parameters. As mentioned earlier, I have used an H-Bridge motor drive as my power converter. Its block is shown below:
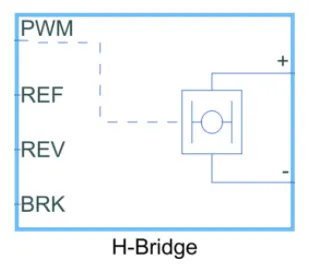
- PWM - This stands for Pulse Width Modulation which will provide the voltage pulses to the H-Bridge either in the PWM or average mode.
- REF - This stands for Reference.
- REV - This stands for Reverse.
- BRK - This stands for Brake.
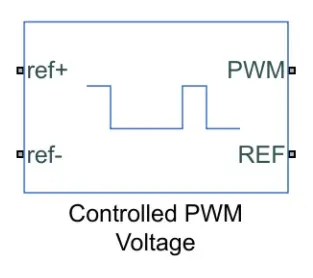
CONTROLLED PWM VOLTAGE BLOCK:
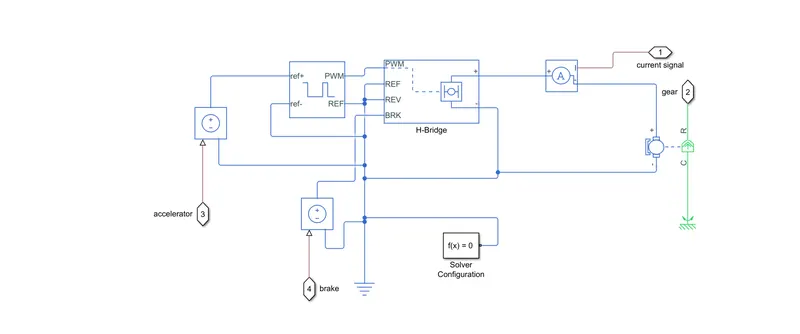
LONGITUDINAL DRIVER:
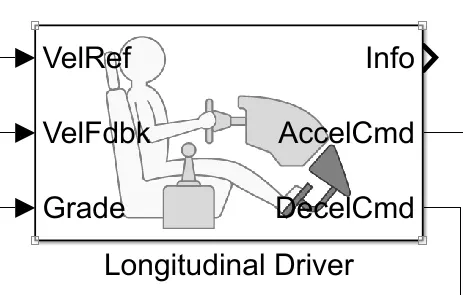
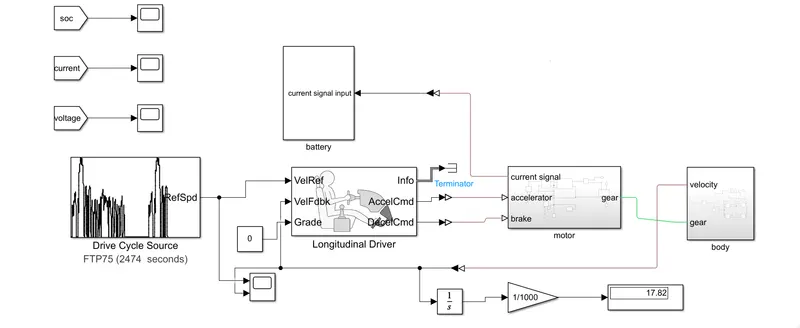
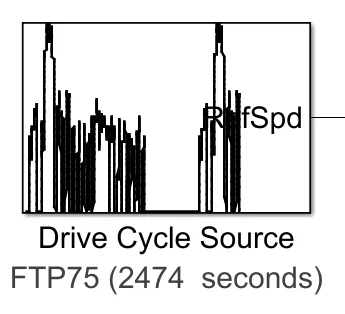
drive cycle :I have considered the FTP75 drive cycle and the output of this block is connected with 'Veh Ref' port of the longitudinal driver.
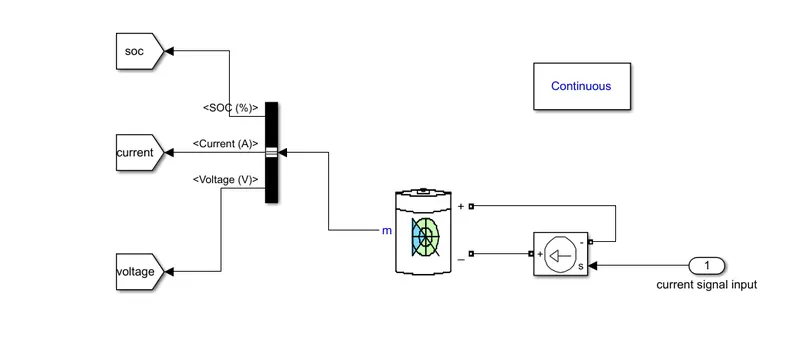
BATTERY :
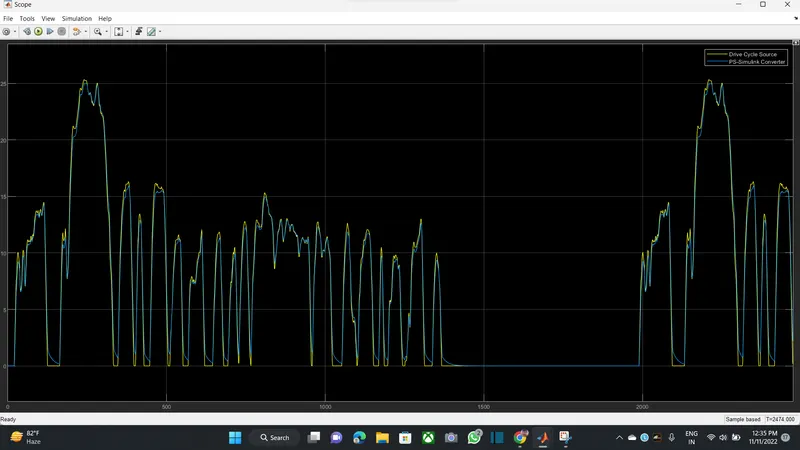
RESULTS :
SOC:
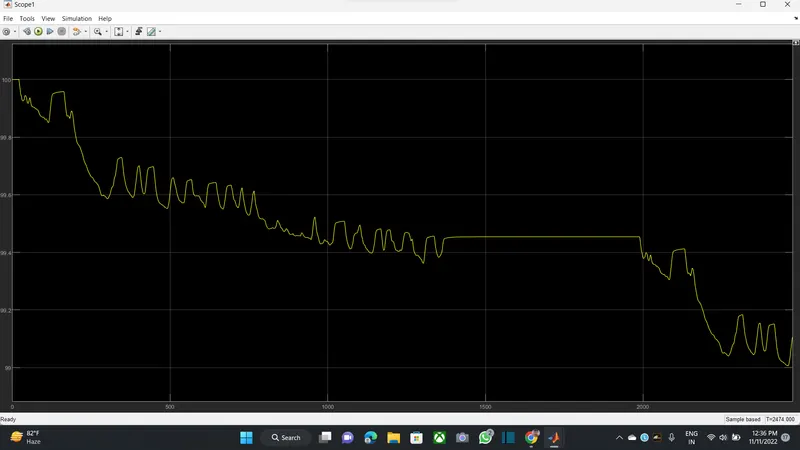
current:
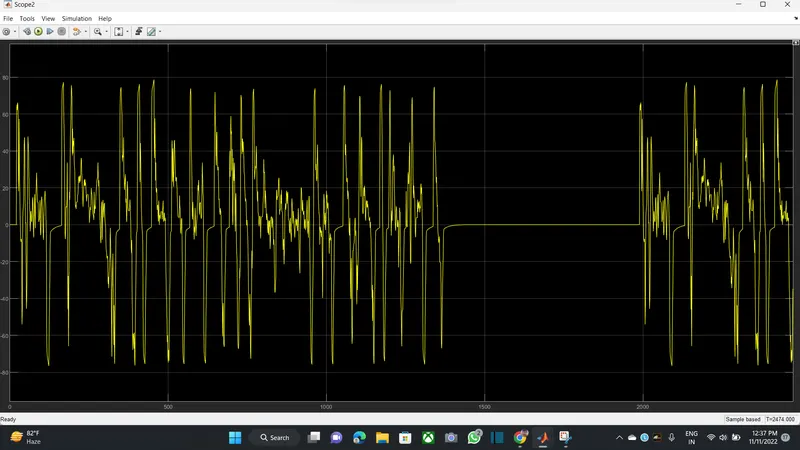
voltage :