Final Project: Design of an Electric Vehicle
- AIM:-Create a MATLAB model of electric car which uses a battery and a DC motor. Choose suitable blocks from Powertrain block set. Prepare a report about your model including following:
- Objectives:
- Systom level configurations
- Model parameters
- Results
- Conclusion
- An electric vehicle mainly consists of four parts which are consider as crucial while designing those are: Drive Source, Motor and its Power controller, Battery and Vehicle Body.
- Based on this image will create MATLAB model considering different subsystems.
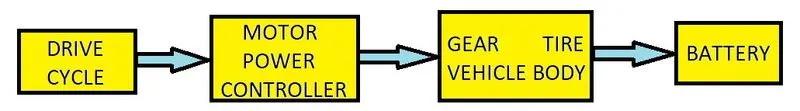
- For better understanding a subsystem is created for each part under which detailed designing is done keeping parameters in mind.
- Below is shown MATLAB model of electric vehicle.
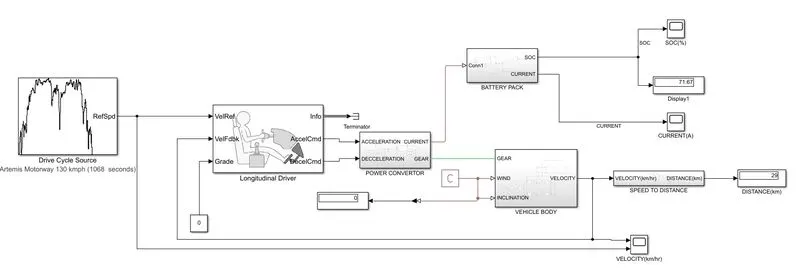
- As per above discussion,briefing each of the subsystem.
- Starting with vehicle body subsystem.
- VEHICLE BODY SUBSYSTEM:-
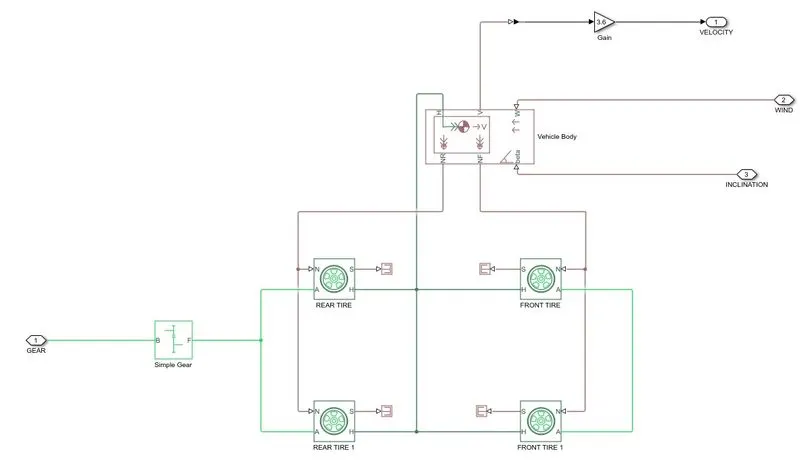
- Here input is receiving from DC motor which is present in Power controller subsystem.
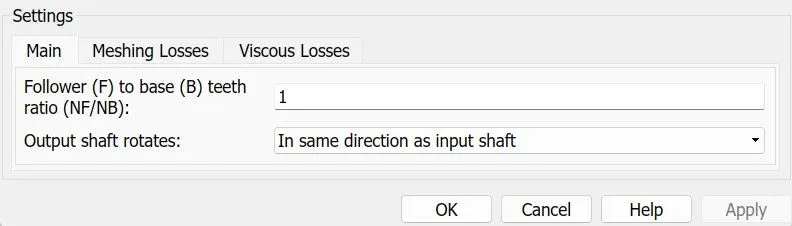
- Simple gear is the ratio of motor speed to driven wheels which we kept as 1 here.
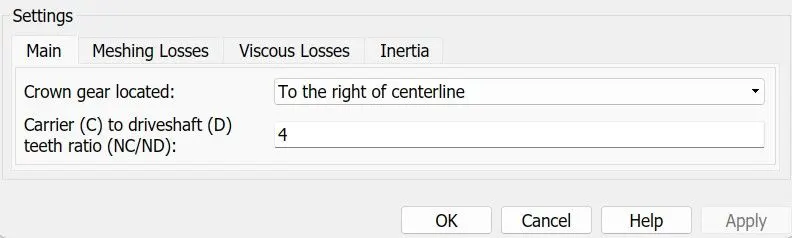
- After gear, differential block is used for providing tractive force equally to front and rear wheels
- For vehicle body we have not considered any gradient and wind effect such that its showing 0 value on display.
- Output of this subsytem is velocity which is converted into Km/hr by adding gain block of value 3.6.
- Below is shown the parameters of various blocks used in this subsystem.
- Main blocks used in this subsystem are as: Tire Magic,vehicle body,Simple gear and Differential.
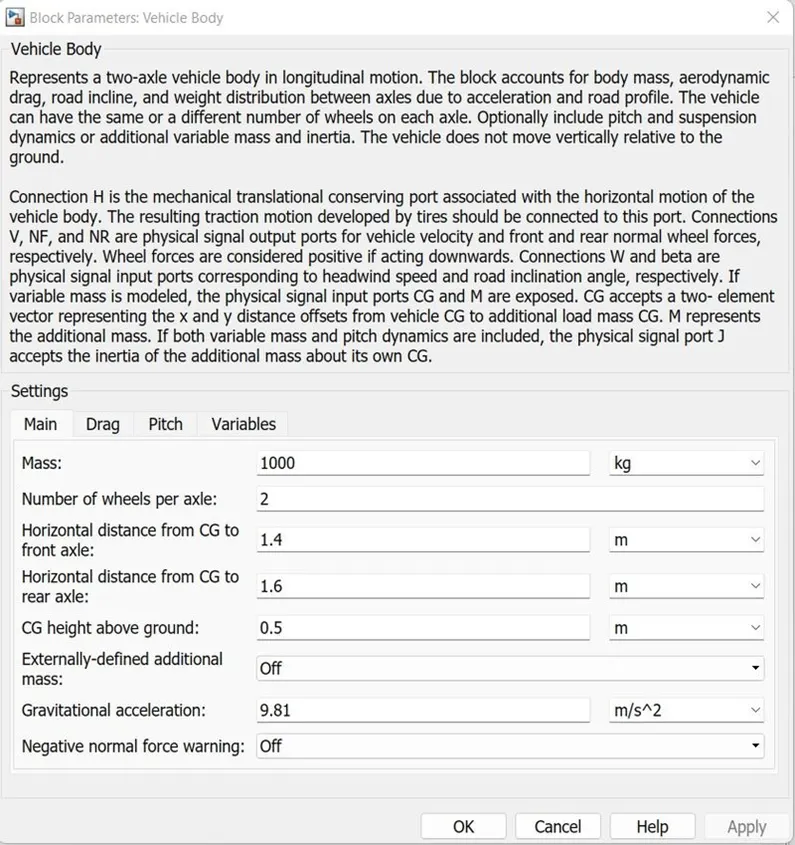
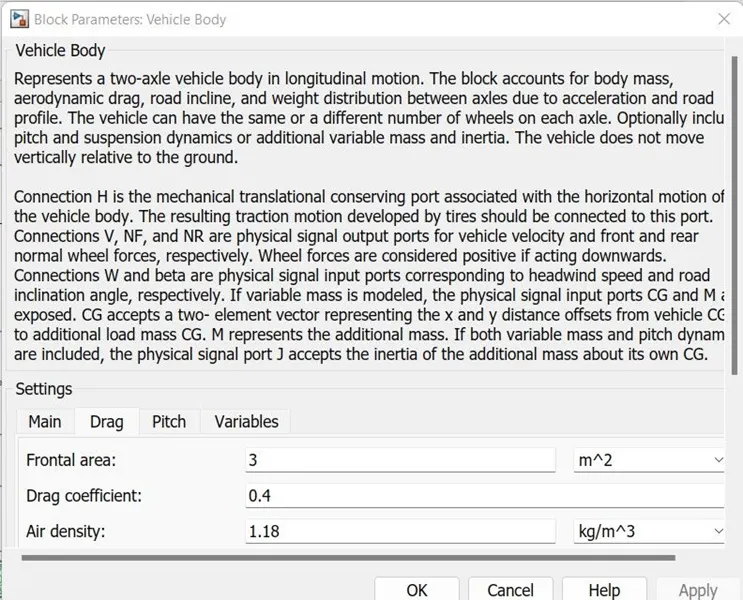
- Vehicle Body:-
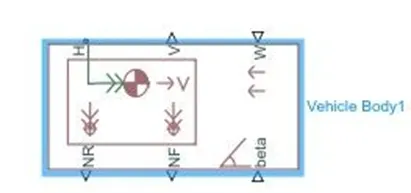
- Beta:- It is a input port which represents a inclination angle in radians.
- W:- Here the letter W means wind so to create any wind speed effects (in m/s) input signal is provided on this port.
- V:- This is the output port represents velocity of the vehicle in m/s.
- H:- Output port represents horizontal movement of tires.
- NR & NF:- These two are output ports which represents axle force applied on rear and front tire, which is considered as braking.
- Paramters adjusted in this block
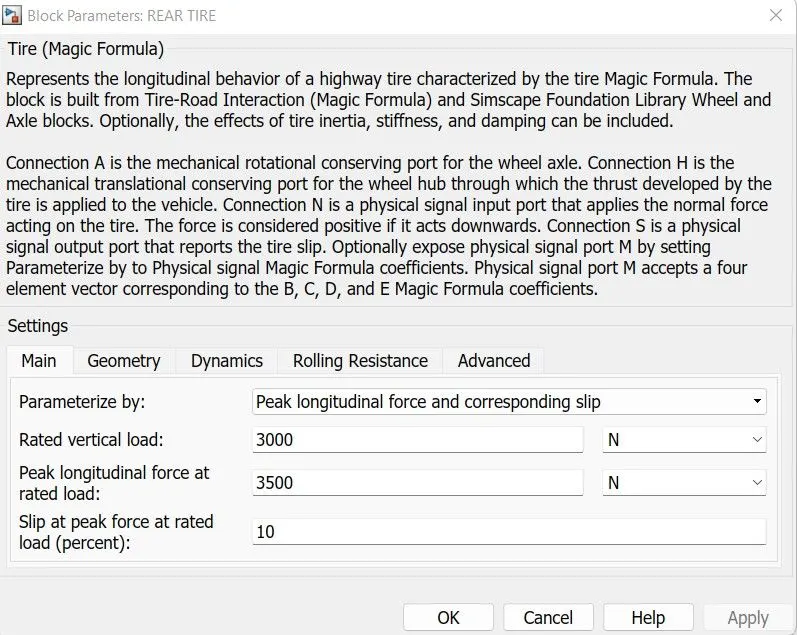
- Tire block:-It represents longitudinal behaviour of highway.
- Simple Gear:- It represents fixed gear ratio or gear box for transmission of tire.
- Differential:-
- POWER CONTROLLER SUBSYSTEM:-
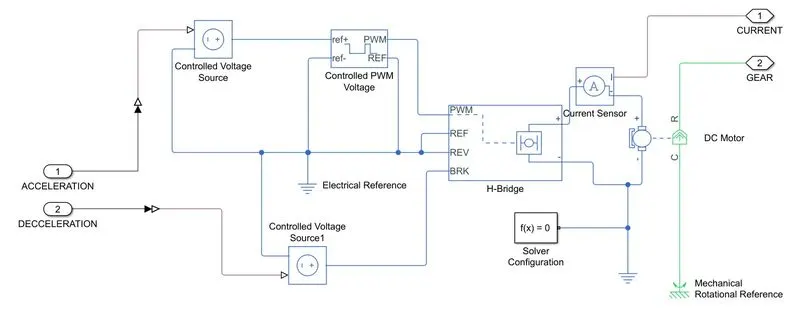
- From longitudinal driver we receive 2 inputs which are Acceleration and decceleration which is shown here as input 1 and 2.
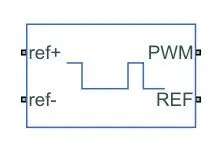
- Controlled PWM voltage block is used to create PWM voltage from the controlled voltage source, when pulse is low output voltage is zero, and its high when pulse is equal to output voitage.
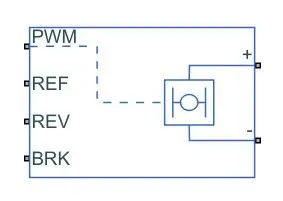
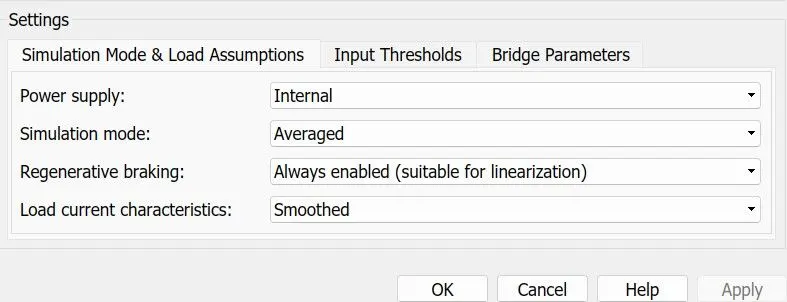
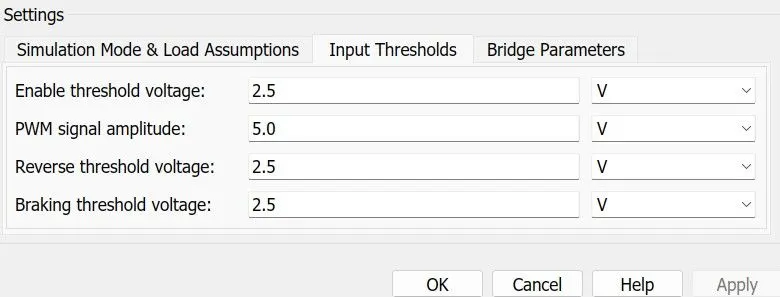
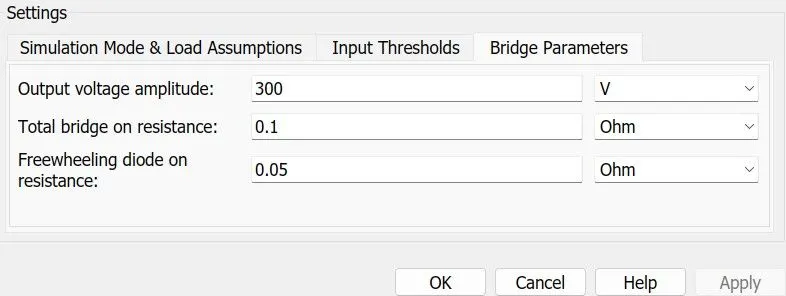
- H-bridge is the power converter used in this model which will fetch power from battery via Controlled PWM voltage block and deliver to DC motor as per the requiremernts.
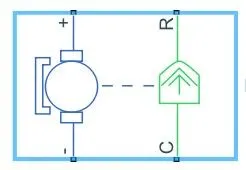
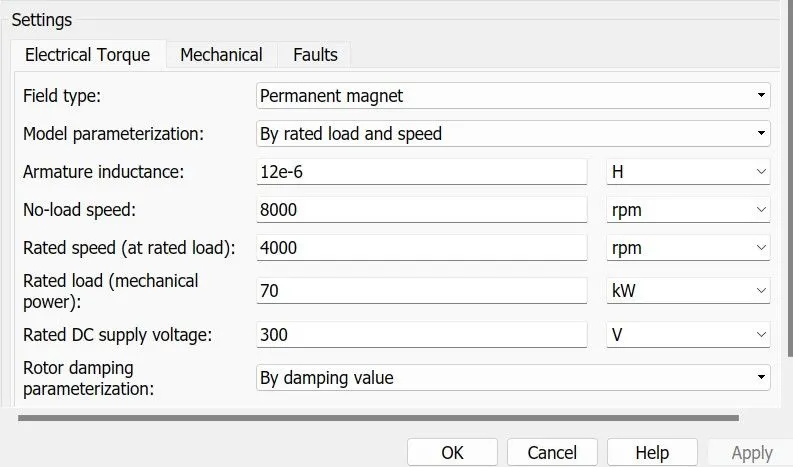
- DC motor is used of 70kW, with rated DC Supply voltage of 300V output of this motor is feed to gear in above discussed subsystem.
- Second Output from current sensor is feed to controlled current source block in battery subsystem.
- Main blocks used in this subsystem are as: DC motor,Controlled PWM voltage and H-bridge.
- DC Motor:-
- H-bridge:-
- Controlled PWM Voltage:-
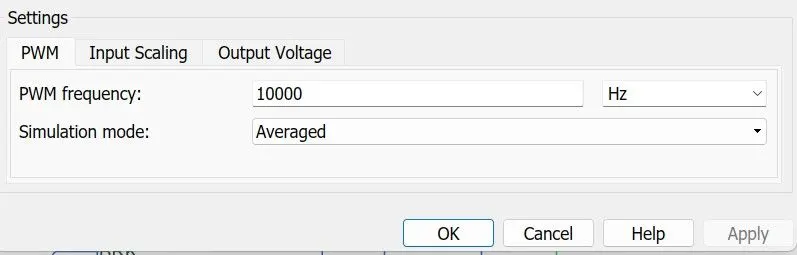
- Other two parameters are by default.
- BATTERY SUBSYSTEM:-
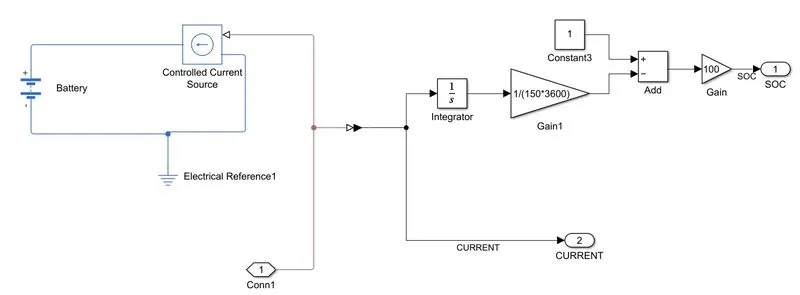
- Battery is used of 150Ah capacity with nominal voltage of 300V.
- This battery pack is used for storing the energy in vehicle during acceleration,It helps to drive DC motor.
- Where as in decceleration mode with the use of regenrative mode of braking these battery gets charged by dc motor.
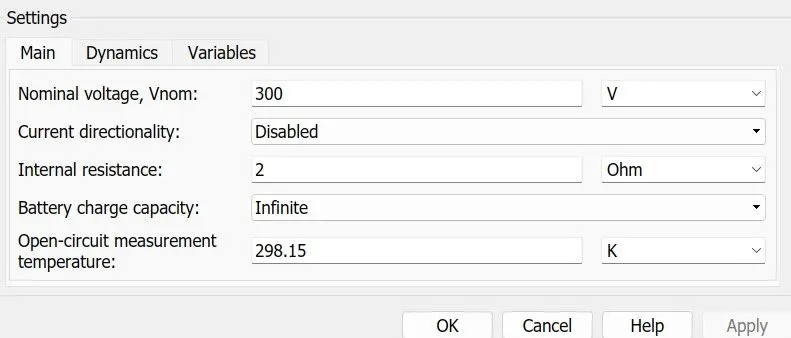
- To measure the state charge of the battery,the integrator block is used to handle data transter and integrate the value of the current signal with respect to time then gain block is used in order to multiply the signal coming from the integrating block.This block will divide a current signal with the ampere rating battery which is 150(ah)*3600 (sec).
- Assuming the battery is always fully charged i have added a constant block with a value of 1 representing 100%.
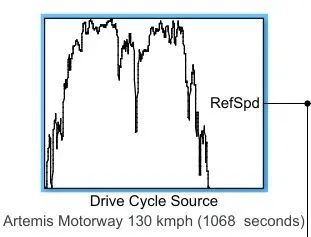
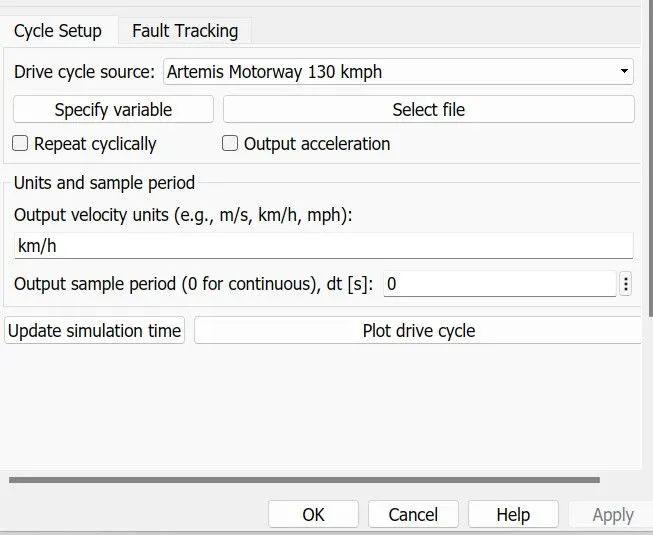
- DRIVE CYCLE:-
- SPEED TO DISTANCE:-
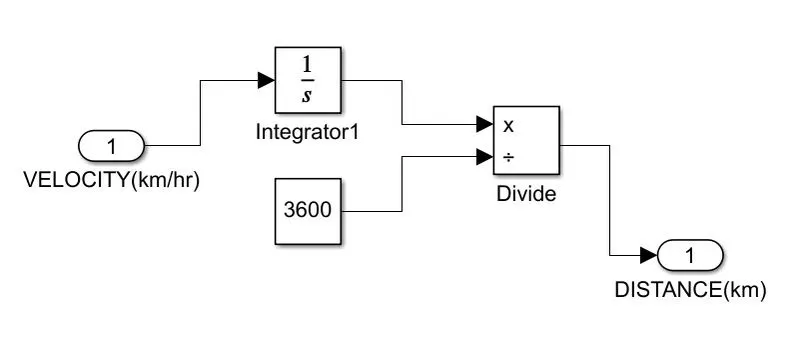
- This subsystem is used to derive distance(km) from speed (km/hr) just for observation by using integrator,constant and divide block.
- List of other small blocks used in this model are as follows:-
- Longitudinal driver
- Controlled voltage source
- Controlled current source
- Current sensor
- PS terminator
- PS constant
- Gain
- Constant
- Divide
- Integrator
- PS-Simulink Converter
- RESULTS:-
- CONCLUSION:-
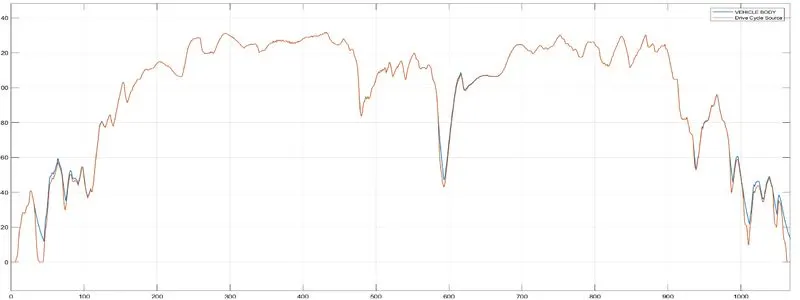
- From first result which is comparison of input data and the actual distance covered by an Ev which is observed that actual data is very close to input one.
- It is seen that when artemis motorway 130kmph drive cycle was toucning 0 axis that time actual drive cycle didnt reached.
- Our input drive cycle is 28.7 km where as actual drive cycle has covered couple of kms more in 1068 seconds i.e 29 km shows in display block.
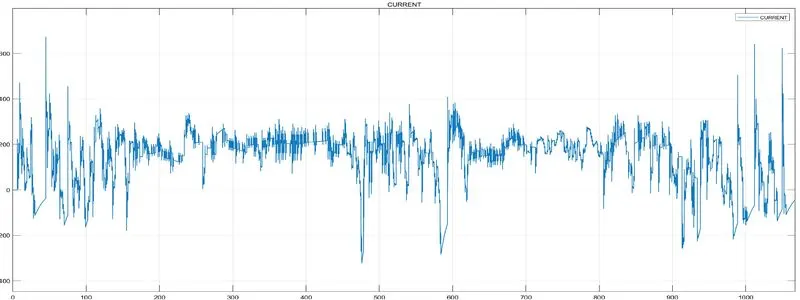
- In second graph Range of current is from -322 to 673A which is related to decceleration and acceleration reapectively.
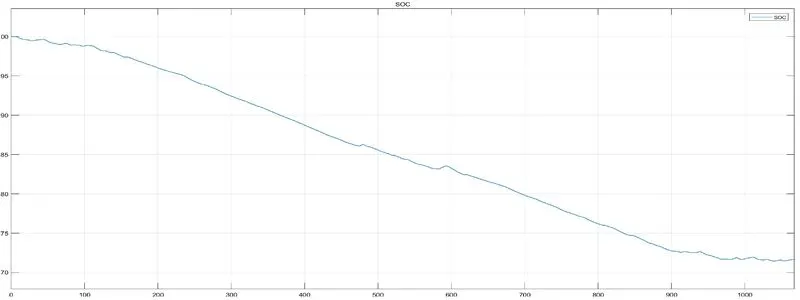
- In third graph,state of charge at the end of drive cycle has reached to near about 71.67% and also few spikes are observed in this which is because of regenerative braking.