Assignment 7-Side Pole Crash Simulation Challenge
OBJECTIVE :-
- To perform a side pole crash simulation with the given BIW frame in Radioss and request for outputs as mentioned in problem statement.
Software used :- Altair hyper-works student version 2020
Problem statement :-
Neon side crash -BIW
- Check unit system and either follow [Mg mm s] or [Kg mm ms].
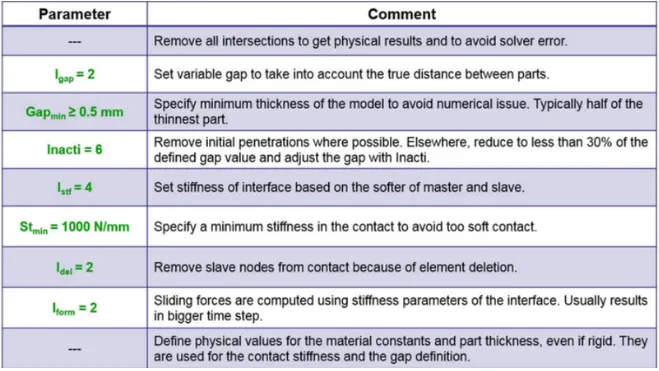
- Create appropriate interface ,friction 0.2 and recommended parameters.
- Make sure of no penetration and intersections.
- Create rigid wall with friction 0.1 as per referance model.
- Compare the model weight with the referance model and use added masses to reach target weight 700kg while getting CG about the required range.
- Initial velocity - 20mph, as per the standards.
- Use model checker to ensure good quality.
- Timestep :0.5 to 0.1 microseconds.
- Run 80ms.
Output requests:
- Sectional force in the cross member.
- Intrusion at B-pillar, hinge pillar and fuel tank region. Provide recommendation on what can help to reduce Fuel tank intrusion.
- Peak velocity of inner node of the door.
ABSTRACT :
- In this project we are about to see the impact of the side body of the car when it hits to the pole, Side body is consist of two side doors with plastic body of arm rest in the windows with electric control panel one for driven and another for passenger, Here we will see that the impact on the side door,hinge, middle pillar,area near to fuel tank, section 1.
PROCEDURE
Check unit system and either follow [Mg mm s] or [Kg mm ms].
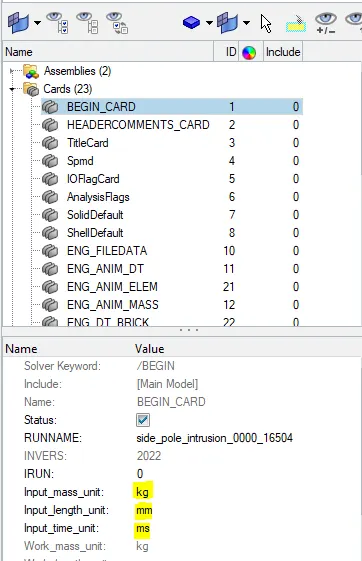
- Checking the unit system and either following [Mg mm s] or [Kg mm ms].
-
STEP 1: Open the starter file neon_side_reduced_000.rad file, go to-
*Menu bar>file>import>solver desk>select .rad file>importSTEP 2: Checking unit system of the model
*Model browser>cards>begin card
Create an appropriate interface, friction 0.2, and recommended parameters.
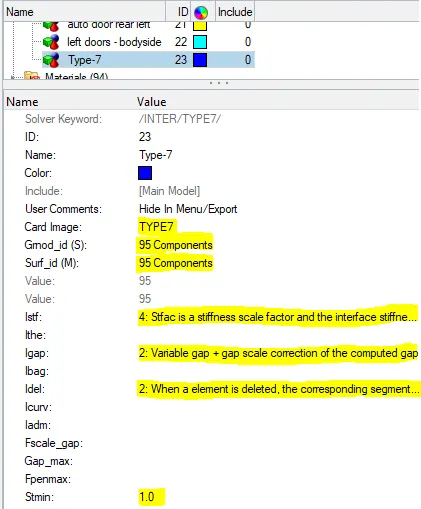
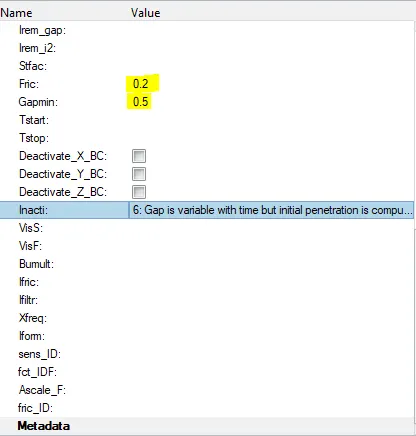
- A contact interface should be defined to view the contact energy. Here the type-7 Contact is used (Node to Surface), because of its high accuracy and correct physical representation. The self-impact is defined in the Contact interface as the body acts as both master and Slave.
- Interface properties Changed to recommended conditions as per mentioned in problem statement and create another interface for bumper and rail contacts. which is shown in image below.
- Model browser->groups->create group->
Make sure of no penetration and intersections.
- To check for penetrations in the model, we will go to Tools menu on Menu bar and click on Penetration Check option. In Penetration check panel, we will select all the components and click on Check command. The software will check for penetrations and then display the results as shown below.
- There should be no penetrations and intersections
*Menubar>penetration check>select group>check
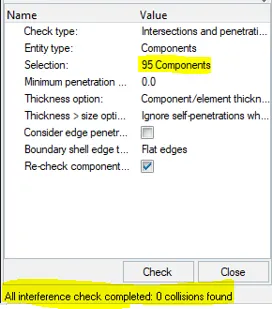
- There are no penetration or intersection error found.
Create a rigid wall with friction 0.1 as per the reference model.
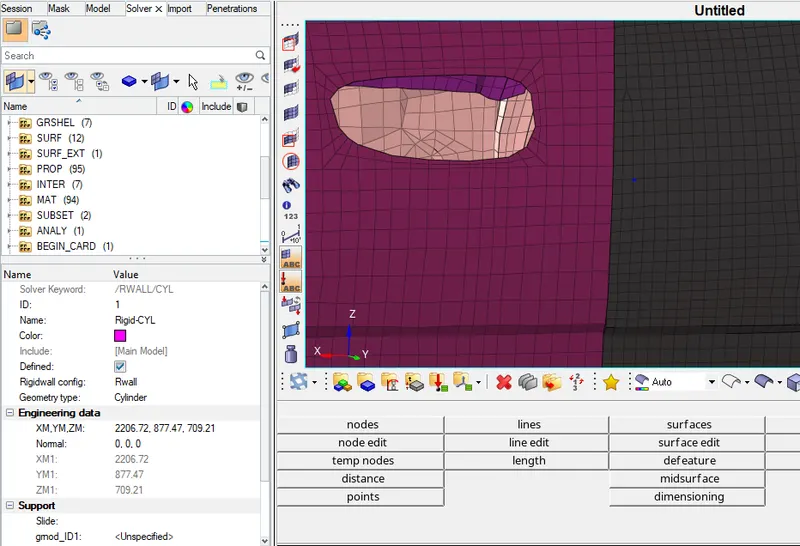
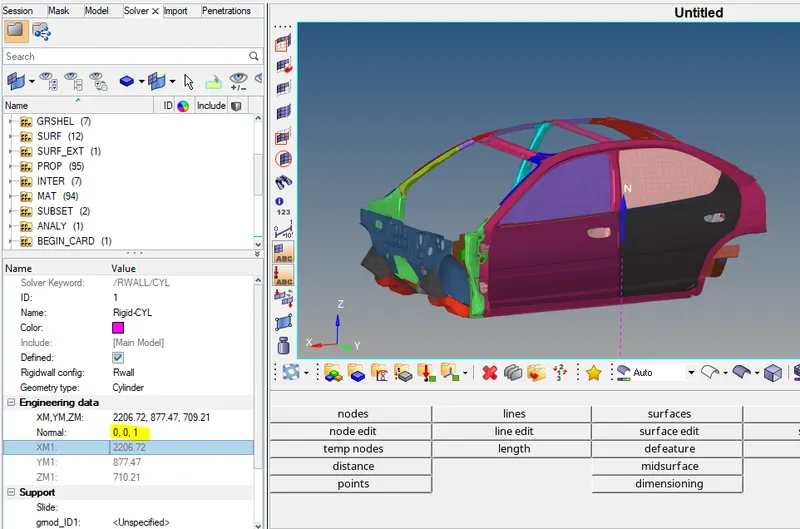
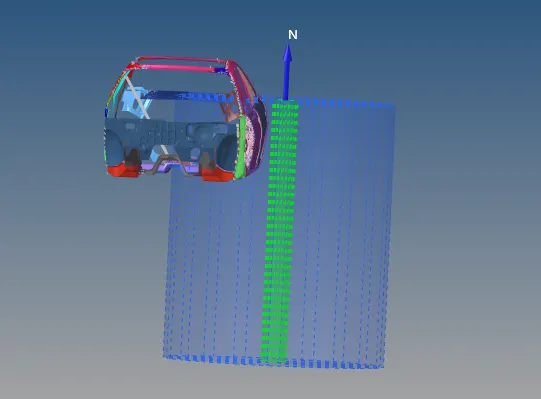
- To create a cylindrical rigid wall at the left side of the car, we will need the outermost node at the front left door of the car. So we will create the outermost node on the element edge using temp nodes option. Then we will right click in solver browser and navigate to Create > RWALL -> CYL. In the RWALL panel, under Engineering data we will specify the coordinates of the pole which will be at some distance from the outermost node on side door.
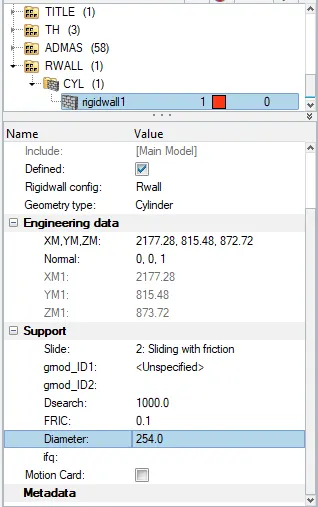
- Then we will give the normal direction to the pole in Z-axis and diameter of the pole to be 254 mm. The FRIC value will be 0.1 and Dsearch value will be 1000 as shown below.
Compare the model weight with the reference model and use added masses to reach the target weight of 700kg while getting CG about the required range.
- To compare the model wight with full scal 300k nodes model and use added masses to reach target weight 700 kg while getting cg about required range
- First we have to know about mass of model that is how much mass the model currently holds along with this we need to know about its cog as well to know this goto to>> mass details >> mass cog inertia.
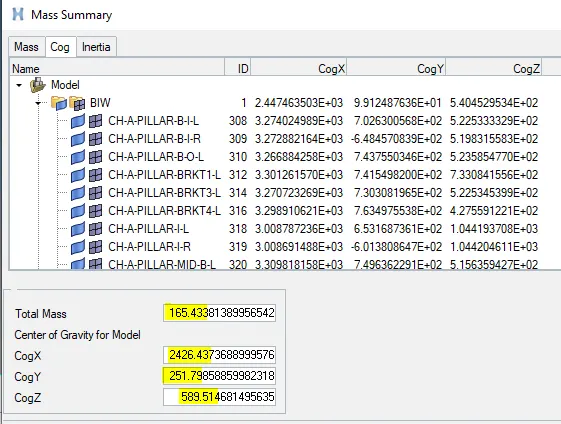
- Here the model has some mass of around 166 kg already assign to it , now we have to add some mass to this model so that this model reach to 700 kg and we can get cog of the model to appropriate location.
- Similarly we can know cog location of the model by clicking cog window near the mass window shows co ordinate of the current cog of the model by these co ordinate we can create a node from geometery >> node.
- After checking this we can add mass in the model from solver >> create >> admas
- Select mass type as mass added at each node of the node group. And select appropriate node on logical position.
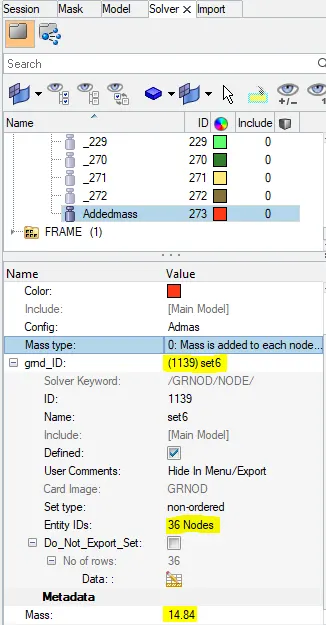
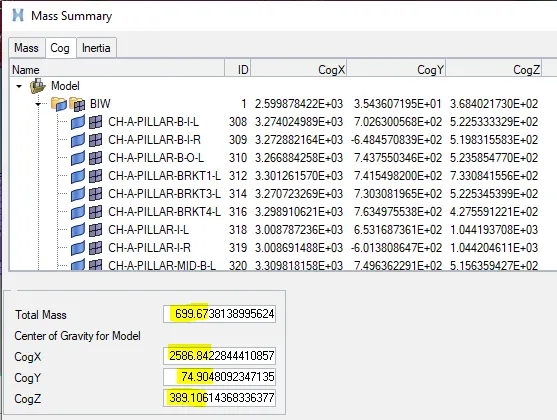
- Once mass is been added it will show centre of mass , now we have to check cog of the model after weight is been added ,check the cog location and create a node at this location.
Initial velocity - 20mph, as per the standards.
- To apply initial velocity of 35 mph we need to first change its units as we are using kg mm ms unit system , to know about its equivalent value in mm/ms we have used consistent unit data as below.
- Now that we know its equivalent value we have to create invel card , to create it go to solver deck >> right click >> create >>boundary conditions>>invel.
- The definition of invel card will be as shown below.
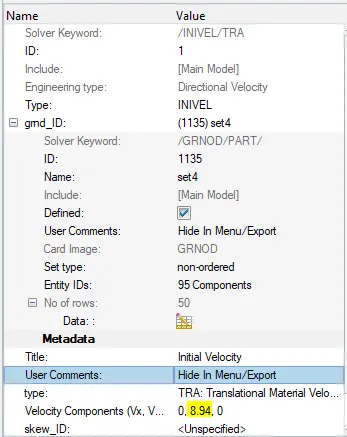
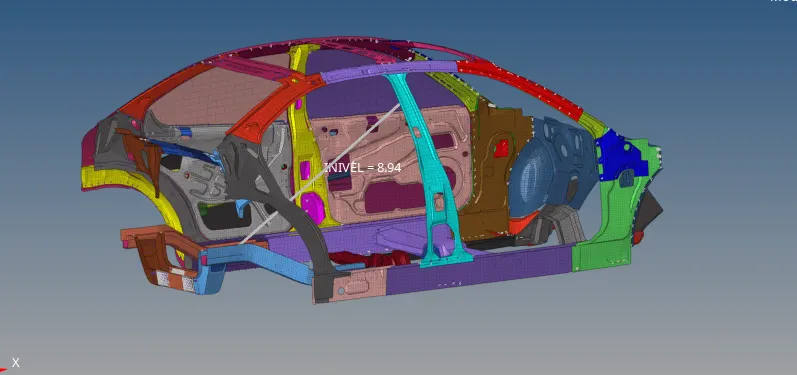
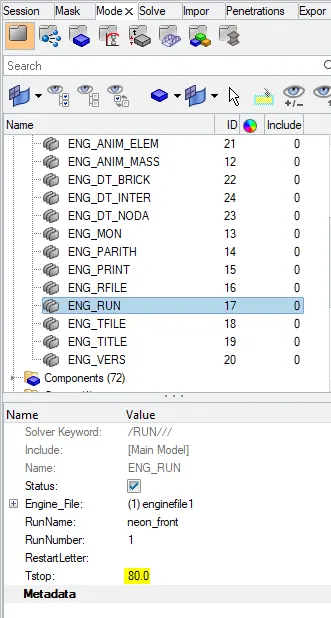
Time-step :0.5 to 0.1 microseconds and Run 80 ms.
- The run time is kept to be 80ms;
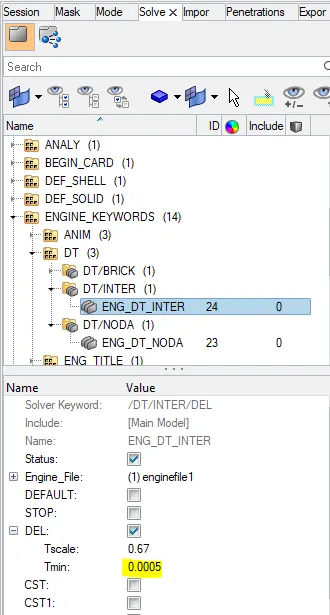
Time-step :0.5 to 0.1 microseconds.
- A type of time step option is “INTER” and time step control “DEL” is used.
- We have to keep 0.67 as time scale factor and 0.0005 as a minimum time step control.
- If time step gets reduced below the minimum time step, then this algorithm will add some mass to the element which leads to maintain time step more than minimum time step.
This method is used in order to control the time step.
- A type of time step option is “NODA” and time step control type “CST” is used.
- In order to create ENG_DT_NODA we have to follow steps as explained below.
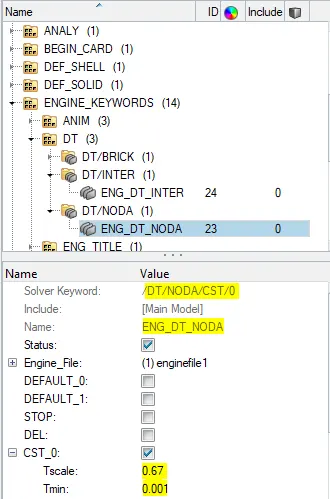
This method is used to control the time step from the nodes.
Output Request :
Sectional force in the cross member.
- Here we have to find forces passing through cross members to do so we need to create an output request
- To perform output request we have to follow the procedure that is for sectional force output request we need section to be created and for section we need frame
- To create frame follow below procedure.
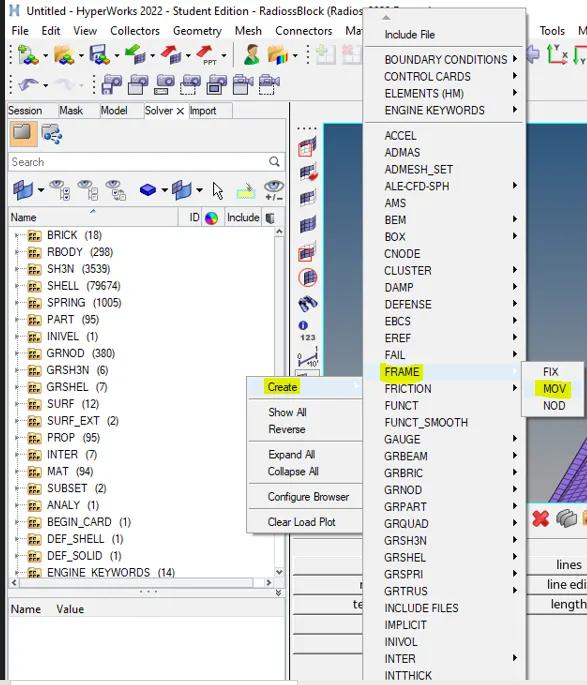
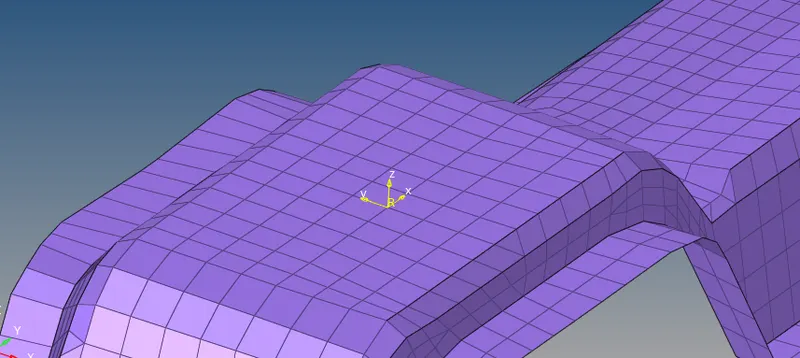
- A frame panel will appear in that we have to choose three nodes to define frame these three nodes will be origin , node for x from origin & third node to define xy plane.
- Once created frame will appear as below.
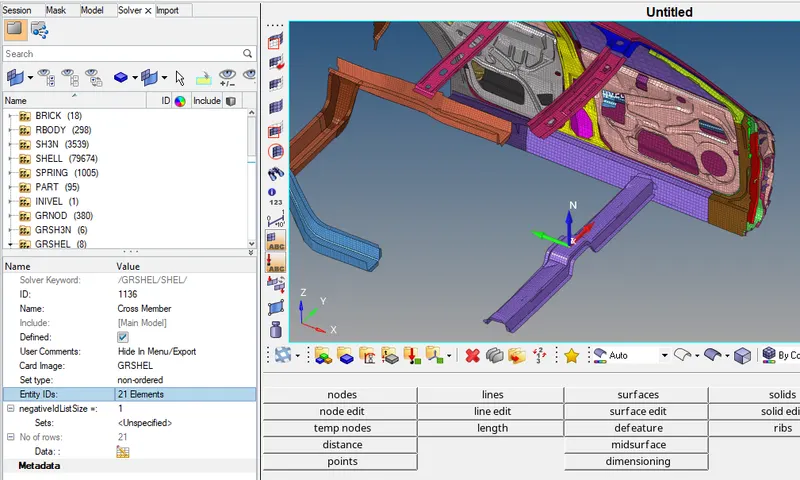
- Now we have to assign GRSHELL id by selecting element as shown in picture below.
- After frame has been done we can we have to create cross section for that go to solver browser create >> sect >> sect
- This will brought a cross section property section ,here we have to select nodes for cross section to do so select node respective to n1,n2,n3 >> in sub panel click on node and pick node for respective node >> proceed
- Now select frame for property for that click on system near frame >> in sub panel click on system >> pick the frame forgh system>> proceed.
- The frame will be for reference of the section.
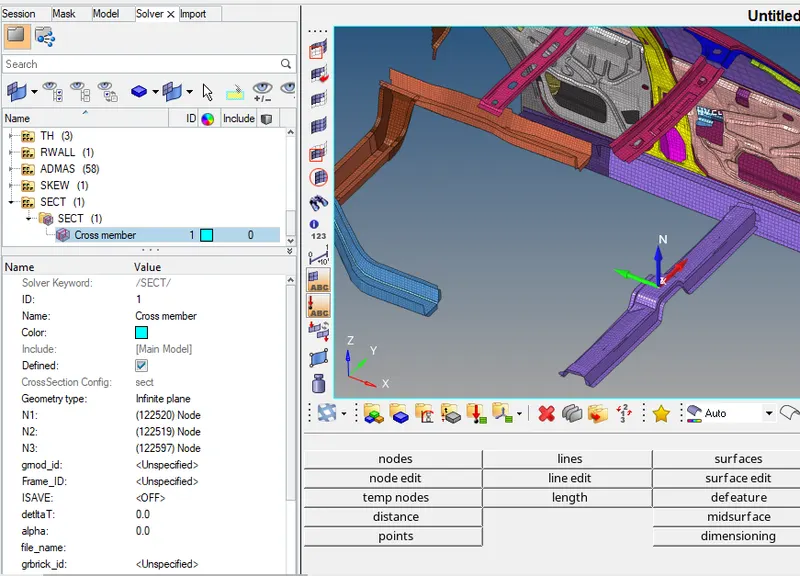
- Once section creation is been done we need to create output request for both of them respectively
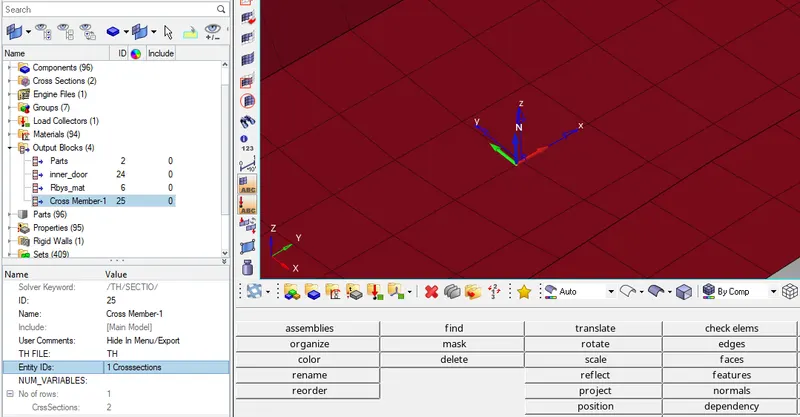
- After element selection do proceed it will create section , similarly create section on another cross member.
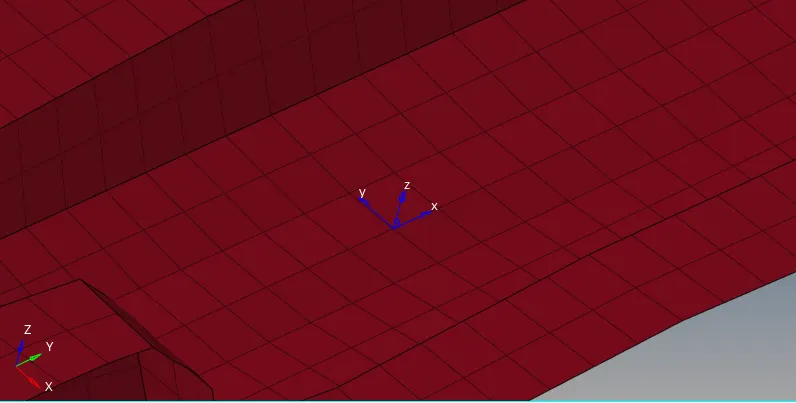
- A frame panel will appear in that we have to choose three nodes to define frame these three nodes will be origin , node for x from origin & third node to define xy plane.
- Once created frame will appear as below.
- Now we have to assign GRSHELL id by selecting element as shown in picture below.
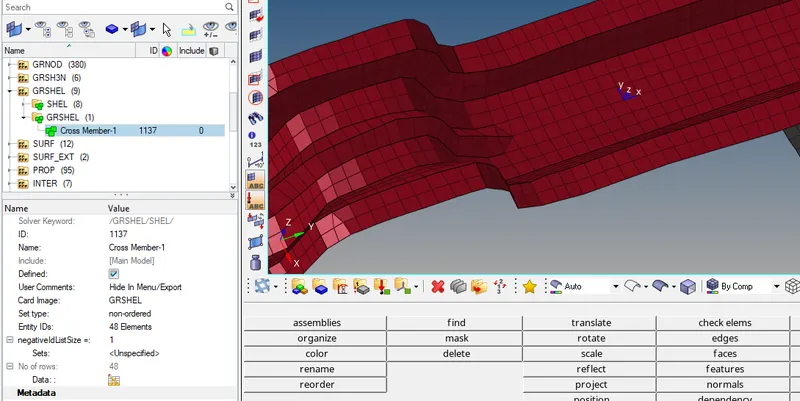
- After frame has been done we can we have to create cross section for that go to solver browser create >> sect >> sect
- This will brought a cross section property section ,here we have to select nodes for cross section to do so select node respective to n1,n2,n3 >> in sub panel click on node and pick node for respective node >> proceed
- Now select frame for property for that click on system near frame >> in sub panel click on system >> pick the frame forgh system>> proceed.
- The frame will be for reference of the section.
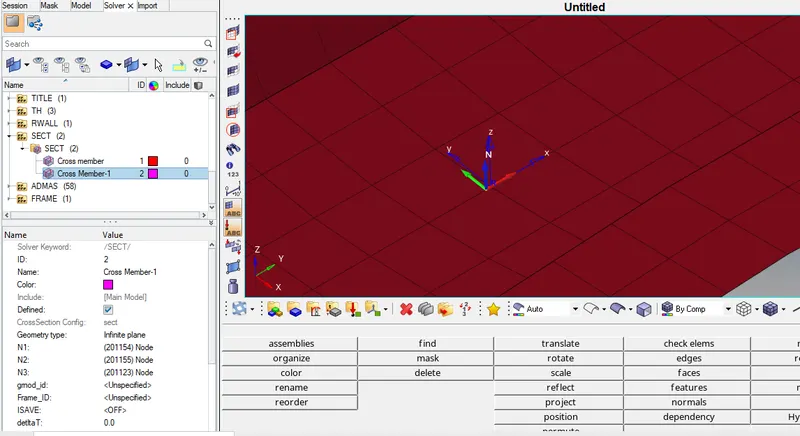
- Once section creation is been done we need to create output request for both of them respectively.
Intrusion at B pillar,hinge pillar and fuel tank region. Provide recommendations on what can help to reduce Fuel tank intrusion.
- Here, we need to find the intrusions at B-pillar, hinge pillar and fuel tank. So to find the results at the specified parts, we need to have a frame of reference. Thus we will create moving frames at the opposite side which are at right B-pillar, hinge pillar right side and fuel tank opposite side as shown below.
Intrusion at Fuel tank
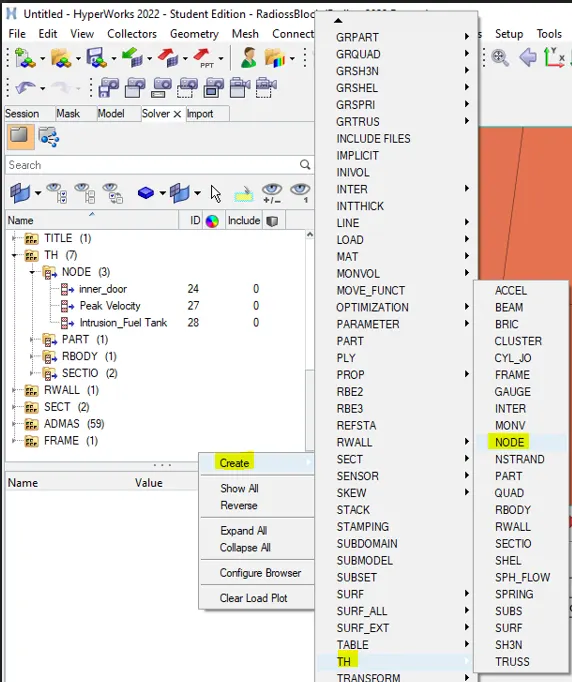
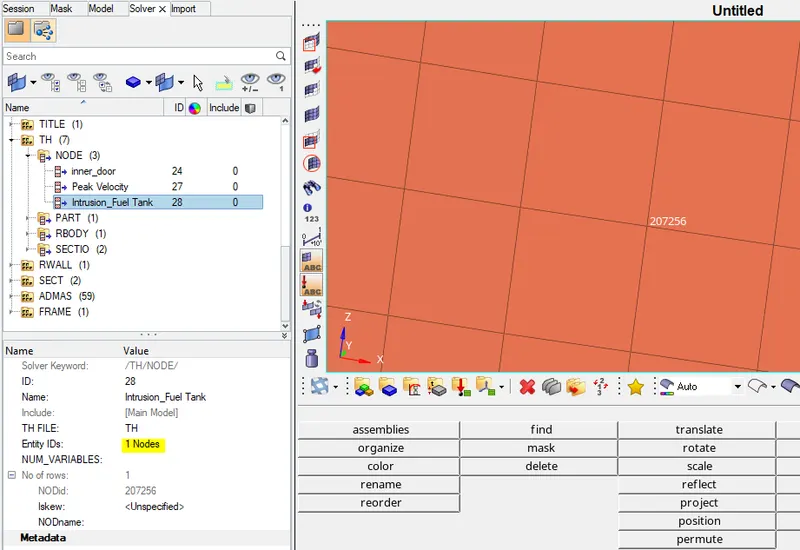
Intrusion at B pillar
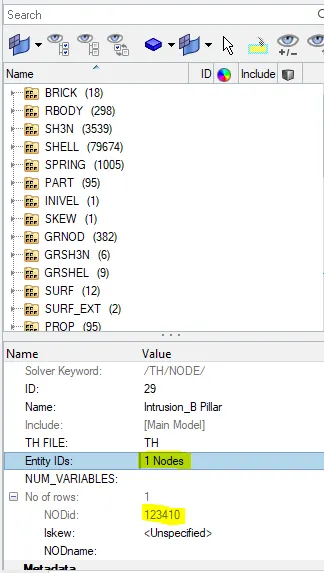
Intrusion at hinge pillar
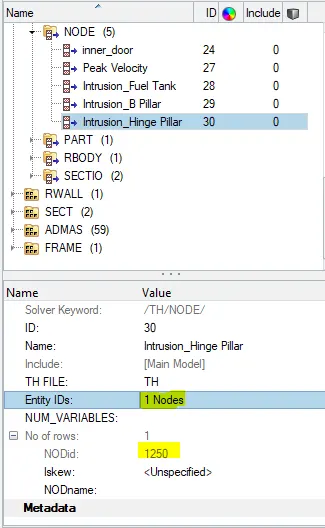
Peak velocity of an inner node of the door.
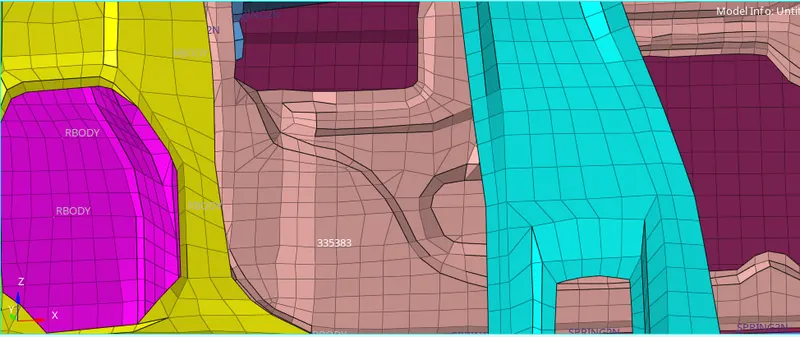
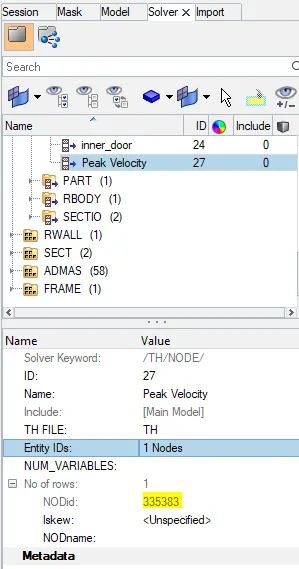
- To find peak velocity at the inner node of the door, we will create a moving frame at the node location by using the same procedure as we used in cross section creation.
- Then we will create output block for the peak velocity by specifying the node and the frame or skew based on which the peak velocity is calculated as shown below.
- This can be directly done with output request selecting any single inner node of the door.
Run the analysis :
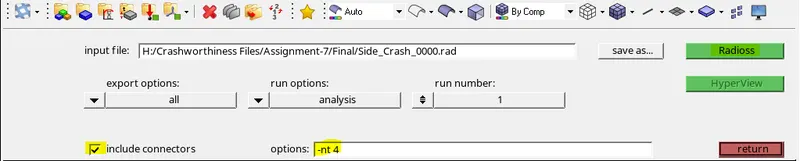
- Analysis >> radioss >> input file : (file location)-save as >> check the include connectors>>option: -nt 4>> hit radioss.
Observation and Result-
- From side_crash_0001.out file, the Total number of cycle was 79900. The energy error is 0.2% which is in acceptable limit. The mass error is 0.2652E-1% which also less than 5% it is acceptable.
- The run was “normal terminated’ which implies the processor successfully completed. There was no sudden changed in energy as well as in error. as shown below
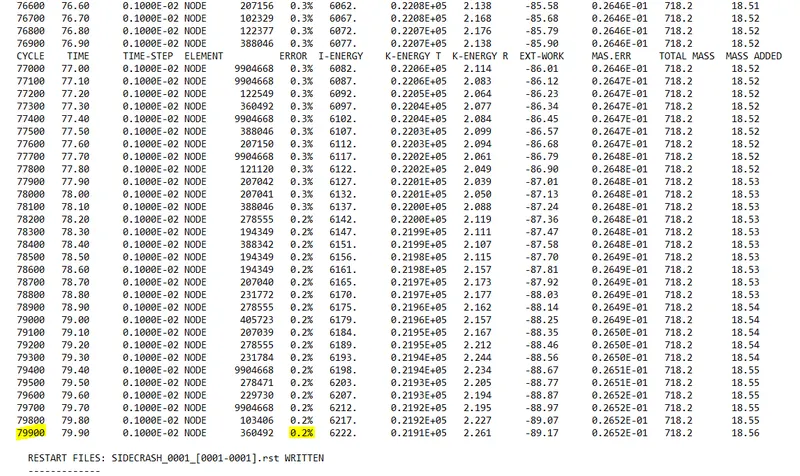
Energy and mass error:
- At the end of the simulation, do the energy error and mass error checks and determine whether results would be acceptable
- Open the save location file and click on the output file of the simulation to check for the energy error and mass error.
- If the error is negative, it means that some energy has been dissipated.
- In the case of under-integrated elements (belytschko shells, solids with 1 integration point), the hourglass energy can explain a negative energy error
- Since it is not counted in the energy balance. The normal amount of hourglass energy is about 10% to 15%.
- If the error is positive, there is an energy creation.
- In the case of using qeph shell formulation or fully integrated elements, the energy error can be slightly positive since there is no hourglass energy and the computation is much more accurate. An error of 1% or 2% will be acceptable.
- In the case of a larger positive energy, the source of this energy has to be identified. Incompatible kinematic conditions can lead to such a situation.
- If the error reaches :99%, the computation has diverged; except in the first cycle of a run for which the initial energy of the system was null so that a relatively false energy balance often introduces large relative error.
Simulation in Hyperview:
- The tool to review the simulation are available on hyper view
- Hyperview is a post-processing and visualization environment for FEA that gives the output of analysis in the simulations format that is user friendly to understand
- From the simulation, we can review how the impact force acts and cause deformation and point of rupture on the model.
- We have to import the animation file in hyperview.
Animation of the crash simulation is as follows:
Displacement contour plot :-
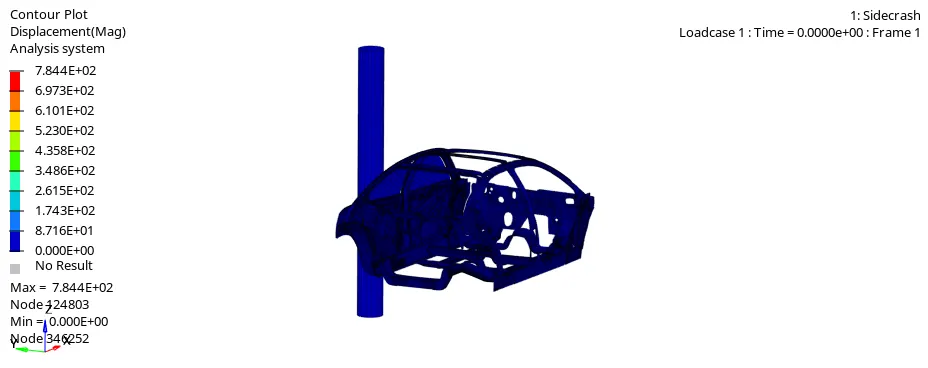
- In the above crash simulation of the vehicle, we can see the vehicle body is impacting on a Pole. After the impact, the frame of the vehicle deforms and the vehicle body gets contracted around the pole with left B-Pillar as the pivot point.
- The CG of the vehicle is in the same axis or direction of the pole, so we can see even deformation of the frame around the pole.
Von mises stress :-
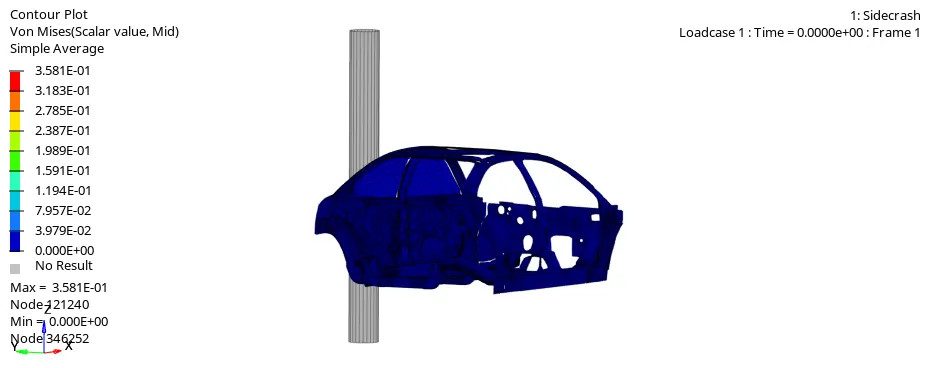
- The stress is more in B-pillar and cross members as B-pillar takes the initial impact and then the impact is transferred to the cross members.
Plot the graph & compare the results
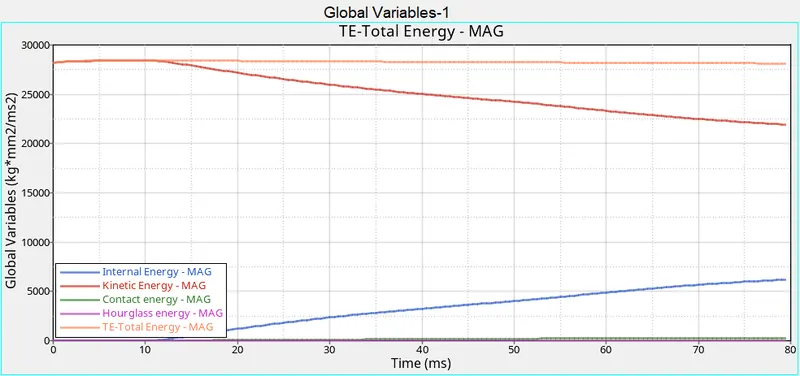
- From the above plot, we can see that there is high amount of Kinetic energy at the start of the simulation but as the simulation progresses, the kinetic energy in the vehicle decreases and gets converted into internal energy, so the internal energy increases in the same proportion. Thus the total energy in the system is almost constant at 30000 kg*mm2/ms2 and due to some energy loss which we can see in energy error, there is some decrease in total energy.
- We can also see some amount of contact energy in the model as we have defined the value of friction in Type 7 interface due to which contact energy is generated.
Sectional forces acting in cross members :-
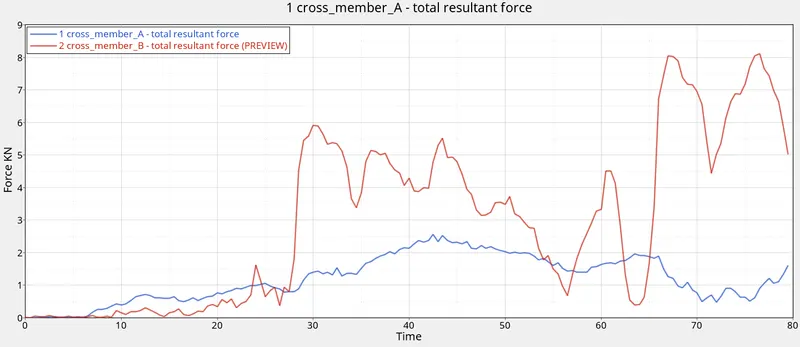
- From the above plot, we can see that the total resultant force in the rear cross member is more than the cross-member A. As the cross-member B is in line with the Pole, it experiences more force.
- The max section force at the mid rail is 8.0 kn and for the driver cross member is 2.8 kn.
Intrusions :-
- Intrusions are one of the important parameters while checking passenger safety in crashes. To know the intrusions at the b-pillar, fuel tank, and hinge pillar we have placed a spring in these particular regions of the b-pillar, fuel tank and hinge pillar from this we can see the intrusion at that particular region and we can also understand how much intrusion is happened in these regions.
- we can see that the hinge pillar has the maximum intrusion, then come to the Fuel tank and the least intrusion is seen at the B pillarregion.
-
Blue line- Intrusion node at Hinge pillar
Red line- Intrusion node at B-pillar
Green line- Intrusion node at fuel tank
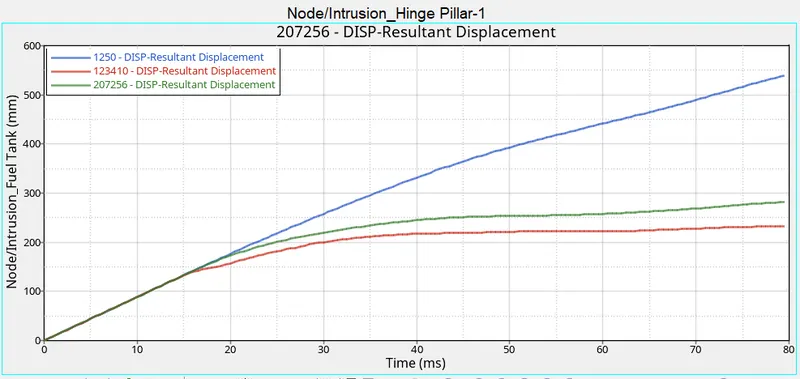
To prevent this failure, we need to reduce the intrusion which we can achieve by adding another cross member in fuel tank region which absorb some energy and resist the movement of fuel tank region and also the cross member can take some deformation.
Also we can increase the strength of the support element near the Fuel tank region by changing the Material or by adding a small support bracket over that region.
Peak velocity of inner node of door :-
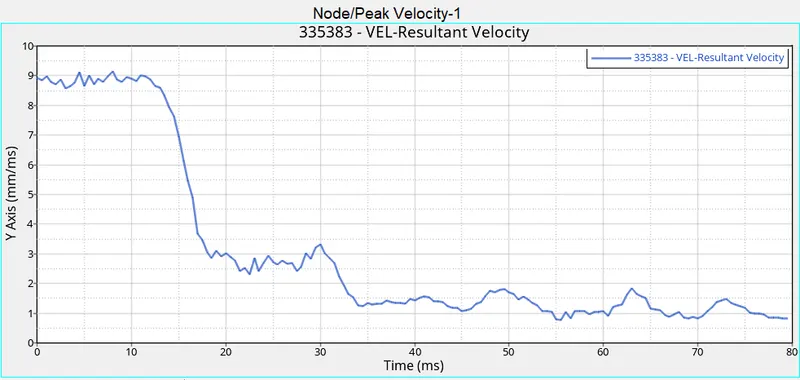
- As we all know that when the car hits the pole first impact will be the door and due to the deformation, the inner portion of the door might hit the passengers inside the car and lead to injuries. Hence it is important that the peak velocity at the door region is to be calculated.
- From the graph, the peak velocity of the node on the door is 8.92 mm/ms. As we seen from above graph there is fluctuations in the shock waves this is because of vibration that occurred during the crash of the vehicle.
Learning outcome
- Learned how to set up a side crash test.
- Learned how the rigid wall interface works and can lead to incompatible kinematic conditions.
- Learned how sectional forces are generated.
- Learned how the distribution of forces among the components during a side crash.
- Learned how some components are designed to deform in such a way to ensure the safety of the passengers inside the cabin.
- Learned how to check for energy, mass, and momentum balance.
- Learned how to debugging errors in order to get the right results.
- Learned how to place a node to see his peak velocity.
Conclusion:
The given model was simulated for the side crash using radioss and the results obtained were validated. The graphical results were plotted for all the test cases. From the simulation, it can be observed that there was maximum deformation in the cabin, and also maximum intrusion was found in the cabin area. This is due to the limited number of nodes in the student version some of the biw, engine blocks, suspension system, etc are removed, so the results are not as in real condition. After understanding these we will get to know what all things we should do on this car to make it safer. For example to decrease the amount of intrusion in the fuel tank region we can introduce a cross member there.