Assignment 7-Side Pole Crash Simulation Challenge
Crashworthiness Analysis using HyperMesh and Radioss
#Project 2 - Side Body Crash Simulation Challenge
AIM: To perform the crash on the Side body of the car to a pole and analysis where stresses are working on it.
OBJECTIVES:
Side Body-BIW
1. Checking the unit system and either following [Mg mm s] or [Kg mm ms].
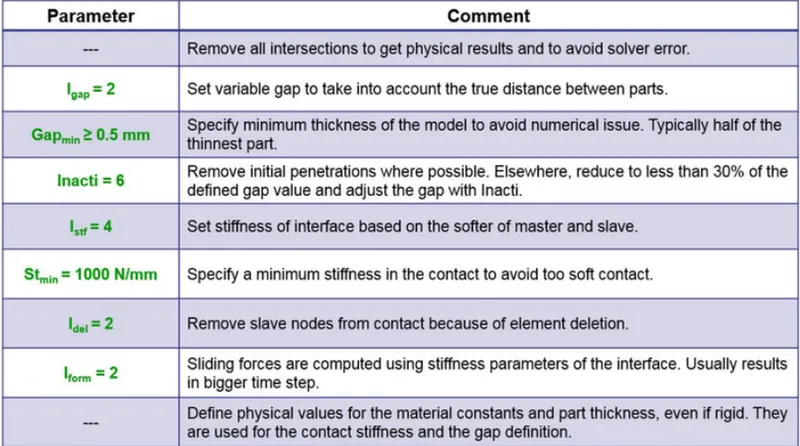
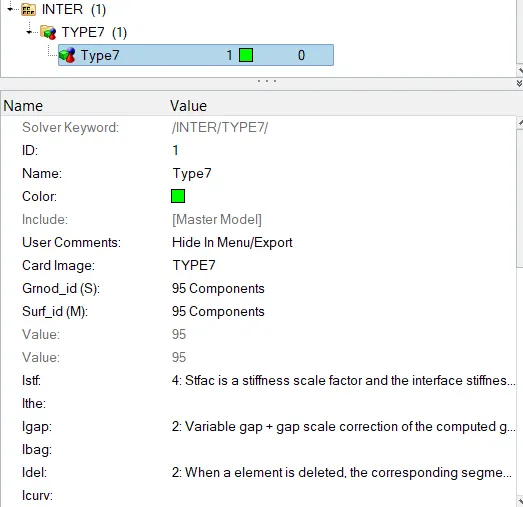
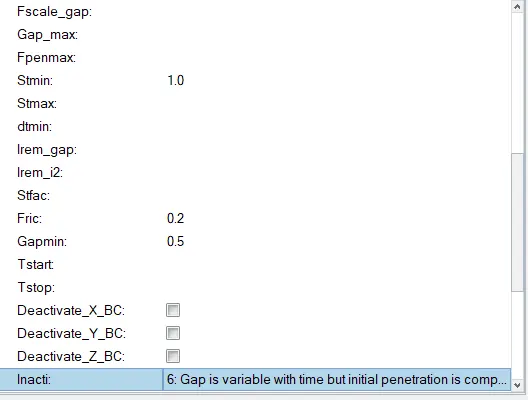
2. Creating appropriate interface, friction 0.2 and recommended parameters.
3. There should be no penetrations and intersections.
4. Creating a rigid pole with friction 0.1.
5. Adding masses to reach target weight 700kg while getting CG about the required range.
6. Adding Initial velocity 35 mph.
7. Running a model checker to ensure good quality.
8. Time-step: 0.5 to 0.1 microseconds.
9. Running 80 ms.
Output requests:
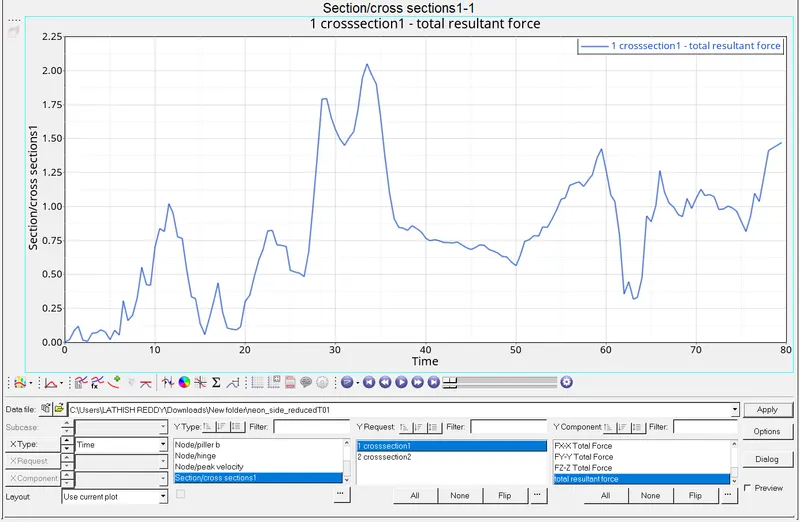
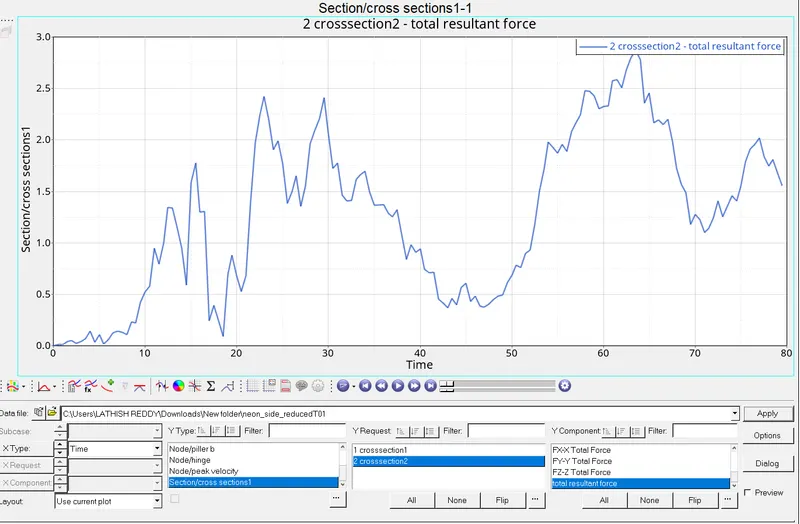
1. Sectional force in the cross member.
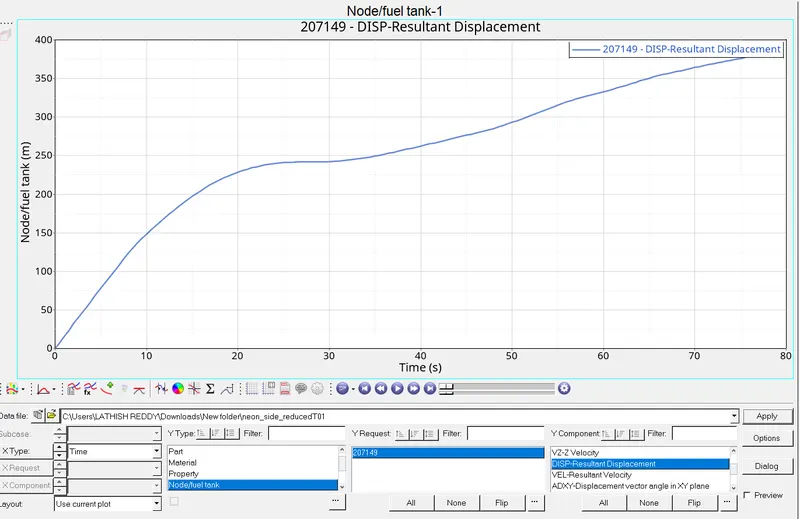
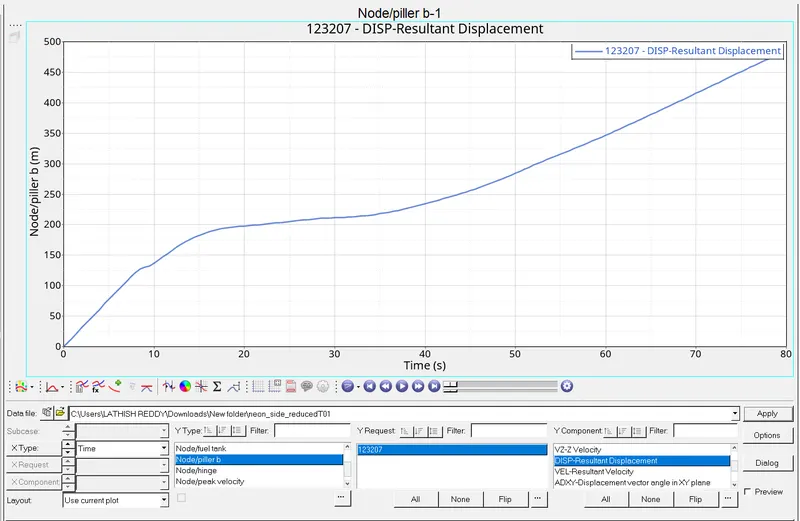
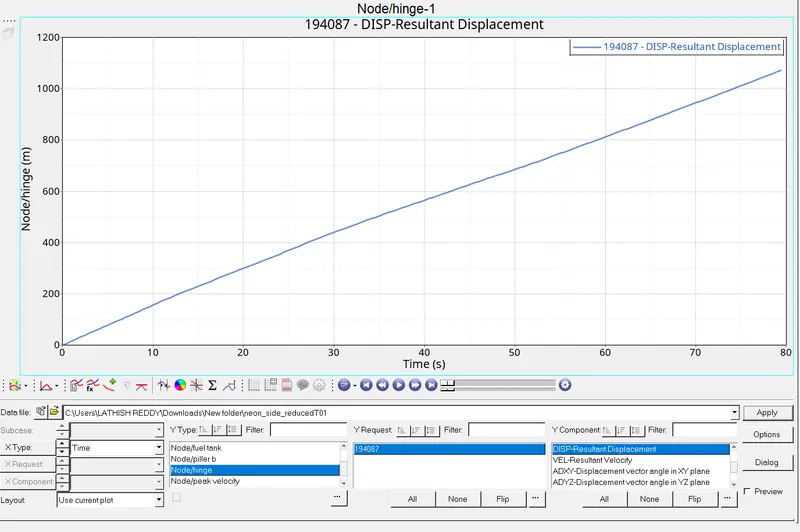
2. Intrusion at B pillar, hinge pillar and fuel tank region. Providing recommendations on what can help to reduce Fuel tank intrusion.
3. Peak velocity of inner node of the door.
ABSTRACT : In this project we are about to see the impact of the side body of the car when it hits to the pole, Side body is consist of two side doors with plastic body of arm rest in the windows with electric control panel one for driven and another for passenger, Here we will see that the impact on the side door,hinge, middle pillar,area near to fuel tank, section 1 and section 2 after it hit to the pole.
PROCEDURE OF OBJECTIVE 1:
Checking the unit system and either following [Mg mm s] or [Kg mm ms].
STEP 1: Open the starter file neon_side_reduced_000.rad file, go to-
*Menu bar>file>import>solver desk>select .rad file>import
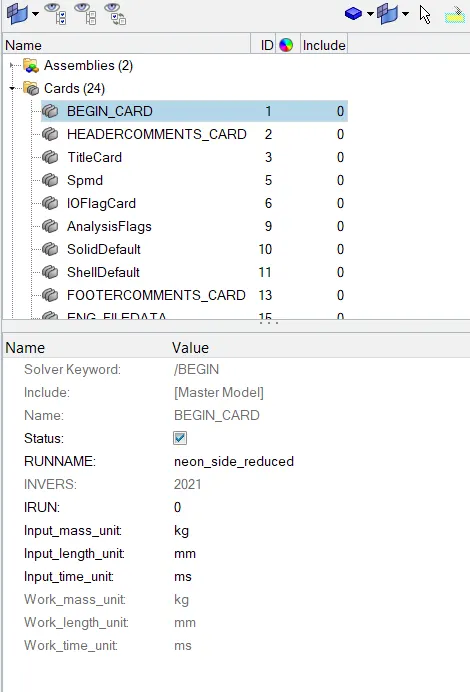
STEP 2: Checking unit system of the model
*Model browser>cards>begin card
PROCEDURE OF OBJECTIVE 2: Creating appropriate interface, friction 0.2 and recommended parameters.
*Model browser>groups>create group>
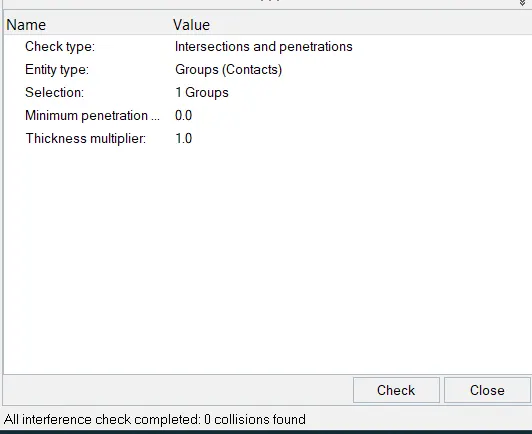
PROCEDURE OF OBJECTIVE 3: There should be no penetrations and intersections
*Menubar>penetration check>select group>check
PROCEDURE OF OBJECTIVE 4: Creating a rigid Pole with friction 0.1.
STEP 1: creating Rwall go to-
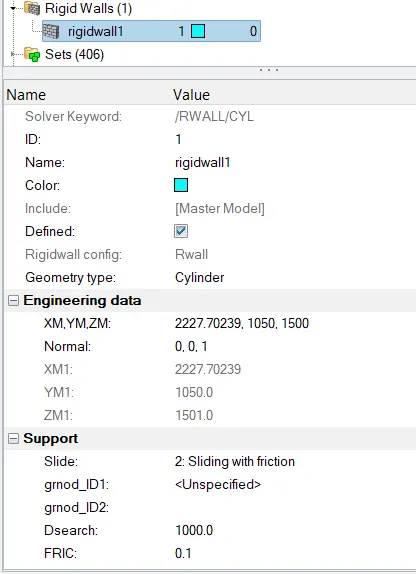
*solver model>create>rwall>CYL
STEP 2: Rwall CYL parameters and friction
We can see that the Rwall Collector has formed automatically in the Model Browser with all parameters given by us.
PROCEDURE OF OBJECTIVE 5: Adding masses to reach target weight 700kg while getting CG about the required range.
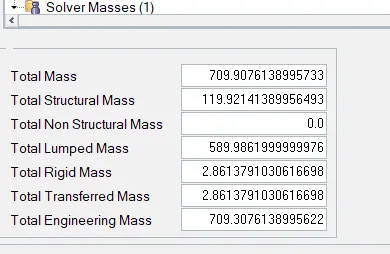
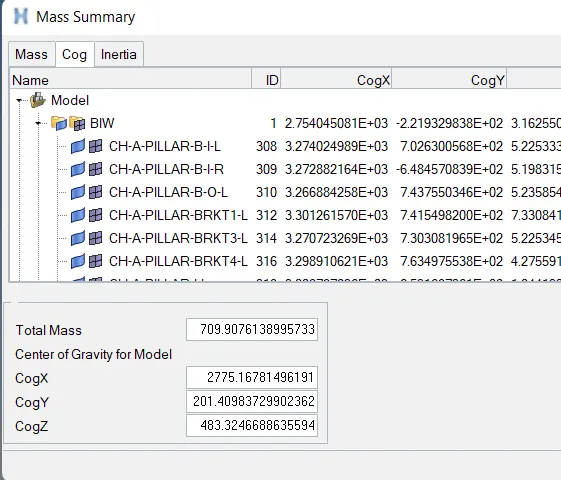
STEP 1: Opening mass summary
*Menu bar>tools>mass details>mass,cog,inertia.
STEP 2: Adding mass to increase overall weight of the car
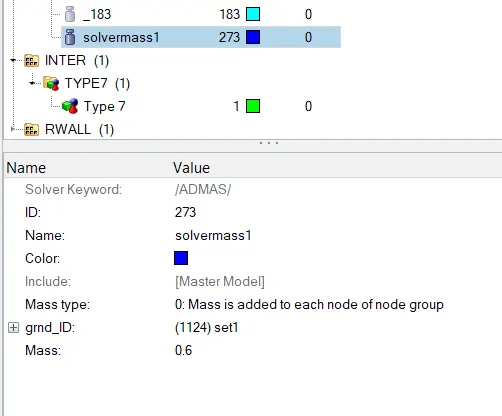
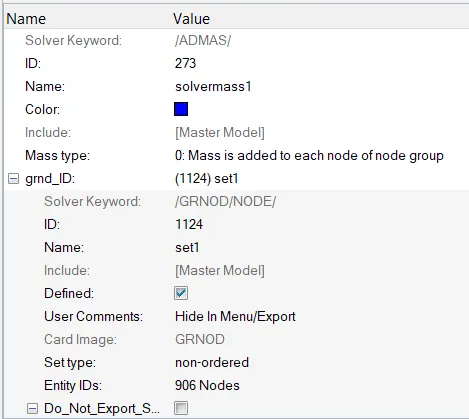
*Solver browser>ADMAS>create>extra mass>give GRNODE ID>select nodes>give mass value
At final we can see that mass is reached around 700 kg
PROCEDURE OF OBJECTIVE 6 : Adding Initial velocity 35 mph.
STEP 1: Creating card
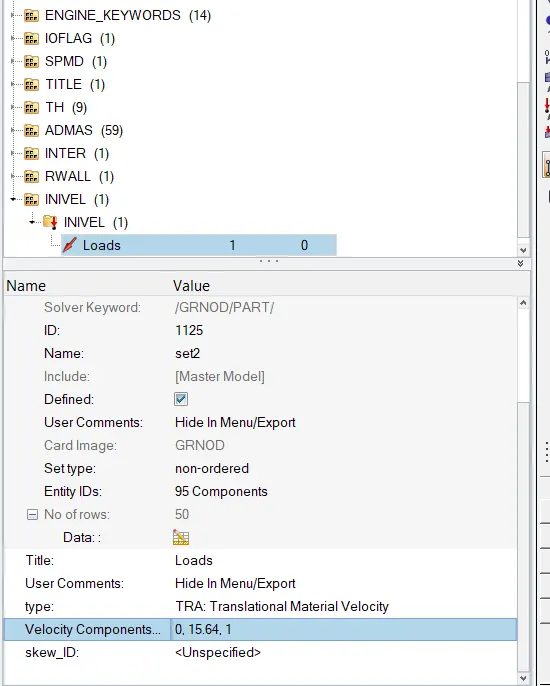
*Solver browser>create>boundary condition>INIVEL
STEP 2: Set GRNODE
*Solver browser>GRNODE>create>GRNODE>node>selcect nodes
STEP 3: Setting up INVEL Parameters
1 mile = 1.609mm
1 hour = 3.6ms
Vo = (35*1.609*10^6) / (3.6*10^6)
Vo = 15.64 mm / ms
We can see that the INIVEL is added to the model.
PROCEDURE OF OBJECTIVE 7 : Running a model checker to ensure good quality.
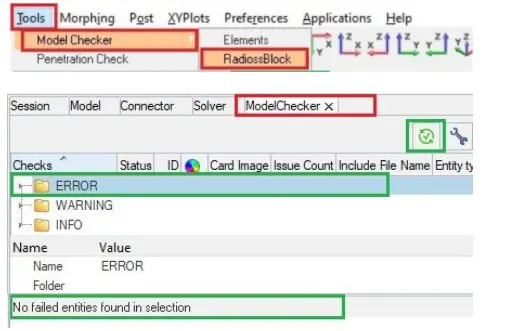
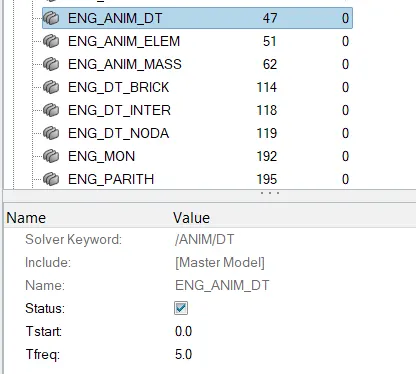
PROCEDURE OF OBJECTIVE 8 : Time-step: 0.5 to 0.1 microseconds.
*Model browser>cards>eng_anim_dt>Tfreq=5.0
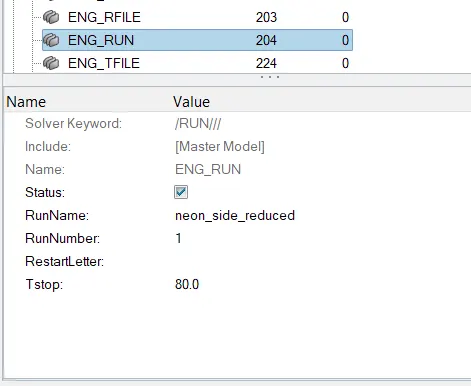
PROCEDURE OF OBJECTIVE 9 : Running 80 ms.
*Model browser>cards>eng_run>Tstop=80.0
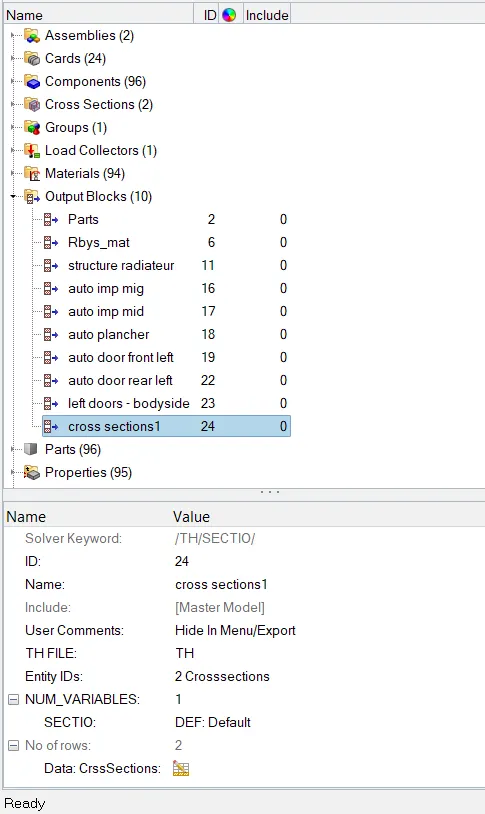
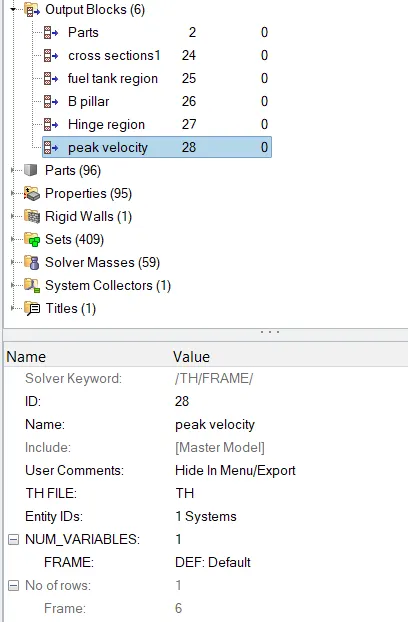
PROCEDURE OF OBJECTIVE 10 : Sectional force in the cross members.
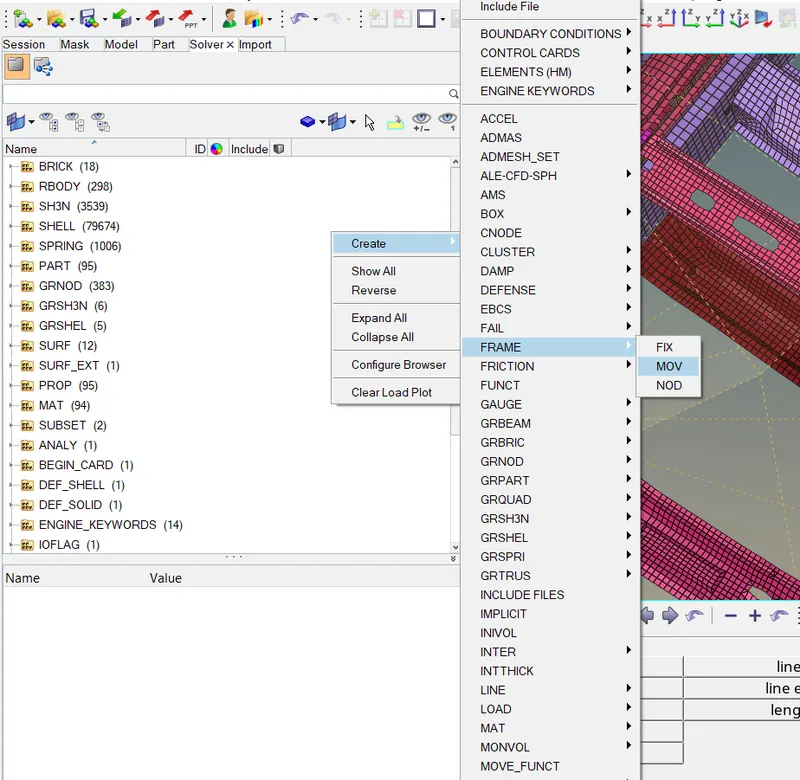
STEP 1: Creating FRAME card in solver browser.
STEP 2: Giving Parameters to FRAME>MOV
*Solver browser>FRAME>MOV>give origin,axis,plane node.
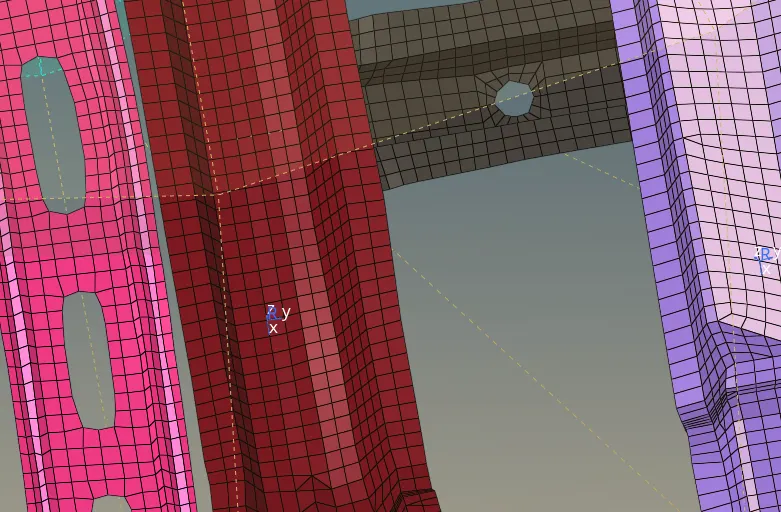
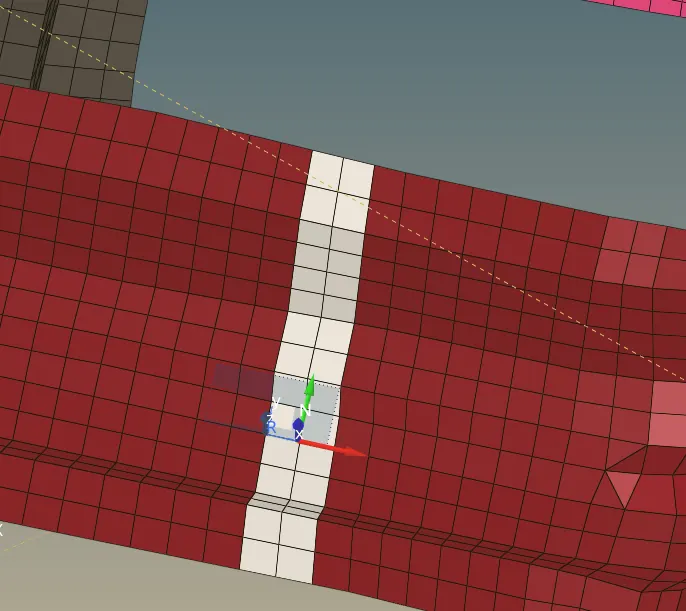
STEP 3: Creating SECT card in solver browser.
STEP 4: Giving parameters with GRSHEL elements selections to Components
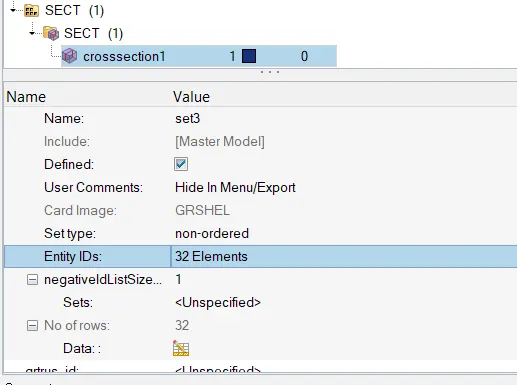
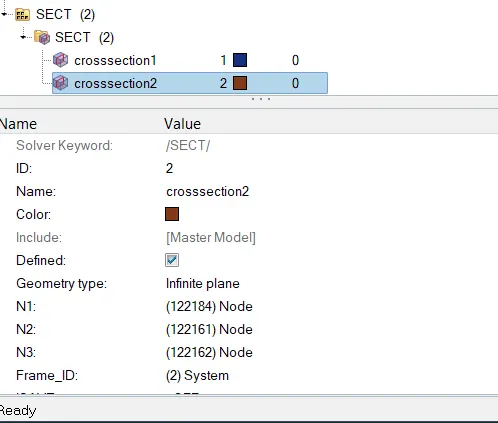
STEP 7: Giving Output Request in Model Browser
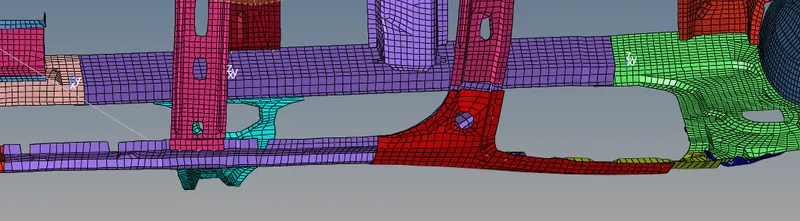
PROCEDURE OF OBJECTIVE 11 : Intrusion at Fuel tank region, B pillar and Hinge pillar.
Fuel Tank Region
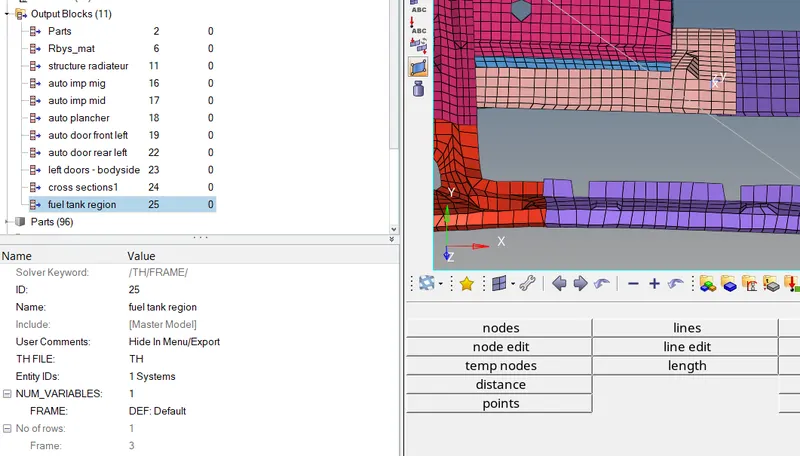
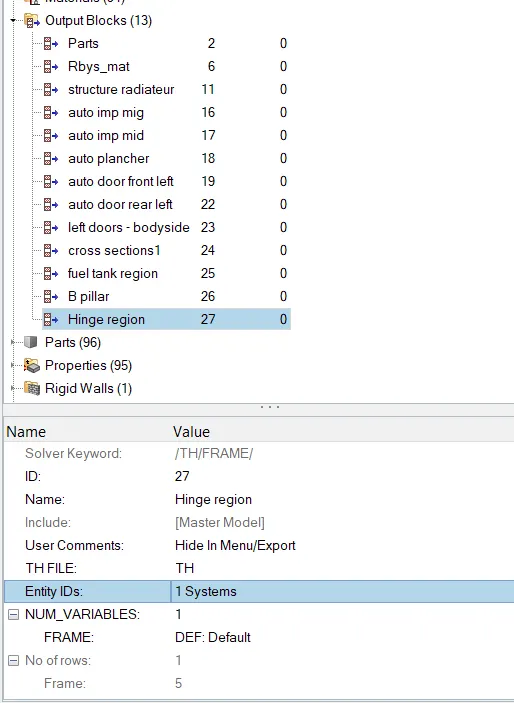
Fuel Tank Region
B Pillar
Hinge
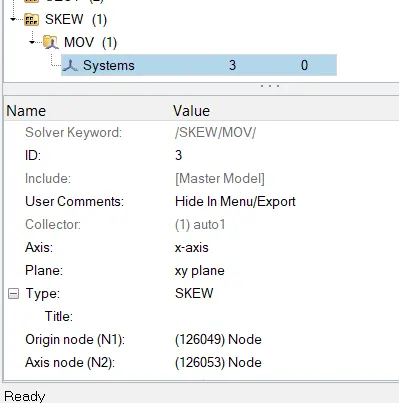
PROCEDURE OF OBJECTIVE 12 : Peak velocity of inner node of the door.
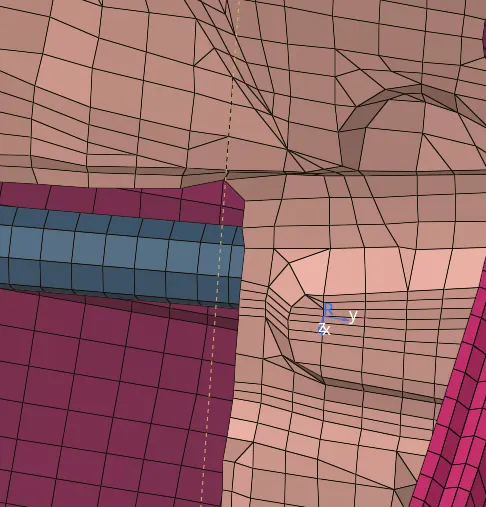
STEP 1: Creating a new local coordinate in SKEW collector of solver browser and giving origin,axis and plane nodes.
SIMULATION OF THE FRONTAL CRASH : Simulating and analysing the car's side portion crash.
STEP 1: Open Hyperworks in Radioss solver.
STEP 2: Import Solver desk Project_2_0000.rad file
STEP 3: Simulating model as it is.
*Analysis>Radioss>save as input Project_2_0000.rad file>Checkbox include collectors>Write (-nt 4) in options>Click Radioss
STEP 4: Switch to Hyper view
STEP 5: Select local model and result Project_2h3d file
RESULTS AFTER CRASH :
To plot the graph we need to switch to Hypergraph,
*Toolbar>select application to Hypergraph 2D>select runnameT01 type file
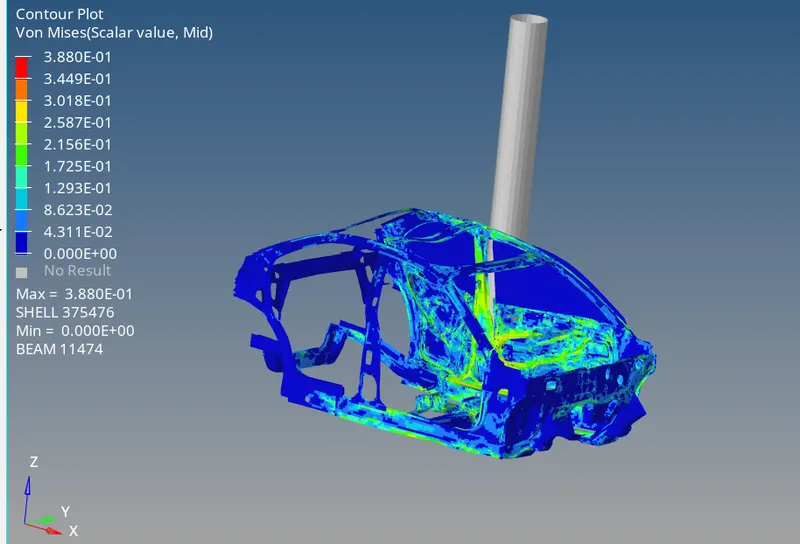
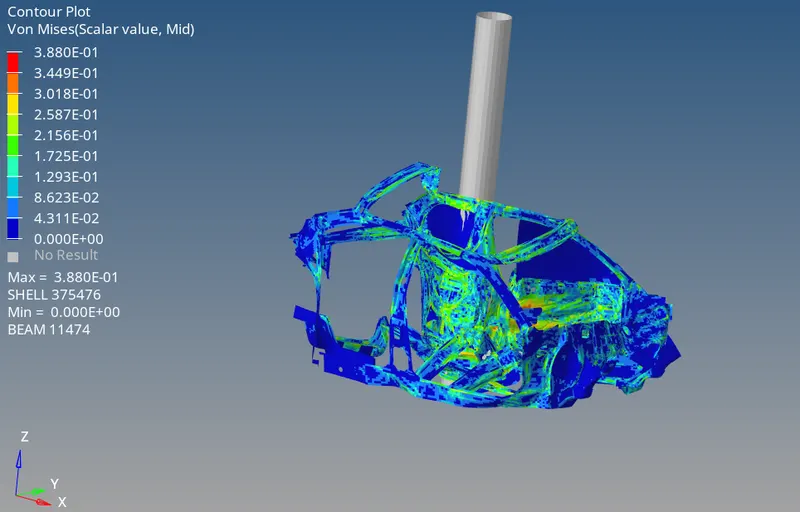
DISPLACEMENT
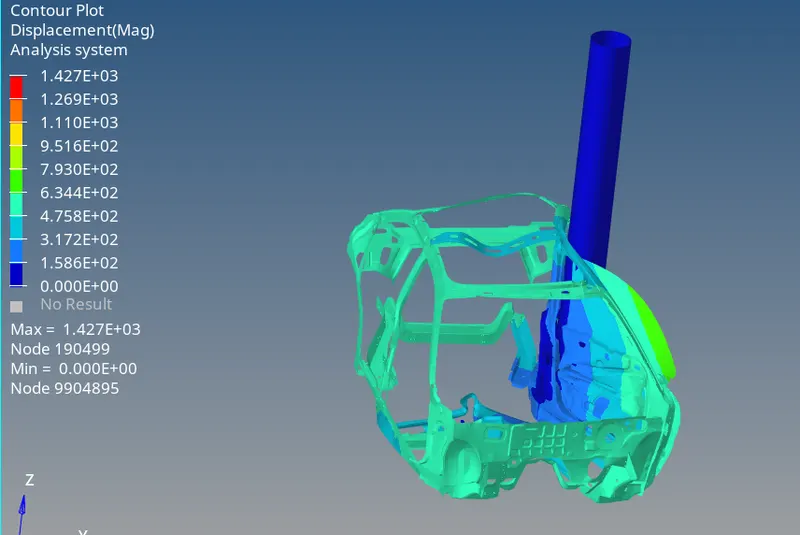
GRAPHS PLOTTED
Fuel Tank
B Pillar
Hinge
Cross Section 1
Cross Section 2
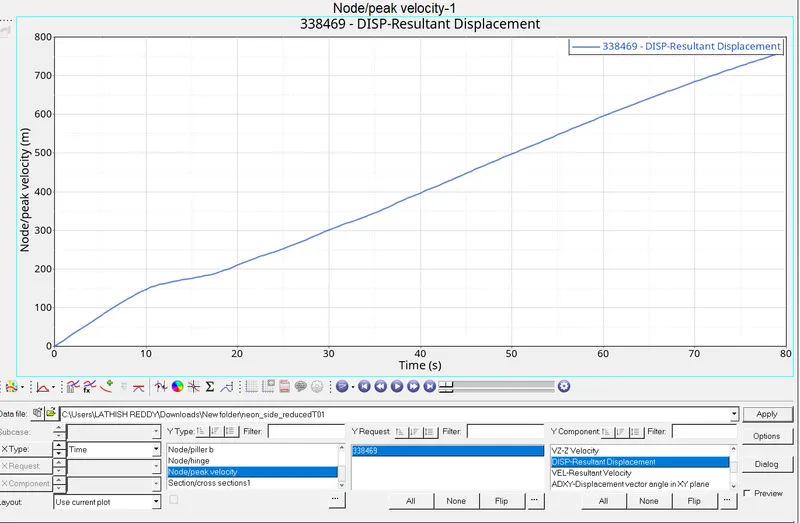
Peak Velocity in the inner of the door
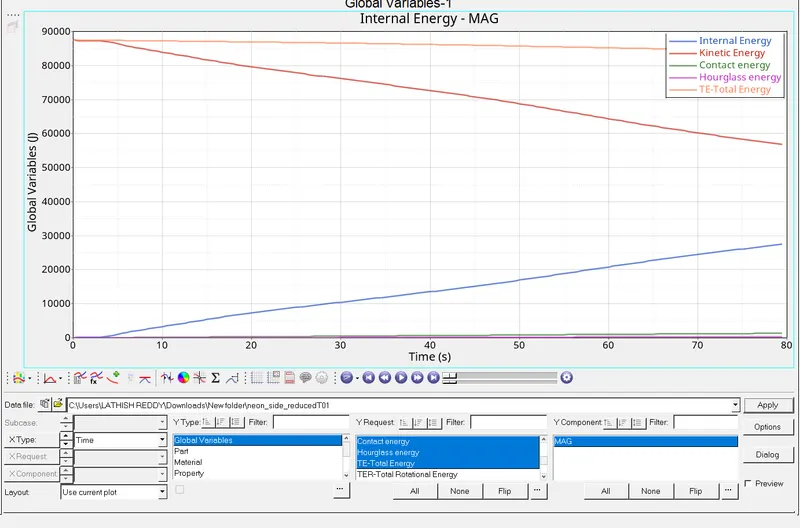
Energy Graph
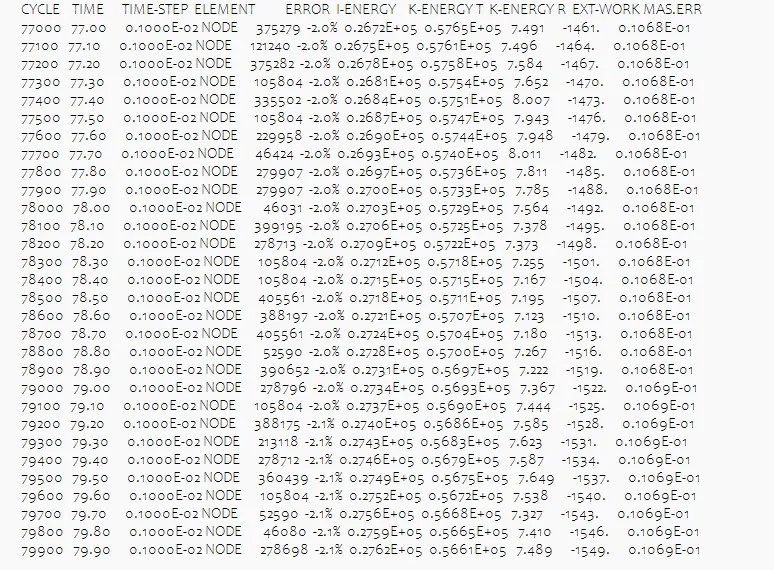
Number of cycles it takes, energy error, mass error and simulation time.
The output file shows us the number of cycle, energy error, mass error
OBSERVATIONS AFTER CRASH :
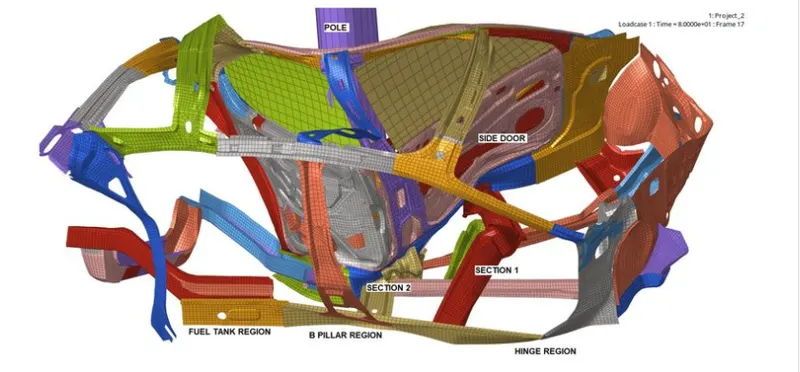
1.We saw in the animation that the most deformation took place in the middle pillar area and the stress is then passed to the side of the rest of the components.
2.We observed that the impact of the crash is mostly at the middle pillar side door of the car and by looking at this we can say that the seating area of the driver and passenger will be also impacted which can cause severe injury to them.
3.The energy graph is shown of Internal energy, Kinetic energy, Contact energy, Hourglass energy and Total energy Vs Time.
4.We can see that Internal energy increases with respect to time whereas Internal energy starts falling down from its peak as time increases.
5.Contact energy and hourglass energy graphs have values near to zero and Total energy remains almost constant as time increases.
LEARNINGS :
Importing starter file runname_0000.rad file
Using Radioss command
Running runname.h3D file in Hyperview to see animation
Reading runname_0001.out file
Using Hypergraph 2D.
Observing energies graph.
Creating Initial velocity.
Creating a Rigid cylinder.
Creating Peak Velocity.
Changing Type 7 parameters.
Type 7: Type 7 card is used to simulate all types of impact between a set of nodes and master surface. Main advantage of type 7 is stiffness is not constant and
increases with the penetration preventing the node from going through the shell midsurface.
Istf 4: Stfac and stiffness is computed from both master and slave characteristics.
Igap 2: variable gap + gap scale correction of the computed gap.
Idel 2: When a 4-node shell, a 3-node shell or a solid element is deleted, the corresponding segment is removed from the master side of the interface. It is also
removed in case of explicit deletion using Radioss Engine keyword /DEL in the Engine file. Additionally, non connected nodes are removed from the slave side
of the interface.
Stmin 1: minimum stiffness (N/M)
GAPmin : Minimum gap for impact activation.
Inacti 6 : Gap is variable with time but initial penetration is computed .
Iform 2 : Stiffness (incremental) formulation
Center of Gravity : The center of gravity (CoG) of an object is the point at which weight is evenly dispersed and all sides are in balance.
Rigid Cylinder: Rigid cylinder is created in the HyperMesh where the car is going to make collisions.
Penetration: There should not be any penetration because nodes get penetrated in the element and cause failure in simulation, removal of penetrated nodes is necessary.
Intrusion: Intrusion is used to check that if the component is withstanding a crash making sure that the component does not fail.
Peak Velocity: It is the highest velocity attained during the impact of the side body (object) at a particular time.