Frontal Crash Test of Dodge Neon BIW Model using RADIOSS
Frontal Crash Test of Dodge Neon BIW Model using RADIOSS
Objective
To Perform a Frontal Crash Test and study the sectional forces, contact and intrusions to conclude the safety of the passenger.
Here is the Basic setup for Frontal Crash test:
i. Set the Unit system (Kg-KN-mm-ms).
ii. Balance the Mass and Centre of Gravity of the Car.
iii. Create a Rigid wall and Type 7 Interface without any penetration.
iv. Create Sections on the respective components.
v. Check Intrusions on the Dashwall.
vi. Study the Acceleration on the Rocker (B-Pillar base).
vii. Perform a Model checker to ensure error-free results.
Procedure
Step 1: Import
Import > Solver Deck > FIRST_RUN_0000.rad (select) > Import
The starter file is in ASCII (American Standard Code for Information Interchange) format and contains model information such as:
i. Nodes
ii. Load Conditions
iii. Velocity
iv. Boundary Conditions, etc.
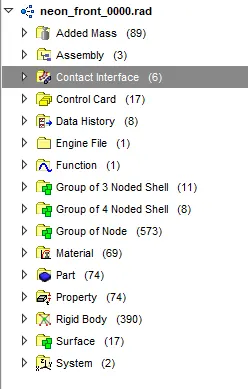
[Note: The starter file should always end with 0000.rad. After changing the parameters (Eg. Velocity) and running the next simulation, the file becomes FIRST_NAME_0001.rad and so on.]
1.1 Delete existing Interfaces
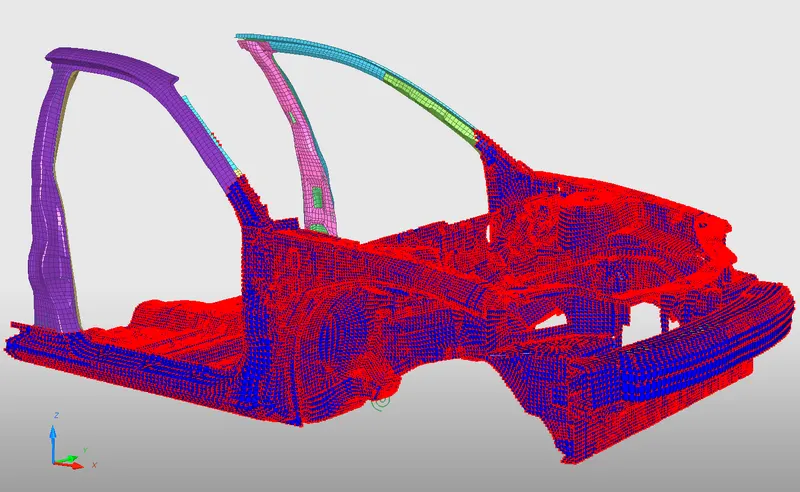
We will be defining our own interfaces for the frontal crash test, so delete the existing interfaces.
Model > Groups > Delete
Step 2: Add Mass
Current weight:
Target weight: 700 Kg
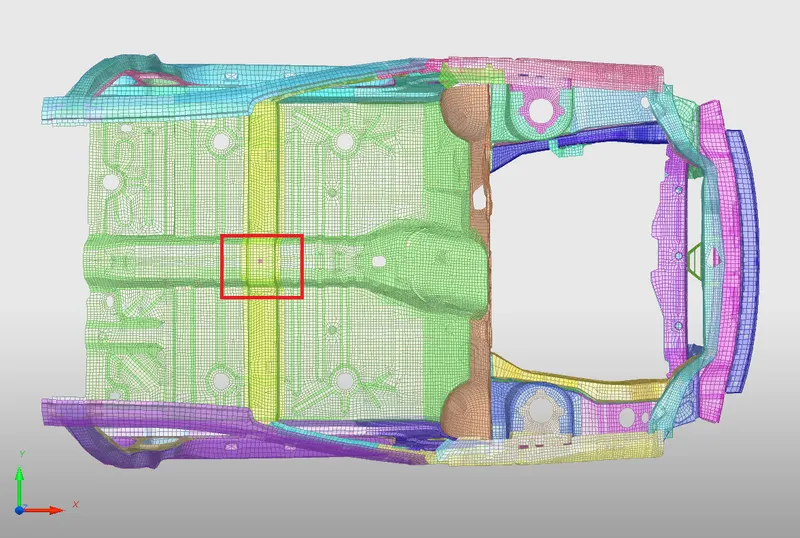
i. We have to add the mass in such a way that the Centre of gravity is exactly in the middle of the Cross Beam to simulate the real-time model.
ii. We are only worried about the position of the COG (X and Y axis) and not the height (Z-axis).
iii. We use Type 1 Mass, where mass is distributed on each node of the selected group.
Added Mass > Create New > Type =1 > Enter the Value (Eg. 100 Kg) > Select the group node by selecting in the graphics
Step 3: Create a Rigid wall
i. It is a Shell element with no thickness (gap) and infinite thickness.
ii. A search tolerance is given (optional) so that the nodes within the range will be taken as slaves.
iii. We are going to create an Infinite plane type Rigid wall.
[Note: To ensure that the Rigid wall is straight and not inclined, we have to create a temp node on the bumper and translate (Shift + F7) it along the global X-axis.]
Browser > Create > Rigidwall > Enter the coordinates of the Temp node [XM, YM, ZM] > Enter the Direction of the Normal [-1, 0, 0]
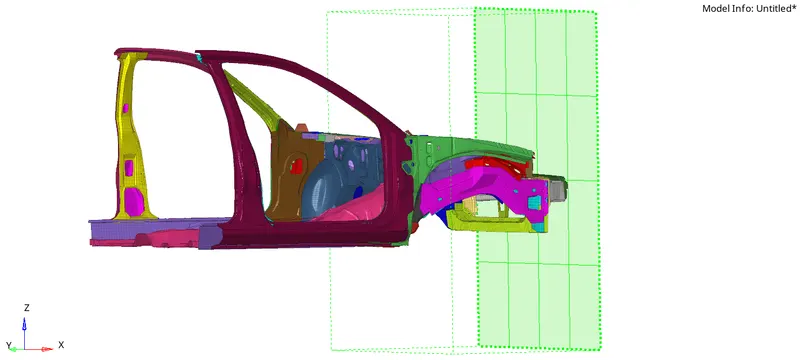
iv. The rigid wall is facing opposite to the car so the normal is on the negative X-axis.
v. We have to provide frictional parameters for the rigid wall when the slave nodes come in contact:
a. Friction type [Slide] = 2 : Sliding with friction
b. Frictional Coefficient [FRIC] = 0.1
Step 4: Create Interface
i. The interface is the Interaction of Parts when they come in contact with each other. This leads to the Penetration of the Slave nodes into the Master Segment.
ii. We are creating a type 7 Interface for:
Impact [ Master: Rigid wall, Slave: Car model]
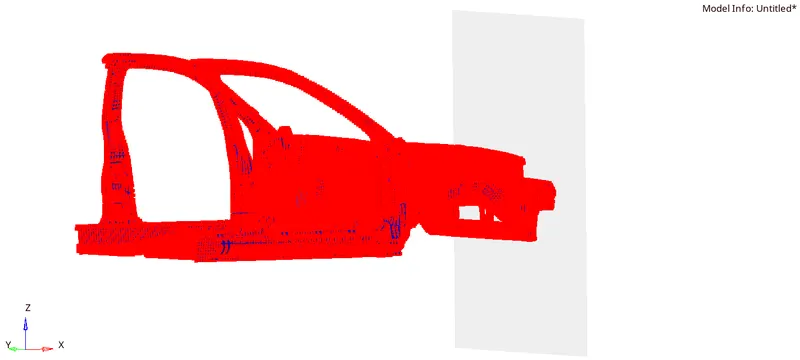
Self [Master and Slave: Car Model]
iii. Contact between Bumper and Rail [Master: Rail component, Slave: Bumper by selecting Group nodes]
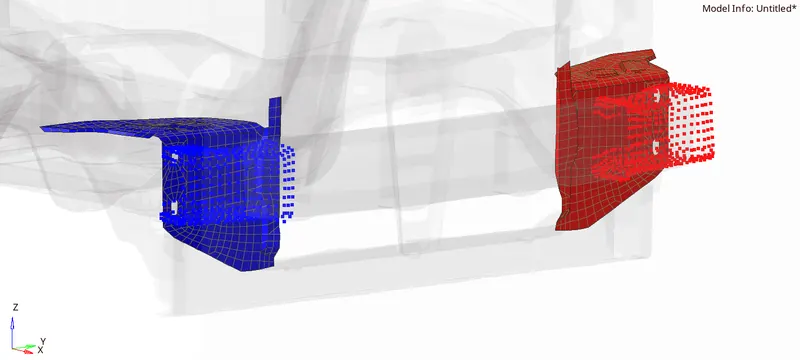
iv. The penetration caused by contact is governed by the Penalty Method. We will be giving Parameters in the Engine Card to make sure that the penetration doesn't happen.
| Control Card | Description |
| `I underset(stf` = 4 | Initial Contact stiffness |
| `Iunderset(gap`= 2 | Variable Gap + Scale Correction |
| `I underset (DEL` = 2 | The Failed Element gets deleted by removing the Master Segment in Contact and deleting the free Slave Nodes. |
| `St underset (min` = 1.0 | Minimum stiffness, to avoid Timestep error. |
| Fric = 0.2 | Columb friction, for modeling tangential forces between contact surfaces. |
| `Gap underset(min` = 0.5 | In case `Iunderset(gap` fails, `Gap underset(min` is used to avoid penetration. |
| Inacti = 6 | The Gap is reduced and removes Penetration error. Further Gap scaling is done to a factor of 0.8 |
| `I underset(FORM` = 2 | Friction formulation during contact (results in bigger timestep) |
Step 5: Plot Sections
i. We have to know how the forces are transmitted from the Bumper to the Dashboard and the rate of deformation. It is done in order to ensure the safety of the passenger.
ii. Certain components have to crash (deform) more than the other so that the forces are distributed correctly leaving very little force left to transmit inside the cabin.
iii. We are creating sections for the following parts:
| Sl.No. | Left side | Right Side |
| 1. | Rail | Rail |
| 2. | Shotgun | Shotgun |
| 3. | A-Pillar | A-Pillar |
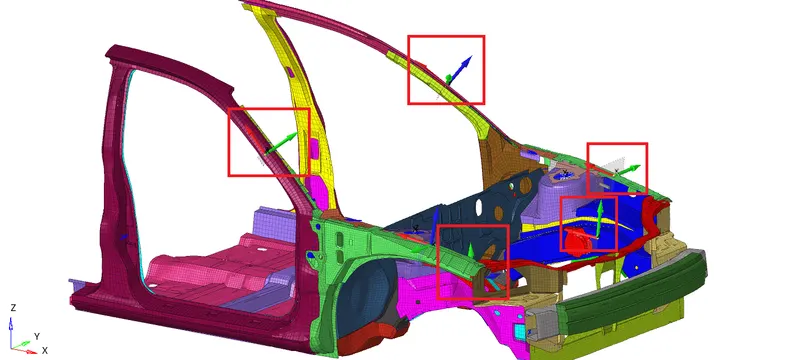
[Note: Make sure that the sections are placed along the same line on either side of the vehicle to study exactly what is happening on the sections of the left and right parts.]
iv. The Sectional forces should be transmitted in the following descending order:
Rail > Bumper Interface > Shotgun > A-Pillar
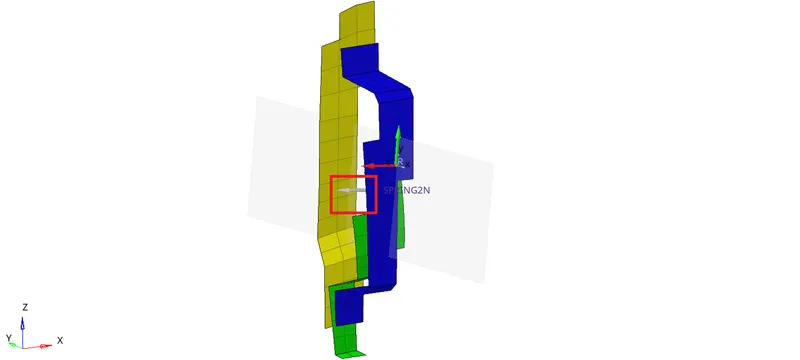
v. On each part, we introduce a Moving Frame that acts as a local coordinate system for the geometry. This will help us understand the Sectional forces passing through the Elements (around the cross-section of the geometry).
Create > Frame > Select the Nodes
| N1 | Origin |
| N2 | Axis (Z-axis) |
| N3 | YZ Plane |
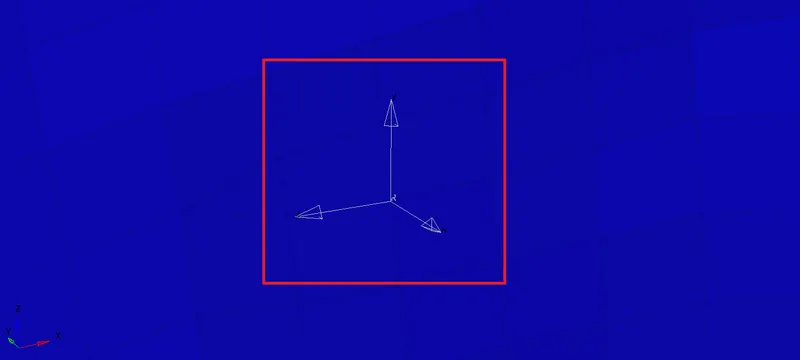
vi. Now we have to create a section with respect to the frame id. The section is created in order to select the elements around the cross-section.
Create > Section > Enter the Parameters
| Nodes | N1, N2, N3 |
| Frame id | Select the frame that we just created. |
| delta T | 0.1 |
| alpha (scale factor) | 0.67 |
| grshel_id | Select 2-4 rows of Shell elements about the frame, around the entire cross-section of the part |
Step 6: Initial Velocity
i. The Velocity is given in mph so we have to convert it into the required unit system, i.e. m/s.
| Velocity in mph | 35 |
| Velocity in m/s | 15.6464 |
ii. Initial velocity is a Boundary Condition defined to a group of nodes (car model).
iii. No function (curve) is required since it is instantaneous. Therefore, it reduces the computation time for the solver.
Parameters required:
| Velocity | 15.6464 [X], 0 [Y], 0 [Z] |
| Skew Id | Global System |
| grnd_Id | Select the nodes by creating a Set |
Step 7: Intrusions on Dashwall
i. We are planting Spring elements to study the intrusions (forces inside the cabin causing deformation/rupture).
ii. Create 2 parallel spring elements from the indicated nodes (966695,66244) till the Crossbeam.
iii. Springs can be created from the 1D Panel > Springs
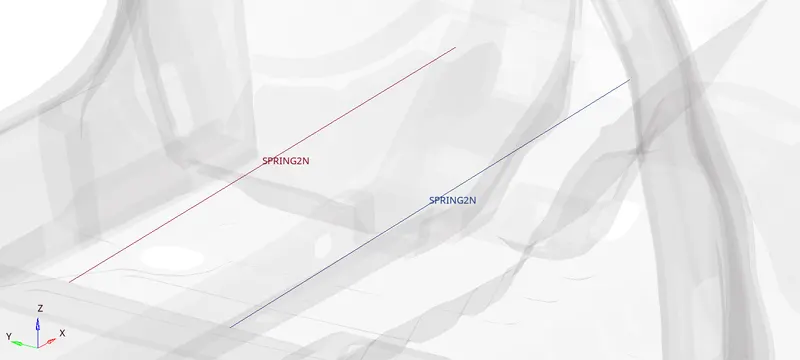
iv. Change the Spring properties in the card:
| Card Image | P4_Spring |
| Mass | 0.001 |
| Stiffness (K1) | 0.0001 |
[Note: The spring's properties shouldn't interfere with the computation so give Negligible Mass and Stiffness for the spring .]
Step 8: Accelerometer
i. We are planting an accelerometer on the Base of each B pillar.
ii. This is done to get the Acceleration output of the Crash i.e. rate of deformation.
Create > ACCEL > Select the Node by ID
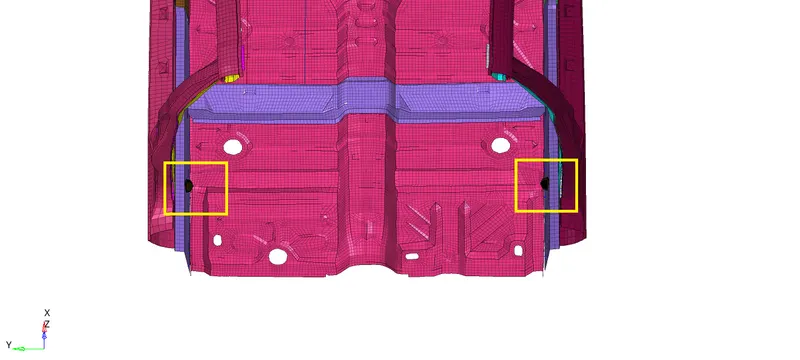
[Note: Make sure the accelerometer is placed in the same positions on the left and right B pillars].
Step 9: Timestep Control
| Engine Card |
`T underset(SCALE` [Scale factor] |
CST [Constant time step method] |
`T underset(min` [Critical Timestep] |
Description |
| ENG_DT_NODA | 0.67 | Default | 0.0003 | Mass is added to the node when the computed timestep becomes smaller than the critical timestep. |
| ENG_DT_BRICK | 0.9 | Default | 0.005 | Controls the timestep by small strain formulation on the elements if they cause the timestep to drop. |
| ENG_DT_INTER | 0.9 | Default | 0.005 | Uses default constant timestep method. |
| ENG_DT | 0.9 | --- | 0.0003 | We enter the Critical Time step here. |
Step 10: Call the Time History Files
i. They are Output files that are requested in the Starter File.
ii. All the Global variables (Internal energy, Kinetic energy, Contact Energy, Hourglass Energy, etc.) are already requested by default.
iii. We have to call for additional Time History files for the boundary conditions that we have created for the frontal crash model.
iv. We can create the Output requests from within the Solver Browser:
Solver Browser > Right Click > Create > TH > Select the Output Request
| Output Requests | Boundary Conditions |
| INTER |
i. Impact ii. Self iii. Bumper & Rail |
| ACCEL |
i. On Left B Pillar ii. On Right B Pillar |
| SPRING |
i. Intrusion on node 66695 ii. Intrusion on node 66244 |
| RWALL | i. Rigid Wall |
| SECTION |
i. Left Rail ii. Left Shotgun iii. Left A-Pillar iv. Right Rail v. Right Shotgun vi. Right A-Pillar |
Step 11: Check for Penetrations
i. Although we have given all the Interface parameters (such as `I underset(gap`, `Gap underset(min`, Inacti, etc.) it is better to check for penetrations before simulation.
ii. Penetrations could be a result of not defining the interfaces properly, or incompatible kinematic conditions at contact, etc.
Tools > Penetration Check
| Groups |
i. Self ii. Left Bumper & Rail iii. Right Bumper & Rail |
| Minimum Penetration Depth | 0.5 mm (Same as `Gap underset(min`) |
Step 12: Model Checker
i. This is the last and final check for the model before giving it for simulation.
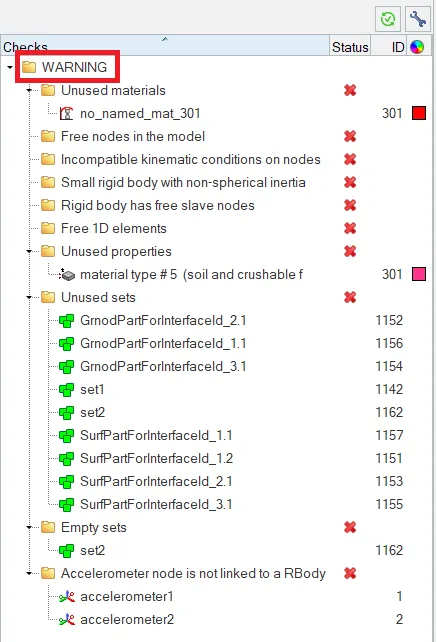
ii. The Model checker will give us any warnings and Errors regarding the model definition and, the boundary and Kinematic conditions, etc.
iii. For example:
a. Boundary Condition is not defined properly
b. Incompatible Kinematic Condition
c. The Part Property or material is not defined properly, etc.
iv. We can avoid the Warnings as the solver will take care of them.
v. But we must fix every Error in order to get a successful simulation free of problems.
Tools > Model checker > Radioss block > Check Runs
Step 13: Conduct the Analysis
Analysis > Radioss > Input File : (File Location) > Hit Radioss
- The input file is the same Started file (contains model information) that we had just imported.
- The animation video along with the frames will be saved in the same folder where the starter file exists.
Step 14: Review the Simulation
We have to import the animation file in Hyperview first:
Hyperview > Load File > FIRST_RUN. h3d > Apply
i. The tools to review the simulation are available on Hyperview.
ii. Hyperview is a post-processing and visualization environment for FEA that gives the output of the analysis in a simulations format that is user friendly to understand.
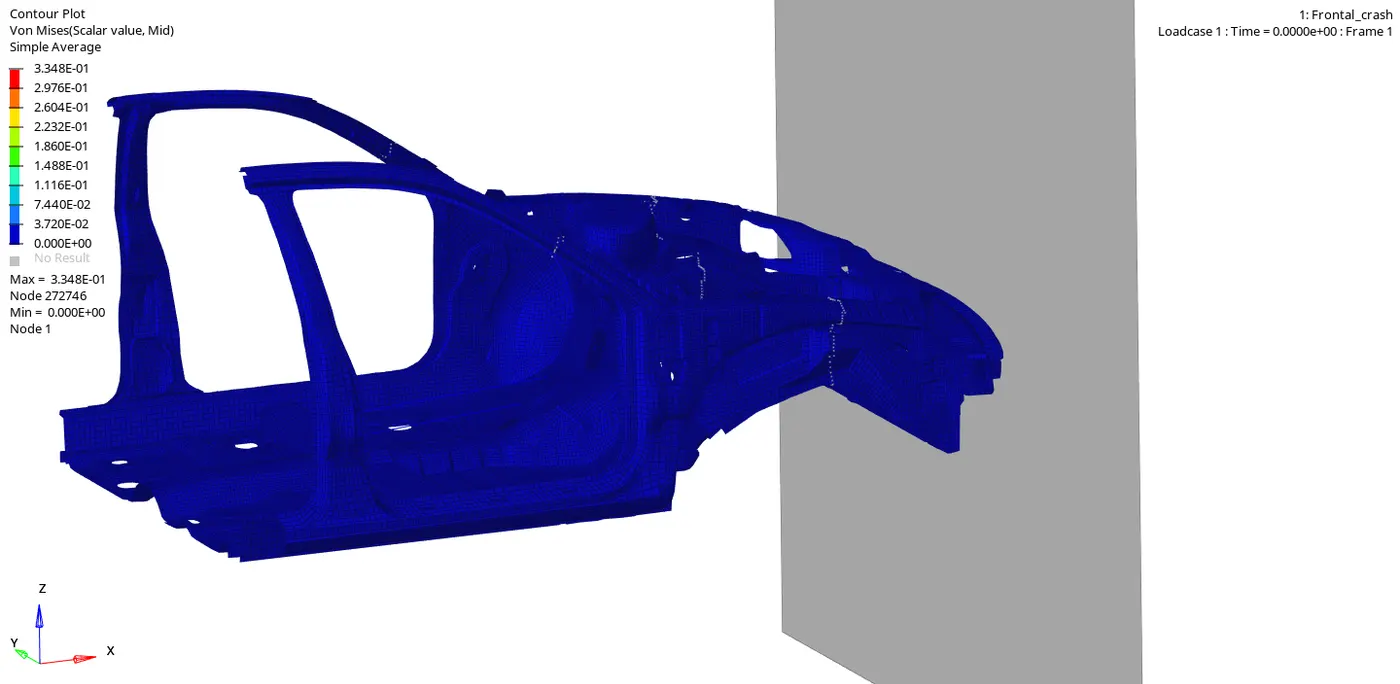
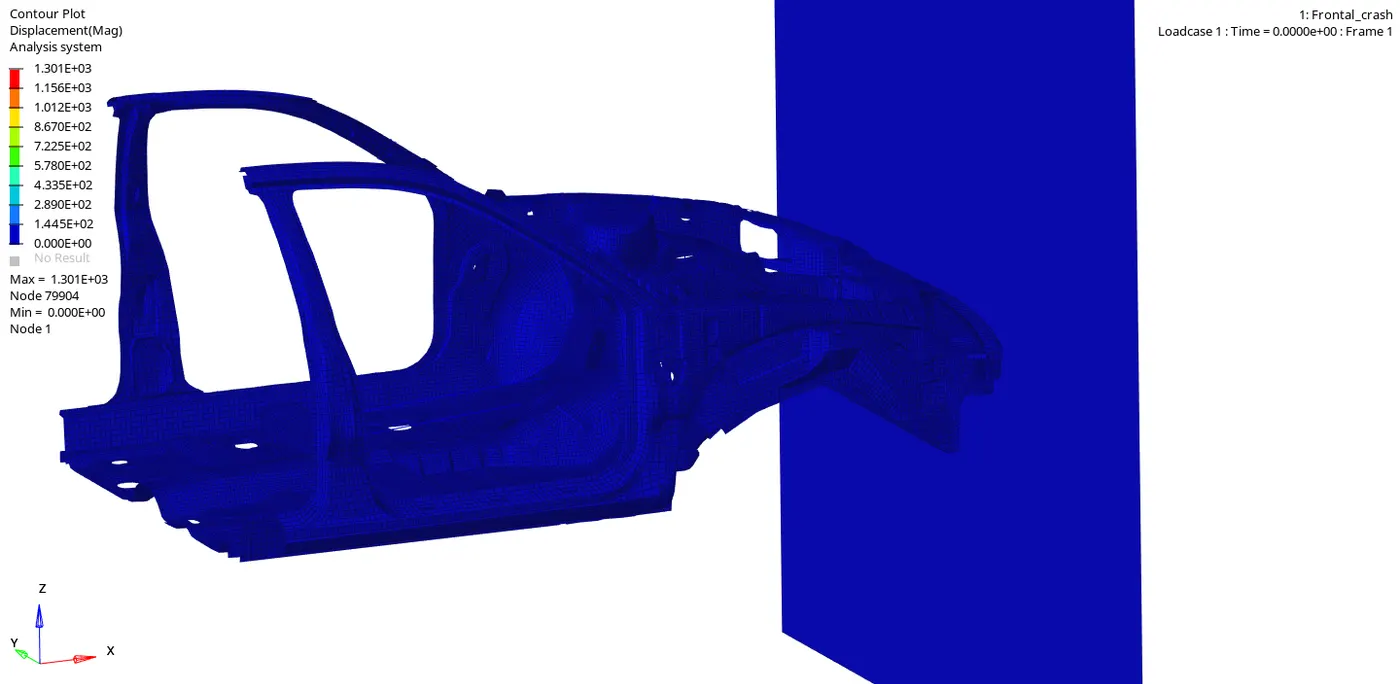
iii. From the simulation, we can review how the impact force acts and causes deformations and point of rupture on the model.
| Von Mises Stress (KN/mm2) | Displacement (mm) |
 |
 |
Step 15: Debugging errors
Check the Starter Output File for Errors:
i. A starter Output file of .out format is generated after analysis.
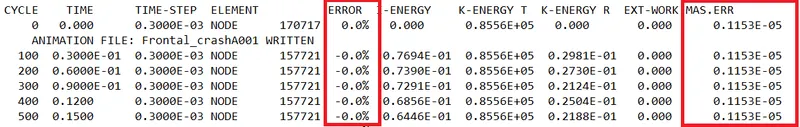
ii. The Output file contains the data during simulation, such as Cycle, Timestep, Energies, and Errors.
iii. We have to check for energy and Mass error.
iv. The Simulation tells only half the picture, we have to study the various energies acting on the system.
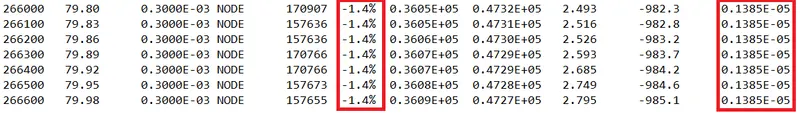
Note: There are some rules to be followed:
i. The error must be Negative and decreasing.
ii. It is normal if the error slightly increases and then increases.
iii. There is a problem if the error only increases, it will reach 99.9% showing computational failure.
iv. The Range for acceptable error is -15% to +5%.
Observation
i. The Energy Error is Negative and has been linearly increasing up to 1.4% only, which is acceptable.
ii. There has been an Initial Small strain Formulation on the Nodal Mass in order to control the Timestep and has lead to a very small Mass error in the first cycles itself.
iii. The addition of masses from then onwards has been very linear and gradual which is acceptable.
iv. We can conclude that there are no errors in the analysis.
Step 16: Plot the Graphs and compare the Results
The tools to plot the graph are available on Hypergraph.
Hypergrapgh 2D > Data File > FIRST_RUNT01 > Apply
Hypergraph is a data analysis and plotting tool that represents the FEA from the simulation in graphs with respect to the selected unit system.
|
Variables |
Variable v/s Time | Description |
|
Global Variables [Kg*mm/ms2] |
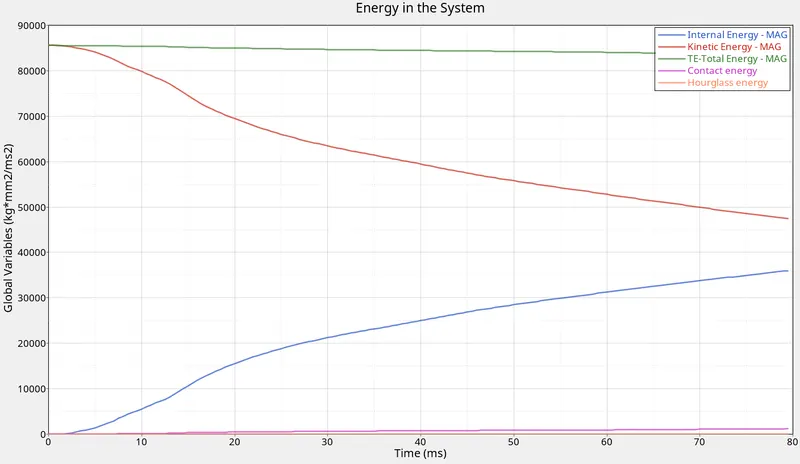 |
i. Ideally, the Total energy (TE) should remain constant, but there are bound to be losses during a contact. The negligible decrease is acceptable. ii. Internal energy, IE (Strain energy due to deformation) increases linearly as the contact increases. iii. The resistance of the Rigid wall causes the vehicle to a standstill. The Kinetic energy (KE) reduces gradually as it is being converted to Strain energy (Internal) and we can visually see that as Deformation in the model. iv. The Contact energy (CE) is very small, but increases very slightly over time as the deformation increases. v. Hourglass Energy (HE) is taken care of and doesn't affect the Timestep and Energy error. The Total Energy in the system remains constant will only -1.4% Energy error (due to small strain formulation). TTE = IE + KE +RKE + CE + HE |
|
Axial forces at Bumper and Rail Interface [KN/mm] |
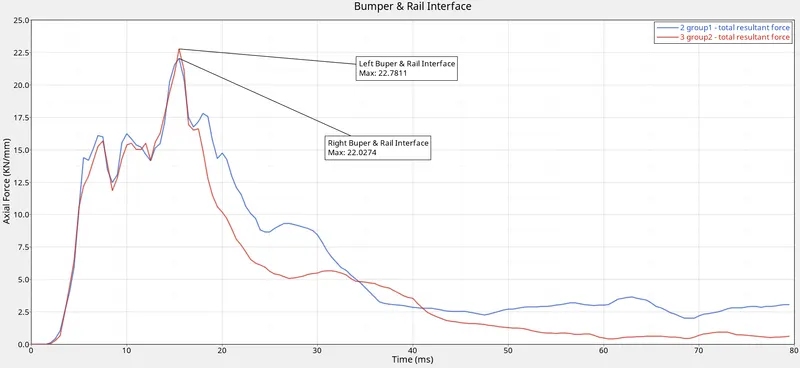 |
We can see that the forces are almost equally getting distributed on either side of the Bumper-rail interface. The first peak occurs at around 7 ms, but due to the increase in contact (self and between rigid wall), the resistance forces (through self contact in bumper) and the opposing forces (rigid wall) act together and results in a further increase on the axial forces on the bumper at 15.5 ms. At that point the bumper reaches failure and no more strain energy can be absorbed. Therefore the forces gradually decrease on the interface. |
|
Sectional forces at Rail [KN/mm] |
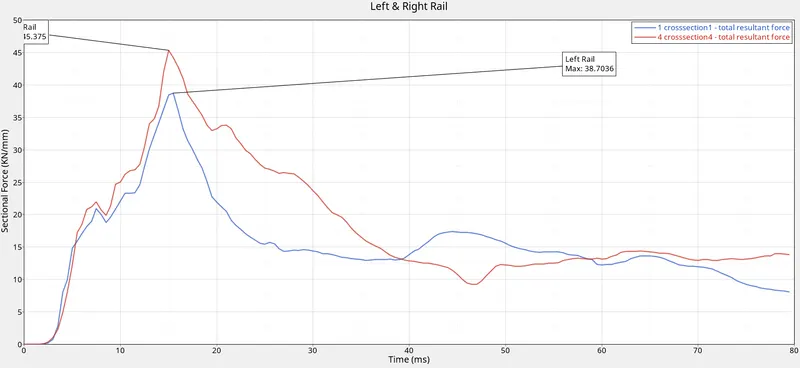 |
There is a hole present in the Right Rail cross-section, along with tria elements at the edges. This leads to stress concentration, therefore an increase in sectional forces in that particular region. Also, the increased forces cause the Right Rail to fail slightly quicker (by .5 ms) than the Left rail. After reaching plastic failure at around 15ms, no more resistance is offered by the component indicating that this part is designed to fail soon so that the forces can get distributed accordingly to other components. From the Plots and Graphs, both the Rails deform at almost the same time. |
|
Sectional forces at Shot Gun [KN/mm] |
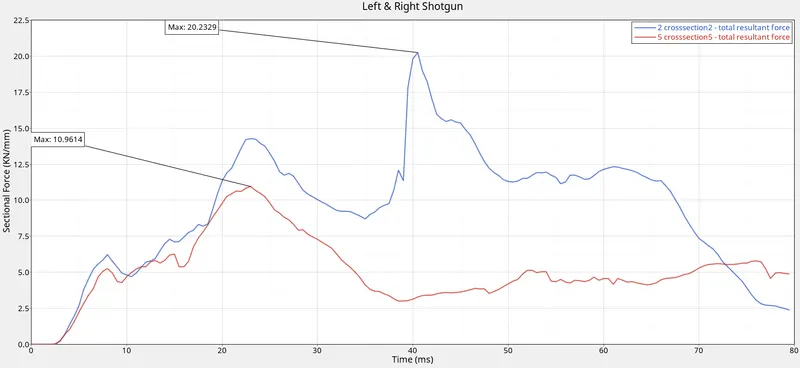 |
As lesser forces have passed through the Left Rail, which means more forces are left to be distributed to the next components, i.e. Shotgun. . The Contact is increased at Shotgun. Left Shotgun Resistance force due to the Rigid wall and the self Contact causes the Left Shotgun to undergo more axial forces of 20.23 KN/mm at 40.5 ms. Right Shotgun undergoes lesser deformation contact and deformation. |
|
Sectional forces at A-Pillar [KN/mm] |
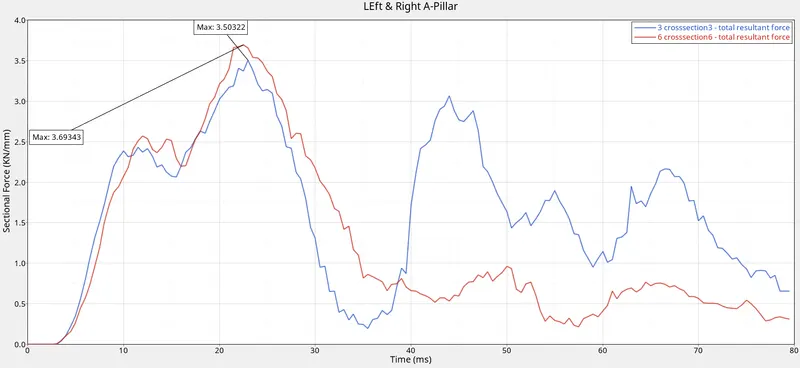 |
The Sectional Forces transmitted to the A-pillar are very small (about 3.5 KN/mm) which is a good indication that lesser forces are being transmitted inside the cabin. The Peak Sectional forces are transmitted at the same time as Shotguns'. The forces on Right A-Pillar gradually decrease after reaching the peak. And we can also see from the simulation that there isn't much deformation too. The Forces on the Left A-Pillar increases again at 44ms indicating that it is undergoing more strain. As we can witness the bending in the simulation. LH A-Pillar bends more than the RH A-Pillar. |
|
Intrusions on the dashboard [mm] |
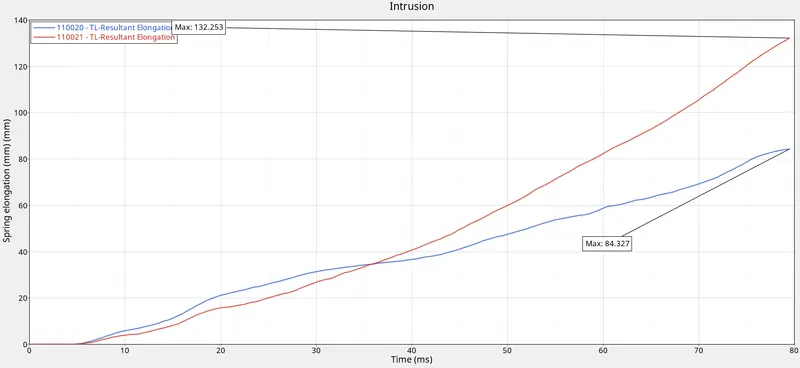 |
Inside the cabin, we can observe that the initial large deformation starts to spread from the centre of the dashboard and gradually reduces as it is distributed. The Intrusion at Node 66244 is closer to the centre so it undergoes more deformation than the Intrusion at Node 66695 which is farther from the centre. |
|
An accelerometer at the Base of B Pillar (Rocker) [mm/ms2] |
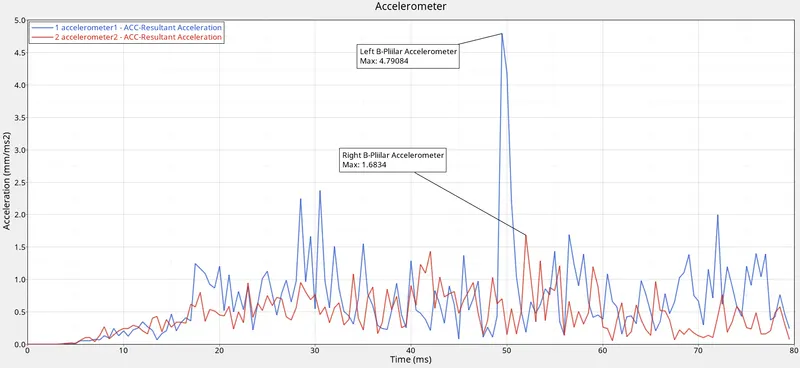 |
The vehicle comes to a stop upon impacting the rigid wall and the Kinetic energy of the components in the front (impact and self) is converted to Strain energy and thereby resulting in deformation of the components in the front. The rest of the car that is still not under contact continues with its state of motion due to the Moment of Inertia. Later at about 49ms, the floor panel begins to deform at a high rate. The deformation is caused by the Opposing forces of the Rigid wall and the Moment of Inertia. The deformation rate is so hight that we need an accelerometer at the Rocker to record it. Acceleration is the rate of change of Velolicty which is, in turn, a result of Rate of deformation. The non-symmetric distribution of forces at the Left and Right side of the car leads to different accelerations on both the Rockers. LH B Pillar undergoes more acceleration (caused by the rate of deformation) than RH B Pillar. |
|
Self Contact of the Frontal Car Model [KN/mm] |
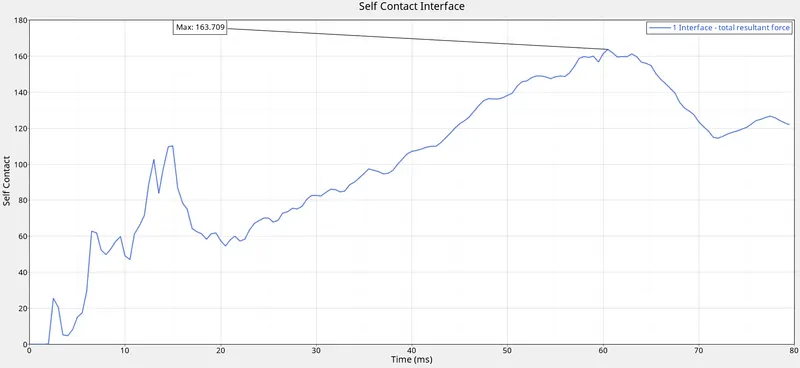 |
Initially, when the car comes to a stop, the Kinetic Energy of the elements moving with a certain velocity is being converted to Strain Energy (opposing deformation). The opposing forces of the Rigid wall and the Moment of Inertia (due to Initial Velocity) leads to an increase in Contact (Bumper, Rail and Shotgun) at 15 ms and a higher rate of deformation in those components. As time increases, the Moment of inertia gradually decreases, the sectional forces (due to Resistance from Rigid wall) also increases gradually and not abruptly. The Maximum Contact Forces of the entire Frontal crash is 163.709 KN/mm at 60.5 ms. |
Conclusion
From the Simulation Animation and the Plots, we can conclude that:
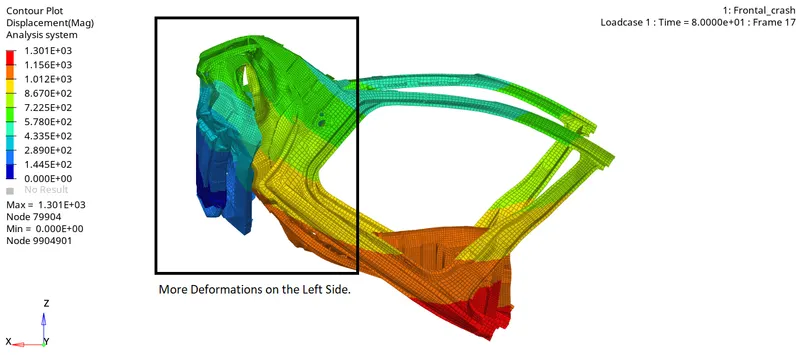
The deformations of the contacted components (Bumper, Rail, Shotgun and A-Pillar) on the Left side are comparatively higher and making sure that the impact forces don't get into the left side of the cabin and affect the driver (left seated).
 |
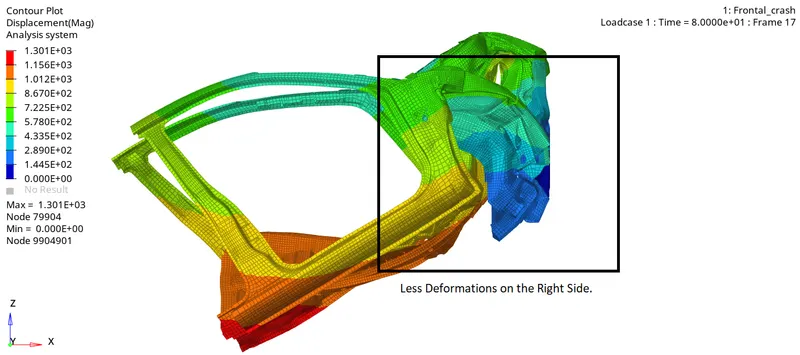 |
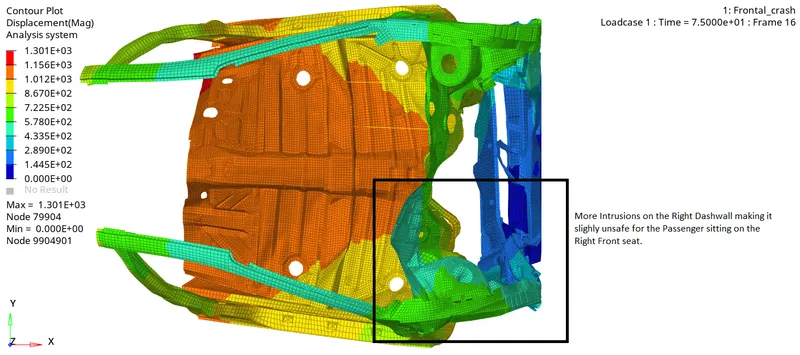
However, the deformations on the Right Side of the Contacted components (Bumper, Rail, Shotgun and A-Pillar) are lesser which lead to more forces being distributed on the Right Dashwall causing more intrusions in the Passenger seat side (right side).
Learning Outcome
i. The minimum conditions required to set up a frontal crash test.
ii. How the Rigid wall interface works and it can lead to incompatible Kinematic conditions.
iii. How Sectional forces are generated.
iv. The distribution of forces among the components during a frontal crash.
v. How some components are designed to deform in such a way to ensure the safety of the passengers inside the cabin.
vi. Check for Energy, mass and momentum balance
vii. Debugging errors in order to get the right results.