Assignment 5-RADIOSS Interfaces & Study of Effect of Notches Challenge
OBJECTIVES:
- To mesh the given Bumper Assembly by following the specified element criteria.
- To study about the commonly used Contact Interfaces of Radioss by observing and comparing the simulation results.
- To study the effect of notches on the deformation of the crush tube.
PROCEDURE:
Meshing the Bumper Assembly:
1) Import the model into Hypermesh.
The given model is imported into Hypermesh using the import option on the menu bar.
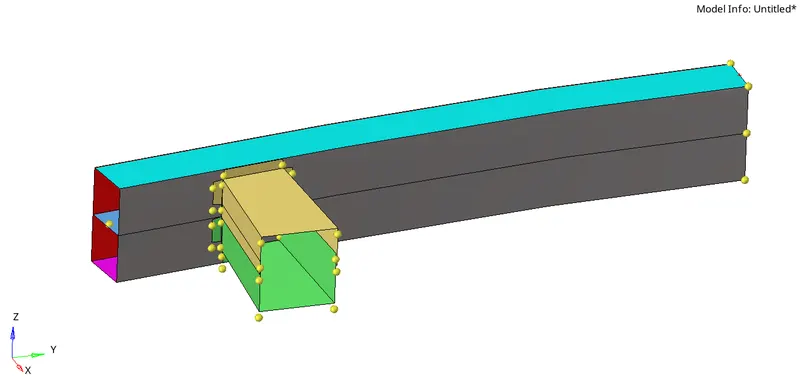
2) Geometry Cleanup
Before meshing, it is necessary to ensure that the model surface is perfect and free from any surface errors. If any defects are found then the required geometry can be done using the various cleanup tools present in Hypermesh.
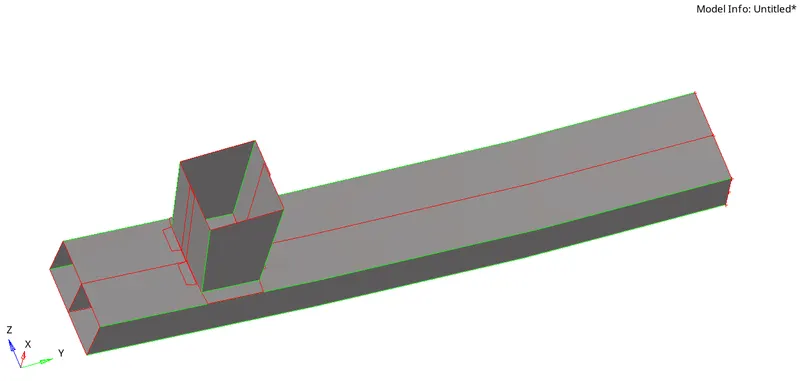
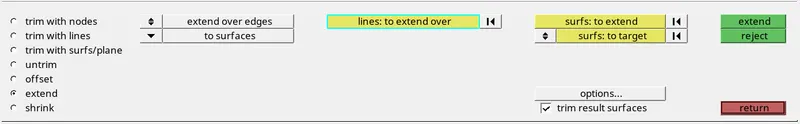
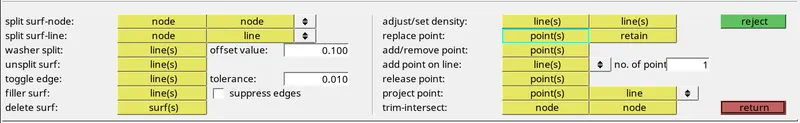
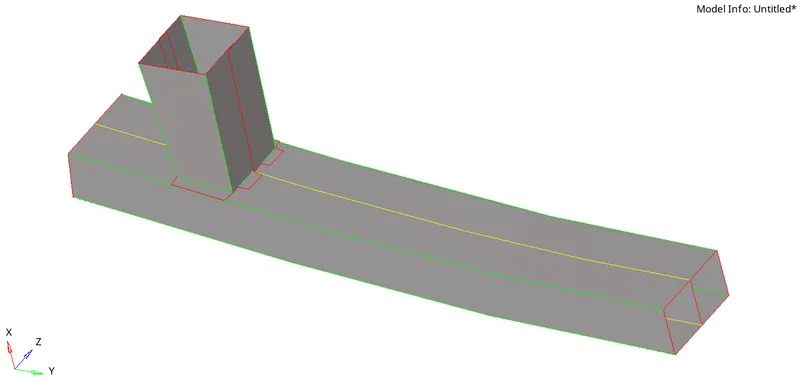
By viewing the model in ‘By Topo’ mode, free edges are found on the model surface. This can be rectified by using the ‘surface edit’ tool and the tools available under the ‘quick edit panel’.
Surface Edit Panel,
Quick Edit Panel,
Model after completion of geometry cleanup,
3) Meshing of midsurface
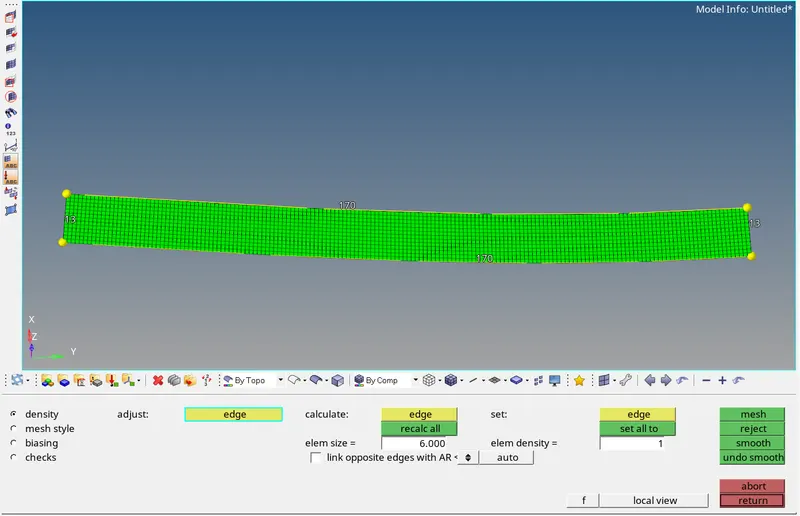
After performing geometry cleanup on the bumper assembly, automeshing is performed with a target element size of 6 mm.
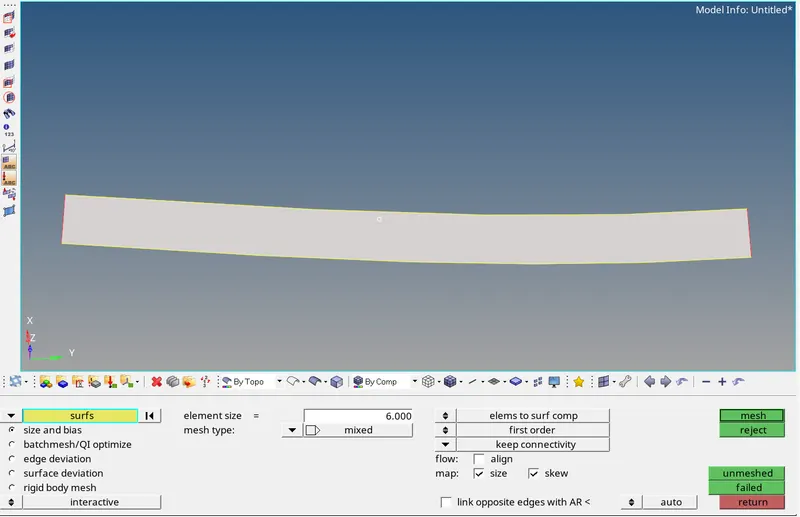
For ensuring proper mesh flow and also for ease of meshing, the meshing is carried out on each of the surfaces one by one.
4) Connecting the crash tube to the bumper
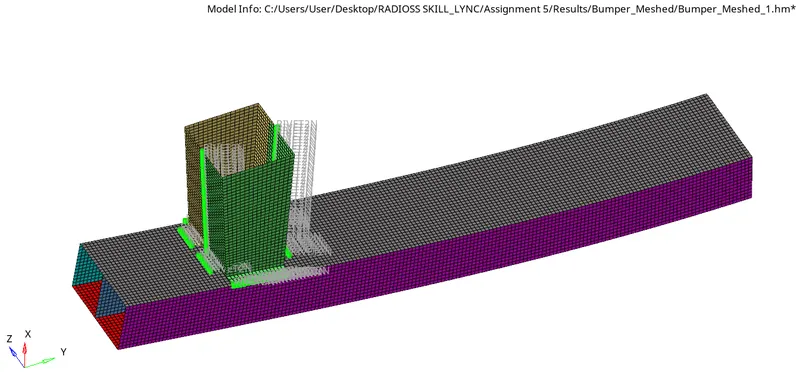
Connections are made in the appropriate places using 1-D connectors.
FINAL MODEL IMAGE:
Setting up different cases by changing the type of Contact Interface used for each case:
CASE 1:
For Case 1 the model has to be run as it is without making any changes to the default settings.
1) Open HyperWorks and select the user profile as RADIOSS.
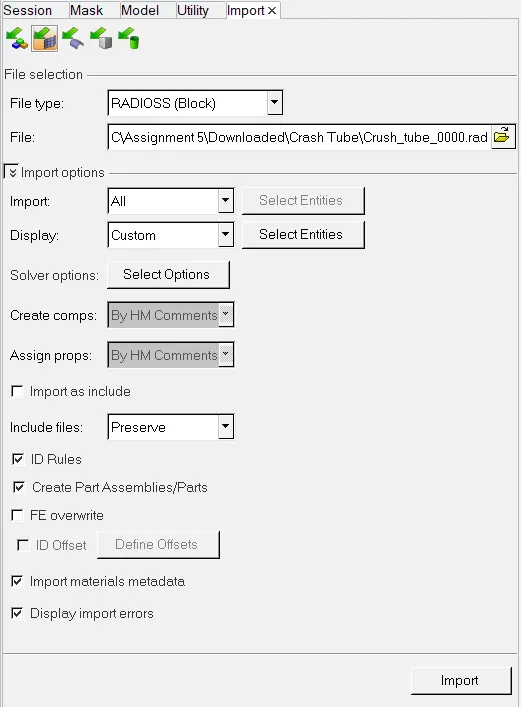
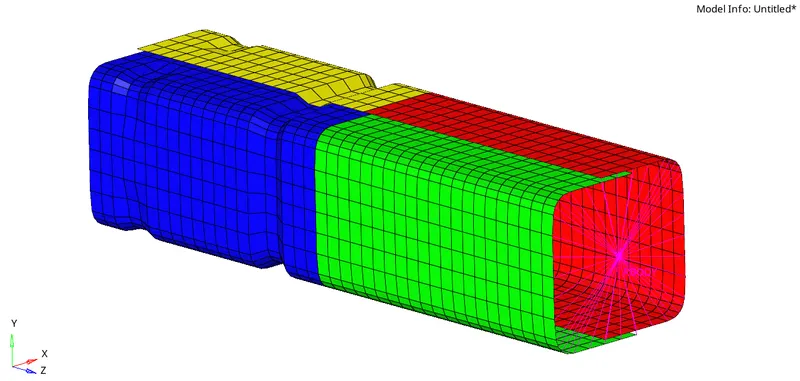
Import the given starter file(Crash_tube_0000.rad) into HyperWorks using the ‘Import Solver Deck’ Tool.
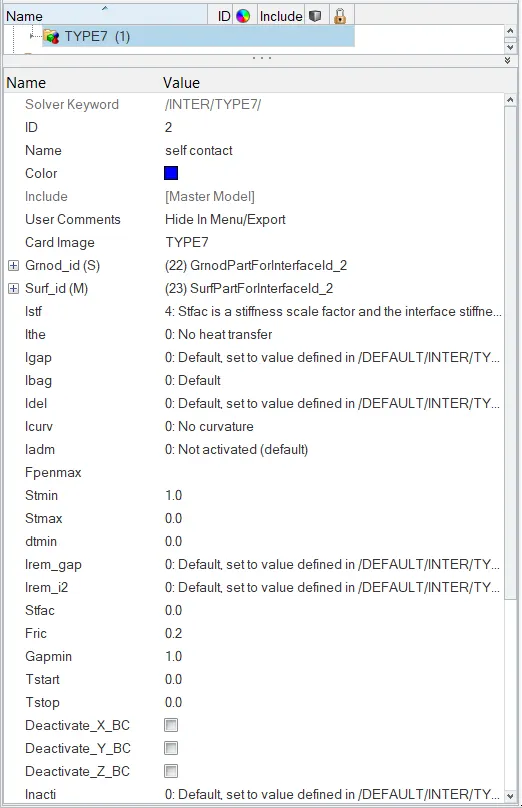
2) For this case, Type 7 interface has been used, which is a node to surface contact with non-linear stiffness.
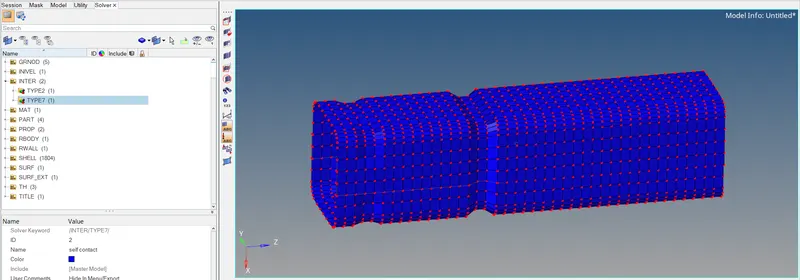
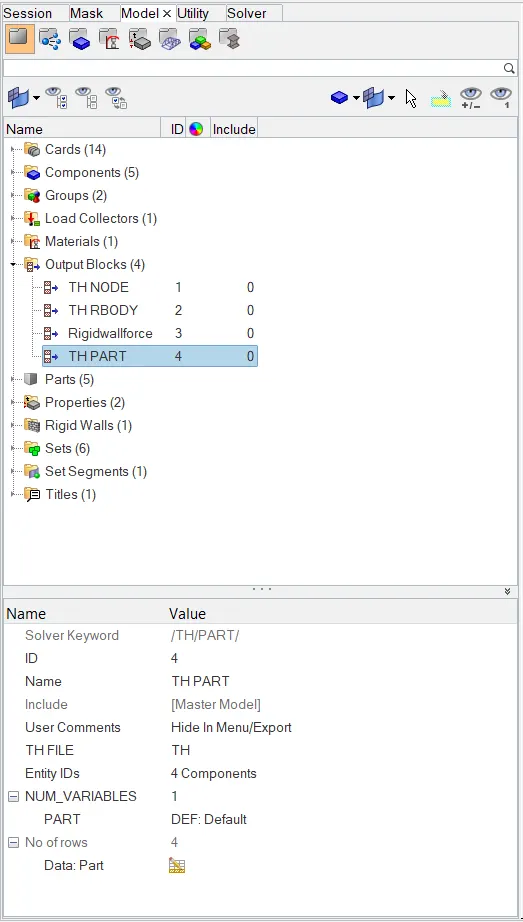
To create TH/PART for all parts,
(Model Browser>Right Click>Create>Output Block>Entity IDs: select the components)
3) Now the file is run in RADIOSS solver.
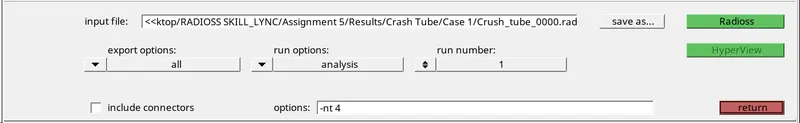
Save the file to the required file destination using the ‘save as’ option.
Analysis > Radioss > click ’save as’ to save the file to the required directory >export options: ‘all’ > run options: ‘analysis’ > run number: ‘1’ > options: ‘-nt 4’(number of threads set to 4, for faster simulation) > Radioss
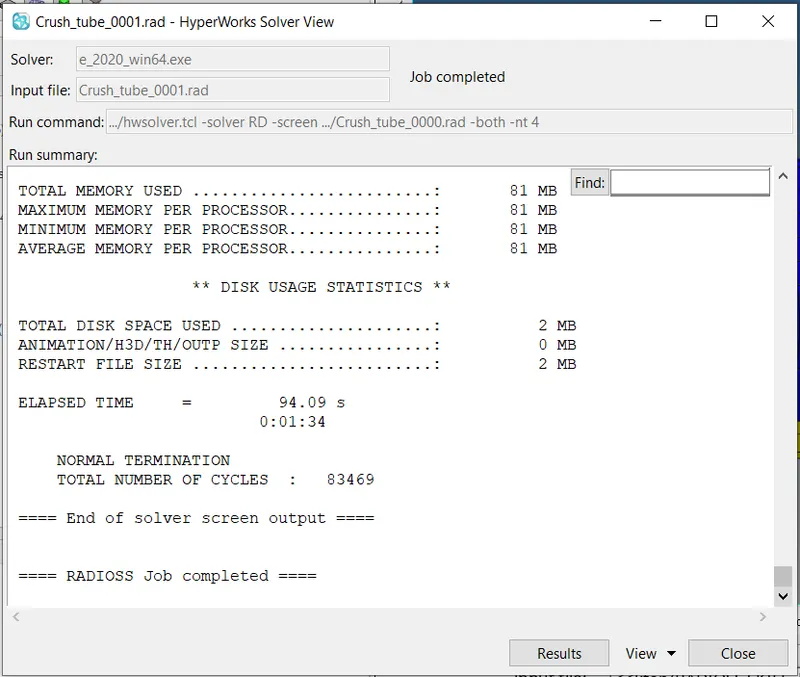
On completion of the simulation, a pop-up window opens showing the run summary.
4) After the simulation is completed, the required values such as ‘Energy error percentage’ and ‘Mass error’ can be viewed by opening the engine output file (file ending with 0001.out) using Notepad.
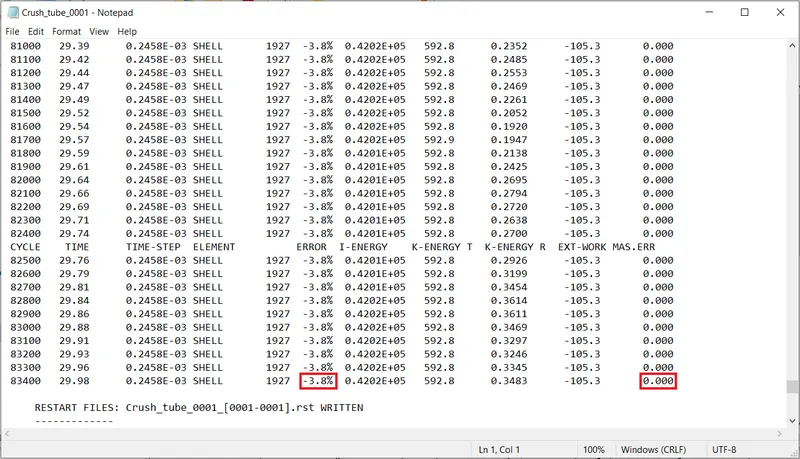
The energy error obtained is -3.8% which is within the acceptable range of -15% to 5%. Also, the mass error is 0%. Hence the result is acceptable.
5) To visualize the simulation results as an animation, HyperView is used. For this, the animation file(file ending with .h3d) is loaded in Hyperview.
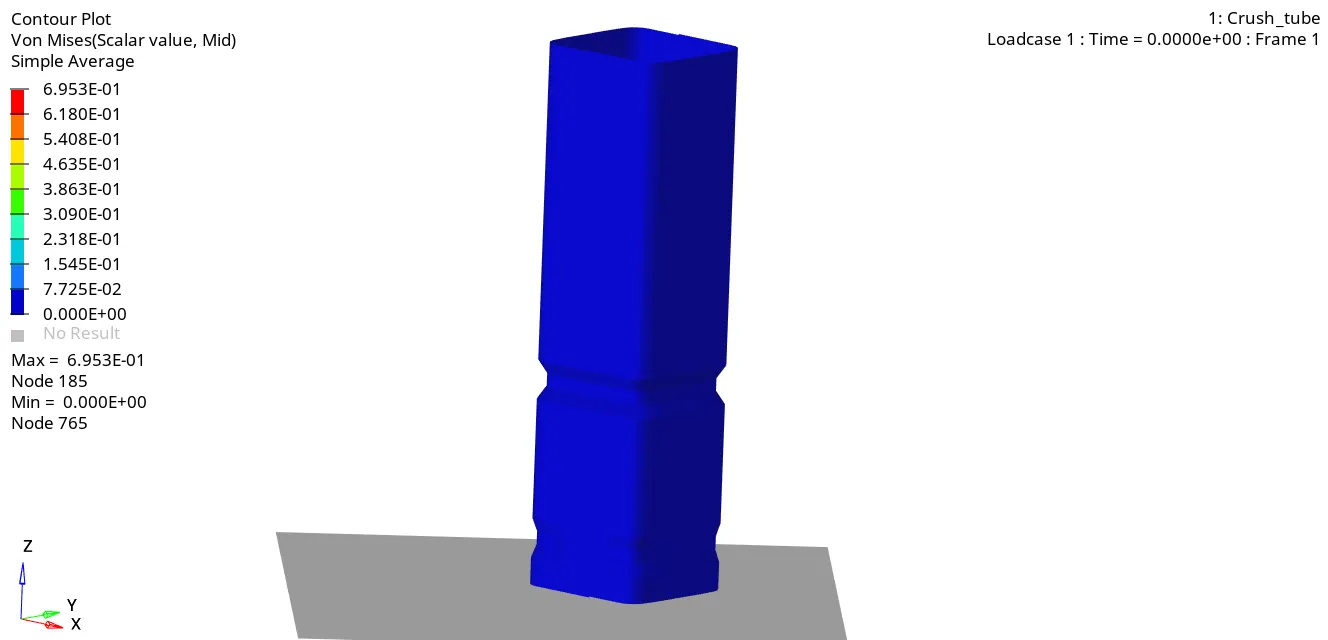
The above animation shows the von misses stress developed in the crush tube. From the animation, it can be observed that the crush tube deforms in the region of the notch first and then deforms further starting from the end in contact with the rigid wall.
6) To plot the Energy Vs Time graph, HyperGraph is opened.
Under ‘data file’, the Time History File ( file ending with T01) is loaded.
(X Type: Time > Y type: Global Variables > Y Request: Internal Energy, Kinetic Energy, Contact Energy, Hourglass Energy and Total Energy > Y Component: MAG > Apply)
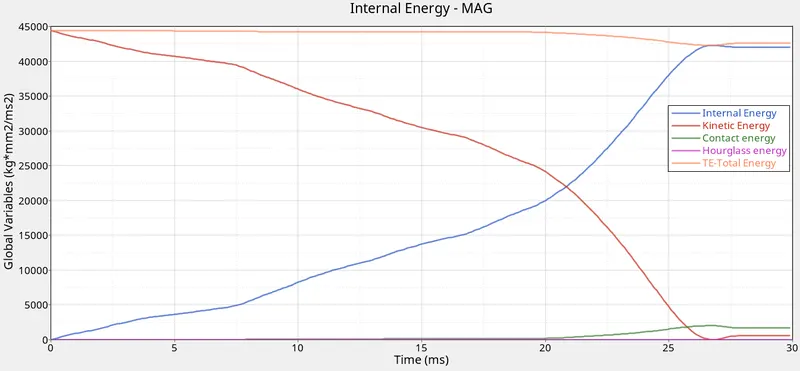
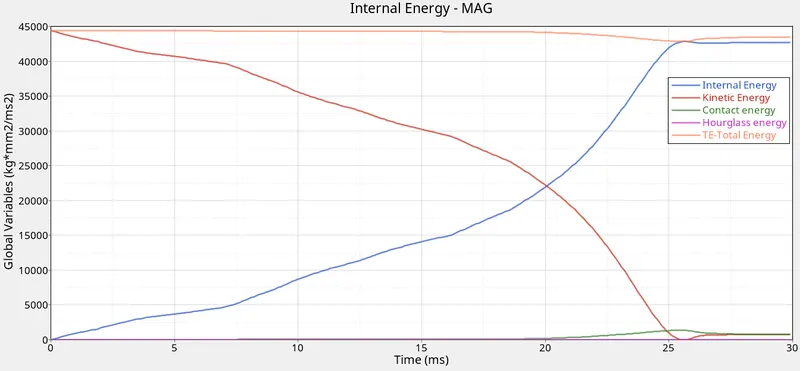
As the graph shows, the Kinetic Energy is maximum at the start and begins to decrease once the crush tube hits the rigid wall. This Kinetic Energy gets converted to Internal Energy as the crush tube deforms as can be seen in the graph by the rise of the Internal Energy Curve. As the crush tube undergoes deformation, due to self-impact, there is an interaction between the slave nodes and the master segments and as a result, resistive forces are generated to keep the slave nodes out of the contact gap. Thus the contact energy increases thereby reducing the total energy.
Similarly, the Rigid Wall Force as a function of Time is also plotted.
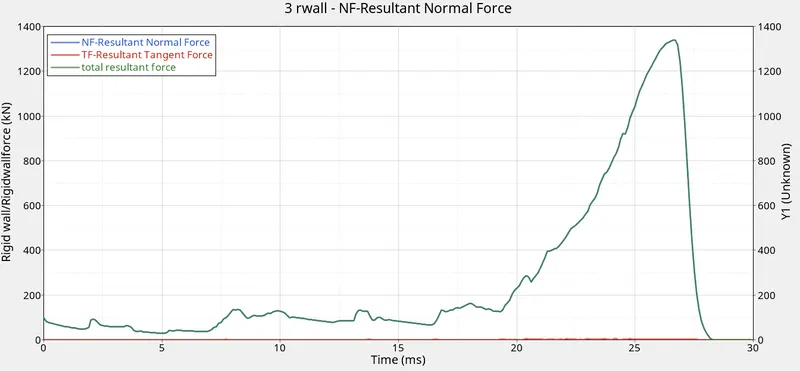
From the graph, it can be observed that at the start of the simulation, forces on the rigid wall is less, as much of the force applied is being absorbed by the materials due to which they deform. When the crush tube is completely crushed it can't deform any further and hence gets pushed against the wall thereby leading to an increase in the rigid wall forces.
CASE 2:
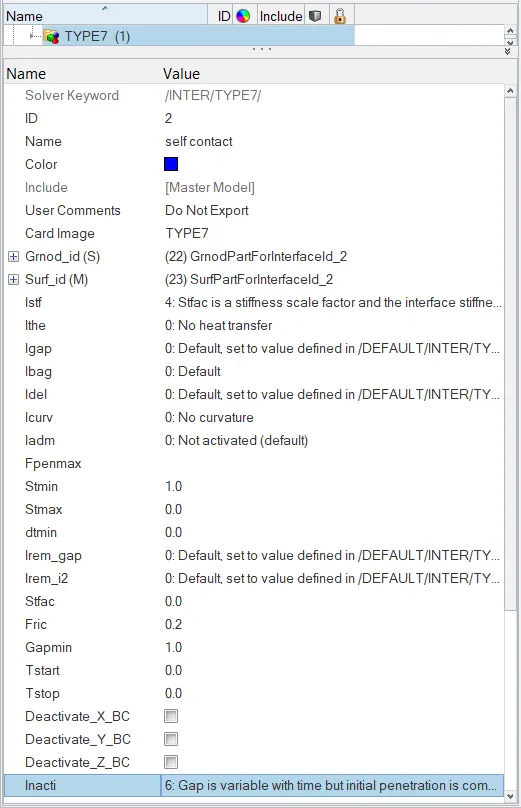
1) In Case 2, the Inacti value is changed to 6 from 0. By using Inacti=6, if there are any initial penetrations present in the model then it will be de-penetrated.
(Solver Browser>INTER>TYPE7>Inacti = 6)
2) Now the file is run in RADIOSS solver.
Save the file to the required file destination using the ‘save as’ option.
On completion of the simulation, a pop-up window opens showing the run summary.
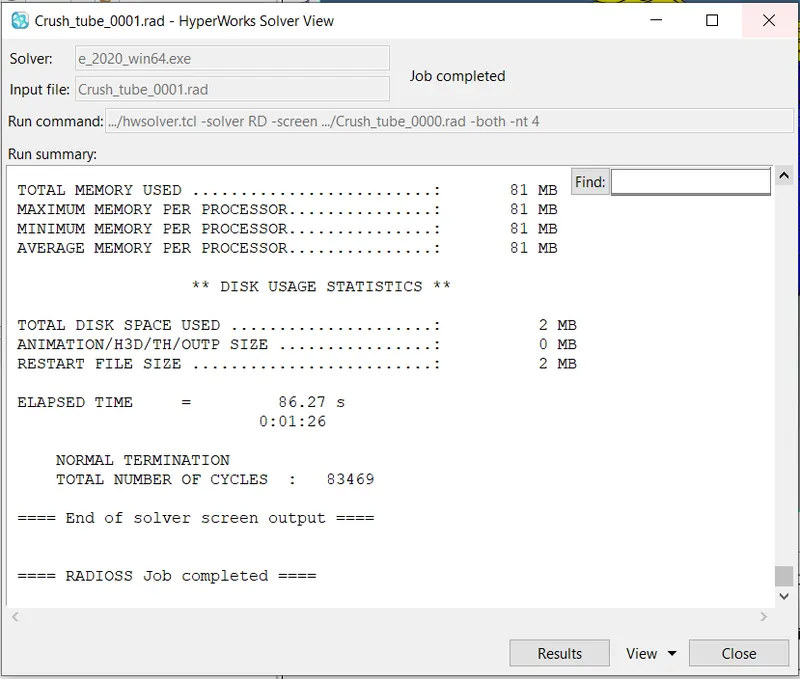
3) After the simulation is completed, the values such as ‘Energy error percentage’ and ‘Mass error’ is viewed by opening the engine output file (0001.out).
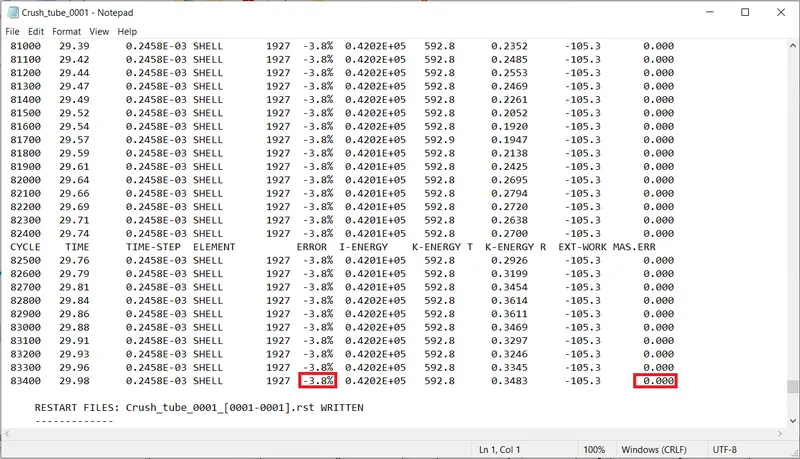
Here also the Energy error percentage is -3.8% and the mass error is 0% both of which are within the acceptable range. Hence the result is acceptable.
4) The simulation results is visualized as an animation using HyperView.
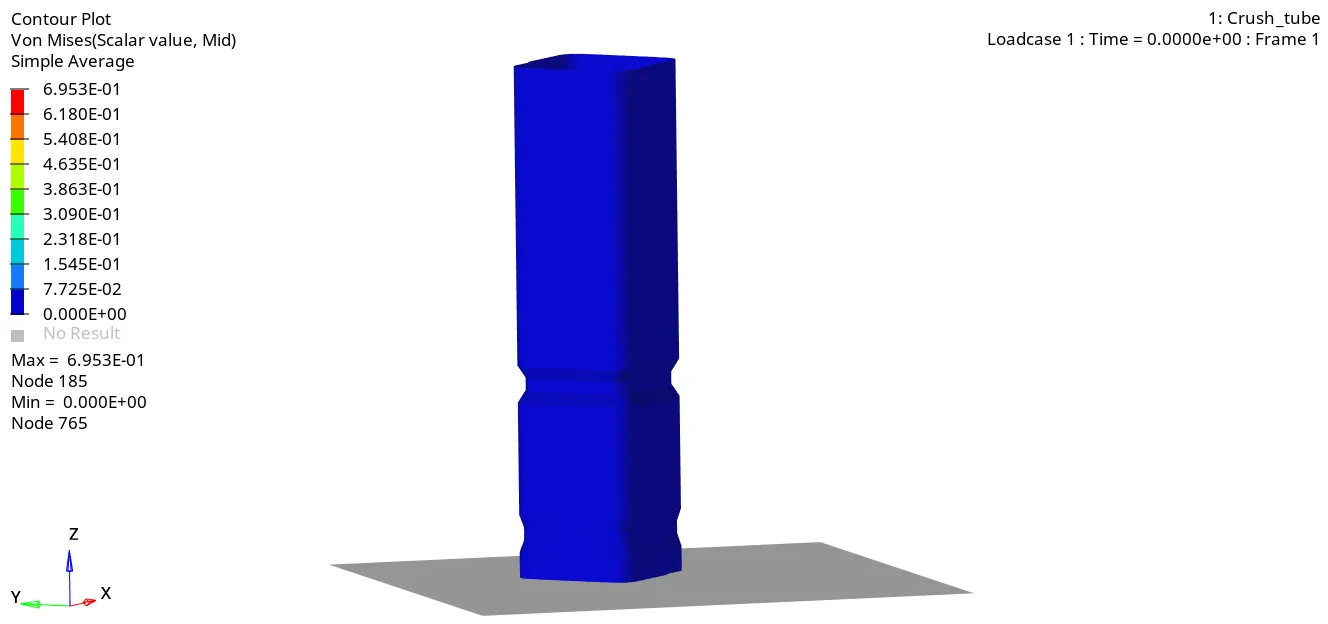
The deformation seen here is similar to what is observed in Case 1.
5) The Energy Vs Time graph is plotted.
Under ‘data file’, the Time History File ( file ending with T01) is loaded.
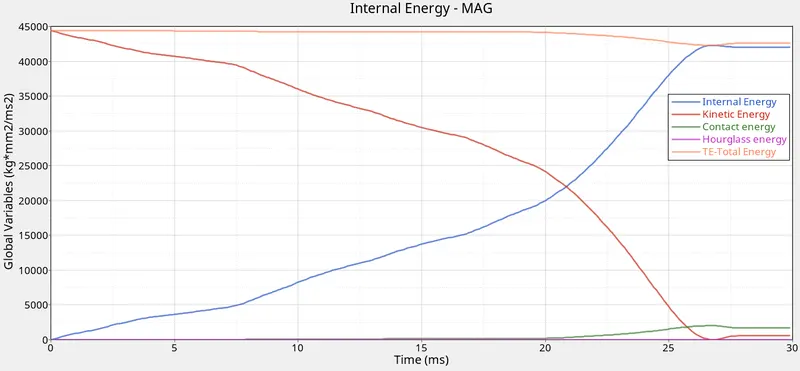
Similarly, the Rigid Wall Force as a function of Time is also plotted.
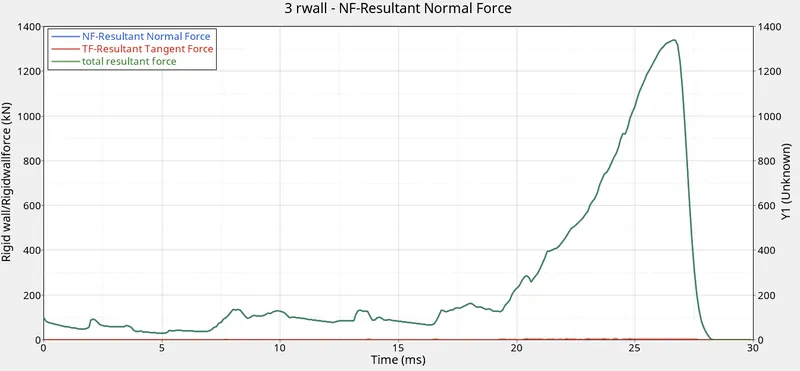
Even though Inacti=6 was activated, since there weren’t any initial penetrations present in the model, no high initial contact forces are generated and hence the graphs are similar to what is seen in Case 1.
CASE 3:
1) In Case 3, Type 11 contact is created and then the simulation is run.
Type 11 is an edge to edge contact with non-linear stiffness. Type 11 works similar to Type 7 in terms of Penalty formulation, Gap definition, and Search method.
(Solver Browser>Right Click>Create>INTER>TYPE11)
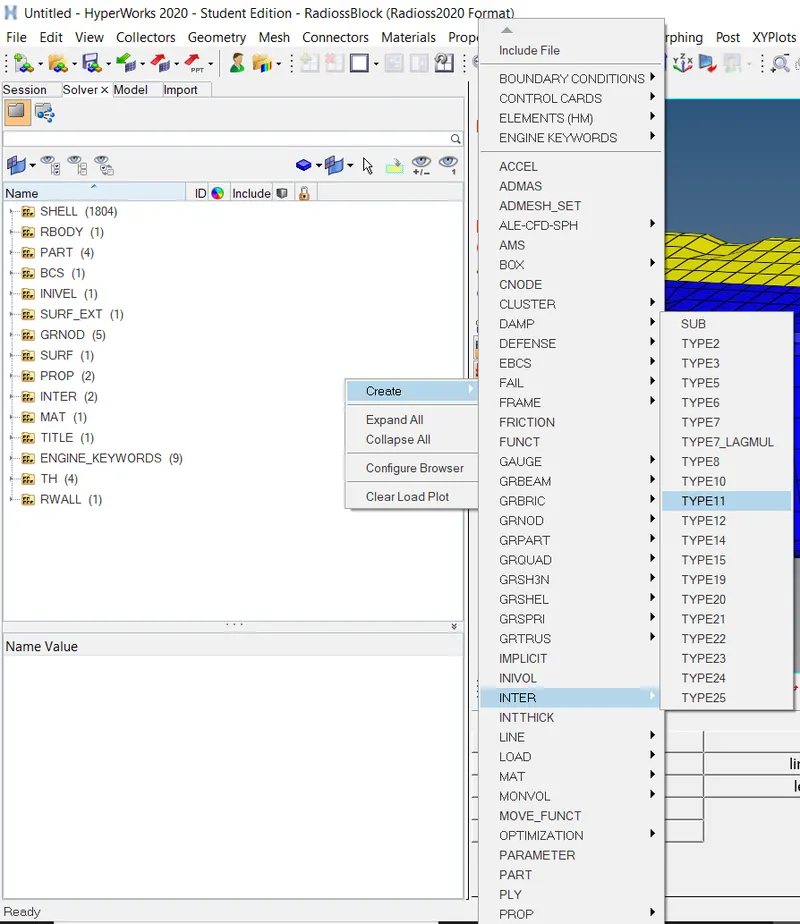
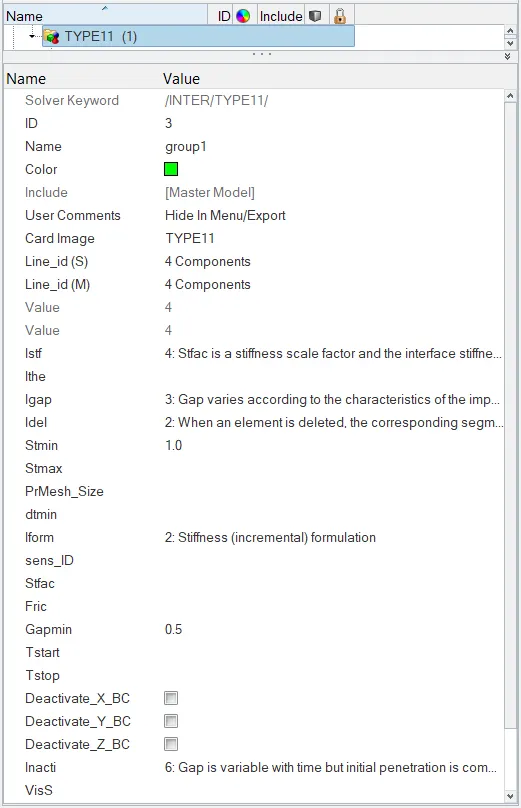
The recommended values for the Type 11 contact are set.
2) Now the file is run in RADIOSS solver.
Save the file to the required file destination using the ‘save as’ option.
On completion of the simulation, a pop-up window opens showing the run summary.
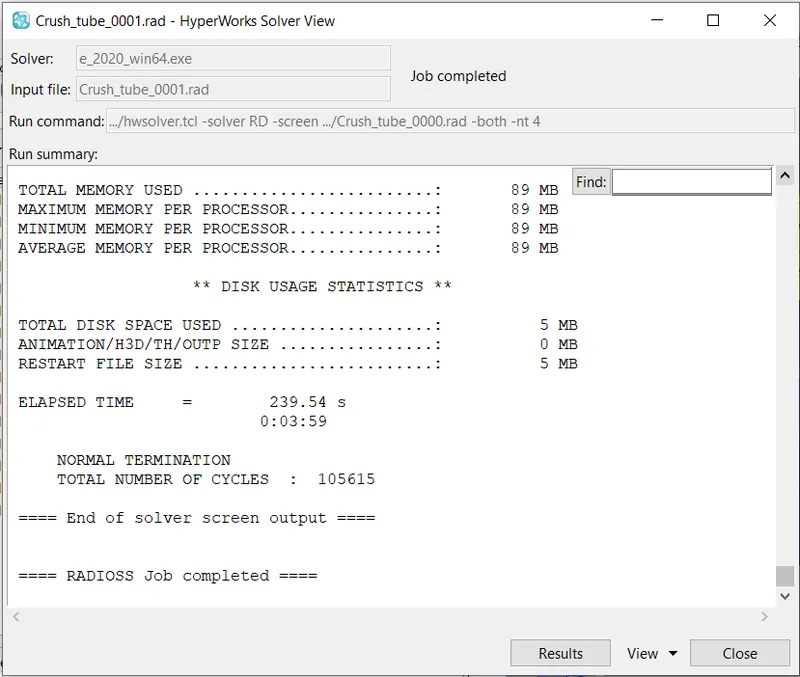
3) After the simulation is completed, the values such as ‘Energy error percentage’ and ‘Mass error’ is viewed by opening the engine output file (0001.out).
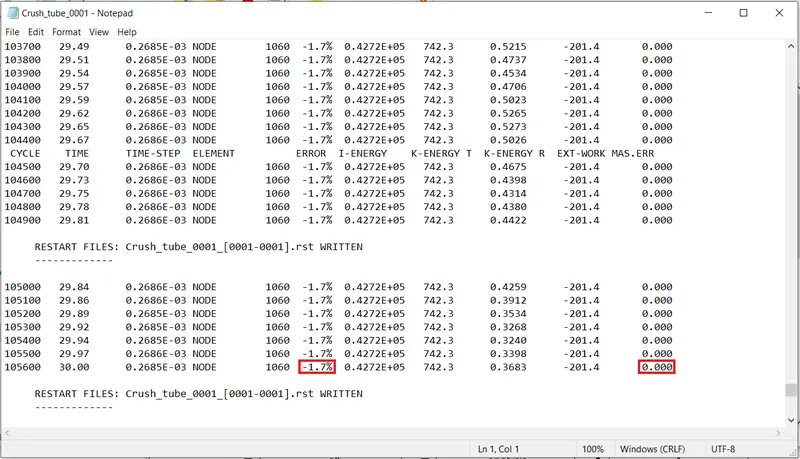
Here the Energy error percentage is -1.7% and the mass error is 0% both of which are within the acceptable range. Hence the result is acceptable.
4) The simulation results is visualized as an animation using HyperView.
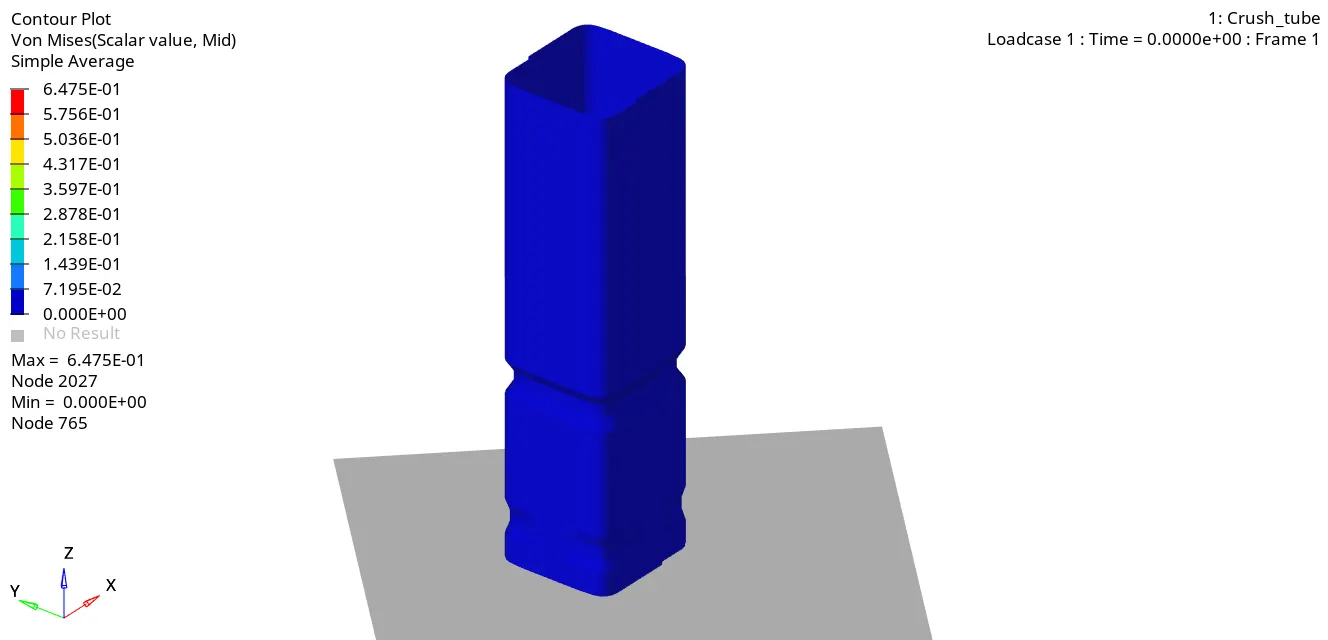
The deformation seen here is similar to what is observed in previous cases and shows that the crush tube deforms in the region of the notch first.
5) The Energy Vs Time graph is plotted.
Under ‘data file’, the Time History File ( file ending with T01) is loaded.
Similarly, the Rigid Wall Force as a function of Time is also plotted.
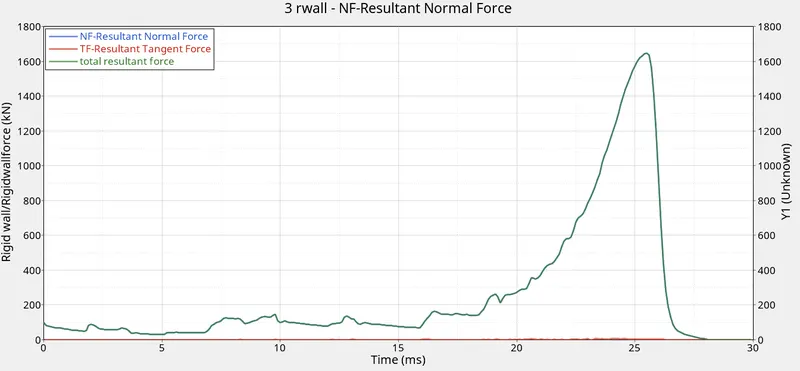
Both the graphs are observed to be similar in nature to what has been observed in the previous cases. However, due to the use of Type 11 contact along with the Type 7 contact, the contact force is found to be slightly lower as compared to the previous 2 cases. Also, the resultant normal force is found to be slightly higher as compared to the previous cases.
Setting up different cases to study the effect of notches on the crash tube:
CASE 4:
1) Import the model into Hypermesh.
The given model is imported into Hypermesh using the import option on the menu bar.
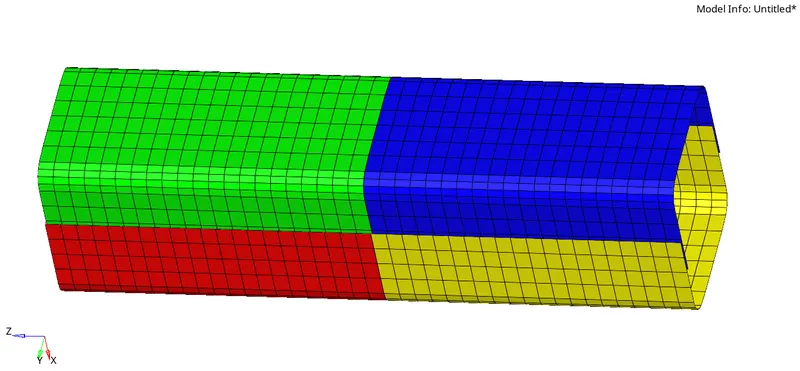
2) In Case 4, both notches on the crash tube and also the boundary condition on the rigid body are removed before running the simulation.
To remove the notches on the crash tube, the ‘align node’ tool available in Hypermesh can be used.
(Geom>node edit>align node (or) use F7)
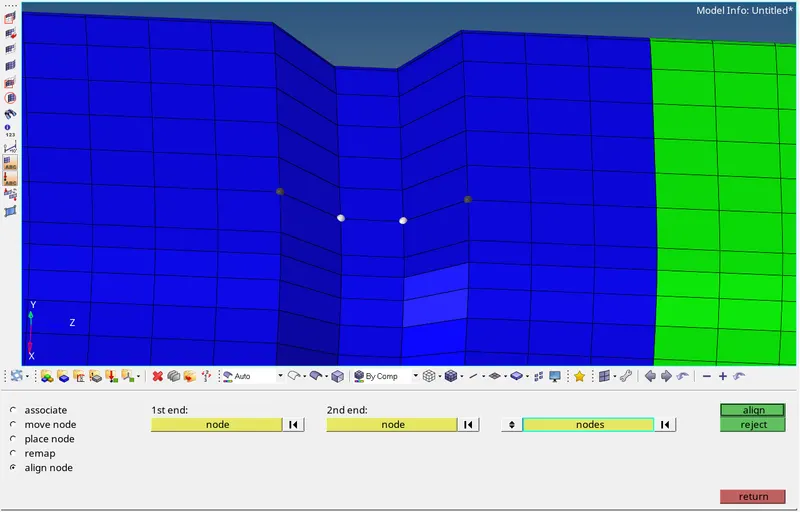
After removing the notches,
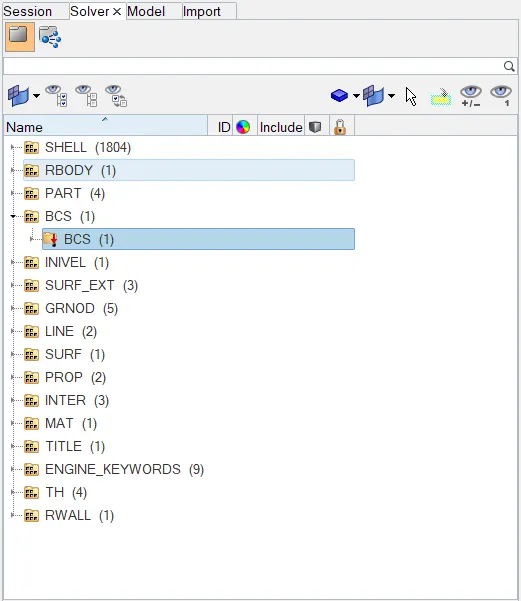
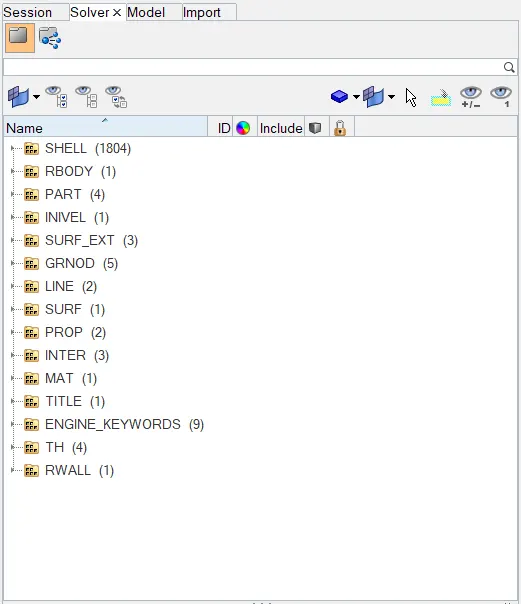
The boundary condition on the rigid body can be deleted from the solver browser. (Referred to as BCS under the Solver browser)
3) Now the file is run in RADIOSS solver.
Save the file to the required file destination using the ‘save as’ option.
On completion of the simulation, a pop-up window opens showing the run summary.
4) After the simulation is completed, the values such as ‘Energy error percentage’ and ‘Mass error’ is viewed by opening the engine output file (0001.out).
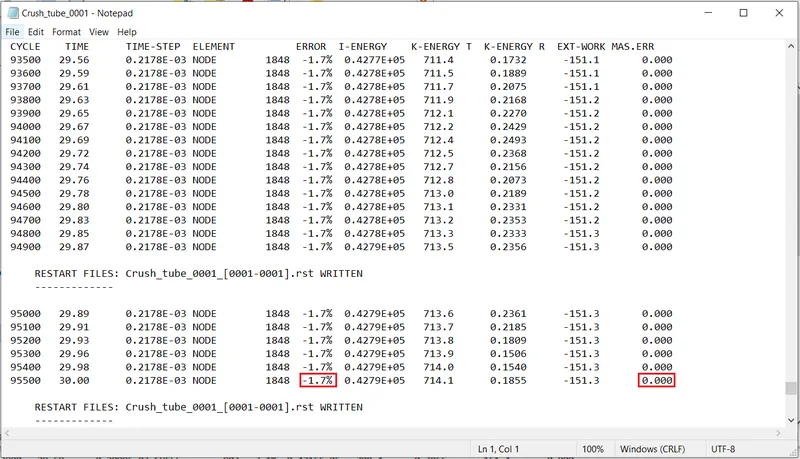
Here the Energy error percentage is -1.7% and the mass error is 0% both of which are within the acceptable range. Hence the result is acceptable.
5) The simulation results is visualized as an animation using HyperView.
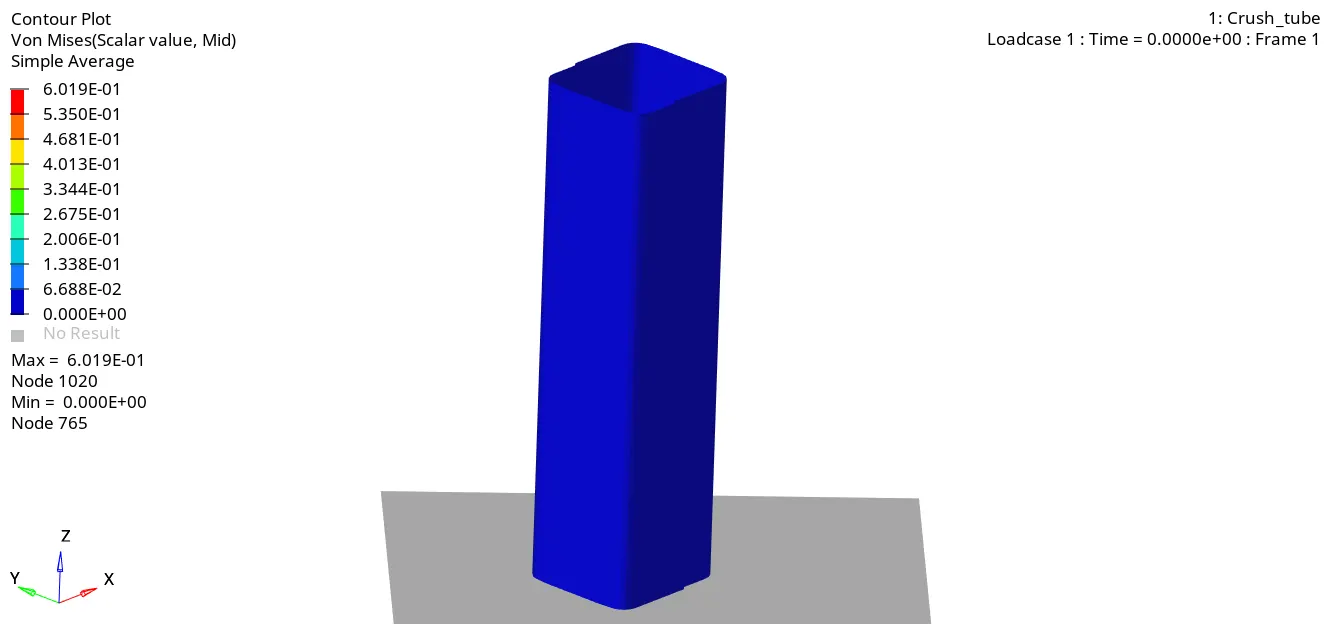
From the animation, it can be observed that since there are no notches present on the model, the deformation of the crush tube starts from the tube end that gets in contact with the rigid wall and then progresses.
6) The Energy Vs Time graph is plotted.
Under ‘data file’, the Time History File ( file ending with T01) is loaded.
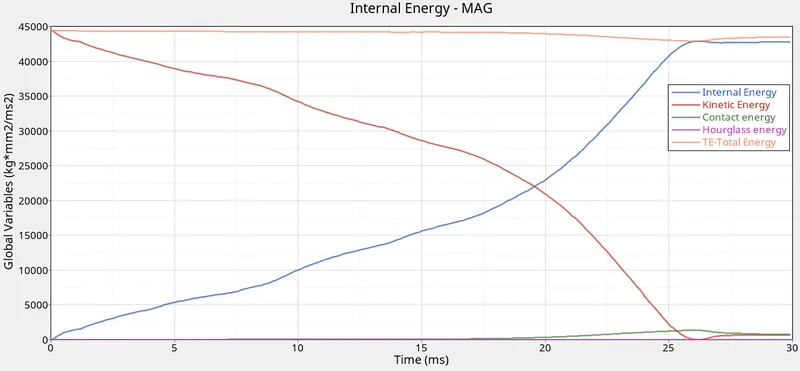
Similarly, the Rigid Wall Force as a function of Time is also plotted.
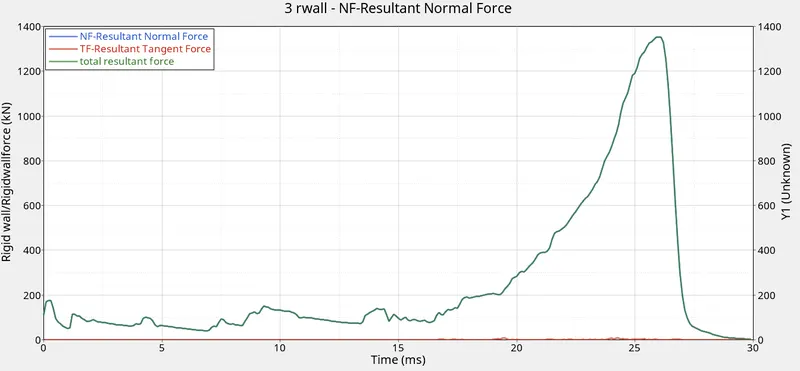
Here also the graphs are observed to be similar in nature to what has been observed in the previous cases.
CASE 5:
1) Import the model into Hypermesh.
The given model is imported into Hypermesh using the import option on the menu bar.
2) In Case 5, a new notch has to be created in the middle of the model after removing all the other notches present on the model.
The Case 4 model which has all the notches removed is used in this case. The new notch in the middle can be created by translating the nodes inwards by the required distance.
(Tool>translate)
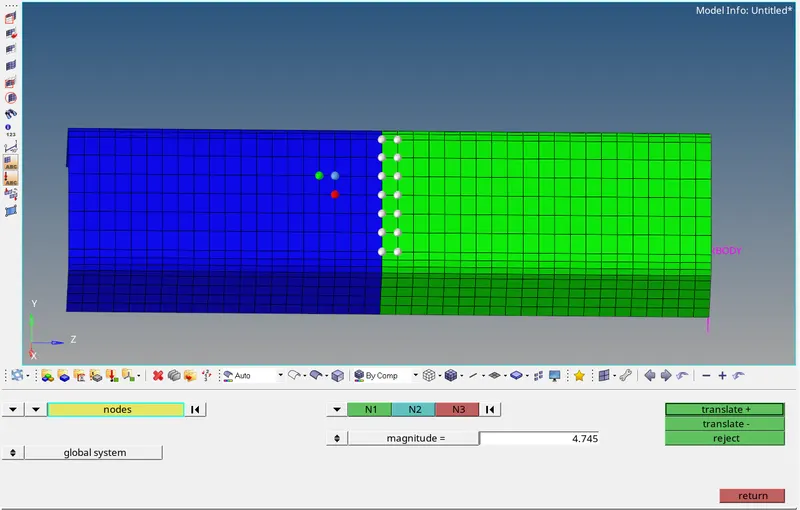
After creating a notch in the middle of the model,
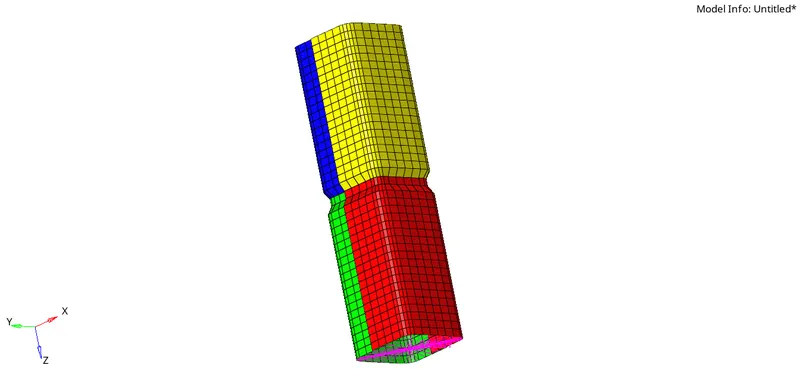
3) Now the file is run in RADIOSS solver.
Save the file to the required file destination using the ‘save as’ option.
On completion of the simulation, a pop-up window opens showing the run summary.
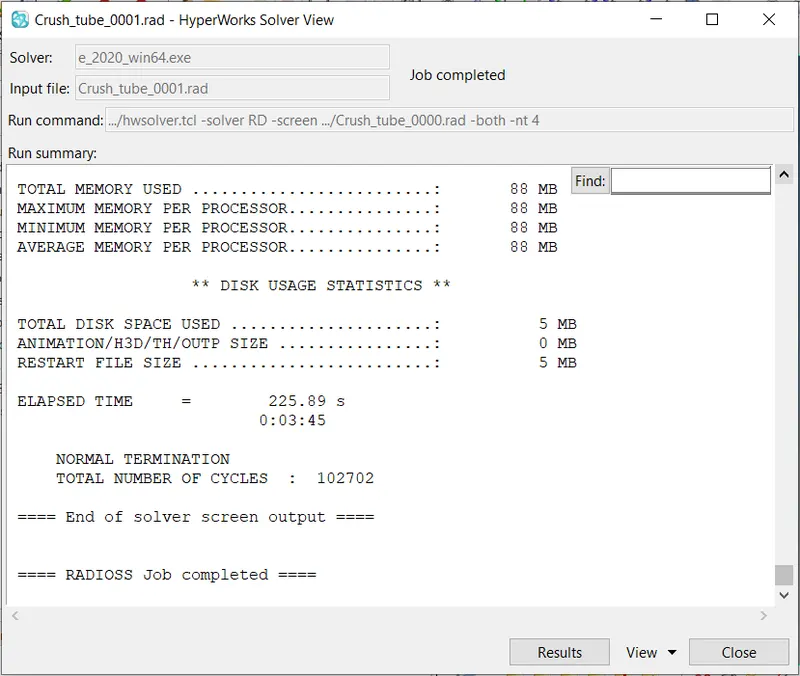
4) After the simulation is completed, the values such as ‘Energy error percentage’ and ‘Mass error’ is viewed by opening the engine output file (0001.out).
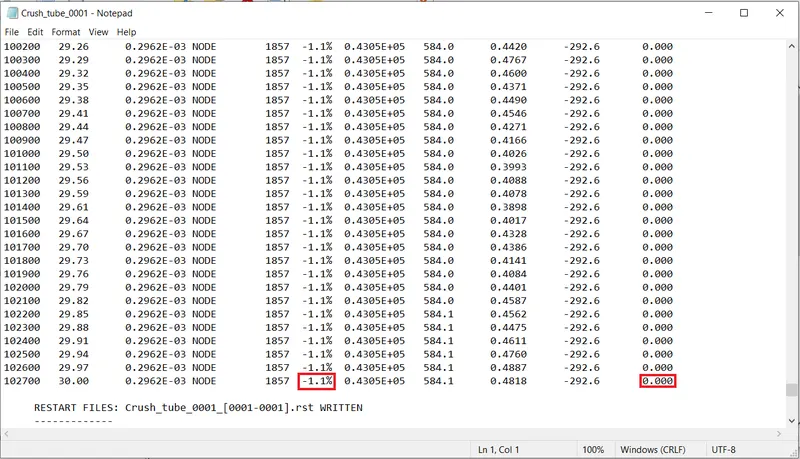
Here the Energy error percentage is -1.1% and the mass error is 0% both of which are within the acceptable range. Hence the result is acceptable.
5) The simulation results is visualized as an animation using HyperView.
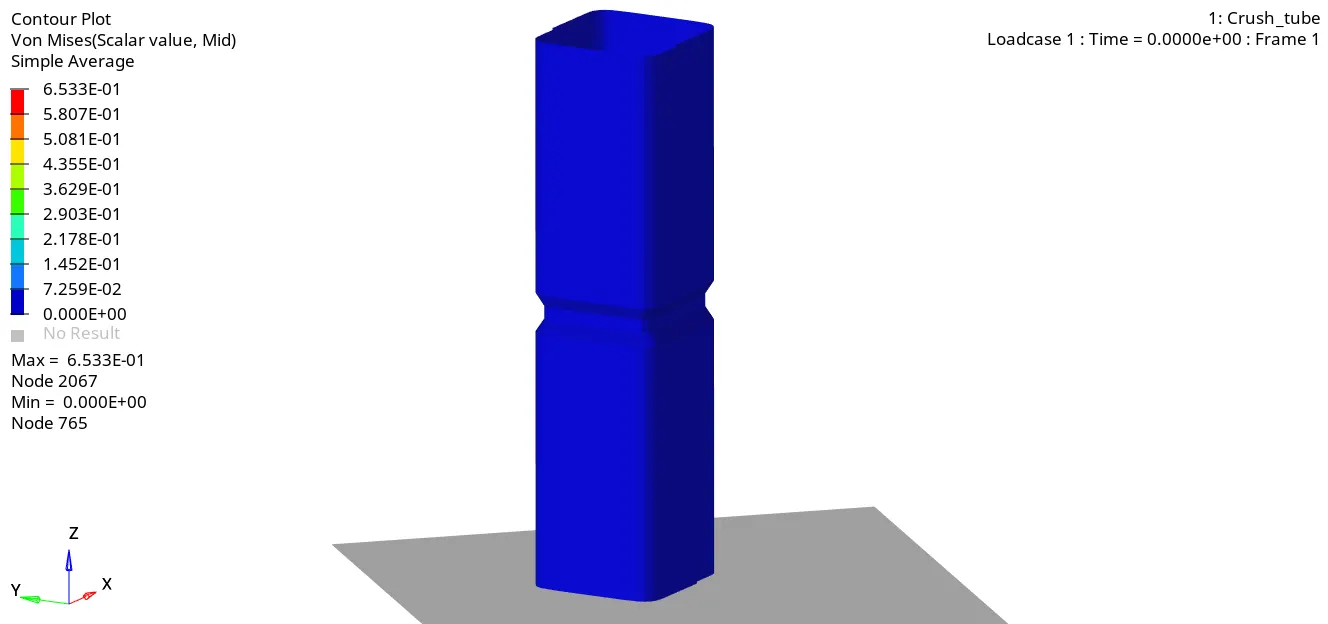
From the animation, it can be observed how the notch impacts the deformation, as the crush tube deforms in the region of the notch first and then further deformation happens starting from the tube end that gets in contact with the rigid wall.
6) The Energy Vs Time graph is plotted.
Under ‘data file’, the Time History File ( file ending with T01) is loaded.
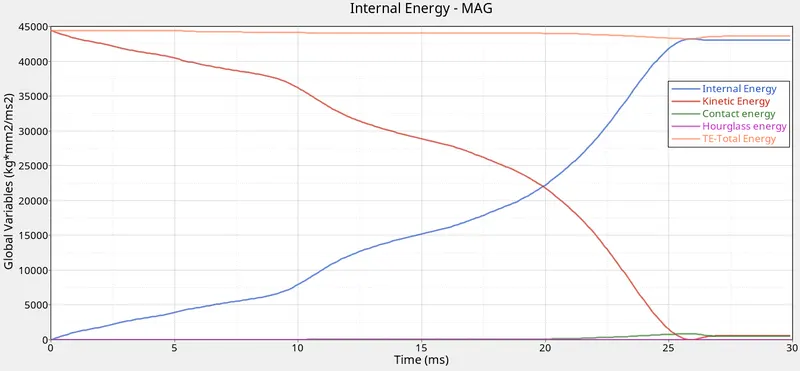
Similarly, the Rigid Wall Force as a function of Time is also plotted.
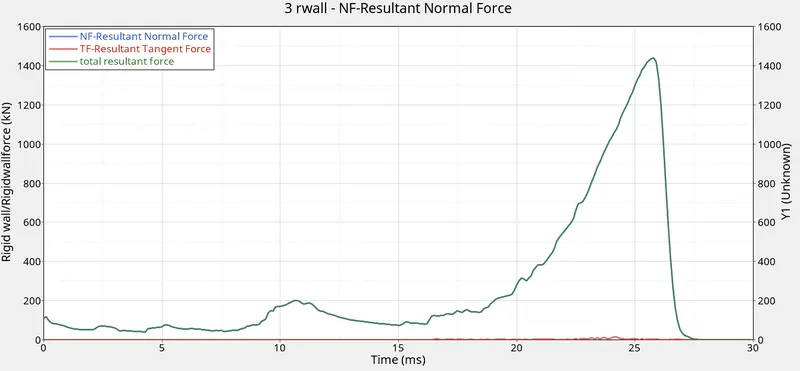
Here again the graphs are observed to be similar in nature to what has been observed in the previous cases.
CASE 6:
1) Import the model into Hypermesh.
The given model is imported into Hypermesh using the import option on the menu bar.
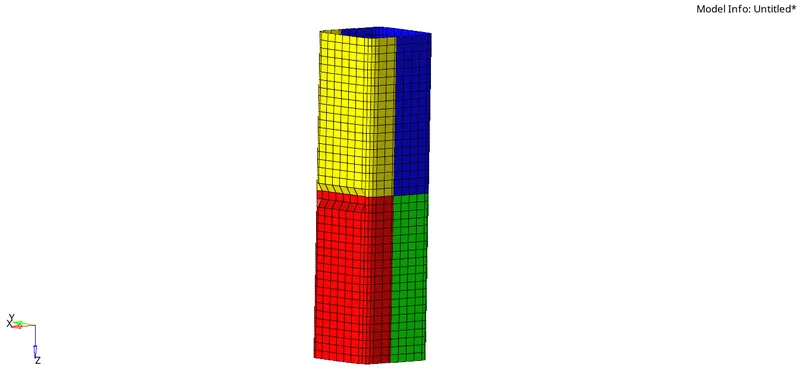
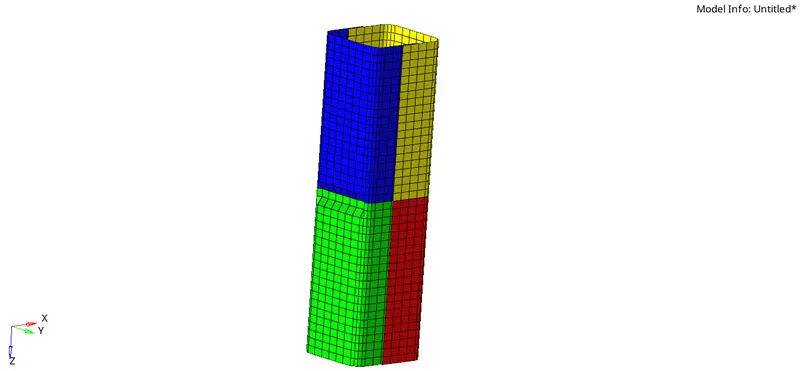
2) In Case 6, create the notch only on the opposing two faces of the model and run the simulation.
As done in Case 5 the notches can be created by translating the nodes inwards by the required distance.
3) Now the file is run in RADIOSS solver.
Save the file to the required file destination using the ‘save as’ option.
On completion of the simulation, a pop-up window opens showing the run summary.
4) After the simulation is completed, the values such as ‘Energy error percentage’ and ‘Mass error’ is viewed by opening the engine output file (0001.out).
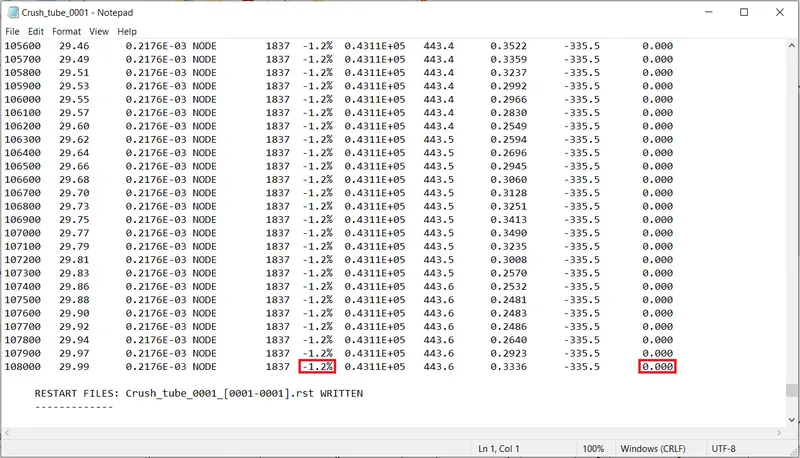
Here the Energy error percentage is -1.2% and the mass error is 0% both of which are within the acceptable range. Hence the result is acceptable.
5) The simulation results is visualized as an animation using HyperView.
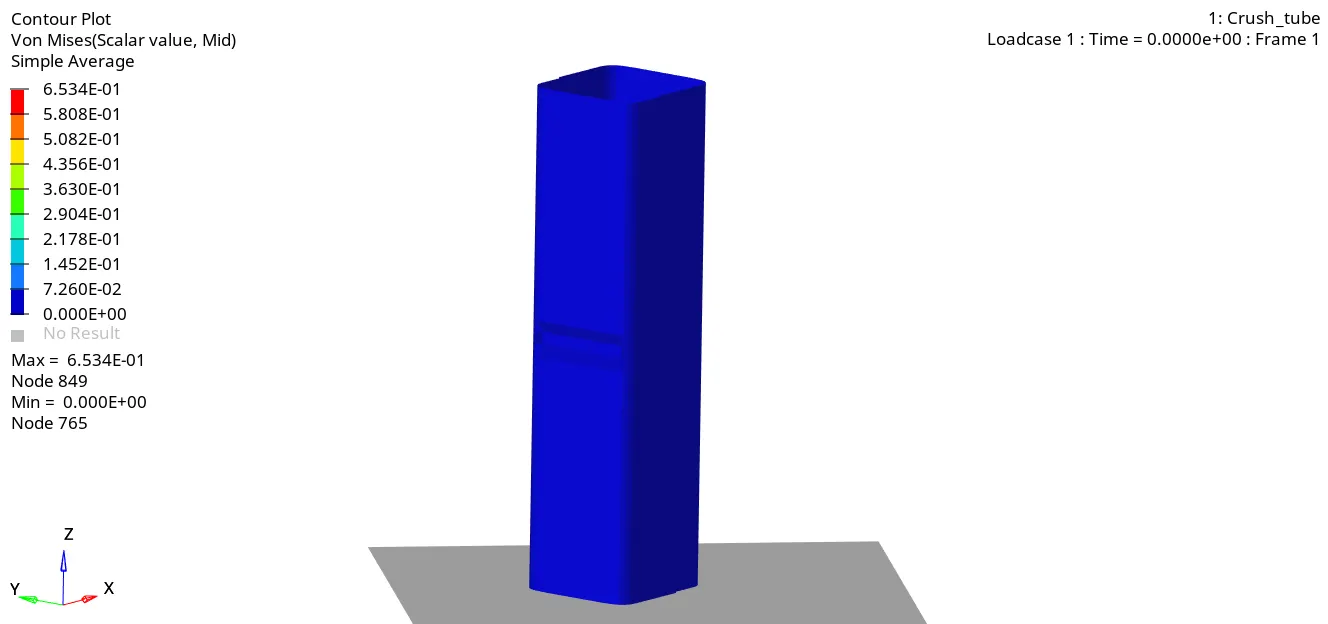
The crush tube deforms in the region of the notch first and then further deformation happens starting from the tube end that gets in contact with the rigid wall and progresses.
6) The Energy Vs Time graph is plotted.
Under ‘data file’, the Time History File ( file ending with T01) is loaded.
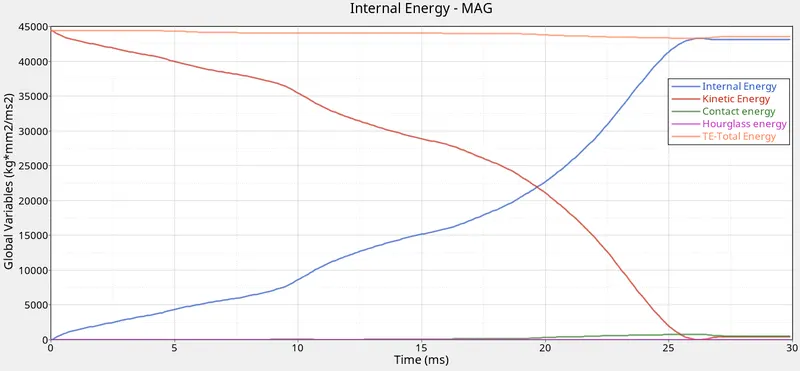
As seen in previous cases, the Kinetic Energy is maximum at the start and begins to decrease once the crush tube hits the rigid wall. This Kinetic Energy gets converted to Internal Energy as the crush tube deforms as can be seen in the graph by the rise of the Internal Energy Curve. As the crush tube undergoes deformation, resistive forces are generated to keep the slave nodes out of the contact gap. Thus the contact energy increases thereby reducing the total energy.
Similarly, the Rigid Wall Force as a function of Time is also plotted.
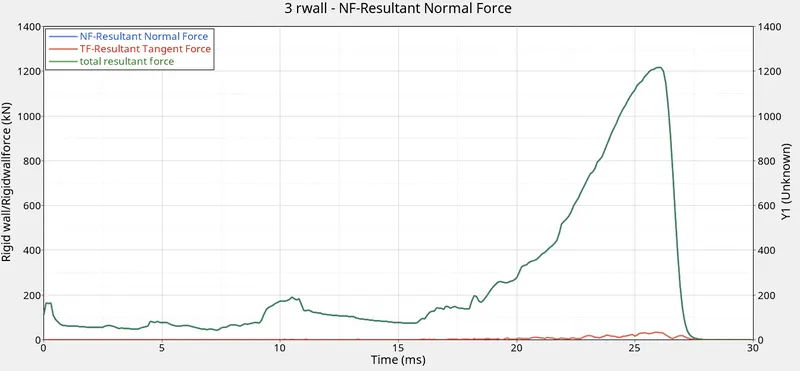
For the resultant force also, the graph is similar to what is observed in the previous cases, at the start of the simulation, forces on the rigid wall is less, as much of the force applied is being absorbed by the materials due to which they deform. When the crush tube is completely crushed it can't deform any further and hence gets pushed against the wall thereby leading to an increase in the rigid wall forces.
CONCLUSION:
Initially, meshing of the Bumper Assembly was carried out by following the specified element criteria. Then, studied the commonly used contact interfaces available in Radioss by implementing them on a crush tube and observing the results obtained on running the simulation. Also studied the effect of notches on the deformation of the crush tube and found that the notch region was the first to undergo deformation in all the cases and hence concluded that the presence of a notch made the nature of deformation more predictable.