Mechanical Mates in Solidworks
Mates are the option available in assembly which is used to create the Geometrical relation between the components and also, to arrest the degrees of the freedom of the component. By applying the mates to components we are able to control the movement of the components as per our requirements.
 Anup KumarH S·8 Sept 2022·7 min read
What is meant by mates in assembly?
Mates are the option available in assembly which is used to create the Geometrical relation between the components and also, to arrest the degrees of the freedom of the component.
By applying the mates to components we are able to control the movement of the components as per our requirements.
Classifications of Mates in Solidworks Assembly:
In the Solidworks Assembly, mates are majorly classified into three categories. Under each category, we have different types of mates. The below image shows the classification of mates.
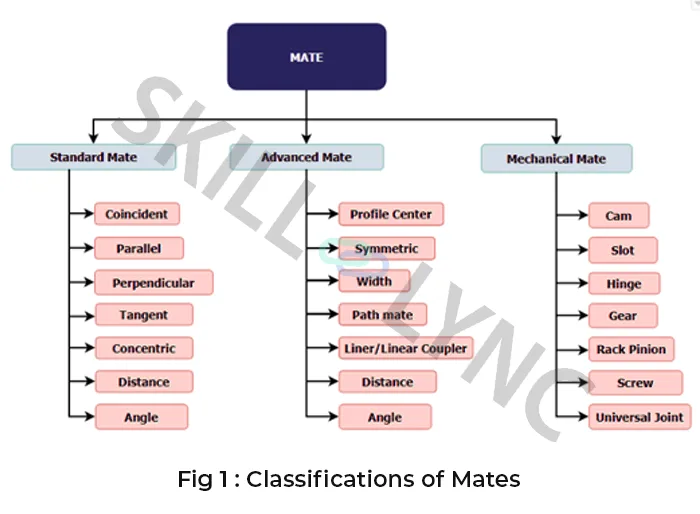
Fig 1 : Classifications of Mates
In this article, we are going to learn about the Mechanical Mates in Solidworks Assembly.
What is meant by Mechanical Mates in Solidworks?
Mechanical Mates are types of mates which mimic real-life motion. For example rotation of two gears, Motion between the cam and follower, etc,
By using the standard mates it is very hard to provide the motion to the components and also while performing simulation it becomes hard to simulate it. To make the things simpler mechanical mates come to the picture. By using mechanical mates we are able to mimic the real -life motions.
You are able to use the mechanical components such as Gears, cam and follower, Screws and Universal Joints, etc,.
There are seven types of mechanical mates available in the Solidworks assembly. We can discuss the different types of mechanical mates and how you can use it in your assembly.
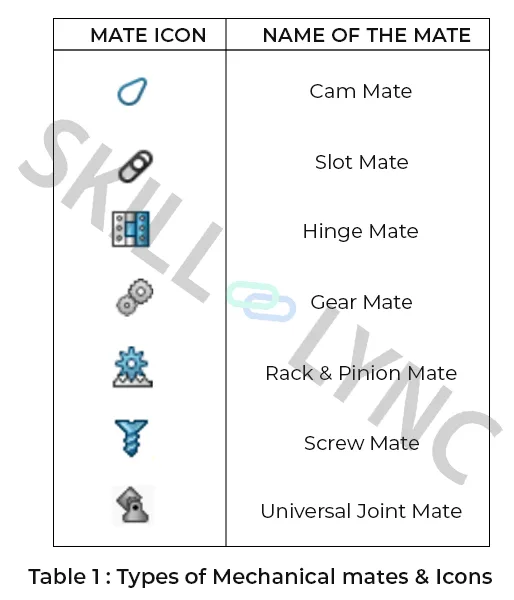
Table 1 : Types of Mechanical mates and Icons
Cam Mate :
Cam mate is the first type of mate available in mechanical mates. As the name indicates that Cam mates is basically to mimic the real motion between the cam and follower.
Rotational motion of the camshaft is converted into the linear motion of the follower by using the Cam mate.
To apply the cam and follower mate the cam has to be made as a closed loop with the tangent faces. The follower has to be made with the vertex point.
While applying the Cam mate basically you need to do two selections in the Cam path you need to select the any one outer face of the cam and in the Cam follower you need to select the vertex point or face which is in contact with the cam.
In the below diagram shows the example of Cam & Mushroom follower with the selections for the cam mate.
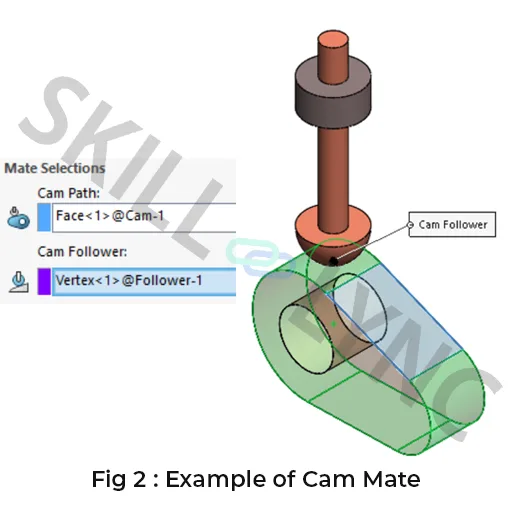
Fig 1 : Example of Cam Mate
Slot Mate :
The second type of mate in solidworks is Slot mate. As the name implies slot mate is basically used to mate a cylindrical component with the slot. By applying this mate component will always be inside and tangent to the slot.
Slot Mates are basically used to apply the mate between slot and slot, Slot & cylindrical part and Slot and axis.
To apply the slot mate in the mate selection box you need to select any one of the faces in the slot and the tangent face of the component which will contact with the slot.
The below example shows the slot mate and selection for the slot mate. There are four types of options available in the slot mate. Different options and uses are given below.
- Free - The component will move freely inside the slot
- Center in slot - Component centers inside the slot
- Distance along slot - We can specify the movement of components inside the slot by specifying the distance
- Percentage along slot - We can specify the movement of components inside the slot by specifying the percentage of slot. The distance will be calculated automatically by specifying the percentage.
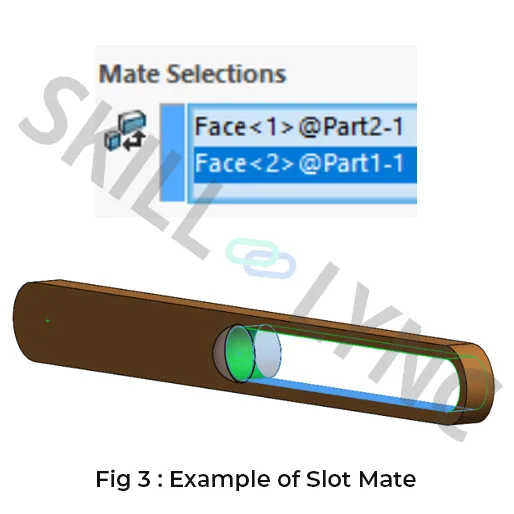
Fig 2 : Example of Slot Mate
Hinge Mate :
Hinge mate is the third type of mechanical mate in Solidworks assembly. It is a combination of coincident and concentric mate to simulate the behaviour of the hinge.
Hinge is basically used to limit the movements between two components to one rotational degree of freedom.
Since this mate is a combination of Coincident and concentric mates to apply this mate you need to select the two pairs of selection.
In the image given below is the example for hinge mate. In the first box “Concentric selection” you need to select the concentric portion of two parts.
In the second box “Coincidence selection” you need to select the faces which need to coincide with one another.
If you enable the “Specify angle limit” you can control the movement between to parts as per the requirement.
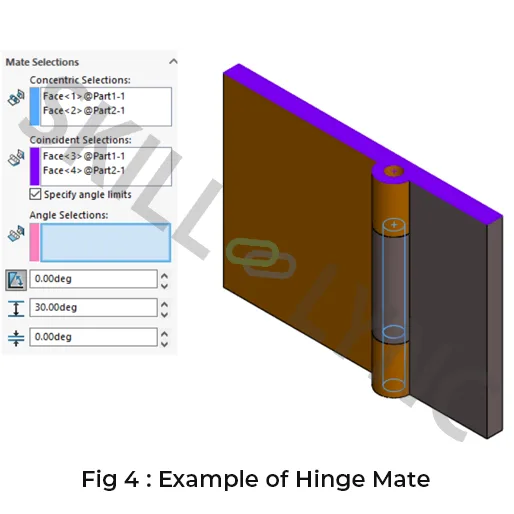
Fig 3: Example for Hinge Mate
Gear Mate :
Gear mate is used to simulate the motion of interlocking gears. This mate is basically used between the two gears or between two cylindrical components.
This mate is done by relating the rotary motion of one component to the other with the ratio.
The ratio between the two cylindrical components determines how much one component rotates compared to the other.
The rotation between two components is happening because of the set ratio. The components are not moving with the actual interlocking of gear teeths.
Since the ratio can be edited and reversed, the gear mate is also a great way to easily relate to objects that need to rotate together.
To apply the gear mate you need to select the cylindrical profiles in gear. After selecting the cylindrical Profiles in the gear it will automatically show the ratio. But you can change the ratio manually as per the requirement.
In the image given below two spur gears are used and also ratio is mentioned as 10mm : 5mm. It means that if the gear one rotates 10mm the gear two rotates 5mm.
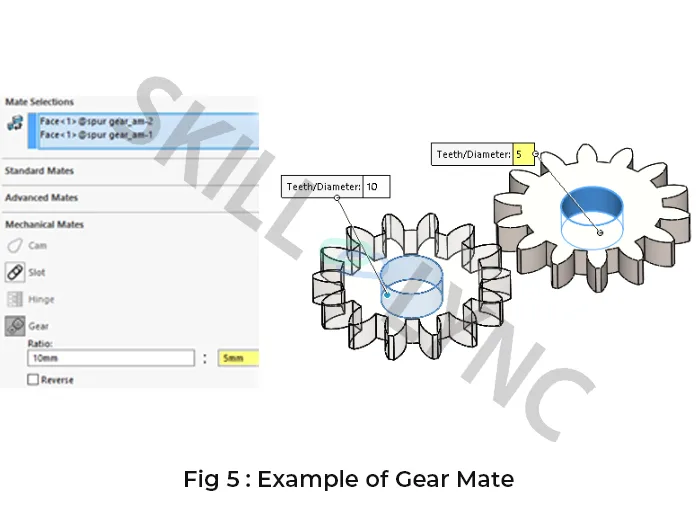
Fig 4 : Example for Gear Mate
Rack Pinion Mate :
Rack and pinion mates are more like the gears mates. It is basically used to simulate the motion between the rack and pinion gears.
Rack and pinion gears are basically used to transfer the rotary motion of one gear (Pinion) into linear motion of the other gear (Rack).
To apply this mate you need a liner edge of the rack or line of rack component and then, cylindrical face or circular edge of the pinion component.
The components are related in two different ways by applying the pitch diameter or else the rack distance travel.
In the below diagram the mate selection box and different options in the Rack and pinion gear is shown. By applying the value to the pinion teeth diameter or Rack distance travel you are able to control the rack and pinion movement.
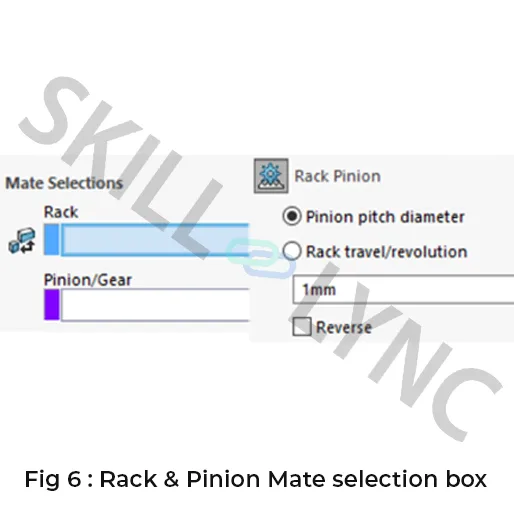
Fig 5 : Rack and Pinion Mate selection box
Screw Mate :
Screw mate in solidworks used to simulate the motion of the screw. In order to apply the screw mates we need two components constrained concentrically.
We are able to apply the rotary and linear motion to the component by using screw mates. Also, we can control the linear movement or rotation of the component.
There are two different options in screw mates. Thus, are given below,
- Revolution/Length-units - Set the number of revolutions of one component for each length unit of the other component translated.
- Distance/Revolution - Sets the distance that one component translates for each revolution of the other component.
This mate is also more like other mates. This will not remove the intersection or collision between the components. In order to remove the collision between the components we can manually use the collision detection method.
To apply the screw mate you need to select the faces of the concentrically constrained component. The diagram given below shows the mate selections and different options in screw mate.
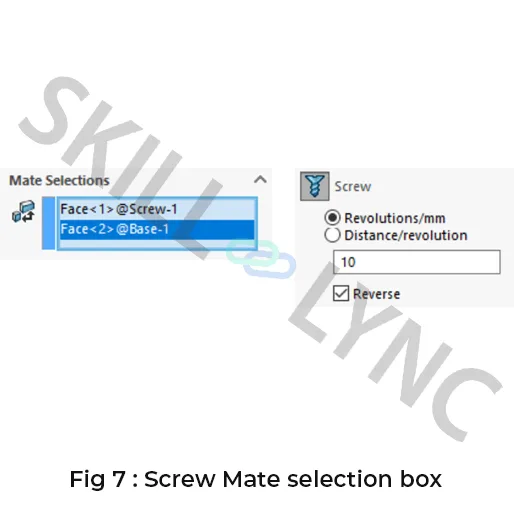
Fig 6 : Screw Mate selection box
Universal Joint Mate :
The last type of mechanical mate in solidworks is Universal joint mate. This mate is used to mimic the motion of the universal joint.
This mate is basically used whenever the two rods at an angle, to transfer the rotational motion from one rod to the other.
To apply this mate you need to select the cylindrical faces of the two different components aligned with some angle. This mate will automatically set some point. Based on this point the component will rotate. By using the “define joint point option” you are able to change the location of the point.
The mate selection for universal joint mate is as simple as normal mate selection.
Conclusion :
In this article we have learned about different types of mechanical mates in solidworks and the functions of mechanical mates.