Week-7 Challenge: DC Motor Control
QUESTION -
1. A. Explain a MATLAB demo model named ‘Speed control of a DC motor using BJT H-bridge’.
Solution -
As shown below the simulink model of an H-bridge used to generate a chopped voltage and to control the speed of a DC motor.
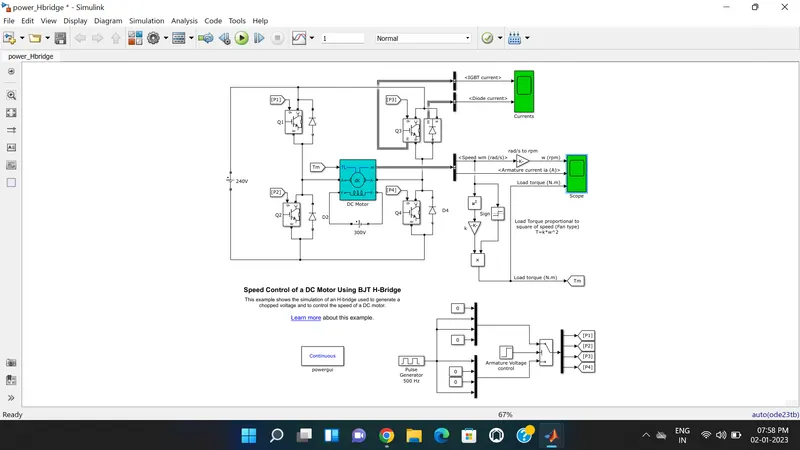
The Bipolar Junction Transistor (BJT) when used for power switching applications, operates as an IGBT. When it is conducting (BJT operating in the saturated region), a forward voltage Vf is developed between collector and emitter (in the range of 1 V). Therefore, the IGBT block can be used to model the BJT device.
An H-bridge is an electronic circuit that switches the polarity of a voltage applied to a load.The H-bridge consists of four BJT/Diode pairs (BJT simulated by IGBT models). Two transistors are switched simultaneously: Q1 and Q4 or Q2 and Q3. When Q1 and Q4 are fired, a positive voltage is applied to the motor and diodes D2-D3 operate as free-wheeling diodes when Q1 and Q4 are switched off. When Q2 and Q3 are fired, a negative voltage is applied to the motor and diodes D1-D4 operate as free-wheeling diodes when Q2 and Q3 are switched off.
Q1 and Q4 -forward motoring
Q2 and Q3 -reverse motoring
Supply voltage of 240V is applied to the Dc motor through H-bridge. Dc motor is connected to a battery and the the Dc motors mechanical input is intiated as torque.Torque for mechanical input of dc motor also switched by goto and from the output of dc motor is connected with bus selector whereas the speed is plotted in the scope .
The speed ,Torque and Armature current is obtained in the Scope block.The another one gives the IGBT and Diode current as shown in the above simulink model.
The DC motor used in the simulink model is a separately excited DC motor and NOT a DC series motor. That is the reason why a DC voltage of 300V is given to the field windings.
OUTPUT -
Duty Cycle is 75% -
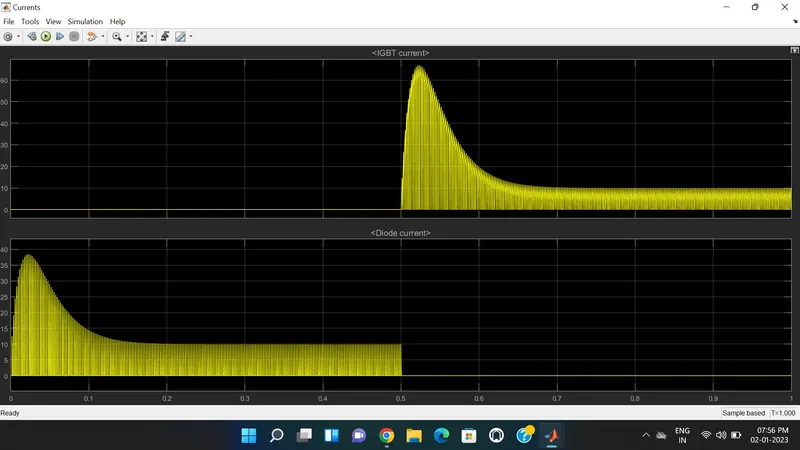
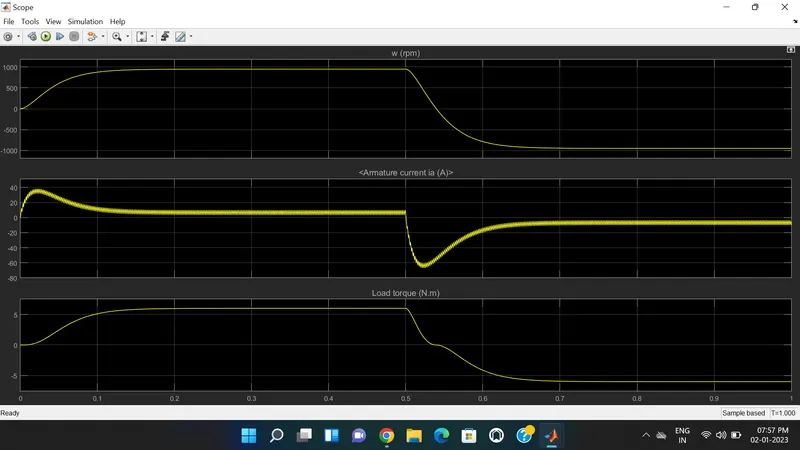
Here the Duty cycle is 75% and time period is 2 milisec which is given in the Pulse generator.Below plot shows the IGBT and Diode current.Also the nature of Armatue Current,speed and Torque are understand by the below plot.
The graph shows that when the switch Q3 is off on the starting stage of current flow and diode curent is on.During the 0.5 sec of time D3 is on that are given according to the pulse generator and after the time period of 0.5 sec D3 switch is off and IGBT current is acted after 0.5 sec and Q3 switch remains on.The speed and armature current is obtained by dc motor and load torque is calculated by torque proportional to the square of speed.
Duty Cycle is 50% -
Plot for the 50%Duty cycle and time period is same as the above i.e 2 milisec.The operation of Diode and IGBT turn on and off is same as discussed in above.Buit here due to reduction in duty cycle, we get the reduced output of IGBT current and Diode current.The nature of speed and Torque plot is same but the armature current which is shoot up in in above case here we can't see it ,because when pulse width decreases, the voltage applied across the DC motor decreases and the armature current finally decreases.
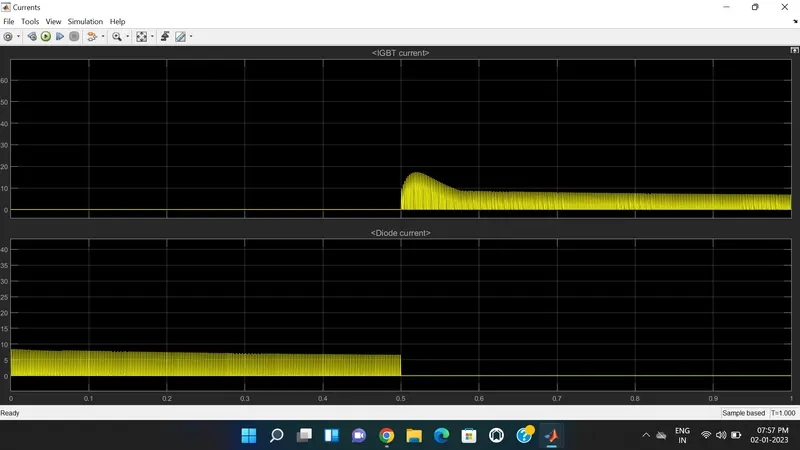
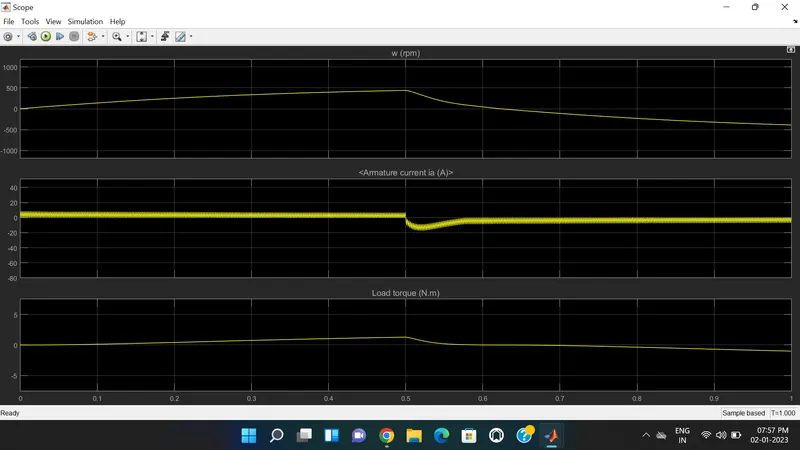
We can see from the output when the duty cycle is 50%. The armature current is lower as compared to the 75% duty cycle. Also, it can be observed that the IGBT Current and the Diode current are also lower when the duty cycle is 50% as in comparison with the 75% duty cycle.
B. Comment on the armature current shoot-up from the scope results.
Solution -
Basic operational voltage equation of a DC motor is given as
E = Eb + IaRa and hence, Ia = (E - Eb) / Ra
Now, when the motor is at rest, obviously, the back emf Eb = 0. Hence, armature current at the moment of starting can be given as Ia = E / Ra. In practical DC machines, armature resistance is basically very low, generally about 0.5 Ω. Therefore, a large current flows through the armature during starting. This current is large enough to damage the armature circuit.
The armature current spikes at each duration of switching when the armature voltage is reversed.
This is due to the transient switching between the two states of positive and negative voltage applied to the motor instantenously. This switching causes the input-surge current or inrush currents. The maximum instantaneous input current drawn by an electrical device when first turned on is known as Inrush current.
C. Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model.
Solution -
Four Quadrant Operation of any drives or DC Motor means that the machine operates in four quadrants. They are Forward Braking, Forward motoring, Reverse motoring and Reverse braking.
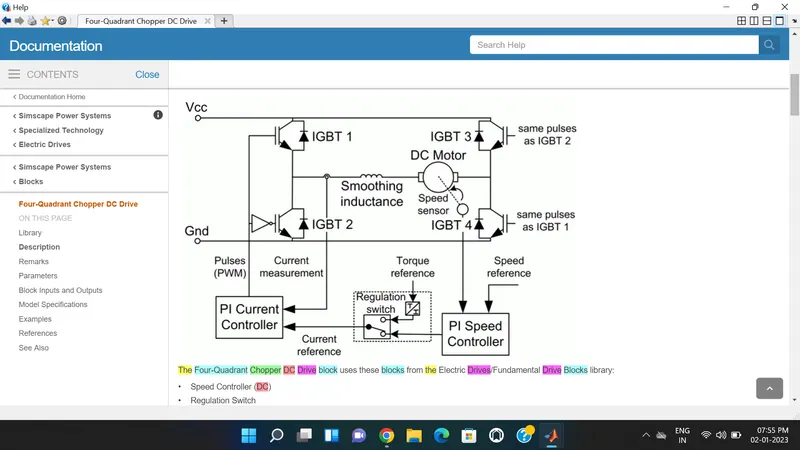
A motor operates in two modes – Motoring and Braking. A motor drive capable of operating in both directions of rotation and of producing both motoring and regeneration is called a Four Quadrant variable speed drive.
The speed control loop outputs the reference armature current of the machine. Using a PI current controller, the chopper duty cycle corresponding to the commanded armature current is derived. This duty cycle is then compared with a sawtooth carrier signal to obtain the required PWM signals for the chopper.
In the I quadrant power developed is positive and the machine is working as a motor supplying mechanical energy. The I (first) quadrant operation is called Forward Motoring. II second quadrant operation is known as Braking. In this quadrant, the direction of rotation is positive, and the torque is negative, and thus, the machine operates as a generator developing a negative torque, which opposes the motion.
The kinetic energy of the rotating parts is available as electrical energy which may be supplied back to the mains. In dynamic braking, the energy is dissipated in the resistance. The III third quadrant operation is known as the reverse motoring. The motor works, in the reverse direction. Both the speed and the torque have negative values while the power is positive.
In the IV fourth quadrant, the torque is positive, and the speed is negative so, The IV forth quadrant operation is known as the reverse breaking.
| H bridge | Four Quadrant chopper DC drive |
| 1.Simulation is continuous and simulation time is more. | 1.Discrete and Simulation time is less . |
| 2.Only Two quadrants of operation are possible. They are Forward motoring and reverse motoring | 2.It can operate in all four quadrants (forward motoring, reverse regeneration, reverse motoring, and forward regeneration). |
| 3.Less complex | 3.More complex. |
| 4.Higher armature current ripple. | 4.Lower armature current ripple due to high switching frequency of DC-DC coverters. |
| 5.Regenerative braking cannot be available. | 5.Regenarative braking can be achieved. |
| 6.Widely Used in Robotics. | 6.Widely used in Automobile. |
| 7.Less control of vehicle | 7.Better control of vehicle |
2. Develop a 2-quadrant chopper using simulink & explain the working of the same with the relevant results. (Refer to article - Multiquadrant operation of motor )
Solution -
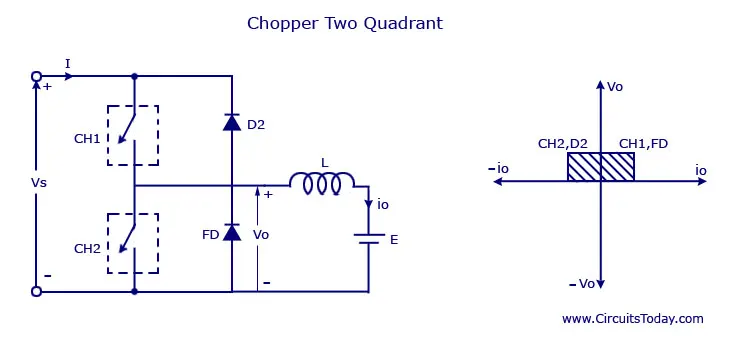
As shown in circuit diagram current flows in two directions across the load inductor from source to load and from load to source .
souce to load-whenever CH1 is ON current flows in forward direction.when CH1 is off ,the remaining current in inductor flows through freewheeling diode by changing its inductor polarity in same direction thus 1st quadrant operation is done until VL>E
load to source-when CH2 is ON current flows in opposite direction thorough CH2 when E>VL .when CH2 is off current flows back to battery source through D2.
SIMULINK MODEL -
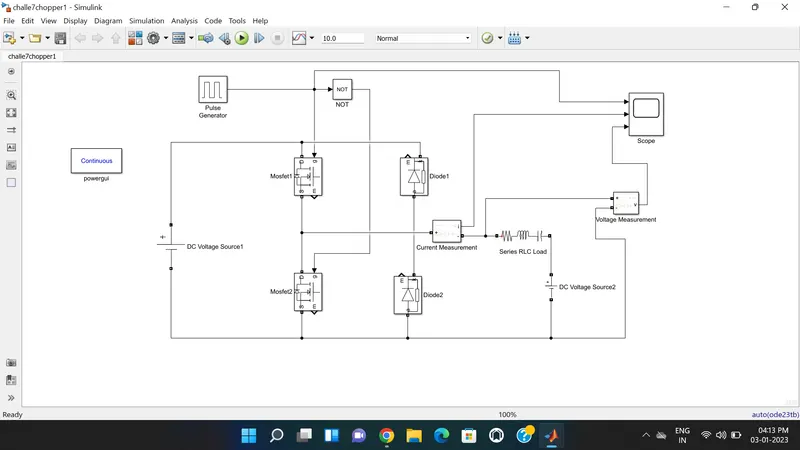
In the simulation, the Pulse Generator block is used to generate gate pulse with parameters Amplitude set to 10, period of 2 seconds and the pulse width of 75%. The DC Voltage source1 is of 24V, an RLC circuit, that will act as motor load, is connected with series with another DC Voltage source2 of 12V.
The NOT – Gate is used so that the 2 MOSFETs don't get closed at the same time and cause short-circuit.Here for performing the operation of 2 quadrant chopper we used 2 MOSFET's and 2 diodes.
Current measurement block is connected in series with the load and voltage measurement block is connected in parallel between the load and DC voltage source2. The RLC load has inductive reactive power is selected as 100var and capacitive reactive power is 50var.
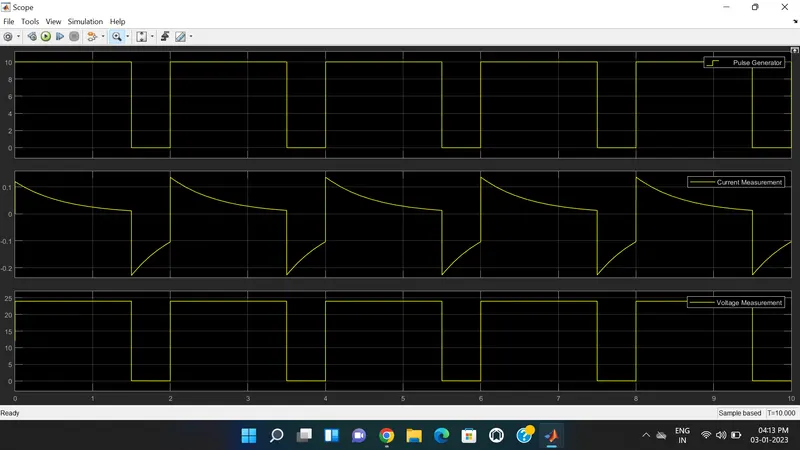
Gate pulse ,Voltage and Current output waveform is obtained at Scope as shown in the model.Powergui block is used to simulate any Simulink model containing Simscape, Power Systems Specialized Technology blocks.
OUTPUT -
In the output, we can observe that the graph of Pulse Generator and the Voltage Measurement is the same, i.e., square wave. Whereas, there is a sudden change in current whenever there is a change in the pulse generator or the voltage. If the change is decreasing, then the current graph shows a negative increase and when the voltage and pulse are constant, the current slowly comes to zero and vice-versa.Due to the capacitor we obtained the below nature of current in the negative direction.
3. Explain in a brief about operation of BLDC motor.
Solution -
A brushless DC motor (also known as a BLDC motor or BL motor) is an electronically commuted DC motorwhich does not have brushes. The controller provides pulses of current to the motor windings which control the speed and torque of the synchronous motor.
These types of motors are highly efficient in producing a large amount of torque over a vast speed range. In brushless motors, permanent magnets rotate around a fixed armature and overcome the problem of connecting current to the armature. Commutation with electronics has a large scope of capabilities and flexibility. They are known for smooth operation and holding torque when stationary.
Construction -
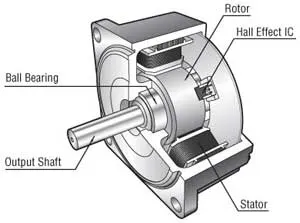
In this motor, the permanent magnets attach to the rotor. The current-carrying conductors or armature windings are located on the stator. They use electrical commutation to convert electrical energy into mechanical energy.
The main design difference between a brushed and brushless motors is the replacement of mechanical commutator with an electric switch circuit. A BLDC Motor is a type of synchronous motor in the sense that the magnetic field generated by the stator and the rotor revolve at the same frequency.
Working -
BLDC motor works on the principle similar to that of a Brushed DC motor. The Lorentz force law which states that whenever a current carrying conductor placed in a magnetic field it experiences a force. As a consequence of reaction force, the magnet will experience an equal and opposite force. In the BLDC motor, the current carrying conductor is stationary and the permanent magnet is moving.
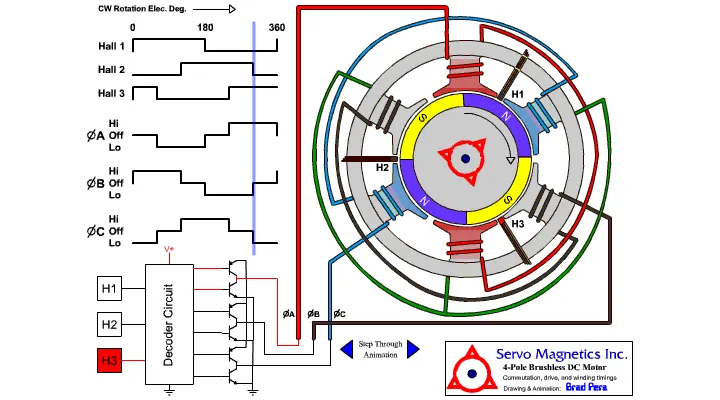
When the stator coils get a supply from source, it becomes electromagnet and starts producing the uniform field in the air gap. Though the source of supply is DC, switching makes to generate an AC voltage waveform with trapezoidal shape. Due to the force of interaction between electromagnet stator and permanent magnet rotor, the rotor continues to rotate.
With the switching of windings as High and Low signals, corresponding winding energized as North and South poles. The permanent magnet rotor with North and South poles align with stator poles which causes the motor to rotate which is clearly showing in the above diagram.
Advantages -
- Higher speed range and lower electric noise generation.
- It has no mechanical commutator and associated problems
- Less overall maintenance due to absence of brushes
- High speed of operation even in loaded and unloaded conditions due to the absence of brushes that limits the speed
- Reduced size with far superior thermal characteristics.
- High efficiency and high output power to size ratio due to the use of permanent magnet rotor.
- Long life as no inspection and maintenance is required for commutator system
Disadvantages -
- Electronic controller required control this motor is expensive.
- Requires complex drive circuitry.
- These motors are costly.
Application -
- Electric vehicles, hybrid vehicles, and electric bicycles.
- Washing machines, compressors and dryers.
- Fans, pumps and blowers.
- Industrial robots.