Week-7 Challenge: DC Motor Control
Que 1:
Ans>
A.Explain a MATLAB demo model named ‘Speed control of a DC motor using BJT H-bridge’:
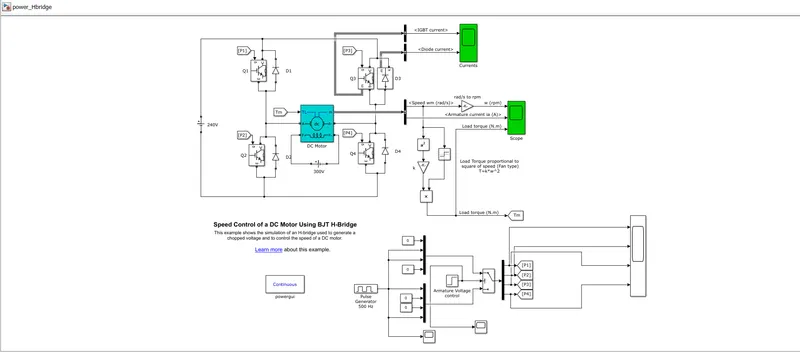
This example shows the simulation of an H-bridge used to generate a chopped voltage and to control the speed of a DC motor.
The H-bridge consists of four BJT/Diode pairs (BJT simulated by IGBT models).
Two transistors are switched simultaneously: Q1 and Q4 or Q2 and Q3. When Q1 and Q4 are fired, a positive voltage is applied to the motor and diodes D2-D3 operate as free-wheeling diodes when Q1 and Q4 are switched off. When Q2 and Q3 are fired, a negative voltage is applied to the motor and diodes D1-D4 operate as free-wheeling diodes when Q2 and Q3 are switched off:
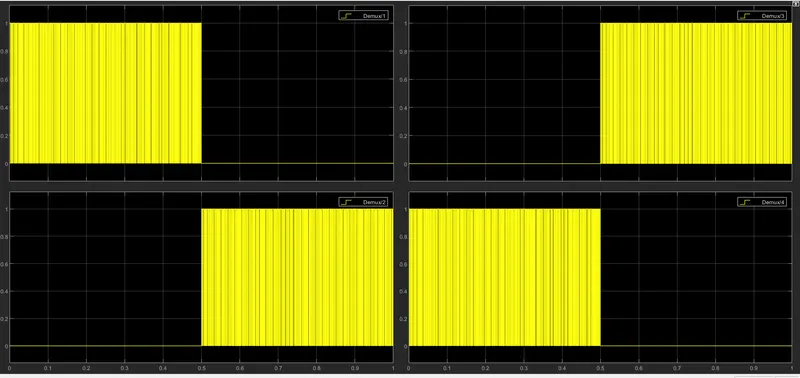
As shown below switching of Q1 and Q4 fired for same time then Q2 and Q3 fired for next duration:
Simulation Results:
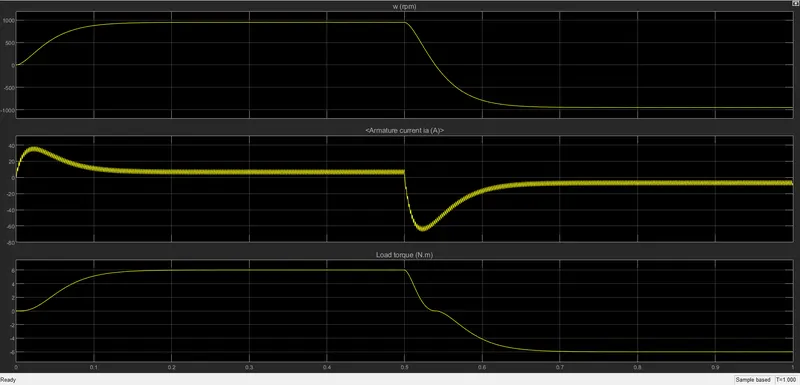
As shown in results
1.when Q1 and Q2 fired then armature current flows is positive and motor rotates in positive direction.
2. When Q3 and Q4 fired then armature current flows is positive and motor rotates in negative directionm
3. As duty cycle of PWM signal is 75% so IGBT's are turn ON for 75 % duration of each cycle of 0.002 then for 25 % motor runs through freewheeling Diode.
4. Torque of motor is directly dependent on armature current as result motor speed which is dependent on torque changes its rotating direction with change in current flowing direction.
B. Comment on the armature current shoot-up from the scope results:
> Current Shoot- up due to duty ratio of PWM signal :
for 75 % duty cycle:
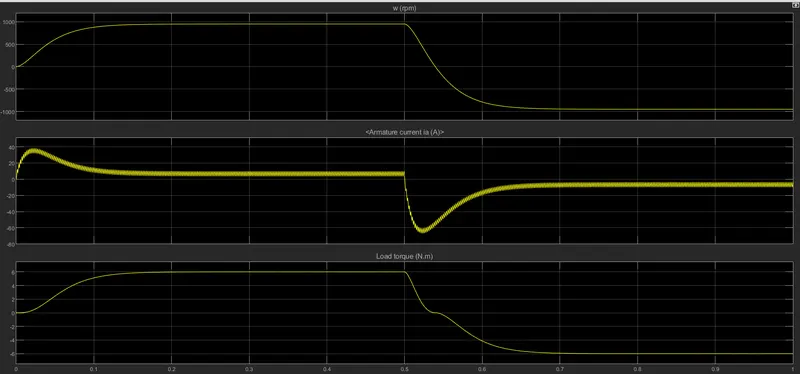
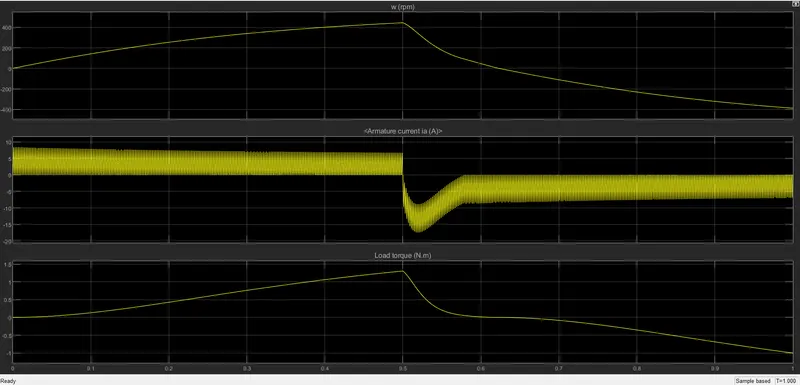
for 50 % duty cycle spike in positive current reduces but load torque reduced which further cause decrease in speed:
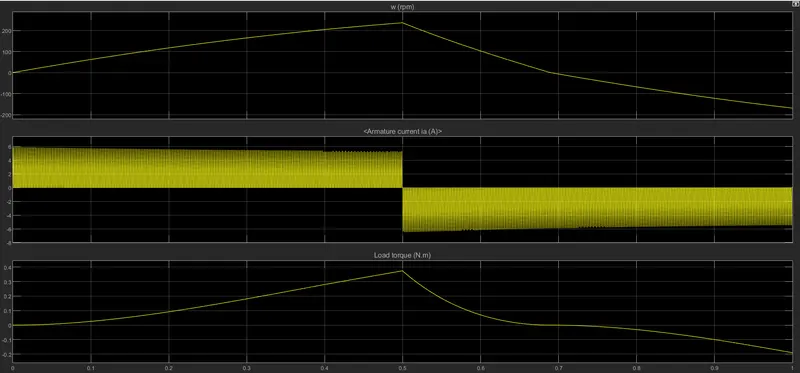
Similarly for 35% duty cycle it reduces spike in both positive and negative current but load torque reduced which further cause decrease in speed:
Conclusion:
So spike in current is due to high voltage which is due to high duty cycle of PWM. By varrying duty cycle we can adjust spike in current but then load torque and Speed of motor decreases
C. Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model.
Ans>
Example using Four-Quadrant Chopper DC Drive (DC7) block as shown below:
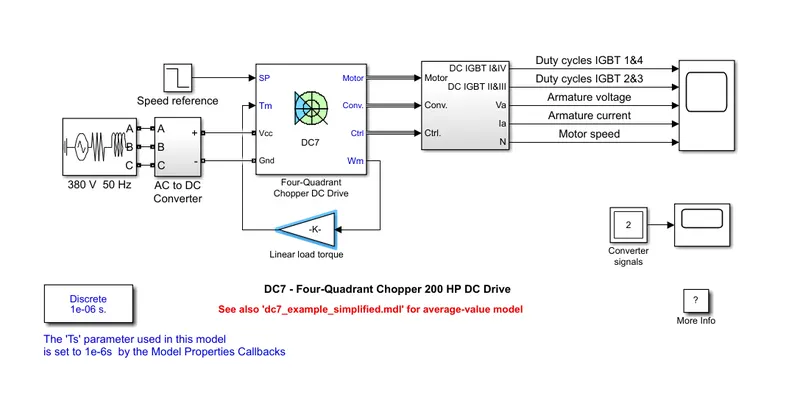
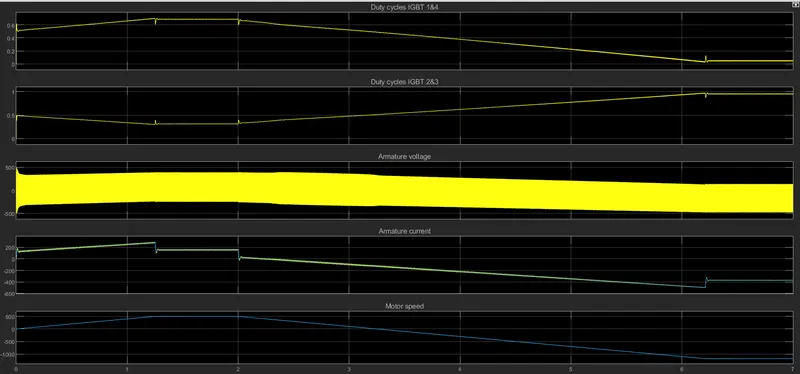
As shown in above example no external pulse and speed control method used instead it used current control method for generating pulse for gate of IGBT and used speed control method for controlling speed which is inside block.
Inputs used:
Speed reference, feedback of load torque requirement, DC voltage
Using this input it automatically control current and generate pulse which used to control speed of motor rather than pnly controlling duty cycle of PWM in case of H-bridge model
Controlling method:
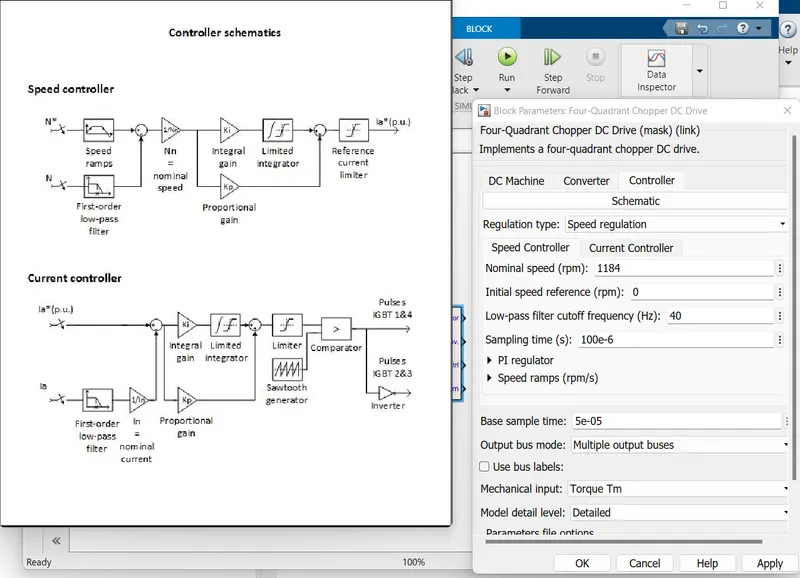
Simulation result shows proper controlling of speed:
Comparison:
| Comparison | ||
| Parameters | Four-Quadrant Chopper DC Drive | H-bridge model |
| Pulse Generation | Using Current control method Pulse generate | PWM |
| Speed Contol | Speed Controller using PID | PWM duty cycle |
| Controlling | Automatic | Manual |
| system | Closed loop | Open loop |
| Duty Cycle | Adjusted Automatically using PI controller | Adjust manually |
Que 2:
Ans>
Two Quadrant Chopper Operation:
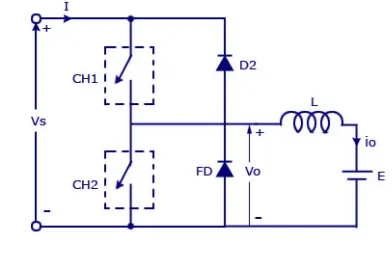
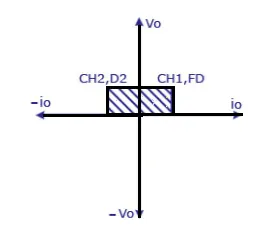
In this type of Chopper, the average voltage will be always positive but the average load current might be positive or negative. The two Switches CH1 and CH2 should not be turned on simultaneously as the combined action may cause a short circuit in supply lines. For regenerative braking and motoring these type of chopper configuration is used.
We will always get a positive output voltage V0 as the freewheeling diode FD is present across the load. When the chopper CH1 is on the current flows from source to load. The inductor stores energy. When Ch1 turn OFF the freewheeling diode starts conducting and the output voltage v0 will be equal to Vs. The direction of the load current i0 will be reversed. The current i0 will be flowing towards the source. The load current will be negative when the CH2 is on. The current completes its path through diode D2.
MATLAB model:
Step 1:
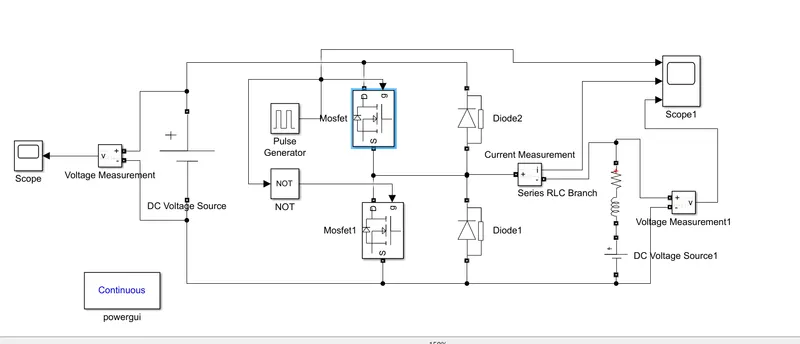
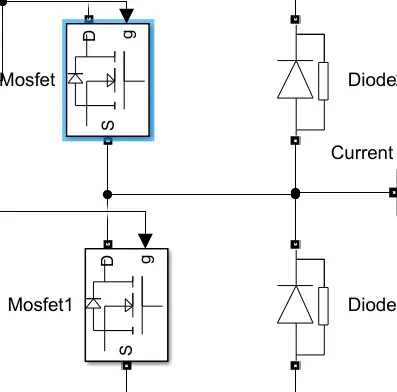
As shown in Model 2 mosfets and 2 diodes are used to create TWO quadrent chopper circuit:
Step 2: DC supply is used as source as shown in fig1
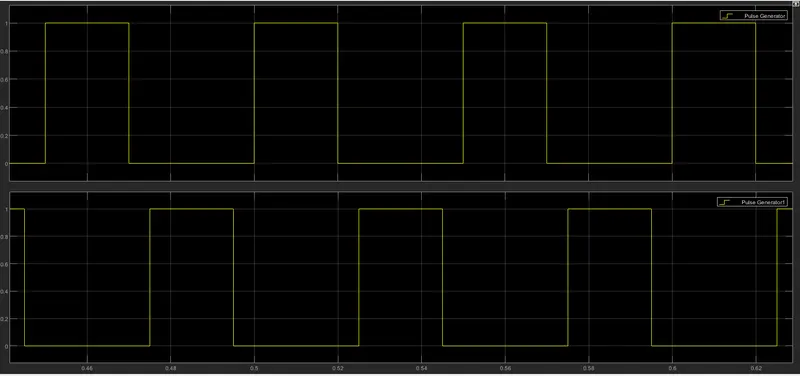
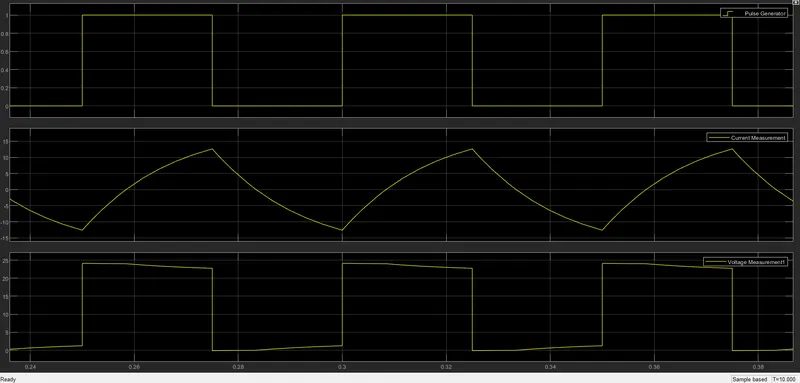
Step 3 :PWM generator is used to generate pulse with delay and duty cycle of 40% as shown below:
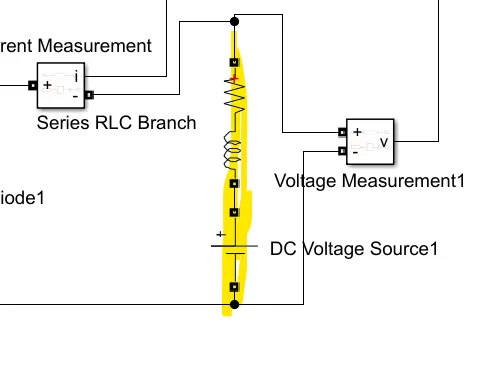
Step 4: RL load and DC voltage source is used to create DC machine load
Simulation Results:
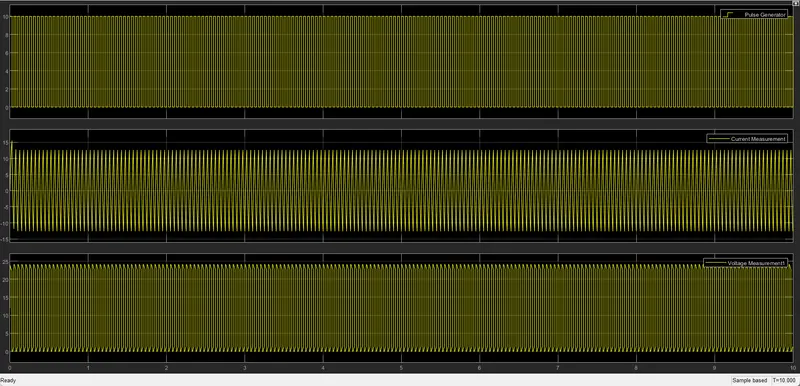
As shown below result :
1. when PWM1 is active then SW1 is on and current is positively increasing
2. When PWM1 is deactive the SW1 is off and load is connected through freewheeling diode and current is decreasing towards zero.
3. when PWM2 is active then SW2 is on and current is negative
4. When PWM2 is deactive the SW2 is off and load is connected through freewheeling diode and current is decreasing towards negative.
and for this total operating period voltage is always positive with chopping voltage.
Que 3: Explain in a brief about operation of BLDC motor.
Ans>
A brushless DC motor (known as BLDC) is a permanent magnet synchronous electric motor which is driven by direct current (DC) electricity and it accomplishes electronically controlled commutation system (commutation is the process of producing rotational torque in the motor by changing phase currents through it at appropriate times) instead of a mechanically commutation system. BLDC motors are also referred as trapezoidal permanent magnet motors.
Construction:
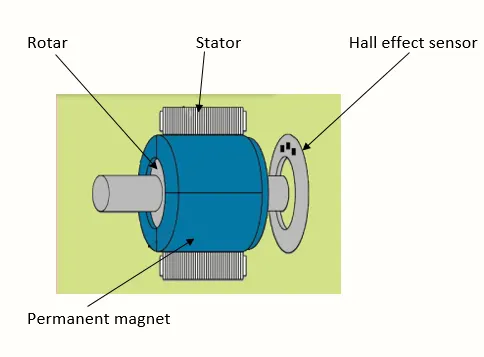
BLDC motors can be constructed in different physical configurations. Depending on the stator windings, these can be configured as single-phase, two-phase, or three-phase motors. However, three-phase BLDC motors with permanent magnet rotor are most commonly used.
The construction of this motor has many similarities of three phase induction motor as well as conventional DC motor. This motor has stator and rotor parts as like all other motors.
Working Principle and Operation of BLDC Motor
BLDC motor works on the principle similar to that of a conventional DC motor, the Lorentz force law which states that whenever a current carrying conductor placed in a magnetic field it experiences a force. As a consequence of reaction force, the magnet will experience an equal and opposite force. In case BLDC motor, the current carrying conductor is stationary while the permanent magnet moves.
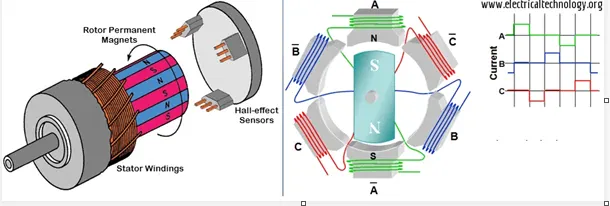
When the stator coils are electrically switched by a supply source, it becomes electromagnet and starts producing the uniform field in the air gap. Though the source of supply is DC, switching makes to generate an AC voltage waveform with trapezoidal shape. Due to the force of interaction between electromagnet stator and permanent magnet rotor, the rotor continues to rotate.
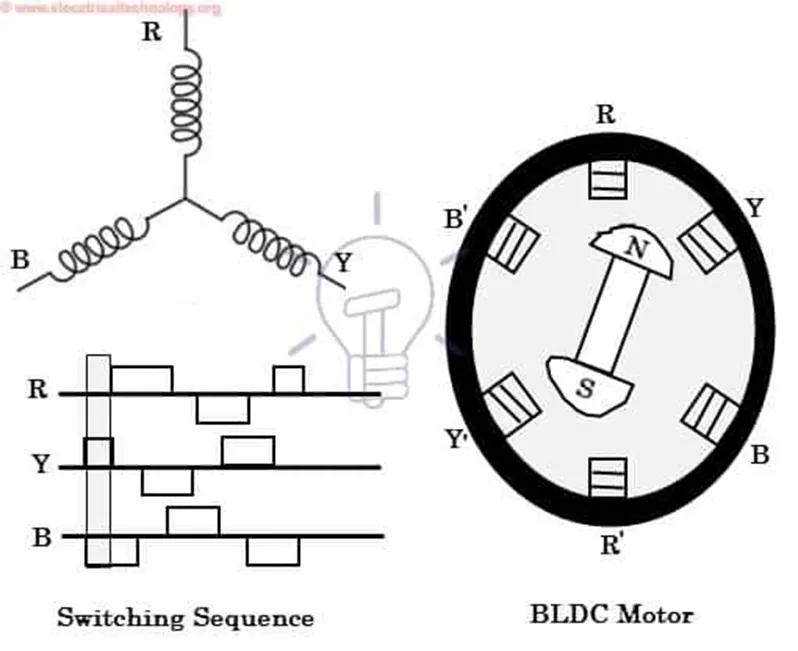
Consider the figure below in which motor stator is excited based on different switching states. With the switching of windings as High and Low signals, corresponding winding energized as North and South poles. The permanent magnet rotor with North and South poles align with stator poles causing motor to rotate.
Observe that motor produces torque because of the development of attraction forces (when North-South or South-North alignment) and repulsion forces (when North-North or South-South alignment). By this way motor moves in a clockwise direction.
Advantages of BLDC Motor
- It has no mechanical commutator and associated problems
- High efficiency due to the use of permanent magnet rotor
- High speed of operation even in loaded and unloaded conditions due to the absence of brushes that limits the speed
- Smaller motor geometry and lighter in weight than both brushed type DC and induction AC motors
- Long life as no inspection and maintenance is required for commutator system
- Higher dynamic response due to low inertia and carrying windings in the stator
- Less electromagnetic interference
- Quite operation (or low noise) due to absence of brushes
Disadvantages of Brushless Motor
- These motors are costly
- Electronic controller required control this motor is expensive
- Not much availability of many integrated electronic control solutions, especially for tiny BLDC motors
- Requires complex drive circuitry
- Need of additional sensors
Applications of Brushless DC Motors (BLDC)
- Computer hard drives and DVD/CD players
- Electric vehicles, hybrid vehicles, and electric bicycles
- Industrial robots, CNC machine tools, and simple belt driven systems
- Washing machines, compressors and dryers
- Fans, pumps and blowers