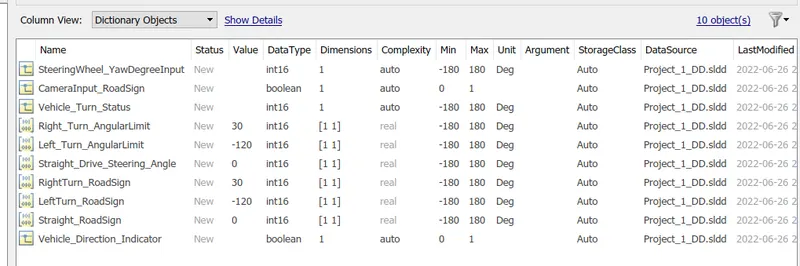
Project 1 (Mini Project on Vehicle Direction Detection
Aim:
Aim of Project to estimate vehicle direction to indicate driver in which direction vehicle moving from steering wheel yaw angle and from camera input.
Step1:
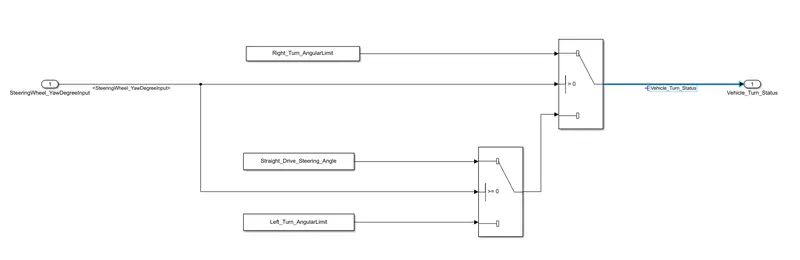
Created model for requiremet 1
Steering wheel angle is compared with right, left and straight angle limit to determine in which direction it is moving,
Output Vehicle turn status will give angle in degree depends on comparison
Step 2:
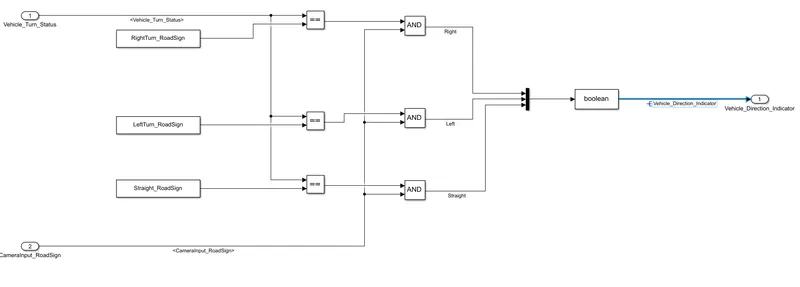
Created model for requirement 2
Ouput from 1st requirement is used as input to this subsystem and it is compared with road data signs if all are equal then using and signal its output compared with Camera Input road sign.
Mux signal is used for combining all output, finally only one signal is true which indicate vehicle direction as output
Step 3:
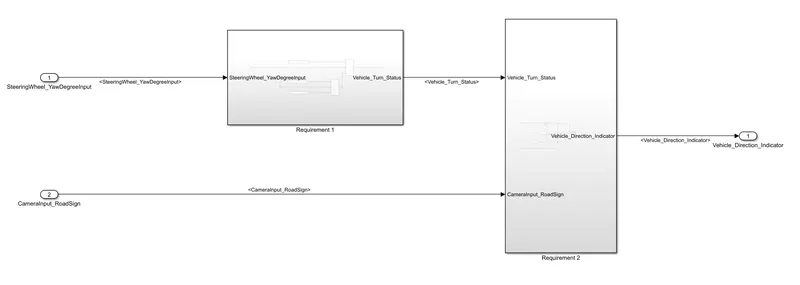
Tag requirements to two subsystems as Requirement 1 and 2
Step 3:
Added signal names to input and output
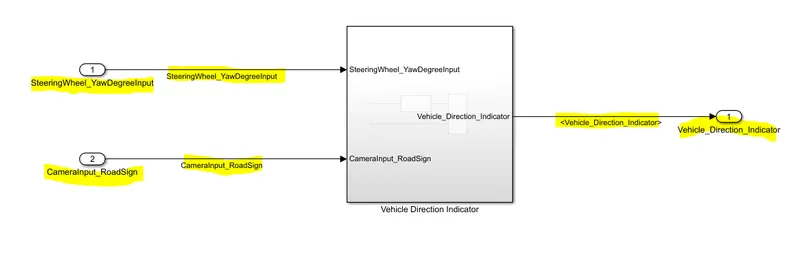
Step 5:
Added propagation tag to every signals
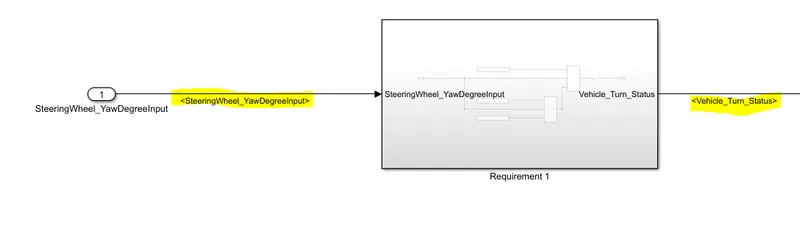
Step 6:
Signal names must resolved to simulink signals
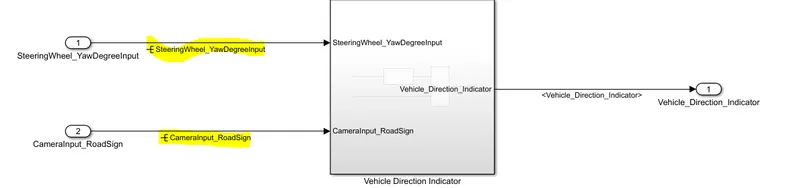
Step 7:
Created Data dictionary file for input, ouput, local and calibrations signal