Project
Aim-
To Prepare a technical report on baja-all-terrain-vehicle-atv-model.
Objective-
Objective is to perform system level simulation Bajaj All-Terrain vehicle with CVT transmission different condition and comments on result
Case 1:
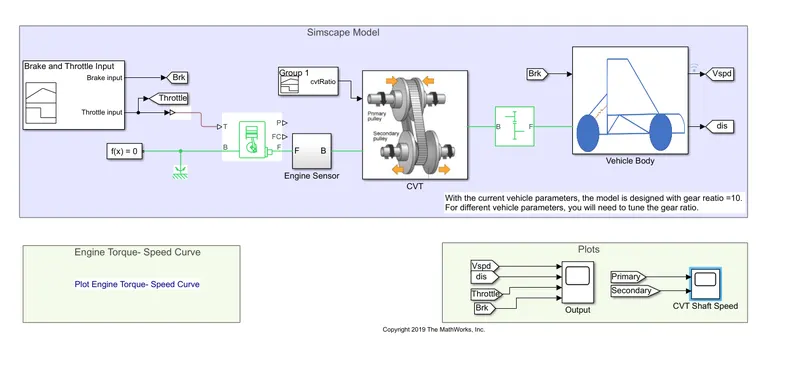
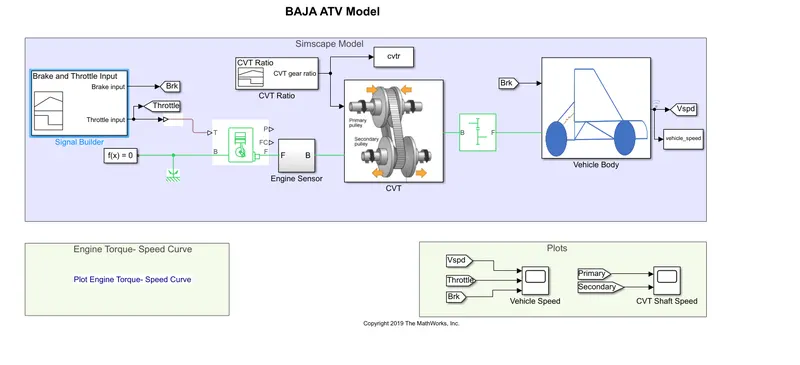
cvtModel is Bajaj All-Terrain vehicle with CVT input is given from signal builder
Step 1:
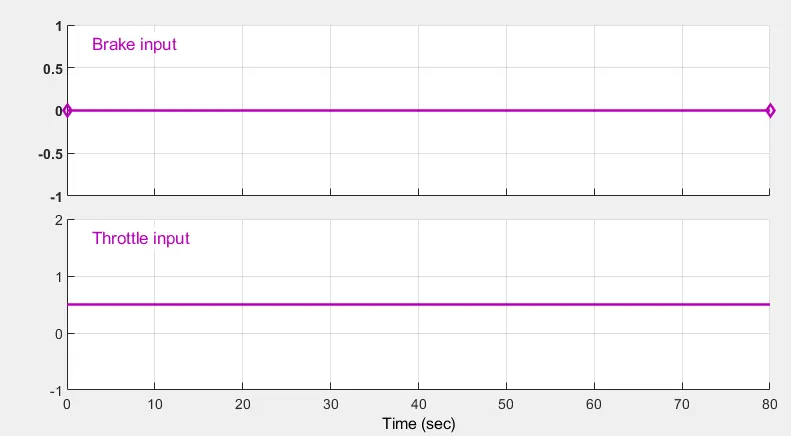
Brake and throttle of acceleration pedal is used as input to the model
Step 2:
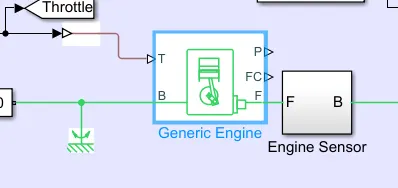
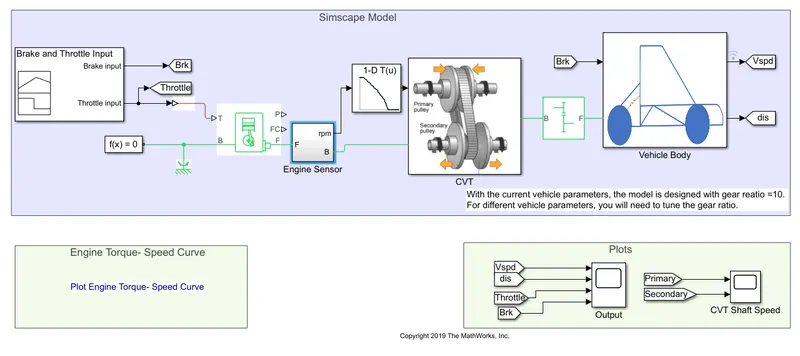
Generic engine is used to convert throttle input into rotating mechanical movement
This rotating movement is sense using engine sensor and give speed output in RPM
Step 3:
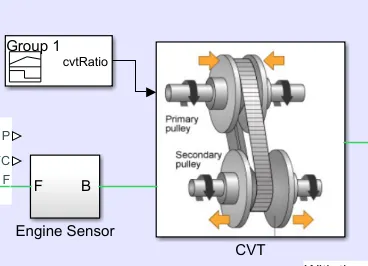
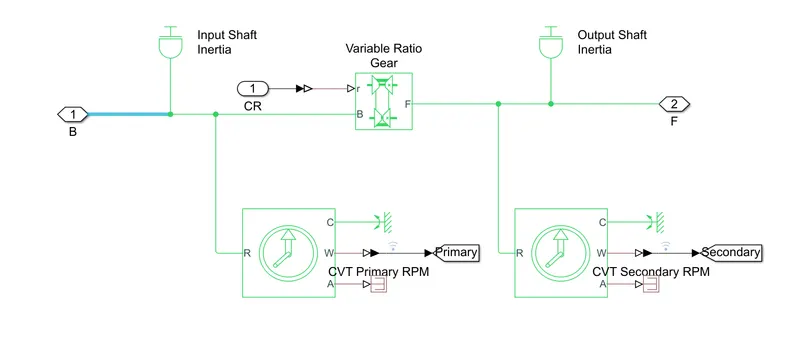
This Speed RPM is converted to higher speed using continuous variable transmission (CVT)
CVT consist of two inputs one is CVT ratio varrying wrt to time and another is Engine Speed in RPM
As CVT consist of two pulley there RPM is measured as primary and secondary RPM. Primary RPM is Engine Speed input and Secondary RPM is CVT transmission Output after adding continuous varrying gear ration wrt to time.
Step 4:
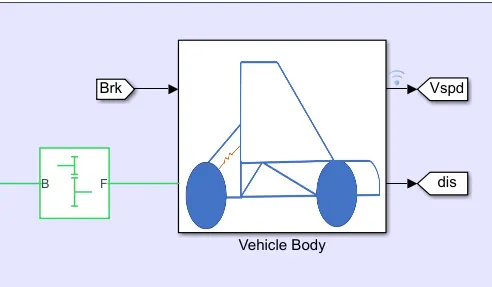
Output of CVT which is secondary speed rpm is given to simple constant gear through which is connected to vehicle wheel
Step 5:
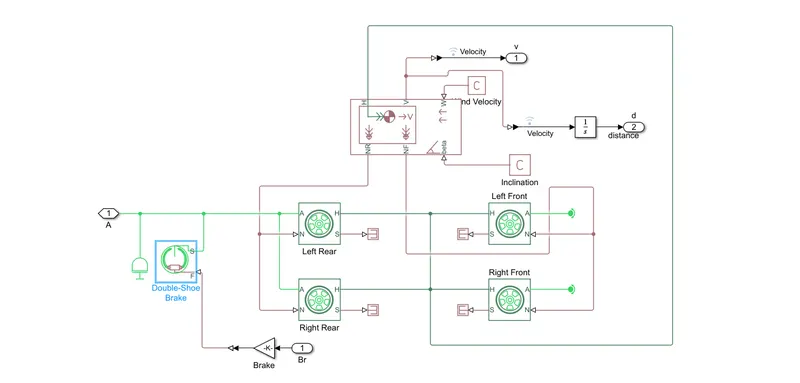
Vehicle body block consist of vehicle body in which vehicle parameters are given as input to act as baja all terrain vehicle and this vehicle body is connected to four wheels
Results:
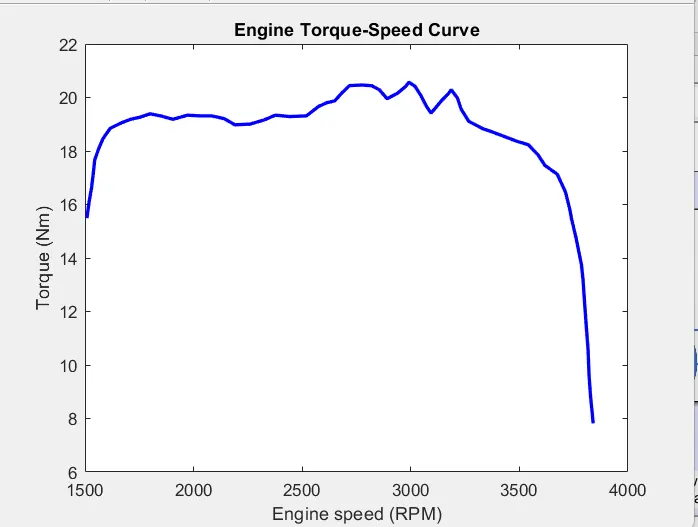
This graph shows torque- speed characteristics of engine
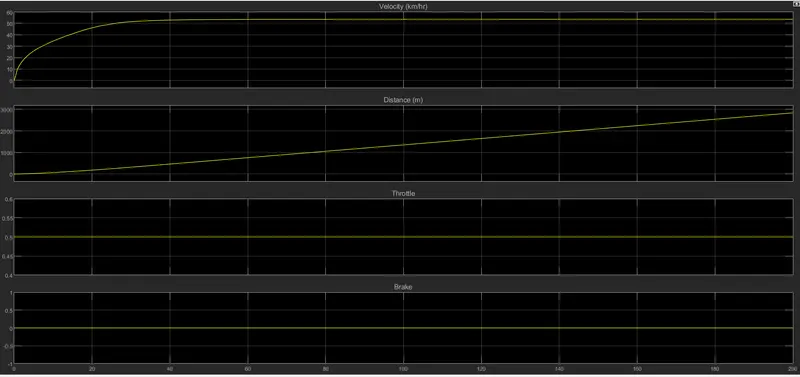
Following results shows that with constant throttle input vehicle speed increases gradually intially and then constant
And Distance is conuously increasing with constant throttle
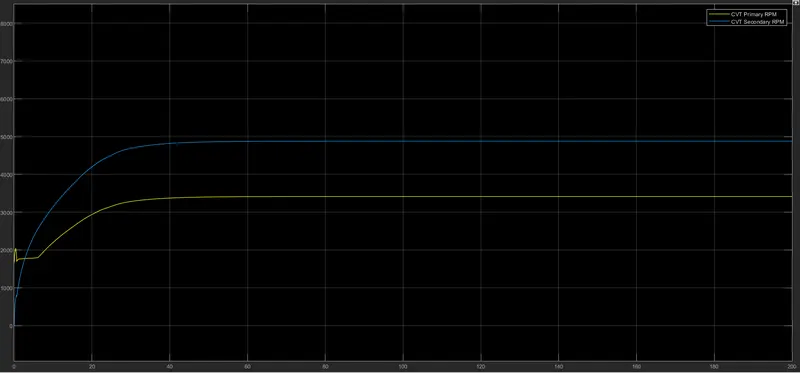
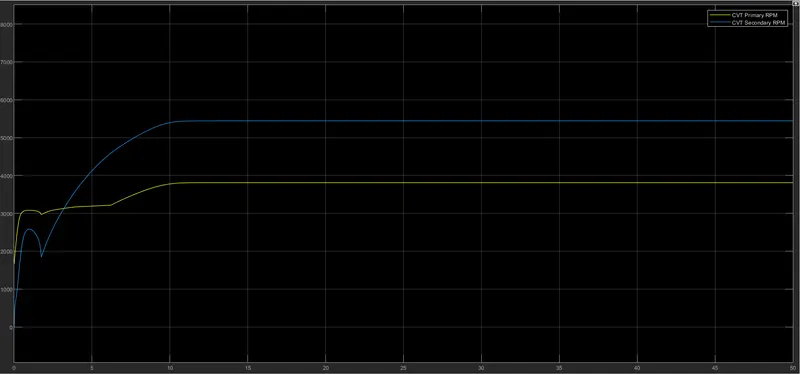
Following results shows comparison of CVT primary speed wrt Secondary speed.
CVT output of secondary speed which is greater than primary speed
Case 2:
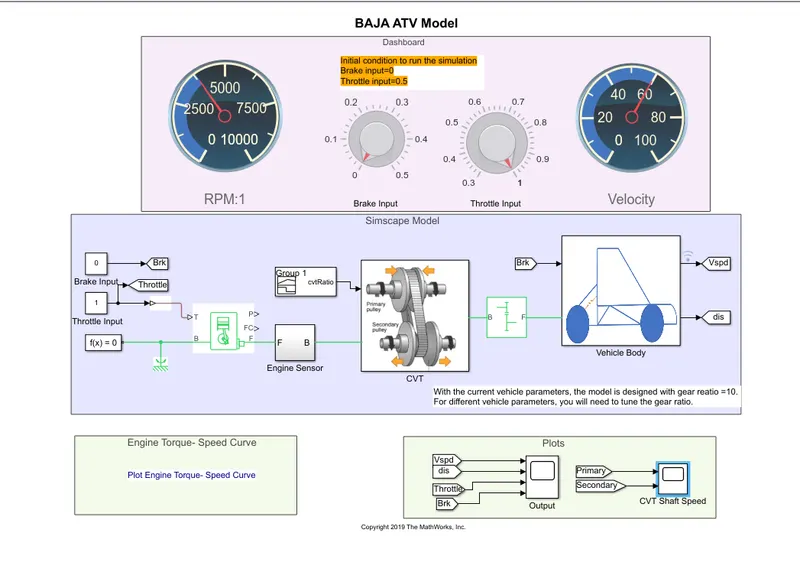
cvtModel_dashboard is added with dashboard to previous model of Bajaj All-Terrain vehicle with CVT input is given from signal builder
Results :
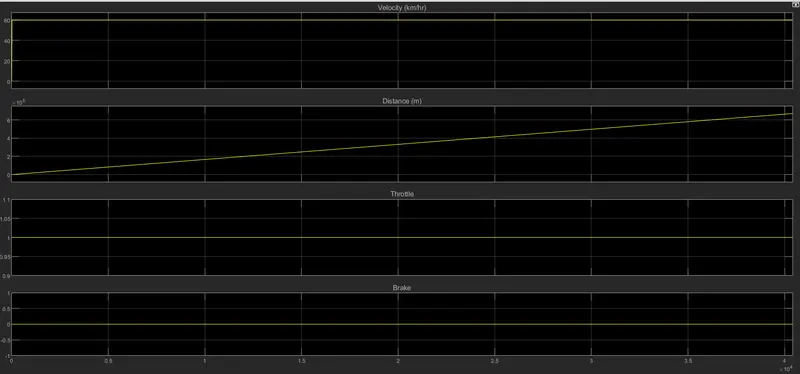
In dashboard we can see real time varrying speed wrt to throttle while simulation is running
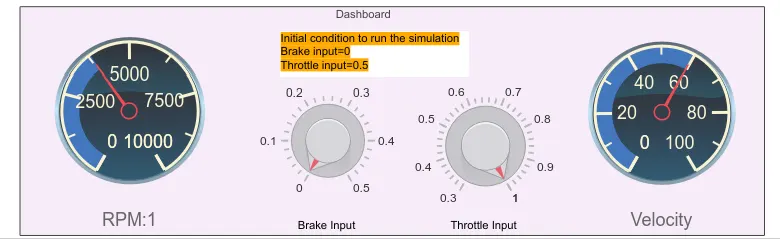
Speed is constant 60kmph as throttle is constant 100%
Case 3:
cvtModel_Mapped in this model mapped data of vehicle speed vs CVT gear ratio is used varry gear ratio depend on speed of running vehicle
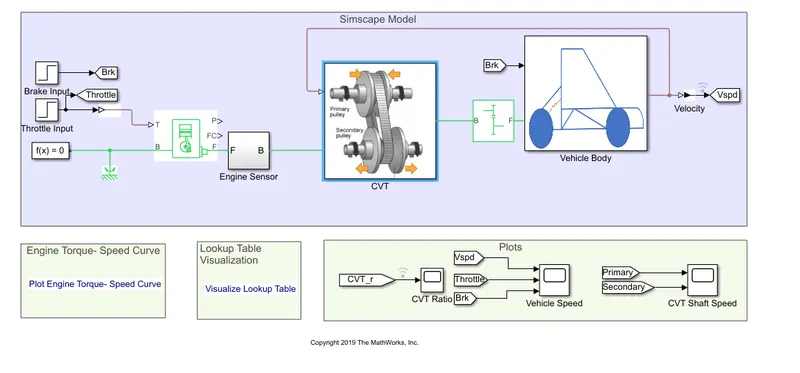
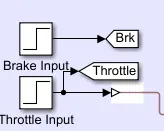
Throttle and brake inputs are given from step block:
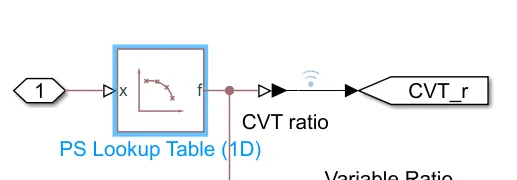
Signal builder block is replaced with simscape look up table in which mapped data of vehicle speed vs cvt gear ratio is used.
CVT ratio varrys depend on vehicle actual speed
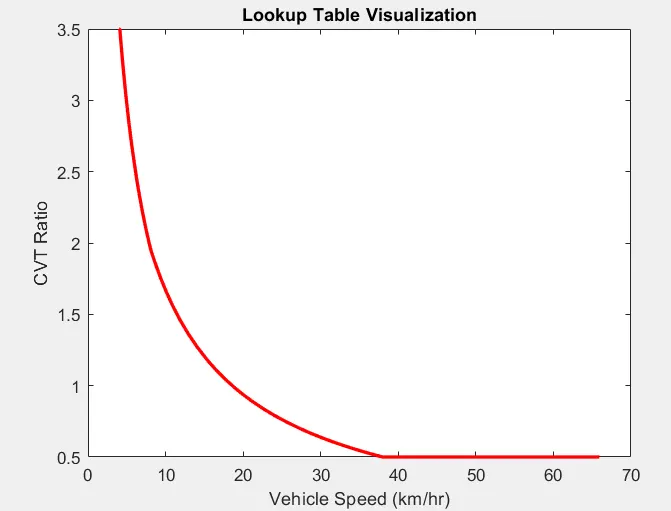
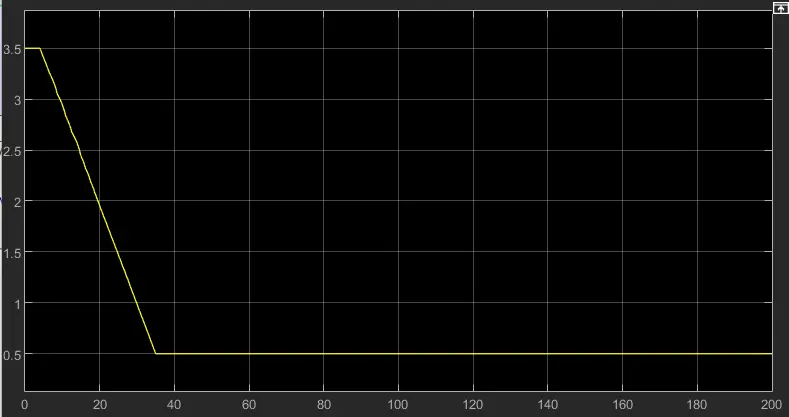
Results:
Following result shows varrying CVR ratio output
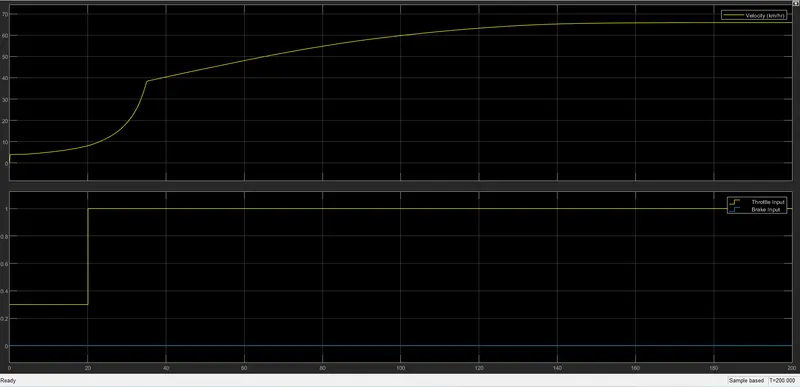
In following result it shows how vehicle speed varry with throttle as intially throttle is 30% press vehicle speed takes time to increase
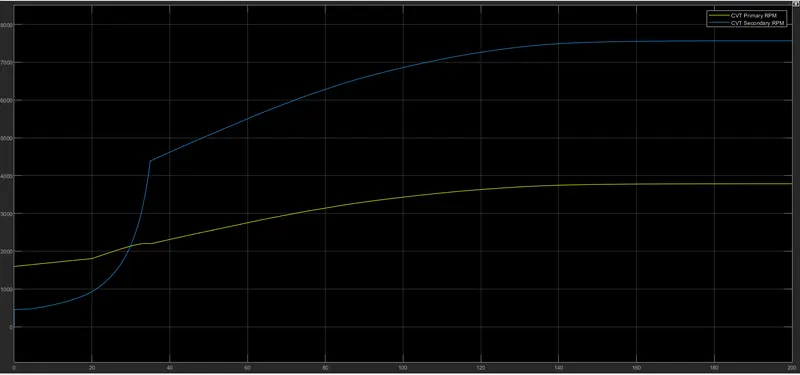
Following results shows primary and secodary speeds of CVT
Intially primary speed was greater than secondary speed because as intially throttle is 30% press vehicle speed takes time to increase but as CVT ratio increases Secondary speed is greater than primary
Case 4:
cvtModel_dashboard_mapped in this model added with dashboard to previous model of mapped data of vehicle speed vs CVT gear ratio is used varry gear ratio inCVT depend on speed of running vehicle
Throttle and brake input are given from constant:
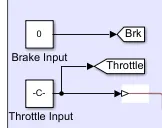
Result
In dashboard we can see real time varrying speed wrt to throttle while simulation is running
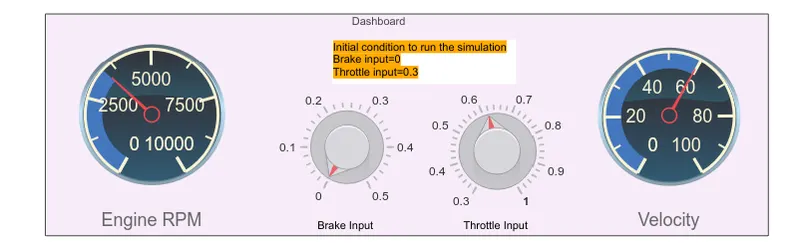
For constant throttle of 60%, how vehicle speed is varry is shown below
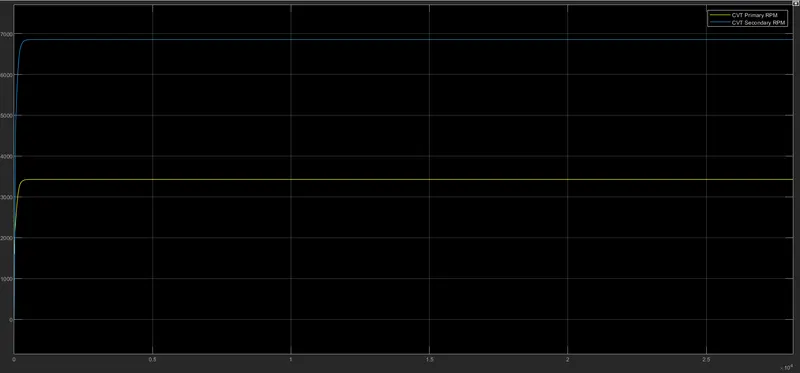
Following graph shows how primary and secondary RPM of CVT varrys
Case 5:
cvtModel_cvratio_rpm model of cvratio in which engine speed (RPM) vs CVT gear ratio is used varry gear ratio in CVT depend on speed of Engine
Step 1:
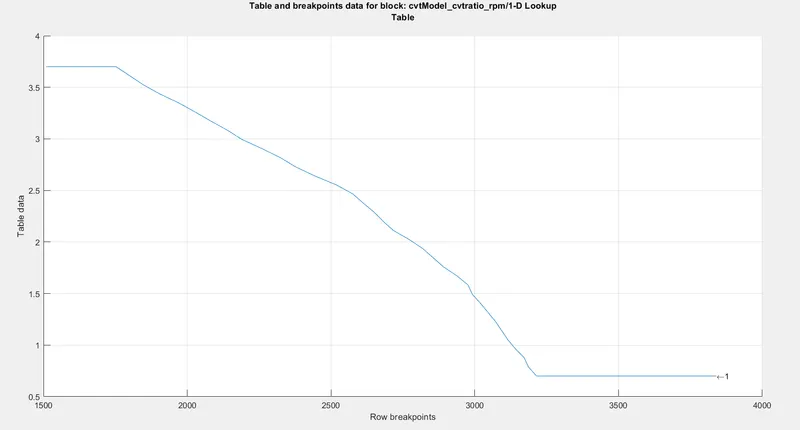
Look up table is used in model which consist graph of engine speed vs cv ratio:
Results:
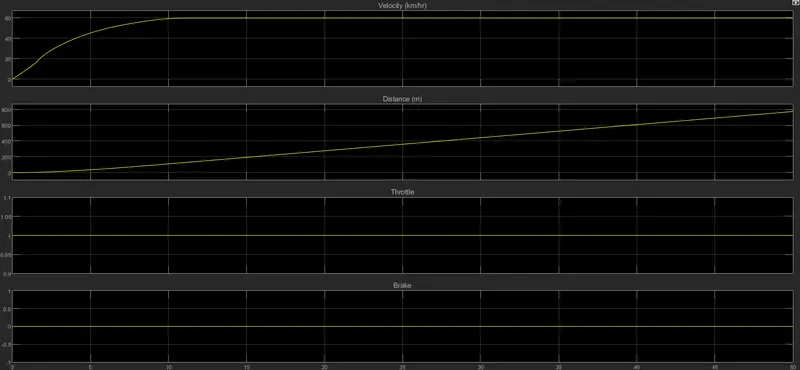
In following result it shows how vehicle speed varry with throttle as intially throttle is 30% press vehicle speed takes time to increase
Following results shows primary and secodary speeds of CVT
Intially primary speed was greater than secondary speed because as intially throttle is 30% press vehicle speed takes time to increase but as CVT ratio increases Secondary speed is greater than primary
Case 6:
cvtModel_Data In this model also signal builder is used to give input of CVT ratio wrt time
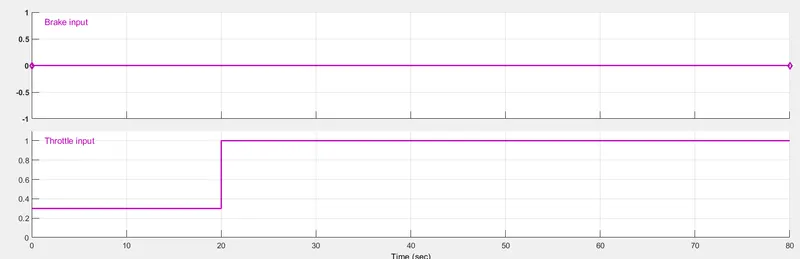
This model is similar with case 1 only difference in throttle input is not constant 100%, Intially in this model throttle is 30 %
Throttle Input:
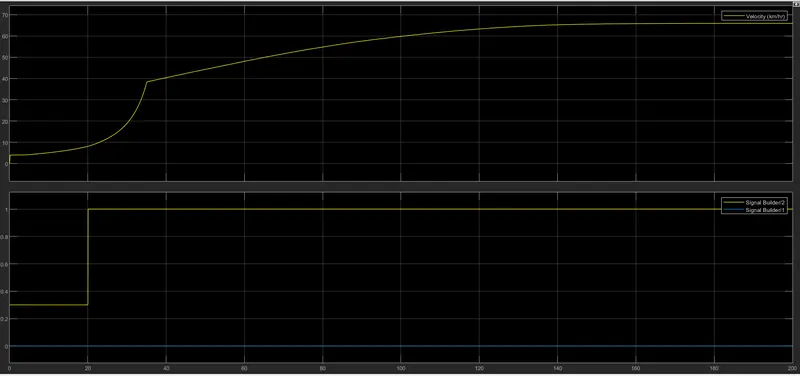
Results:
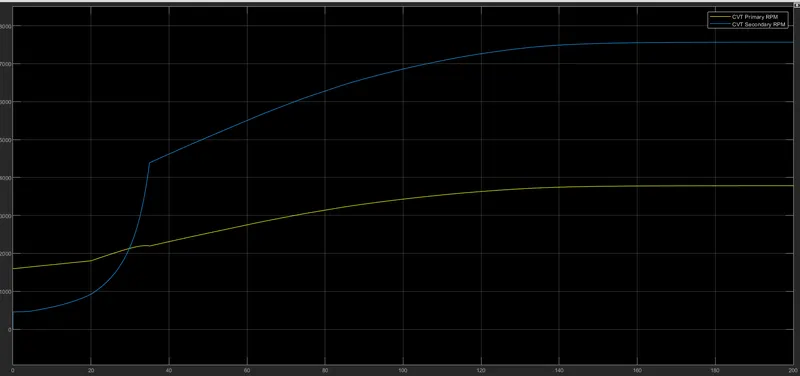
Following results shows varrying vehicle speed output depending on throttle input and CVT ratio
Following results shows varring Primary and Secondary RPM of CVT
Conclusion:
Different methods of CVT ratio input and throttle input is used to compare simulation result of different system model of BAJA All-terrain-Vehicle